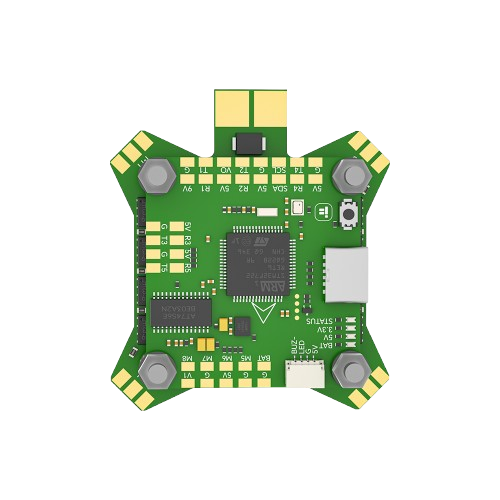
The iFlight Blitz F435 Flight Controller is a high-performance electronic device designed to manage the flight dynamics of drones and other unmanned aerial vehicles (UAVs). It processes data from various onboard sensors, such as gyroscopes, accelerometers, and barometers, to stabilize and control the vehicle's movements. This flight controller is particularly suited for FPV (First Person View) drones, offering advanced features for smooth and precise flight.
Explore Projects Built with Flight Controller
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
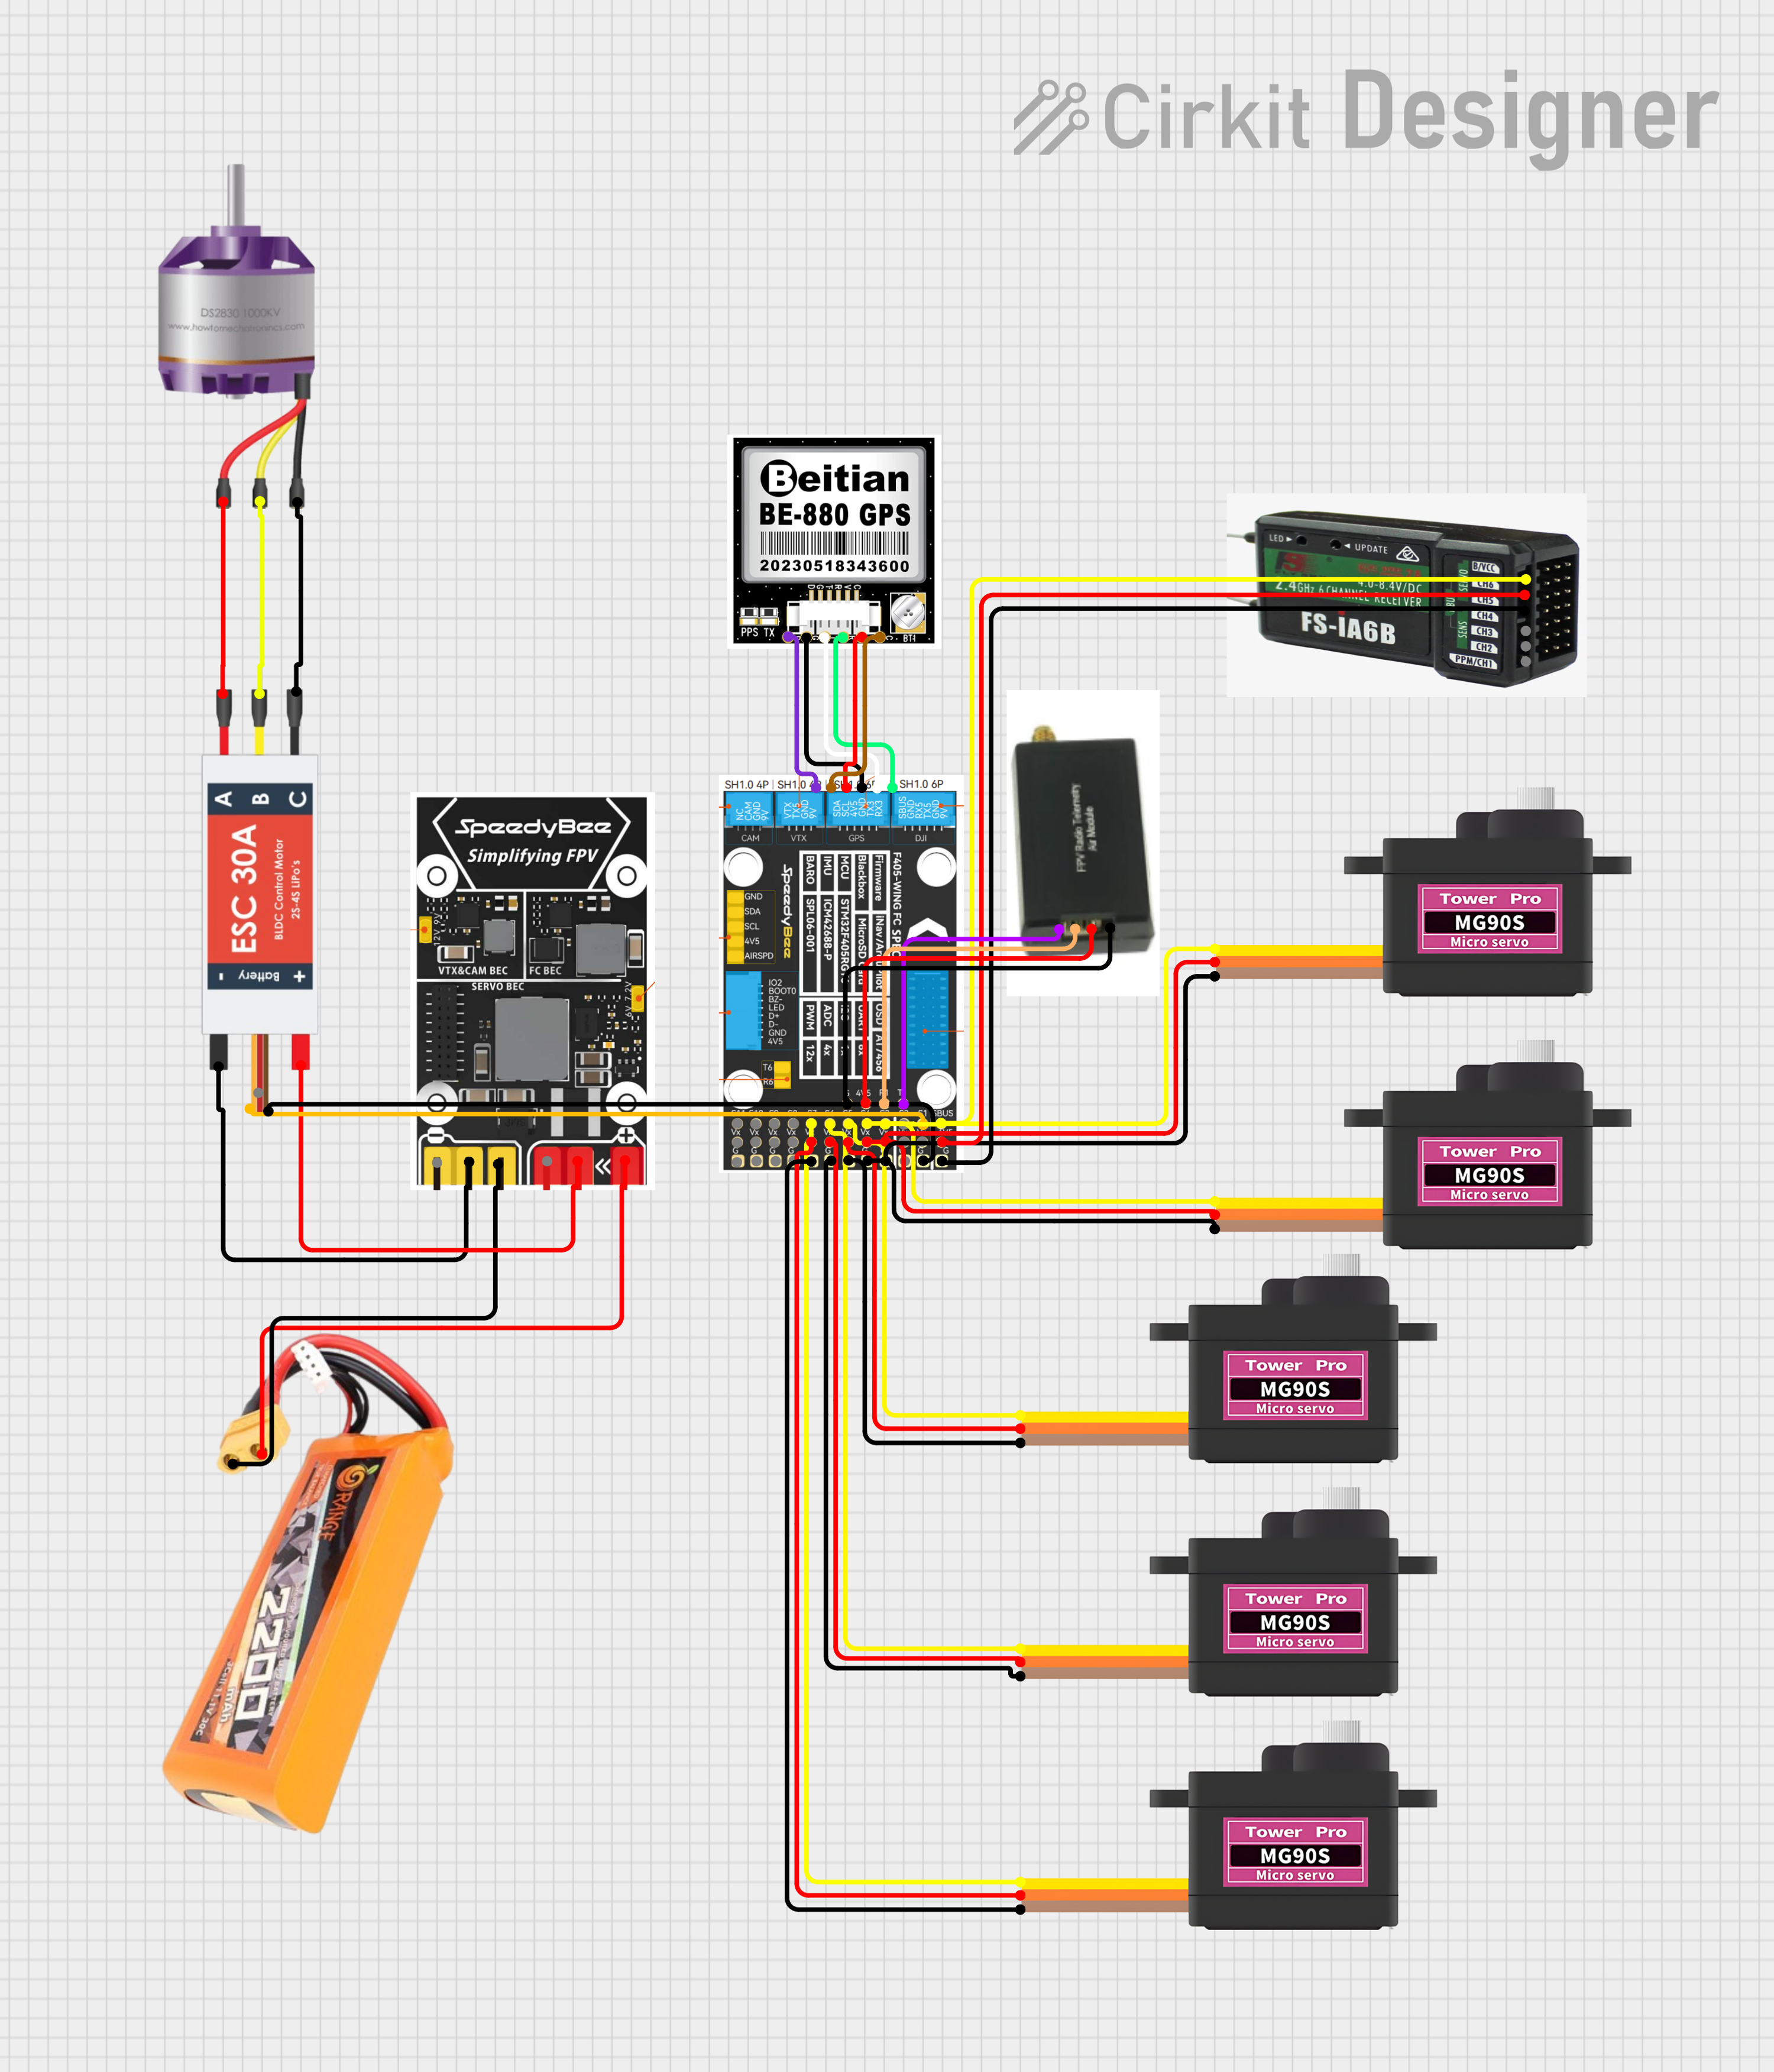
This circuit is designed for a remote-controlled vehicle or drone, featuring a flight controller that manages a brushless motor, servomotors for actuation, telemetry for data communication, and a GPS module for positioning. It is powered by a lipo battery and includes a receiver for remote control inputs.
This circuit is designed for a UAV control system, featuring an H743-SLIM V3 flight controller connected to multiple servos for control surfaces, a GPS module for navigation, a telemetry radio for communication, and a digital airspeed sensor for flight data. The system is powered by a LiPo battery and includes a Raspberry Pi for additional processing and control tasks.
This circuit is a quadcopter control system that includes a LiPo battery, four BLDC motors, four ESCs, a KK2.1.5 flight controller, and an FS-R6B receiver. The KK2.1.5 flight controller manages the ESCs and motors based on input signals from the receiver, which is powered by the LiPo battery.
This circuit is an automated landing gear system for a model aircraft, utilizing an ESP32 microcontroller to control two servos based on input from an ultrasonic sensor and a toggle switch. The system displays distance measurements and gear status on a 16x2 LCD screen via an I2C interface.
Educational projects involving flight dynamics and control systems
Technical Specifications
The iFlight Blitz F435 Flight Controller is equipped with cutting-edge hardware to ensure reliable and efficient performance. Below are the key technical details:
General Specifications
Processor: STM32F4 series microcontroller
IMU (Inertial Measurement Unit): MPU6000 (6-axis gyro and accelerometer)
Input Voltage: 2S–6S LiPo (7.4V–25.2V)
BEC Output: 5V @ 2.5A, 9V @ 2.5A
UART Ports: 5 UARTs for peripherals (e.g., GPS, telemetry, receiver)
Flash Memory: 16MB for Blackbox logging
Firmware: Betaflight-compatible
Dimensions: 36mm x 36mm (30.5mm x 30.5mm mounting holes)
Weight: 7.5g
Pin Configuration and Descriptions
The Blitz F435 Flight Controller features a well-labeled pinout for easy integration into your drone build. Below is the pin configuration:
Pin Name
Description
GND
Ground connection for power and signal reference
VBAT
Battery voltage input (2S–6S LiPo)
5V
5V power output for peripherals
9V
9V power output for peripherals
RX1, TX1
UART1 for receiver or telemetry modules
RX2, TX2
UART2 for GPS or other peripherals
RX3, TX3
UART3 for additional peripherals
RX4, TX4
UART4 for additional peripherals
RX5, TX5
UART5 for additional peripherals
SCL, SDA
I2C interface for external sensors
M1–M4
Motor outputs for ESCs (Electronic Speed Controllers)
LED
Addressable LED signal output
Buzzer
Buzzer signal output for audible alerts
RSSI
Analog RSSI input for signal strength monitoring
Current
Current sensor input for monitoring power consumption
Boot
Bootloader mode activation for firmware updates
Usage Instructions
How to Use the Blitz F435 in a Circuit
Power Connection: Connect the VBAT pin to your drone's battery (2S–6S LiPo). Ensure the polarity is correct to avoid damage.
Motor Connection: Connect the ESC signal wires to the M1–M4 pins. Match the motor order as specified in Betaflight.
Receiver Connection: Connect your receiver to one of the UART ports (e.g., RX1/TX1). Configure the protocol in Betaflight (e.g., SBUS, DSMX).
Peripheral Connection: Attach additional peripherals like GPS, telemetry modules, or LEDs to the appropriate UART or signal pins.
Firmware Setup: Flash the latest Betaflight firmware using the Betaflight Configurator. Configure the flight controller settings, including PID tuning, motor mapping, and receiver setup.
Calibration: Calibrate the accelerometer and other sensors in Betaflight Configurator to ensure accurate flight dynamics.
Important Considerations and Best Practices
Voltage Compatibility: Ensure your battery voltage is within the supported range (7.4V–25.2V).
Heat Management: Avoid overheating by ensuring proper airflow around the flight controller.
Firmware Updates: Regularly update the firmware to access new features and bug fixes.
Wiring: Double-check all connections to prevent short circuits or incorrect wiring.
Blackbox Logging: Use the onboard 16MB flash memory for flight data logging to analyze and improve performance.
Example Code for Arduino UNO Integration
While the Blitz F435 is not typically used with an Arduino UNO, you can use an Arduino to simulate sensor data or communicate with the flight controller via UART. Below is an example of sending data to the flight controller:
#include <SoftwareSerial.h>

// Define RX and TX pins for UART communication
SoftwareSerial mySerial(10, 11); // RX = pin 10, TX = pin 11

void setup() {
  // Initialize serial communication
  Serial.begin(9600); // Monitor communication
  mySerial.begin(115200); // UART communication with flight controller

  Serial.println("Arduino to Flight Controller Communication Initialized");
}

void loop() {
  // Example: Send a test message to the flight controller
  mySerial.println("Hello, Flight Controller!");

  // Check for incoming data from the flight controller
  if (mySerial.available()) {
    String data = mySerial.readString();
    Serial.println("Received from FC: " + data);
  }

  delay(1000); // Wait 1 second before sending the next message
}
Troubleshooting and FAQs
Common Issues and Solutions
Flight Controller Not Powering On
Cause: Incorrect wiring or insufficient power supply.
Solution: Verify the VBAT connection and ensure the battery voltage is within the supported range.
Motors Not Spinning
Cause: Incorrect motor mapping or ESC configuration.
Solution: Check motor order and ESC protocol settings in Betaflight Configurator.
No Receiver Signal
Cause: Improper receiver connection or protocol mismatch.
Solution: Ensure the receiver is connected to the correct UART port and the protocol is configured correctly in Betaflight.
Unstable Flight
Cause: Incorrect PID tuning or sensor calibration.
Solution: Recalibrate the sensors and adjust PID settings in Betaflight Configurator.
Firmware Update Fails
Cause: Incorrect bootloader mode or USB connection issue.
Solution: Hold the Boot button while connecting the flight controller to your computer and retry the firmware update.
FAQs
Q: Can I use the Blitz F435 with iNav firmware?
A: Yes, the Blitz F435 is compatible with iNav firmware for advanced navigation features.
Q: What is the maximum supported LiPo cell count?
A: The Blitz F435 supports up to 6S LiPo batteries (25.2V).
Q: How do I connect an external barometer?
A: Use the I2C pins (SCL and SDA) to connect the external barometer and configure it in Betaflight.
Q: Can I use this flight controller for fixed-wing aircraft?
A: Yes, the Blitz F435 can be configured for fixed-wing aircraft in Betaflight or iNav.
This documentation provides a comprehensive guide to using the iFlight Blitz F435 Flight Controller effectively. For further assistance, refer to the manufacturer's resources or community forums.

 Open Project in Cirkit Designer