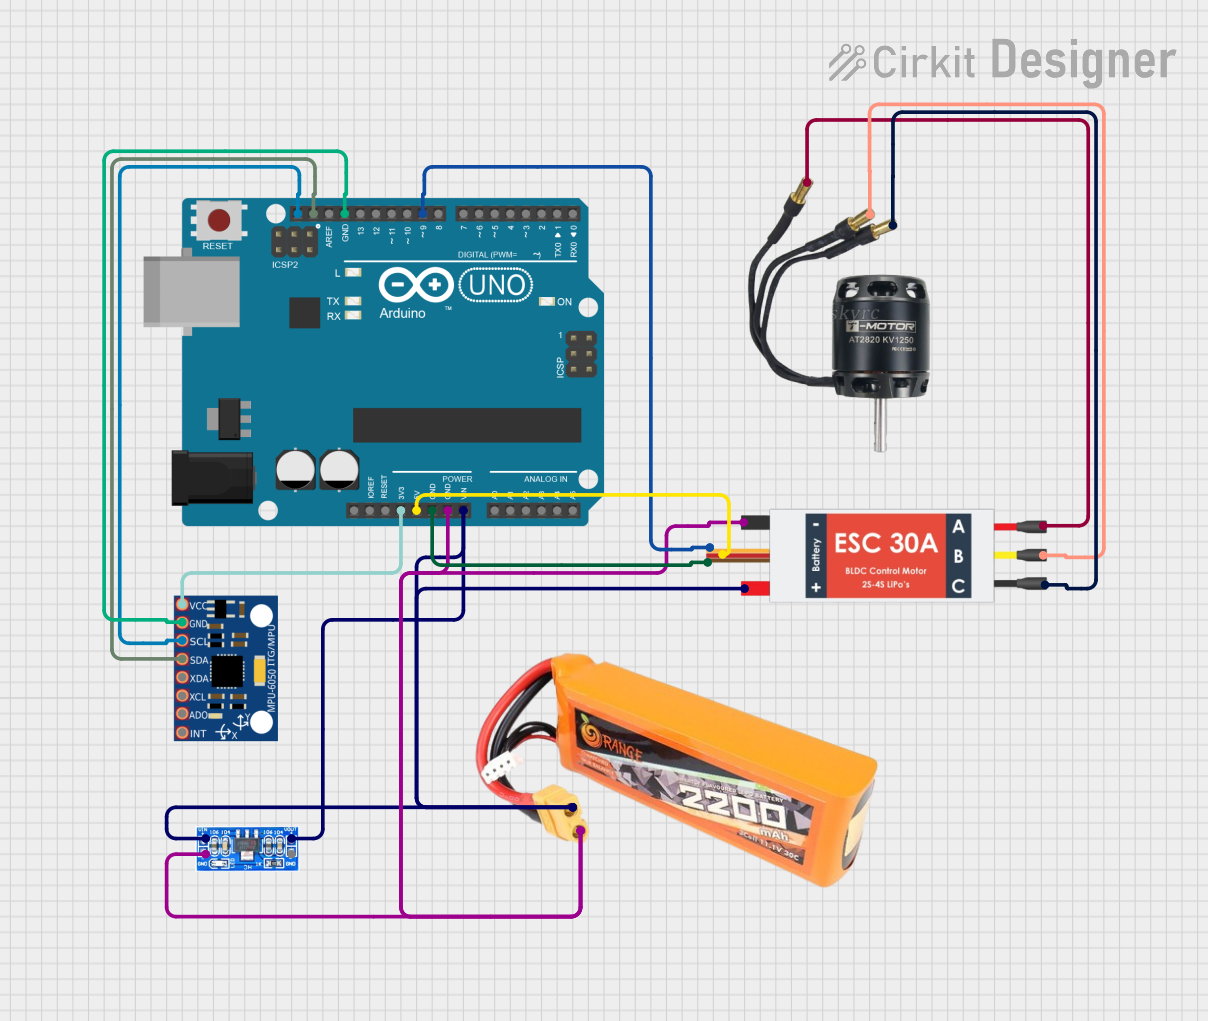
Arduino UNO Controlled BLDC Motor Stabilization System with MPU-6050 IMU Open Project in Cirkit Designer
This circuit is designed to control a brushless DC (BLDC) motor using an Arduino UNO microcontroller and an Electronic Speed Controller (ESC). The Arduino reads orientation data from an MPU-6050 inertial measurement unit (IMU) and adjusts the motor's speed to stabilize a system, likely a reaction flywheel stabilization system. Power is supplied by a lipo battery, with voltage regulation provided by an AMS1117 voltage regulator.
Open Project in Cirkit Designer