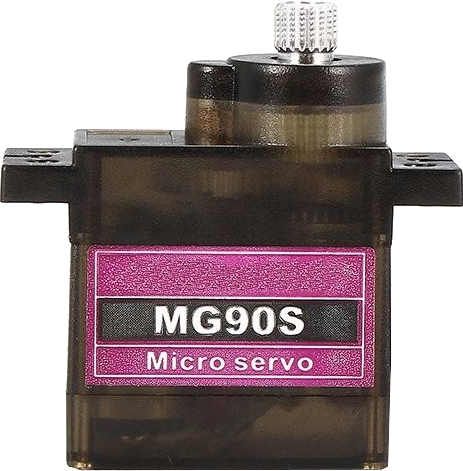
The MG90S is a small, lightweight servo motor commonly used in robotics and hobby projects. It features a metal gear for improved durability and provides precise control of angular position, making it ideal for applications requiring movement and positioning. This servo motor is widely appreciated for its reliability, compact size, and ease of use, making it a popular choice for beginners and professionals alike.
Explore Projects Built with Servo MG90S
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
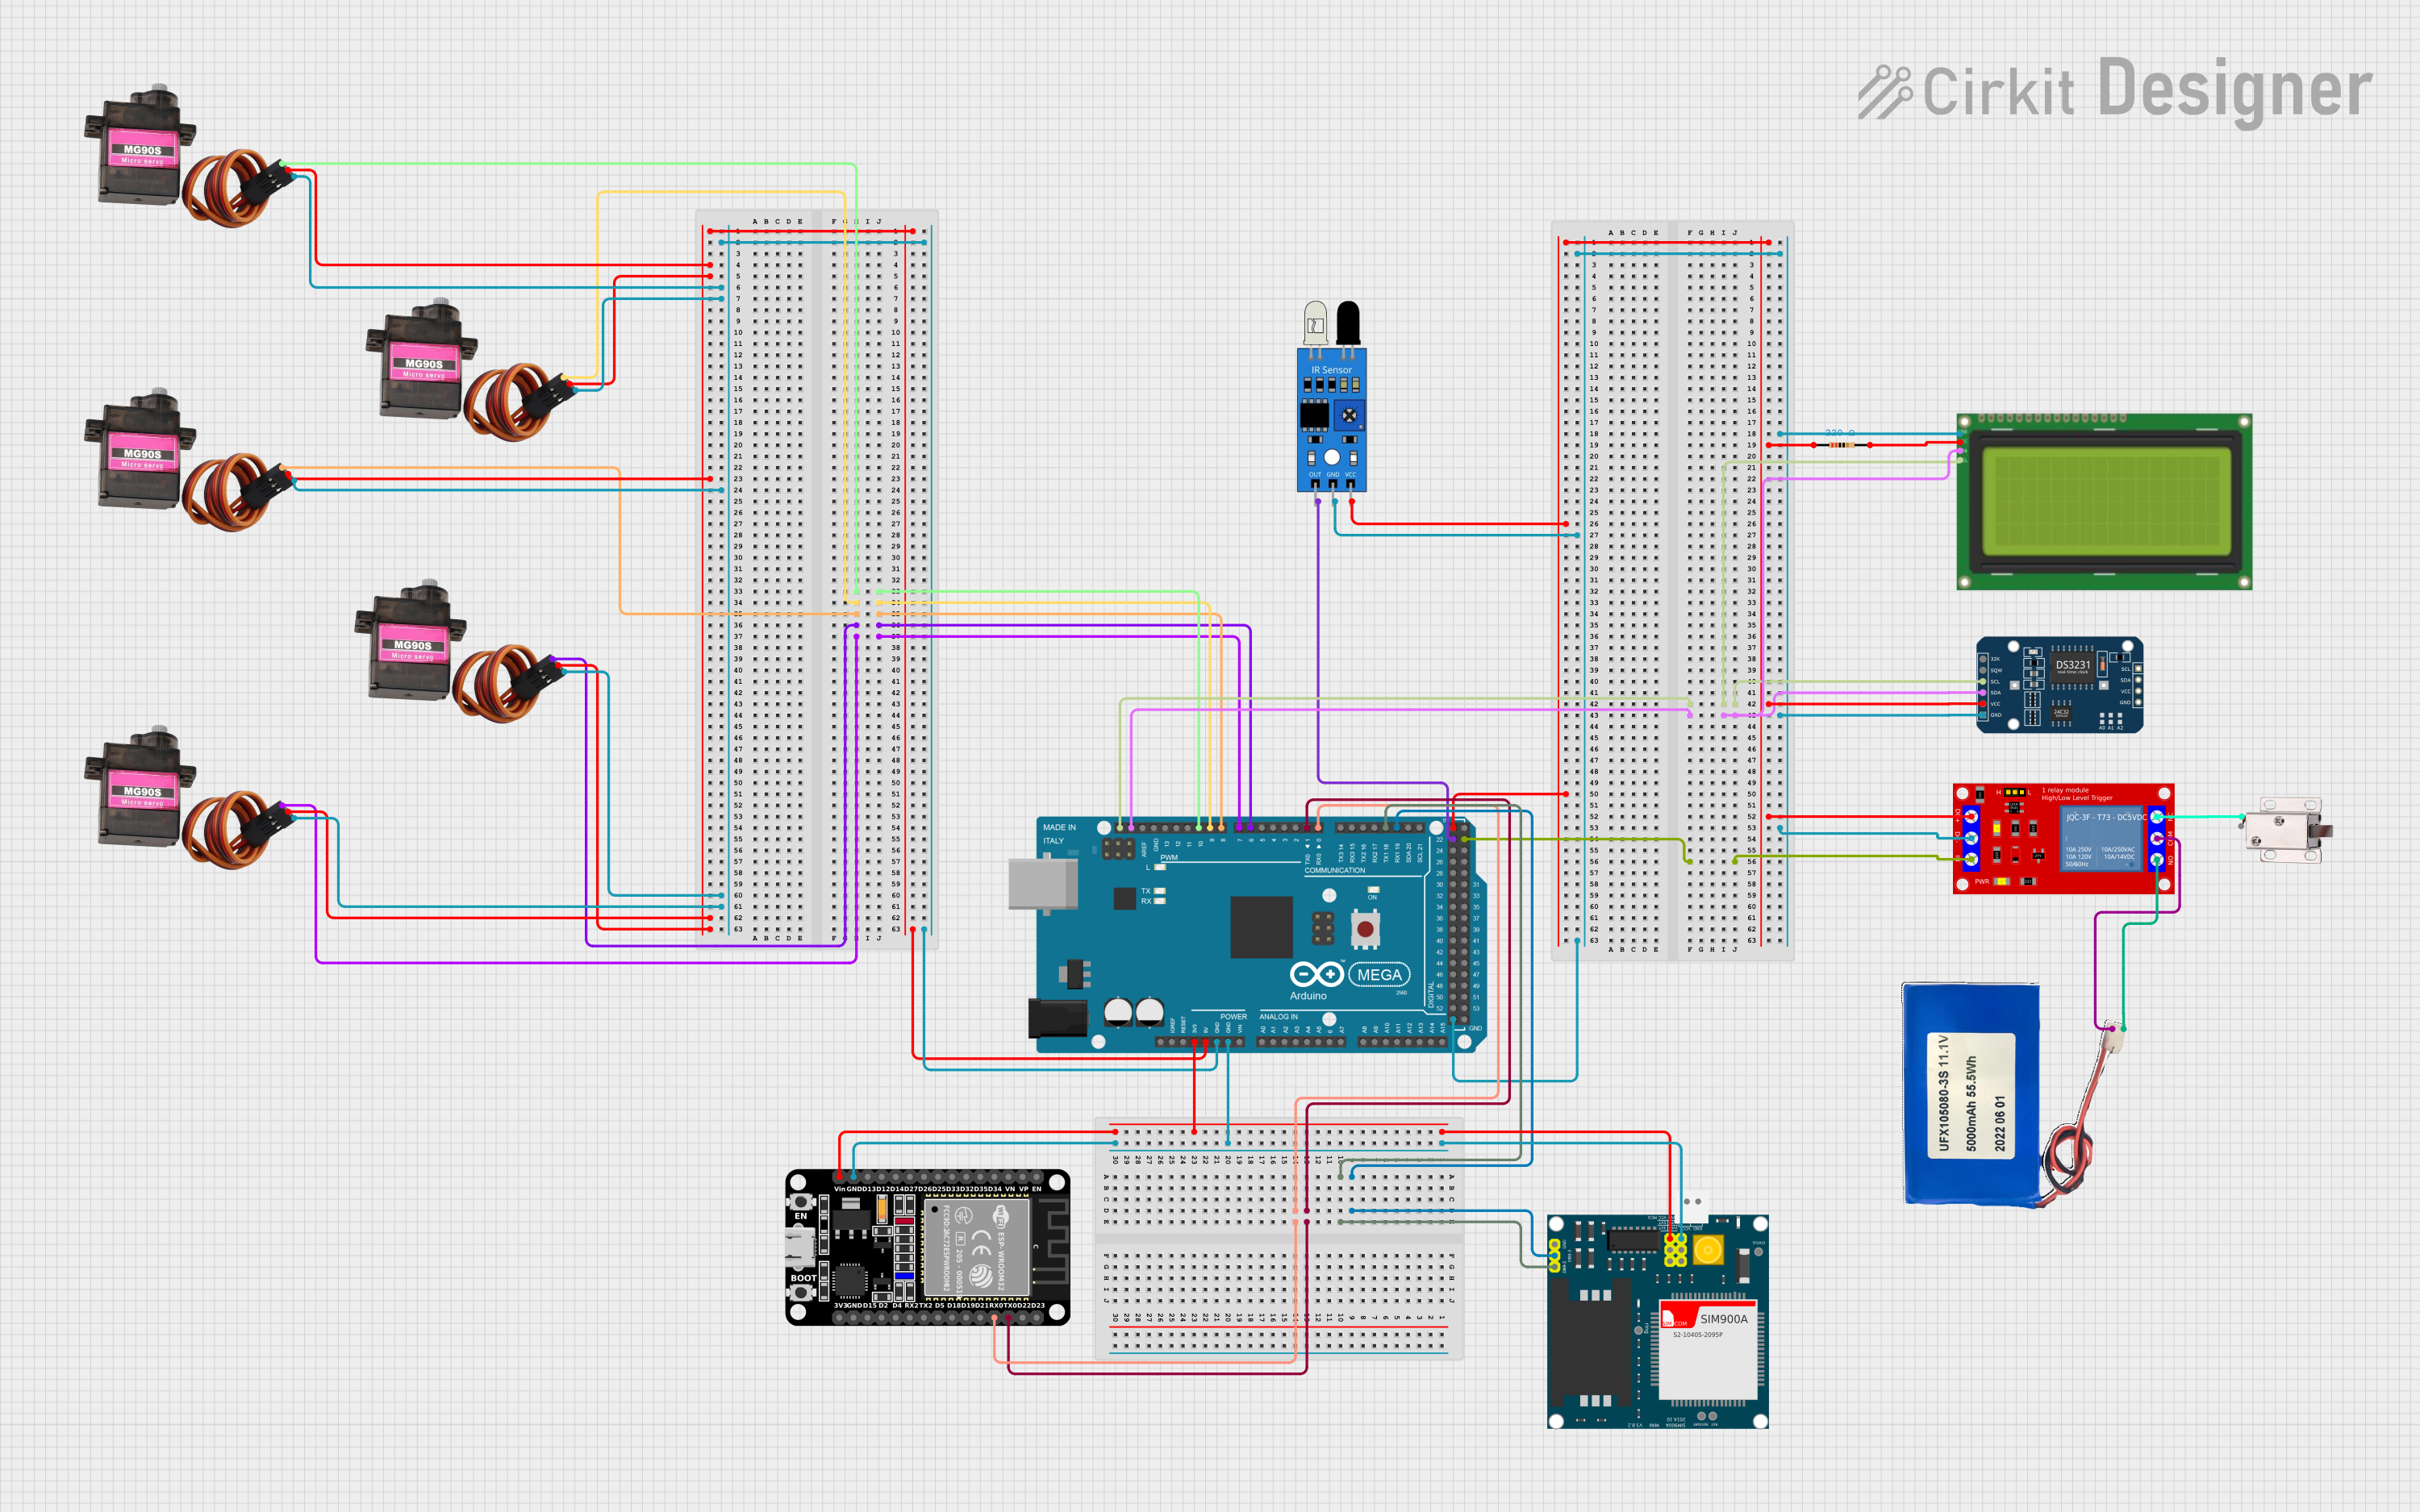
This circuit is a control system utilizing an Arduino Mega 2560 to manage multiple MG90S servos, an LCD display, a DS3231 RTC module, a SIM900A GSM module, and an ESP32 for communication. It also includes a relay module to control a 12V solenoid lock, an IR sensor for input, and a Li-ion battery for power supply.
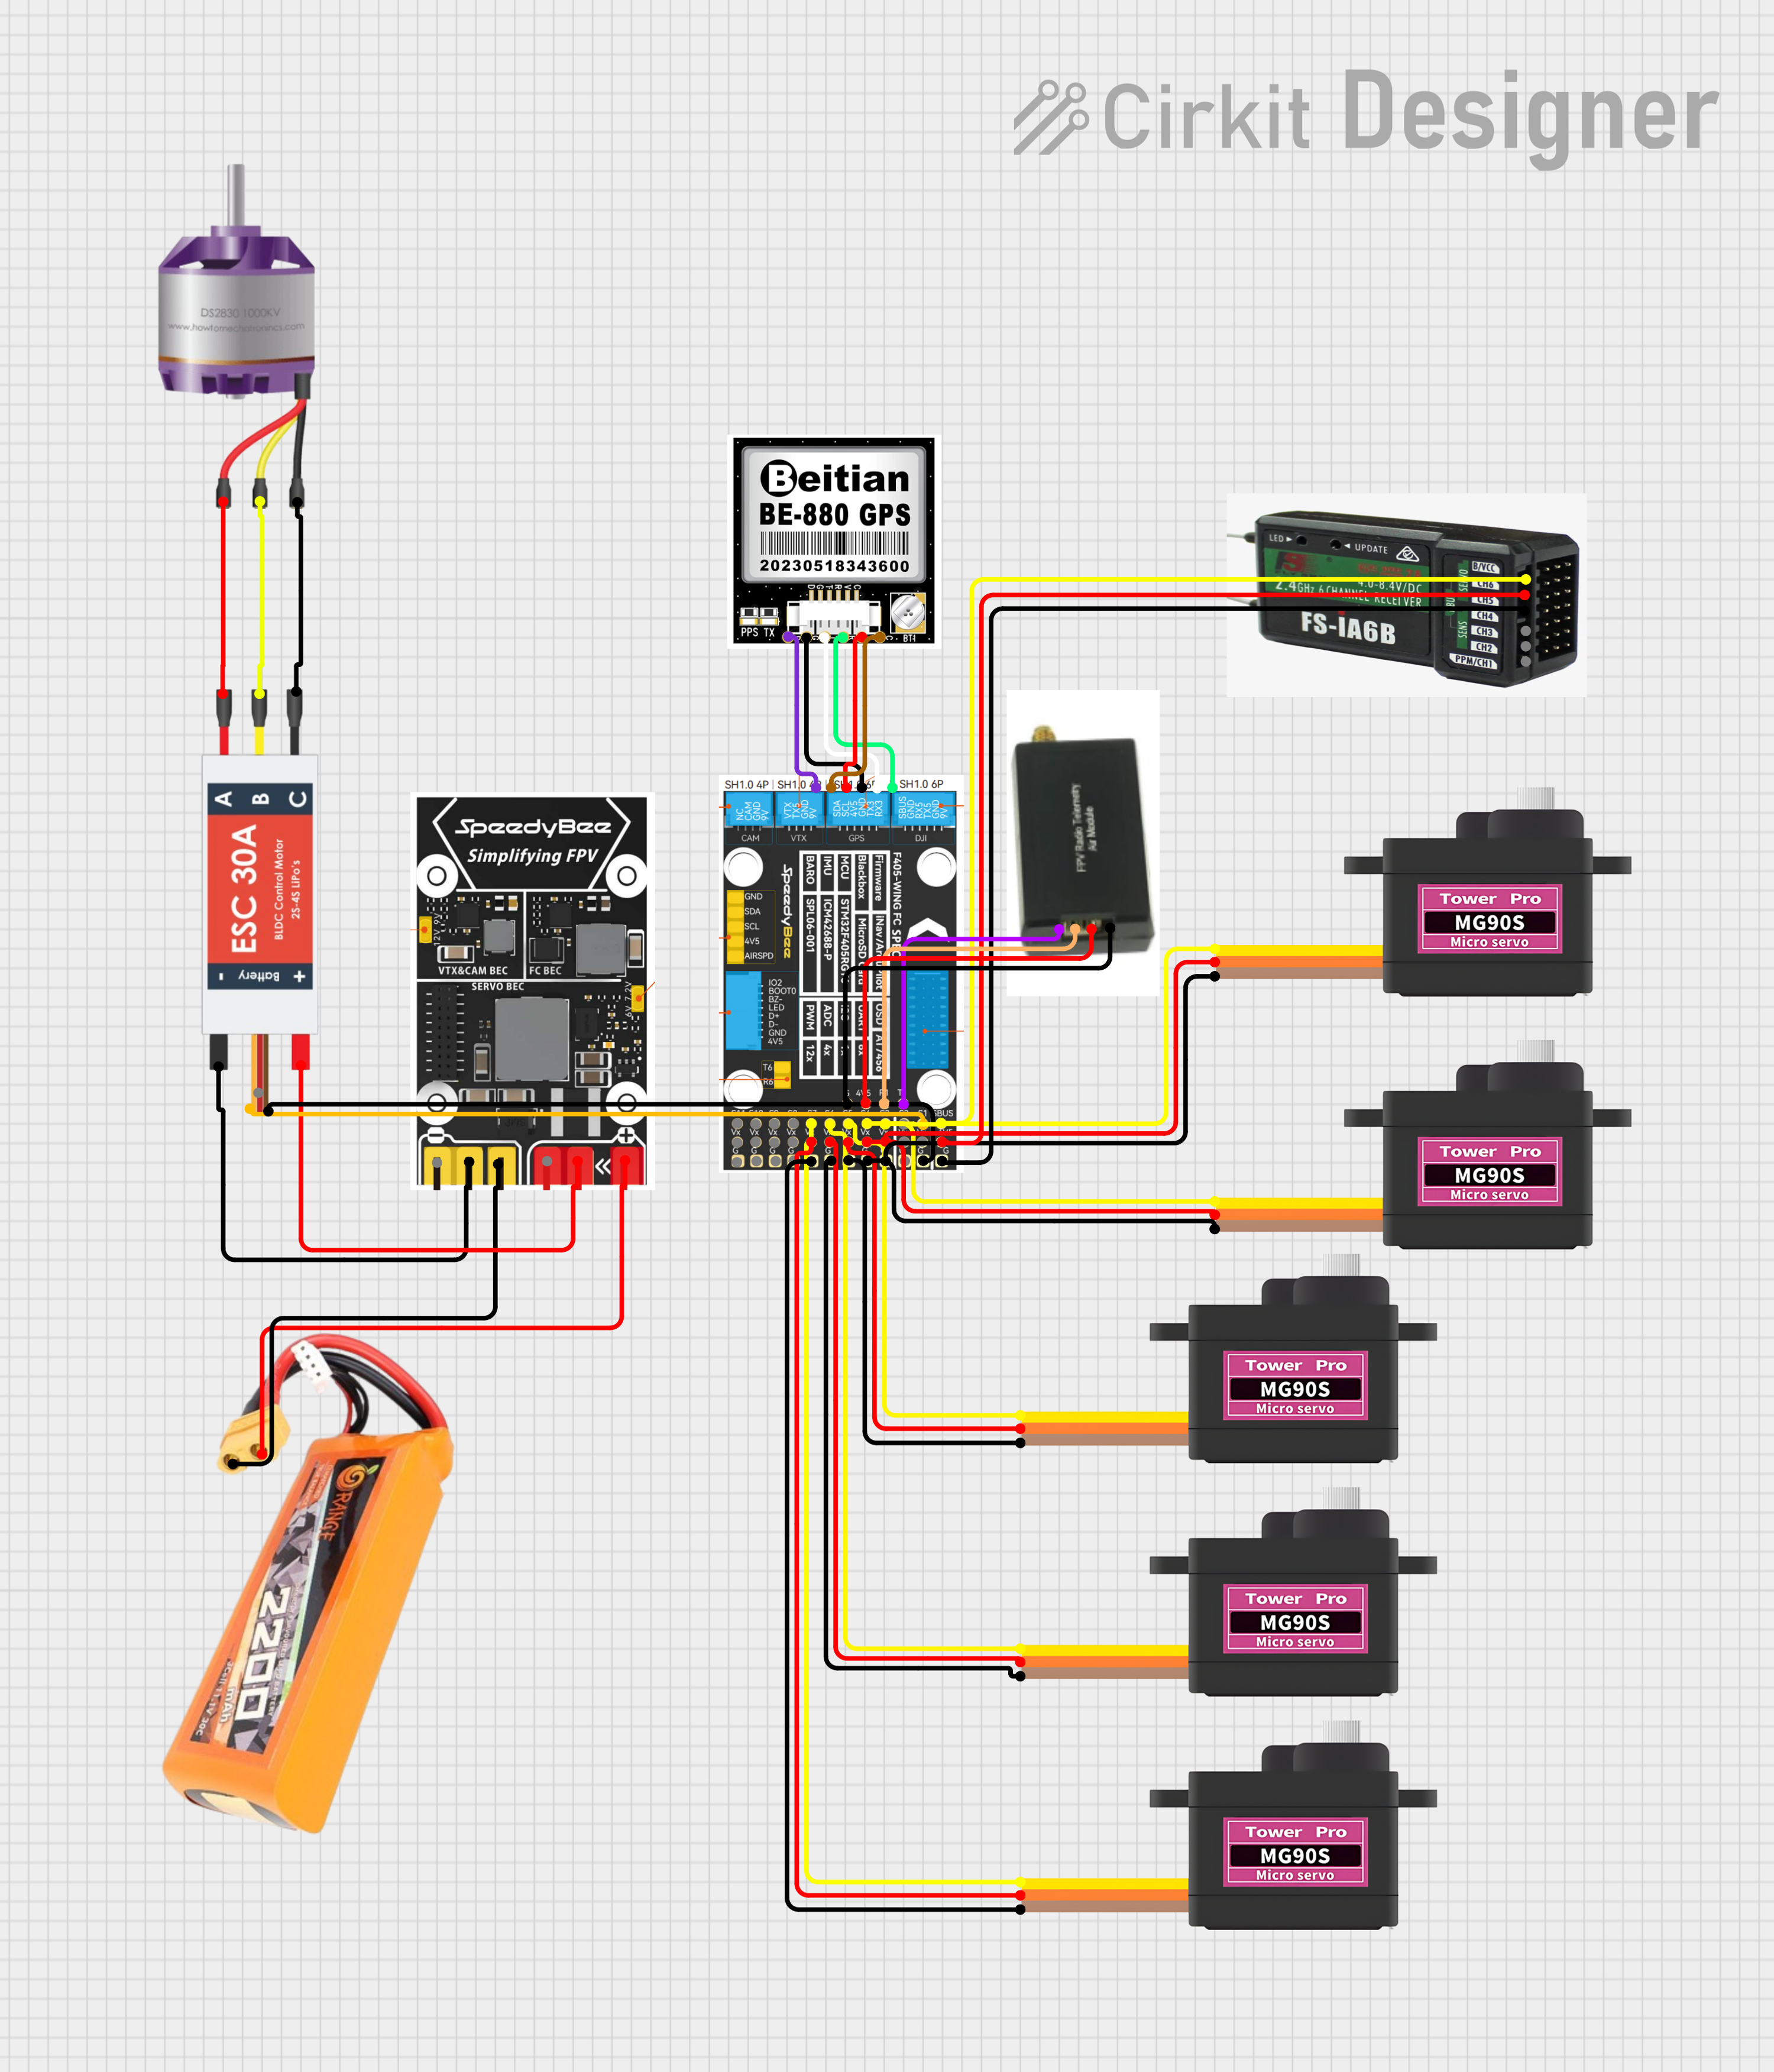
This circuit is designed for a remote-controlled vehicle or drone, featuring a flight controller that manages a brushless motor, servomotors for actuation, telemetry for data communication, and a GPS module for positioning. It is powered by a lipo battery and includes a receiver for remote control inputs.
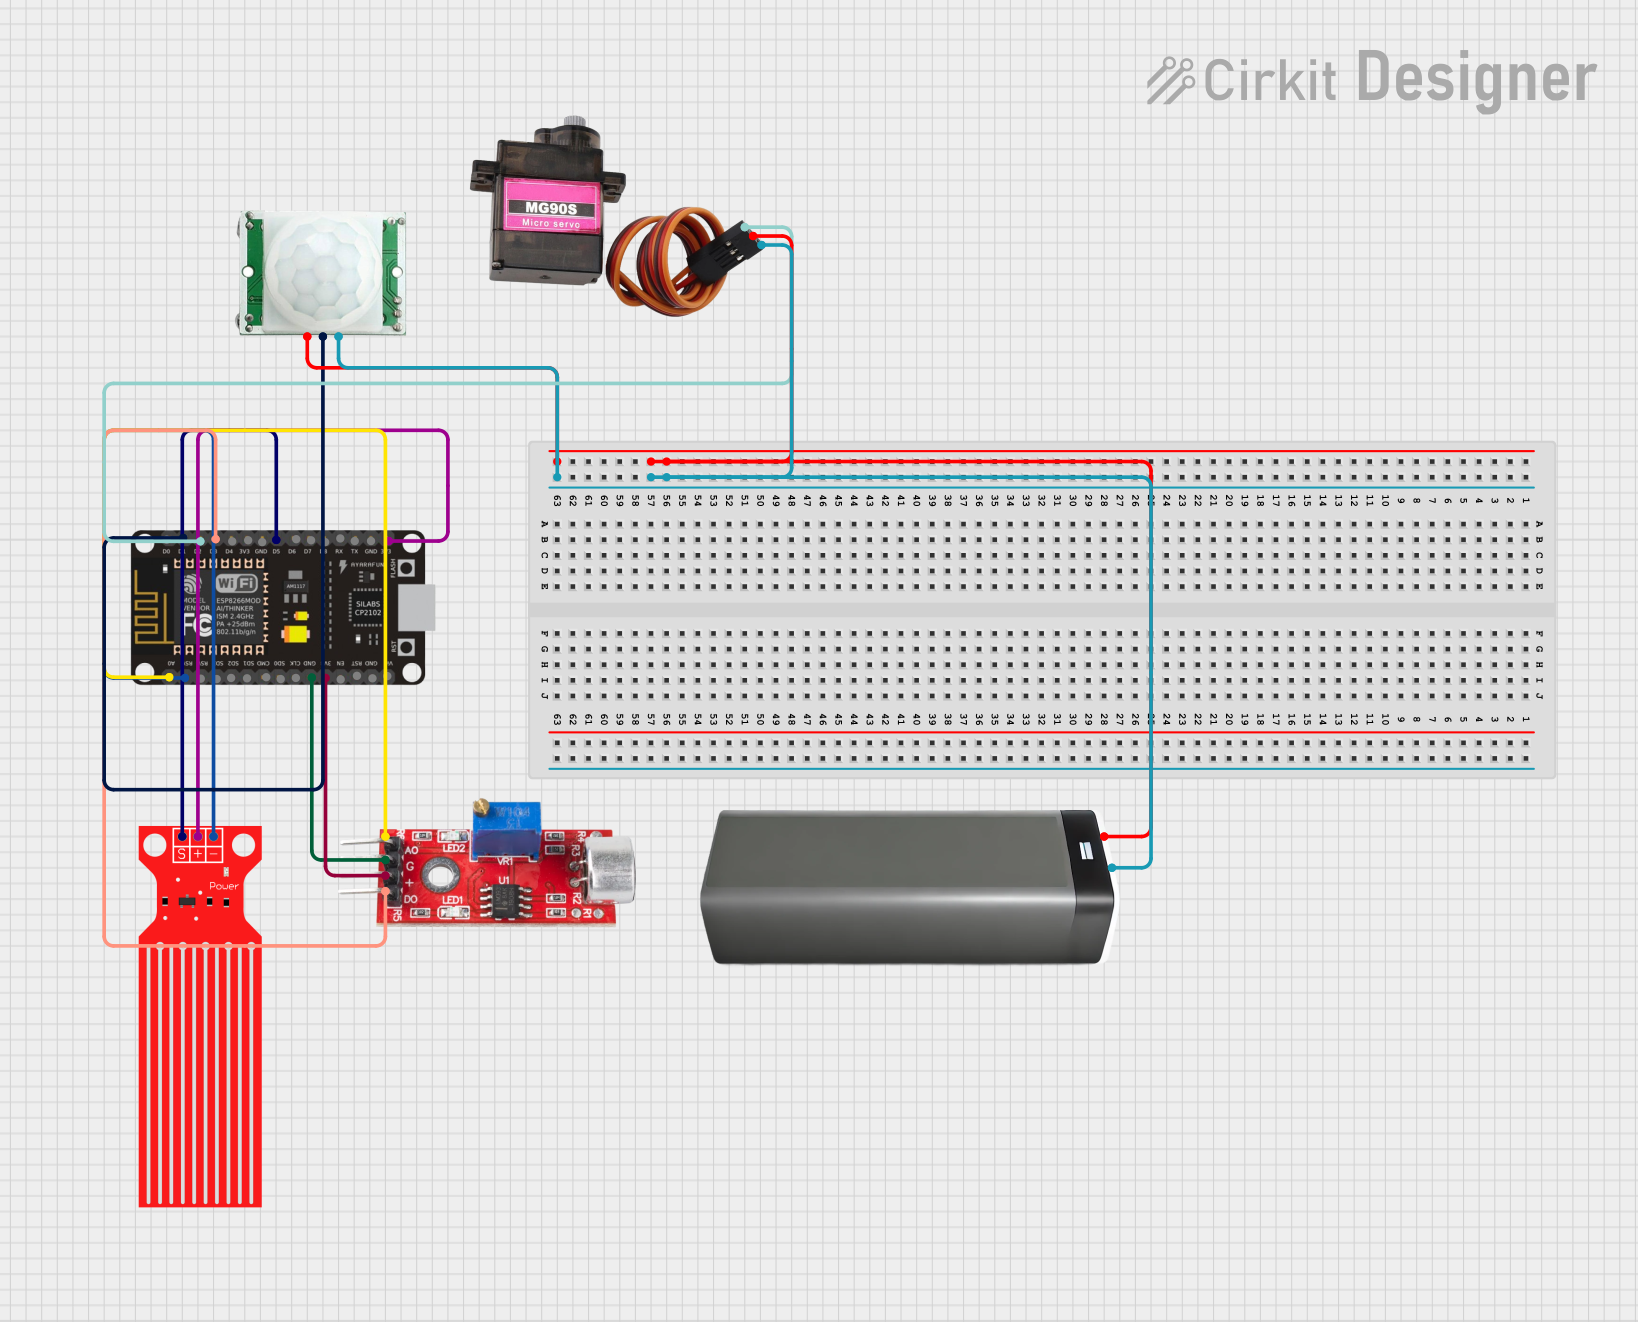
This circuit is designed around an ESP8266 NodeMCU microcontroller, which interfaces with a variety of sensors and a servo motor. It includes a PIR motion sensor to detect movement, a sound sensor for audio detection, and a water level sensor for monitoring liquid levels. The MG90S servo motor is controlled by the microcontroller, and the entire system is powered by a battery pack.
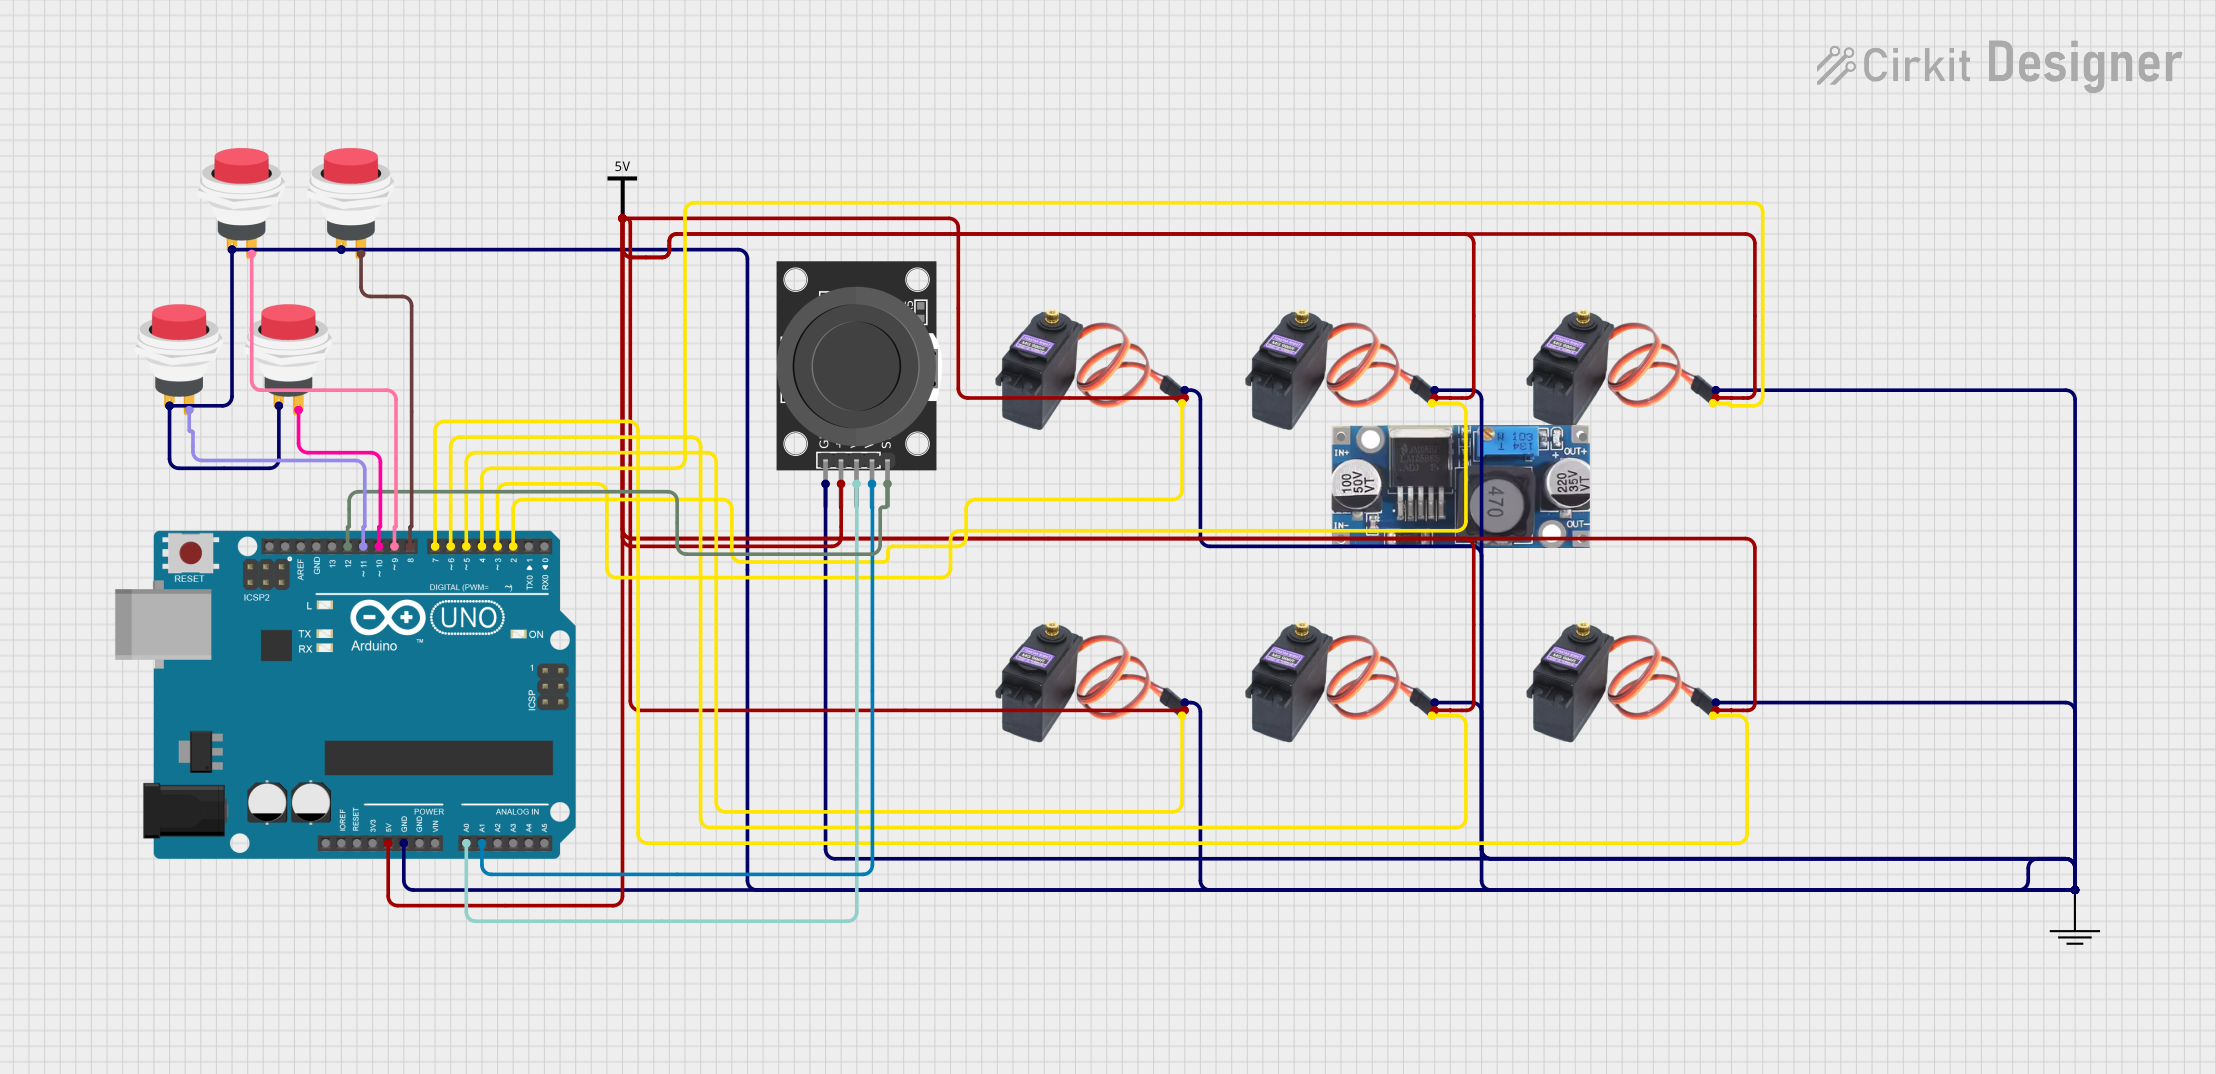
This is a servo control system featuring an Arduino UNO that processes input from a dual-axis joystick and push switches to operate multiple MG996R servo motors. It is designed for precise multi-axis control, potentially for applications like robotics or remote-controlled mechanisms.
The MG90S servo motor is designed to deliver high performance in a compact form factor. Below are its key technical details:
Parameter
Specification
Operating Voltage
4.8V to 6.0V
Stall Torque
1.8 kg·cm (4.8V), 2.2 kg·cm (6.0V)
Operating Speed
0.1 sec/60° (4.8V), 0.08 sec/60° (6.0V)
Gear Type
Metal
Weight
13.4 g
Dimensions
22.8 × 12.2 × 28.5 mm
Control Signal
PWM (Pulse Width Modulation)
PWM Pulse Range
500 µs to 2500 µs
Rotation Angle
0° to 180°
Connector Type
3-pin female header (Dupont style)
Pin Configuration
The MG90S servo motor has a 3-wire connector with the following pinout:
Wire Color
Function
Description
Brown
Ground (GND)
Connect to the ground of the power supply
Red
Power (VCC)
Connect to a 4.8V–6.0V power source
Orange
Signal (PWM)
Connect to the PWM signal from a microcontroller
Usage Instructions
The MG90S servo motor is straightforward to use and can be controlled using a microcontroller like an Arduino. Below are the steps to use it in a circuit:
Circuit Connection
Power Supply: Connect the red wire to a 5V power source and the brown wire to ground (GND). Ensure the power supply can provide sufficient current (at least 1A) to avoid voltage drops.
Signal Connection: Connect the orange wire to a PWM-capable pin on your microcontroller (e.g., pin 9 on an Arduino UNO).
Bypass Capacitor: Place a 100 µF capacitor across the power supply terminals to stabilize the voltage and reduce noise.
Arduino Example Code
Below is an example of how to control the MG90S servo motor using an Arduino UNO:
#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object to control the MG90S

void setup() {
  myServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000); // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000); // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000); // Wait for 1 second
}
Important Considerations
Power Supply: Avoid powering the servo directly from the Arduino's 5V pin, as it may not provide enough current. Use an external power source if possible.
PWM Signal: Ensure the PWM signal is within the specified range (500 µs to 2500 µs) to avoid damaging the servo.
Mechanical Load: Do not exceed the servo's torque rating to prevent overheating or damage to the motor.
Troubleshooting and FAQs
Common Issues
Servo Not Moving
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check the wiring and ensure the power supply provides at least 1A of current.
Servo Jittering
Cause: Electrical noise or unstable power supply.
Solution: Add a bypass capacitor (e.g., 100 µF) across the power supply terminals.
Servo Overheating
Cause: Excessive mechanical load or prolonged operation at high torque.
Solution: Reduce the load or allow the servo to cool down periodically.
Limited Rotation
Cause: The MG90S is a positional servo with a range of 0° to 180°.
Solution: Ensure your PWM signal is within the specified range (500 µs to 2500 µs).
FAQs
Q: Can the MG90S rotate continuously?
A: No, the MG90S is a positional servo with a limited rotation range of 0° to 180°. For continuous rotation, consider using a continuous rotation servo.
Q: Can I control multiple MG90S servos with one Arduino?
A: Yes, you can control multiple servos using different PWM-capable pins. However, ensure your power supply can handle the combined current draw of all servos.
Q: What happens if I exceed the torque rating?
A: Exceeding the torque rating can cause the servo to stall, overheat, or become damaged. Always operate within the specified limits.
Q: Can I use the MG90S with a Raspberry Pi?
A: Yes, the MG90S can be controlled using the Raspberry Pi's GPIO pins with a PWM signal. However, you may need a dedicated PWM driver for precise control.

 Open Project in Cirkit Designer