A right servo is a type of motor designed for precise control of angular position. Unlike standard DC motors, servos are equipped with a feedback mechanism that allows them to rotate to a specific angle as commanded. This makes them ideal for applications requiring accurate positioning and controlled motion. Right servos are commonly used in robotics, automation systems, RC vehicles, and mechanical arms.
Explore Projects Built with Right Servo
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
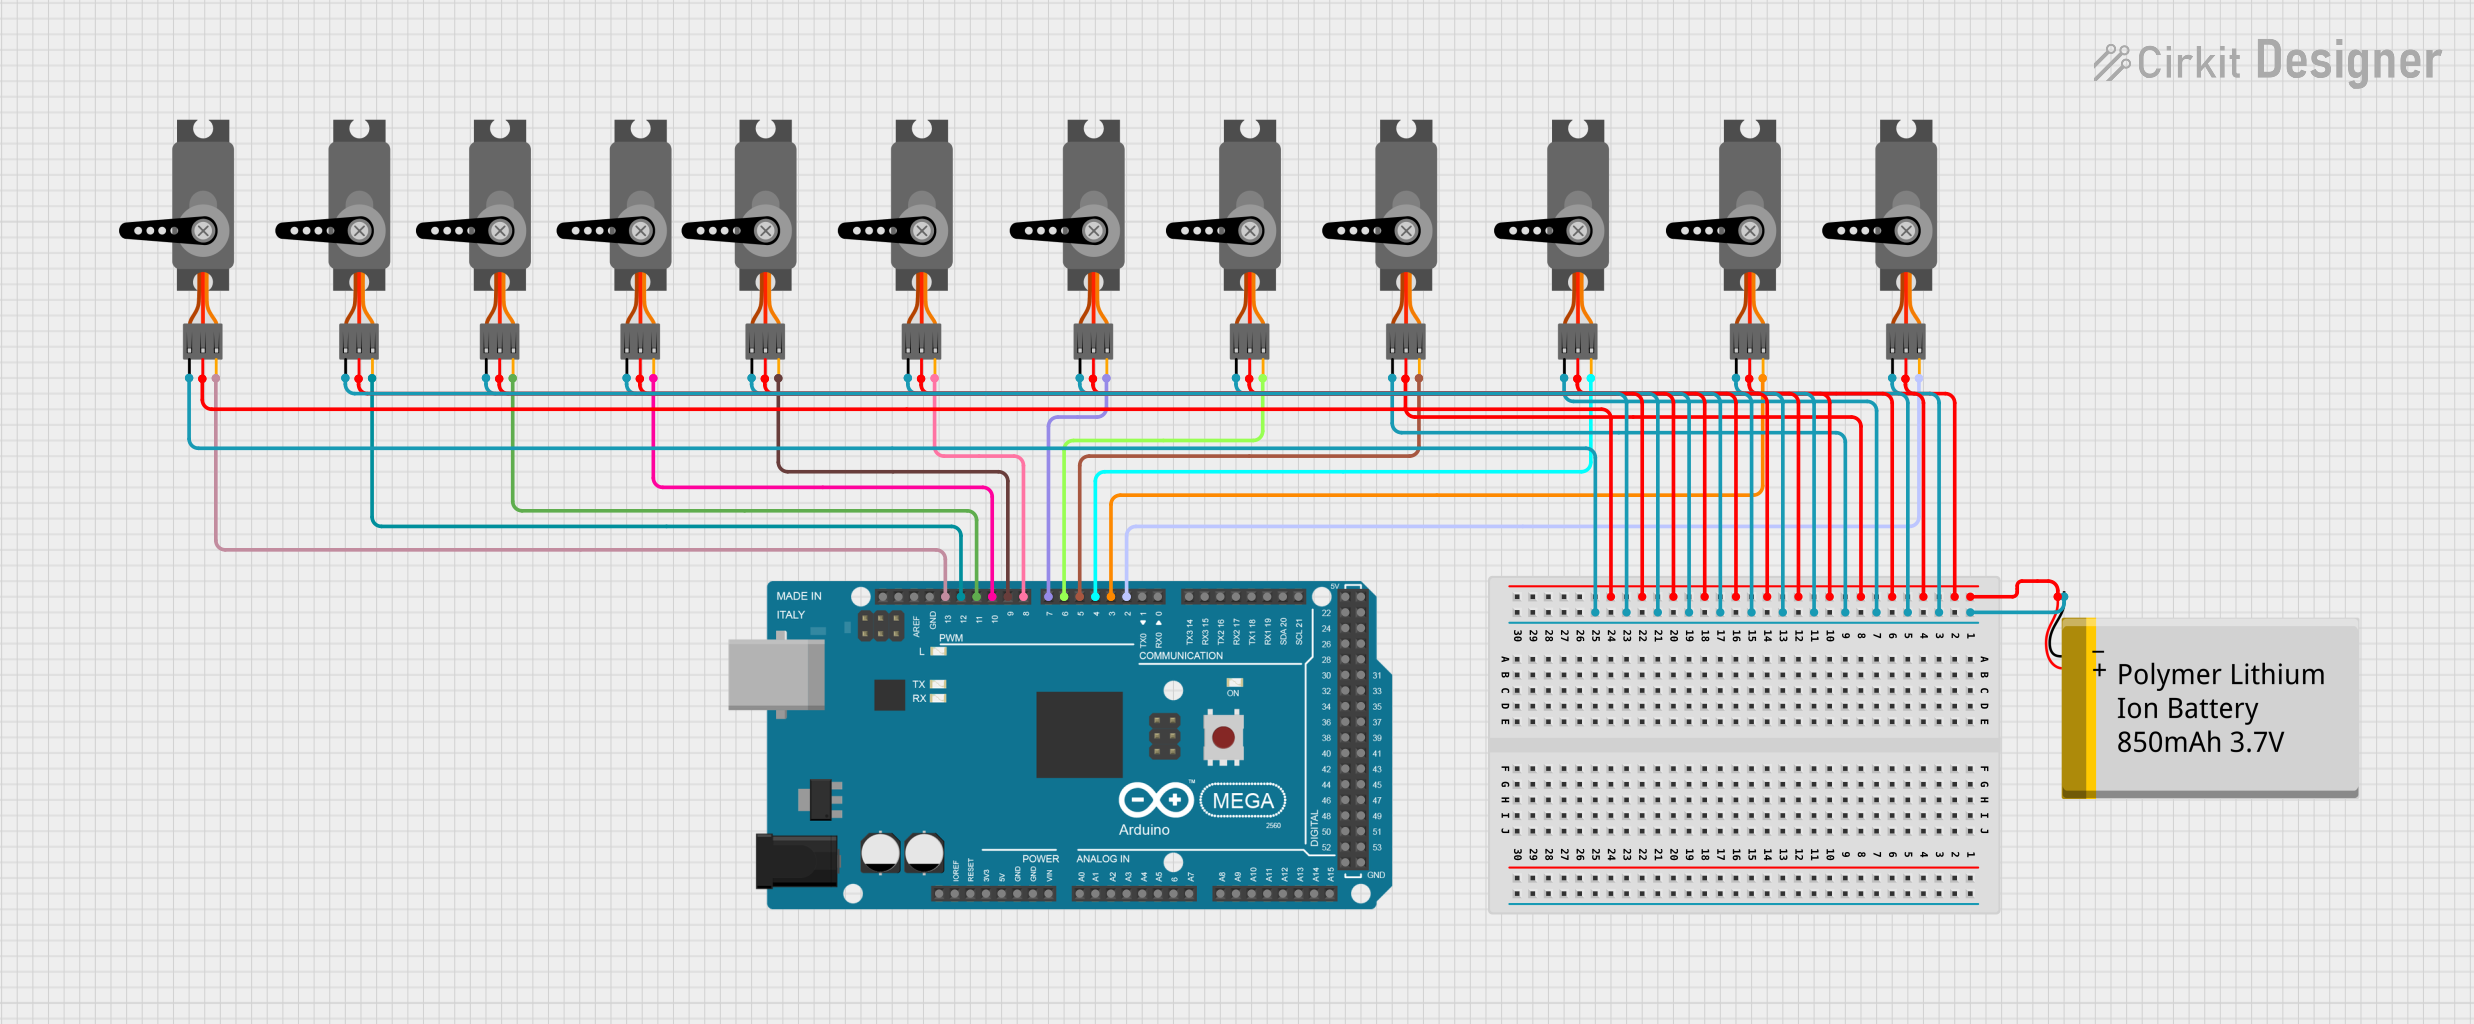
This circuit consists of an Arduino Mega 2560 microcontroller connected to twelve servo motors, each individually controlled by a distinct PWM pin on the Arduino. The servos are powered by a single Polymer Lithium Ion Battery, with all servos sharing a common power (VCC) and ground (GND) connection. The embedded code on the Arduino is designed to randomly position each servo within a 0 to 180-degree range, with a random delay between movements, demonstrating a multi-servo control system possibly for applications like robotics or animatronics.
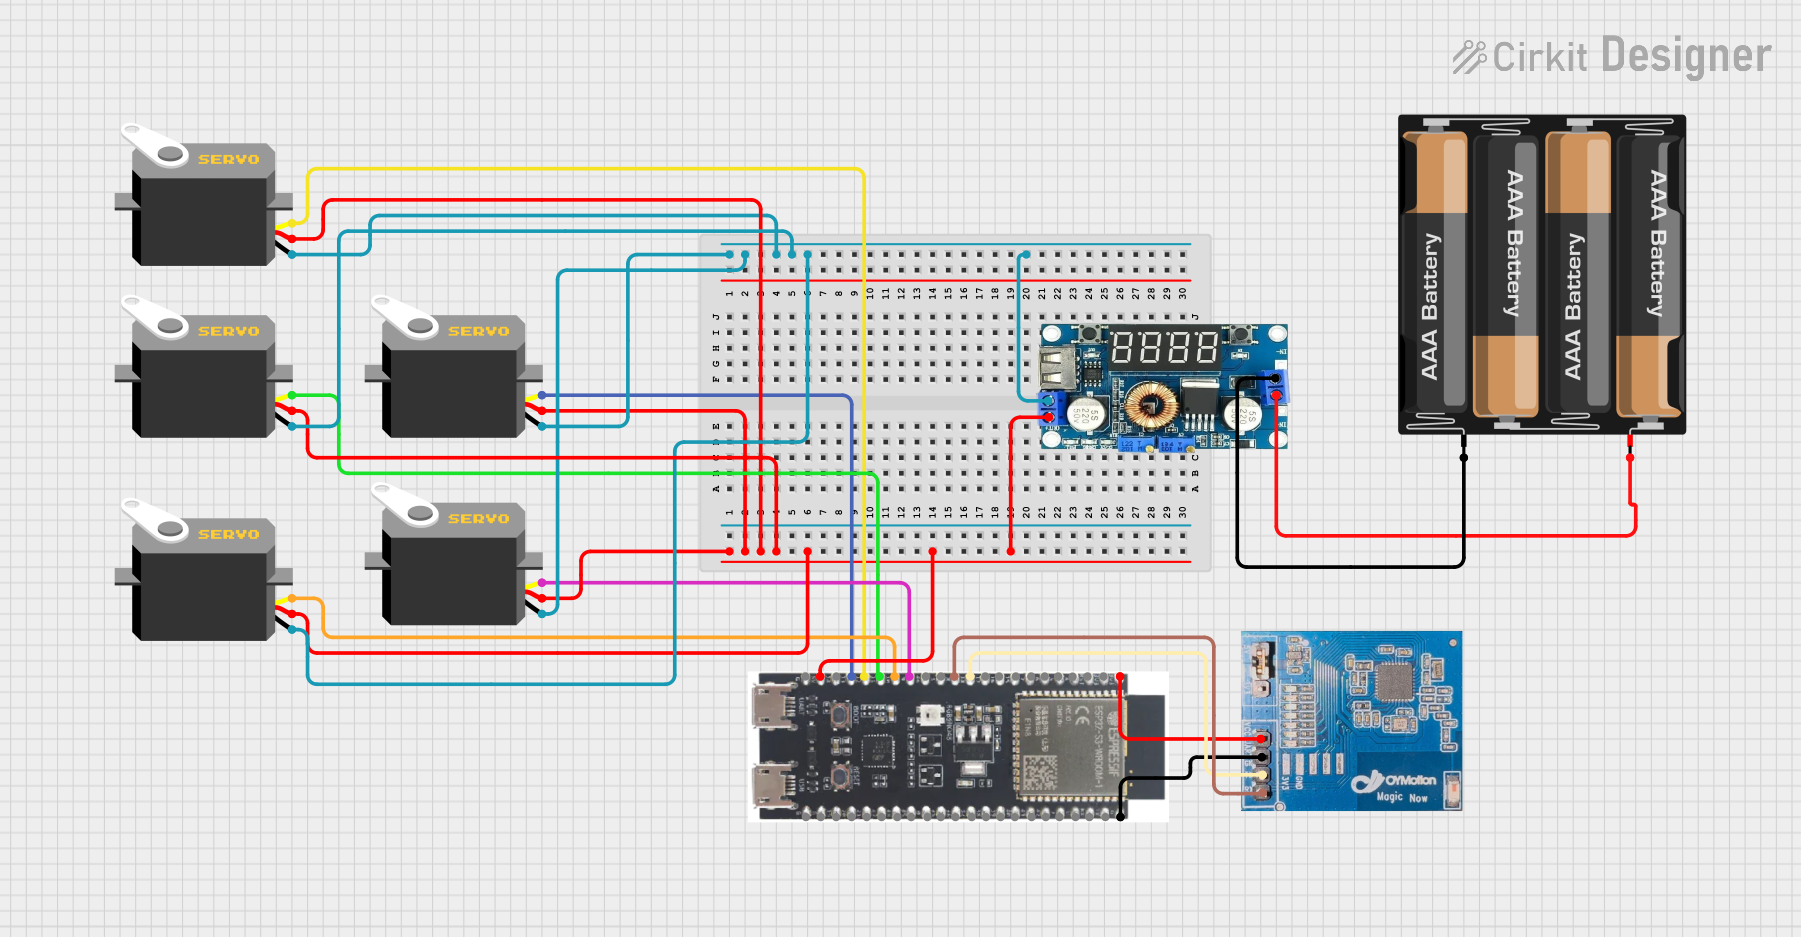
This circuit is a servo control system powered by a 4 x AAA battery pack, regulated by a step-down DC regulator. An ESP32-S3 microcontroller controls five servos and communicates with a gForceJoint UART sensor, enabling precise servo movements based on sensor inputs.
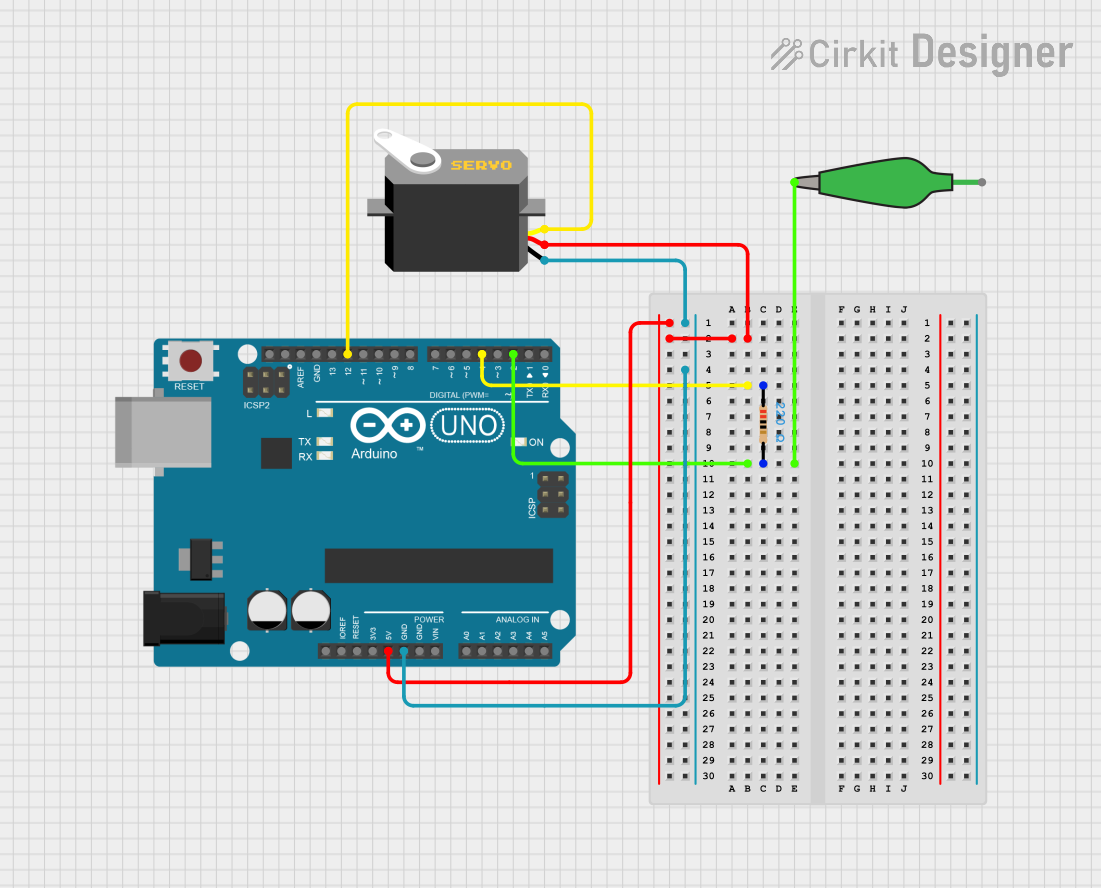
This circuit uses an Arduino UNO to control a servo motor. The servo motor is powered by the 5V and GND pins of the Arduino, and its control signal is connected to digital pin D12. Additionally, a resistor is connected between digital pins D4 and D2, with an alligator clip cable connected to D2.
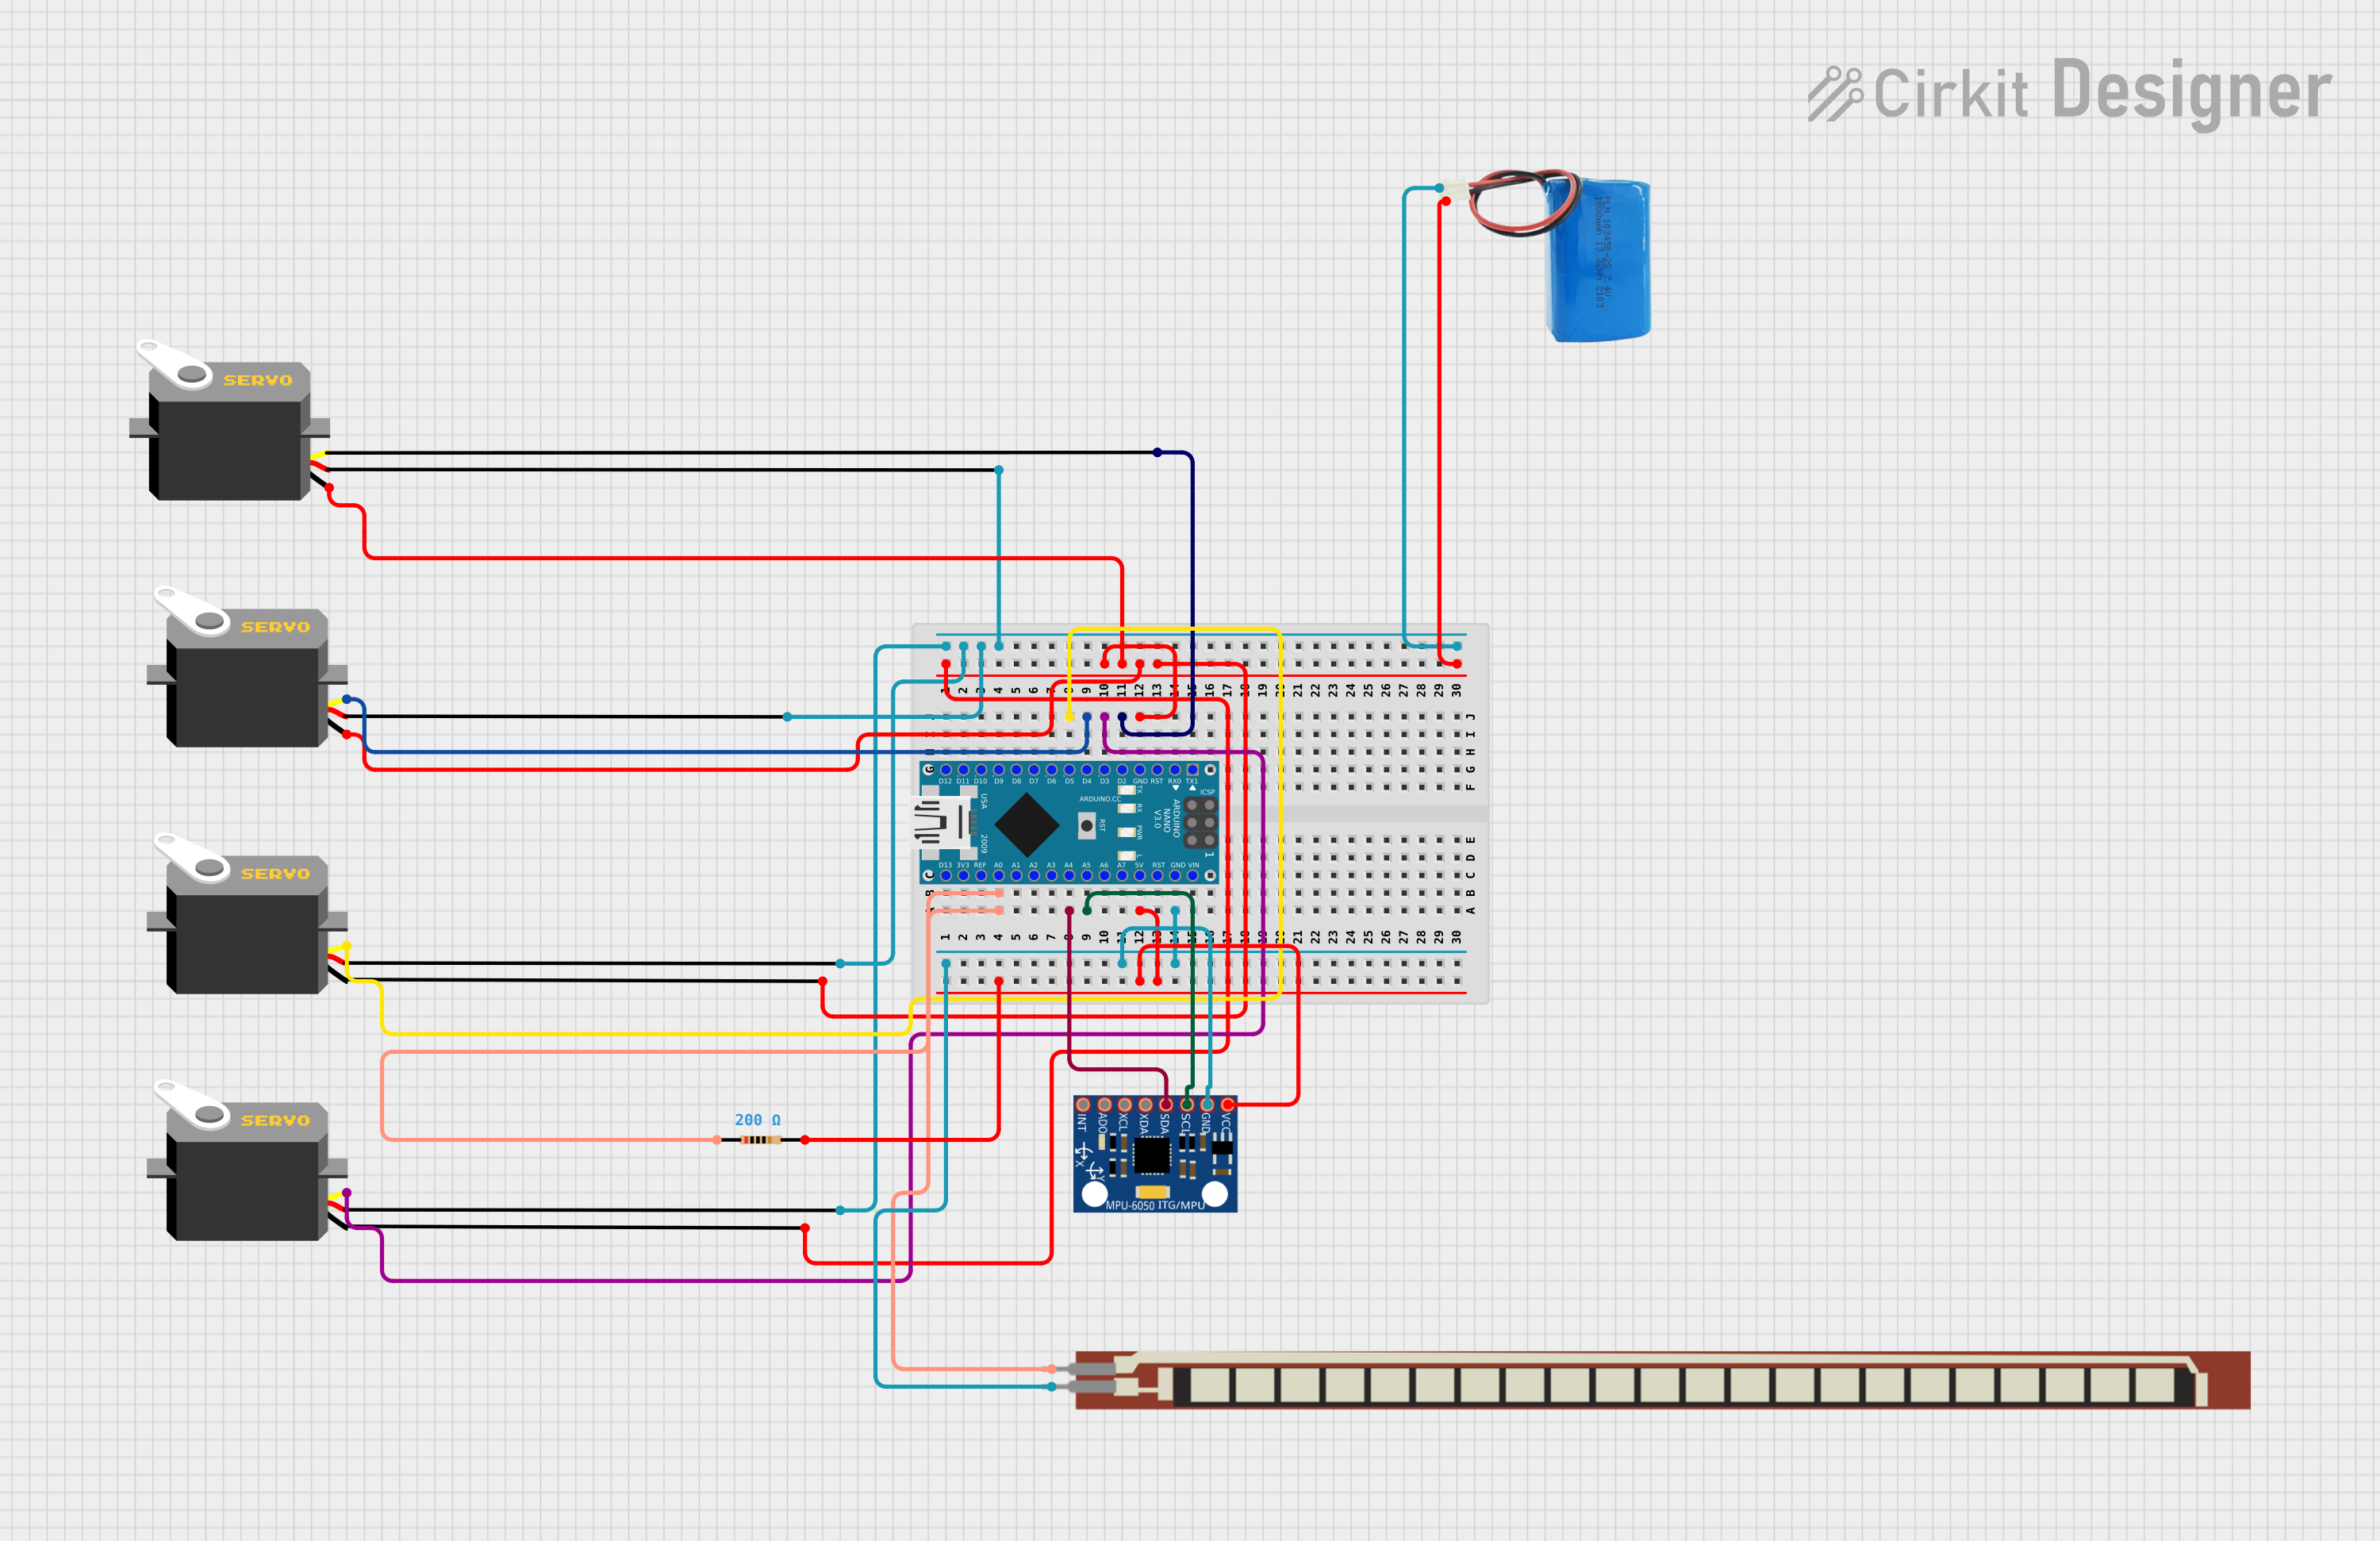
This circuit is designed to control a robotic arm with four servo motors, using an Arduino Nano as the microcontroller and an MPU-6050 accelerometer/gyroscope for motion sensing. The servos are controlled based on the orientation data from the MPU-6050, and a flex sensor adjusts the grip of the robotic arm. The Arduino Nano reads the sensor data, processes it, and generates PWM signals to control the position of each servo accordingly.
Operating Current: 100mA to 500mA (depending on load)
Torque: 2.5 kg·cm to 10 kg·cm (varies by model)
Rotation Range: 0° to 180° (standard), some models support 360° continuous rotation
Signal Type: PWM (Pulse Width Modulation)
Control Pulse Width: 500µs to 2500µs
Neutral Position Pulse Width: ~1500µs (90° position)
Connector Type: 3-pin (Signal, VCC, GND)
Pin Configuration and Descriptions:
Pin Number
Pin Name
Description
1
Signal
Receives PWM signal for angle control
2
VCC
Power supply (4.8V to 6.0V)
3
GND
Ground connection
Usage Instructions
How to Use the Right Servo in a Circuit:
Power Connection:
Connect the VCC pin to a 5V power source (e.g., Arduino 5V pin or external power supply).
Connect the GND pin to the ground of the power source.
Signal Connection:
Connect the Signal pin to a PWM-capable pin on a microcontroller (e.g., Arduino UNO pin 9 or 10).
PWM Signal:
Use a PWM signal to control the servo's angle. A pulse width of 500µs corresponds to 0°, 1500µs to 90°, and 2500µs to 180°.
External Power Supply (if needed):
For high-torque servos, use an external power supply to avoid overloading the microcontroller. Ensure the ground of the external power supply is connected to the microcontroller's ground.
Important Considerations:
Avoid stalling the servo for extended periods, as it may overheat.
Use a capacitor across the power supply to stabilize voltage and reduce noise.
Ensure the PWM signal is within the specified range to prevent damage to the servo.
Example Code for Arduino UNO:
#include <Servo.h> // Include the Servo library

Servo rightServo; // Create a Servo object to control the right servo

void setup() {
  rightServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  rightServo.write(0); // Move the servo to 0 degrees
  delay(1000);         // Wait for 1 second

  rightServo.write(90); // Move the servo to 90 degrees
  delay(1000);          // Wait for 1 second

  rightServo.write(180); // Move the servo to 180 degrees
  delay(1000);           // Wait for 1 second
}
Best Practices:
Use a dedicated power supply for multiple servos to prevent voltage drops.
Test the servo's range of motion before integrating it into your project.
Avoid applying excessive force to the servo horn to prevent damage.
Troubleshooting and FAQs
Common Issues and Solutions:
Servo Not Moving:
Cause: Incorrect wiring or no PWM signal.
Solution: Verify the connections and ensure the Signal pin is connected to a PWM-capable pin.
Servo Jitters or Vibrations:
Cause: Unstable power supply or noisy PWM signal.
Solution: Add a capacitor across the power supply and ensure the PWM signal is clean.
Servo Overheating:
Cause: Prolonged stalling or excessive load.
Solution: Reduce the load or avoid stalling the servo for extended periods.
Servo Moves Erratically:
Cause: Ground connection is missing or loose.
Solution: Ensure the ground of the servo is connected to the ground of the microcontroller.
FAQs:
Q1: Can I use a right servo with a 3.3V microcontroller?
A1: Yes, but you need a level shifter to convert the 3.3V PWM signal to 5V. Alternatively, use a servo that supports 3.3V logic.
Q2: How do I increase the torque of my servo?
A2: Use a higher torque-rated servo or increase the supply voltage within the servo's operating range.
Q3: Can I control multiple servos with one Arduino?
A3: Yes, but ensure the Arduino has enough PWM pins and use an external power supply for the servos.
Q4: What happens if I send a pulse width outside the specified range?
A4: The servo may attempt to move beyond its physical limits, potentially causing damage. Always stay within the recommended pulse width range.
By following this documentation, you can effectively integrate and troubleshoot a right servo in your projects.

 Open Project in Cirkit Designer