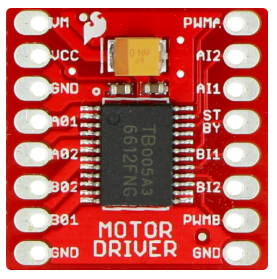
The TB6612FNG is a dual H-bridge motor driver IC manufactured by Arduino, designed to control two DC motors or one stepper motor. It supports PWM (Pulse Width Modulation) for precise speed control and direction management. With a compact design and robust performance, the TB6612FNG is widely used in robotics, automation, and other motor control applications.
Explore Projects Built with TB6612FNG
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
This circuit is an emergency alert system that uses a NUCLEO-F072RB microcontroller to send SMS alerts and make calls via a SIM800L GSM module, while obtaining location data from a GPS NEO 6M module. The system is powered by a Li-ion battery and includes a TP4056 module for battery charging and protection, with a rocker switch to control power to the microcontroller.
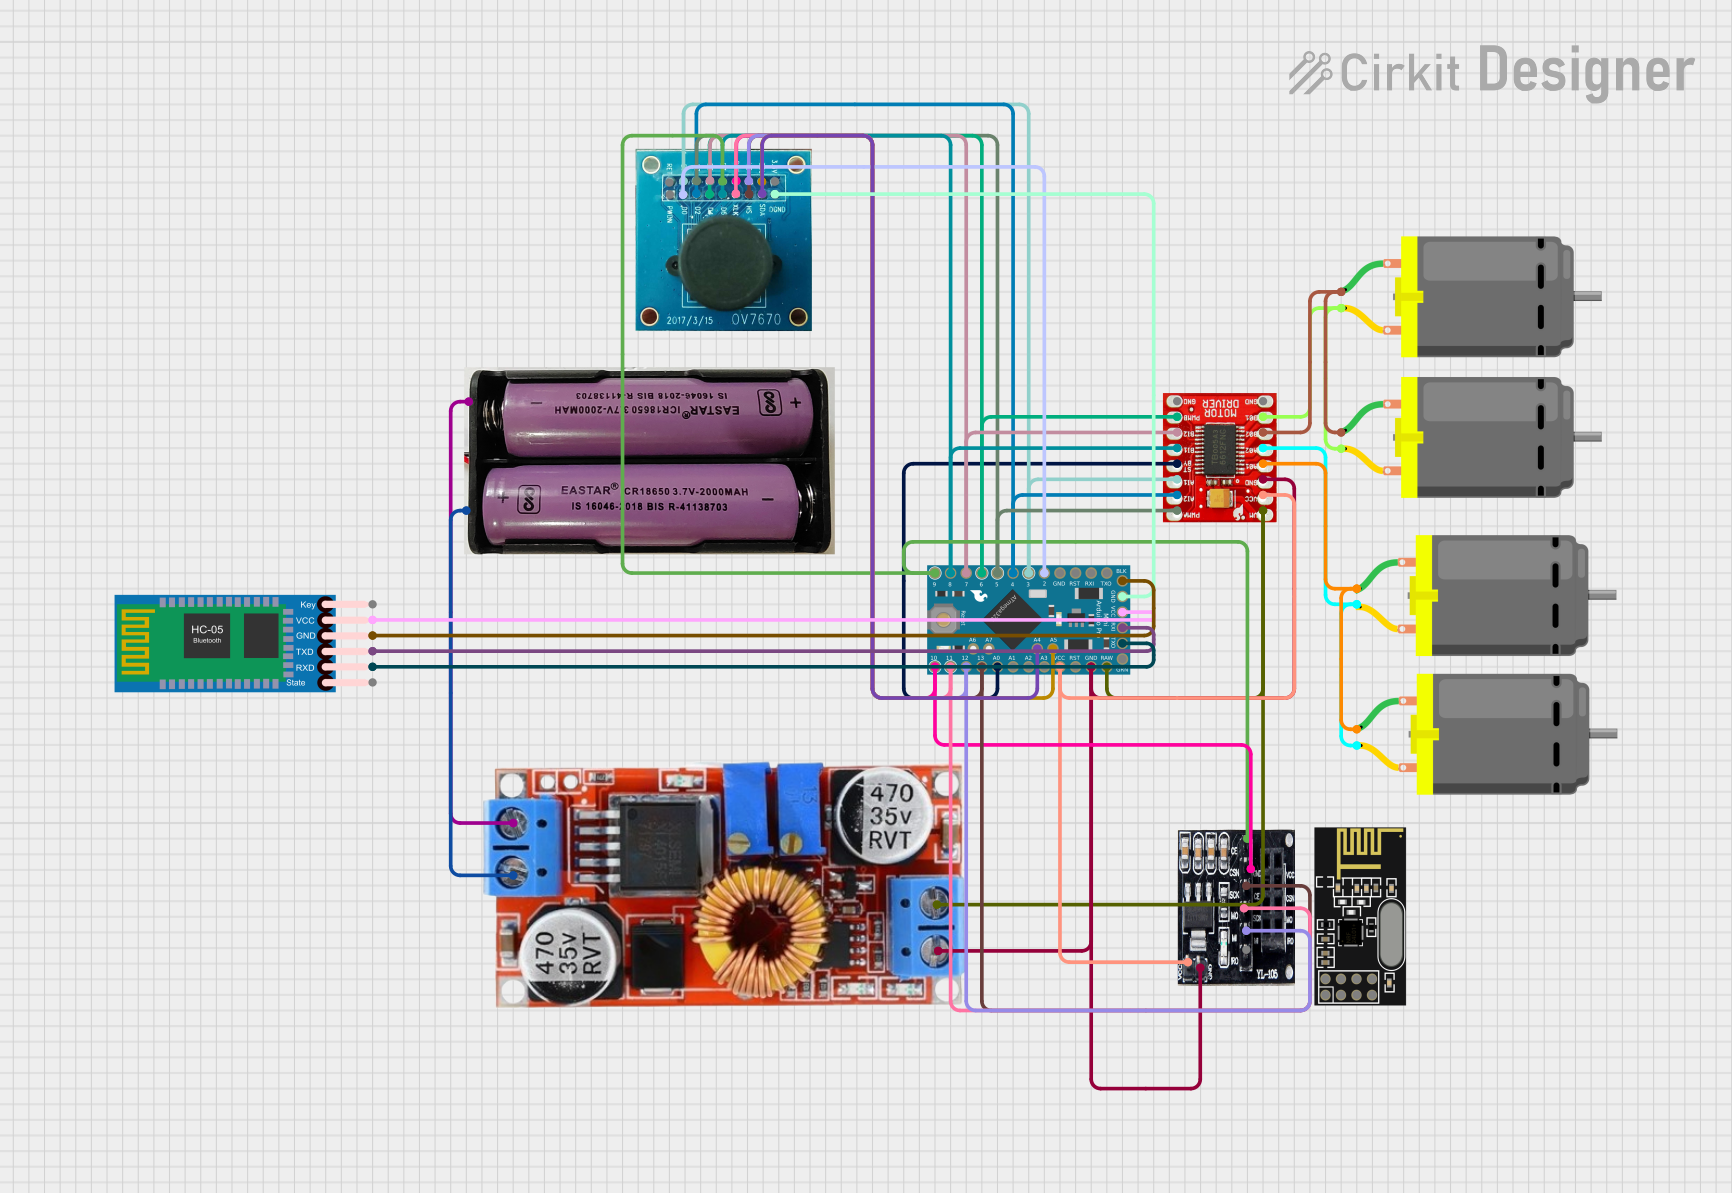
This circuit is a remote-controlled robotic system featuring an Arduino Pro Mini, a TB6612FNG motor driver, and an NRF24L01 wireless module. The Arduino controls four DC motors via the motor driver and communicates wirelessly using the NRF24L01 module, while an OV7670 camera module and an HC-05 Bluetooth module provide additional functionality.
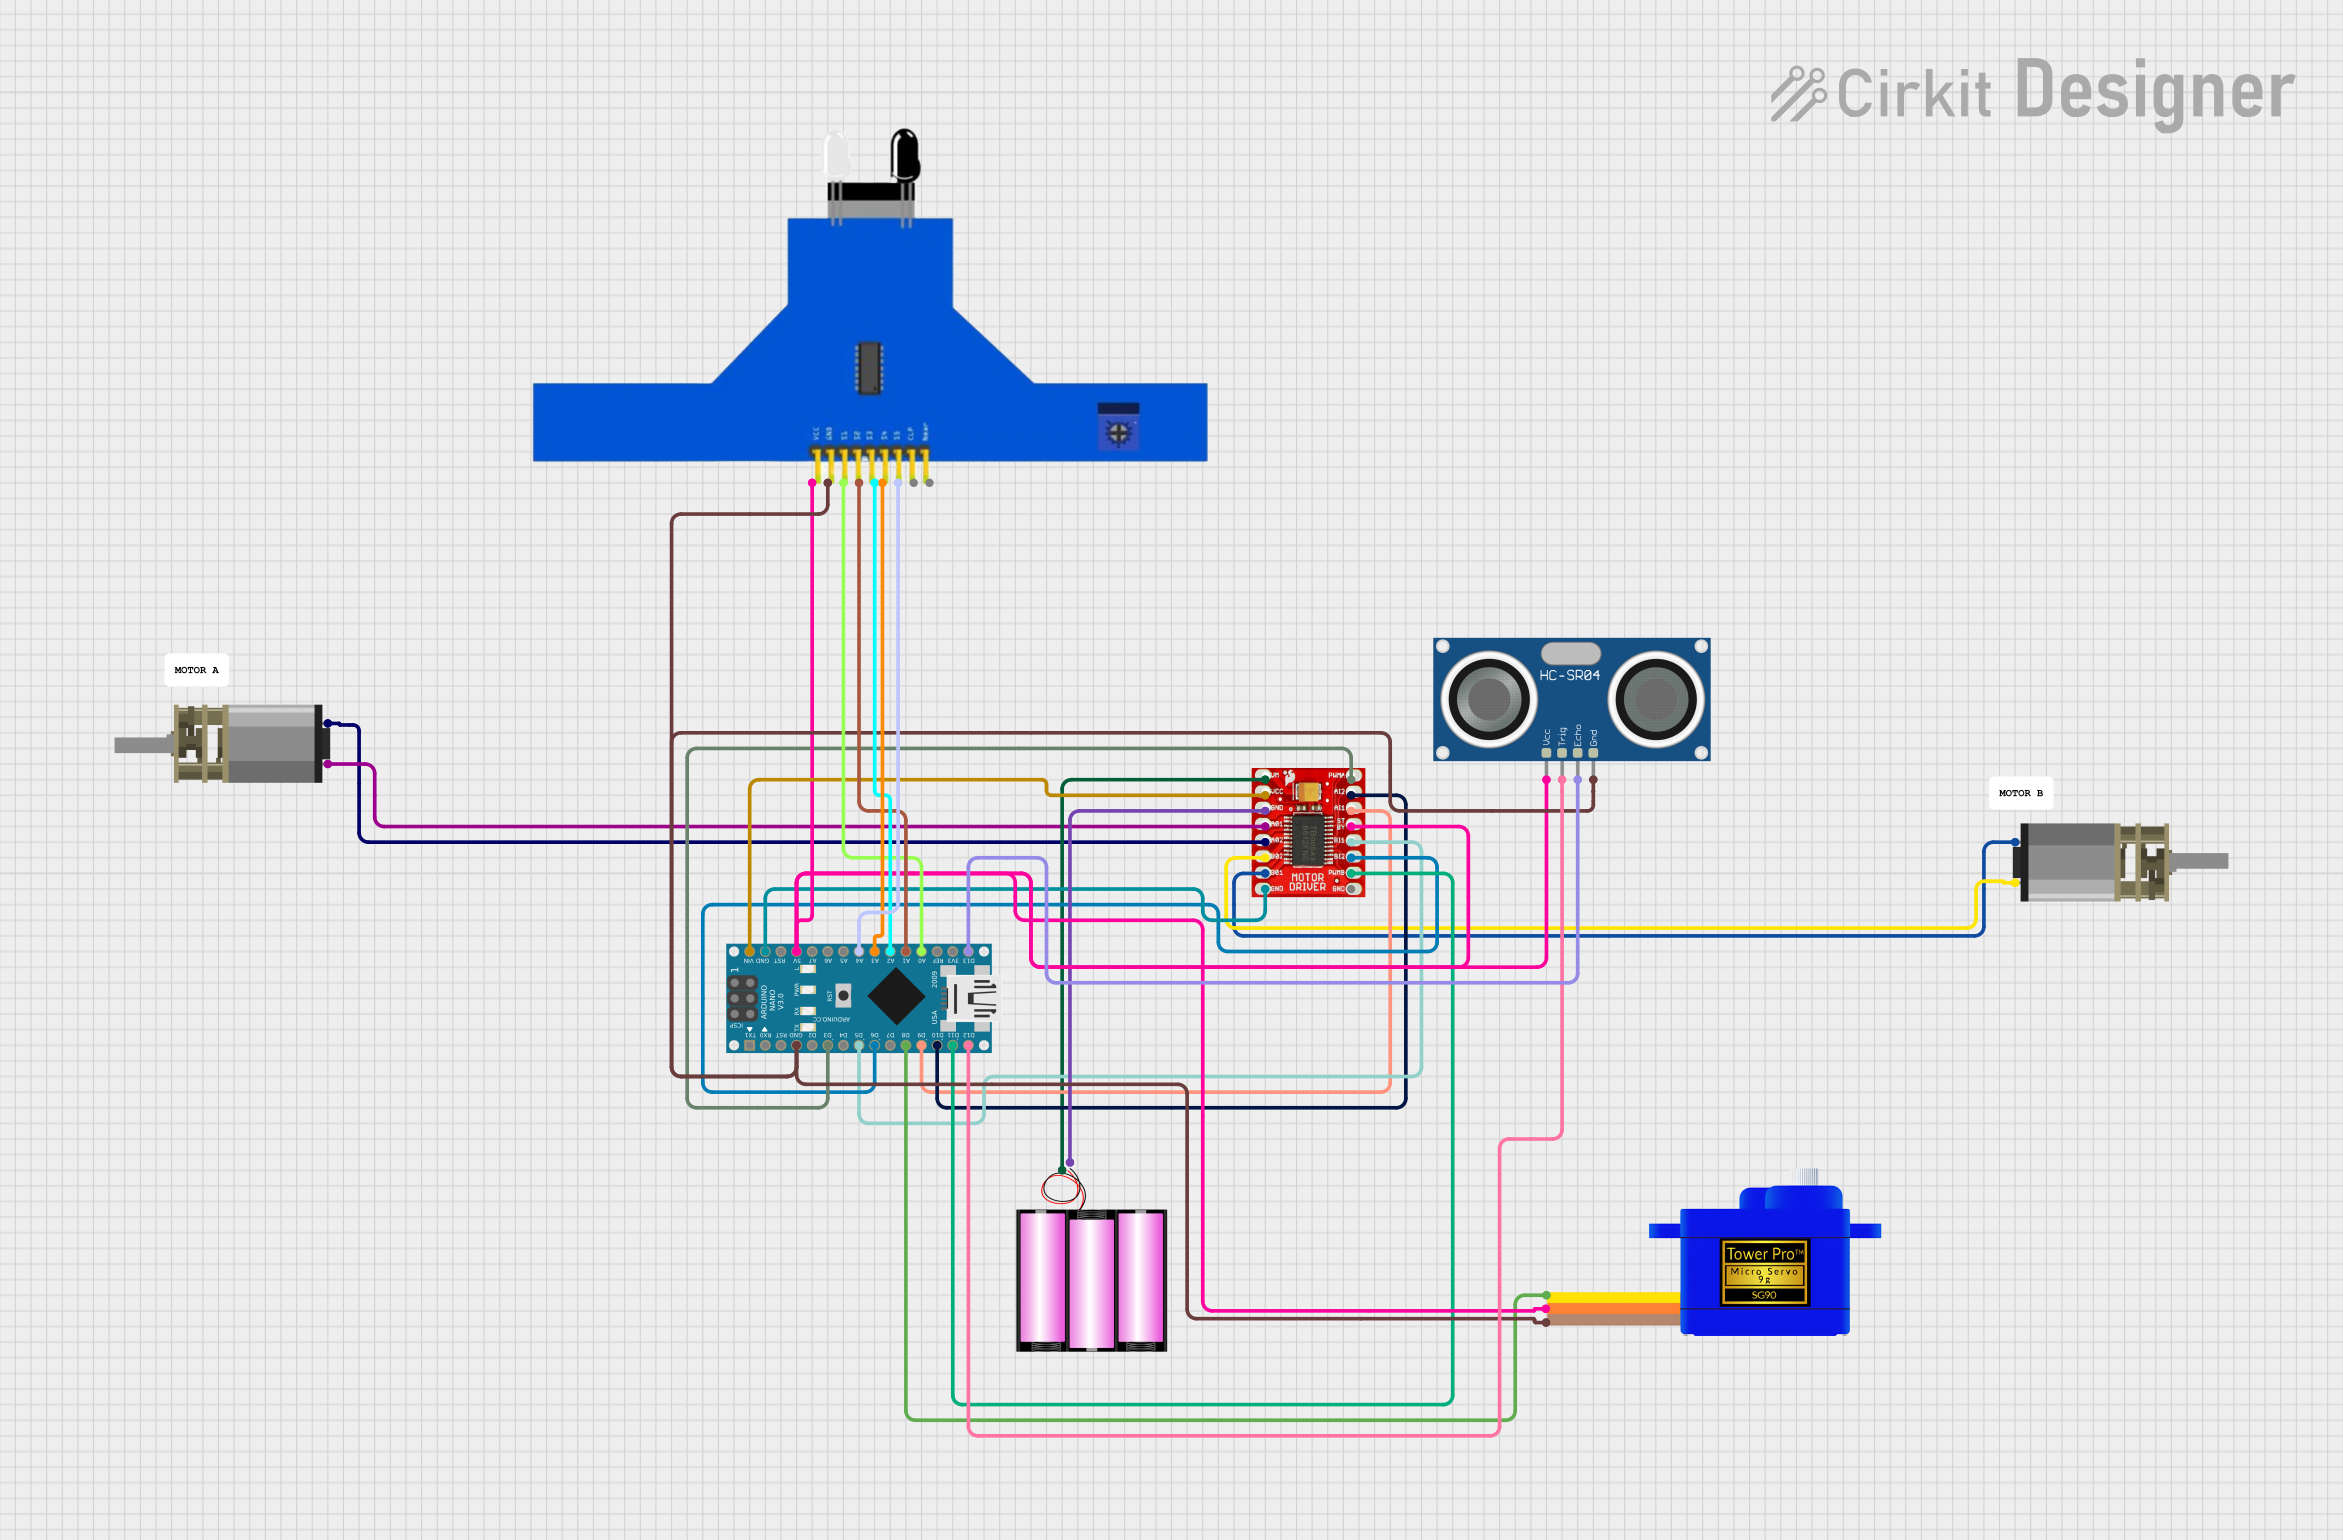
This circuit features an Arduino Nano microcontroller interfaced with a TB6612FNG motor driver to control two DC Mini Metal Gear Motors. It also includes an HC-SR04 Ultrasonic Sensor for distance measurement, a 5 channel IR sensor for line tracking, and a Servomotor SG90 for positioning tasks. The system is powered by a 12V battery, with the Arduino Nano managing sensor inputs and motor outputs to perform tasks such as navigation or automation.
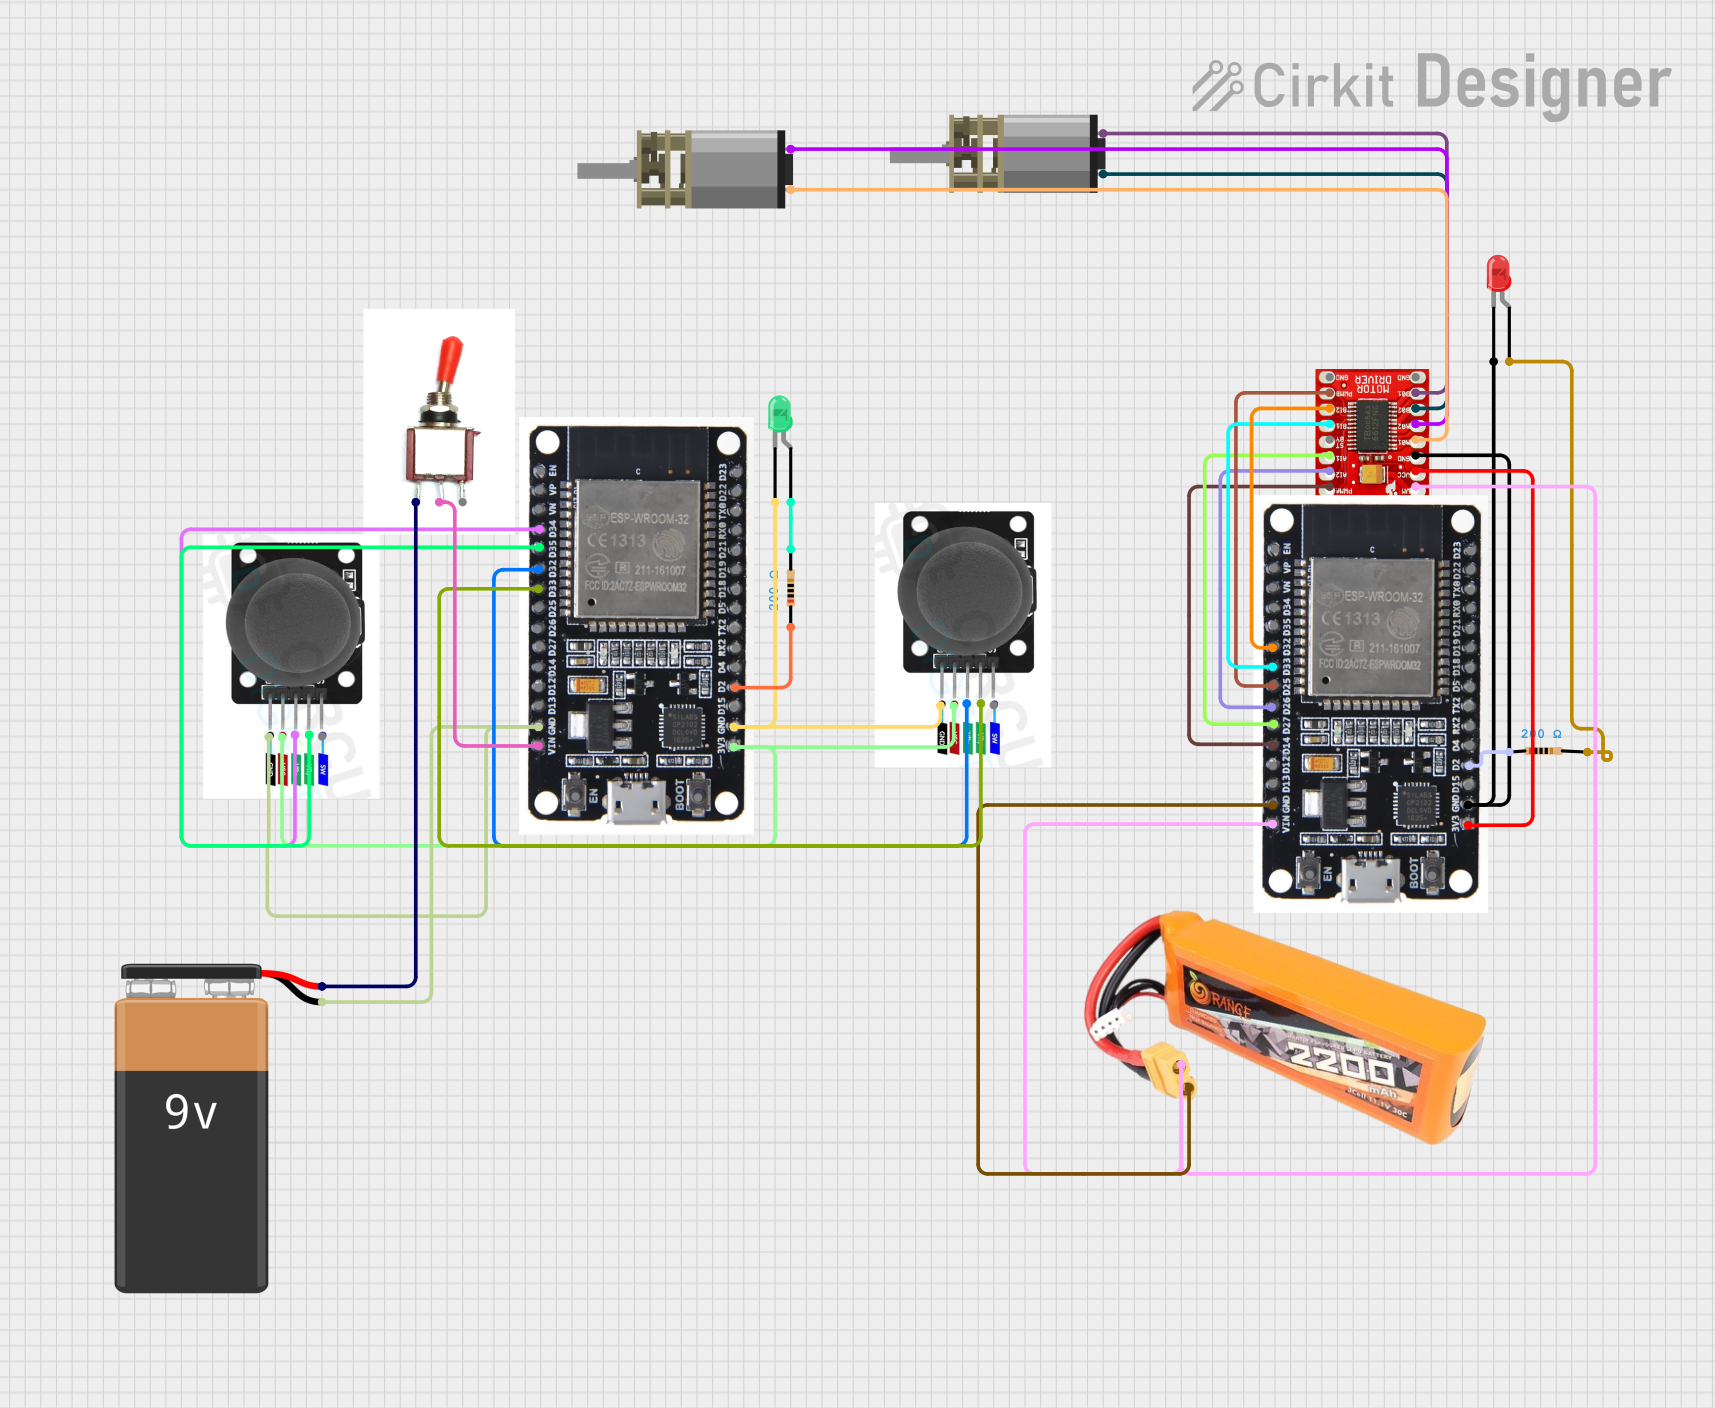
This circuit is a remote-controlled motor system using two ESP32 microcontrollers and joystick modules. One ESP32 reads joystick positions and transmits them via Bluetooth to the second ESP32, which controls two DC motors through a TB6612FNG motor driver. The system includes LEDs for status indication and is powered by a 9V battery and a LiPo battery.
Robotics: Driving wheels or actuators in robotic systems
Automation: Controlling conveyor belts or small machinery
DIY Projects: Building motorized toys or custom motorized systems
Stepper Motor Control: Driving stepper motors for precise positioning
Technical Specifications
The TB6612FNG is a versatile motor driver IC with the following key specifications:
Parameter
Value
Supply Voltage (Vcc)
2.5V to 13.5V
Motor Output Current
1.2A (continuous per channel)
Peak Output Current
3.2A (short duration per channel)
Logic Input Voltage
2.7V to 5.5V
Control Method
PWM (Pulse Width Modulation)
Operating Temperature
-20°C to +85°C
Standby Current
1 µA (typical)
Pin Configuration and Descriptions
The TB6612FNG has 16 pins, each serving a specific function. Below is the pinout and description:
Pin Number
Pin Name
Description
1
AIN1
Input signal for Motor A direction control
2
AIN2
Input signal for Motor A direction control
3
PWMA
PWM input for Motor A speed control
4
A01
Output 1 for Motor A
5
A02
Output 2 for Motor A
6
VM
Motor power supply (2.5V to 13.5V)
7
GND
Ground
8
STBY
Standby control (active high to enable the IC)
9
B02
Output 2 for Motor B
10
B01
Output 1 for Motor B
11
PWMB
PWM input for Motor B speed control
12
BIN2
Input signal for Motor B direction control
13
BIN1
Input signal for Motor B direction control
14
VCC
Logic power supply (2.7V to 5.5V)
15
NC
No connection
16
NC
No connection
Usage Instructions
How to Use the TB6612FNG in a Circuit
Power Connections:
Connect the VM pin to the motor power supply (2.5V to 13.5V).
Connect the VCC pin to the logic power supply (2.7V to 5.5V).
Connect the GND pin to the ground of the circuit.
Motor Connections:
Connect the motor terminals to A01 and A02 for Motor A, and B01 and B02 for Motor B.
Control Signals:
Use the AIN1 and AIN2 pins to control the direction of Motor A.
Use the BIN1 and BIN2 pins to control the direction of Motor B.
Apply PWM signals to PWMA and PWMB to control the speed of Motor A and Motor B, respectively.
Standby Mode:
Set the STBY pin high to enable the IC. Pull it low to put the IC in standby mode.
Important Considerations and Best Practices
Use appropriate decoupling capacitors near the VM and VCC pins to stabilize the power supply.
Ensure the motor current does not exceed the maximum continuous current rating of 1.2A per channel.
Use heat sinks or proper ventilation if operating near the peak current for extended periods.
Avoid floating input pins; always connect them to a defined logic level.
Example Code for Arduino UNO
Below is an example code to control two DC motors using the TB6612FNG and an Arduino UNO:
// Define motor control pins
#define AIN1 7  // Motor A direction control pin 1
#define AIN2 8  // Motor A direction control pin 2
#define PWMA 9  // Motor A speed control (PWM) pin
#define BIN1 10 // Motor B direction control pin 1
#define BIN2 11 // Motor B direction control pin 2
#define PWMB 3  // Motor B speed control (PWM) pin
#define STBY 6  // Standby control pin

void setup() {
  // Set motor control pins as outputs
  pinMode(AIN1, OUTPUT);
  pinMode(AIN2, OUTPUT);
  pinMode(PWMA, OUTPUT);
  pinMode(BIN1, OUTPUT);
  pinMode(BIN2, OUTPUT);
  pinMode(PWMB, OUTPUT);
  pinMode(STBY, OUTPUT);

  // Enable the motor driver
  digitalWrite(STBY, HIGH);
}

void loop() {
  // Motor A: Forward at 50% speed
  digitalWrite(AIN1, HIGH);
  digitalWrite(AIN2, LOW);
  analogWrite(PWMA, 128); // 50% duty cycle (0-255)

  // Motor B: Reverse at 75% speed
  digitalWrite(BIN1, LOW);
  digitalWrite(BIN2, HIGH);
  analogWrite(PWMB, 192); // 75% duty cycle (0-255)

  delay(2000); // Run motors for 2 seconds

  // Stop both motors
  analogWrite(PWMA, 0);
  analogWrite(PWMB, 0);

  delay(2000); // Wait for 2 seconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motors Not Running:
Ensure the STBY pin is set high to enable the IC.
Verify that the power supply voltage is within the specified range for VM and VCC.
Check the connections to the motor terminals and control pins.
Motor Running in the Wrong Direction:
Swap the logic levels on the direction control pins (AIN1, AIN2, BIN1, BIN2).
Overheating:
Ensure the motor current does not exceed 1.2A per channel.
Add heat sinks or improve ventilation around the IC.
PWM Not Controlling Speed:
Verify that the PWM signal is being generated correctly by the microcontroller.
Check the connections to the PWMA and PWMB pins.
FAQs
Q: Can the TB6612FNG drive stepper motors?
A: Yes, the TB6612FNG can drive a stepper motor by controlling the two H-bridges in a coordinated manner.
Q: What happens if the motor current exceeds 1.2A?
A: The IC may overheat or enter thermal shutdown to protect itself. Ensure the motor current stays within the rated limits.
Q: Can I use the TB6612FNG with a 3.3V microcontroller?
A: Yes, the logic input voltage range (2.7V to 5.5V) supports 3.3V microcontrollers.


 Open Project in Cirkit Designer