Introduction
The Troyka IMU 10 DoF is a compact and versatile Inertial Measurement Unit (IMU) designed for applications requiring precise motion and orientation tracking. This module integrates a 3-axis accelerometer, a 3-axis gyroscope, and a 3-axis magnetometer, along with a barometric pressure sensor, to provide 10 degrees of freedom (DoF) for comprehensive motion sensing. It is ideal for robotics, navigation systems, drones, and other projects that demand accurate spatial awareness.
Common Applications
- Robotics and autonomous vehicles
- Drone stabilization and navigation
- Virtual reality (VR) and augmented reality (AR) systems
- Wearable devices for motion tracking
- Scientific experiments and data logging
Technical Specifications
The following table outlines the key technical details of the Troyka IMU 10 DoF:
Pin Configuration
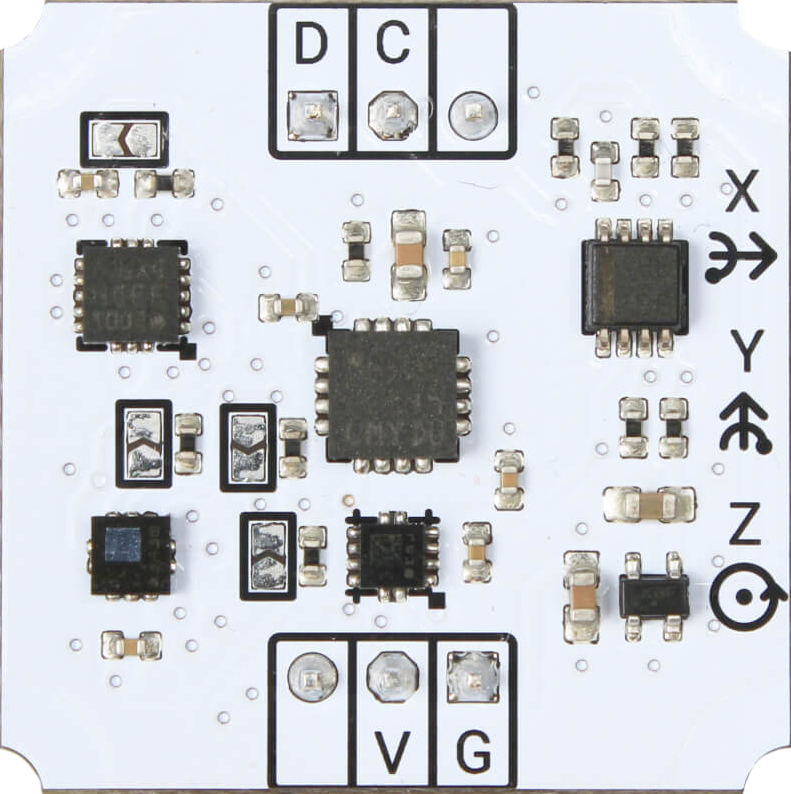
The Troyka IMU 10 DoF features the following pin layout:
Usage Instructions
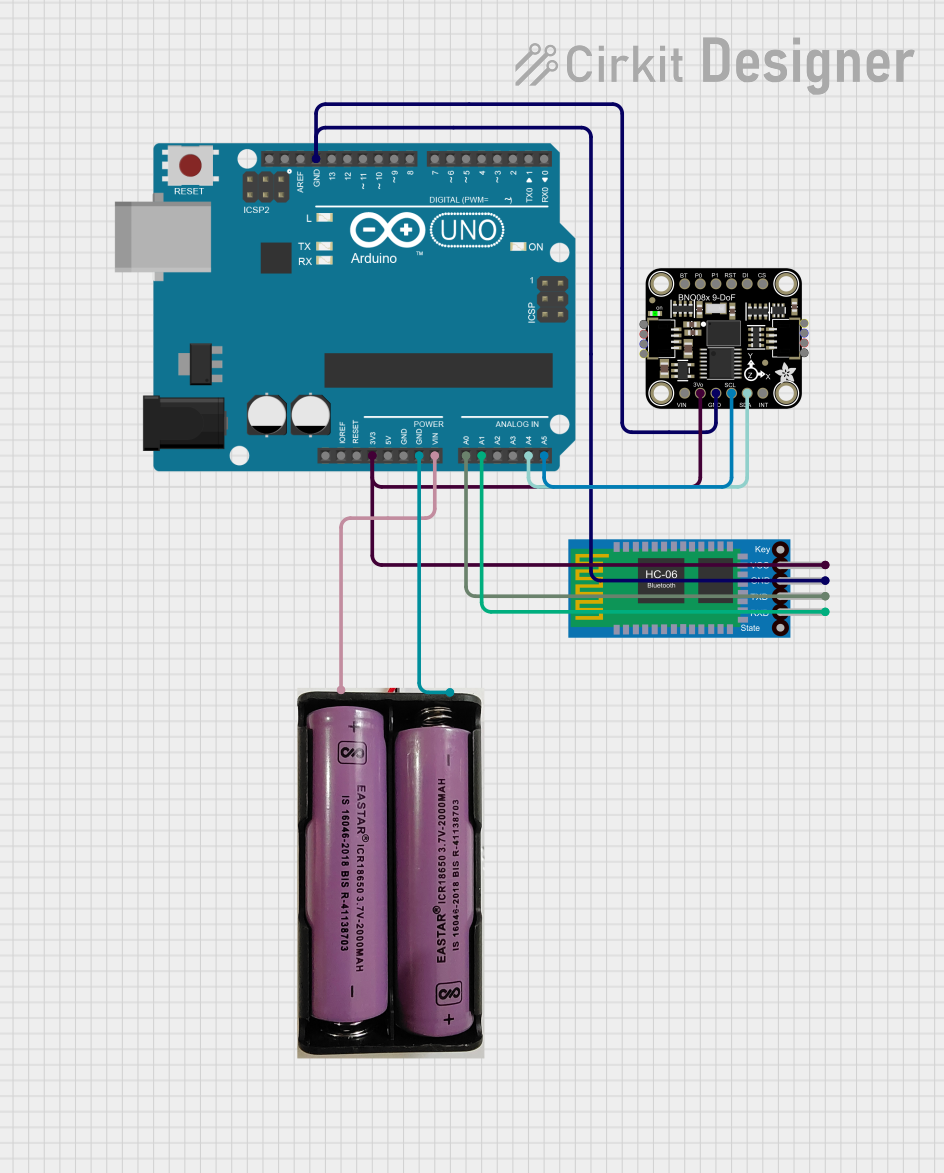
Connecting the IMU to an Arduino UNO
To use the Troyka IMU 10 DoF with an Arduino UNO, follow these steps:
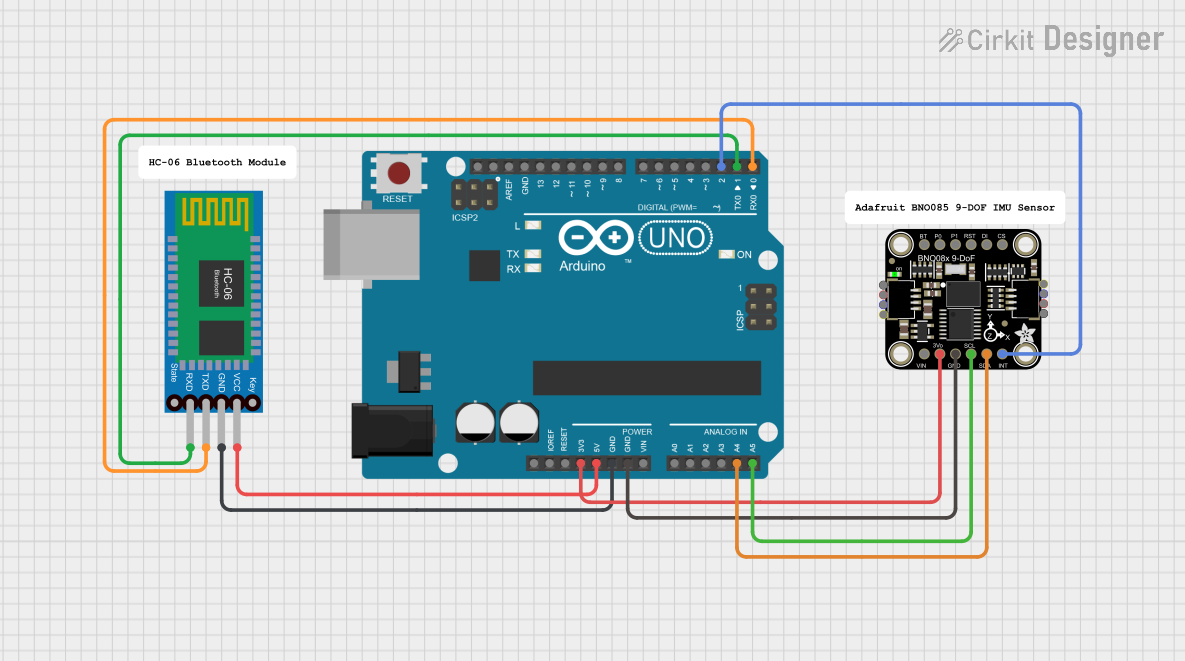
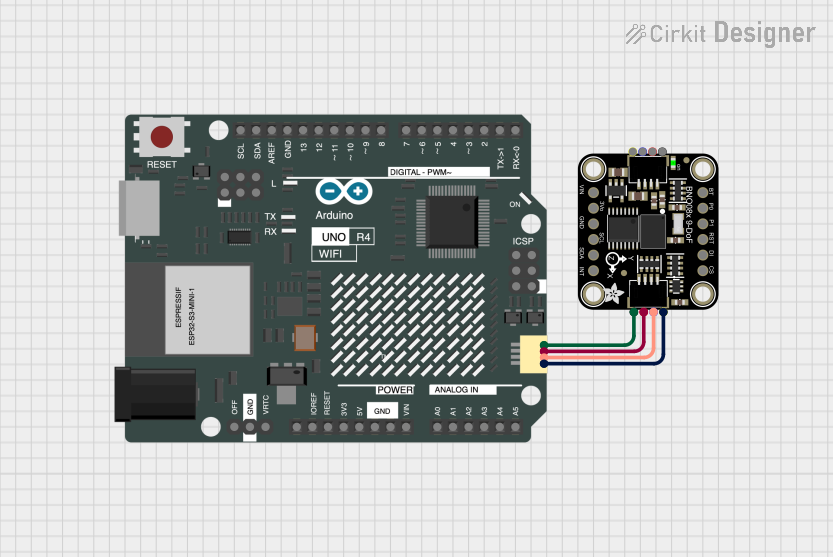
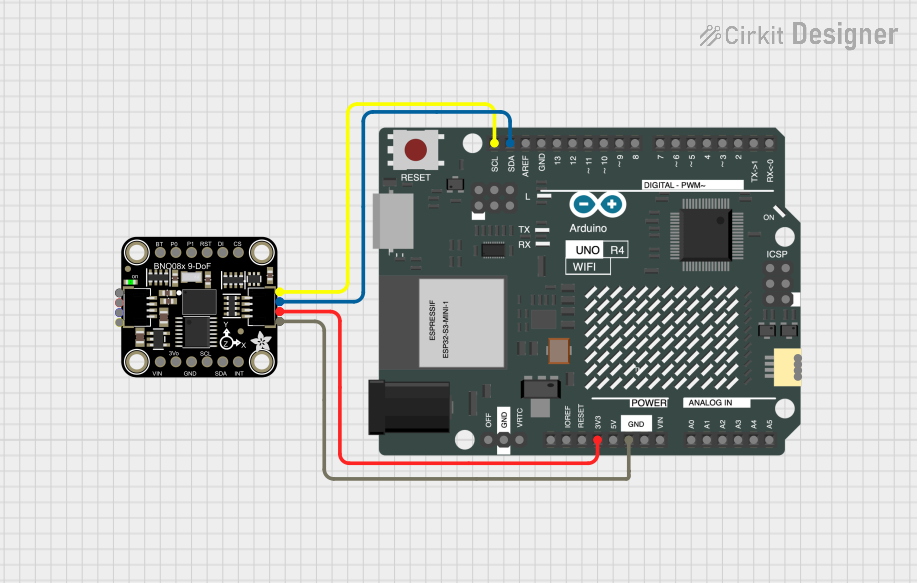
- Connect the VCC pin of the IMU to the 5V pin on the Arduino.
- Connect the GND pin of the IMU to the GND pin on the Arduino.
- Connect the SDA pin of the IMU to the A4 pin on the Arduino (I2C data line).
- Connect the SCL pin of the IMU to the A5 pin on the Arduino (I2C clock line).
Sample Arduino Code
Below is an example Arduino sketch to read data from the IMU using the I2C interface:
#include <Wire.h>

// Define the I2C address of the IMU
#define IMU_ADDRESS 0x68

void setup() {
  Wire.begin(); // Initialize I2C communication
  Serial.begin(9600); // Start serial communication for debugging

  // Wake up the IMU (if required by the specific IMU model)
  Wire.beginTransmission(IMU_ADDRESS);
  Wire.write(0x6B); // Power management register
  Wire.write(0x00); // Set to normal mode
  Wire.endTransmission();

  Serial.println("Troyka IMU 10 DoF initialized.");
}

void loop() {
  Wire.beginTransmission(IMU_ADDRESS);
  Wire.write(0x3B); // Starting register for accelerometer data
  Wire.endTransmission(false);
  Wire.requestFrom(IMU_ADDRESS, 6, true); // Request 6 bytes of data

  // Read accelerometer data
  int16_t accelX = (Wire.read() << 8) | Wire.read();
  int16_t accelY = (Wire.read() << 8) | Wire.read();
  int16_t accelZ = (Wire.read() << 8) | Wire.read();

  // Print accelerometer data to the Serial Monitor
  Serial.print("Accel X: "); Serial.print(accelX);
  Serial.print(" | Accel Y: "); Serial.print(accelY);
  Serial.print(" | Accel Z: "); Serial.println(accelZ);

  delay(500); // Wait for 500ms before the next reading
}
Best Practices
- Ensure proper power supply (3.3V–5V) to avoid damaging the IMU.
- Use pull-up resistors on the I2C lines (SDA and SCL) if not already integrated.
- Mount the IMU securely to minimize vibrations and improve measurement accuracy.
- Calibrate the accelerometer, gyroscope, and magnetometer for optimal performance.
Troubleshooting and FAQs
Common Issues
No data or incorrect readings from the IMU.
- Solution: Verify the wiring connections and ensure the correct I2C address is used in the code.
- Tip: Use an I2C scanner sketch to detect the IMU's address.
Inconsistent or noisy sensor data.
- Solution: Check for external vibrations or magnetic interference near the IMU.
- Tip: Implement software filtering (e.g., a Kalman filter) to smooth the data.
The IMU is not detected by the Arduino.
- Solution: Ensure the IMU is powered correctly and the SDA/SCL lines are connected properly.
- Tip: Confirm that the Arduino's I2C pins (A4 and A5) are not being used by other devices.
FAQs
Q: Can I use the Troyka IMU 10 DoF with a 3.3V microcontroller?
A: Yes, the IMU supports both 3.3V and 5V logic levels, making it compatible with a wide range of microcontrollers.
Q: How do I calibrate the sensors?
A: Calibration can be performed by collecting raw data from the sensors and applying offsets or scaling factors. Many libraries (e.g., MPU6050 or BNO055 libraries) include built-in calibration functions.
Q: Can I use SPI instead of I2C?
A: Yes, the IMU supports SPI communication. Refer to the pin configuration table for SPI pin connections.
Q: What is the maximum sampling rate of the IMU?
A: The sampling rate depends on the specific sensor configuration. Refer to the sensor datasheets for detailed information.

 Open Project in Cirkit Designer