Cirkit Designer LogoCirkit DesignerYour all-in-one circuit design IDE Launch Cirkit Designer App

How to Use KK 2.1.5 FLIGHT CONTROLLER: Examples, Pinouts, and Specs

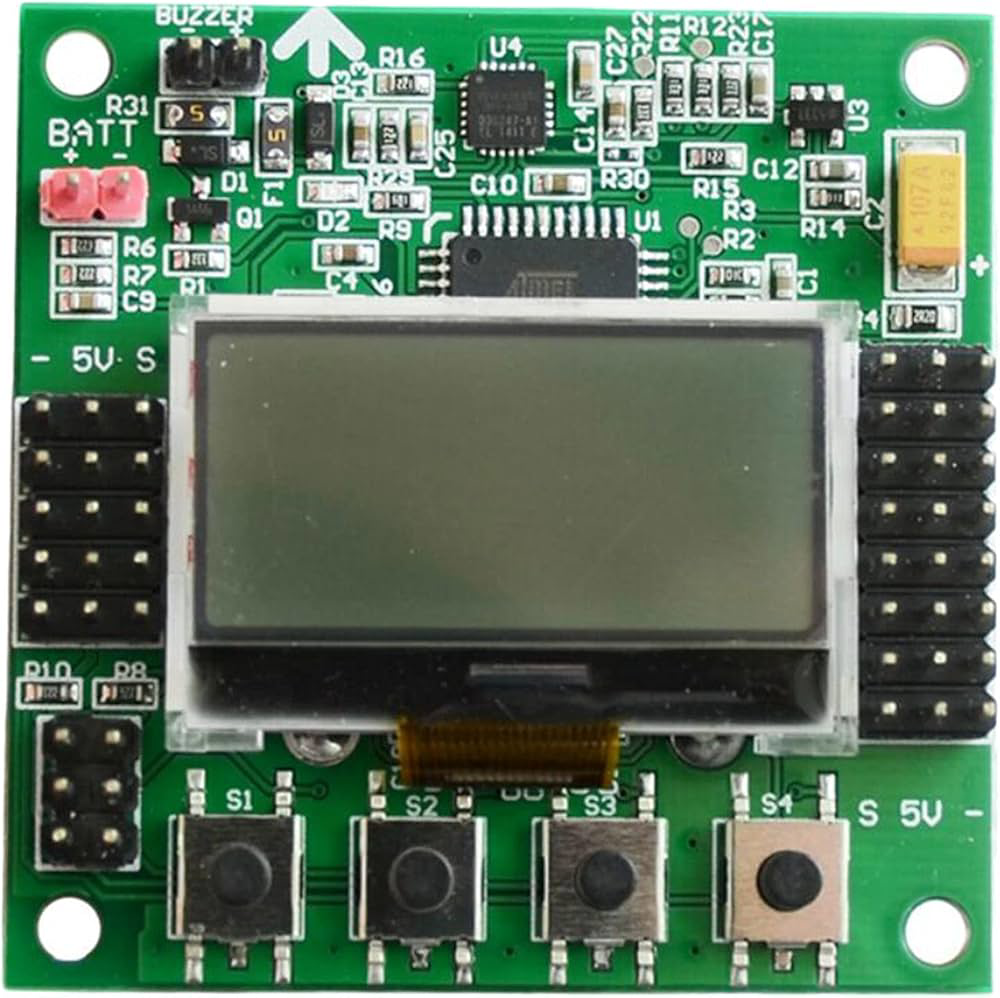
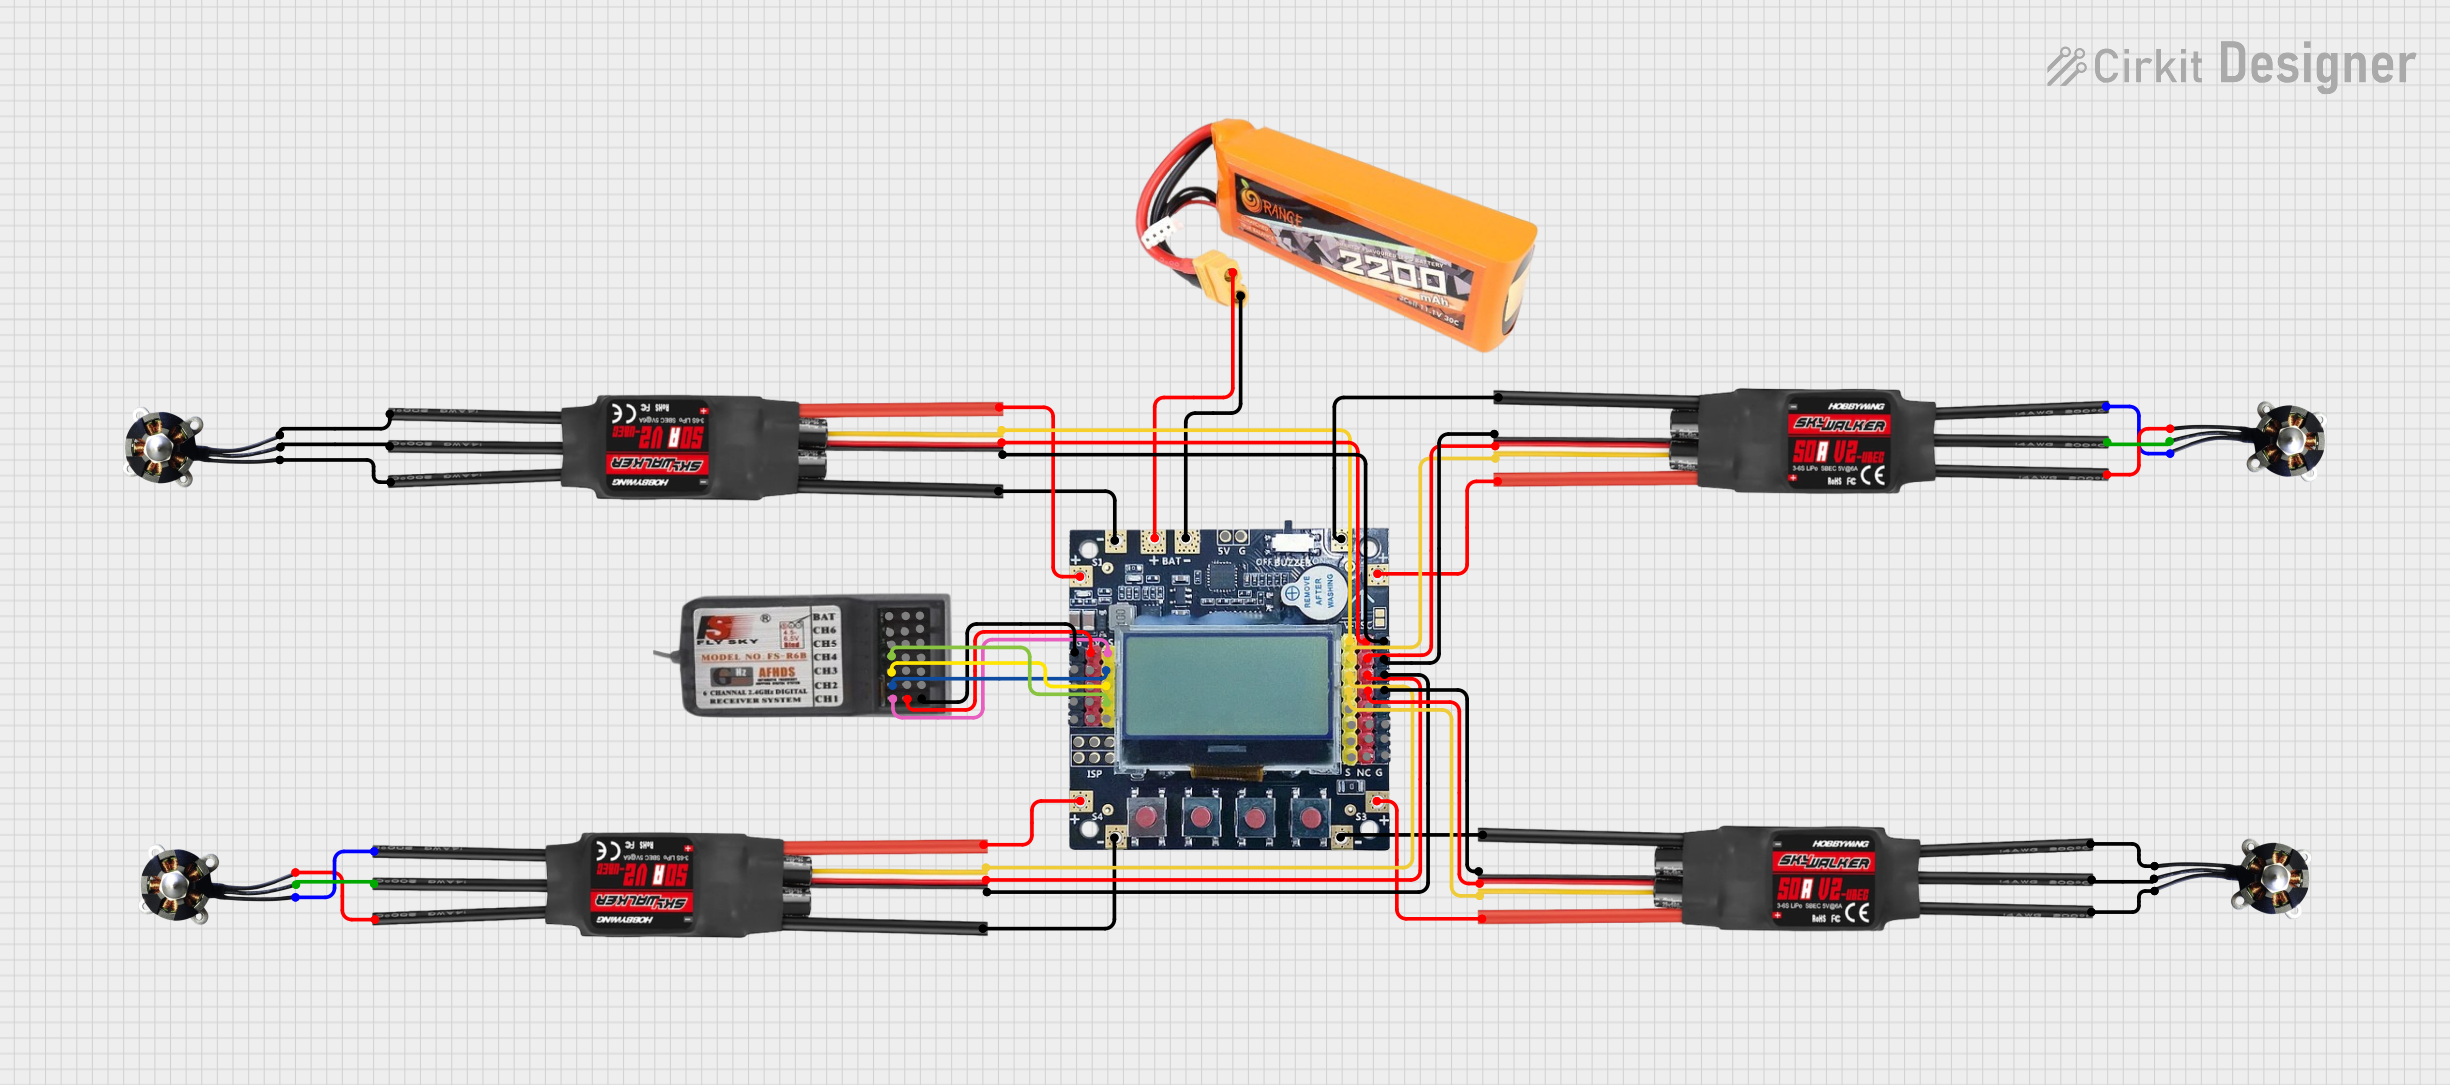
Image of KK 2.1.5 FLIGHT CONTROLLERDesign with KK 2.1.5 FLIGHT CONTROLLER in Cirkit Designer

Introduction

The KK 2.1.5 Flight Controller is an advanced electronic device designed for stabilizing and managing the flight of multirotor aircraft, commonly known as drones. It integrates sensor data and user inputs to provide real-time adjustments to the motor outputs, ensuring stable flight and responsive control. This flight controller is popular among hobbyists and enthusiasts for its ease of use and robust feature set.

Explore Projects Built with KK 2.1.5 FLIGHT CONTROLLER

Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
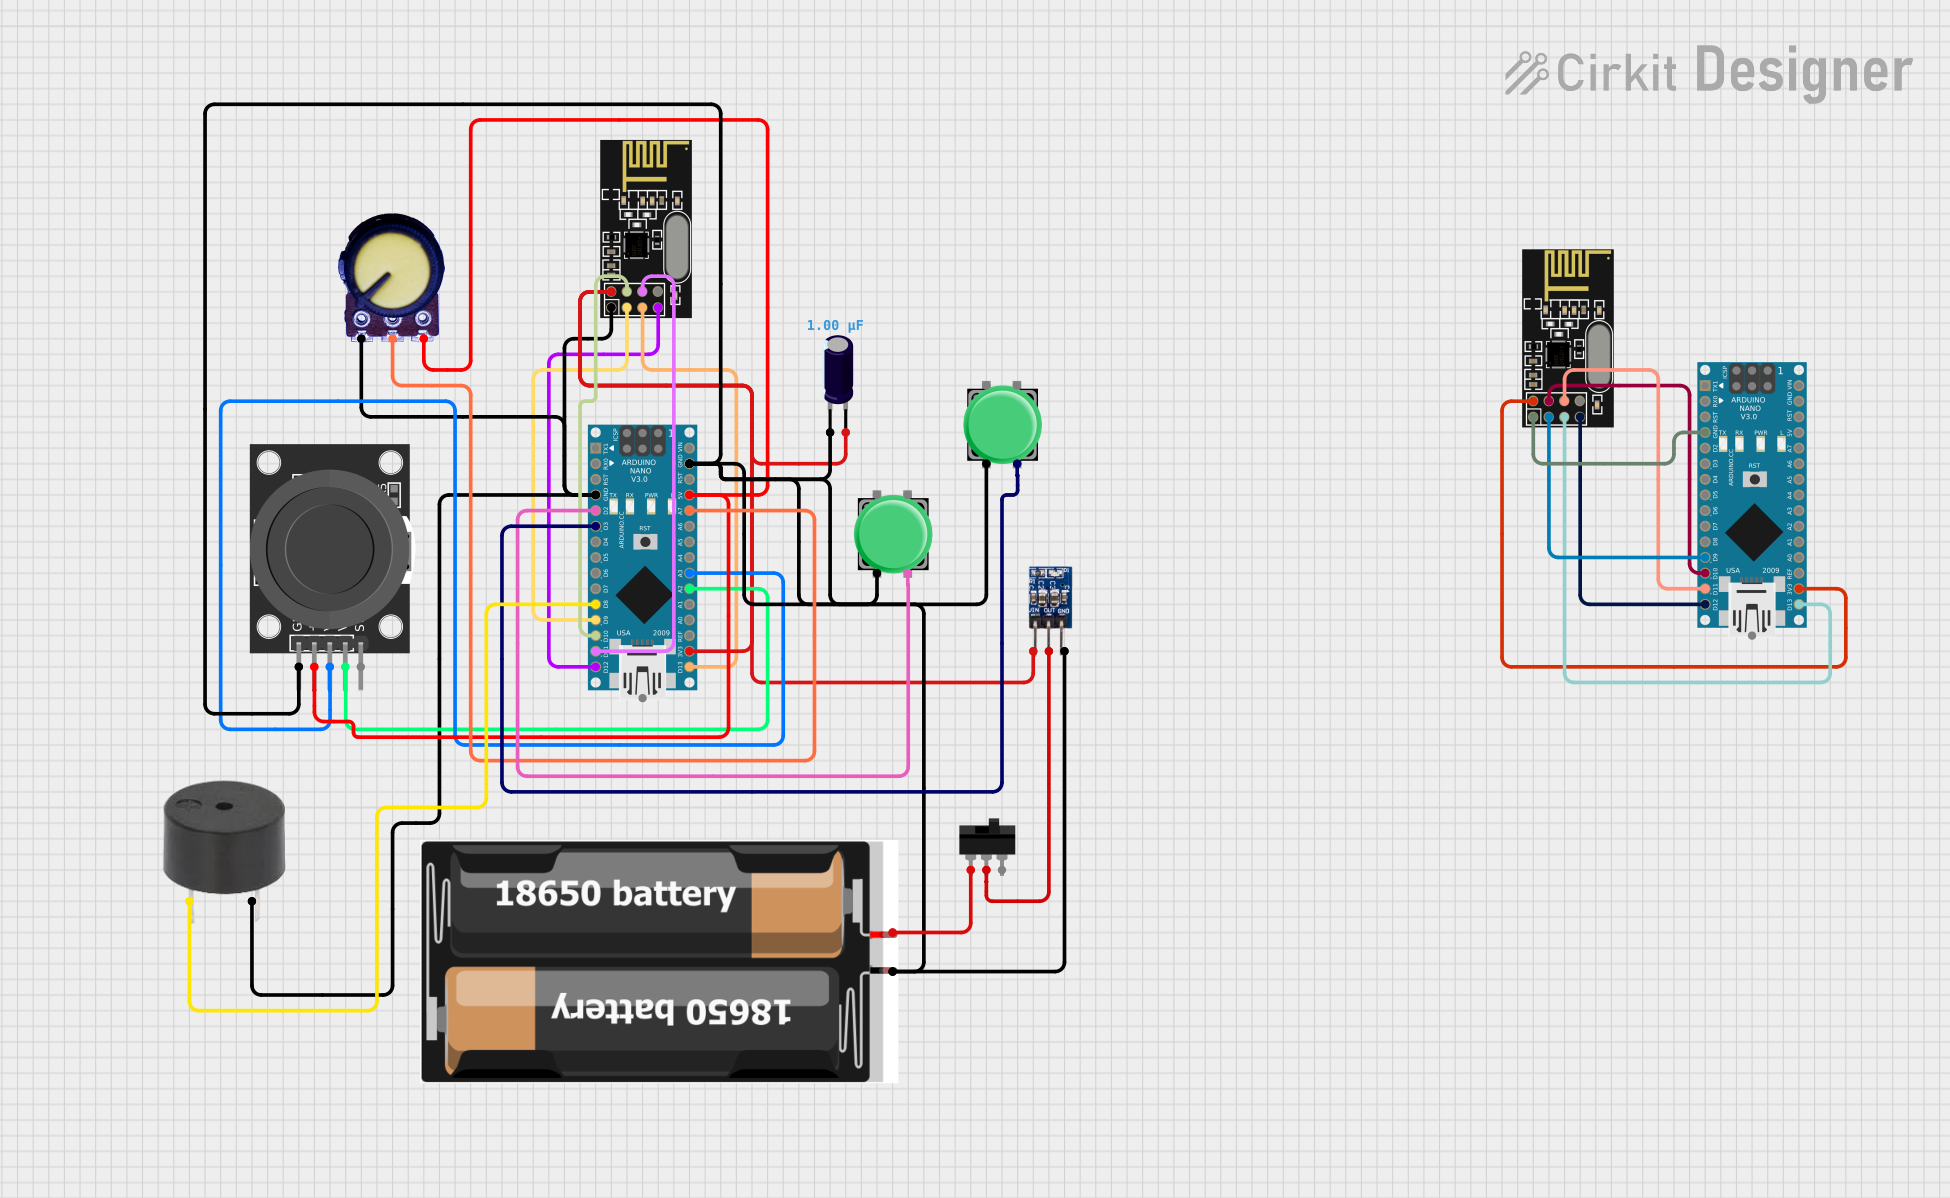
Image of Arduino Nano-Based Drone Remote Control with NRF24L01 Wireless Communication: A project utilizing KK 2.1.5 FLIGHT CONTROLLER in a practical application
Arduino Nano-Based Drone Remote Control with NRF24L01 Wireless Communication

This circuit is a wireless drone control system utilizing two Arduino Nano microcontrollers. One Arduino Nano is configured as a transmitter with a joystick module, potentiometer, pushbuttons, and an NRF24L01 module for sending control signals. The other Arduino Nano acts as a receiver, interfacing with a corresponding NRF24L01 module to receive the transmitted signals, and it includes a buzzer for audio feedback. The system is powered by a 2x 18650 battery pack with voltage regulation provided by an AMS1117 3.3V regulator and an electrolytic capacitor for smoothing.

Open Project in Cirkit Designer

Common Applications and Use Cases

Technical Specifications

Key Technical Details

Pin Configuration and Descriptions

Pin Number Description Type
1 Ground Power
2 +5V Input Power
3-8 Motor Outputs Signal
9-12 M1-M4 Inputs (Receiver) Signal
13 Aileron Input (Receiver) Signal
14 Elevator Input (Receiver) Signal
15 Throttle Input (Receiver) Signal
16 Rudder Input (Receiver) Signal
17 Auxiliary 1 Input (Receiver) Signal
18 Auxiliary 2 Input (Receiver) Signal
19 Ground Power
20 +5V Output Power

Usage Instructions

How to Use the Component in a Circuit

  1. Power Supply: Connect a 4.8V to 6.0V power source to the +5V Input (Pin 2) and Ground (Pin 1) to power the KK 2.1.5 Flight Controller.
  2. Receiver Connections: Connect the receiver outputs to the corresponding inputs on the flight controller (Pins 9-18).
  3. Motor Connections: Connect the motor electronic speed controllers (ESCs) to the Motor Outputs (Pins 3-8).
  4. Calibration: Before the first flight, calibrate the sensors through the onboard menu system.
  5. Mounting: Secure the flight controller to the drone frame, ensuring it is level and free from vibration.

Important Considerations and Best Practices

Troubleshooting and FAQs

Common Issues

Solutions and Tips for Troubleshooting

FAQs

Q: Can I use a different type of receiver with the KK 2.1.5? A: Yes, the KK 2.1.5 is compatible with various receivers as long as they can connect to the standard input pins.

Q: How do I update the firmware on the KK 2.1.5? A: Firmware updates can be performed using a USBasp AVR programming device and the appropriate software tool.

Q: What should I do if the flight controller does not power on? A: Check the power supply connections, ensure the battery is charged, and inspect the board for any signs of damage.

For further assistance, consult the KK 2.1.5 Flight Controller community forums and support resources.

(Note: This documentation is a generic guide and may not cover all aspects of the KK 2.1.5 Flight Controller. Always refer to the manufacturer's official documentation for the most accurate and detailed information.)