The TMC2209 is a stepper motor driver IC manufactured by Fysetec (Part ID: V4.0). It is designed for high-performance applications requiring precise and silent motor control. The TMC2209 features advanced technologies such as StealthChop2 for silent operation, SpreadCycle for high torque, and StallGuard4 for sensorless homing. These features make it an excellent choice for 3D printers, CNC machines, and other motion control systems.
Explore Projects Built with TMC2209
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
This circuit features an Arduino UNO microcontroller interfaced with a TCS3200 color sensor and an I2C LCD 16x2 display. The TCS3200 color sensor's output is connected to the Arduino's digital pin D12, and its frequency scaling pins (S0-S3) are connected to digital pins D8-D11 for configuration. The LCD display communicates with the Arduino via the I2C protocol, using A4 (SDA) and A5 (SCL) for data transfer, allowing the system to display color readings or other information from the sensor.
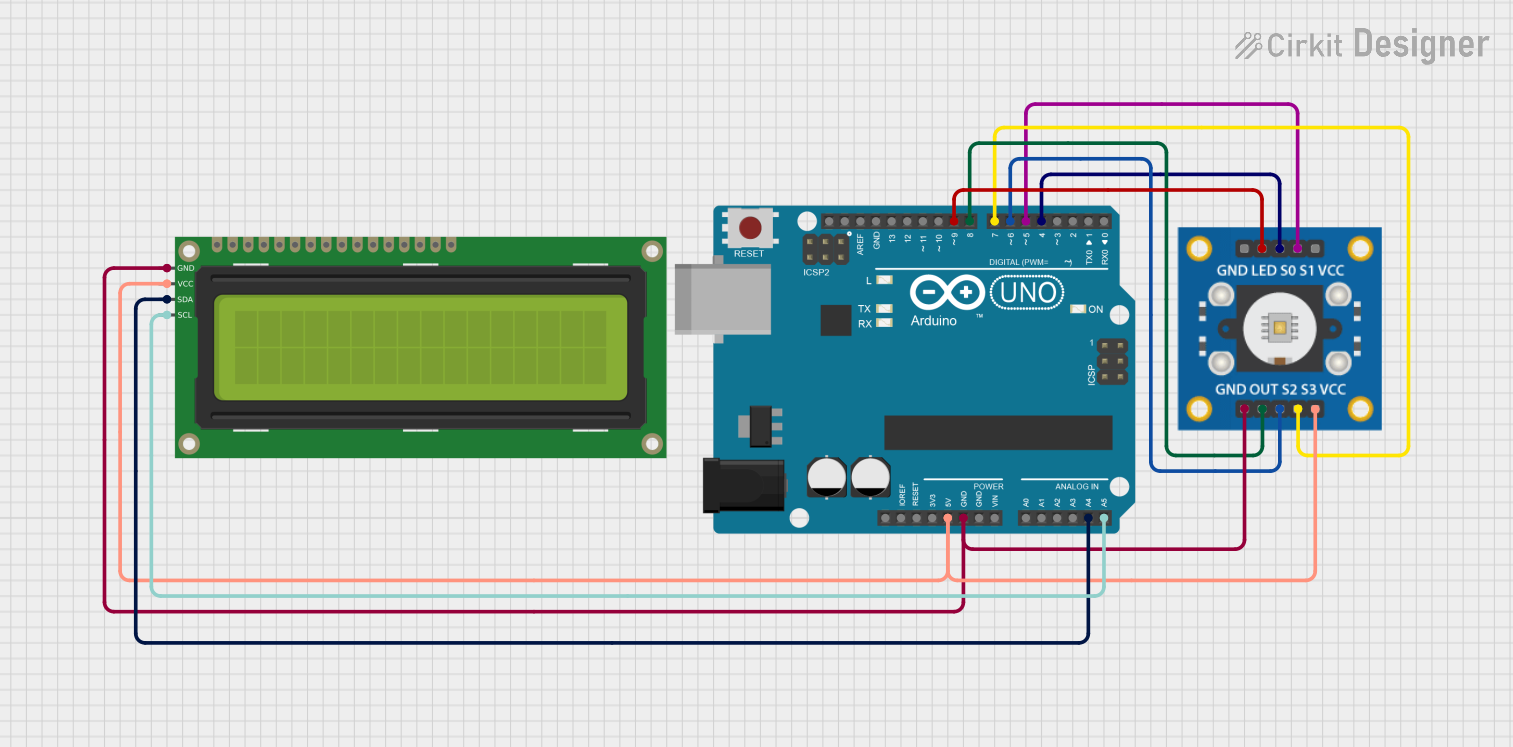
This circuit features an Arduino UNO microcontroller connected to a 16x2 I2C LCD display and a TCS3200 color sensor. The Arduino powers both the LCD and the color sensor, communicates with the LCD via I2C (using A4 and A5 pins for SDA and SCL), and interfaces with the TCS3200 using digital pins D4 to D9 to control the sensor and read its output. The purpose of this circuit is likely to read color information with the TCS3200 and display it on the LCD screen.
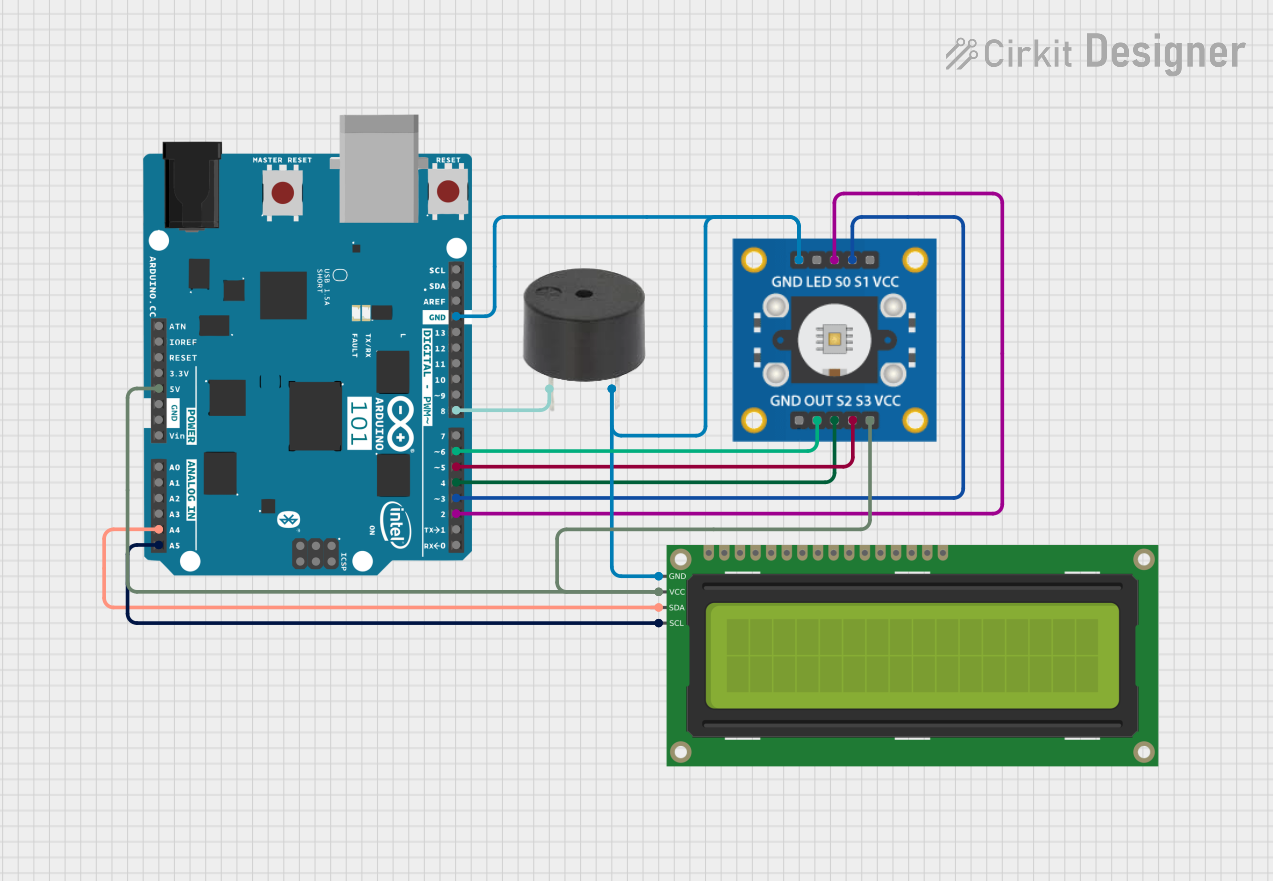
This circuit features an Arduino 101 microcontroller connected to a TCS3200 color sensor and a 16x2 I2C LCD display for output. The Arduino is configured to communicate with the LCD via I2C (using A4/SDA and A5/SCL pins for data exchange) and to receive color frequency signals from the TCS3200 on its D6 PWM pin. Additionally, a buzzer is connected to the D8 pin of the Arduino, potentially for audio signaling based on color detection or other programmed conditions.
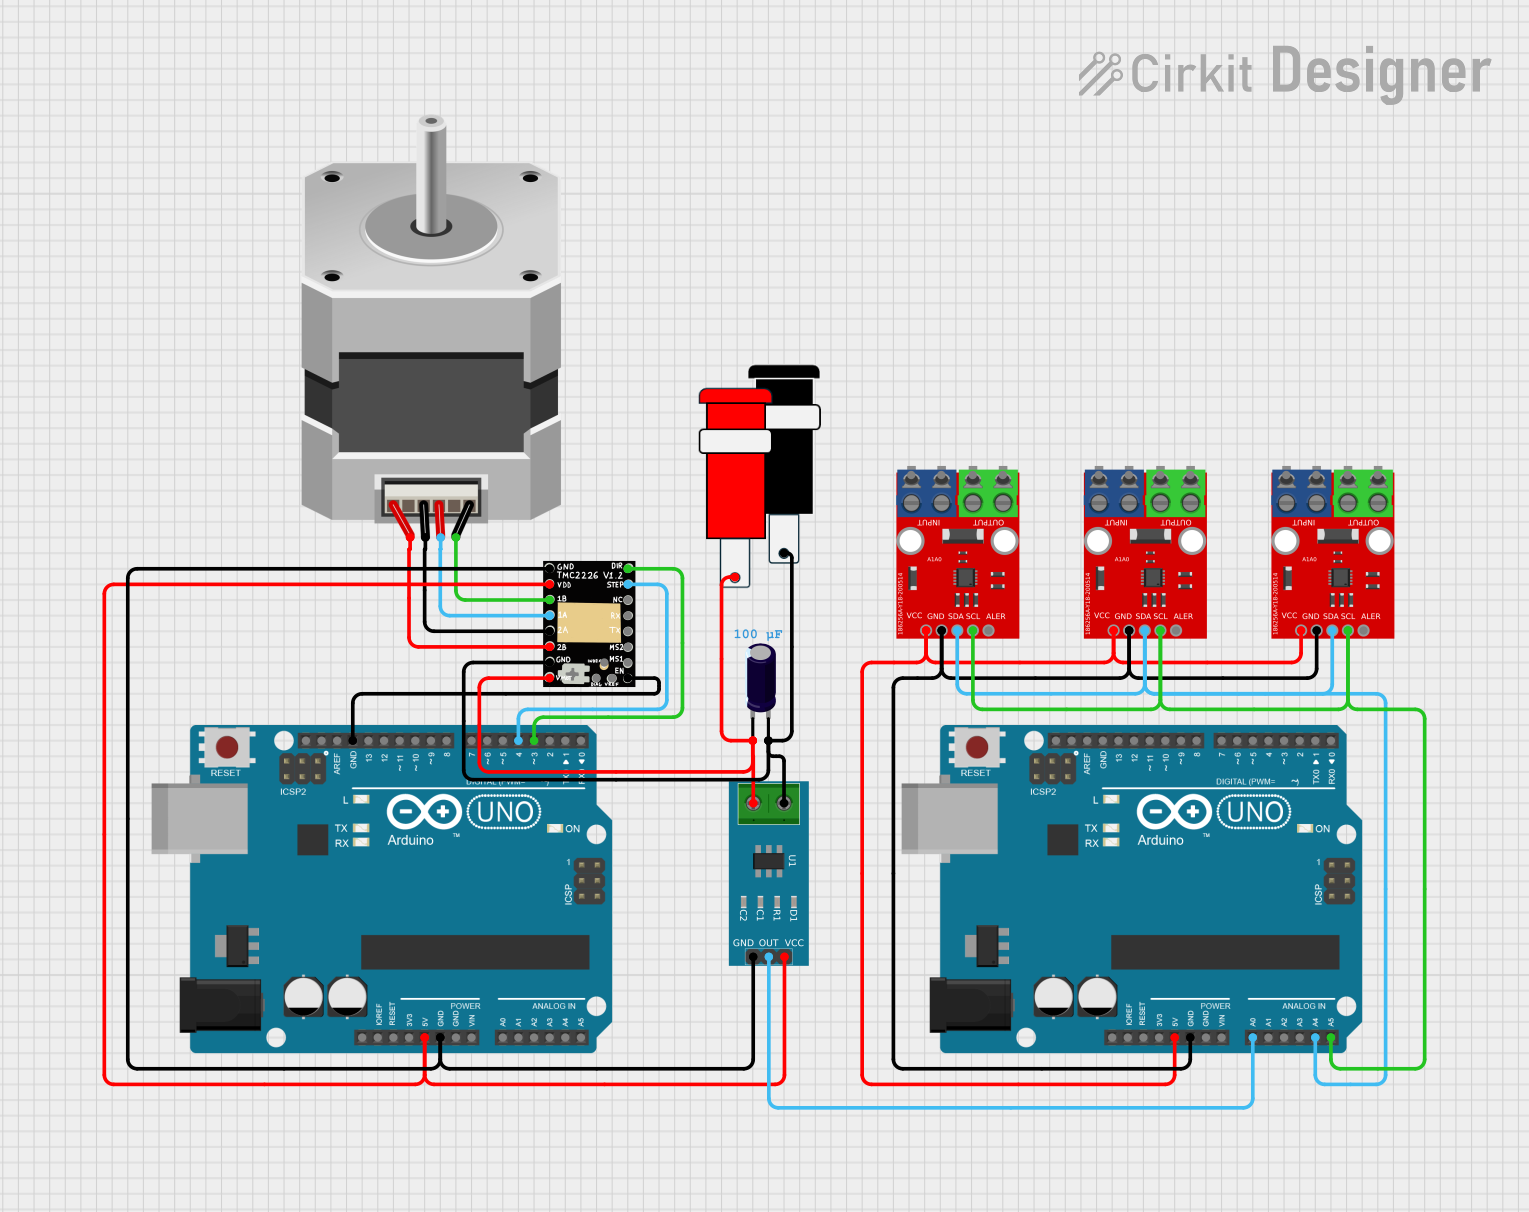
This circuit controls a bipolar stepper motor using a TMC2226 stepper driver, which is managed by an Arduino UNO. The circuit also includes a current sensor to monitor the motor's current, and multiple Nazarbayev University components are interconnected for additional functionality. Power is supplied through a 5V connector, and an electrolytic capacitor is used for voltage stabilization.
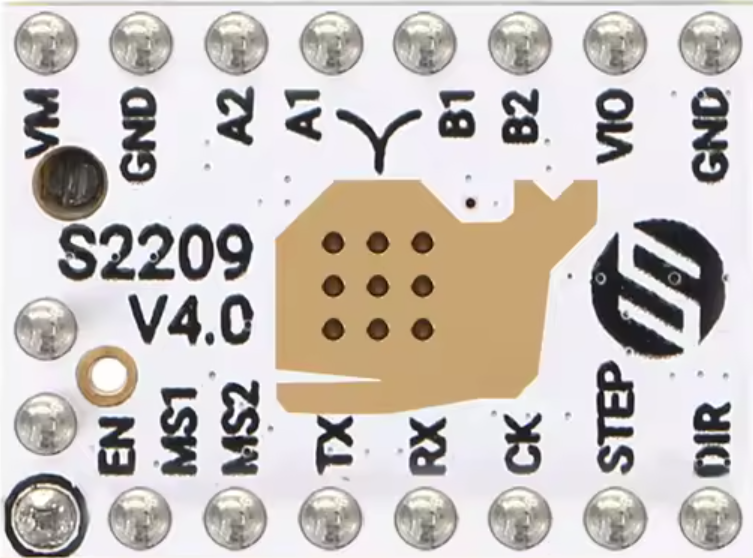
The TMC2209 is typically available in a 28-pin package. Below is the pin configuration and description:
Pin Number
Pin Name
Description
1
VCC_IO
Logic voltage input (3.3V or 5V)
2
GND
Ground
3
VM
Motor power supply (4.75V to 29V)
4
ENN
Enable input (active low)
5
DIR
Direction control input
6
STEP
Step pulse input
7
UART_TX
UART transmit pin
8
UART_RX
UART receive pin
9
MS1
Microstepping resolution select (MS1)
10
MS2
Microstepping resolution select (MS2)
11
DIAG
Diagnostic output
12
INDEX
Microstep position indicator
13
VREF
Reference voltage for current setting
14
NC
Not connected
Note: The remaining pins are typically used for internal functions or are not connected. Refer to the manufacturer's datasheet for a complete pinout.
Usage Instructions
How to Use the TMC2209 in a Circuit
Power Supply: Connect the motor power supply (VM) to a voltage source between 4.75V and 29V. Ensure the logic voltage (VCC_IO) matches your microcontroller's logic level (3.3V or 5V).
Microstepping Configuration: Use the MS1 and MS2 pins to set the desired microstepping resolution. For example:
MS1 = LOW, MS2 = LOW: Full step
MS1 = HIGH, MS2 = LOW: Half step
MS1 = HIGH, MS2 = HIGH: 1/16 step
Control Signals: Connect the STEP and DIR pins to your microcontroller for step and direction control.
UART Communication: For advanced features like StallGuard4 and CoolStep, connect the UART_TX and UART_RX pins to your microcontroller's UART interface.
Current Setting: Adjust the VREF pin to set the motor current. Use the formula provided in the datasheet to calculate the appropriate VREF voltage.
Important Considerations
Cooling: The TMC2209 can generate heat during operation. Use a heatsink or active cooling if necessary.
Decoupling Capacitors: Place decoupling capacitors close to the VM and VCC_IO pins to ensure stable operation.
Motor Compatibility: Ensure the stepper motor's current rating matches the TMC2209's capabilities.
Example: Using TMC2209 with Arduino UNO
Below is an example of how to control the TMC2209 using an Arduino UNO:
// Example code to control TMC2209 with Arduino UNO
// This code assumes the TMC2209 is connected in STEP/DIR mode

#define STEP_PIN 3  // Pin connected to STEP
#define DIR_PIN 4   // Pin connected to DIR
#define ENABLE_PIN 5 // Pin connected to ENN (active low)

void setup() {
  pinMode(STEP_PIN, OUTPUT);  // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);   // Set DIR pin as output
  pinMode(ENABLE_PIN, OUTPUT); // Set ENABLE pin as output

  digitalWrite(ENABLE_PIN, LOW); // Enable the driver (ENN is active low)
  digitalWrite(DIR_PIN, HIGH);   // Set direction (HIGH or LOW)
}

void loop() {
  // Generate step pulses
  digitalWrite(STEP_PIN, HIGH);  // Set STEP pin HIGH
  delayMicroseconds(500);        // Wait 500 microseconds
  digitalWrite(STEP_PIN, LOW);   // Set STEP pin LOW
  delayMicroseconds(500);        // Wait 500 microseconds
}
Note: Adjust the delayMicroseconds value to control the motor speed.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check all connections and ensure the power supply meets the voltage and current requirements.
Overheating
Cause: Excessive motor current or inadequate cooling.
Solution: Reduce the motor current by adjusting the VREF pin and add a heatsink or fan.
No UART Communication
Cause: Incorrect UART wiring or baud rate mismatch.
Solution: Verify the UART connections and ensure the baud rate matches the microcontroller's settings.
Stepper Motor Vibrates but Does Not Rotate
Cause: Incorrect microstepping configuration or insufficient current.
Solution: Check the MS1 and MS2 pin settings and adjust the motor current.
FAQs
Q: Can the TMC2209 operate without UART?
A: Yes, the TMC2209 can operate in standalone mode using STEP/DIR control without UART.
Q: What is the maximum microstepping resolution?
A: The TMC2209 supports up to 1/256 microstepping.
Q: How do I enable sensorless homing?
A: Sensorless homing requires UART communication to configure the StallGuard4 feature. Refer to the datasheet for detailed instructions.
Q: Can I use the TMC2209 with a 12V power supply?
A: Yes, the TMC2209 supports motor power supply voltages between 4.75V and 29V, including 12V.
By following this documentation, you can effectively integrate the TMC2209 into your projects for precise and silent stepper motor control.


 Open Project in Cirkit Designer