Cirkit Designer LogoCirkit DesignerYour all-in-one circuit design IDE Launch Cirkit Designer App

How to Use motor and wheels: Examples, Pinouts, and Specs

Image of motor and wheelsDesign with motor and wheels in Cirkit Designer

Introduction

Explore Projects Built with motor and wheels

Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
Image of Battery-Powered Dual Gearmotor Drive System: A project utilizing motor and wheels in a practical application

Battery-Powered Dual Gearmotor Drive System

This circuit consists of a 6V battery pack connected in parallel to two DC gearmotors, one for the left wheel and one for the right wheel of a vehicle. The battery provides power directly to both motors, enabling them to run simultaneously. As there is no control circuitry or microcontroller code provided, the motors will run continuously when the circuit is powered.

Open Project in Cirkit Designer
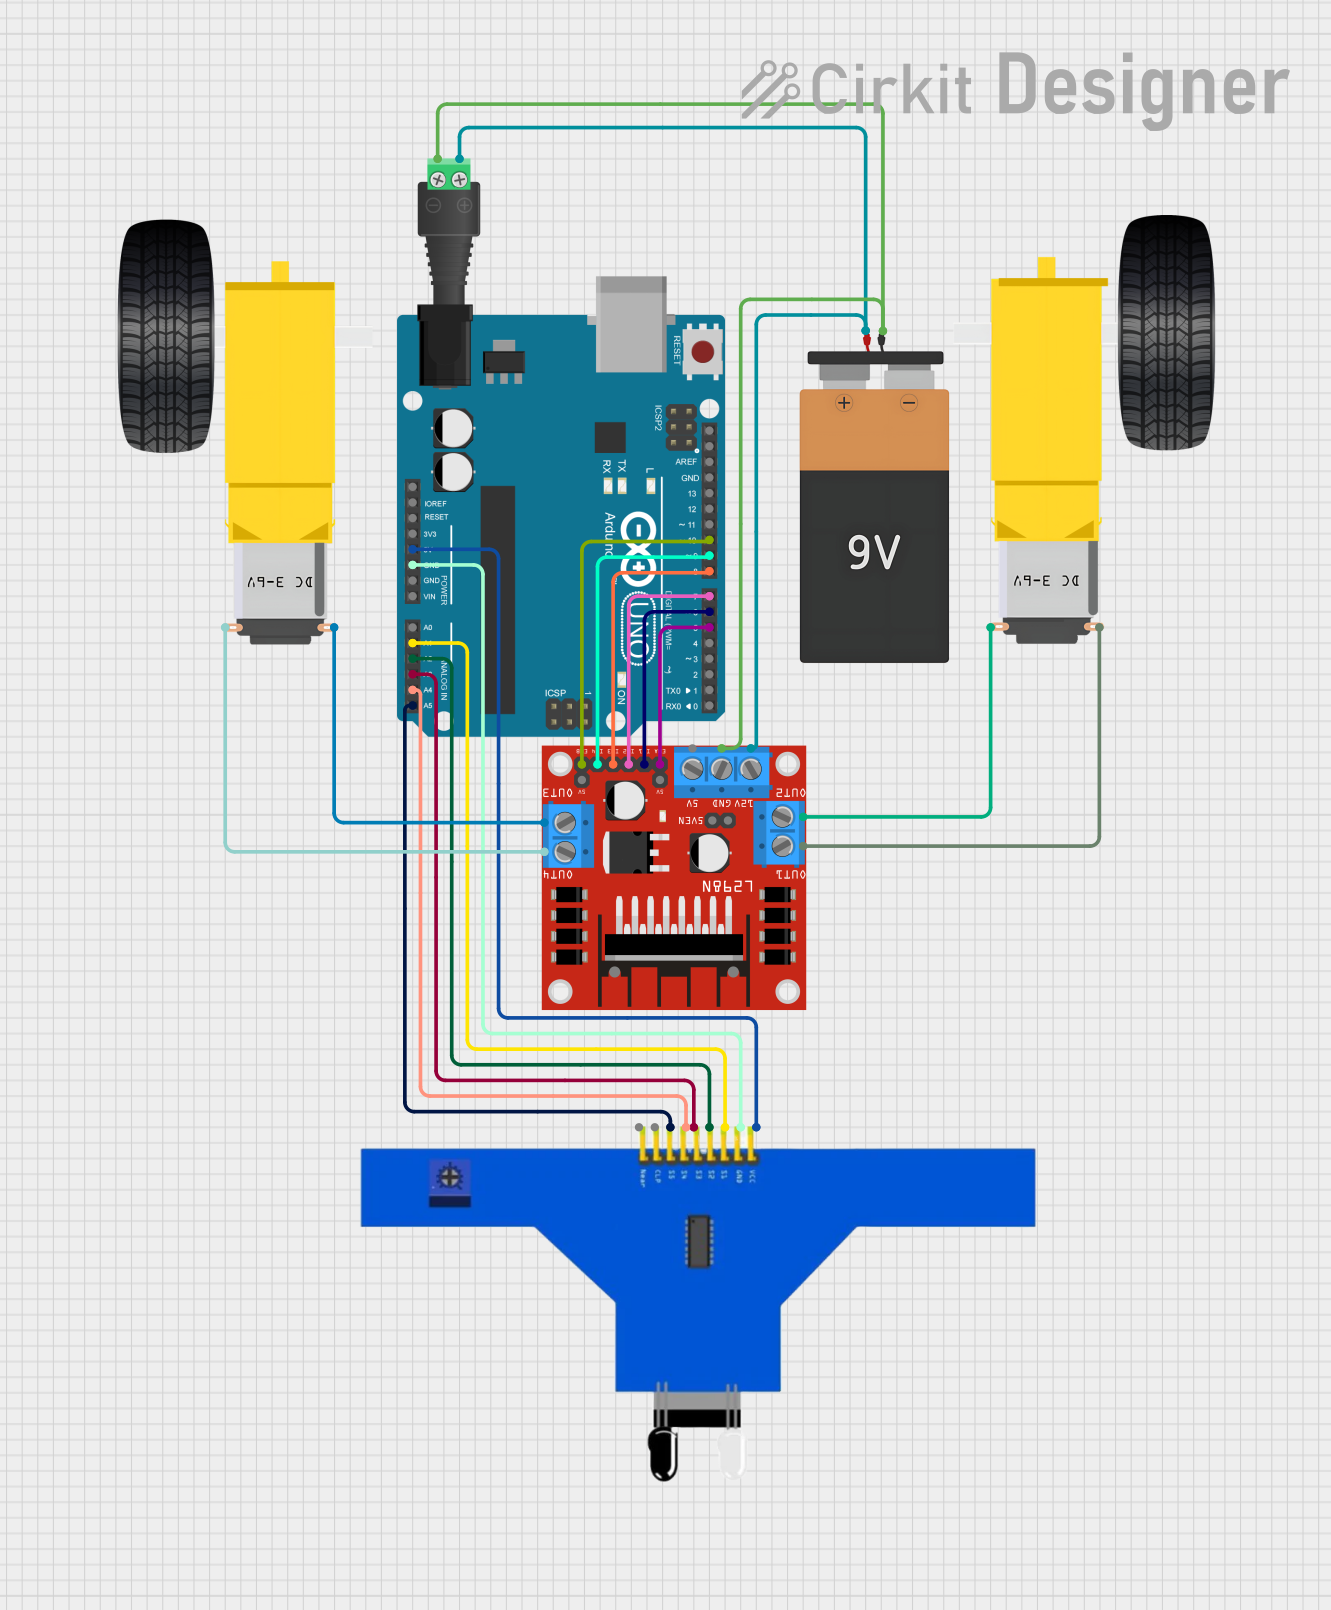
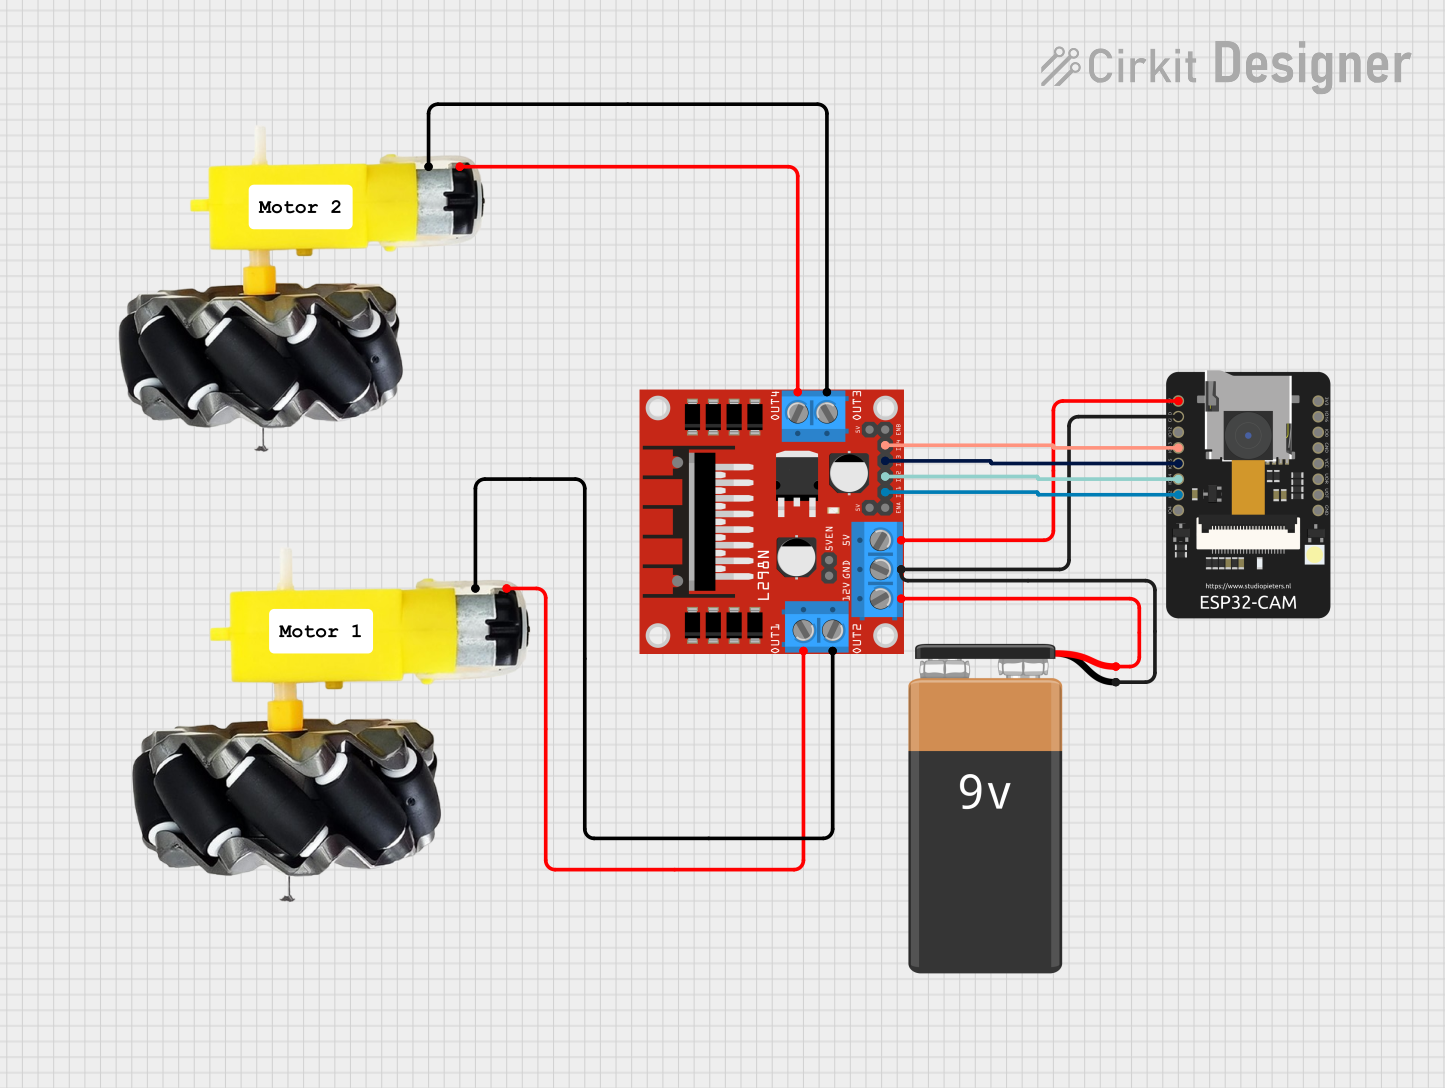
Image of Arduino-Controlled Robotic Vehicle with IR Sensors and L298N Motor Driver: A project utilizing motor and wheels in a practical application
Arduino-Controlled Robotic Vehicle with IR Sensors and L298N Motor Driver

This circuit is designed to control a pair of DC gearmotors using an L298N motor driver module, which is interfaced with an Arduino UNO microcontroller. The Arduino is also connected to a 5-channel IR sensor for input, which may be used for line tracking or obstacle detection. Power is supplied by a 9V battery connected through a 2.1mm barrel jack, and the motor driver module regulates this power to drive the left and right gearmotors for a mobile robot platform.

Open Project in Cirkit Designer
Image of ESP32-CAM Controlled Wi-Fi Robot Car: A project utilizing motor and wheels in a practical application
ESP32-CAM Controlled Wi-Fi Robot Car

This circuit is designed to control a two-wheel motorized vehicle using an ESP32-CAM microcontroller. The ESP32-CAM is interfaced with an L298N DC motor driver to control the direction and speed of the motors attached to the wheels. Additionally, the ESP32-CAM is configured to capture images and provide WiFi connectivity for remote control via a web server with a user interface for driving commands.

Open Project in Cirkit Designer

Technical Specifications

Pin Configuration and Descriptions

For a typical DC motor with two terminals:

Pin Name Description
V+ Positive terminal for motor power
V- Negative terminal for motor power

For a stepper motor (4-wire configuration):

Pin Name Description
A+ Coil A positive terminal
A- Coil A negative terminal
B+ Coil B positive terminal
B- Coil B negative terminal

Usage Instructions

How to Use the Component in a Circuit

  1. Connecting a DC Motor:

    • Use an H-bridge motor driver (e.g., L298N or L293D) to control the motor's direction and speed.
    • Connect the motor terminals (V+ and V-) to the motor output pins of the driver.
    • Supply appropriate voltage to the motor driver and control it using a microcontroller (e.g., Arduino).
  2. Connecting a Stepper Motor:

    • Use a stepper motor driver (e.g., ULN2003 or A4988) to control the stepper motor.
    • Connect the motor's coil terminals (A+, A-, B+, B-) to the driver's output pins.
    • Supply the required voltage to the driver and control the motor using step pulses from a microcontroller.

Important Considerations and Best Practices

Example Code for Arduino UNO (DC Motor Control)

// Example code to control a DC motor using an L298N motor driver
// Connect IN1 and IN2 of the motor driver to Arduino pins 9 and 10

#define IN1 9  // Motor driver input pin 1
#define IN2 10 // Motor driver input pin 2

void setup() {
  pinMode(IN1, OUTPUT); // Set IN1 as output
  pinMode(IN2, OUTPUT); // Set IN2 as output
}

void loop() {
  // Rotate motor forward
  digitalWrite(IN1, HIGH); // Set IN1 high
  digitalWrite(IN2, LOW);  // Set IN2 low
  delay(2000);             // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);  // Set IN1 low
  digitalWrite(IN2, LOW);  // Set IN2 low
  delay(1000);             // Wait for 1 second

  // Rotate motor backward
  digitalWrite(IN1, LOW);  // Set IN1 low
  digitalWrite(IN2, HIGH); // Set IN2 high
  delay(2000);             // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);  // Set IN1 low
  digitalWrite(IN2, LOW);  // Set IN2 low
  delay(1000);             // Wait for 1 second
}

Troubleshooting and FAQs

Common Issues

  1. Motor Not Spinning:

    • Check the power supply voltage and ensure it matches the motor's requirements.
    • Verify the motor driver connections and ensure the control signals are correct.
    • Inspect the motor for physical damage or obstructions.
  2. Motor Spins in One Direction Only:

    • Ensure both control pins (e.g., IN1 and IN2) are properly connected to the microcontroller.
    • Check the motor driver for faults or loose connections.
  3. Stepper Motor Skipping Steps:

    • Verify the step sequence and ensure the microcontroller is sending the correct signals.
    • Check the power supply and ensure it provides sufficient current for the motor.
  4. Wheels Slipping:

    • Use wheels with better traction or adjust the weight distribution of the robot.

Solutions and Tips for Troubleshooting