How to Use MPU6050: Examples, Pinouts, and Specs
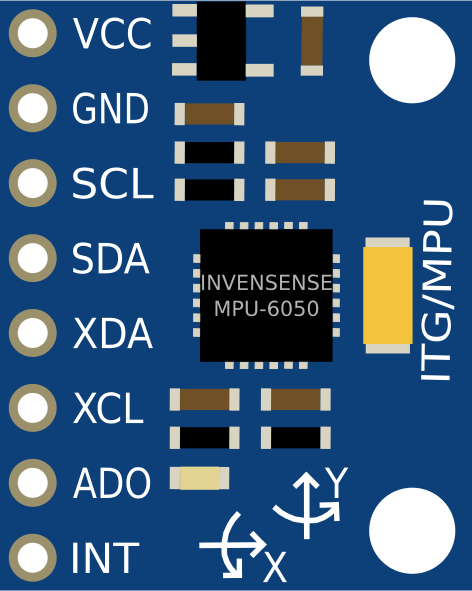
 Design with MPU6050 in Cirkit Designer
Introduction
The MPU6050 is a 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer on a single chip. This compact and versatile sensor is widely used in applications requiring motion sensing and orientation detection. Its ability to measure angular velocity and linear acceleration makes it ideal for robotics, drones, smartphones, gaming devices, and wearable technology. Additionally, the MPU6050 features a Digital Motion Processor (DMP) that can process complex motion algorithms internally, reducing the computational load on the host microcontroller.
Explore Projects Built with MPU6050
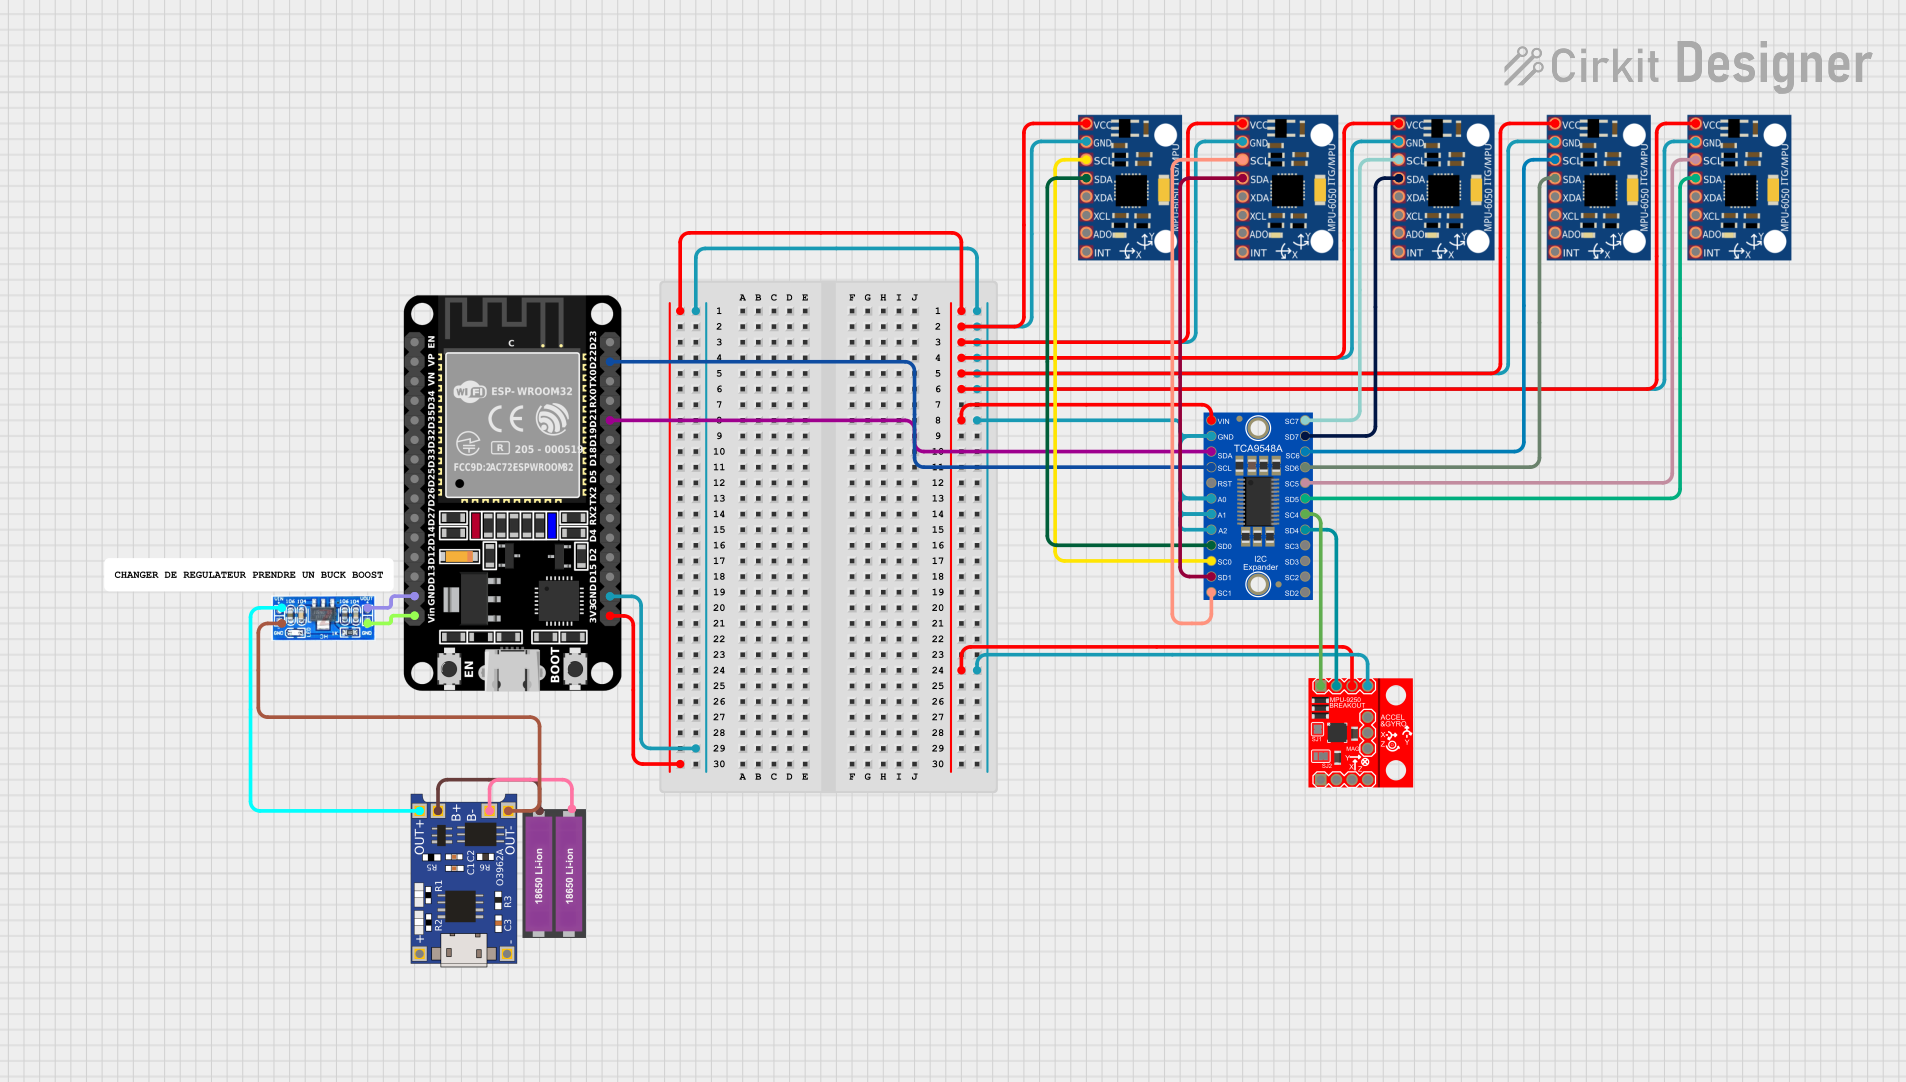 Open Project in Cirkit Designer
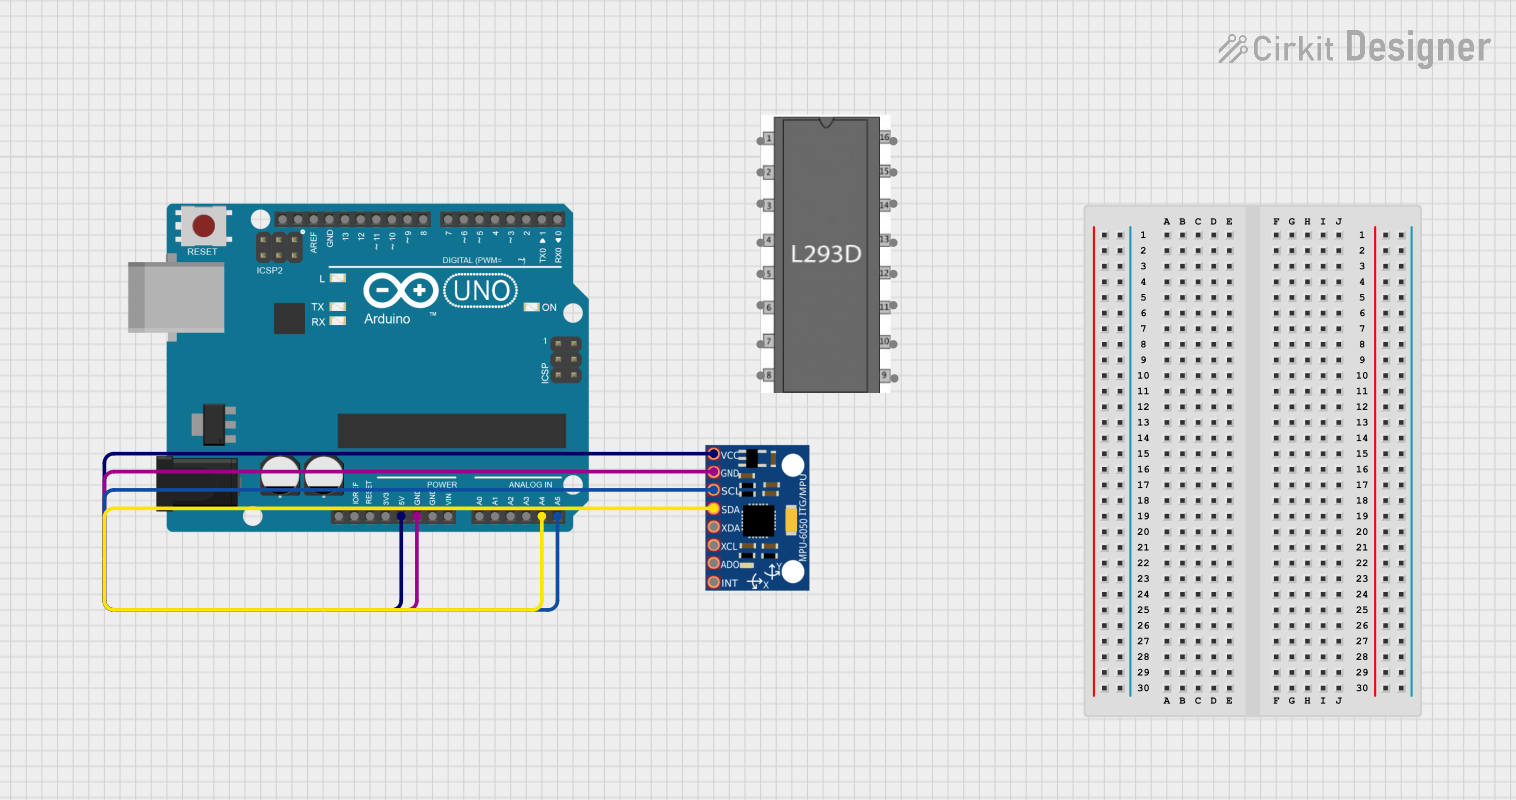 Open Project in Cirkit Designer
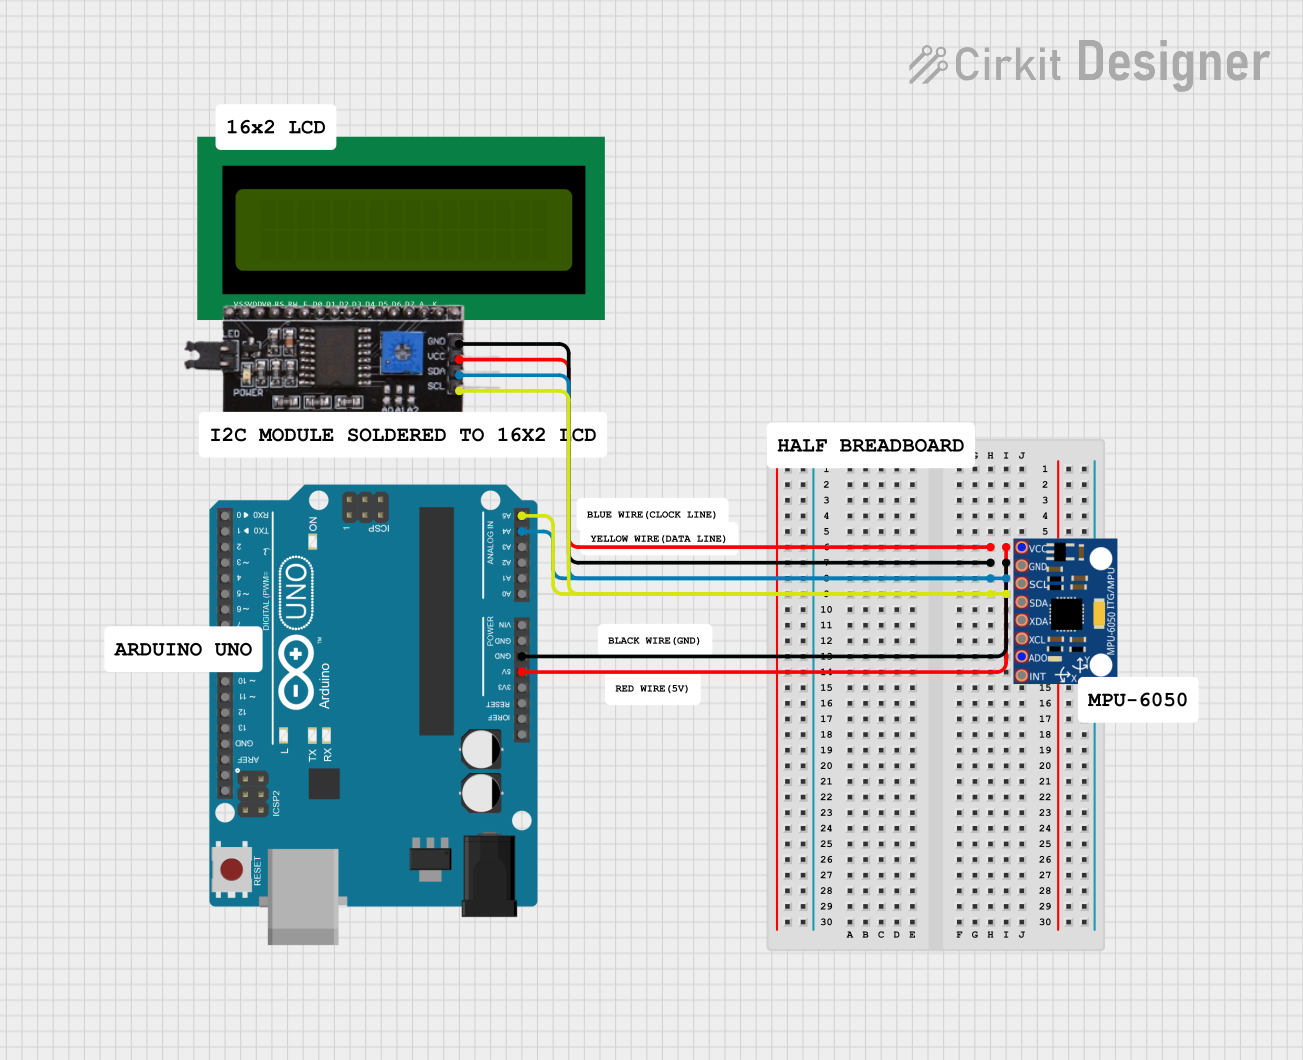 Open Project in Cirkit Designer
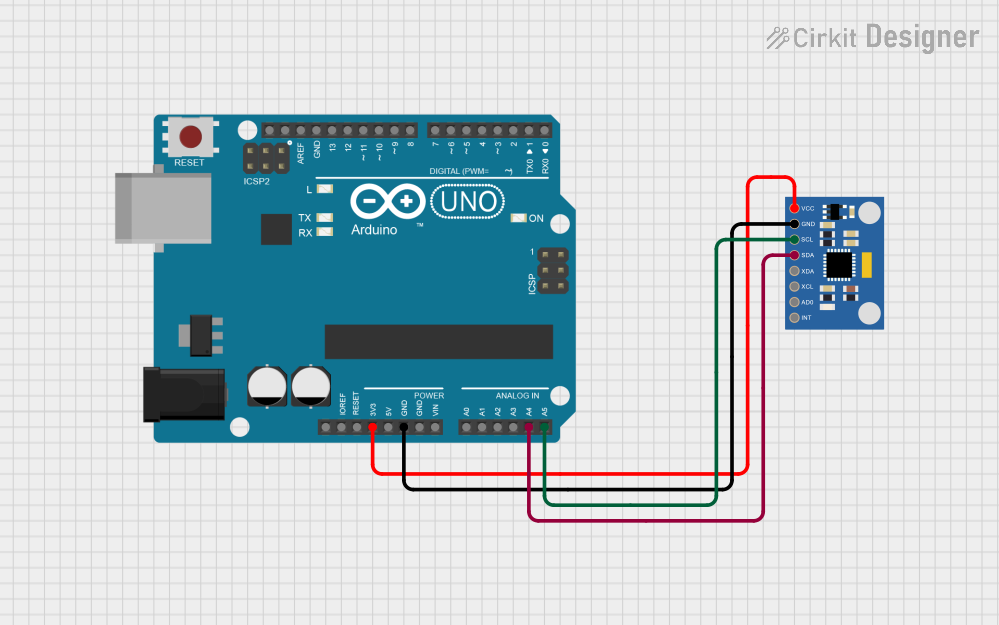 Open Project in Cirkit Designer
Explore Projects Built with MPU6050
Open Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerTechnical Specifications
The following are the key technical details of the MPU6050:
- Supply Voltage: 2.375V to 3.46V (typically 3.3V)
- Communication Interface: I2C (up to 400kHz)
- Gyroscope Range: ±250, ±500, ±1000, ±2000 degrees/second
- Accelerometer Range: ±2g, ±4g, ±8g, ±16g
- Operating Temperature: -40°C to +85°C
- Power Consumption: 3.9mA (typical in active mode)
- Package: 4x4x0.9mm QFN
Pin Configuration and Descriptions
The MPU6050 has 8 pins, as described in the table below:
| Pin Number | Pin Name | Description |
|---|---|---|
| 1 | VDD | Power supply input (2.375V to 3.46V) |
| 2 | VLOGIC | Logic voltage level input (1.8V to VDD) |
| 3 | GND | Ground connection |
| 4 | SCL | I2C clock input |
| 5 | SDA | I2C data input/output |
| 6 | AD0 | I2C address select (connect to GND for 0x68 or VDD for 0x69) |
| 7 | INT | Interrupt output (active high, used for motion detection or data ready) |
| 8 | FSYNC | Frame synchronization input (optional, used for external sync signals) |
Usage Instructions
Connecting the MPU6050 to a Circuit
- Power Supply: Connect the VDD pin to a 3.3V power source and the GND pin to ground.
- Logic Level: If your microcontroller operates at 5V logic, use a level shifter for the I2C lines (SCL and SDA).
- I2C Communication: Connect the SCL and SDA pins to the corresponding I2C pins on your microcontroller. Pull-up resistors (typically 4.7kΩ) are required on the SCL and SDA lines.
- Address Selection: Connect the AD0 pin to GND for the default I2C address (0x68) or to VDD for an alternate address (0x69).
- Interrupt Pin: Optionally, connect the INT pin to a GPIO pin on your microcontroller to handle interrupts.
Example Code for Arduino UNO
Below is an example of how to interface the MPU6050 with an Arduino UNO using the Wire library:
#include <Wire.h>

// MPU6050 I2C address (default is 0x68 when AD0 is connected to GND)
const int MPU6050_ADDR = 0x68;

// MPU6050 register addresses
const int PWR_MGMT_1 = 0x6B; // Power management register
const int ACCEL_XOUT_H = 0x3B; // Accelerometer X-axis high byte

void setup() {
  Wire.begin(); // Initialize I2C communication
  Serial.begin(9600); // Initialize serial communication for debugging

  // Wake up the MPU6050 (it starts in sleep mode)
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(PWR_MGMT_1); // Access power management register
  Wire.write(0); // Set to 0 to wake up the sensor
  Wire.endTransmission();

  Serial.println("MPU6050 initialized");
}

void loop() {
  // Request accelerometer data
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(ACCEL_XOUT_H); // Start reading from ACCEL_XOUT_H register
  Wire.endTransmission(false); // Send repeated start condition
  Wire.requestFrom(MPU6050_ADDR, 6); // Request 6 bytes (X, Y, Z high and low)

  if (Wire.available() == 6) {
    int16_t accelX = (Wire.read() << 8) | Wire.read(); // Combine high and low bytes
    int16_t accelY = (Wire.read() << 8) | Wire.read();
    int16_t accelZ = (Wire.read() << 8) | Wire.read();

    // Print accelerometer values
    Serial.print("Accel X: "); Serial.print(accelX);
    Serial.print(" | Accel Y: "); Serial.print(accelY);
    Serial.print(" | Accel Z: "); Serial.println(accelZ);
  }

  delay(500); // Wait 500ms before the next reading
}
Important Considerations
- Power Supply: Ensure the MPU6050 is powered within its specified voltage range to avoid damage.
- I2C Pull-Up Resistors: Use appropriate pull-up resistors on the SCL and SDA lines for reliable communication.
- Mounting Orientation: Properly align the sensor on your PCB to ensure accurate motion readings.
- Interrupts: Use the INT pin for applications requiring real-time motion detection or data-ready signals.
Troubleshooting and FAQs
Common Issues
No I2C Communication:
- Ensure the MPU6050 is powered correctly and the I2C lines have pull-up resistors.
- Verify the I2C address (0x68 or 0x69) matches your configuration.
- Check for loose or incorrect wiring.
Incorrect or No Data:
- Confirm the MPU6050 is initialized properly (e.g., wake-up command sent to PWR_MGMT_1).
- Ensure the sensor is not in sleep mode.
Unstable Readings:
- Minimize vibrations and noise in the environment.
- Use filtering techniques or the DMP for more stable data.
FAQs
Q: Can the MPU6050 be used with a 5V microcontroller?
A: Yes, but you must use a logic level shifter for the I2C lines (SCL and SDA) to avoid damaging the sensor.
Q: How do I calibrate the MPU6050?
A: Calibration involves determining and compensating for sensor offsets. This can be done by averaging readings when the sensor is stationary and subtracting the offsets from subsequent measurements.
Q: What is the purpose of the DMP?
A: The Digital Motion Processor (DMP) offloads complex motion processing tasks from the microcontroller, enabling features like sensor fusion and gesture recognition.
Q: Can I use the MPU6050 without the DMP?
A: Yes, you can directly read raw accelerometer and gyroscope data and process it in your microcontroller.