The GX Servo 200 is a high-performance servo motor manufactured by GX Servo, designed for applications requiring precise control and high torque output. Its robust design makes it ideal for use in robotics, automation systems, and other electromechanical projects. The GX Servo 200 is engineered to deliver reliable performance, even under demanding conditions, making it a popular choice for both hobbyists and professionals.
Explore Projects Built with GX servo 200
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
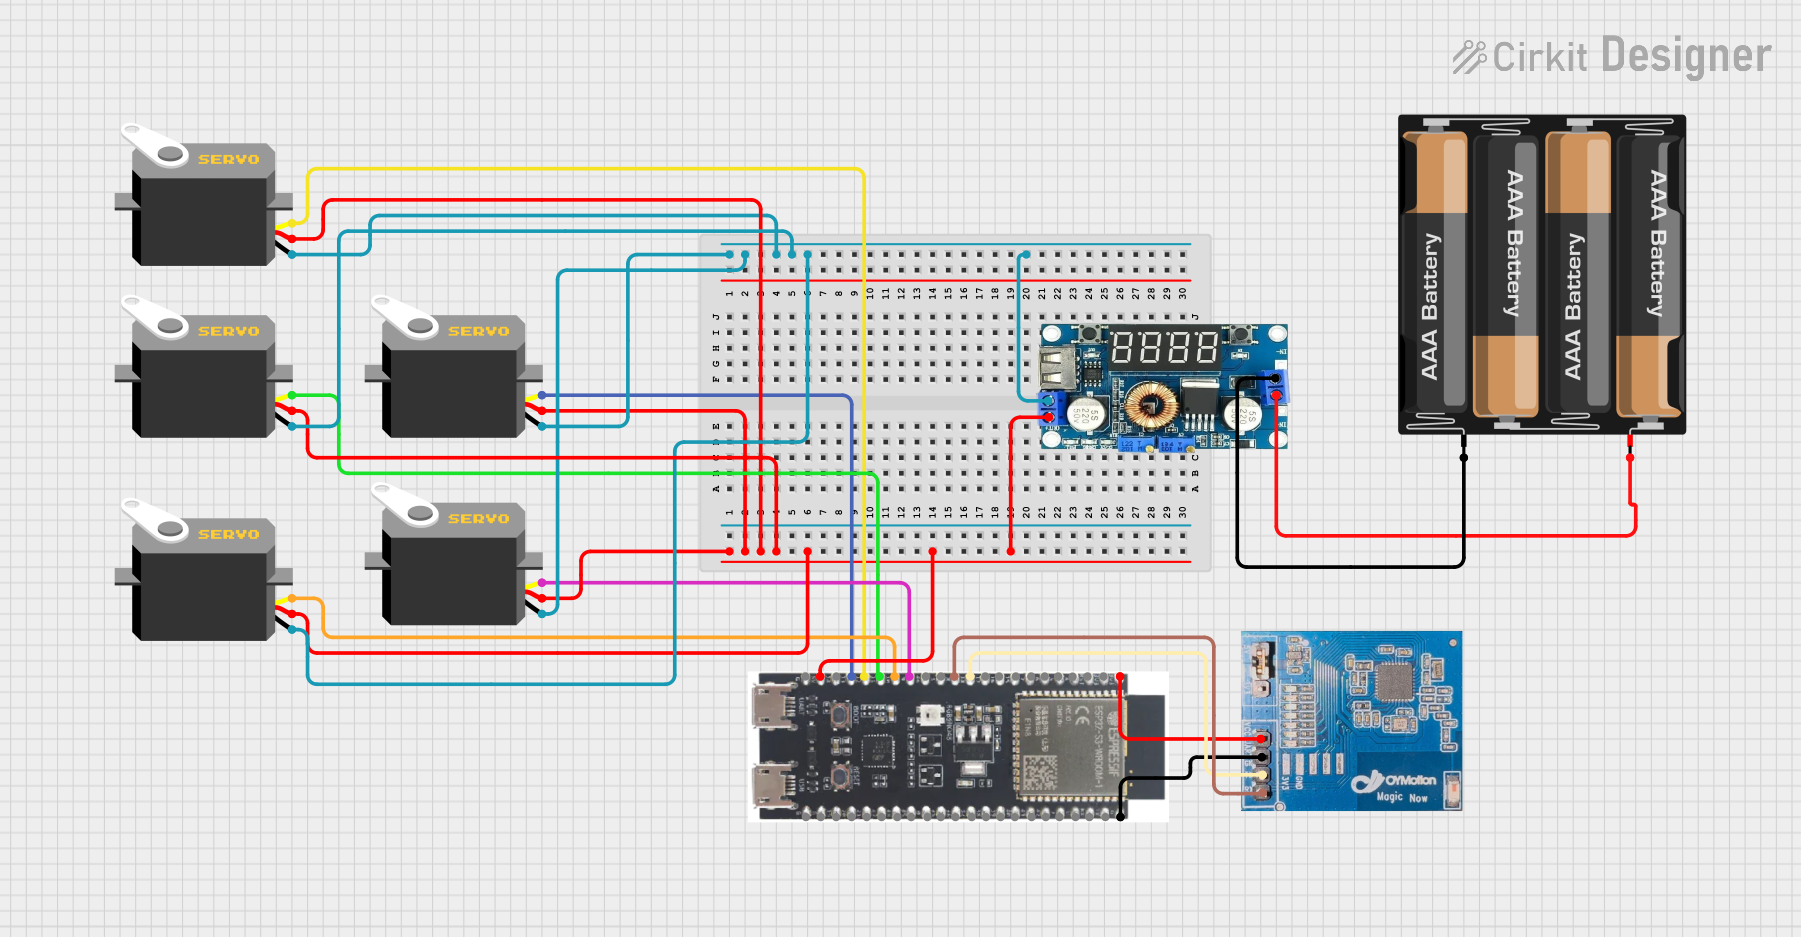
This circuit is a servo control system powered by a 4 x AAA battery pack, regulated by a step-down DC regulator. An ESP32-S3 microcontroller controls five servos and communicates with a gForceJoint UART sensor, enabling precise servo movements based on sensor inputs.
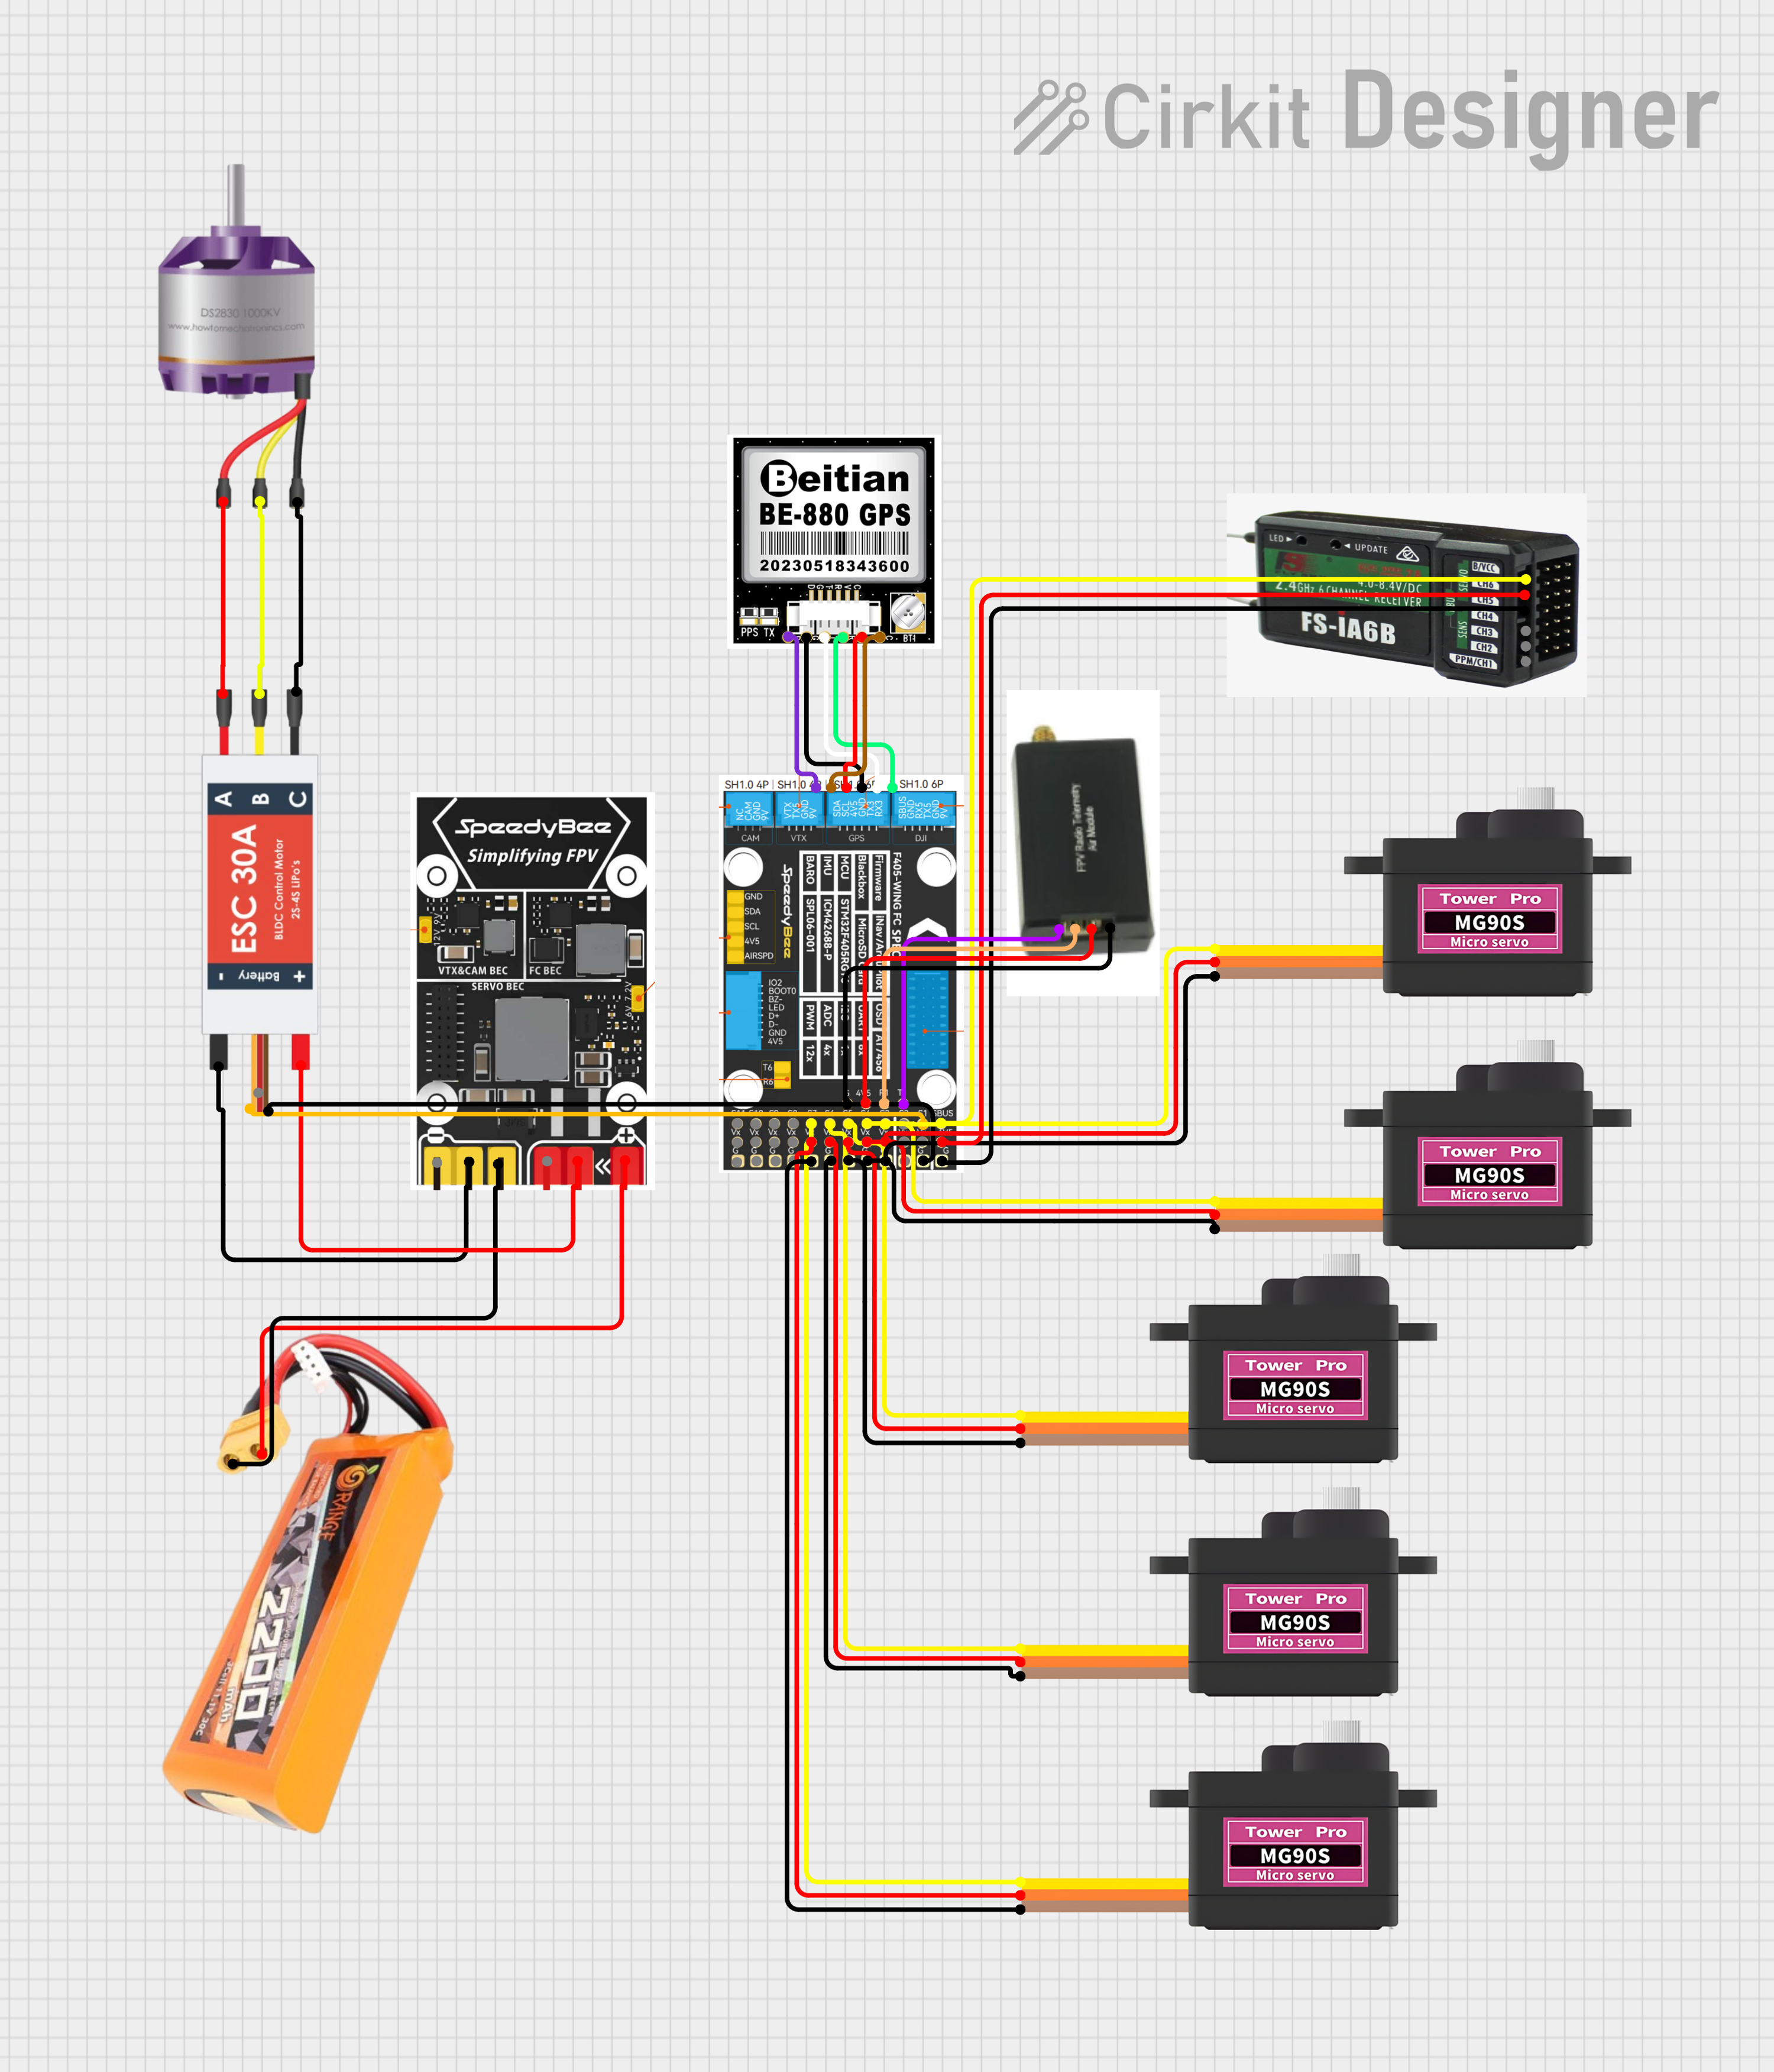
This circuit is designed for a remote-controlled vehicle or drone, featuring a flight controller that manages a brushless motor, servomotors for actuation, telemetry for data communication, and a GPS module for positioning. It is powered by a lipo battery and includes a receiver for remote control inputs.
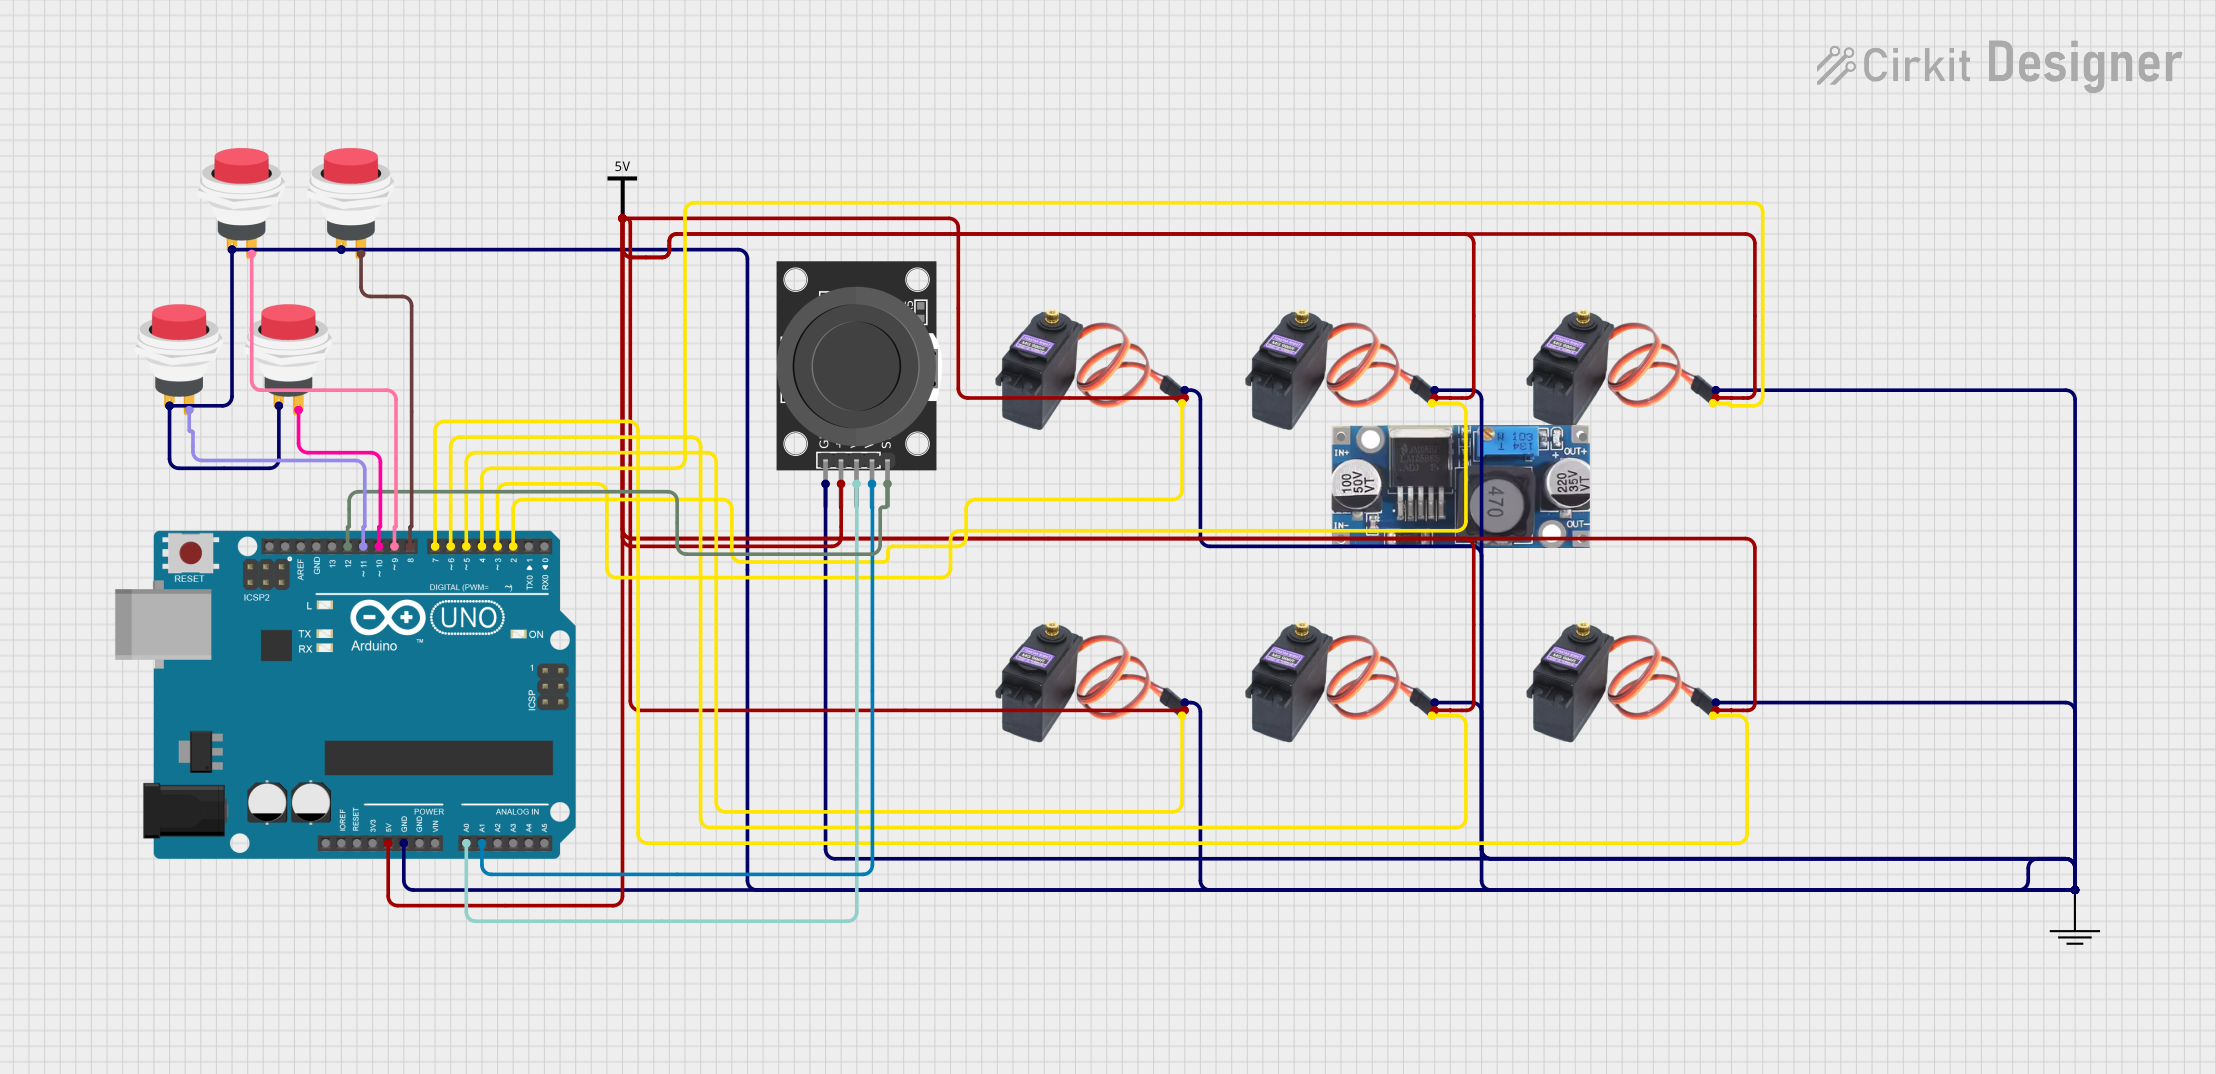
This is a servo control system featuring an Arduino UNO that processes input from a dual-axis joystick and push switches to operate multiple MG996R servo motors. It is designed for precise multi-axis control, potentially for applications like robotics or remote-controlled mechanisms.
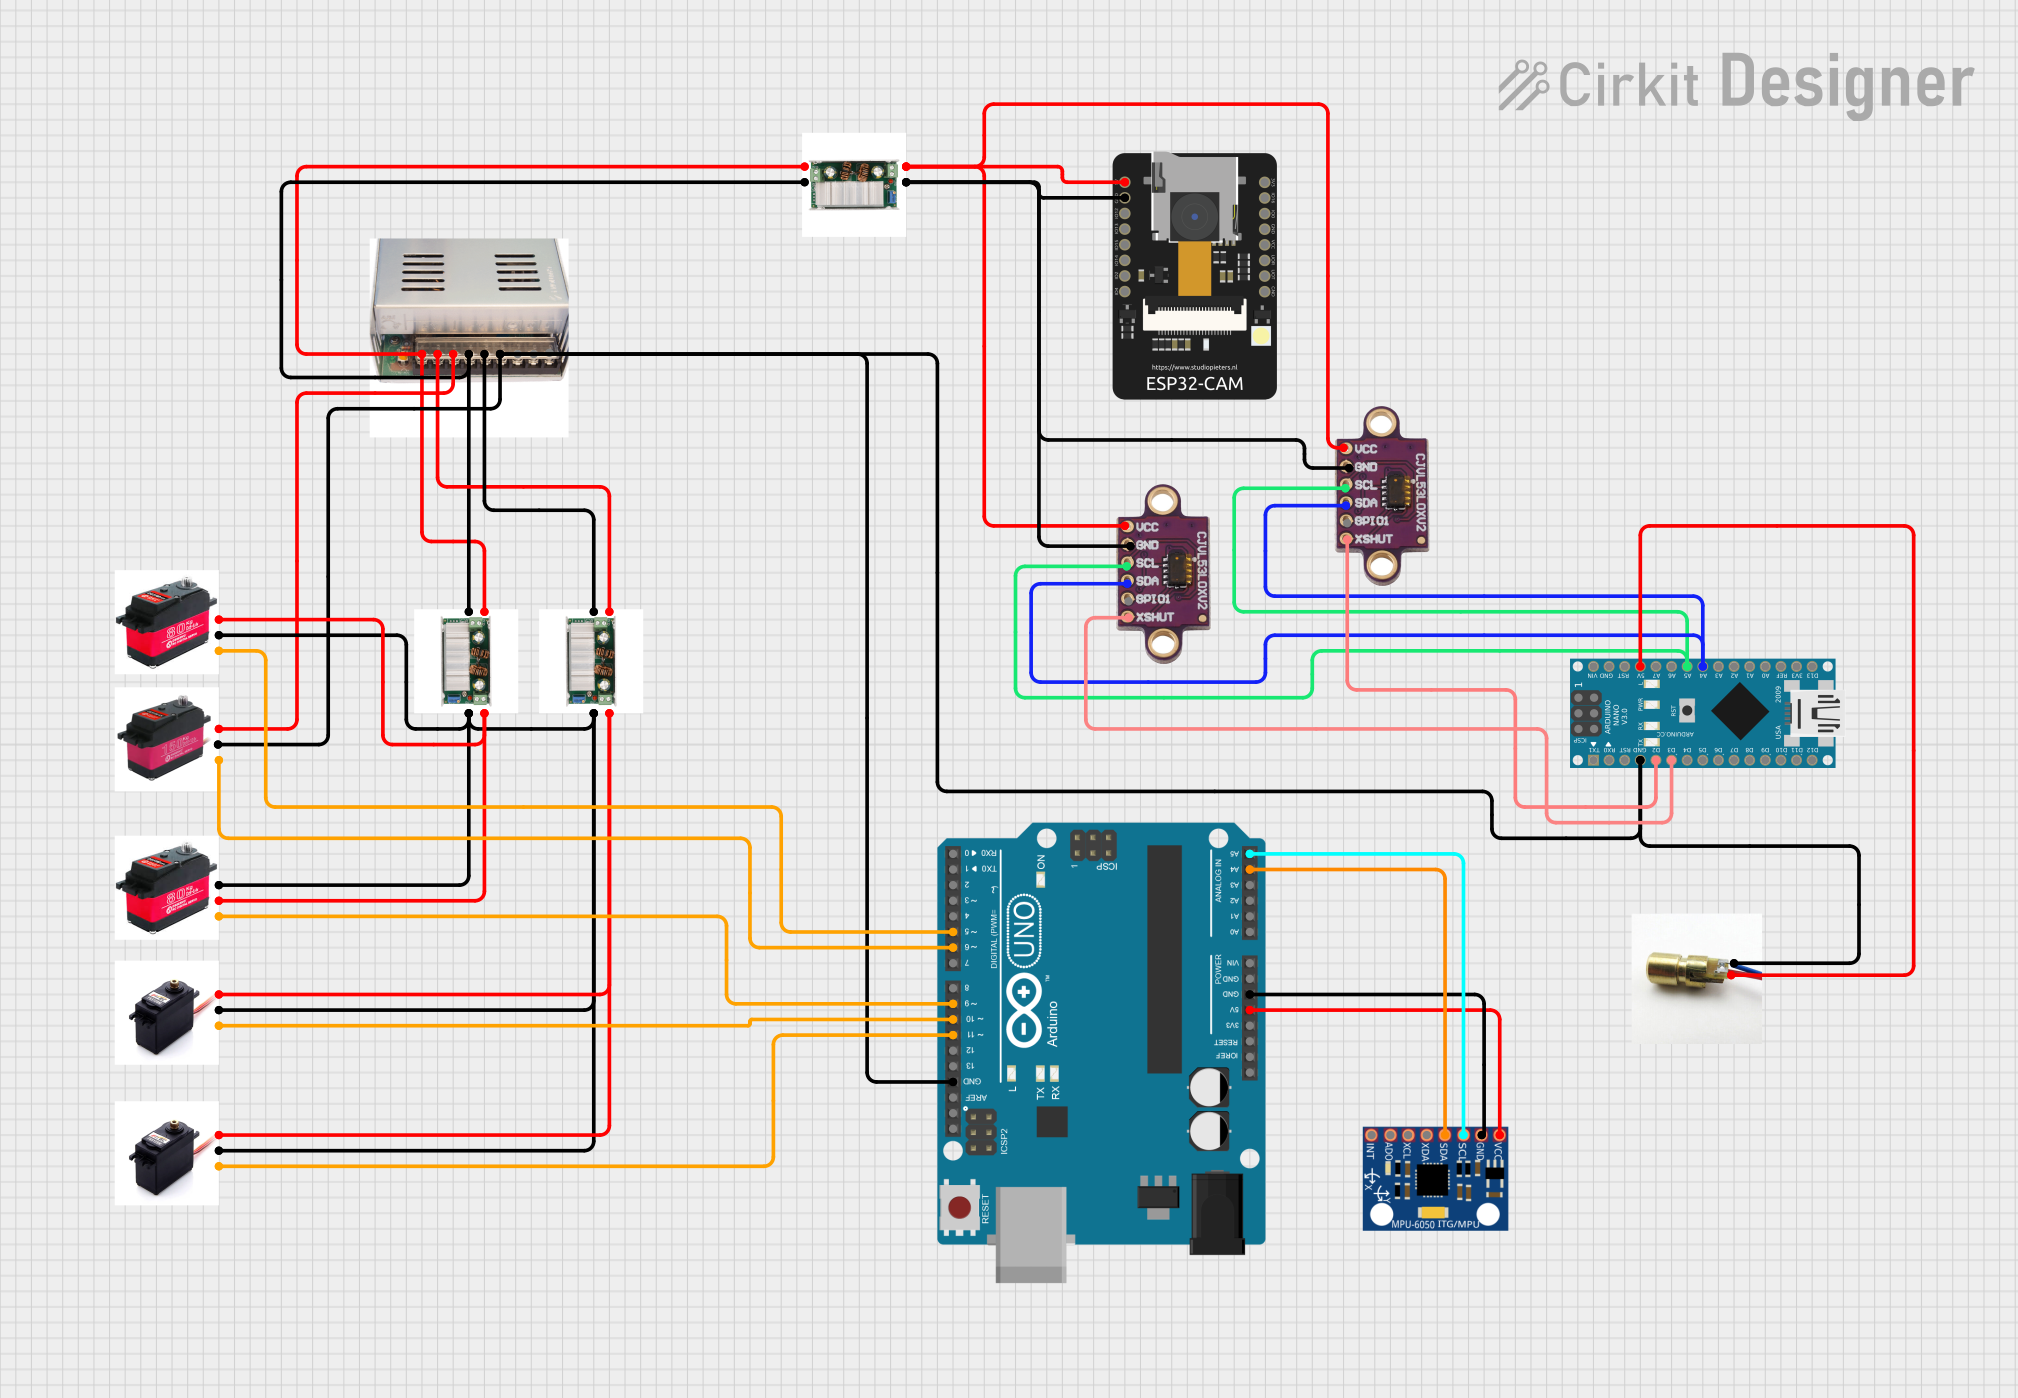
This circuit appears to be a servo motor control system with multiple servo motors of different torque ratings, powered by a 12V/30A DC power supply through DC-to-DC converters. It includes an Arduino UNO and an Arduino Nano for control logic, interfaced with an MPU-6050 for motion sensing and two vl53l0xv2 sensors for distance measurement. Additionally, there is an ESP32-CAM module for image capture and a laser diode, likely for positioning or targeting, all orchestrated by embedded code running on the microcontrollers.
The following table outlines the key technical details of the GX Servo 200:
Parameter
Value
Operating Voltage
4.8V to 7.4V
Stall Torque
20 kg·cm @ 6.0V, 25 kg·cm @ 7.4V
Operating Speed
0.16 sec/60° @ 6.0V, 0.14 sec/60° @ 7.4V
Control Signal
PWM (Pulse Width Modulation)
PWM Pulse Range
500 µs to 2500 µs
Dead Band Width
3 µs
Operating Temperature
-10°C to 50°C
Weight
60 g
Dimensions
40 mm x 20 mm x 40 mm
Pin Configuration
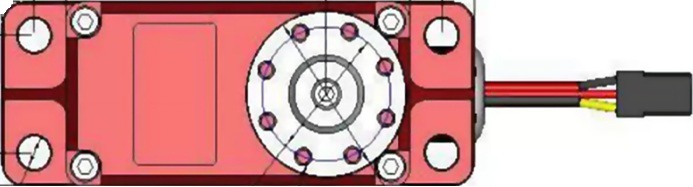
The GX Servo 200 has a standard 3-pin connector for interfacing with control systems. The pinout is as follows:
Pin
Wire Color
Function
1
Brown
Ground (GND)
2
Red
Power Supply (VCC)
3
Orange
Signal (PWM Input)
Usage Instructions
How to Use the GX Servo 200 in a Circuit
Power Supply: Connect the red wire to a regulated power source within the operating voltage range (4.8V to 7.4V). Ensure the power supply can provide sufficient current for the servo's operation.
Ground Connection: Connect the brown wire to the ground of your circuit.
Signal Input: Connect the orange wire to the PWM output pin of your microcontroller or servo controller. The PWM signal controls the servo's position.
Important Considerations
Voltage Range: Do not exceed the specified voltage range to avoid damaging the servo.
Current Requirements: Ensure your power supply can handle the peak current draw, especially under high torque conditions.
PWM Signal: Use a PWM signal with a pulse width between 500 µs (minimum position) and 2500 µs (maximum position). A 1500 µs pulse corresponds to the neutral (center) position.
Mounting: Secure the servo using appropriate screws and brackets to prevent movement during operation.
Heat Management: Avoid prolonged operation at stall torque to prevent overheating.
Example: Controlling the GX Servo 200 with an Arduino UNO
Below is an example code snippet to control the GX Servo 200 using an Arduino UNO:
#include <Servo.h> // Include the Servo library

Servo gxServo; // Create a Servo object to control the GX Servo 200

void setup() {
  gxServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  gxServo.write(0); // Move the servo to 0 degrees
  delay(1000); // Wait for 1 second

  gxServo.write(90); // Move the servo to 90 degrees
  delay(1000); // Wait for 1 second

  gxServo.write(180); // Move the servo to 180 degrees
  delay(1000); // Wait for 1 second
}
Code Explanation:
The Servo library is used to control the GX Servo 200.
The attach() function links the servo to a specific PWM pin on the Arduino.
The write() function sets the servo's position in degrees (0° to 180°).
Troubleshooting and FAQs
Common Issues and Solutions
Servo Not Moving:
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check the wiring and ensure the power supply meets the voltage and current requirements.
Erratic Movement:
Cause: Noise or interference in the PWM signal.
Solution: Use shielded cables for the signal wire and ensure a stable PWM signal from the controller.
Overheating:
Cause: Prolonged operation at stall torque or excessive load.
Solution: Reduce the load on the servo and avoid operating it at stall torque for extended periods.
Servo Jittering:
Cause: Insufficient power supply or unstable voltage.
Solution: Use a capacitor across the power supply to stabilize the voltage.
FAQs
Q1: Can the GX Servo 200 rotate continuously?
A1: No, the GX Servo 200 is a standard servo designed for angular positioning (0° to 180°). For continuous rotation, a modified or continuous rotation servo is required.
Q2: What is the maximum current draw of the GX Servo 200?
A2: The maximum current draw depends on the load and operating voltage. Under stall conditions, it can draw up to 2.5A. Ensure your power supply can handle this.
Q3: Can I use the GX Servo 200 with a Raspberry Pi?
A3: Yes, but since the Raspberry Pi does not have hardware PWM on all GPIO pins, it is recommended to use a dedicated PWM driver (e.g., PCA9685) for precise control.
Q4: How do I calibrate the servo's neutral position?
A4: The servo's neutral position (1500 µs pulse width) is factory-calibrated. If adjustments are needed, use a servo tester or adjust the PWM signal in your code.
By following this documentation, you can effectively integrate the GX Servo 200 into your projects and achieve precise control for a wide range of applications.

 Open Project in Cirkit Designer