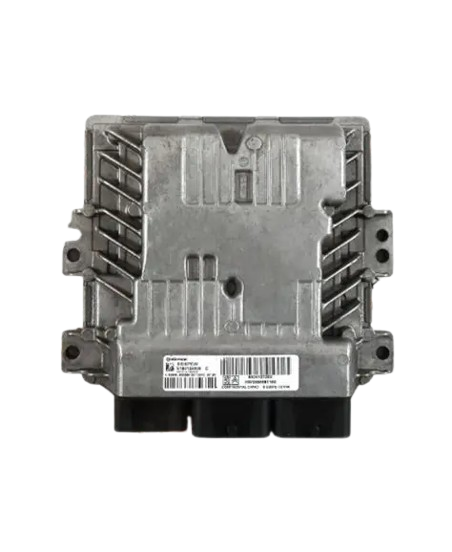
The Electronic Control Unit (ECU), manufactured by CAR (Part ID: CAR), is a digital computer designed to manage and control various functions in a vehicle. It plays a critical role in modern automotive systems by ensuring optimal performance, efficiency, and safety. The ECU processes data from various sensors and executes commands to control actuators, enabling precise management of systems such as engine performance, transmission, braking, and more.
Explore Projects Built with ECU
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
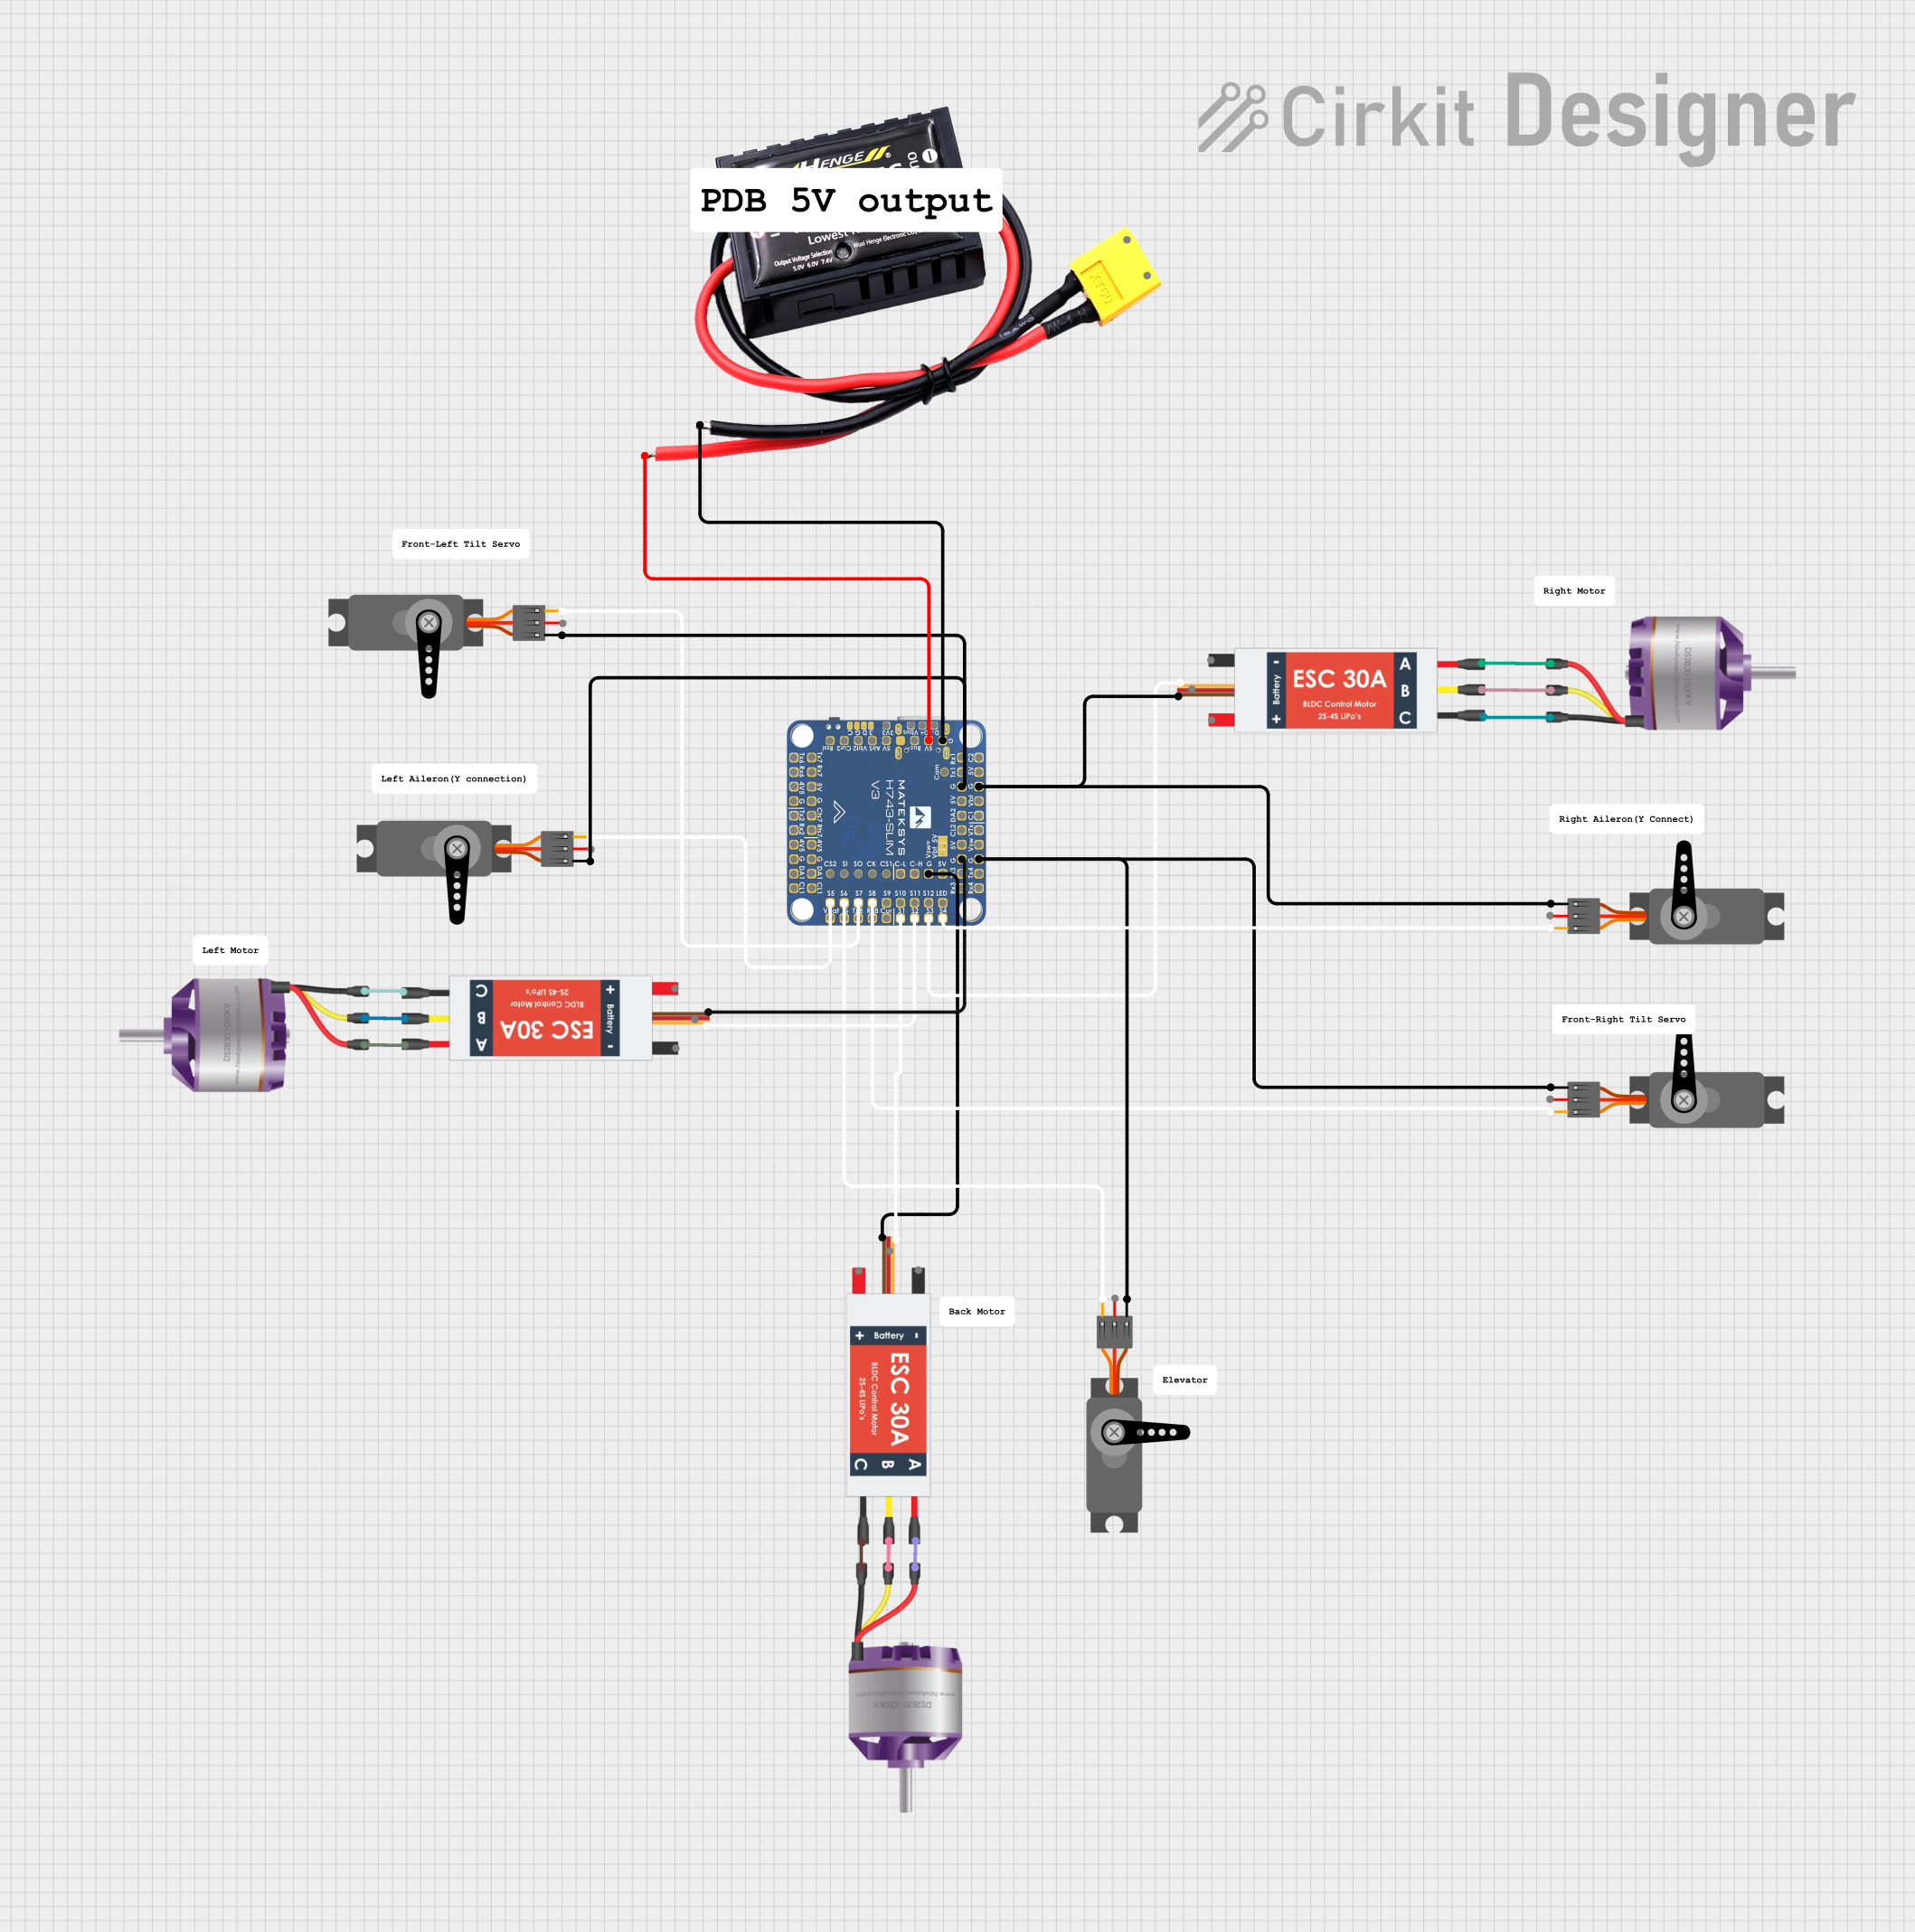
This circuit is designed to control multiple servos and brushless motors using an H743-SLIM V3 microcontroller. The servos are connected to the microcontroller's PWM pins, while the brushless motors are controlled via Electronic Speed Controllers (ESCs) that are also interfaced with the microcontroller. A 12A UBEC provides the necessary power to the microcontroller and other components.
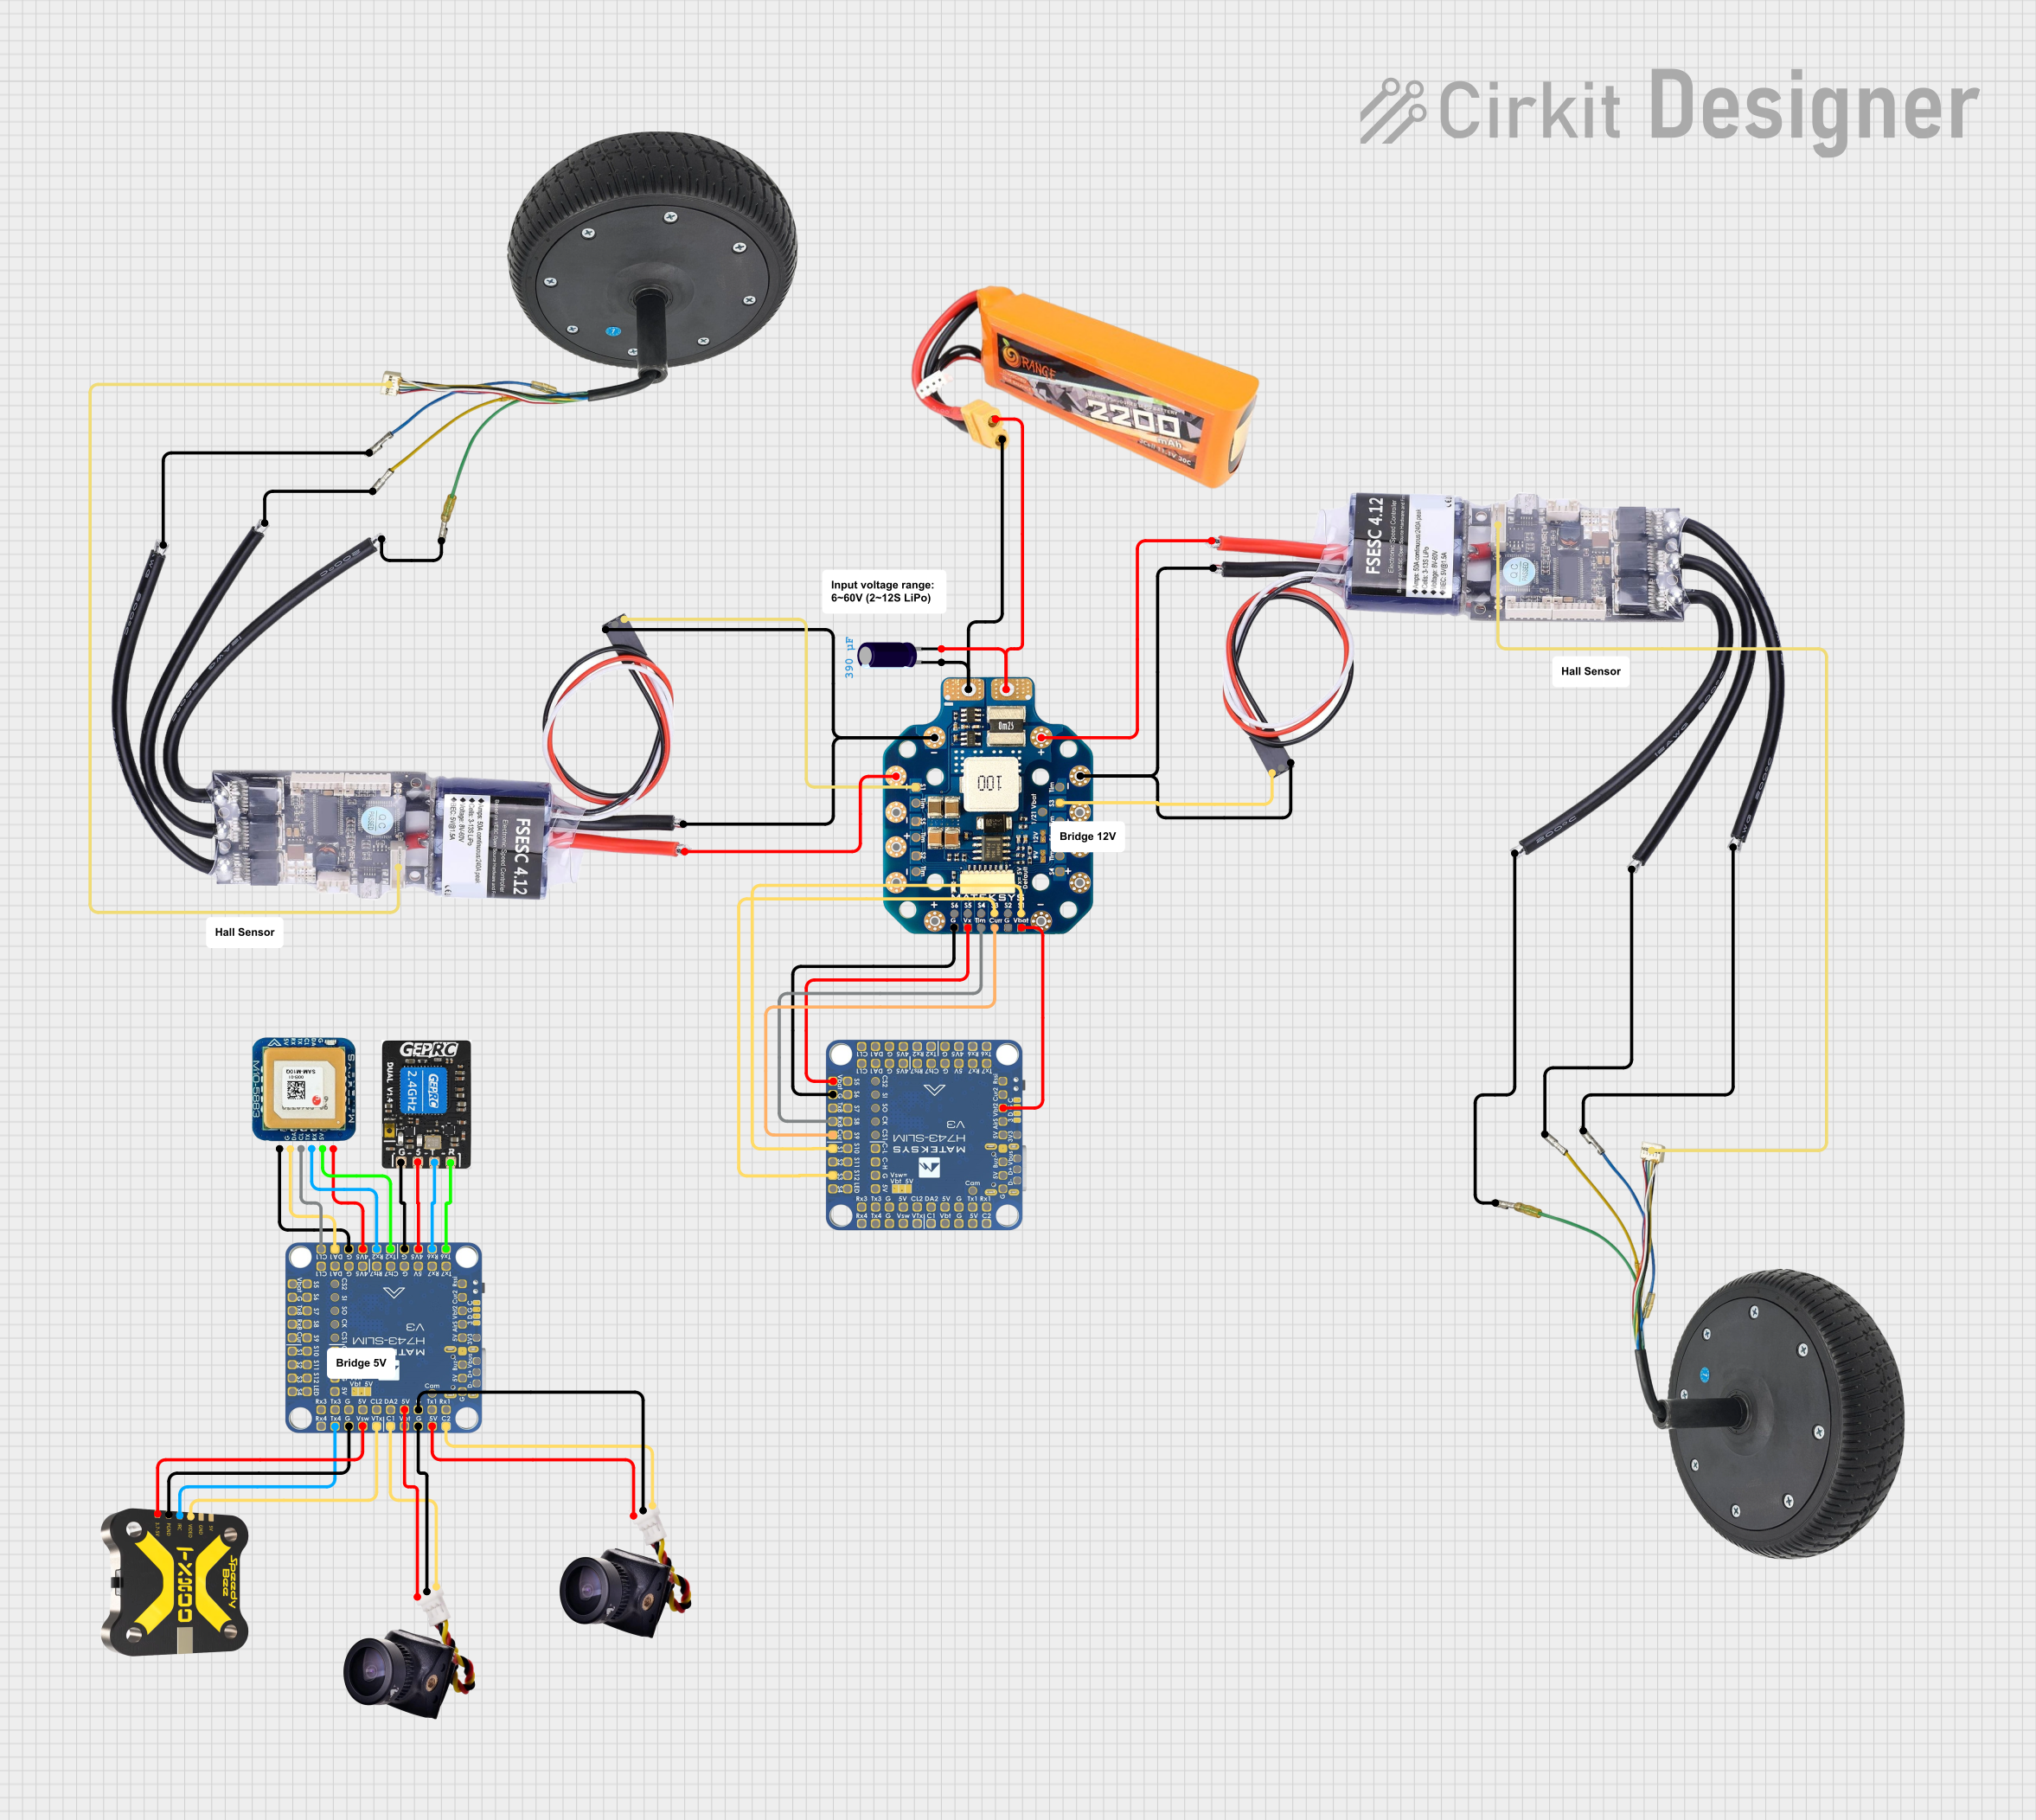
This circuit appears to be a power distribution and control system for a vehicle with two motorized wheels, possibly a drone or a robot. It includes a lipo battery connected to a Power Distribution Board (PDB) that distributes power to two Electronic Speed Controllers (ESCs) which in turn control the speed and direction of the motors. The system also integrates a flight controller (H743-SLIM V3) for managing various peripherals including GPS, FPV camera system, and a telemetry link (ExpressLRS).
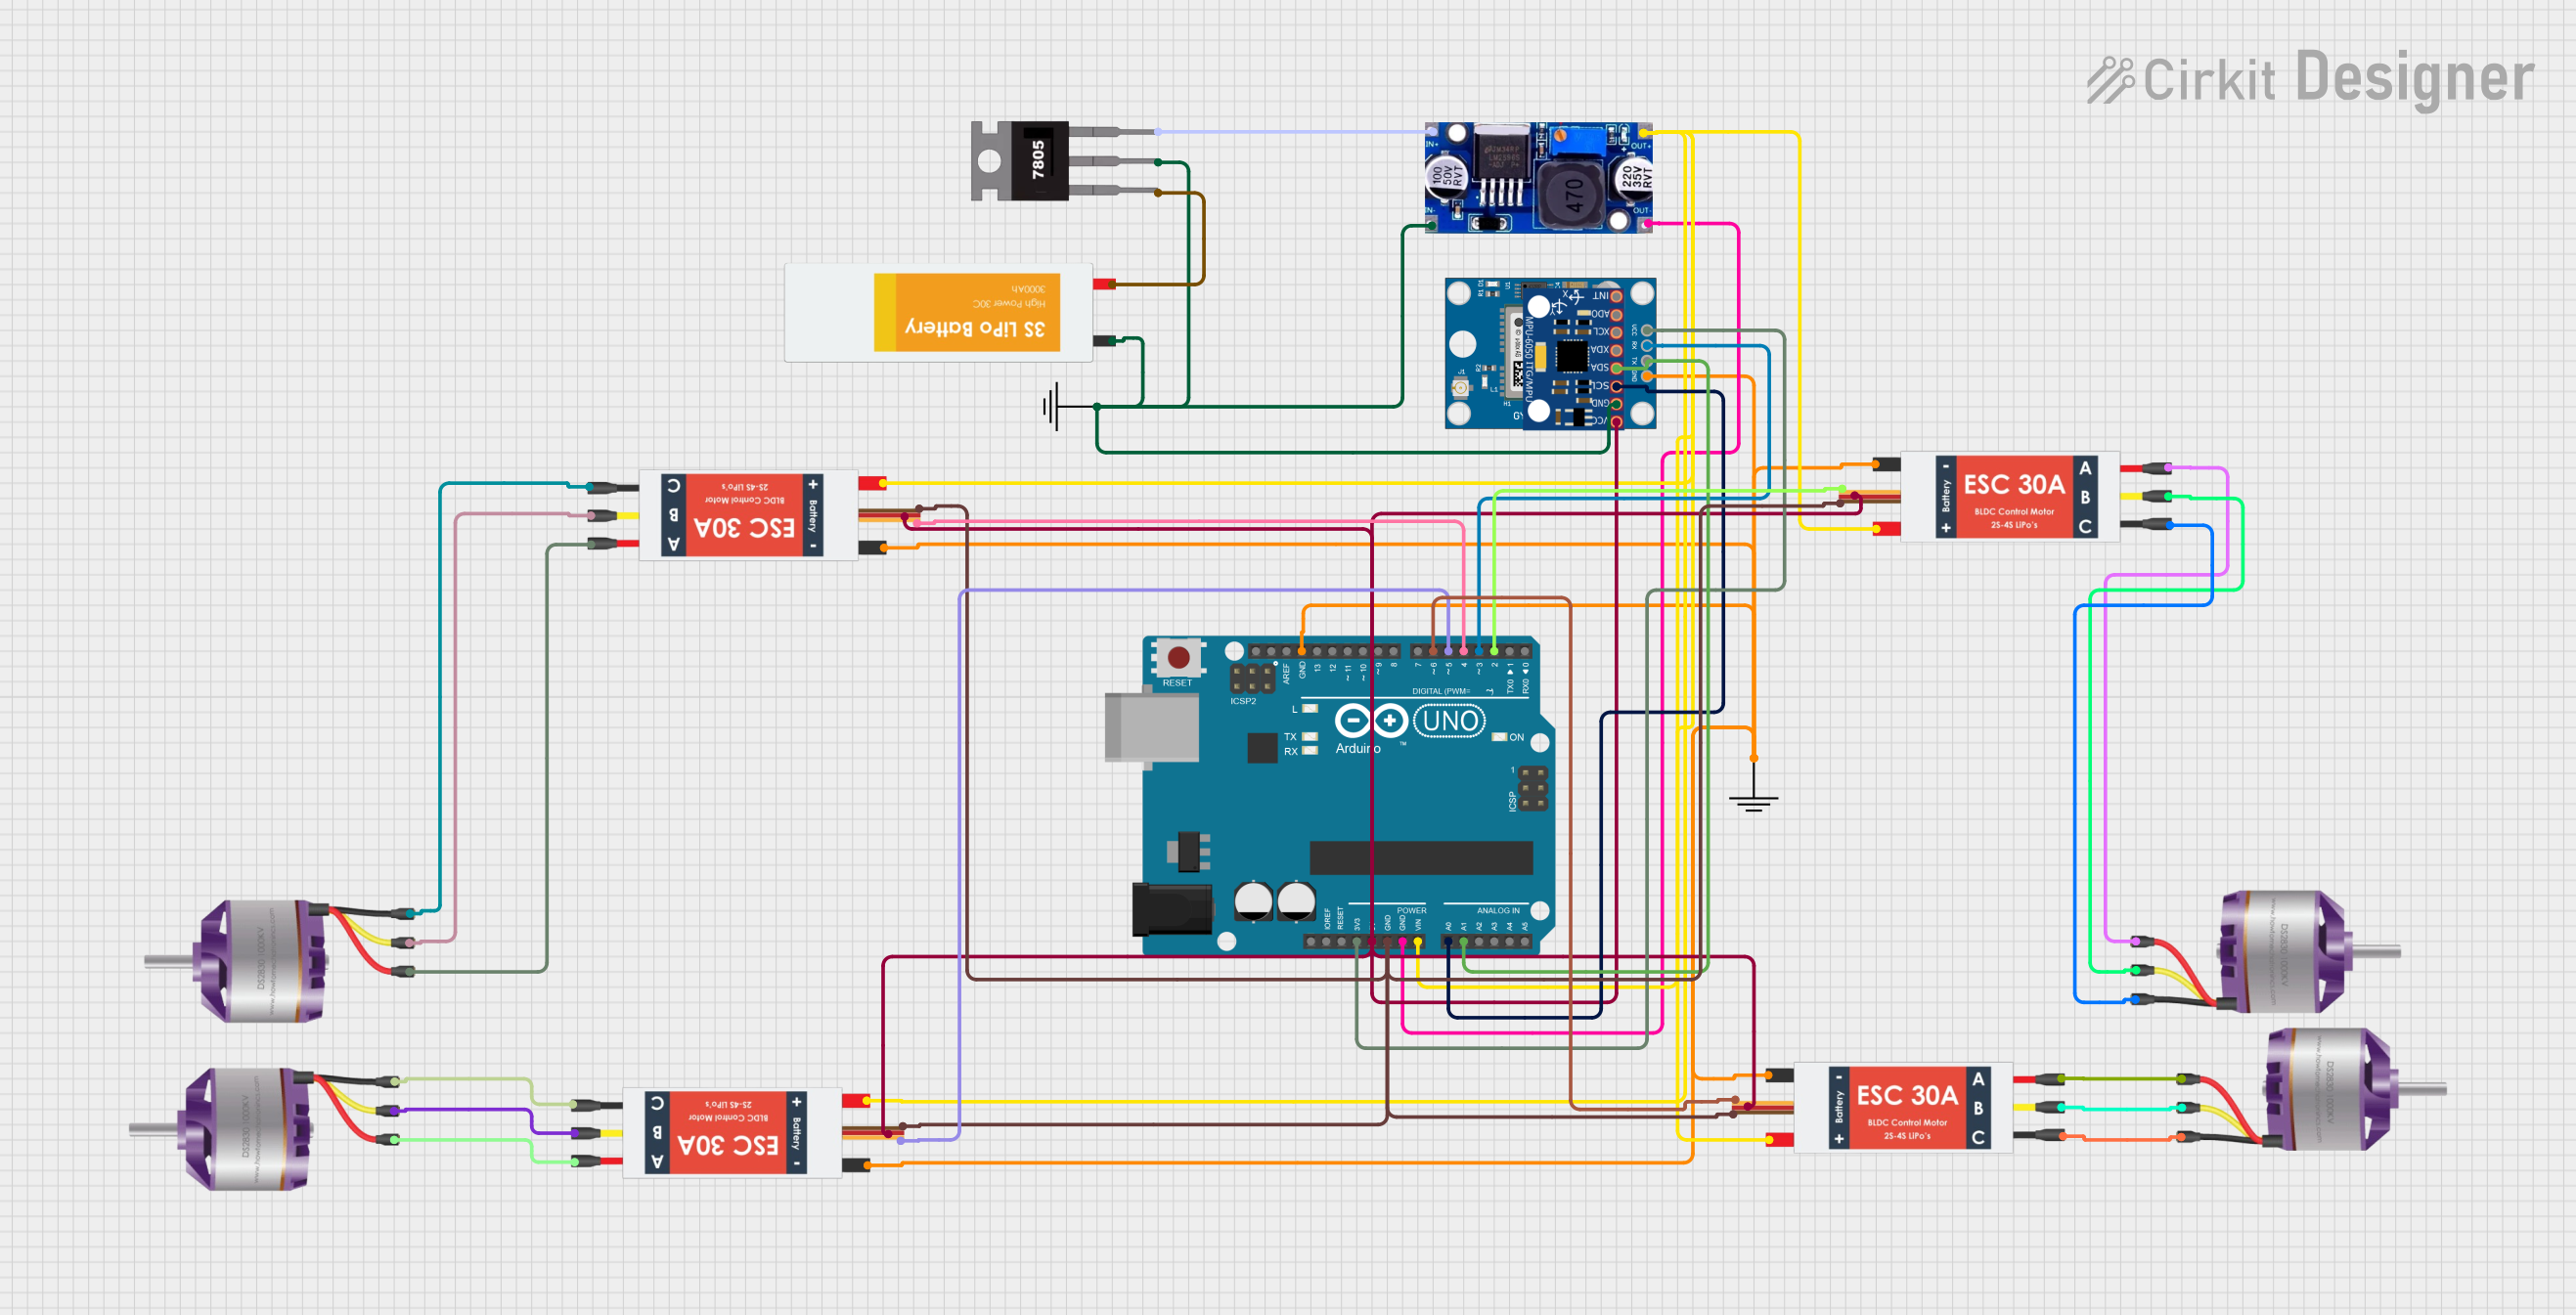
This circuit is a quadcopter control system featuring an Arduino UNO, four brushless motors, and four Electronic Speed Controllers (ESCs). The Arduino UNO manages the ESCs to control the motors, while additional components like a GPS module and an MPU-6050 sensor provide navigation and orientation data.
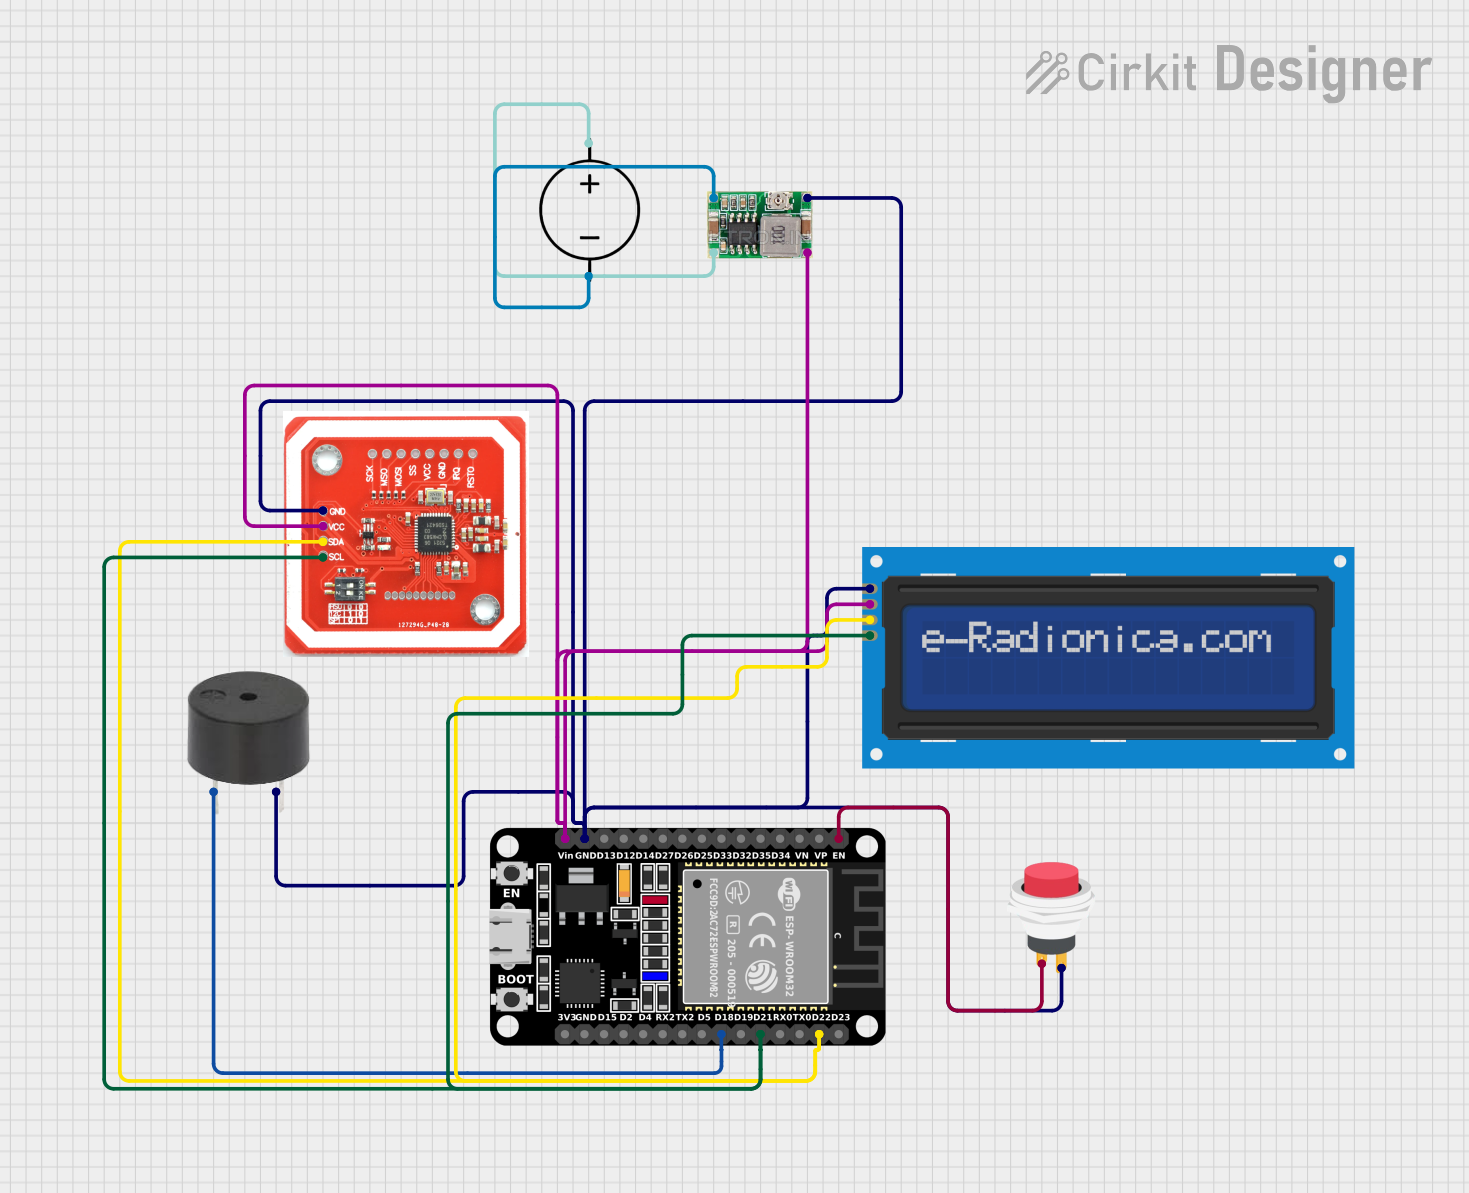
This circuit features an ESP32 microcontroller that interfaces with an LCD screen and an NFC/RFID reader, likely for the purpose of tracking and displaying student attendance or count. The LCD is used to show the number of students detected by the NFC/RFID reader, with a fixed count displayed on the second line. A buzzer is also connected to the ESP32, which could be used for audible notifications, and a push switch is included to control the power to the ESP32. Power regulation is managed by a Mini 360 Buck Converter connected to a DC power source.
Engine Management: Controls fuel injection, ignition timing, and air-fuel ratio for optimal engine performance.
Transmission Control: Manages gear shifting in automatic transmissions for smooth operation.
Anti-lock Braking System (ABS): Ensures safe braking by preventing wheel lock-up.
Airbag Deployment: Activates airbags during a collision to protect passengers.
Climate Control: Regulates cabin temperature and airflow.
Advanced Driver Assistance Systems (ADAS): Supports features like lane-keeping assist, adaptive cruise control, and parking assistance.
Technical Specifications
The following table outlines the key technical details of the ECU:
Parameter
Specification
Operating Voltage
12V DC (nominal), 9V-16V range
Power Consumption
5W-50W (depending on system load)
Communication Protocols
CAN, LIN, FlexRay, Ethernet
Processor Type
32-bit microcontroller
Memory
Flash: 1MB-4MB, RAM: 256KB-1MB
Operating Temperature
-40°C to +85°C
Dimensions
Varies by model, typically compact
Weight
~500g
Pin Configuration and Descriptions
The ECU typically features a multi-pin connector for interfacing with sensors, actuators, and other vehicle systems. Below is an example of a generic pin configuration:
Pin Number
Pin Name
Description
1
Power (+12V)
Main power supply input
2
Ground (GND)
Ground connection
3
CAN_H
High line for CAN bus communication
4
CAN_L
Low line for CAN bus communication
5
Sensor Input 1
Analog input from a connected sensor
6
Sensor Input 2
Analog input from another sensor
7
Actuator Output 1
Output signal to control an actuator
8
Actuator Output 2
Output signal to control another actuator
9
Diagnostic Port
Interface for diagnostics and programming
10
Reserved
Reserved for future use
Note: Pin configurations may vary depending on the specific ECU model and application.
Usage Instructions
How to Use the ECU in a Circuit
Power Connection: Connect the ECU's power pin to a stable 12V DC source and the ground pin to the vehicle's chassis or a common ground.
Sensor Inputs: Wire the appropriate sensors (e.g., temperature, pressure, or speed sensors) to the designated input pins.
Actuator Outputs: Connect actuators (e.g., fuel injectors, solenoids, or motors) to the output pins as specified in the vehicle's wiring diagram.
Communication: Use the CAN_H and CAN_L pins to connect the ECU to the vehicle's CAN bus for data exchange with other modules.
Diagnostics: Connect a diagnostic tool to the diagnostic port for programming, troubleshooting, or firmware updates.
Important Considerations and Best Practices
Voltage Stability: Ensure the power supply is stable and within the specified range (9V-16V) to prevent damage to the ECU.
Wiring Integrity: Use high-quality automotive-grade wires and connectors to avoid signal loss or interference.
Grounding: Proper grounding is essential to prevent electrical noise and ensure reliable operation.
Firmware Updates: Regularly update the ECU firmware to benefit from performance improvements and bug fixes.
Environmental Protection: Install the ECU in a location protected from excessive heat, moisture, and vibration.
Example: Connecting the ECU to an Arduino UNO
While the ECU is primarily designed for automotive systems, it can be interfaced with an Arduino UNO for testing or prototyping purposes. Below is an example of how to read data from the ECU using the CAN bus:
Required Components
Arduino UNO
CAN bus shield
ECU
Jumper wires
Sample Code
#include <SPI.h>
#include <mcp_can.h>

// Define the CAN bus shield's CS pin
#define CAN_CS_PIN 10

// Initialize the CAN bus object
MCP_CAN CAN(CAN_CS_PIN);

void setup() {
  Serial.begin(9600); // Initialize serial communication for debugging

  // Initialize the CAN bus at 500 kbps
  if (CAN.begin(MCP_ANY, 500000, MCP_8MHZ) == CAN_OK) {
    Serial.println("CAN bus initialized successfully!");
  } else {
    Serial.println("Error initializing CAN bus. Check connections.");
    while (1); // Halt execution if initialization fails
  }

  CAN.setMode(MCP_NORMAL); // Set CAN bus to normal mode
  Serial.println("CAN bus set to normal mode.");
}

void loop() {
  unsigned char len = 0;
  unsigned char buf[8];

  // Check if data is available on the CAN bus
  if (CAN.checkReceive() == CAN_MSGAVAIL) {
    CAN.readMsgBuf(&len, buf); // Read the received message

    Serial.print("Received data: ");
    for (int i = 0; i < len; i++) {
      Serial.print(buf[i], HEX); // Print each byte in hexadecimal format
      Serial.print(" ");
    }
    Serial.println();
  }

  delay(100); // Add a small delay to avoid flooding the serial monitor
}
Note: This code assumes the use of an MCP2515-based CAN bus shield. Adjust the settings as needed for your specific hardware.
Troubleshooting and FAQs
Common Issues and Solutions
ECU Not Powering On
Cause: Insufficient or unstable power supply.
Solution: Verify the power source and ensure it provides a stable 12V DC.
No Communication with Other Modules
Cause: Faulty CAN bus wiring or incorrect termination.
Solution: Check the CAN_H and CAN_L connections and ensure proper termination resistors (120Ω) are in place.
Sensor Data Not Detected
Cause: Loose or damaged sensor connections.
Solution: Inspect the wiring and connectors for damage or poor contact.
Actuator Not Responding
Cause: Incorrect wiring or faulty actuator.
Solution: Verify the actuator's wiring and test it independently to confirm functionality.
FAQs
Q: Can the ECU be used in non-automotive applications? A: Yes, the ECU can be adapted for use in other systems requiring real-time control, such as industrial automation or robotics.
Q: How do I update the ECU firmware? A: Use a compatible diagnostic tool or programming interface to upload the latest firmware provided by the manufacturer.
Q: What happens if the ECU overheats? A: Most ECUs have built-in thermal protection and will shut down or reduce performance to prevent damage. Ensure proper ventilation and avoid exposure to excessive heat.
Q: Can I repair a damaged ECU? A: Repairs should only be performed by qualified technicians with access to the necessary tools and replacement components.
For additional support, refer to the manufacturer's documentation or contact their technical support team.

 Open Project in Cirkit Designer