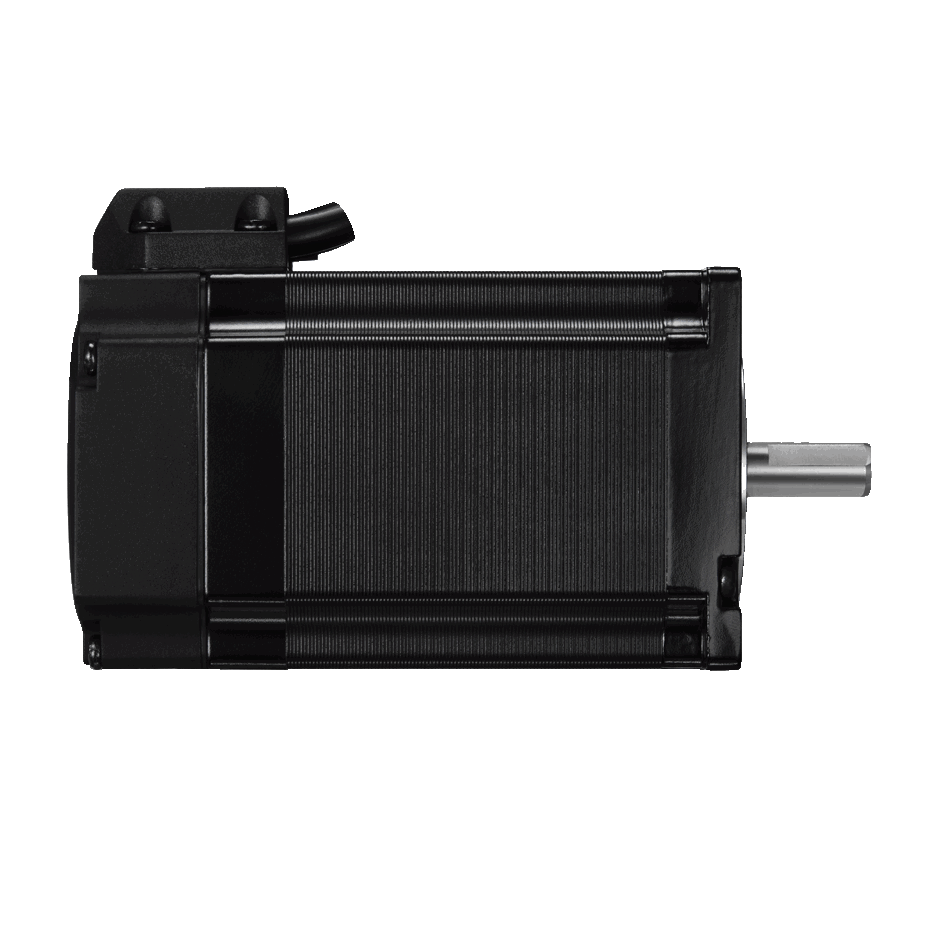
The NEMA 23 Closed Loop Stepper System (Leadshine CS-M22323) is a high-performance stepper motor system designed for precision motion control applications. This system integrates a NEMA 23 stepper motor with a closed-loop control mechanism, which ensures improved accuracy, reduced vibration, and enhanced torque performance compared to traditional open-loop stepper systems. The closed-loop feedback eliminates issues such as missed steps and provides smoother operation, making it ideal for demanding applications.
Explore Projects Built with NEMA 23 Closed Loop Stepper System
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
This is a complex control system designed for automation tasks, featuring motion control with stepper motors, environmental sensing, and time-based operations. It includes power management, actuator control via relays, and a user interface provided by a Raspberry Pi connected to a touchscreen display.
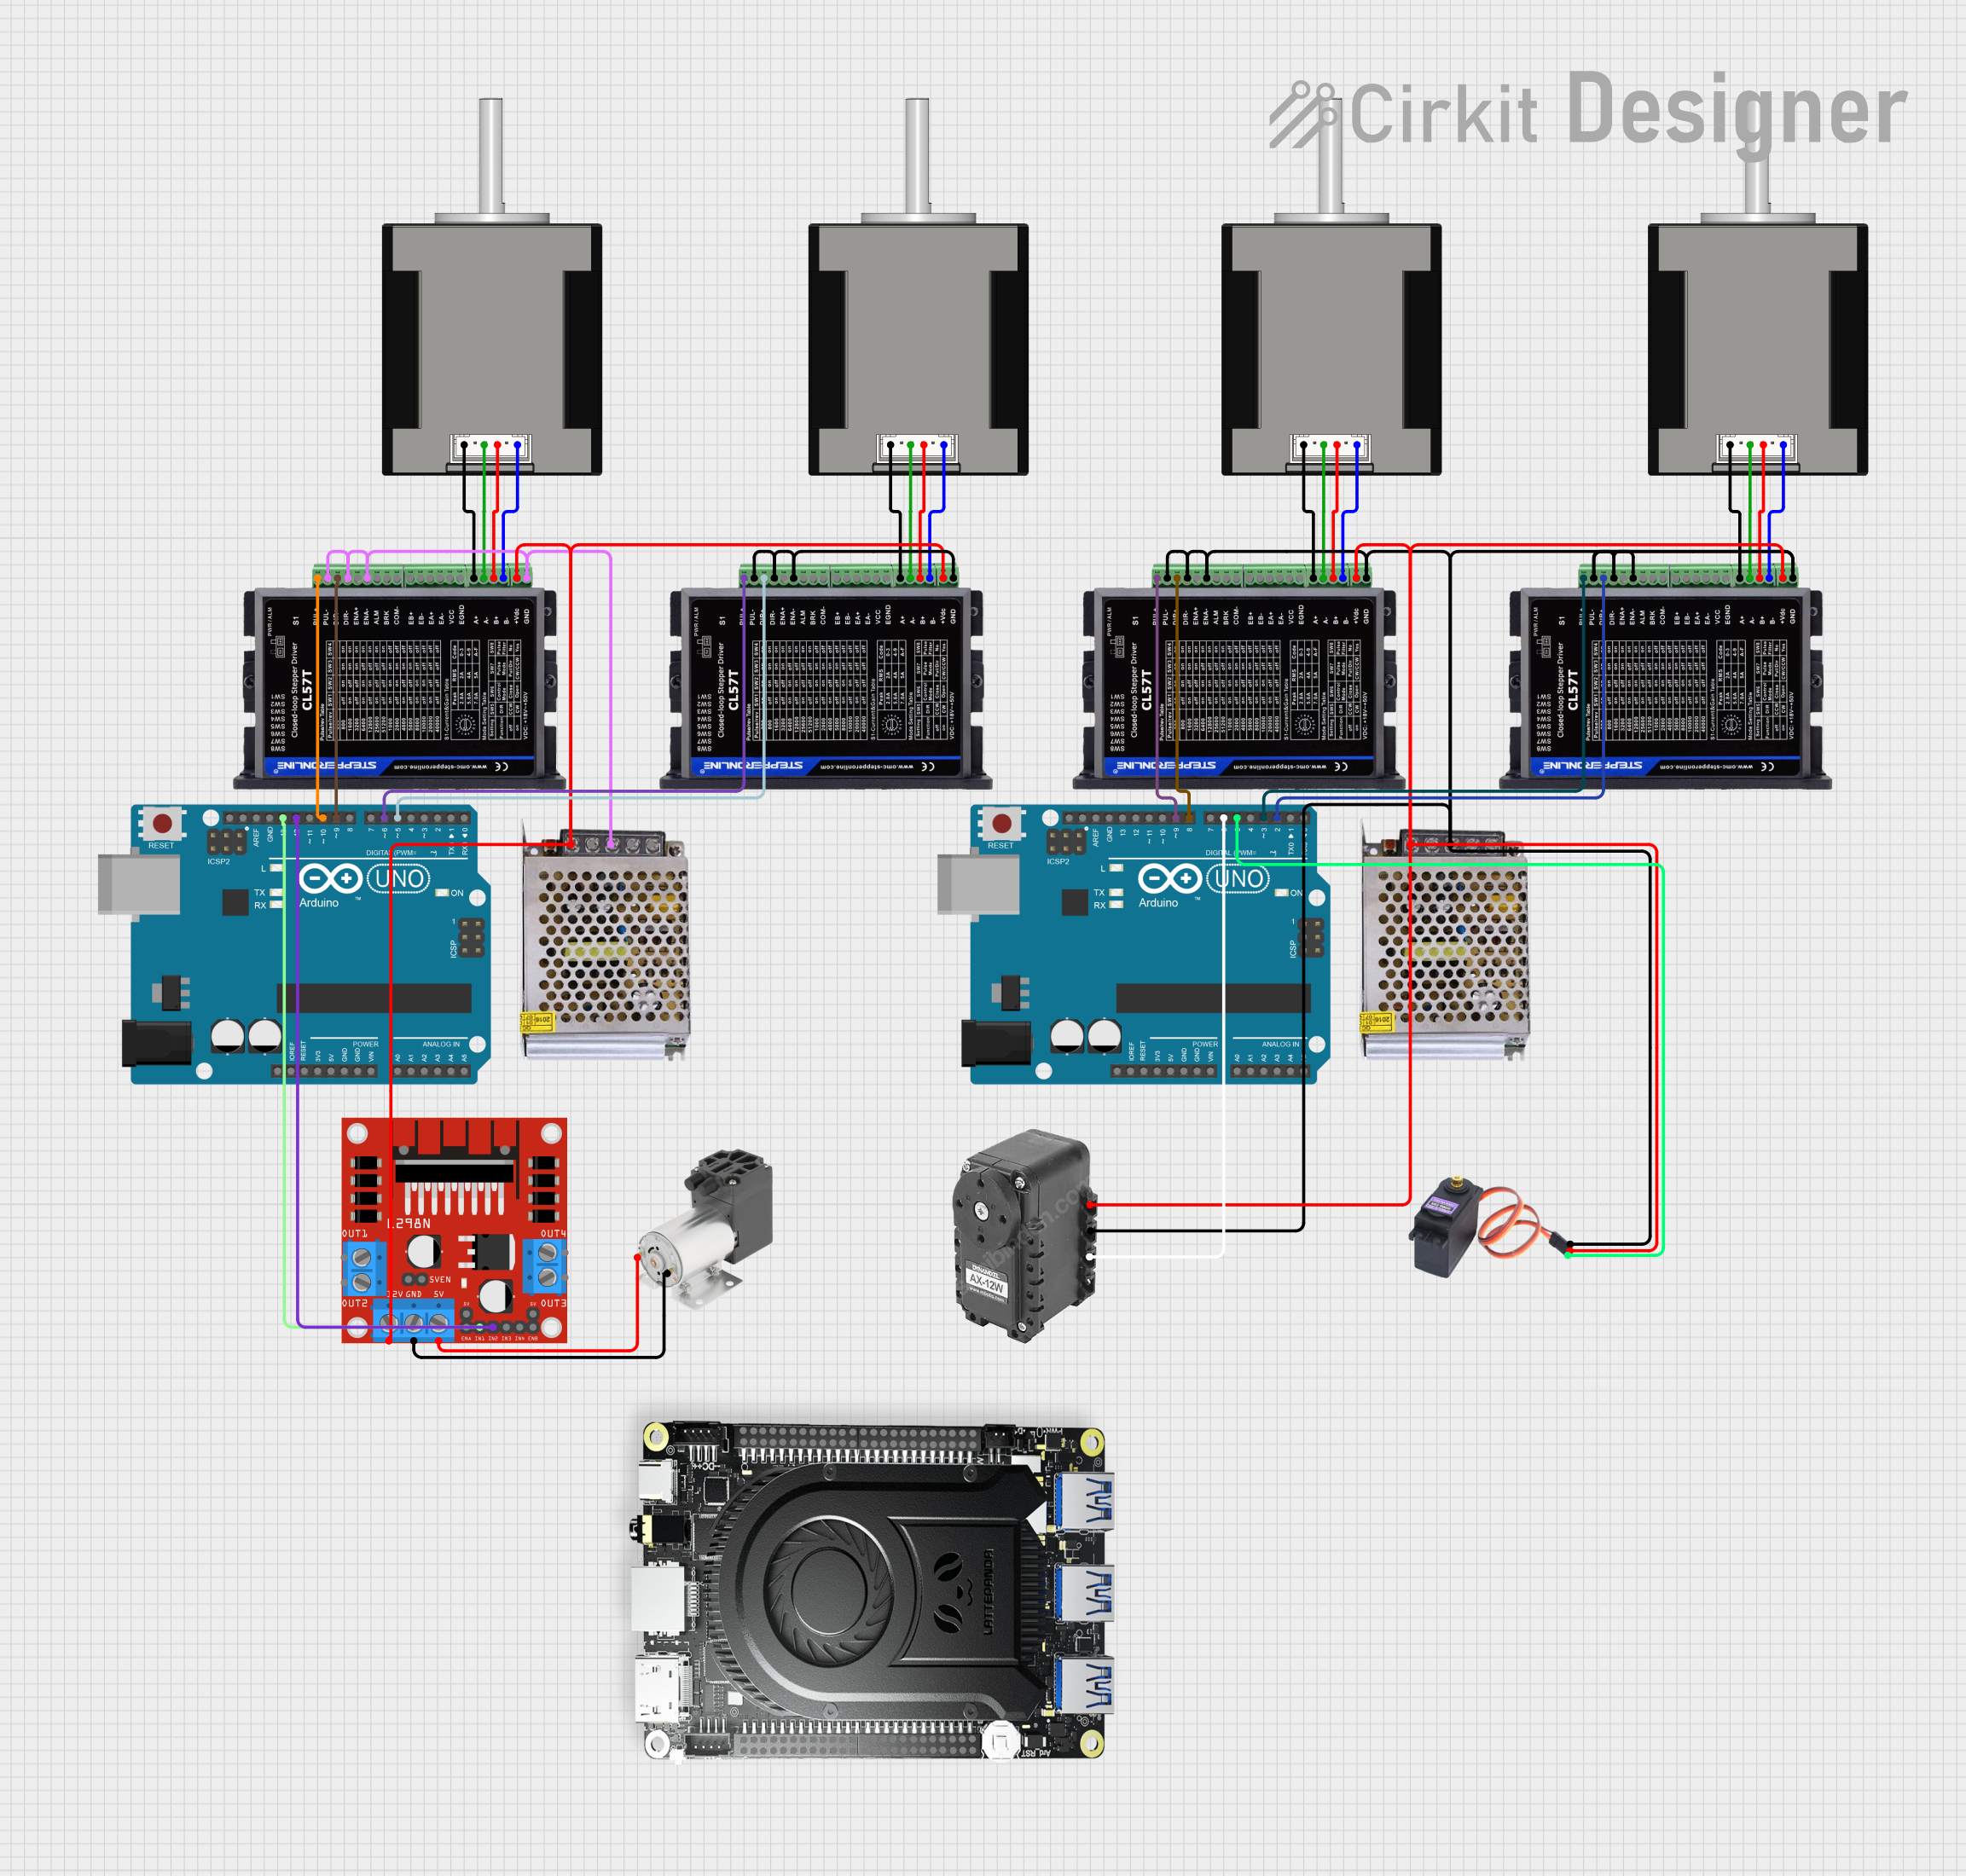
This circuit controls multiple stepper motors and a DC motor using Arduino UNOs and Stepperonline CL57T Closed Loop Stepper Drivers, powered by a 12V power supply. It also includes a Dynamixel motor and a mini vacuum pump, with the Arduino UNOs managing the motor drivers and other components through digital I/O pins.
This circuit is a CNC control system that integrates multiple power supplies, stepper motor drivers, and breakout boards to control stepper motors and other peripherals. It includes an Arduino Nano for additional control logic and an Ethernet Smooth Stepper for network connectivity, enabling precise control of CNC machinery.
This circuit controls a NEMA 23 stepper motor using a DM542 stepper driver, managed by an Arduino UNO. It includes a keypad shield for user input, limit switches for position feedback, and a relay module for controlling additional devices, with an emergency stop and indicator lamps for safety and status indication.
Industrial equipment for positioning and actuation
Technical Specifications
Key Technical Details
Parameter
Value
Motor Frame Size
NEMA 23 (57 x 57 mm)
Manufacturer Part ID
CS-M22323
Control Type
Closed-loop (with encoder feedback)
Step Angle
1.8°
Holding Torque
2.3 Nm (325 oz-in)
Rated Current
3.5 A
Voltage Range
24 VDC to 50 VDC
Encoder Resolution
1000 lines/rev (4000 counts/rev)
Communication Interface
Pulse/Direction or Step/Dir signals
Operating Temperature
-20°C to +50°C
Insulation Class
Class B
Pin Configuration and Descriptions
The system includes a motor and a driver. Below is the pin configuration for the driver:
Driver Input Signals
Pin Number
Signal Name
Description
1
PUL+
Pulse signal input (positive)
2
PUL-
Pulse signal input (negative)
3
DIR+
Direction signal input (positive)
4
DIR-
Direction signal input (negative)
5
ENA+
Enable signal input (positive)
6
ENA-
Enable signal input (negative)
Power and Motor Connections
Pin Number
Signal Name
Description
7
V+
Power supply positive (24-50 VDC)
8
V-
Power supply negative (GND)
9
A+
Motor winding A+
10
A-
Motor winding A-
11
B+
Motor winding B+
12
B-
Motor winding B-
Encoder Feedback Signals
Pin Number
Signal Name
Description
13
EA+
Encoder A+ signal
14
EA-
Encoder A- signal
15
EB+
Encoder B+ signal
16
EB-
Encoder B- signal
17
VCC
Encoder power supply (5 VDC)
18
GND
Encoder ground
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Connect a DC power supply (24-50 VDC) to the V+ and V- terminals of the driver. Ensure the power supply can provide sufficient current for the motor (at least 3.5 A).
Motor Connections: Connect the motor windings to the A+, A-, B+, and B- terminals of the driver. Follow the wiring diagram provided in the manufacturer's datasheet to avoid incorrect connections.
Control Signals:
Connect the PUL+, PUL-, DIR+, and DIR- pins to a microcontroller or motion controller capable of generating pulse and direction signals.
If using an Arduino UNO, use digital pins to generate the required signals.
Encoder Feedback: Connect the encoder signals (EA+, EA-, EB+, EB-) to the corresponding pins on the driver. Ensure the encoder power supply (VCC and GND) is properly connected.
Enable Signal: Optionally, connect the ENA+ and ENA- pins to enable or disable the motor driver via an external signal.
Important Considerations and Best Practices
Power Supply: Use a regulated DC power supply within the specified voltage range to avoid damage to the driver or motor.
Signal Integrity: Use shielded cables for control and encoder signals to minimize noise interference.
Heat Dissipation: Ensure proper ventilation or heat sinking for the driver to prevent overheating during operation.
Step Resolution: Configure the microstepping settings on the driver (if applicable) to achieve the desired resolution and smoothness.
Wiring: Double-check all connections before powering on the system to prevent short circuits or incorrect wiring.
Example Code for Arduino UNO
Below is an example Arduino sketch to control the NEMA 23 Closed Loop Stepper System using pulse and direction signals:
// Define pin connections for the stepper driver
const int pulsePin = 2;  // Pulse signal connected to digital pin 2
const int dirPin = 3;    // Direction signal connected to digital pin 3

void setup() {
  // Set pin modes
  pinMode(pulsePin, OUTPUT);
  pinMode(dirPin, OUTPUT);

  // Set initial direction
  digitalWrite(dirPin, HIGH); // HIGH for clockwise, LOW for counterclockwise
}

void loop() {
  // Generate pulses to move the motor
  digitalWrite(pulsePin, HIGH); // Set pulse pin HIGH
  delayMicroseconds(500);       // Pulse width (500 µs)
  digitalWrite(pulsePin, LOW);  // Set pulse pin LOW
  delayMicroseconds(500);       // Pulse interval (500 µs)
}
Note: Adjust the delayMicroseconds values to control the motor speed. A shorter delay results in higher speed, while a longer delay reduces speed.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Verify the power supply voltage and current are within the specified range.
Check the pulse and direction signal connections.
Ensure the enable signal (ENA+ and ENA-) is active (if used).
Missed Steps or Erratic Movement:
Ensure the encoder feedback signals are properly connected.
Use shielded cables to reduce noise interference.
Verify the microstepping settings on the driver.
Overheating:
Check for proper ventilation or heat sinking for the driver.
Reduce the motor current setting if possible.
No Encoder Feedback:
Verify the encoder power supply (VCC and GND) connections.
Check the encoder signal wiring (EA+, EA-, EB+, EB-).
FAQs
Can I use this system with an Arduino?
Yes, the system can be controlled using an Arduino or any microcontroller capable of generating pulse and direction signals.
What is the advantage of closed-loop control?
Closed-loop control provides higher accuracy, eliminates missed steps, and improves torque performance compared to open-loop systems.
What is the maximum speed of the motor?
The maximum speed depends on the pulse frequency and load conditions. Refer to the manufacturer's datasheet for detailed performance curves.
Can I use a higher voltage power supply?
No, the power supply voltage must not exceed 50 VDC to avoid damaging the driver.


 Open Project in Cirkit Designer