The TMC2209, manufactured by BIGTREETECH, is a highly efficient and versatile stepper motor driver designed for applications requiring precise motor control. It is widely used in 3D printers, CNC machines, and other motion control systems. The TMC2209 is known for its silent operation, thanks to StealthChop2 technology, and advanced features such as stall detection (StallGuard4) and microstepping control. It supports up to 256 microsteps, ensuring smooth and accurate motor movement.
Explore Projects Built with TMC2209
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
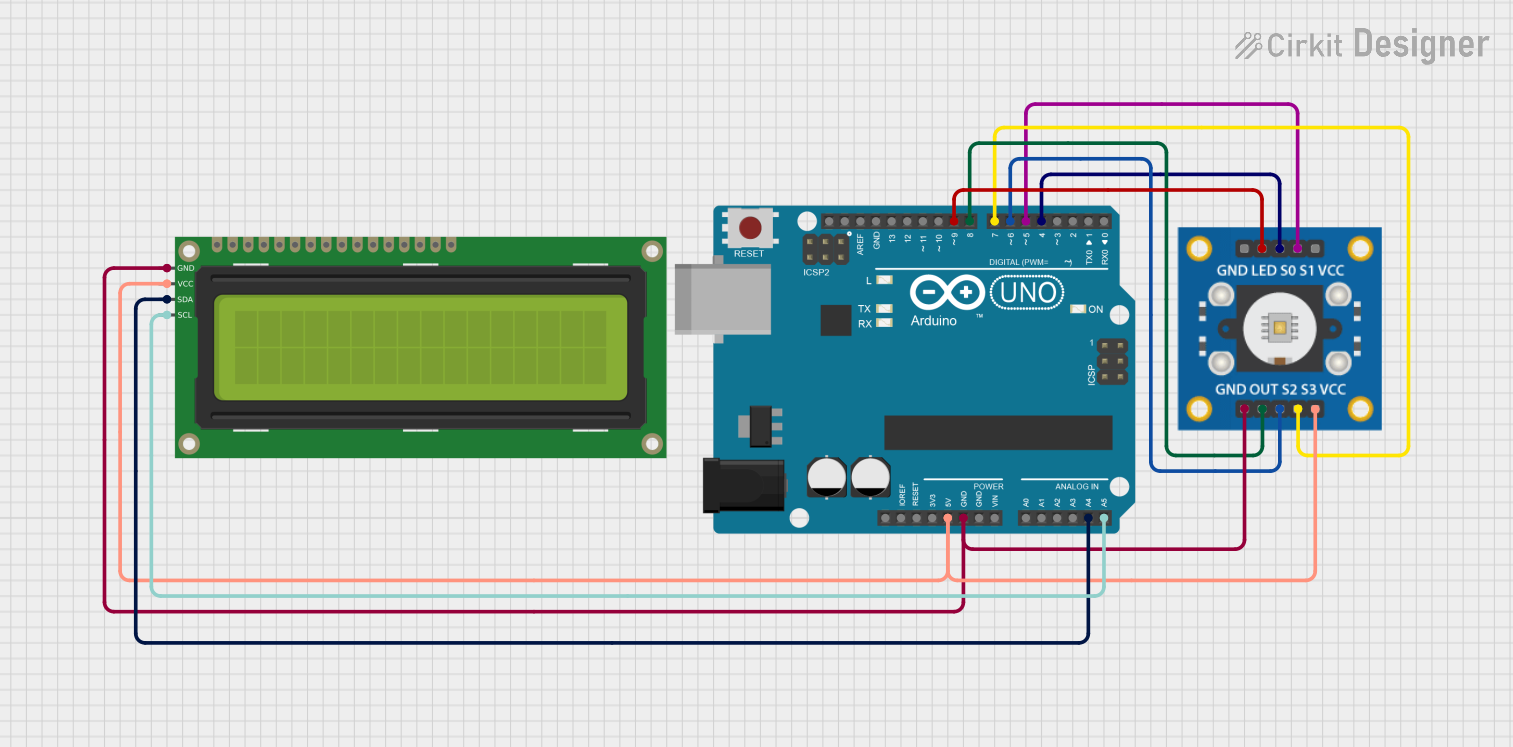
This circuit features an Arduino UNO microcontroller interfaced with a TCS3200 color sensor and an I2C LCD 16x2 display. The TCS3200 color sensor's output is connected to the Arduino's digital pin D12, and its frequency scaling pins (S0-S3) are connected to digital pins D8-D11 for configuration. The LCD display communicates with the Arduino via the I2C protocol, using A4 (SDA) and A5 (SCL) for data transfer, allowing the system to display color readings or other information from the sensor.
This circuit features an Arduino UNO microcontroller connected to a 16x2 I2C LCD display and a TCS3200 color sensor. The Arduino powers both the LCD and the color sensor, communicates with the LCD via I2C (using A4 and A5 pins for SDA and SCL), and interfaces with the TCS3200 using digital pins D4 to D9 to control the sensor and read its output. The purpose of this circuit is likely to read color information with the TCS3200 and display it on the LCD screen.
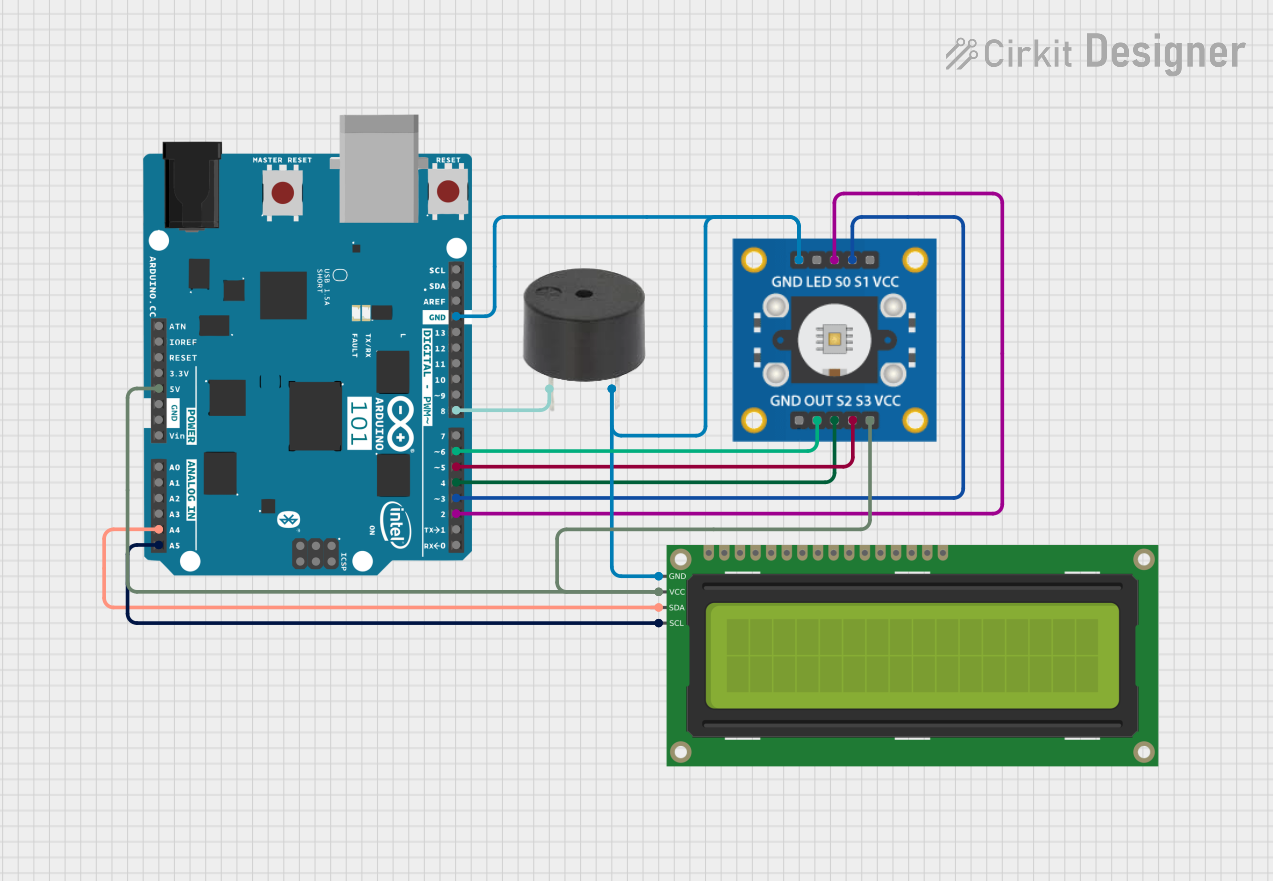
This circuit features an Arduino 101 microcontroller connected to a TCS3200 color sensor and a 16x2 I2C LCD display for output. The Arduino is configured to communicate with the LCD via I2C (using A4/SDA and A5/SCL pins for data exchange) and to receive color frequency signals from the TCS3200 on its D6 PWM pin. Additionally, a buzzer is connected to the D8 pin of the Arduino, potentially for audio signaling based on color detection or other programmed conditions.
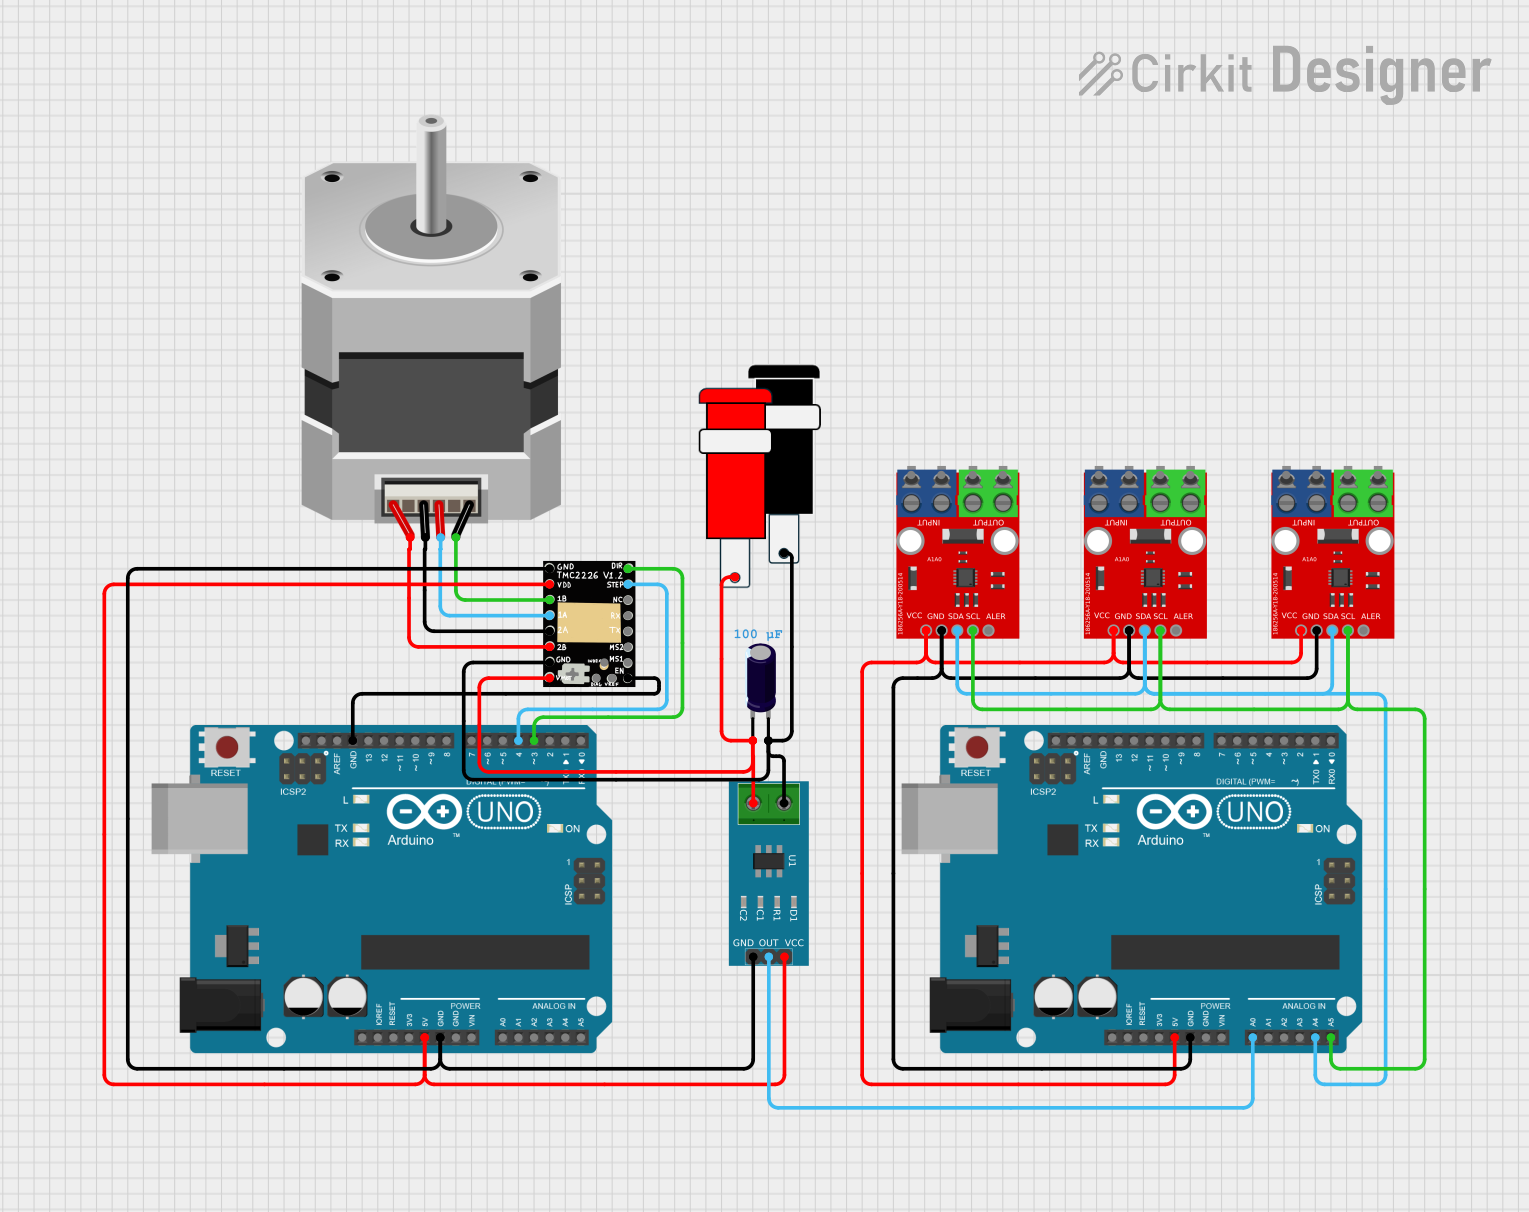
This circuit controls a bipolar stepper motor using a TMC2226 stepper driver, which is managed by an Arduino UNO. The circuit also includes a current sensor to monitor the motor's current, and multiple Nazarbayev University components are interconnected for additional functionality. Power is supplied through a 5V connector, and an electrolytic capacitor is used for voltage stabilization.
Any application requiring silent and efficient stepper motor operation
Technical Specifications
The TMC2209 offers a range of features and specifications that make it suitable for demanding applications. Below are the key technical details:
Key Specifications
Parameter
Value
Operating Voltage Range
4.75V to 29V
Maximum Motor Current
2.0A RMS (2.8A peak)
Microstepping Resolution
Up to 256 microsteps
Communication Interface
UART
Logic Voltage
3.3V or 5V compatible
Features
StealthChop2, StallGuard4,
CoolStep, SpreadCycle
Package Type
QFN28
Pin Configuration
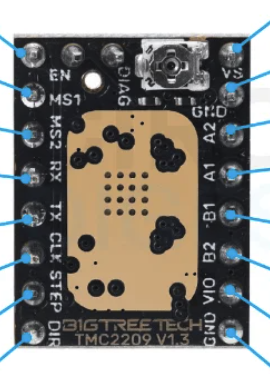
The TMC2209 comes in a 28-pin QFN package. Below is the pin configuration and description:
Pin Number
Pin Name
Description
1
GND
Ground
2
VM
Motor power supply (4.75V to 29V)
3
VCC_IO
Logic voltage input (3.3V or 5V)
4
ENN
Enable input (active low)
5
DIR
Direction control input
6
STEP
Step pulse input
7
UART
UART communication pin
8
MS1
Microstep resolution selection
9
MS2
Microstep resolution selection
10
DIAG
Diagnostic output
11
INDEX
Microstep index output
12
GND
Ground
13-28
Various
Motor coil connections and other functions
Usage Instructions
The TMC2209 is designed to be easy to integrate into a variety of systems. Below are the steps and best practices for using the TMC2209 in a circuit.
Basic Circuit Connection
Power Supply: Connect the motor power supply (VM) to a voltage source between 4.75V and 29V. Ensure the power supply can handle the current requirements of your stepper motor.
Logic Voltage: Connect the VCC_IO pin to the logic voltage of your microcontroller (3.3V or 5V).
Control Pins: Connect the STEP and DIR pins to the corresponding outputs of your microcontroller for step and direction control.
UART Communication: If using UART, connect the UART pin to the microcontroller's UART TX pin. Ensure proper configuration of the UART baud rate.
Microstepping: Use the MS1 and MS2 pins to set the desired microstepping resolution. Refer to the datasheet for the microstepping configuration table.
Enable Pin: Connect the ENN pin to ground to enable the driver.
Important Considerations
Cooling: The TMC2209 can generate heat during operation. Use a heatsink or active cooling if necessary to prevent overheating.
Current Limiting: Set the motor current limit using the UART interface or external resistors to protect the motor and driver.
StealthChop2: Enable StealthChop2 for silent operation, especially in noise-sensitive applications.
Stall Detection: Use StallGuard4 for sensorless homing and stall detection.
Example Code for Arduino UNO
Below is an example of how to control the TMC2209 using an Arduino UNO:
// Example code to control a stepper motor with the TMC2209 driver
// Ensure the TMC2209 is properly connected to the Arduino UNO

#define STEP_PIN 3  // Pin connected to the STEP pin of TMC2209
#define DIR_PIN  4  // Pin connected to the DIR pin of TMC2209
#define EN_PIN   5  // Pin connected to the ENN pin of TMC2209

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output
  pinMode(EN_PIN, OUTPUT);   // Set ENN pin as output

  digitalWrite(EN_PIN, LOW); // Enable the driver (ENN is active low)
  digitalWrite(DIR_PIN, HIGH); // Set initial direction
}

void loop() {
  // Generate step pulses to move the motor
  digitalWrite(STEP_PIN, HIGH); // Step pulse high
  delayMicroseconds(500);       // Wait 500 microseconds
  digitalWrite(STEP_PIN, LOW);  // Step pulse low
  delayMicroseconds(500);       // Wait 500 microseconds
}
Notes:
Adjust the delayMicroseconds() value to control the motor speed.
Ensure the motor current limit is set appropriately to avoid overheating.
Troubleshooting and FAQs
Common Issues
Motor Not Moving
Check the power supply connections and ensure the voltage is within the specified range.
Verify the STEP and DIR signals from the microcontroller.
Ensure the ENN pin is connected to ground to enable the driver.
Overheating
Ensure proper cooling with a heatsink or fan.
Check the motor current limit and reduce it if necessary.
Noisy Operation
Enable StealthChop2 mode for silent operation.
Verify the microstepping configuration.
Stall Detection Not Working
Ensure StallGuard4 is enabled via UART.
Check the motor load and adjust the sensitivity settings.
FAQs
Q: Can the TMC2209 be used with 12V or 24V power supplies?
A: Yes, the TMC2209 supports a wide voltage range of 4.75V to 29V, making it compatible with 12V and 24V systems.
Q: How do I set the motor current limit?
A: The motor current limit can be set via the UART interface or by adjusting external resistors. Refer to the datasheet for detailed instructions.
Q: Is the TMC2209 compatible with 3.3V microcontrollers?
A: Yes, the TMC2209 is compatible with both 3.3V and 5V logic levels.
Q: Can I use the TMC2209 for sensorless homing?
A: Yes, the TMC2209 supports sensorless homing using the StallGuard4 feature. Ensure proper configuration via UART.
By following this documentation, users can effectively integrate and operate the TMC2209 in their projects.


 Open Project in Cirkit Designer