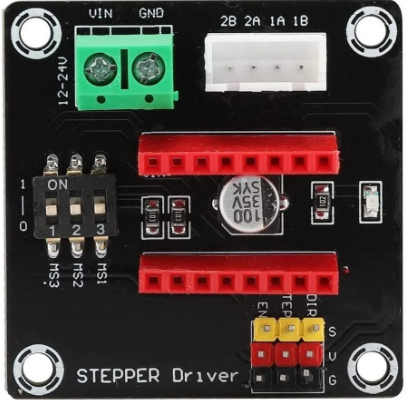
The DVR8825 is a high-performance stepper motor driver designed for precise control of stepper motors. It supports adjustable current control, microstepping (up to 1/32 steps), and includes built-in thermal shutdown protection. This makes it an ideal choice for applications requiring accurate motor control, such as robotics, 3D printers, CNC machines, and other automation systems.
Explore Projects Built with Modulo Expancion Dvr8825
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
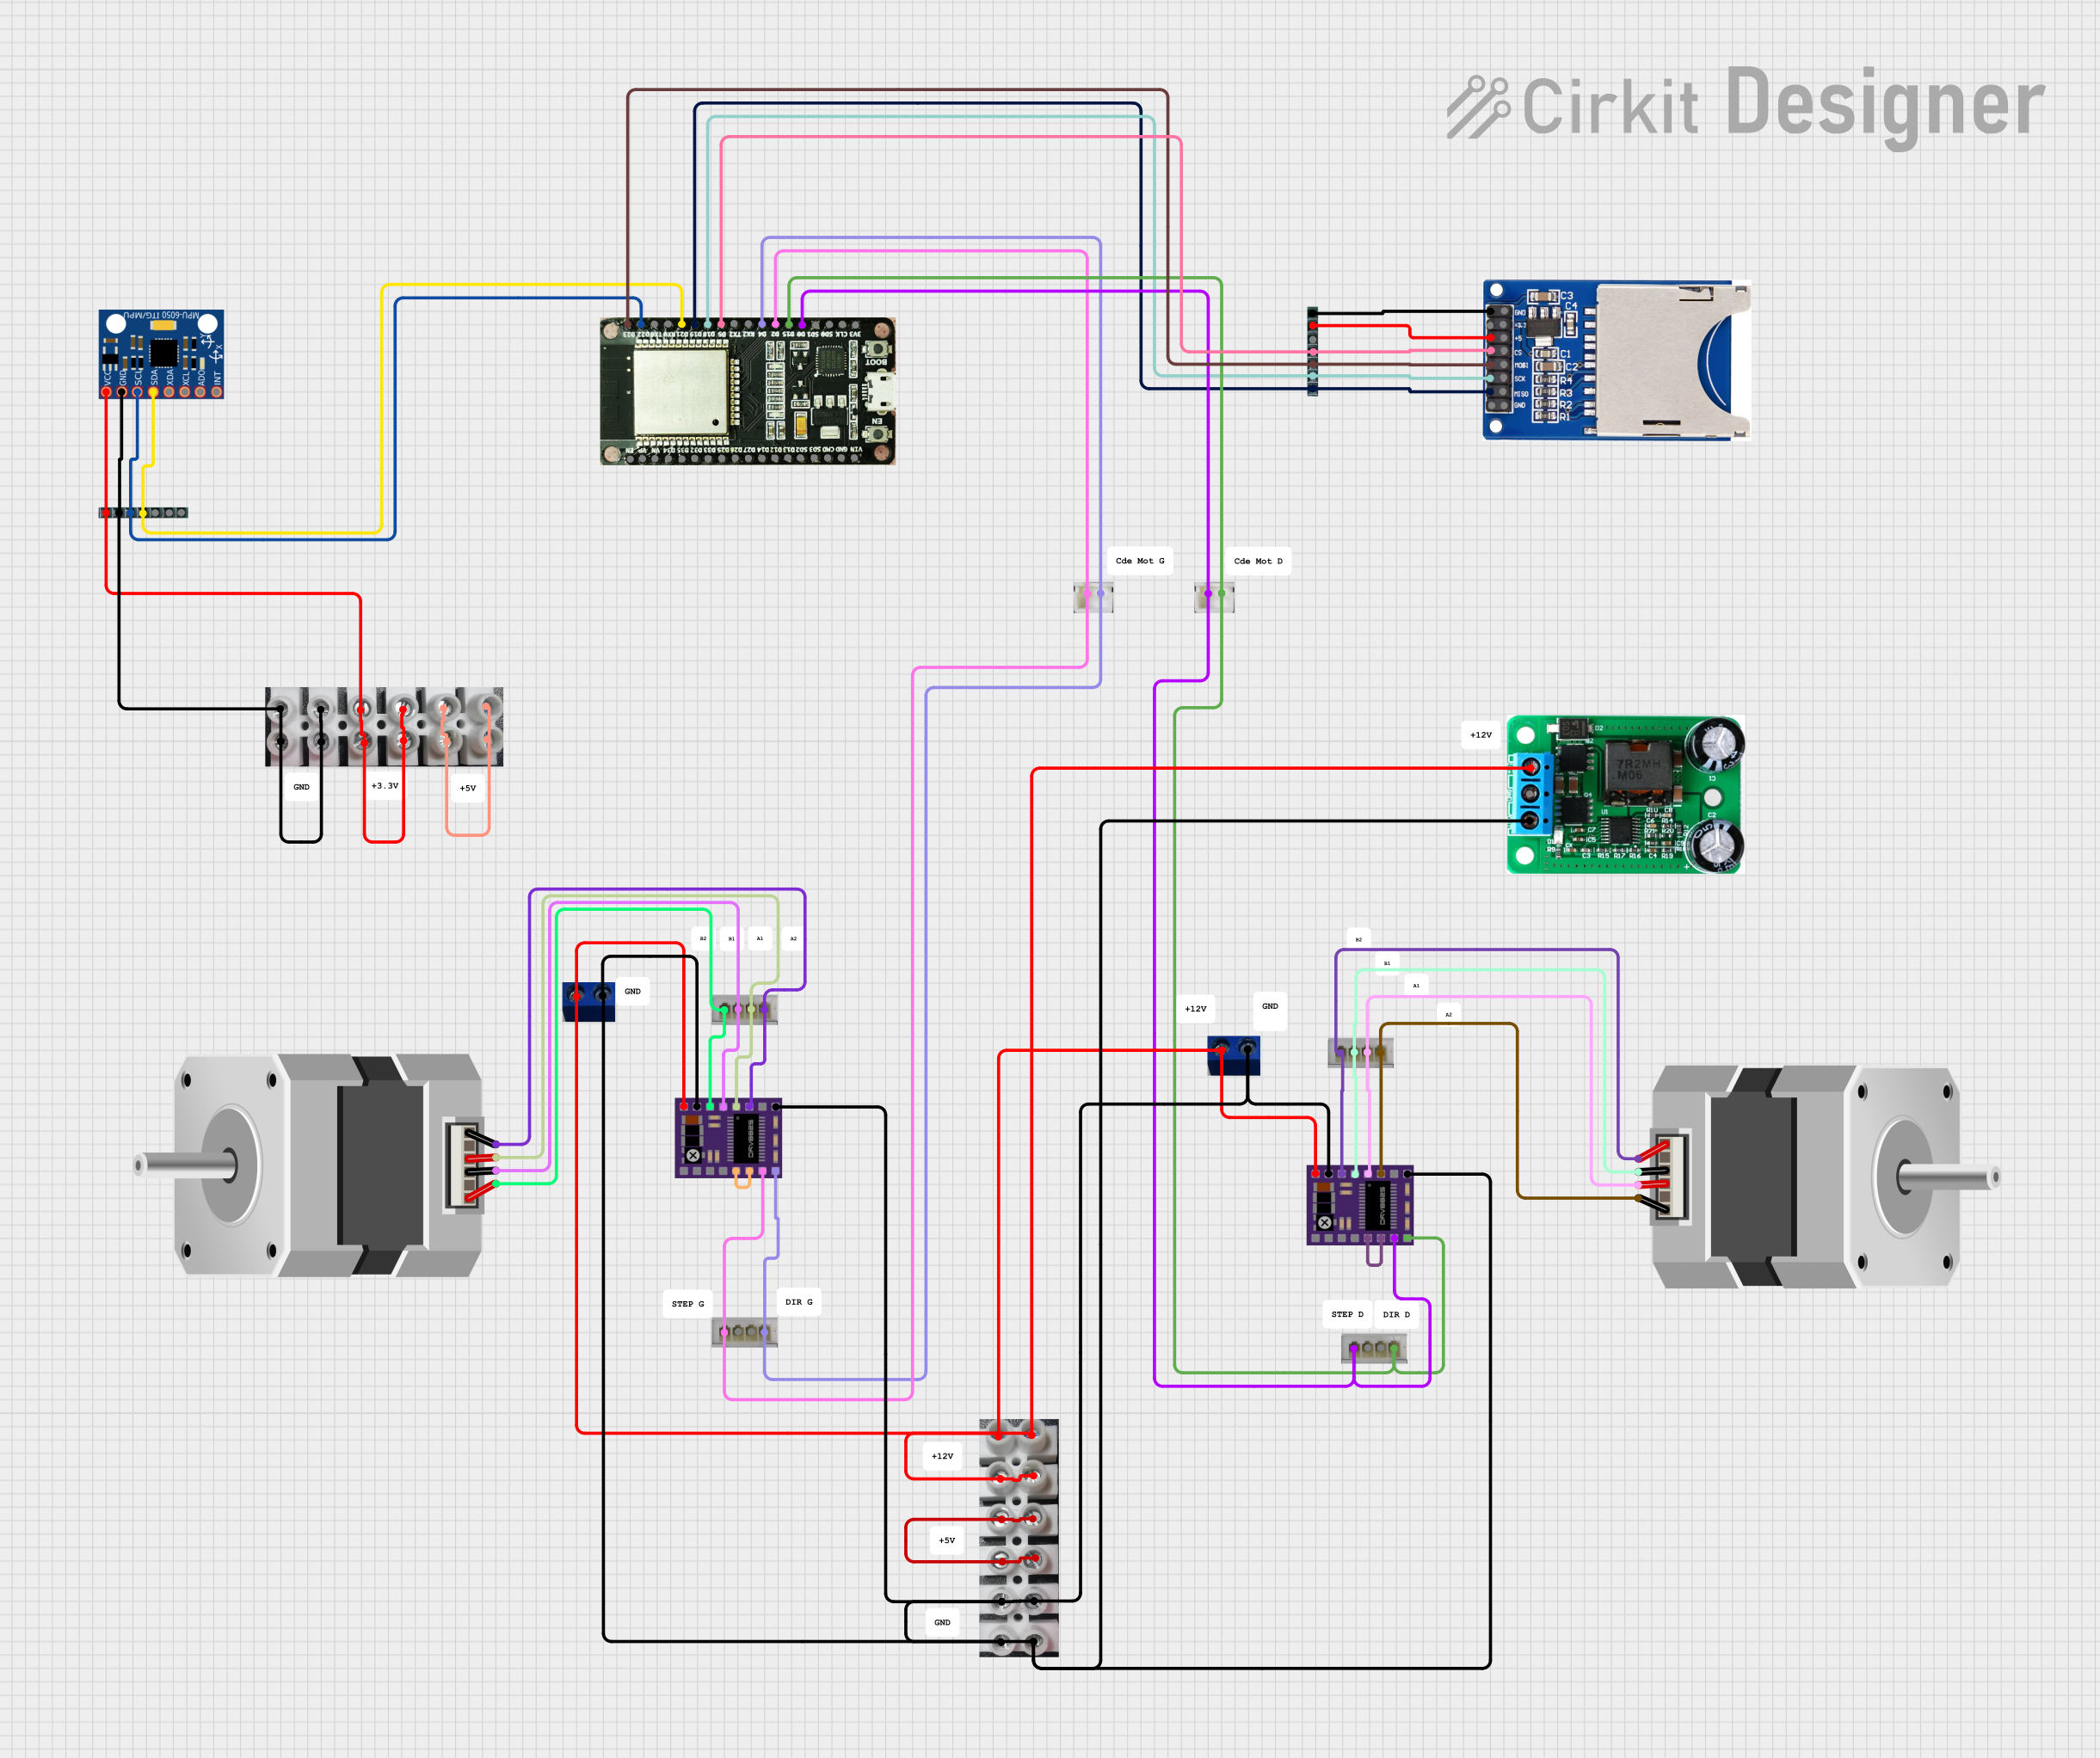
This circuit is designed for motion control and data logging. It uses an ESP32 microcontroller to manage two DRV8825 stepper motor drivers for precise movement, interfaces with an SD card reader for data storage, and incorporates an MPU-6050 for motion tracking. Power regulation and distribution are handled by conversion modules and dominos.
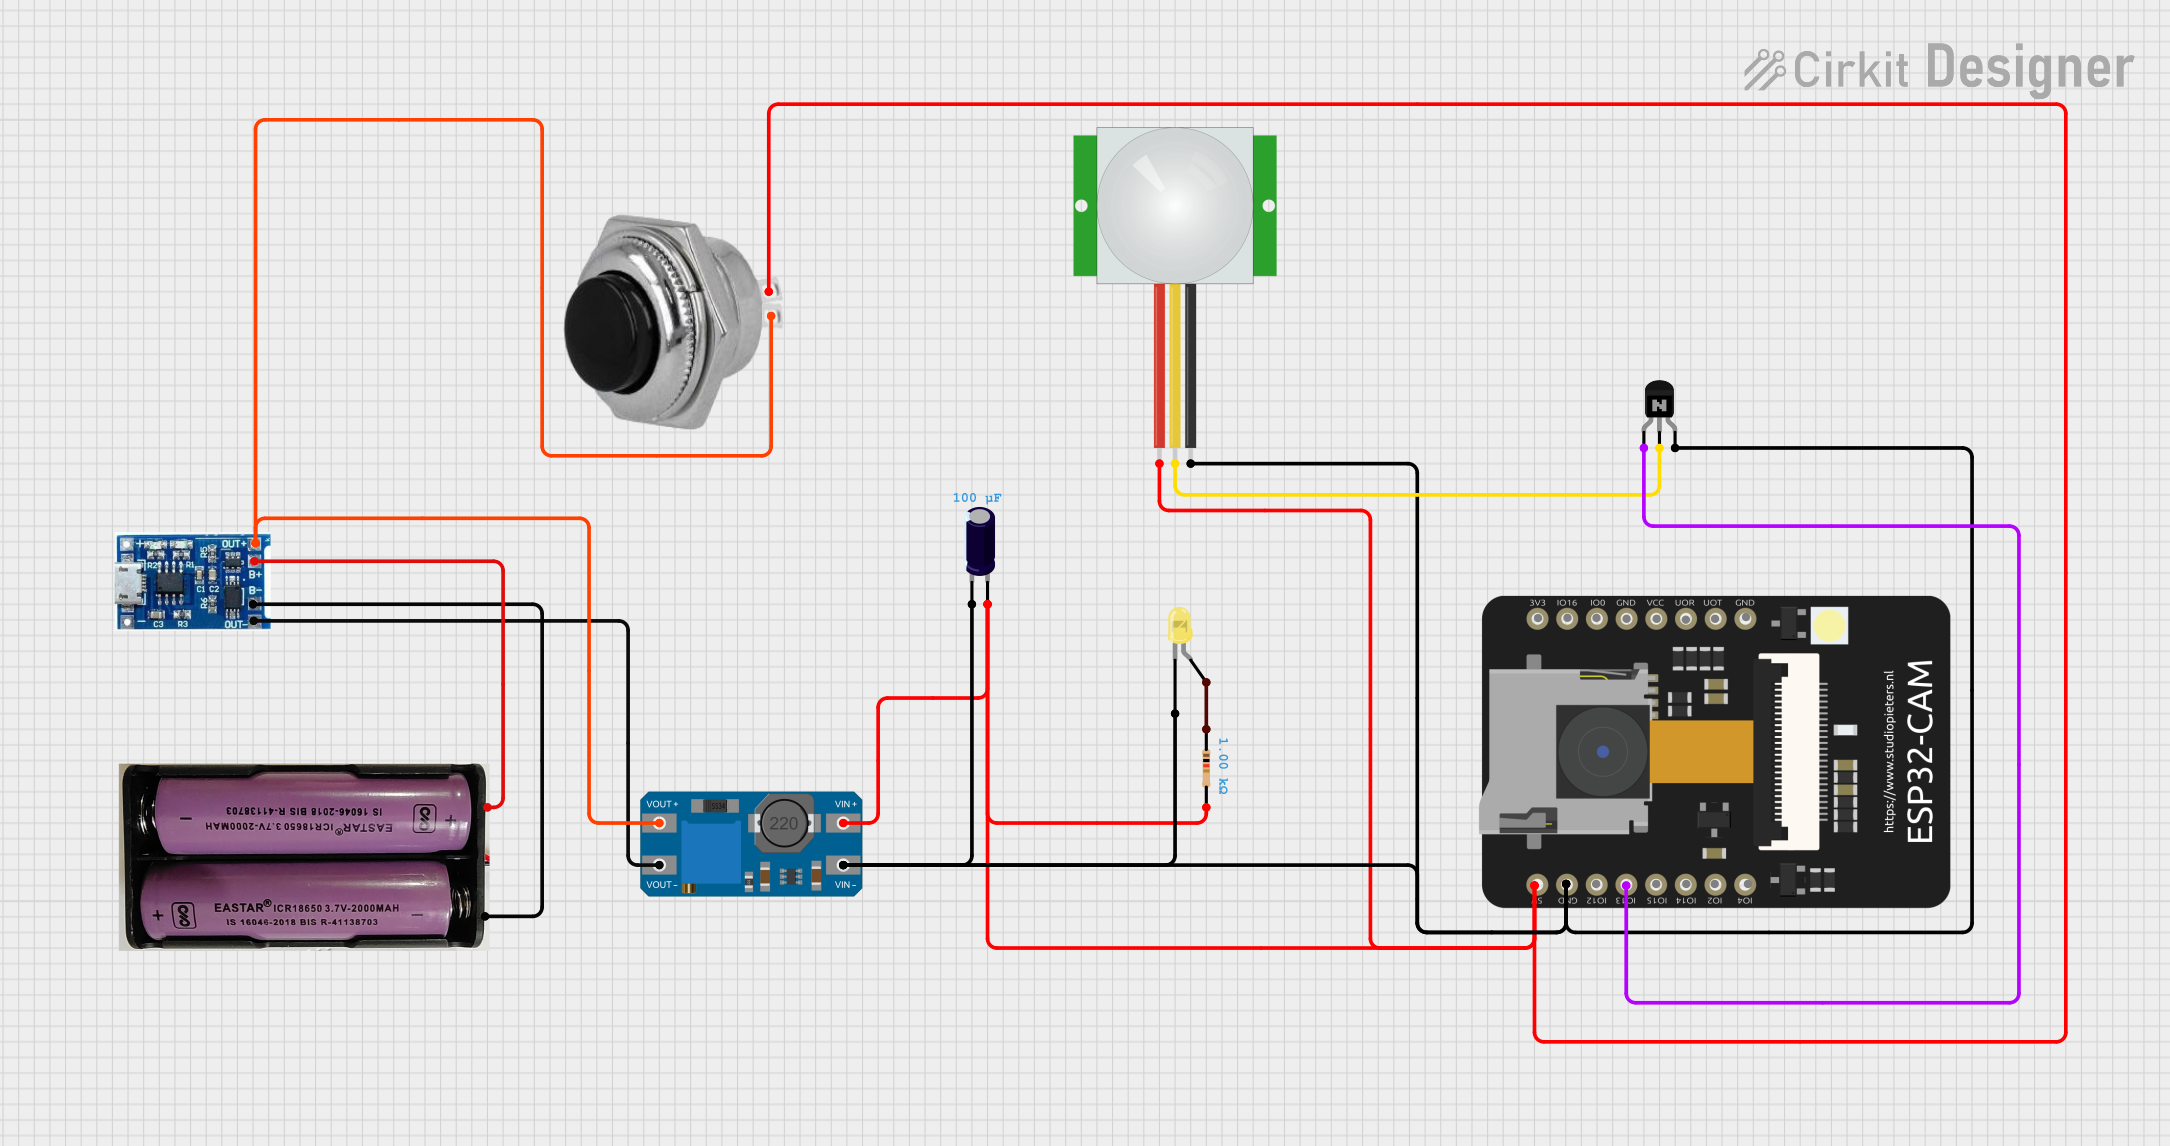
This is a motion-activated camera system powered by a 7.4V battery with a charging module. It uses a PIR sensor to detect motion and an ESP32 CAM microcontroller to process the signal and activate a yellow LED through an NPN transistor. A voltage booster and capacitor are included for power management, and a momentary switch allows for manual power control.
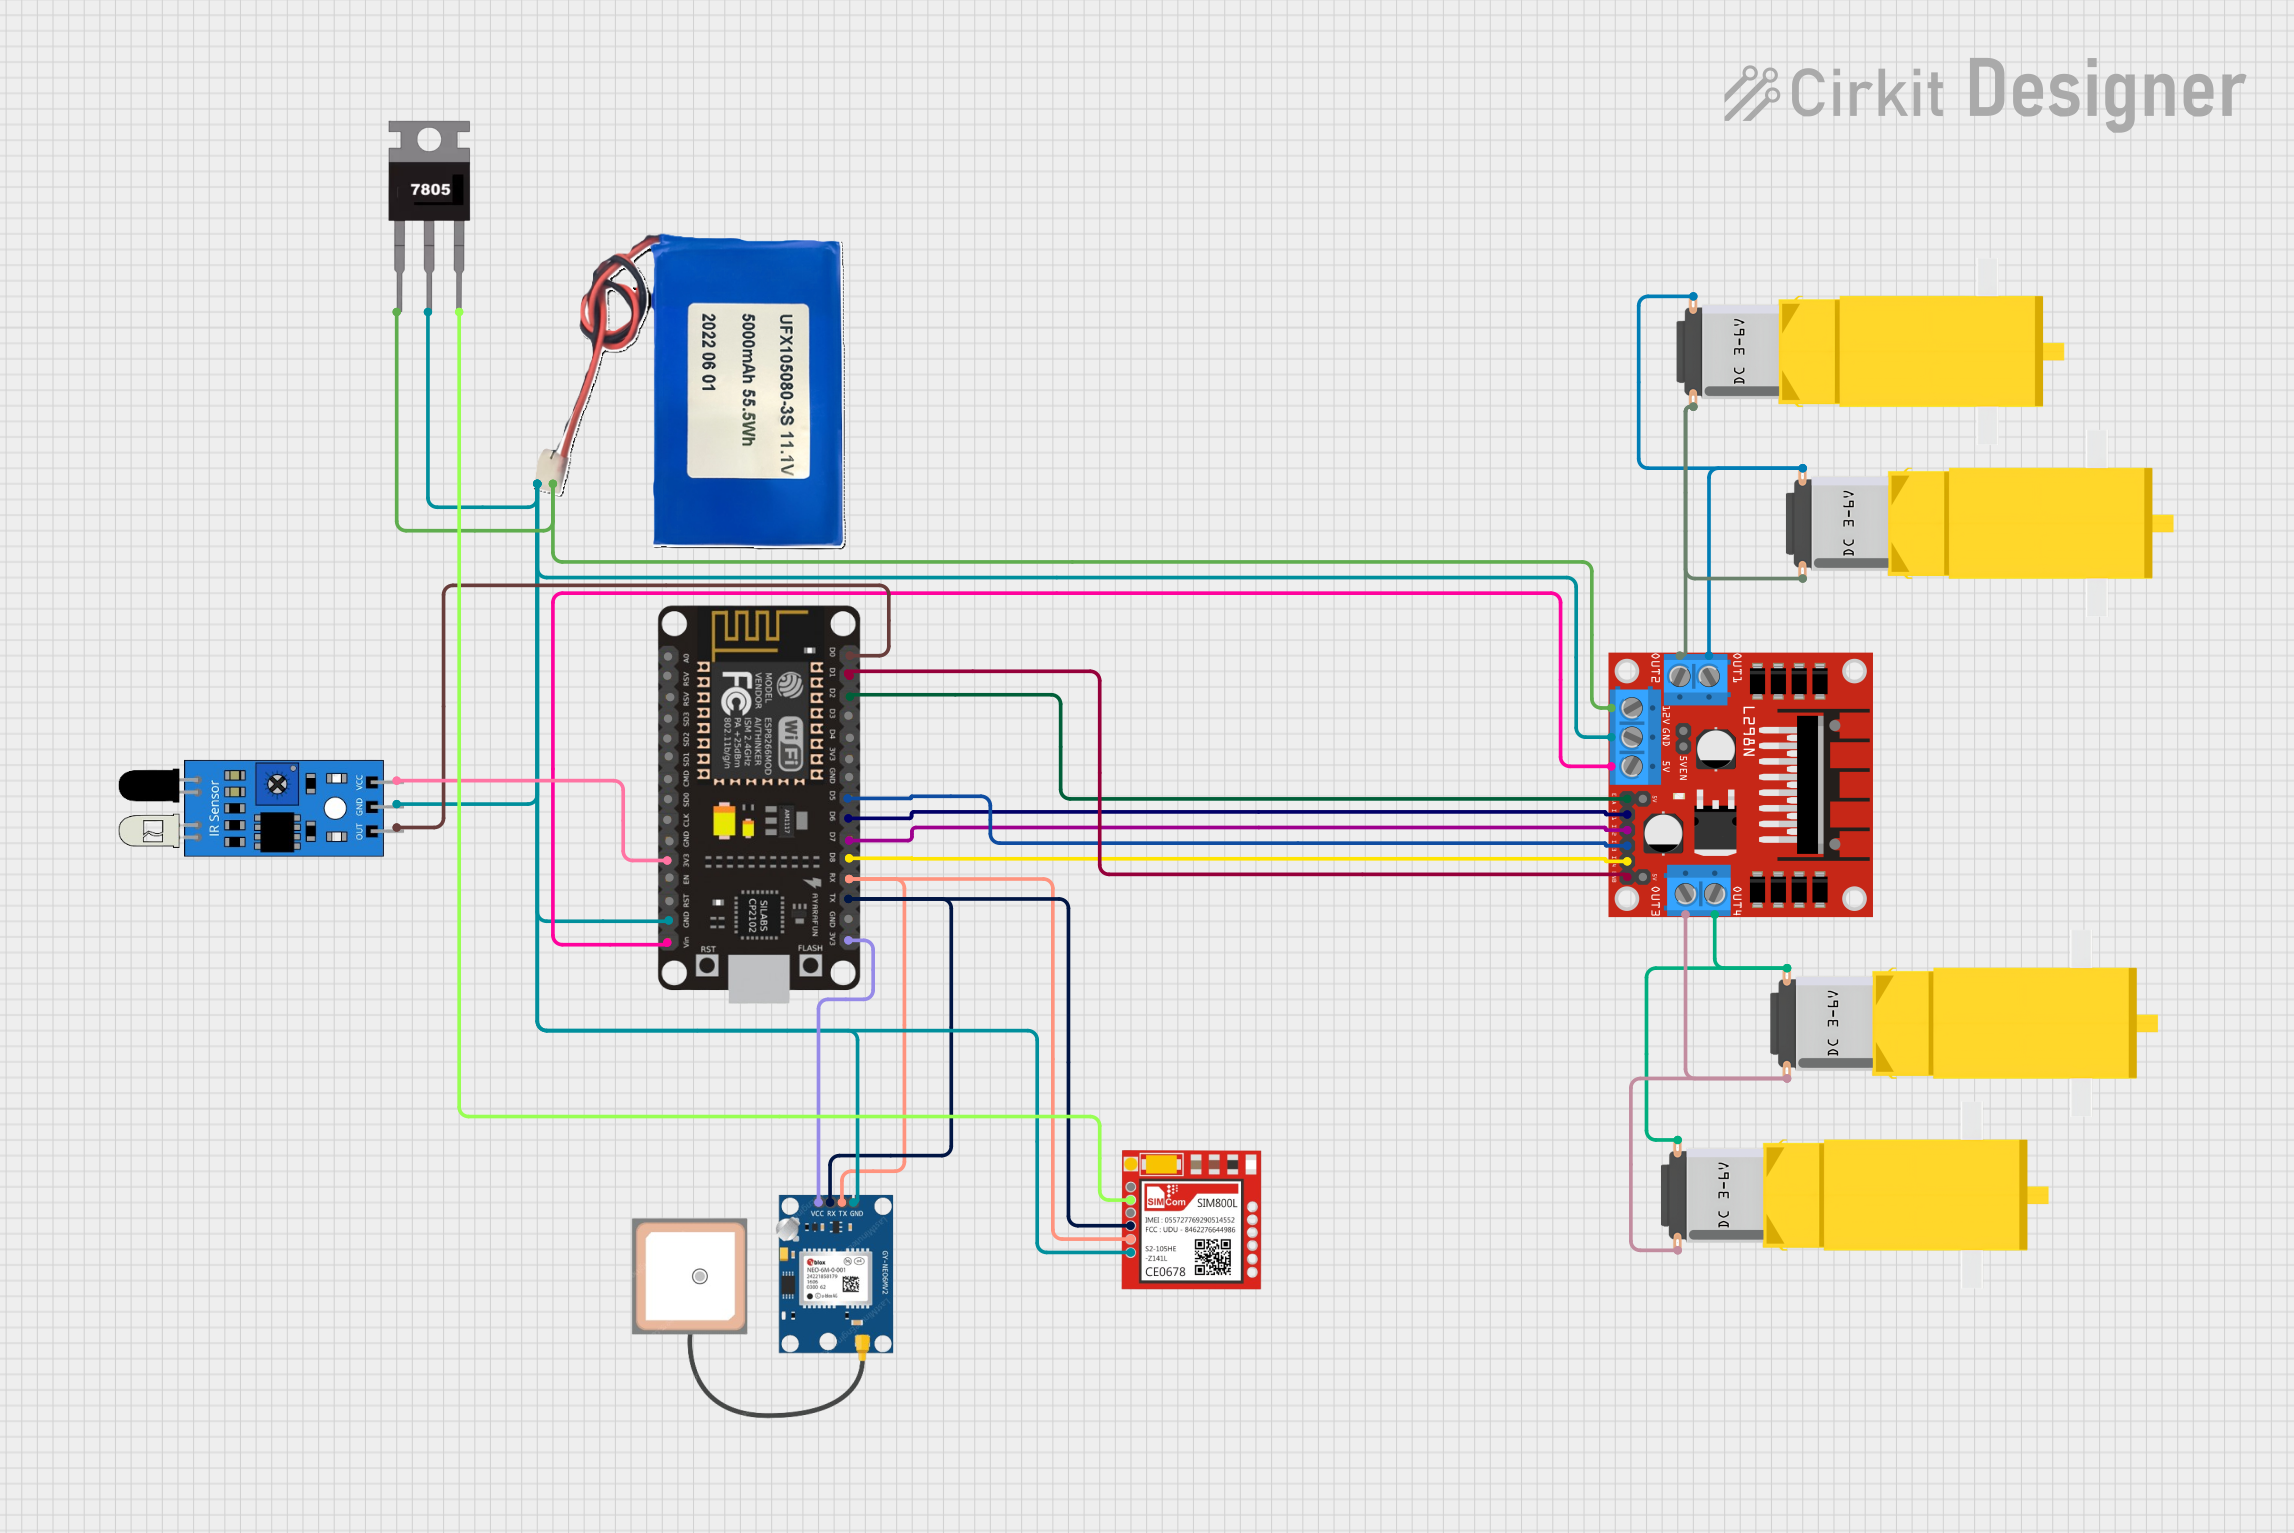
This circuit is designed for a 4-wheeled WiFi-controlled car with a basket, which uses an ESP8266 NodeMCU microcontroller for logic control. It features an IR sensor for basket full detection, a GPS module for location tracking, and a GSM module (Sim800l) for sending SMS notifications. The L298N motor driver controls four DC gearmotors for movement, and the system is powered by a Li-ion battery with a 7805 voltage regulator providing stable power to the GSM module.
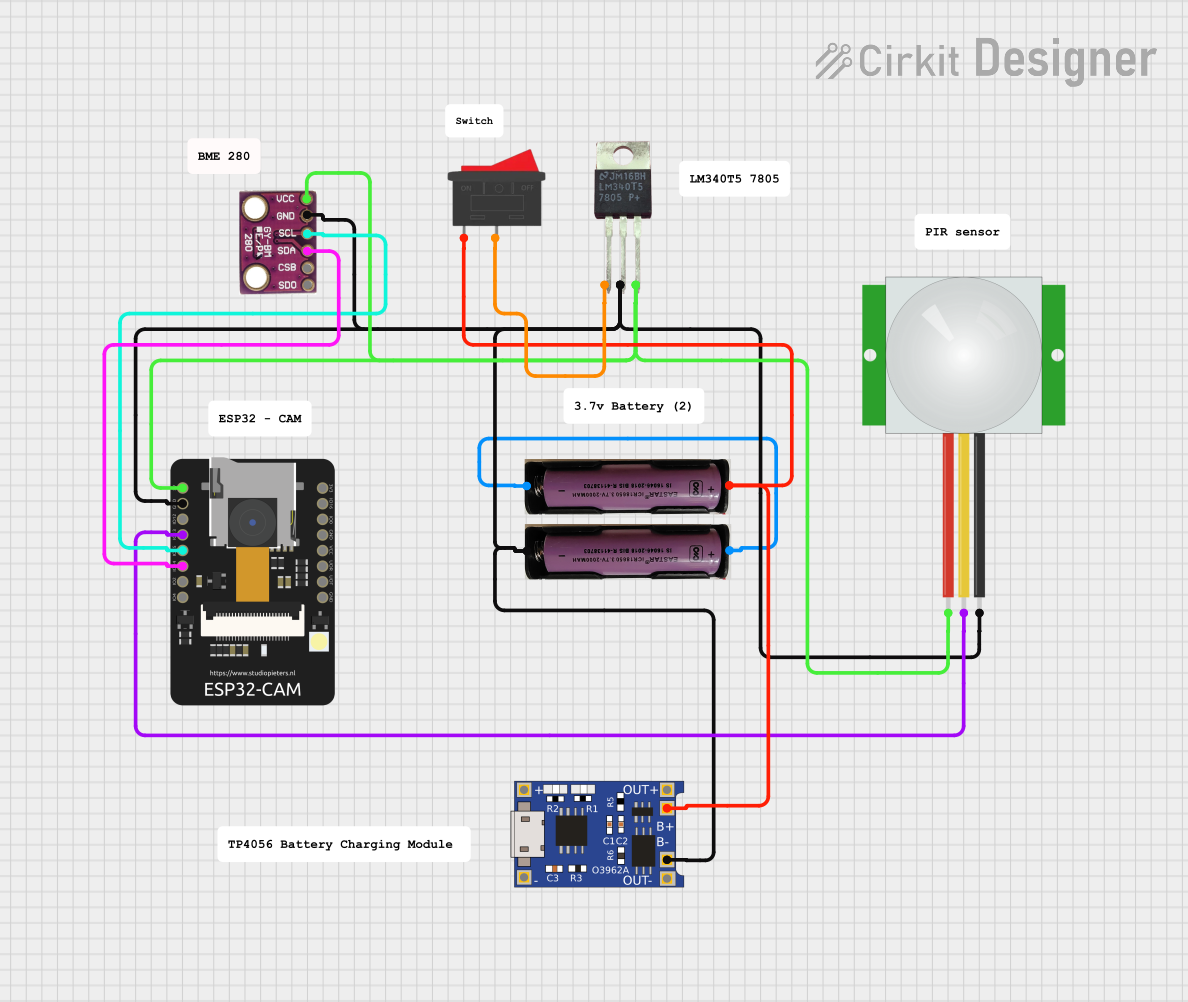
This circuit is a wireless surveillance system using an ESP32-CAM module, a PIR motion sensor, and a BMP280 sensor. The ESP32-CAM captures images and sends them via Telegram when motion is detected by the PIR sensor, while the BMP280 provides environmental data. The system is powered by a 3.7V battery, regulated to 5V using an LM340T5 7805 voltage regulator, and includes a TP4056 for battery charging.
The DVR8825 offers robust performance and flexibility for stepper motor control. Below are its key technical specifications:
Parameter
Value
Motor Voltage (VMOT)
8.2V to 45V
Logic Voltage (VDD)
3.3V or 5V
Maximum Current per Phase
2.2A (with sufficient cooling)
Microstepping Modes
Full, 1/2, 1/4, 1/8, 1/16, 1/32
Thermal Shutdown
Yes
Overcurrent Protection
Yes
Dimensions
15mm x 20mm
Pin Configuration and Descriptions
The DVR8825 module has 16 pins. Below is the pinout and description:
Pin Name
Type
Description
VMOT
Power Input
Motor power supply (8.2V to 45V). Connect a capacitor (100µF or higher) nearby.
GND
Power Ground
Ground connection for motor power supply.
VDD
Power Input
Logic power supply (3.3V or 5V).
GND
Power Ground
Ground connection for logic power supply.
STEP
Input
Step signal input. Each pulse moves the motor one step.
DIR
Input
Direction control input. High/Low determines motor rotation direction.
ENABLE
Input
Enable/disable the driver. Low = enabled, High = disabled.
MS1, MS2, MS3
Input
Microstepping mode selection pins.
RESET
Input
Resets the driver. Active low.
SLEEP
Input
Puts the driver into low-power sleep mode. Active low.
FAULT
Output
Fault indicator. Low when a fault condition occurs.
A1, A2
Output
Outputs for motor coil A.
B1, B2
Output
Outputs for motor coil B.
Microstepping Configuration
The microstepping mode is configured using the MS1, MS2, and MS3 pins. The table below shows the settings:
MS1
MS2
MS3
Microstepping Mode
Low
Low
Low
Full Step
High
Low
Low
1/2 Step
Low
High
Low
1/4 Step
High
High
Low
1/8 Step
Low
Low
High
1/16 Step
High
High
High
1/32 Step
Usage Instructions
Connecting the DVR8825 to a Stepper Motor
Power Supply: Connect VMOT and GND to the motor power supply (8.2V to 45V). Add a capacitor (100µF or higher) across these pins to prevent voltage spikes.
Logic Power: Connect VDD and GND to the logic power supply (3.3V or 5V).
Motor Connections: Connect the stepper motor coils to A1, A2, B1, and B2. Ensure the correct pairing of motor wires.
Control Pins: Connect STEP, DIR, and ENABLE to your microcontroller or control circuit. Use pull-up or pull-down resistors if necessary.
Microstepping: Set MS1, MS2, and MS3 to configure the desired microstepping mode.
Optional Pins: Connect RESET and SLEEP if you need to use these features. Otherwise, tie them to VDD to keep the driver active.
Example: Using the DVR8825 with Arduino UNO
Below is an example of how to control a stepper motor using the DVR8825 and an Arduino UNO:
Wiring Diagram
VMOT: Connect to a 12V power supply.
GND (VMOT): Connect to the power supply ground.
VDD: Connect to the Arduino 5V pin.
GND (VDD): Connect to the Arduino GND pin.
STEP: Connect to Arduino pin 3.
DIR: Connect to Arduino pin 4.
ENABLE: Connect to Arduino pin 5 (optional, can be tied to GND for always enabled).
Arduino Code
// Define pin connections
#define STEP_PIN 3  // Pin connected to STEP
#define DIR_PIN 4   // Pin connected to DIR
#define ENABLE_PIN 5 // Pin connected to ENABLE (optional)

void setup() {
  // Set pin modes
  pinMode(STEP_PIN, OUTPUT);
  pinMode(DIR_PIN, OUTPUT);
  pinMode(ENABLE_PIN, OUTPUT);

  // Enable the driver
  digitalWrite(ENABLE_PIN, LOW); // LOW = enabled
}

void loop() {
  // Set direction
  digitalWrite(DIR_PIN, HIGH); // HIGH = one direction, LOW = opposite

  // Generate step pulses
  for (int i = 0; i < 200; i++) { // 200 steps for one revolution (1.8°/step motor)
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(500); // Adjust for speed
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(500);
  }

  delay(1000); // Wait 1 second before reversing direction

  // Reverse direction
  digitalWrite(DIR_PIN, LOW);
  for (int i = 0; i < 200; i++) {
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(500);
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(500);
  }

  delay(1000); // Wait 1 second before repeating
}
Best Practices
Use a heatsink or active cooling if driving motors at high current.
Always power the logic circuit (VDD) before the motor power (VMOT) to avoid damage.
Avoid disconnecting the motor while the driver is powered to prevent damage to the driver.
Troubleshooting and FAQs
Common Issues
Motor Not Moving:
Check the power supply connections (VMOT and VDD).
Verify the STEP and DIR signals from the microcontroller.
Ensure the motor wires are correctly paired and connected.
Overheating:
Use a heatsink or active cooling.
Reduce the current limit using the potentiometer.
Driver Not Enabling:
Ensure the ENABLE pin is set to LOW.
Check the logic power supply (VDD).
Erratic Motor Movement:
Verify the microstepping configuration (MS1, MS2, MS3).
Check for loose or incorrect wiring.
FAQs
Q: How do I set the current limit?
A: Adjust the potentiometer on the DVR8825 while monitoring the reference voltage (VREF). Use the formula: Current Limit = VREF × 2 (for full-step mode).
Q: Can I use the DVR8825 with a 3.3V microcontroller?
A: Yes, the DVR8825 supports logic levels of 3.3V and 5V.
Q: What happens if the driver overheats?
A: The DVR8825 has thermal shutdown protection. It will disable itself until the temperature drops to a safe level.

 Open Project in Cirkit Designer