A motor driver is an electronic circuit designed to control the operation of a motor by regulating its speed and direction. It typically achieves this by using Pulse Width Modulation (PWM) signals. Motor drivers act as an interface between microcontrollers (or other control systems) and motors, as microcontrollers often cannot supply the required current or voltage to drive motors directly.
Explore Projects Built with Motor Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
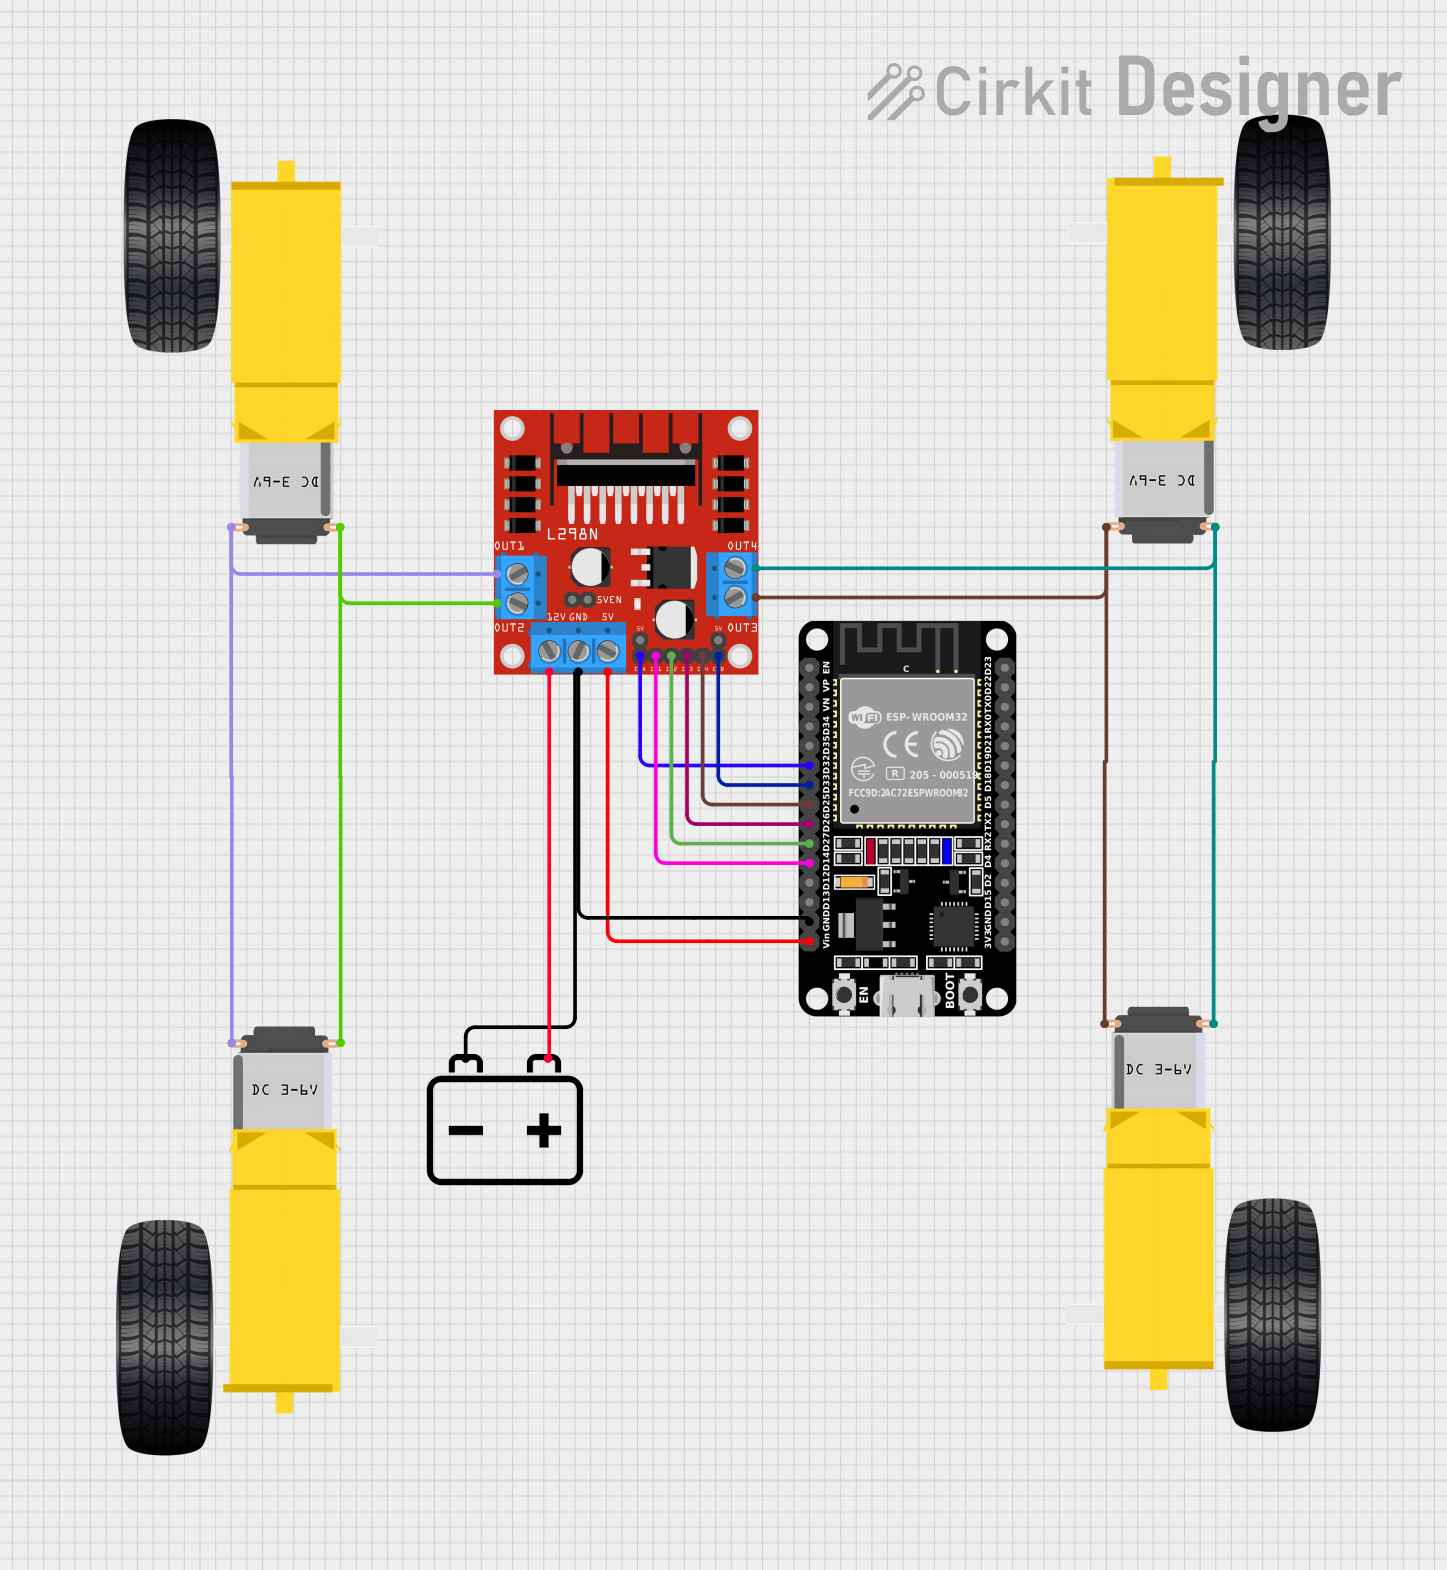
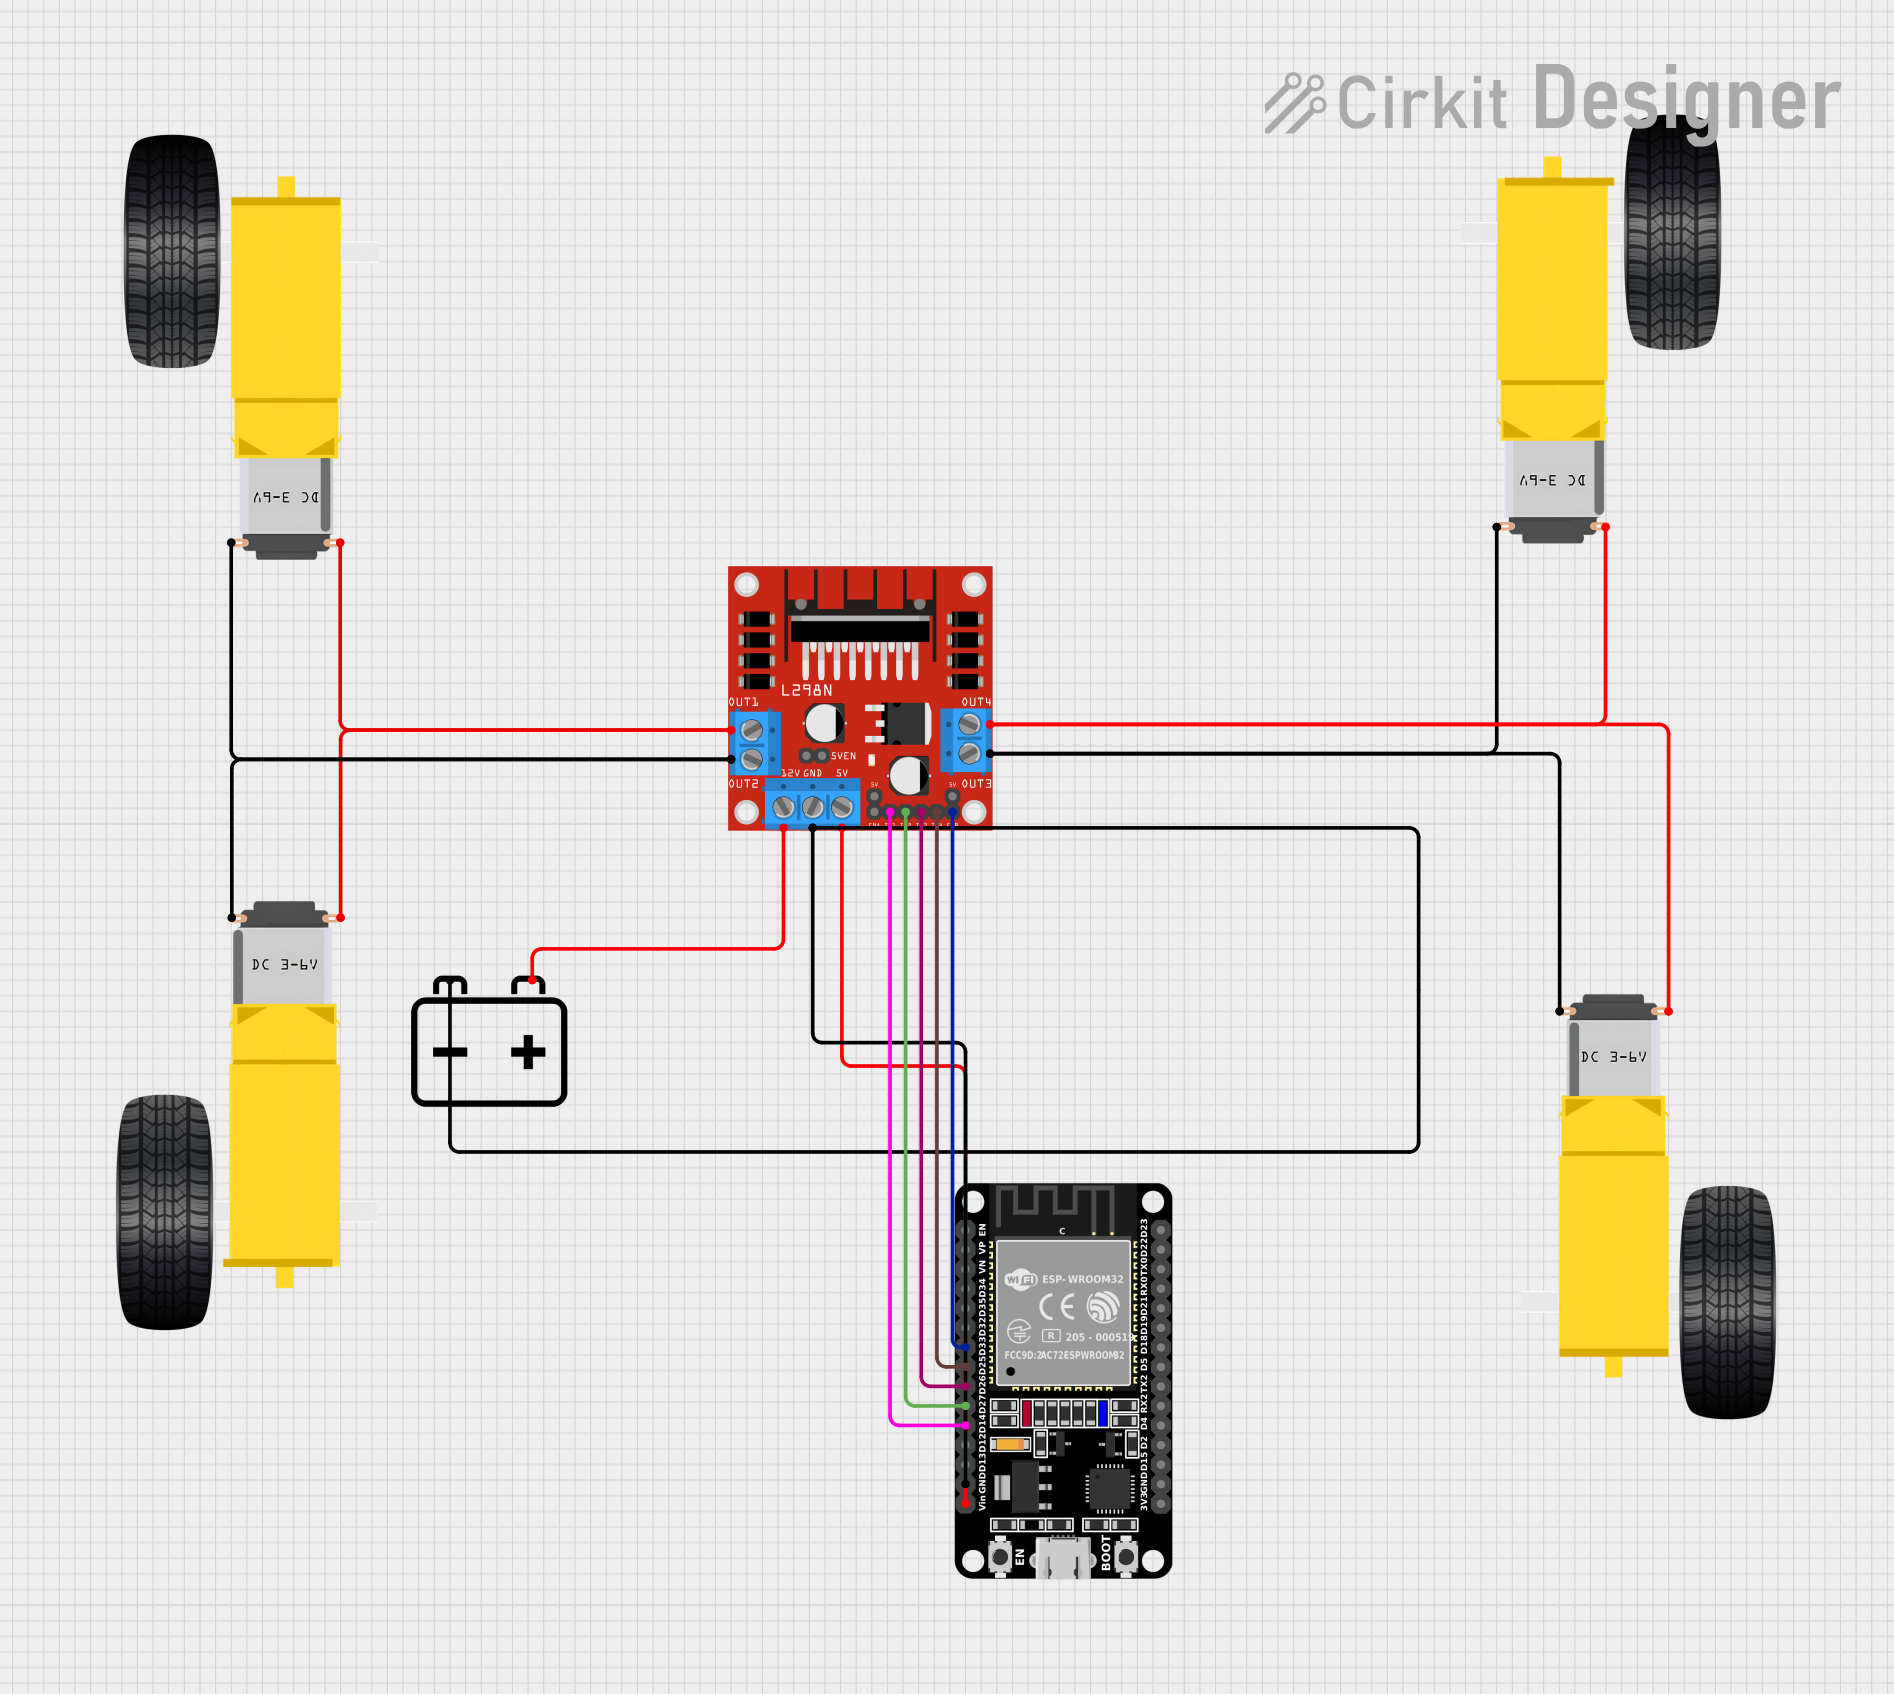
This circuit is a motor control system powered by a 12V battery, utilizing an L298N motor driver to control four DC gearmotors. An ESP32 microcontroller is used to send control signals to the motor driver, enabling precise control of the motors for applications such as a robotic vehicle.
This circuit is designed to control four DC gearmotors using an L298N motor driver module, which is interfaced with an ESP32 microcontroller. The ESP32 uses its GPIO pins to send control signals to the L298N driver, enabling the independent operation of the motors, such as direction and speed control. Power is supplied by a 12V battery connected to the motor driver, with the ESP32 receiving its power through a voltage regulator on the L298N module.
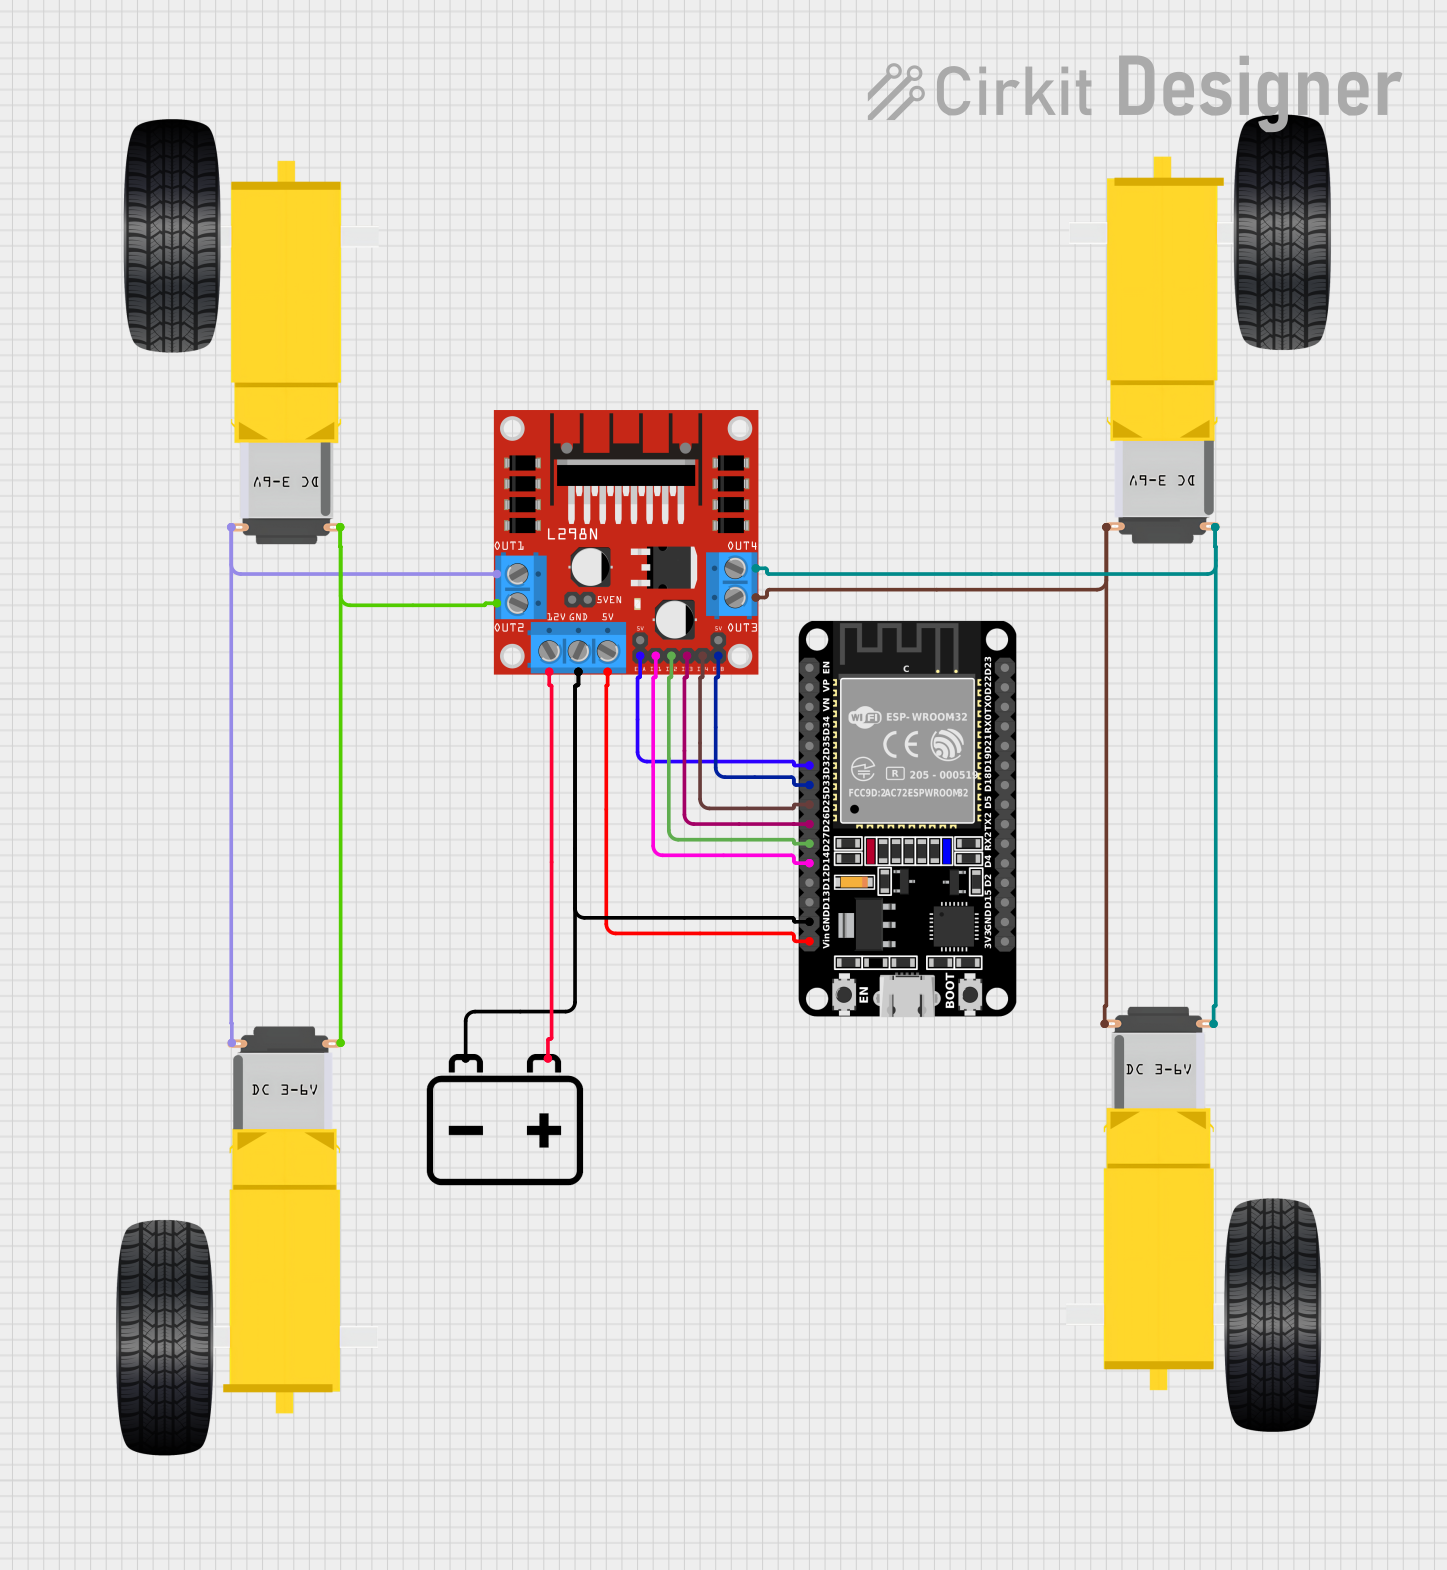
This circuit is a motor control system using an ESP32 microcontroller and an L298N motor driver to control four DC gear motors. The ESP32 provides control signals to the L298N, which in turn drives the motors, powered by a 12V battery, enabling bidirectional control of the motors for applications such as a robotic vehicle.
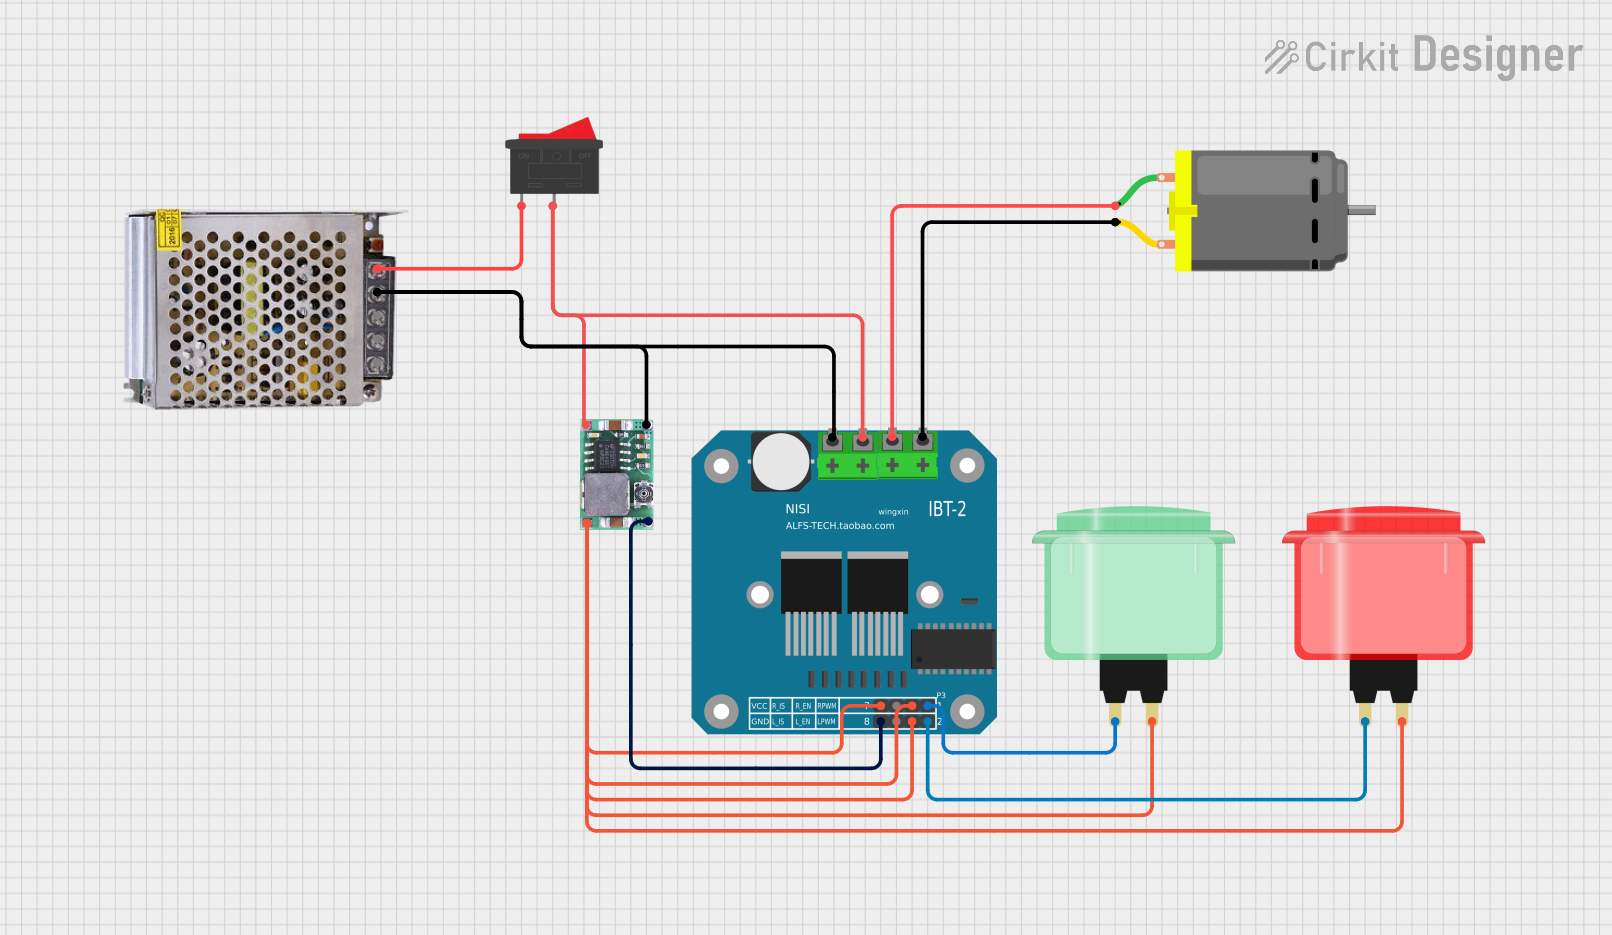
This circuit controls a DC motor using a BTS7960 motor driver, powered by a 12V power supply and regulated by a DC-DC step-down converter. The motor's operation is controlled via two arcade buttons and a rocker switch, allowing for user input to manage the motor's direction and power.
Robotics: Controlling DC motors, stepper motors, or servo motors in robotic systems.
Industrial Automation: Driving conveyor belts, pumps, or other motorized equipment.
Electric Vehicles: Managing motor speed and direction in electric bikes or cars.
Home Automation: Operating fans, curtains, or other motorized devices.
DIY Projects: Building remote-controlled cars, drones, or other hobbyist projects.
Technical Specifications
Below are the general technical specifications for a typical motor driver (e.g., L298N Dual H-Bridge Motor Driver):
Key Technical Details
Operating Voltage: 5V to 35V
Output Current: Up to 2A per channel (continuous), 3A peak
Control Logic Voltage: 3.3V or 5V (compatible with most microcontrollers)
Number of Channels: 2 (can control two motors independently)
PWM Frequency: Up to 25 kHz
Built-in Protection: Thermal shutdown and overcurrent protection
Pin Configuration and Descriptions
The following table describes the pinout for a typical motor driver module:
Pin Name
Type
Description
VCC
Power Input
Connect to the motor power supply (5V to 35V).
GND
Ground
Common ground for the motor driver and the control circuit.
5V
Power Output
Provides 5V output (used to power the control circuit if needed).
IN1, IN2
Control Input
Logic inputs to control the direction of Motor A.
IN3, IN4
Control Input
Logic inputs to control the direction of Motor B.
ENA
PWM Input
Enables and controls the speed of Motor A using a PWM signal.
ENB
PWM Input
Enables and controls the speed of Motor B using a PWM signal.
OUT1, OUT2
Motor Output
Connect to the terminals of Motor A.
OUT3, OUT4
Motor Output
Connect to the terminals of Motor B.
Usage Instructions
How to Use the Component in a Circuit
Power Connections:
Connect the motor power supply to the VCC pin and the ground to the GND pin.
If your microcontroller operates at 5V, you can use the 5V pin on the motor driver to power it.
Motor Connections:
Connect the terminals of Motor A to OUT1 and OUT2.
Connect the terminals of Motor B to OUT3 and OUT4 (if using a second motor).
Control Connections:
Connect the control pins (IN1, IN2, IN3, IN4) to the digital output pins of your microcontroller.
Use the ENA and ENB pins to control the speed of the motors via PWM signals.
Direction Control:
Set the logic levels of IN1 and IN2 to control the direction of Motor A.
Similarly, use IN3 and IN4 for Motor B.
Speed Control:
Apply a PWM signal to the ENA pin to control the speed of Motor A.
Apply a PWM signal to the ENB pin to control the speed of Motor B.
Important Considerations and Best Practices
Ensure the motor driver’s current and voltage ratings match the requirements of your motors.
Use a heat sink or cooling fan if the motor driver gets too hot during operation.
Always connect the ground of the motor driver to the ground of the microcontroller to ensure proper operation.
Avoid exceeding the maximum current and voltage ratings to prevent damage to the motor driver.
Example Code for Arduino UNO
Below is an example code to control a DC motor using an L298N motor driver and an Arduino UNO:
// Define motor control pins
const int IN1 = 7;  // Motor A direction control pin 1
const int IN2 = 8;  // Motor A direction control pin 2
const int ENA = 9;  // Motor A speed control (PWM) pin

void setup() {
  // Set motor control pins as outputs
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  pinMode(ENA, OUTPUT);
}

void loop() {
  // Rotate motor forward
  digitalWrite(IN1, HIGH);  // Set IN1 high
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 128);    // Set speed to 50% (PWM value: 128 out of 255)
  delay(2000);              // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 0);      // Set speed to 0
  delay(1000);              // Wait for 1 second

  // Rotate motor backward
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, HIGH);  // Set IN2 high
  analogWrite(ENA, 128);    // Set speed to 50% (PWM value: 128 out of 255)
  delay(2000);              // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 0);      // Set speed to 0
  delay(1000);              // Wait for 1 second
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Running:
Cause: Incorrect wiring or loose connections.
Solution: Double-check all connections, especially the motor power supply and control pins.
Motor Running in the Wrong Direction:
Cause: Control pins (IN1, IN2, etc.) are not set correctly.
Solution: Swap the logic levels of the control pins to reverse the motor direction.
Motor Driver Overheating:
Cause: Excessive current draw from the motor.
Solution: Use a motor with lower current requirements or add a heat sink to the motor driver.
PWM Signal Not Controlling Speed:
Cause: Incorrect PWM pin configuration or incompatible frequency.
Solution: Verify the PWM pin and ensure the frequency is within the motor driver’s supported range.
FAQs
Can I use the motor driver with a 3.3V microcontroller?
Yes, most motor drivers are compatible with 3.3V logic levels, but check the datasheet to confirm.
What type of motors can I control with this driver?
You can control DC motors and stepper motors. For stepper motors, additional control logic may be required.
Can I power the motor driver and the microcontroller from the same power source?
Yes, but ensure the power source can supply sufficient current for both the motor and the microcontroller.
How do I control two motors independently?
Use IN1, IN2, and ENA for Motor A, and IN3, IN4, and ENB for Motor B. Configure them separately in your code.

 Open Project in Cirkit Designer