The [SEENGREAT] 라즈베리파이용 2채널 CAN 버스 확장 모듈 [220488] is a dual-channel CAN (Controller Area Network) bus expansion module designed specifically for Raspberry Pi. This module allows Raspberry Pi to communicate with CAN bus devices, making it ideal for automotive, industrial, and IoT applications. It supports high-speed communication and is compatible with a wide range of CAN-enabled devices.
Explore Projects Built with [SEENGREAT] 라즈베리파이용 2채널 CAN 버스 확장 모듈 [220488]
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
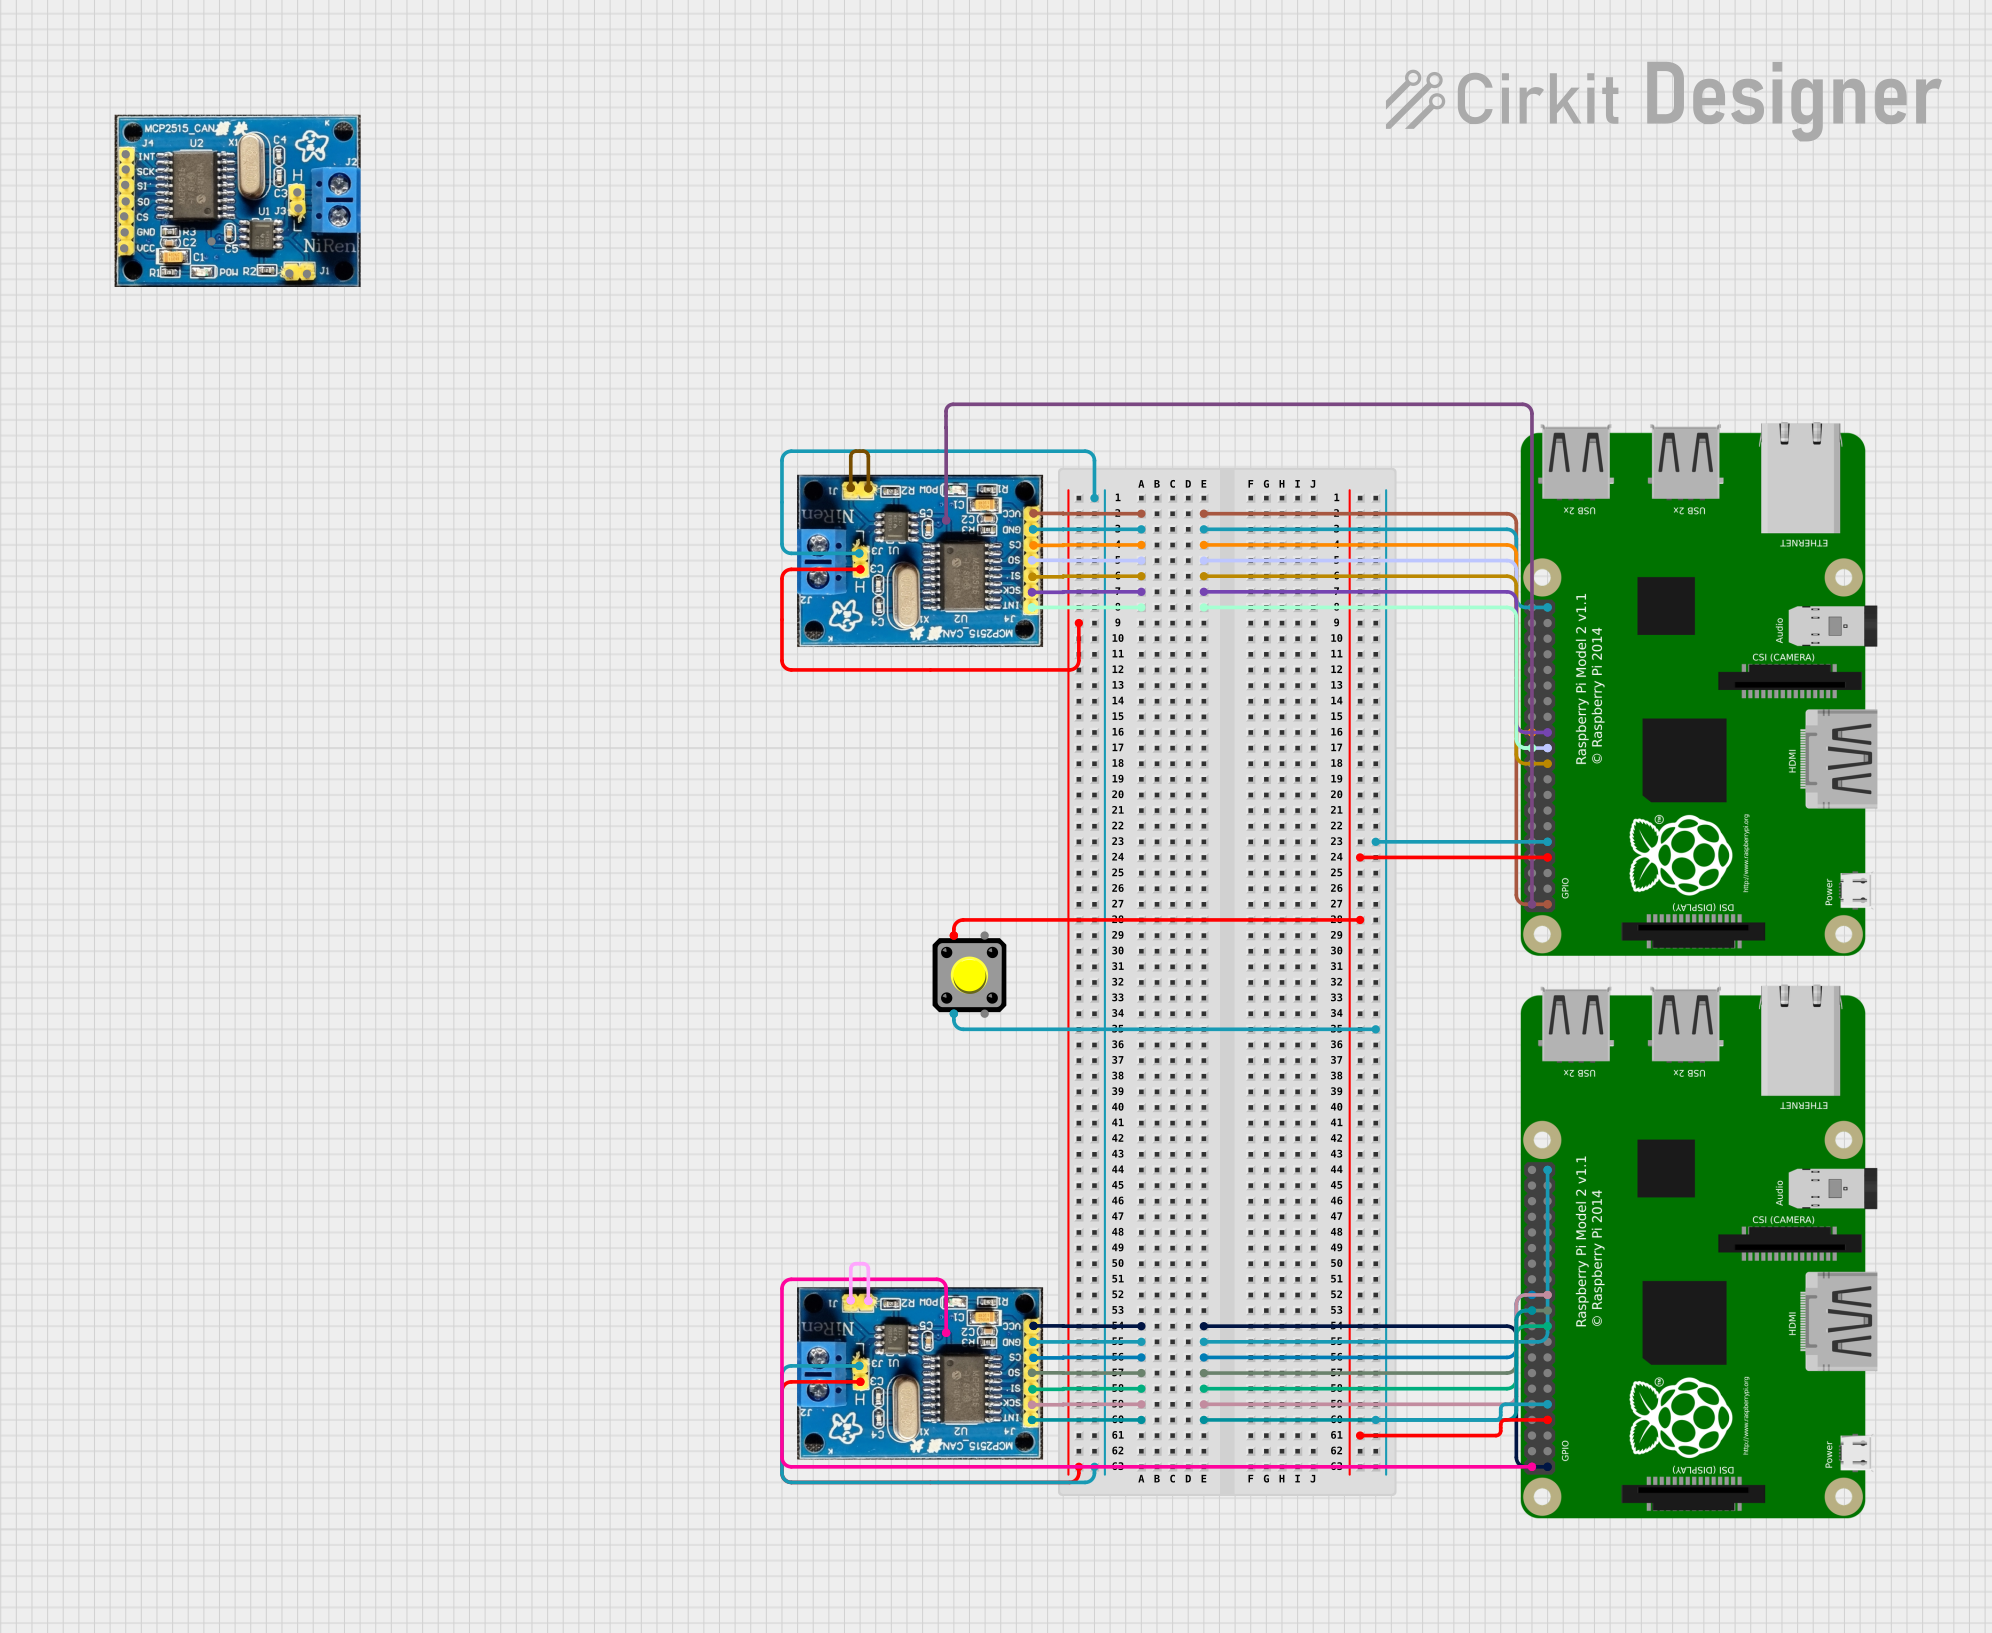
This circuit features two Raspberry Pi 2B microcontrollers connected to separate CAN BUS modules, forming a CAN network for data exchange. A pushbutton is included for user interaction, interfaced with GPIO pins on both Raspberry Pis.
This circuit features a LilyGo-SIM7000G module for cellular communication and GPS functionality, interfaced with an RTC DS3231 for real-time clock capabilities. It includes voltage sensing through two voltage sensor modules, and uses an 8-channel opto-coupler for isolating different parts of the circuit. Power management is handled by a buck converter connected to a DC power source and batteries, with a fuse for protection and a rocker switch for on/off control. Additionally, there's an LED for indication purposes.
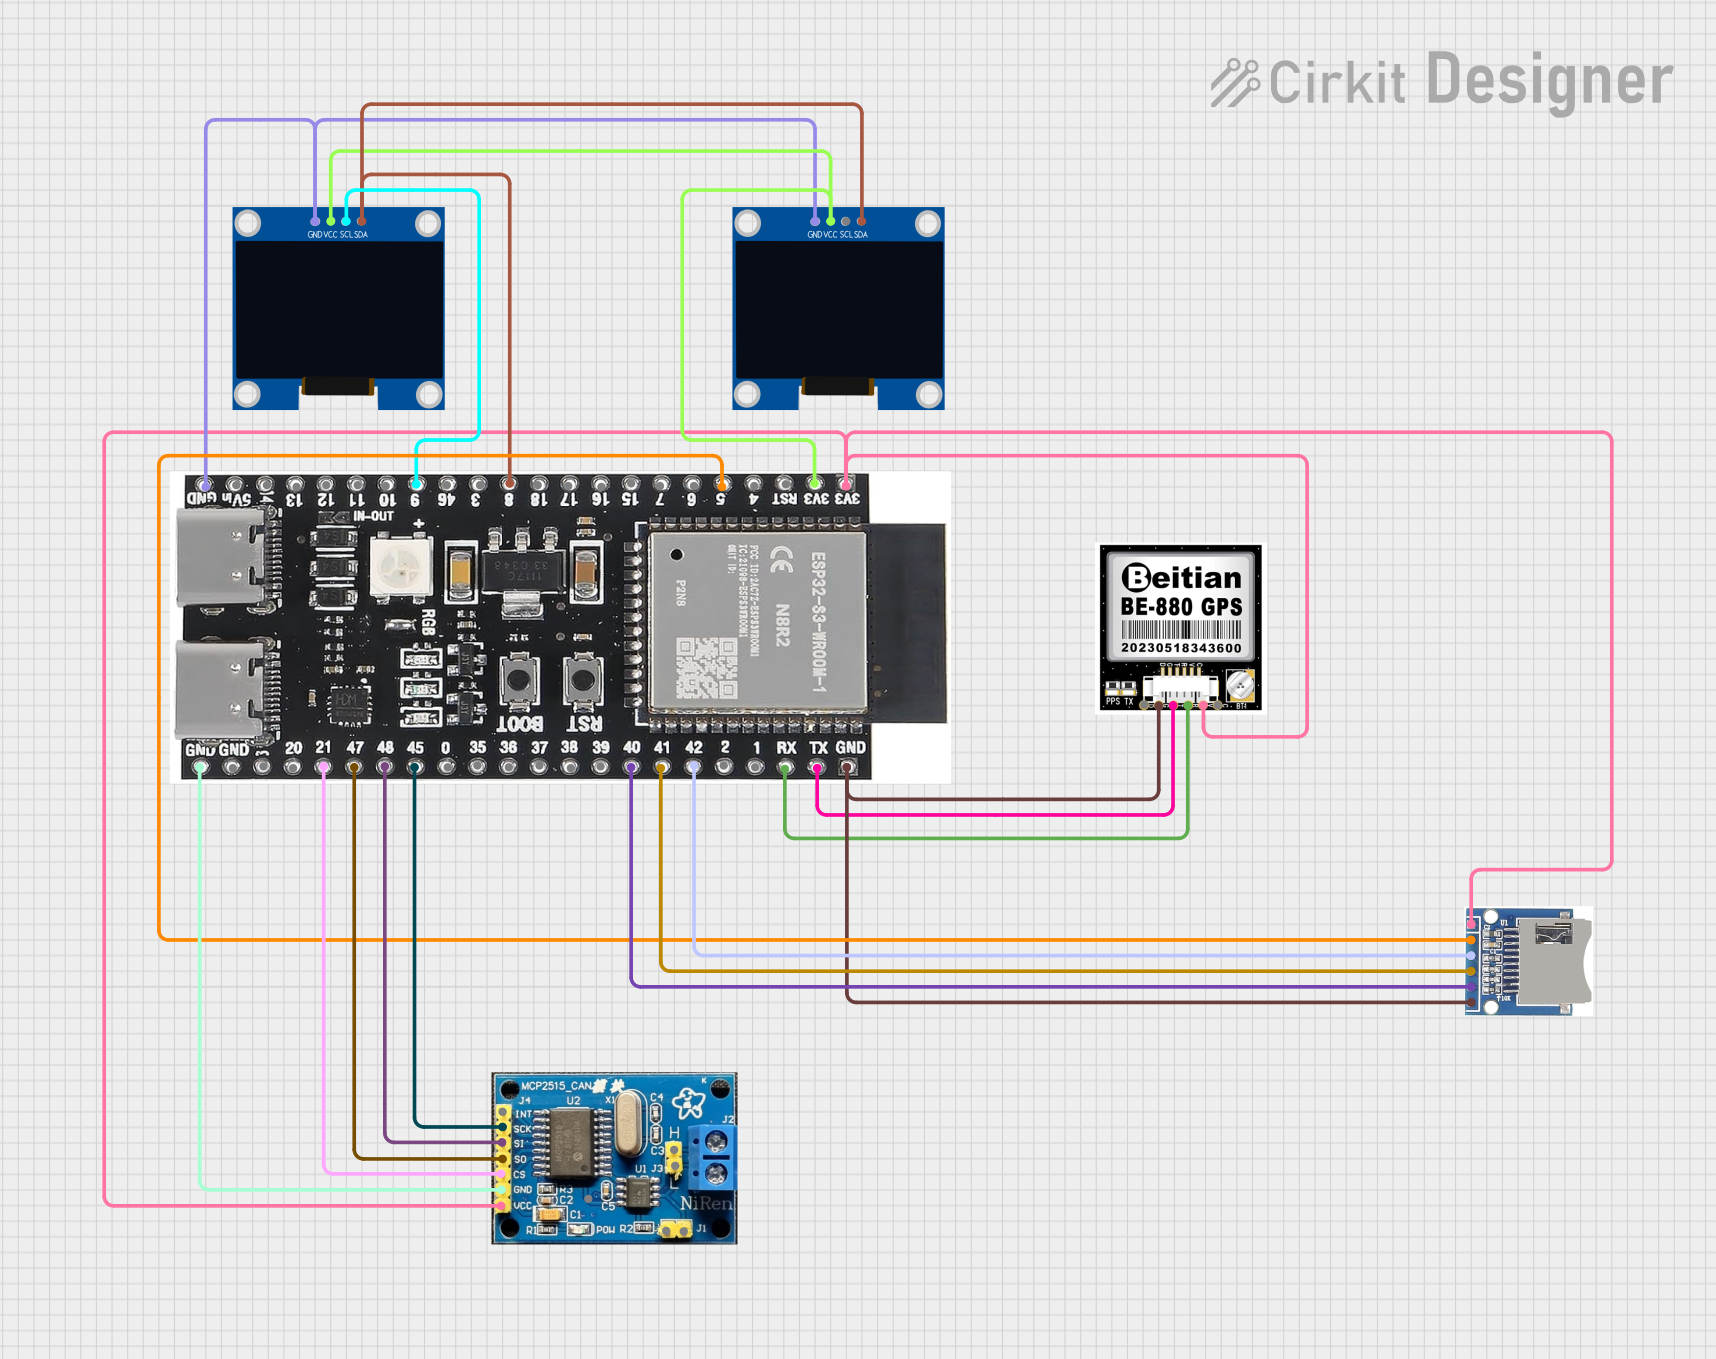
This circuit features an ESP32-S3 microcontroller interfaced with an SD card module, two OLED displays, a GPS module, and a CAN bus module. The ESP32-S3 records GPS data to the SD card, displays speed on one OLED, and shows wind speed from the CAN bus on the other OLED, providing a comprehensive data logging and display system.
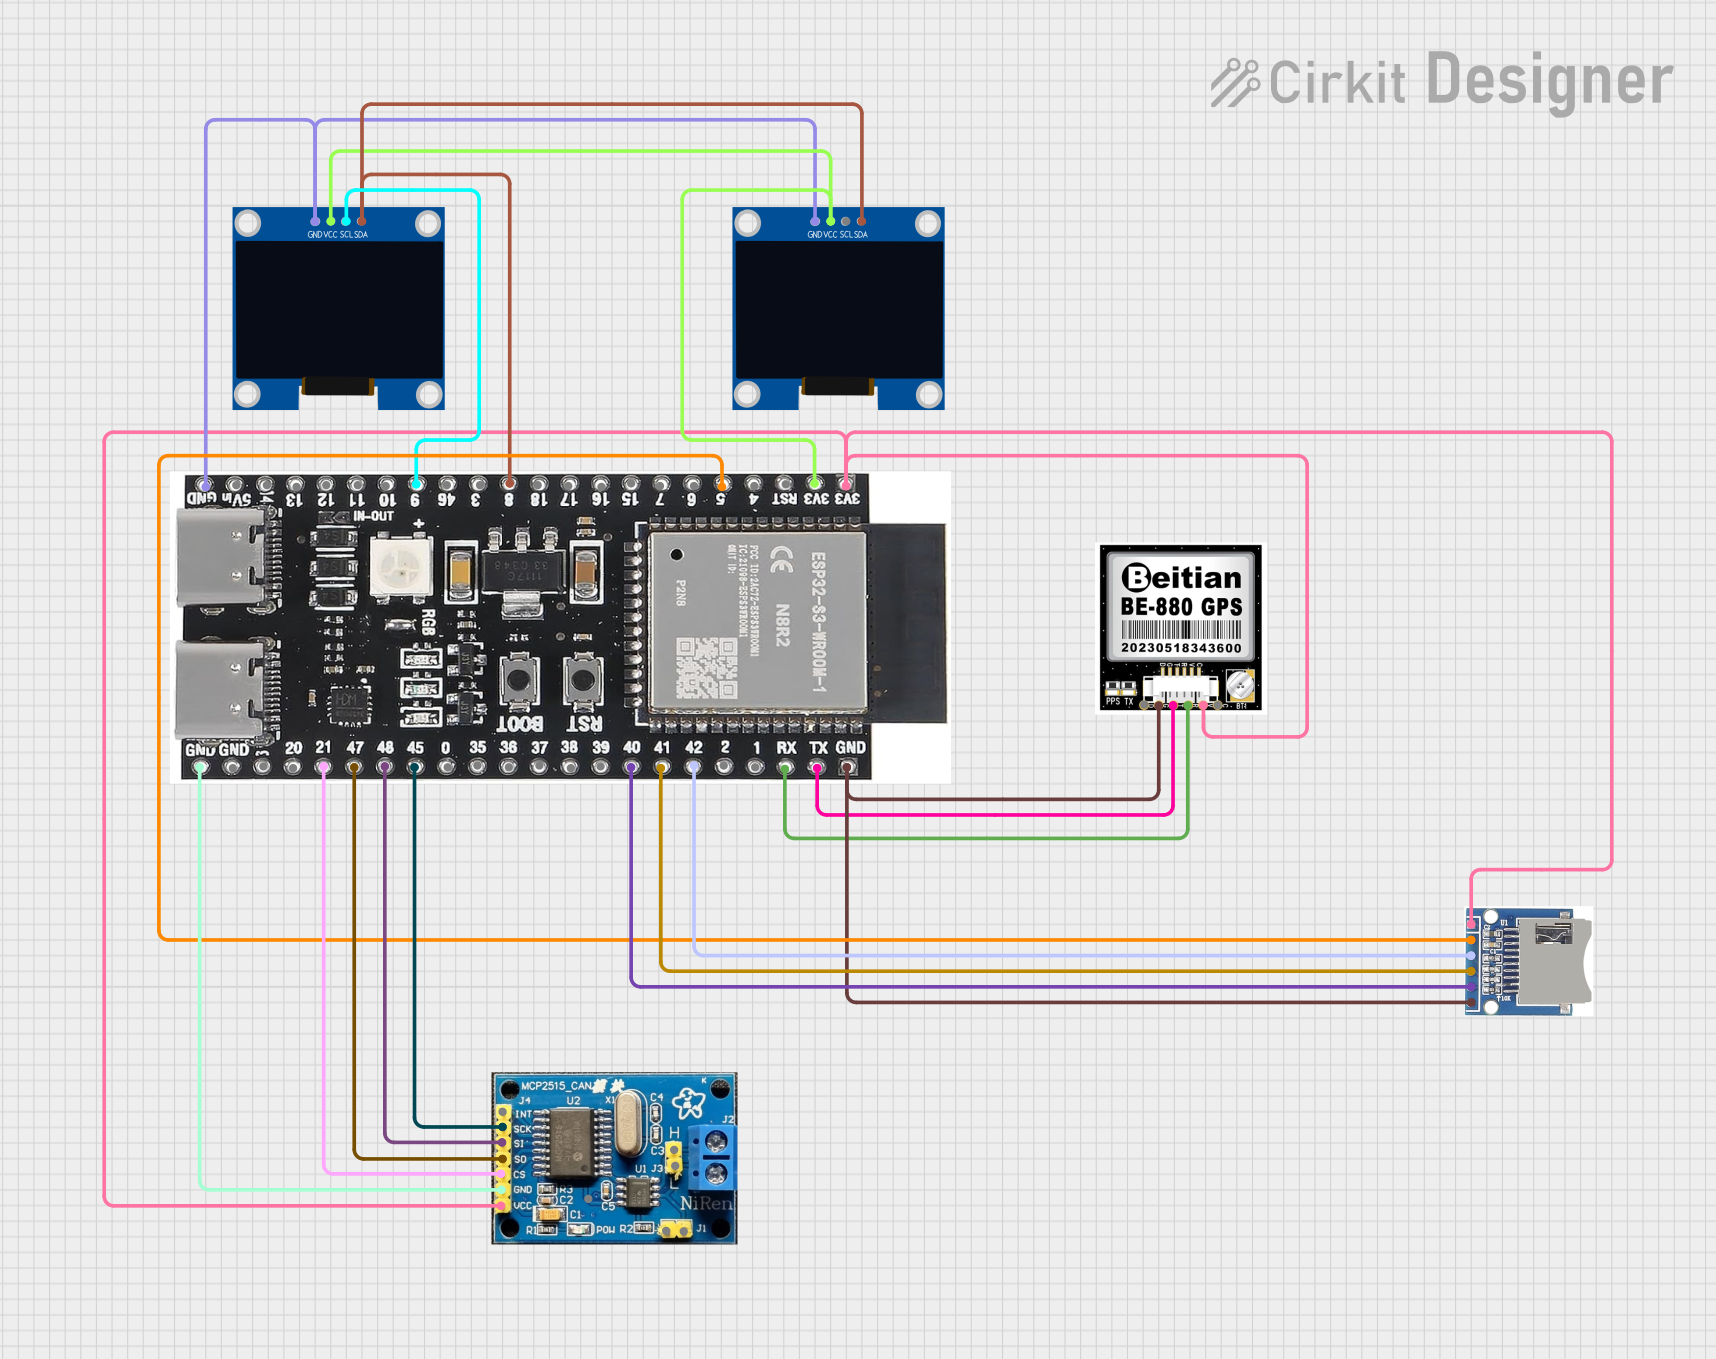
This circuit features an ESP32-S3 microcontroller interfaced with an SD card, two OLED displays, a GPS module, and a CAN bus module. It records GPS data to the SD card every second, displays speed in knots on one OLED display, and shows wind speed from the CAN bus in NMEA 2000 format on the other OLED display.
The module connects to the Raspberry Pi via the GPIO header. Below is the pin configuration:
Pin
Name
Description
2
5V
Power supply (5V input from Raspberry Pi)
6
GND
Ground
19
SPI_MOSI
SPI Master Out Slave In
21
SPI_MISO
SPI Master In Slave Out
23
SPI_SCLK
SPI Clock
24
CS1
Chip Select for CAN Channel 1
26
CS2
Chip Select for CAN Channel 2
22
INT1
Interrupt for CAN Channel 1
18
INT2
Interrupt for CAN Channel 2
Usage Instructions
How to Use the Component in a Circuit
Hardware Setup:
Mount the module onto the Raspberry Pi GPIO header.
Connect CAN_H and CAN_L lines of the CAN bus to the module's terminal block.
Ensure proper termination resistors (120Ω) are present at both ends of the CAN bus.
Software Setup:
Install the necessary libraries and drivers for the MCP2515 CAN controller.
Configure the SPI interface on the Raspberry Pi.
Basic Circuit Example:
Connect the module to a CAN bus network with other CAN-enabled devices.
Use the Raspberry Pi to send and receive CAN messages.
Important Considerations and Best Practices
Ensure the Raspberry Pi SPI interface is enabled via raspi-config.
Use proper grounding to avoid noise and communication errors.
Verify the baud rate and CAN ID settings match those of the other devices on the CAN bus.
Avoid long cable runs to minimize signal degradation.
Example Code for Raspberry Pi
Below is an example Python script to initialize and send a CAN message using the module:
import can
import time

# Initialize the CAN interface
# Replace 'can0' with the appropriate interface name for your setup
bus = can.interface.Bus(channel='can0', bustype='socketcan')

# Create a CAN message
msg = can.Message(arbitration_id=0x123, data=[0x11, 0x22, 0x33, 0x44, 0x55, 0x66, 0x77, 0x88],
                  is_extended_id=False)

try:
    # Send the CAN message
    bus.send(msg)
    print("Message sent on CAN bus")
except can.CanError:
    print("Failed to send message")

# Wait for a response (optional)
try:
    response = bus.recv(timeout=1.0)  # Wait for 1 second
    if response:
        print(f"Received message: {response}")
    else:
        print("No response received")
except Exception as e:
    print(f"Error receiving message: {e}")
Notes:
Install the python-can library using pip install python-can before running the script.
Replace can0 with the correct CAN interface name (e.g., can1) if using the second channel.
Troubleshooting and FAQs
Common Issues Users Might Face
No Communication on the CAN Bus:
Cause: Incorrect wiring or missing termination resistors.
Solution: Verify connections and ensure 120Ω resistors are present at both ends of the CAN bus.
SPI Interface Not Working:
Cause: SPI not enabled on the Raspberry Pi.
Solution: Enable SPI via raspi-config and reboot the Raspberry Pi.
CAN Messages Not Being Sent or Received:
Cause: Mismatched baud rate or CAN ID.
Solution: Ensure the baud rate and CAN ID match those of other devices on the network.
Module Overheating:
Cause: Excessive current draw or improper power supply.
Solution: Check the power supply and ensure the module is not overloaded.
Solutions and Tips for Troubleshooting
Use a CAN bus analyzer to monitor traffic and diagnose issues.
Double-check the pin connections and ensure the module is securely mounted on the Raspberry Pi.
Test the module with a simple loopback configuration to verify functionality.
By following this documentation, users can effectively integrate the [SEENGREAT] 라즈베리파이용 2채널 CAN 버스 확장 모듈 [220488] into their projects and leverage its capabilities for reliable CAN bus communication.


 Open Project in Cirkit Designer