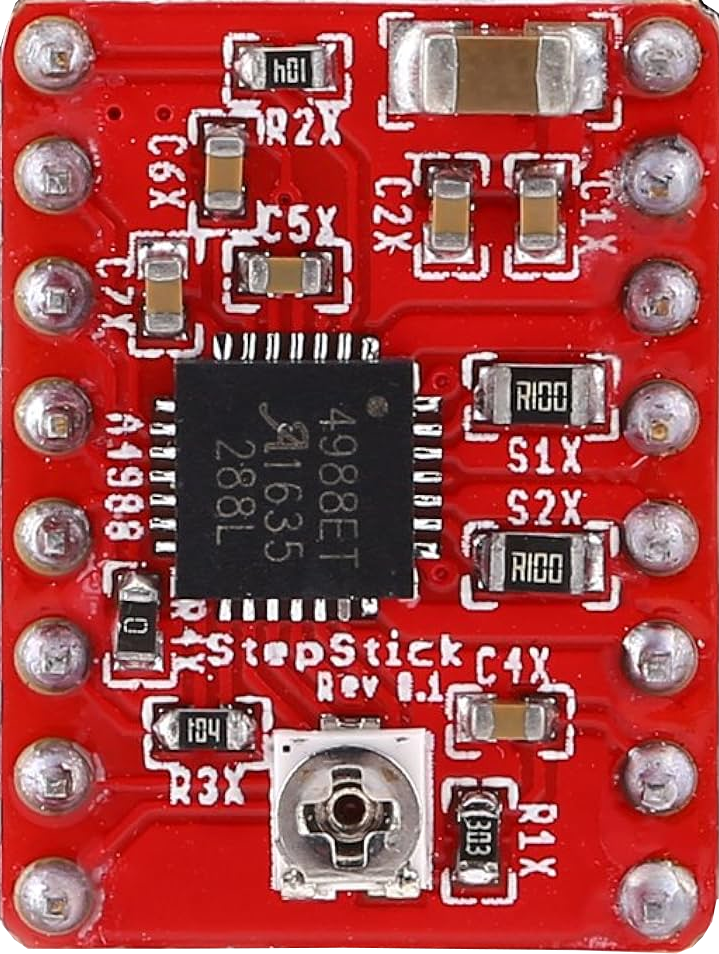
The A4988 is a microstepping driver designed for controlling bipolar stepper motors. It enables precise control of motor position, speed, and torque by supporting microstepping resolutions down to 1/16th of a step. The driver features adjustable current control, over-temperature protection, and short-circuit protection, making it a reliable choice for a wide range of applications.
Explore Projects Built with Driver A4988 for Stepper
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
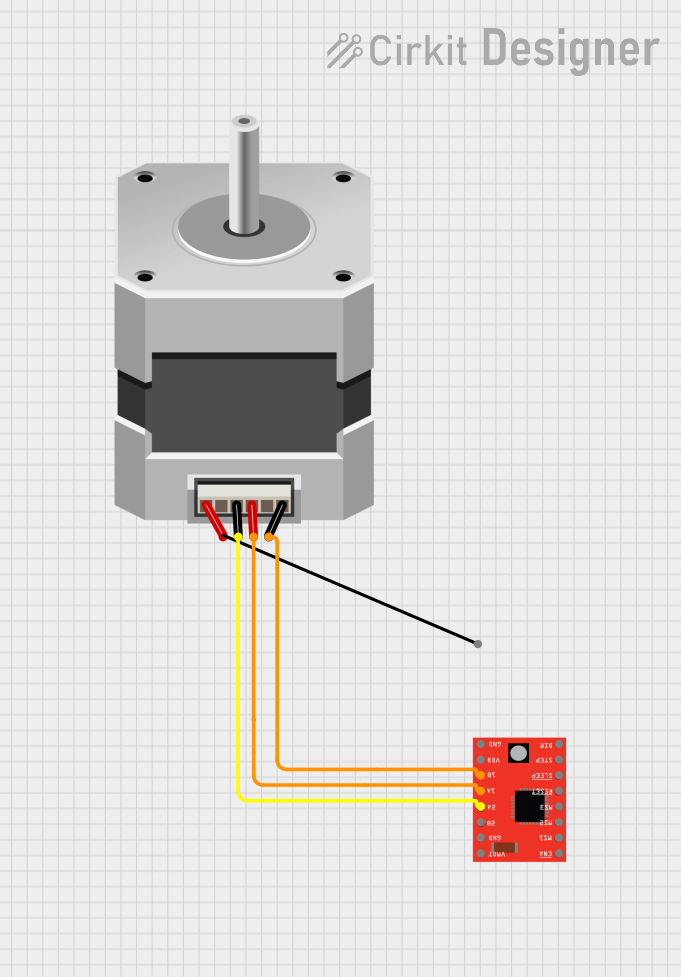
This circuit is designed to control a bipolar stepper motor using an A4988 stepper motor driver. The driver interfaces with the motor by connecting its output pins to the motor's coils, allowing precise control of the motor's movement.
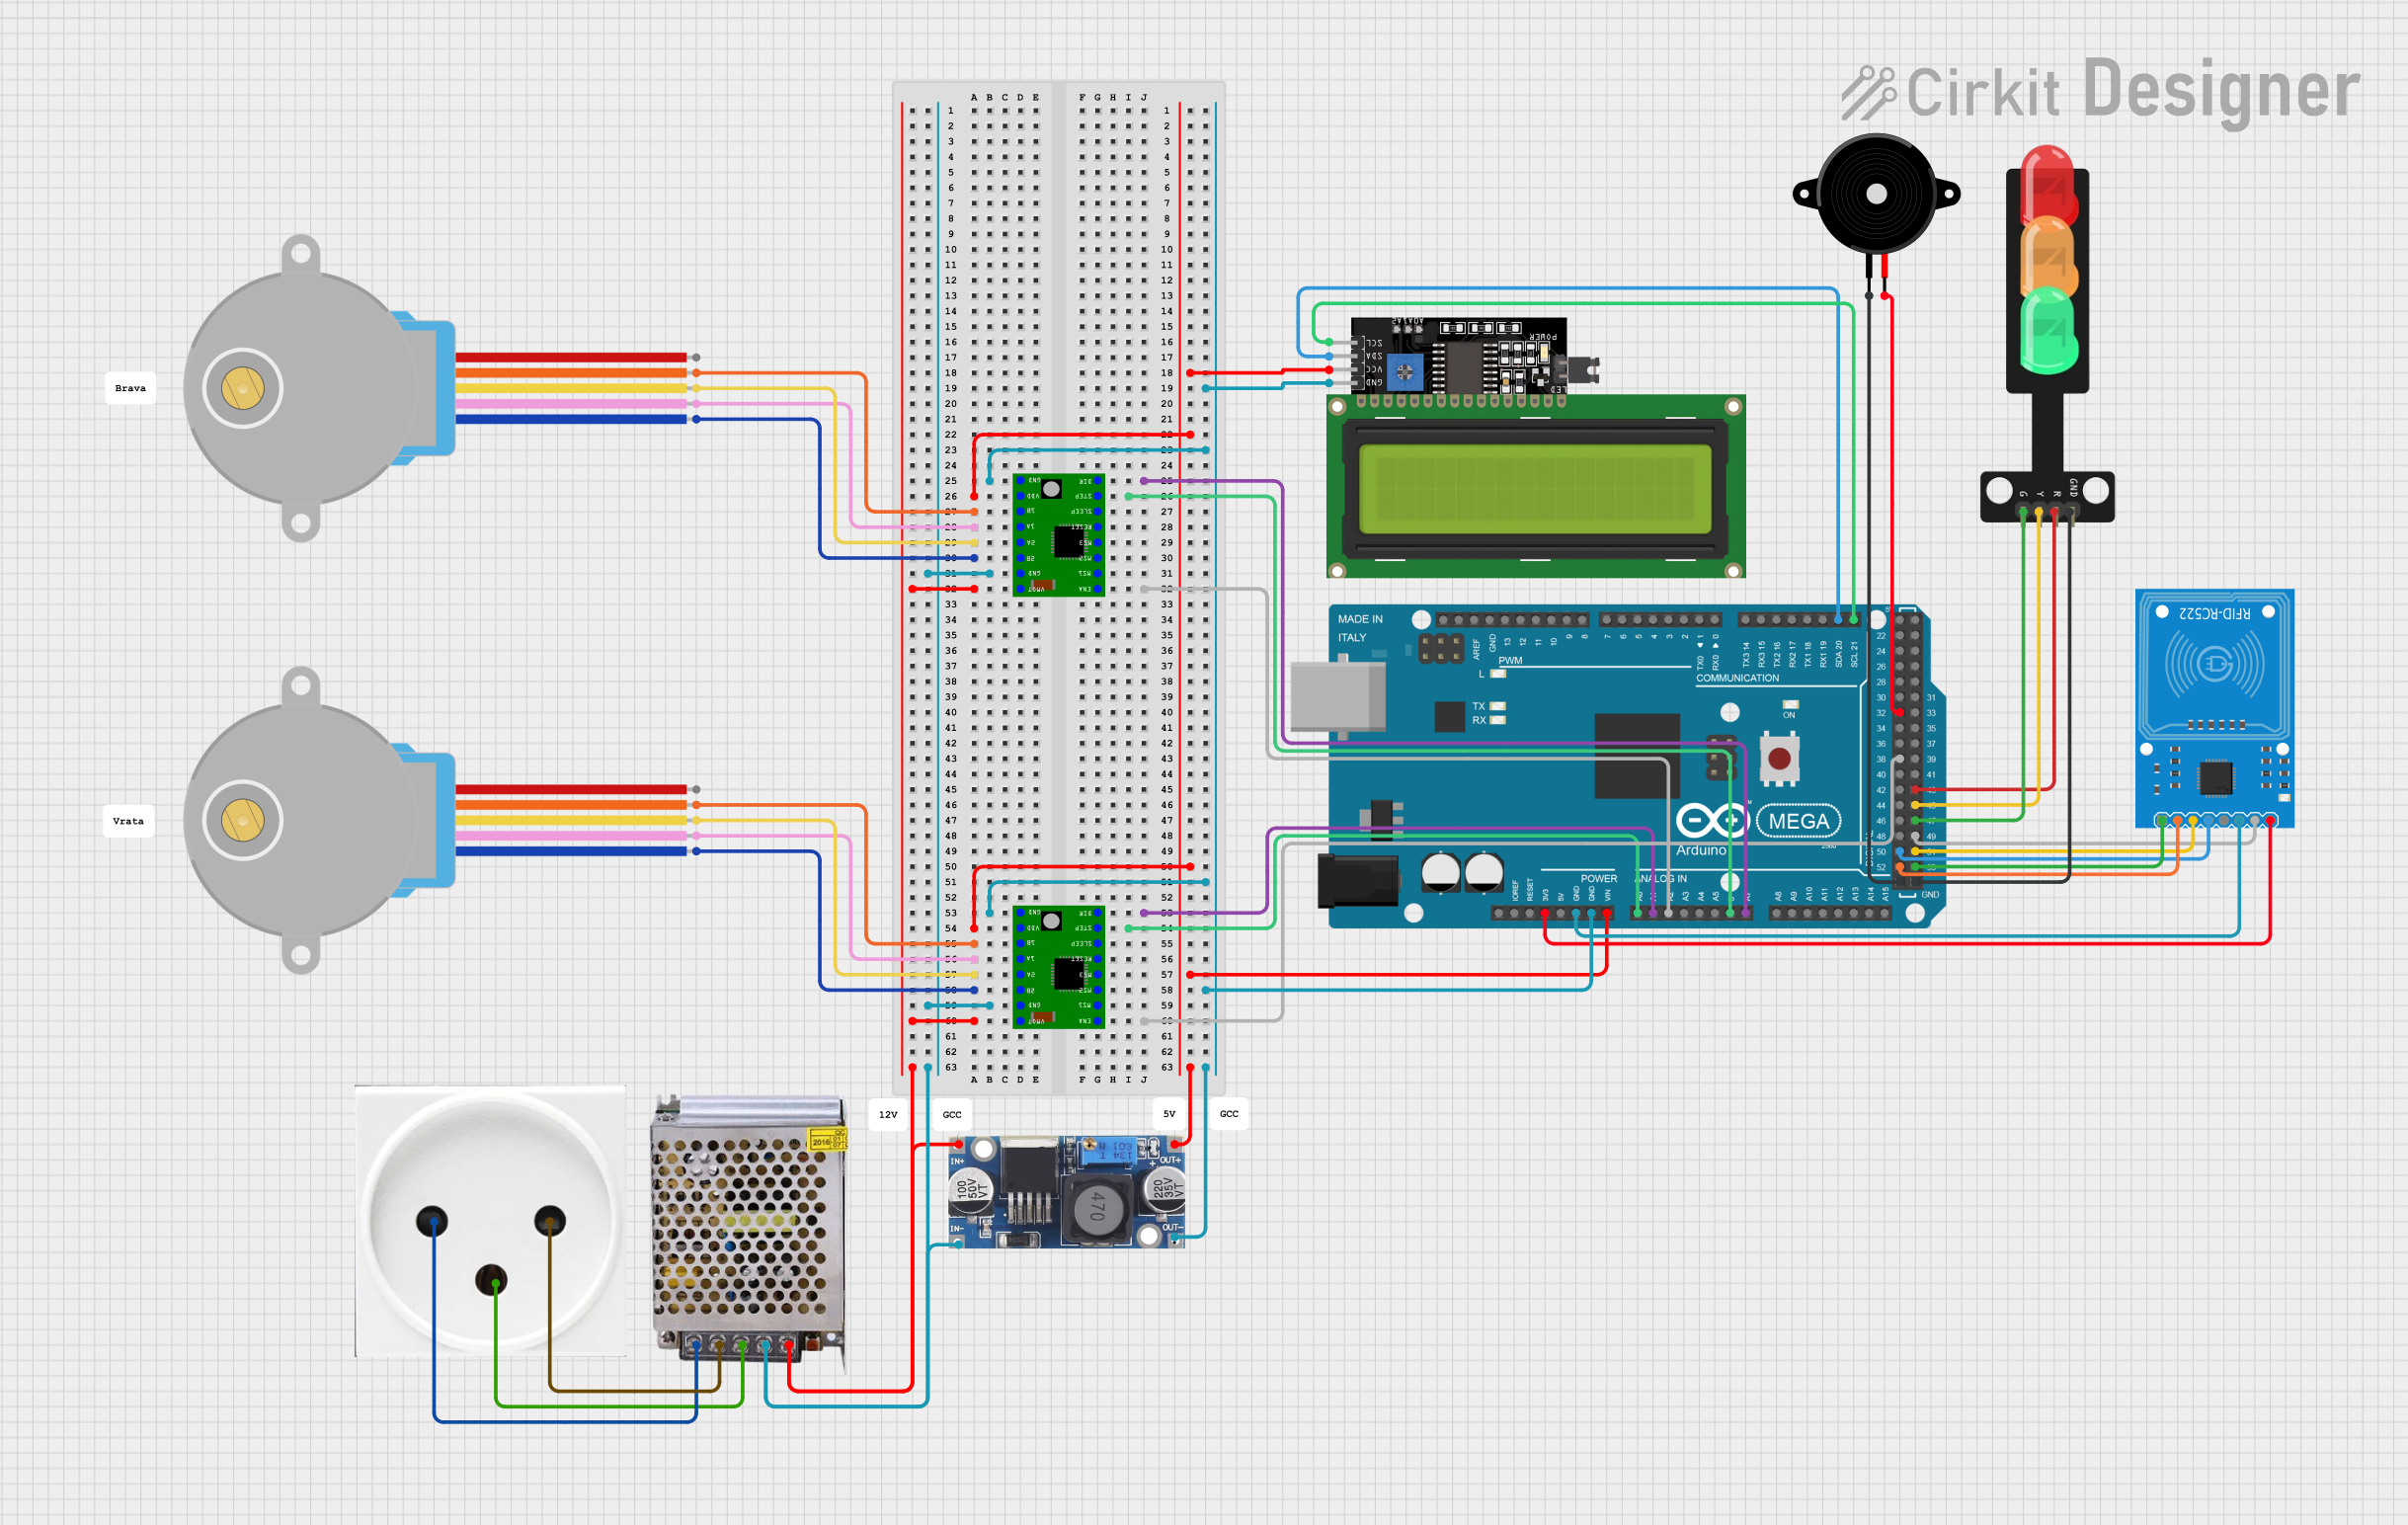
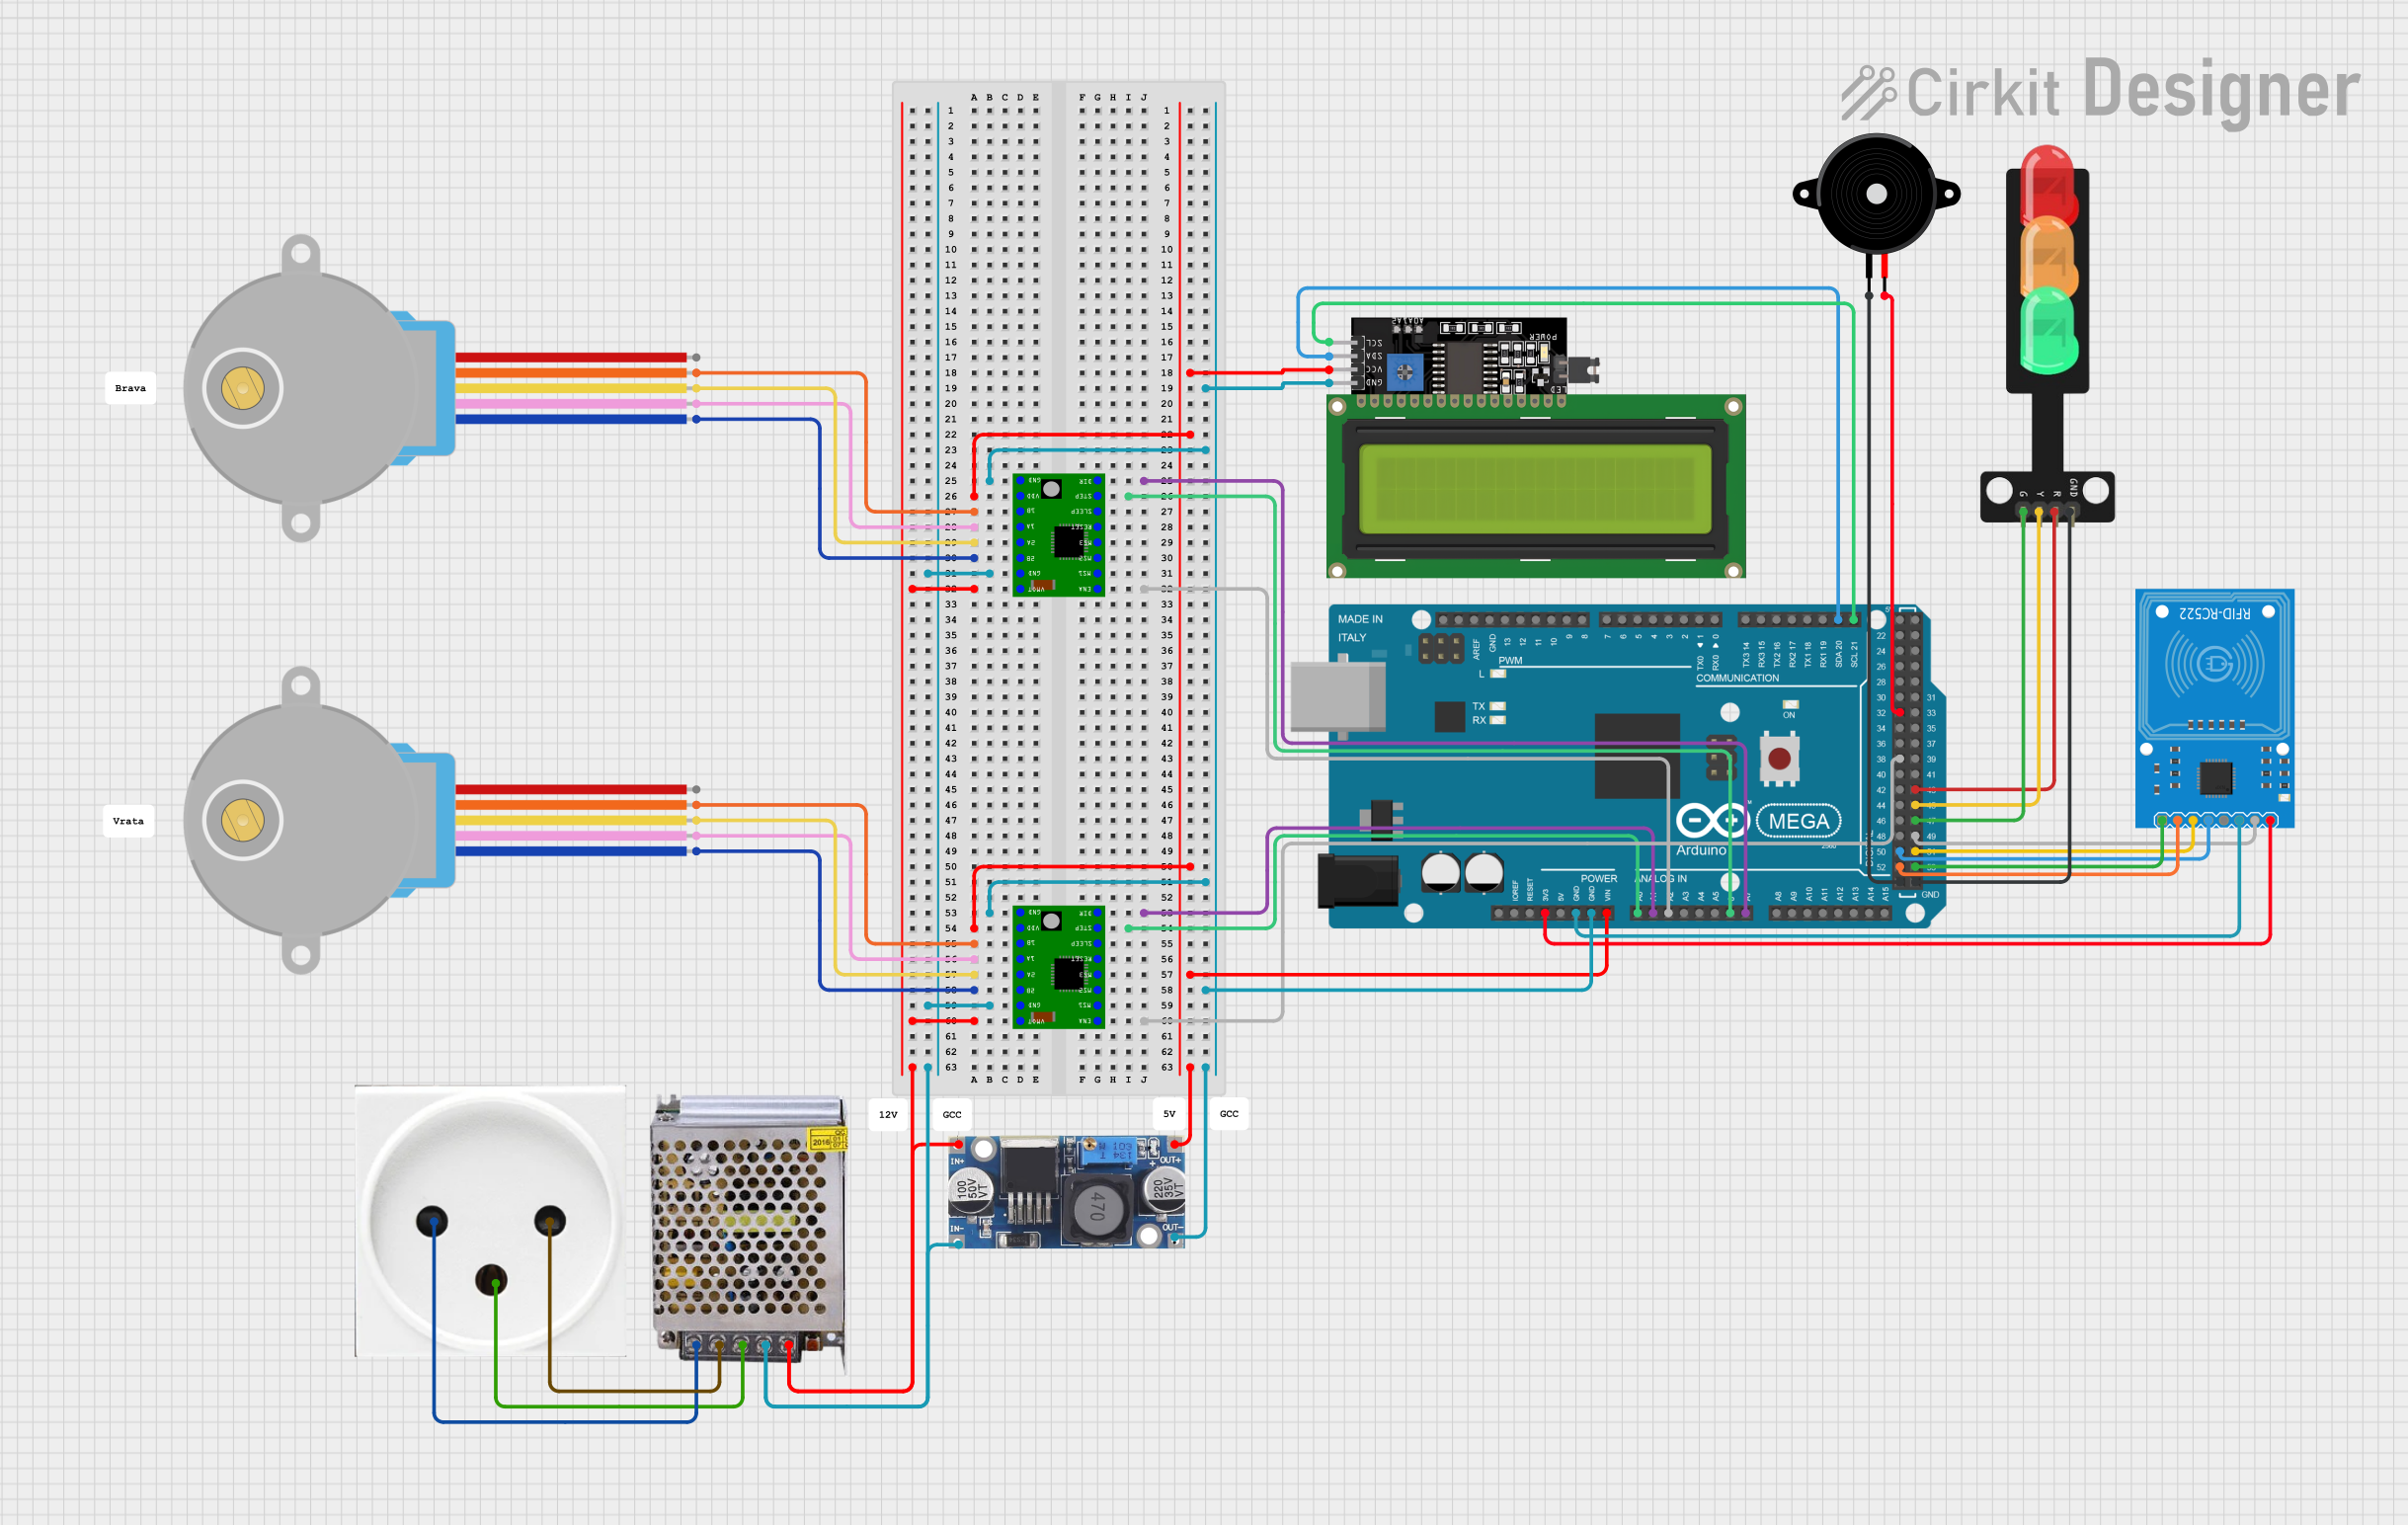
This circuit controls two 28BYJ-48 stepper motors using A4988 stepper motor driver carriers, interfaced with an Arduino Mega 2560 microcontroller. It features an RFID-RC522 module for RFID reading, a 16x4 LCD display with I2C interface for user interaction, and a piezo speaker for audio feedback. Additionally, there is a traffic light module controlled by the Arduino, and a 48V to 5V converter to step down voltage for the logic levels. The power supply provides 12V to the motor drivers and is connected to a standard power outlet.
This circuit is designed to control two 28BYJ-48 stepper motors using A4988 stepper motor driver carriers, with an Arduino Mega 2560 as the central microcontroller. It includes an RFID-RC522 module for RFID reading, an LCD display for user interface, and a traffic light and piezo speaker for visual and audio signaling. The circuit is powered by a 12V 5A power supply, which is stepped down to 5V for logic level components, and it interfaces with a power outlet for AC to DC conversion.
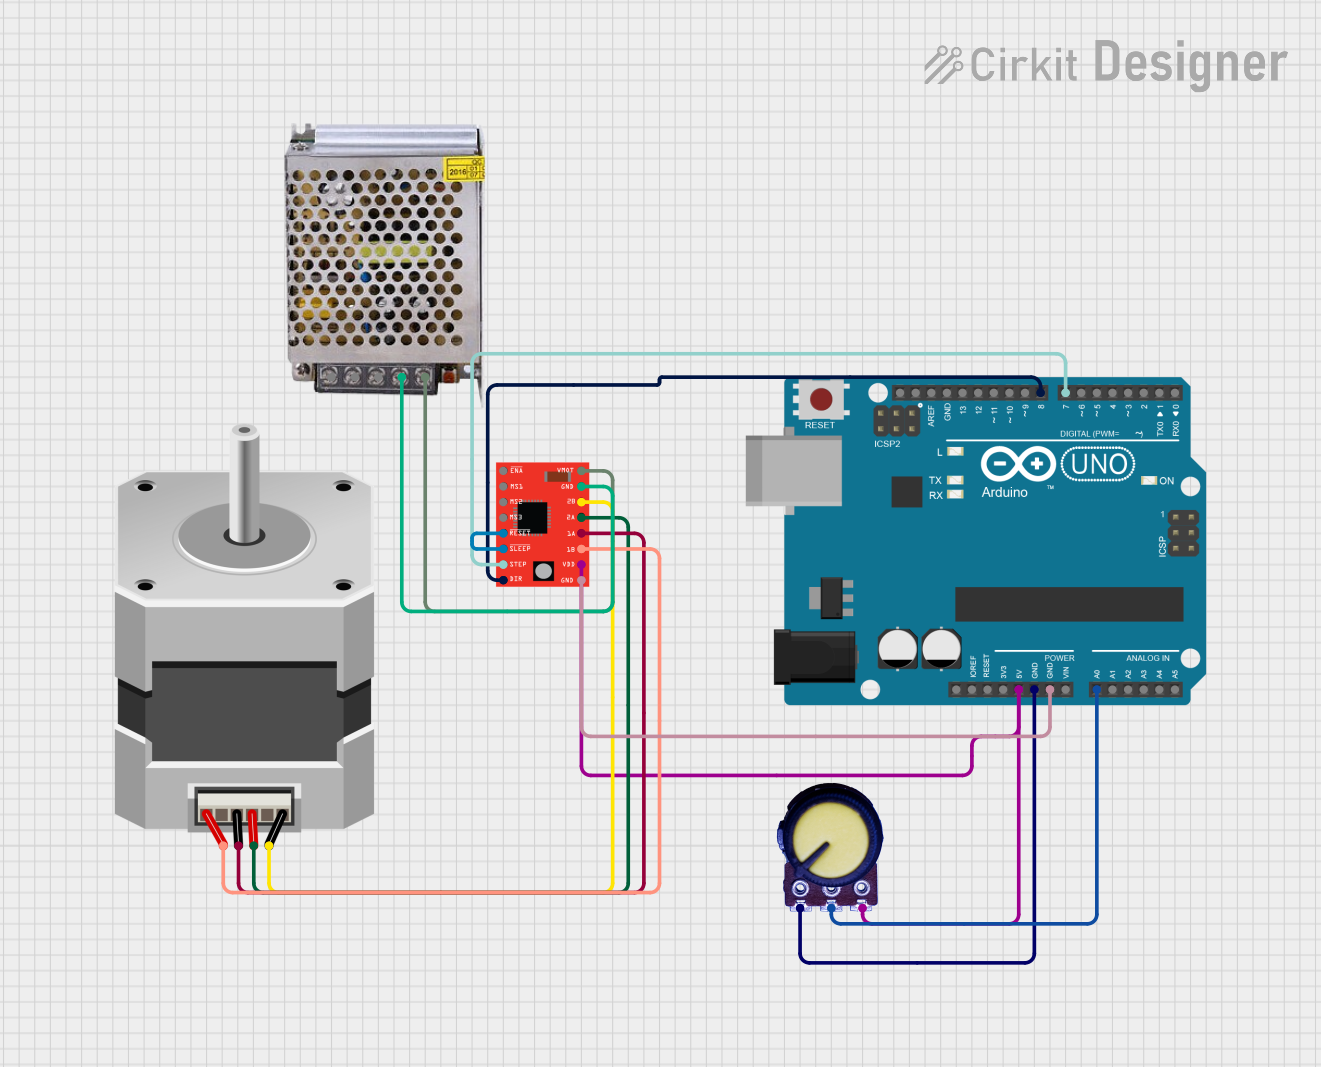
This circuit controls a bipolar stepper motor using an A4988 stepper motor driver, which is interfaced with an Arduino UNO microcontroller. The Arduino provides control signals for the direction (DIR) and stepping (STEP) of the motor, while a potentiometer connected to an analog input (A0) may be used for speed or position feedback. The motor driver is powered by a 12V power supply, and the RESET and SLEEP pins of the driver are connected together, likely to enable the motor driver to operate immediately upon power-up.
The A4988 driver module has 16 pins. Below is the pinout and description:
Pin Name
Type
Description
VMOT
Power Input
Motor power supply (8V to 35V). Connect a capacitor (100 µF or higher) nearby.
GND
Power Ground
Ground connection for motor power supply.
VDD
Power Input
Logic power supply (3.3V to 5V).
GND
Power Ground
Ground connection for logic power supply.
1A, 1B
Motor Output
Connect to one coil of the stepper motor.
2A, 2B
Motor Output
Connect to the other coil of the stepper motor.
STEP
Logic Input
Controls the step signal. Each pulse moves the motor one step.
DIR
Logic Input
Sets the direction of motor rotation.
ENABLE
Logic Input
Enables or disables the driver (active low).
MS1, MS2, MS3
Logic Input
Microstepping resolution selection.
RESET
Logic Input
Resets the driver (active low).
SLEEP
Logic Input
Puts the driver into low-power sleep mode (active low).
REF
Analog Input
Reference voltage for current control.
Usage Instructions
Connecting the A4988 to a Stepper Motor
Power Supply: Connect VMOT and GND to a motor power supply (8V to 35V). Add a decoupling capacitor (100 µF or higher) across these pins to prevent voltage spikes.
Logic Power: Connect VDD and GND to a 3.3V or 5V logic power supply.
Motor Connections: Connect the stepper motor coils to pins 1A, 1B, 2A, and 2B. Ensure the correct pairing of coils.
Control Pins: Connect STEP and DIR to your microcontroller or control circuit. Use ENABLE, RESET, and SLEEP as needed.
Microstepping: Set MS1, MS2, and MS3 to configure the desired microstepping mode:
Full step: MS1 = 0, MS2 = 0, MS3 = 0
Half step: MS1 = 1, MS2 = 0, MS3 = 0
1/4 step: MS1 = 0, MS2 = 1, MS3 = 0
1/8 step: MS1 = 1, MS2 = 1, MS3 = 0
1/16 step: MS1 = 1, MS2 = 1, MS3 = 1
Current Adjustment: Use the onboard potentiometer to set the current limit. This prevents overheating and ensures optimal motor performance.
Example: Using A4988 with Arduino UNO
Below is an example code to control a stepper motor using the A4988 driver and Arduino UNO:
// Define control pins for the A4988 driver
#define STEP_PIN 3  // Connect to STEP pin on A4988
#define DIR_PIN 4   // Connect to DIR pin on A4988

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output

  digitalWrite(DIR_PIN, HIGH); // Set initial direction (HIGH = clockwise)
}

void loop() {
  // Generate step pulses to move the motor
  for (int i = 0; i < 200; i++) { // 200 steps for one revolution (1.8°/step)
    digitalWrite(STEP_PIN, HIGH); // Set STEP pin HIGH
    delayMicroseconds(1000);      // Wait 1 ms (adjust for speed control)
    digitalWrite(STEP_PIN, LOW);  // Set STEP pin LOW
    delayMicroseconds(1000);      // Wait 1 ms
  }

  delay(1000); // Wait 1 second before changing direction

  // Change direction
  digitalWrite(DIR_PIN, !digitalRead(DIR_PIN)); // Toggle direction
}
Best Practices
Always power the logic circuit (VDD) before the motor power supply (VMOT) to avoid damaging the driver.
Use a heat sink or cooling fan if operating near the maximum current limit.
Avoid disconnecting the motor while the driver is powered, as this can damage the A4988.
Troubleshooting and FAQs
Common Issues
Motor Not Moving:
Check the power supply connections (VMOT and VDD).
Verify the STEP and DIR signals from the microcontroller.
Ensure the motor coils are correctly connected to 1A, 1B, 2A, and 2B.
Overheating:
Reduce the current limit using the potentiometer.
Add a heat sink or cooling fan to the driver.
Vibrations or Noise:
Use a higher microstepping resolution (e.g., 1/8 or 1/16 step).
Ensure the motor is compatible with the driver.
Driver Not Responding:
Check the ENABLE pin (should be LOW to enable the driver).
Verify the RESET and SLEEP pins are not unintentionally activated.
FAQs
Q: Can I use the A4988 with a unipolar stepper motor?
A: No, the A4988 is designed for bipolar stepper motors only.
Q: How do I calculate the current limit?
A: The current limit is set using the formula: Current Limit = VREF / (8 × R_sense)
where R_sense is the value of the sense resistor (typically 0.1Ω).
Q: What happens if I exceed the maximum voltage?
A: Exceeding 35V on VMOT can permanently damage the driver. Always use a regulated power supply.
Q: Can I daisy-chain multiple A4988 drivers?
A: Yes, you can control multiple drivers using separate STEP and DIR pins for each motor.
By following this documentation, you can effectively use the A4988 driver to control stepper motors in your projects.

 Open Project in Cirkit Designer