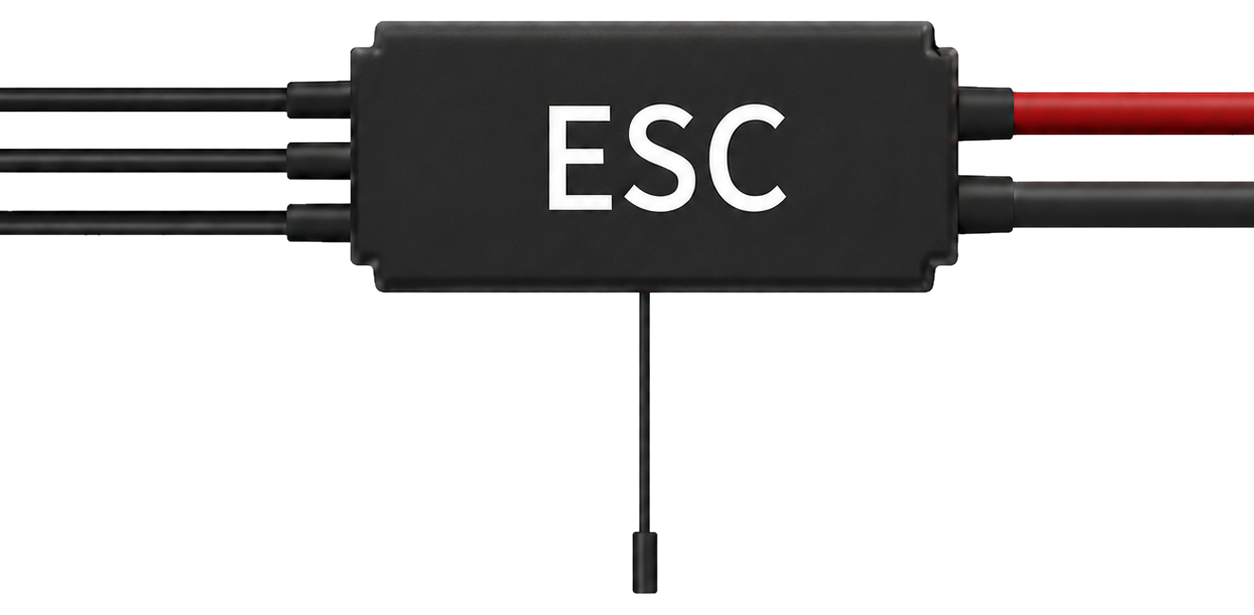
An Electronic Speed Controller (ESC) is a critical component used to regulate the speed, direction, and braking of an electric motor. It achieves this by varying the voltage and current supplied to the motor. ESCs are widely used in applications such as remote-controlled (RC) vehicles, drones, electric skateboards, and robotics. They enable precise motor control, making them essential for devices requiring variable speed and direction.
Common applications of ESCs include:
RC cars, boats, and airplanes
Multirotor drones and quadcopters
Electric bicycles and skateboards
Robotics and automation systems
Explore Projects Built with ESC
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
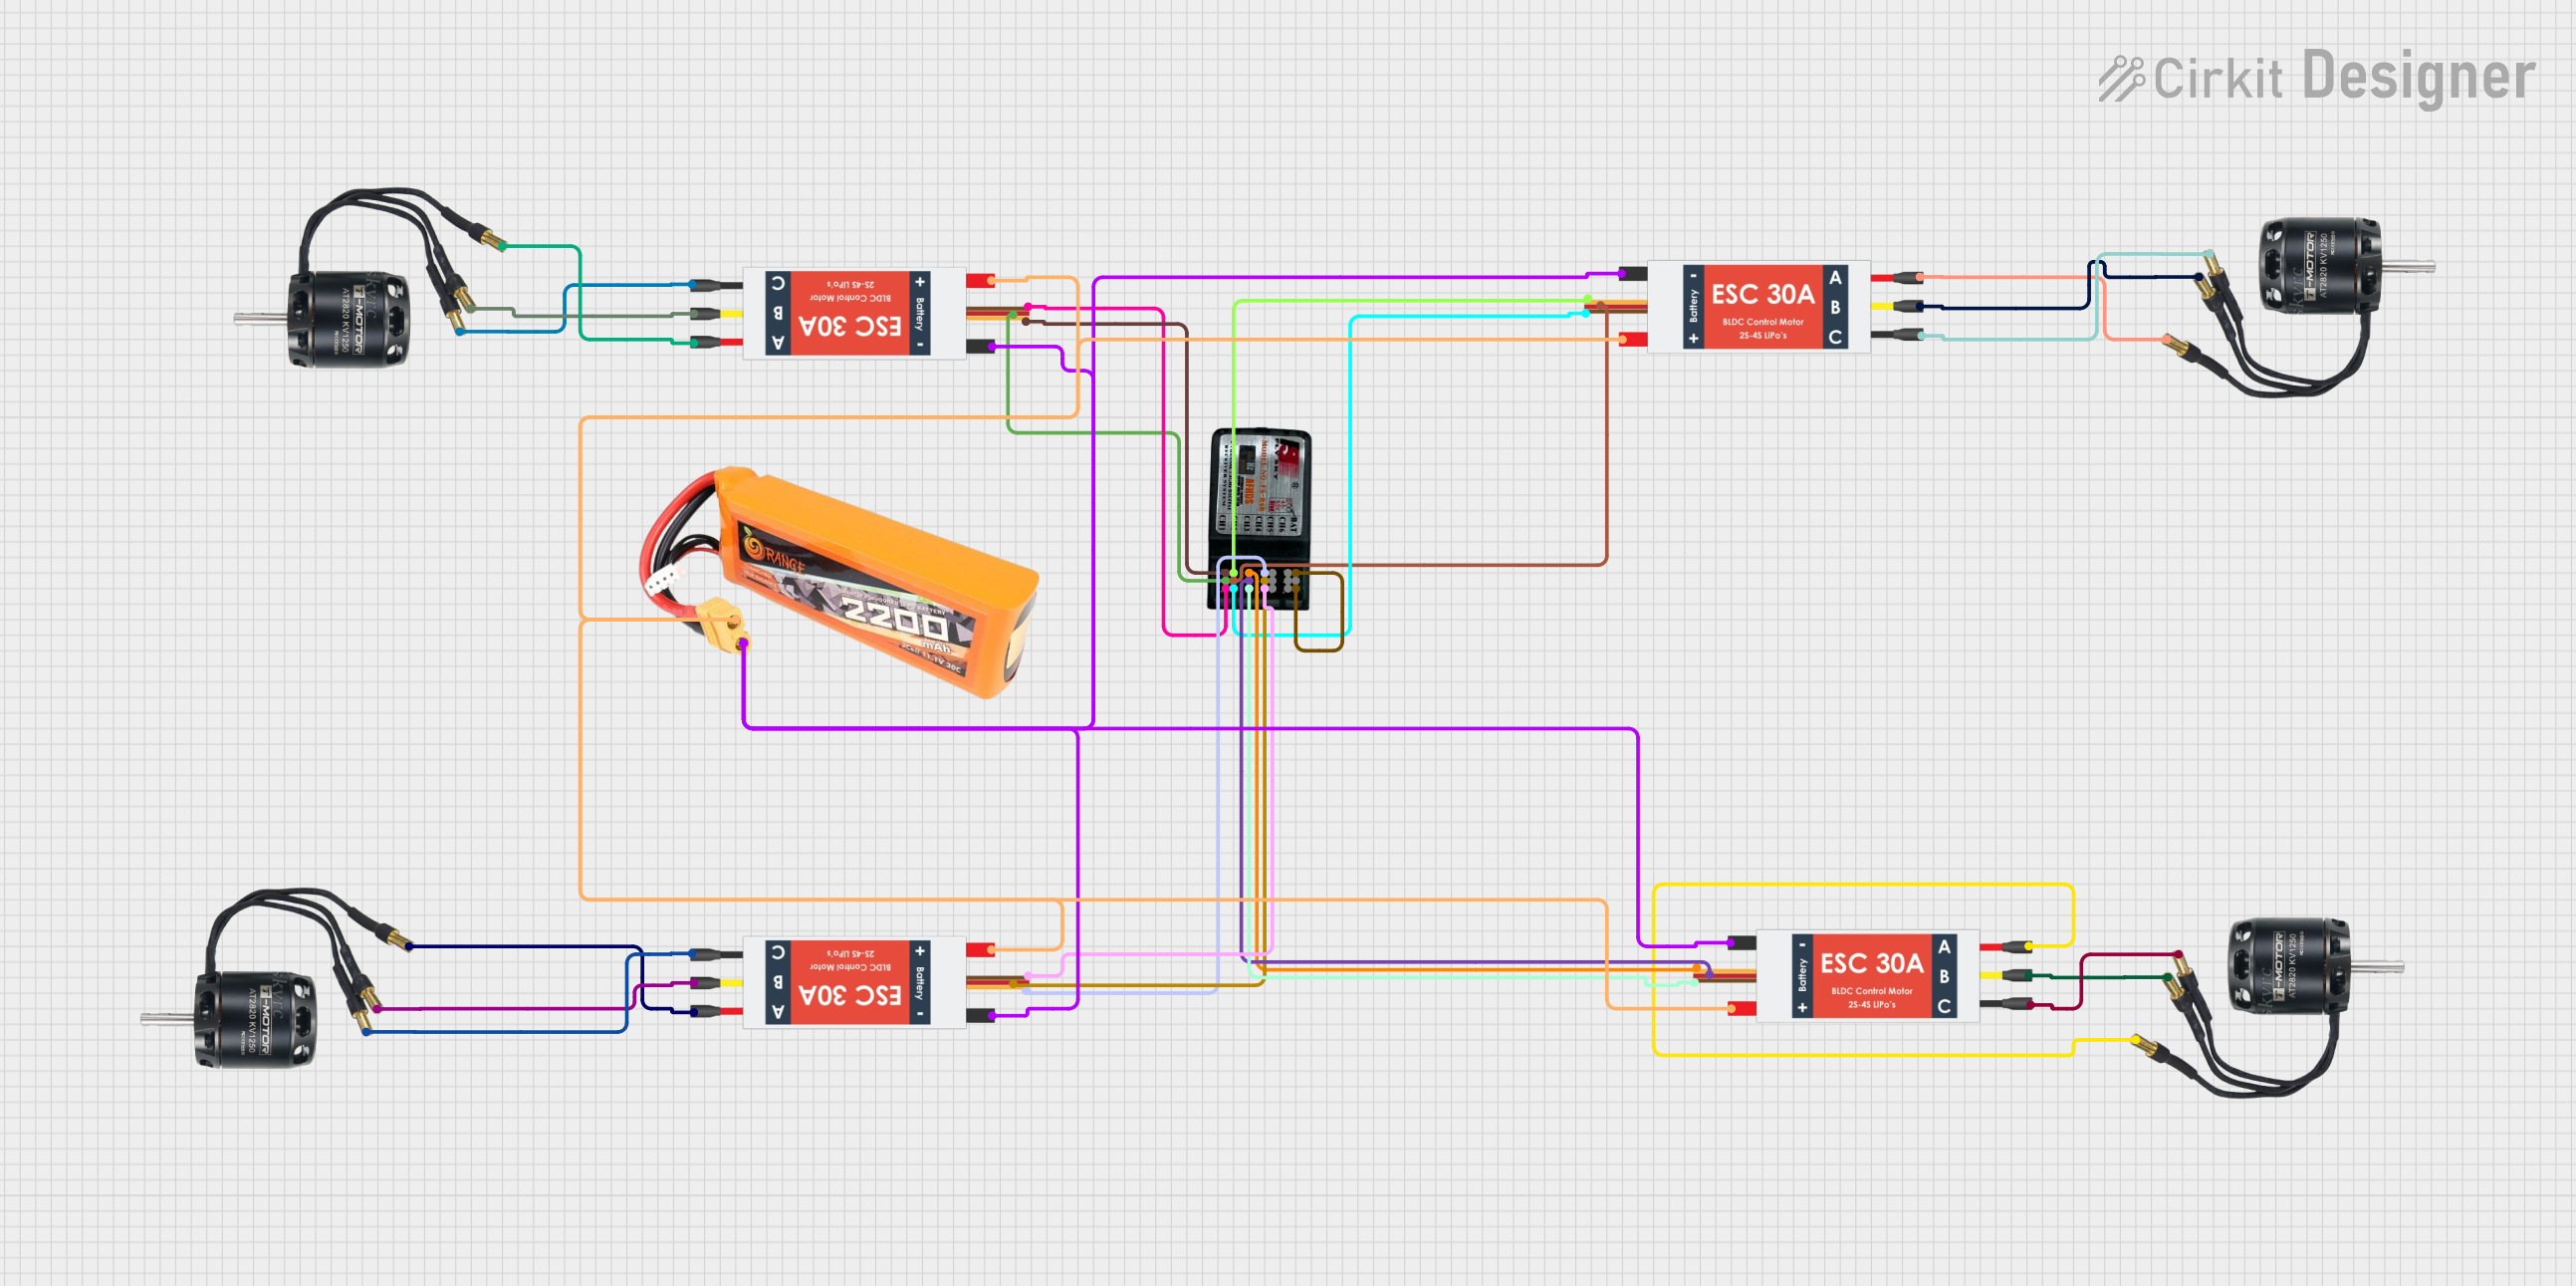
This circuit is designed to control four Brushless DC (BLDC) motors using corresponding Electronic Speed Controllers (ESCs). Each ESC receives power from a shared LiPo battery and control signals from an FS-CT6B receiver, which likely receives input from a remote transmitter for wireless control. The ESCs regulate the power supplied to the motors based on the received signals, enabling precise speed and direction control of the motors, typically used in applications such as drones or remote-controlled vehicles.
This circuit is designed to control a brushless motor via an Electronic Speed Controller (ESC), which receives power from a 12v battery managed by a Charge Controller connected to a solar panel. The ESC is interfaced with an ESP32 Devkit V1 microcontroller for signal control, and the circuit includes a SIM800L GSM module and a LoRa Ra-02 SX1278 module for communication purposes. Additional components include an HC-SR04 Ultrasonic Sensor for distance measurement, an MG996R servo, and a 1 Channel 5V Relay Module for switching applications, all powered by a step-down module that regulates voltage from the charge controller.
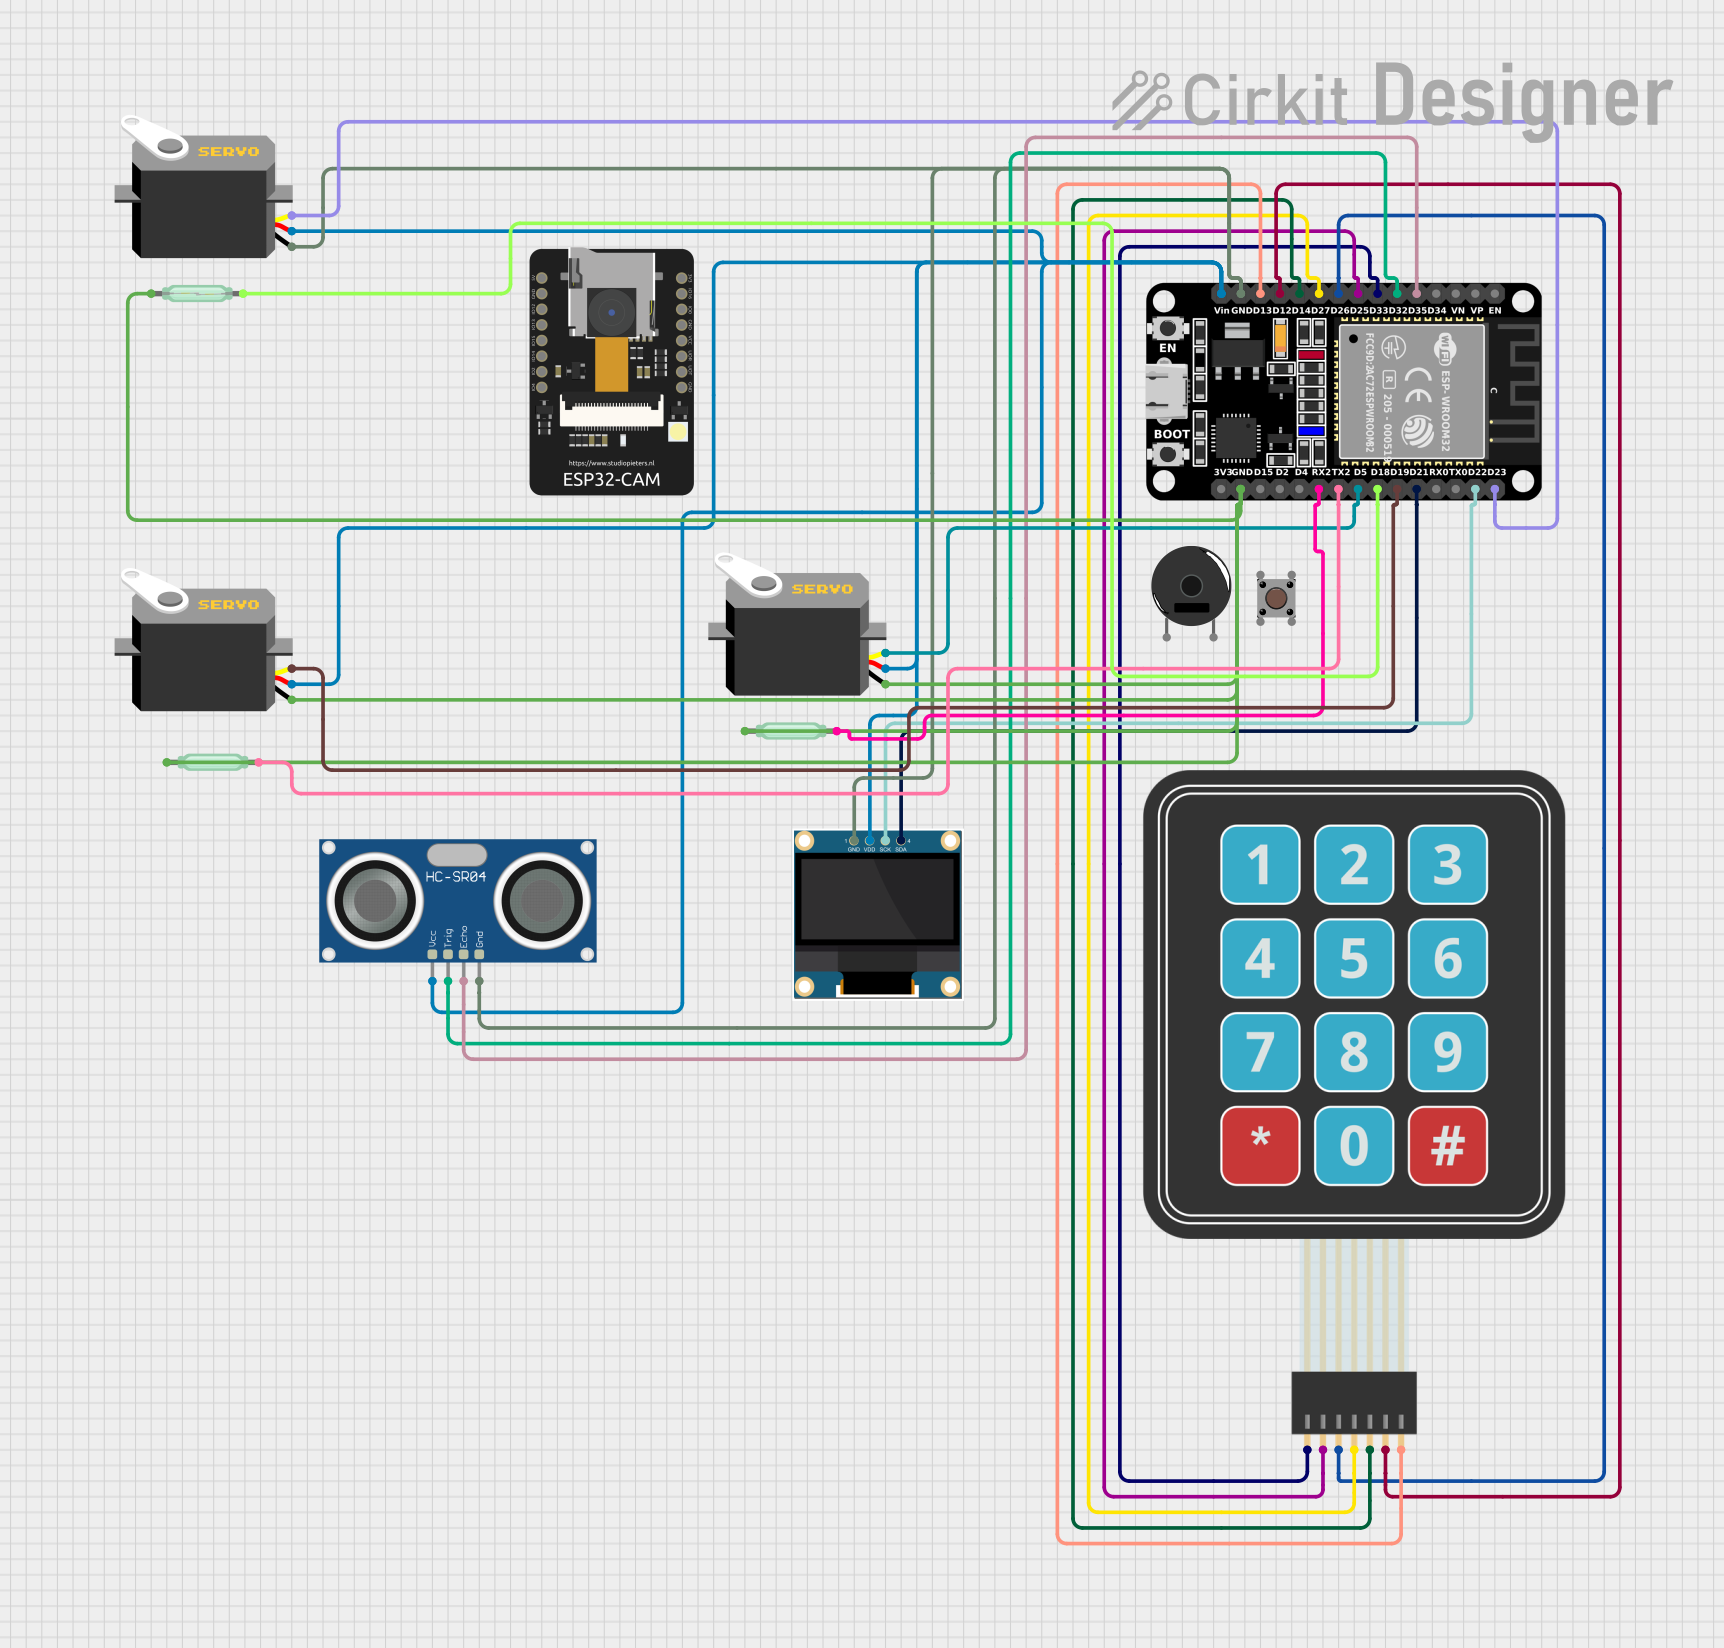
This circuit features an ESP32 microcontroller interfacing with multiple peripherals including three servos, an ultrasonic sensor, an OLED display, a membrane keypad, and several reed switches. The ESP32 controls the servos and reads inputs from the ultrasonic sensor, keypad, and reed switches, while also driving the OLED display to provide visual feedback.
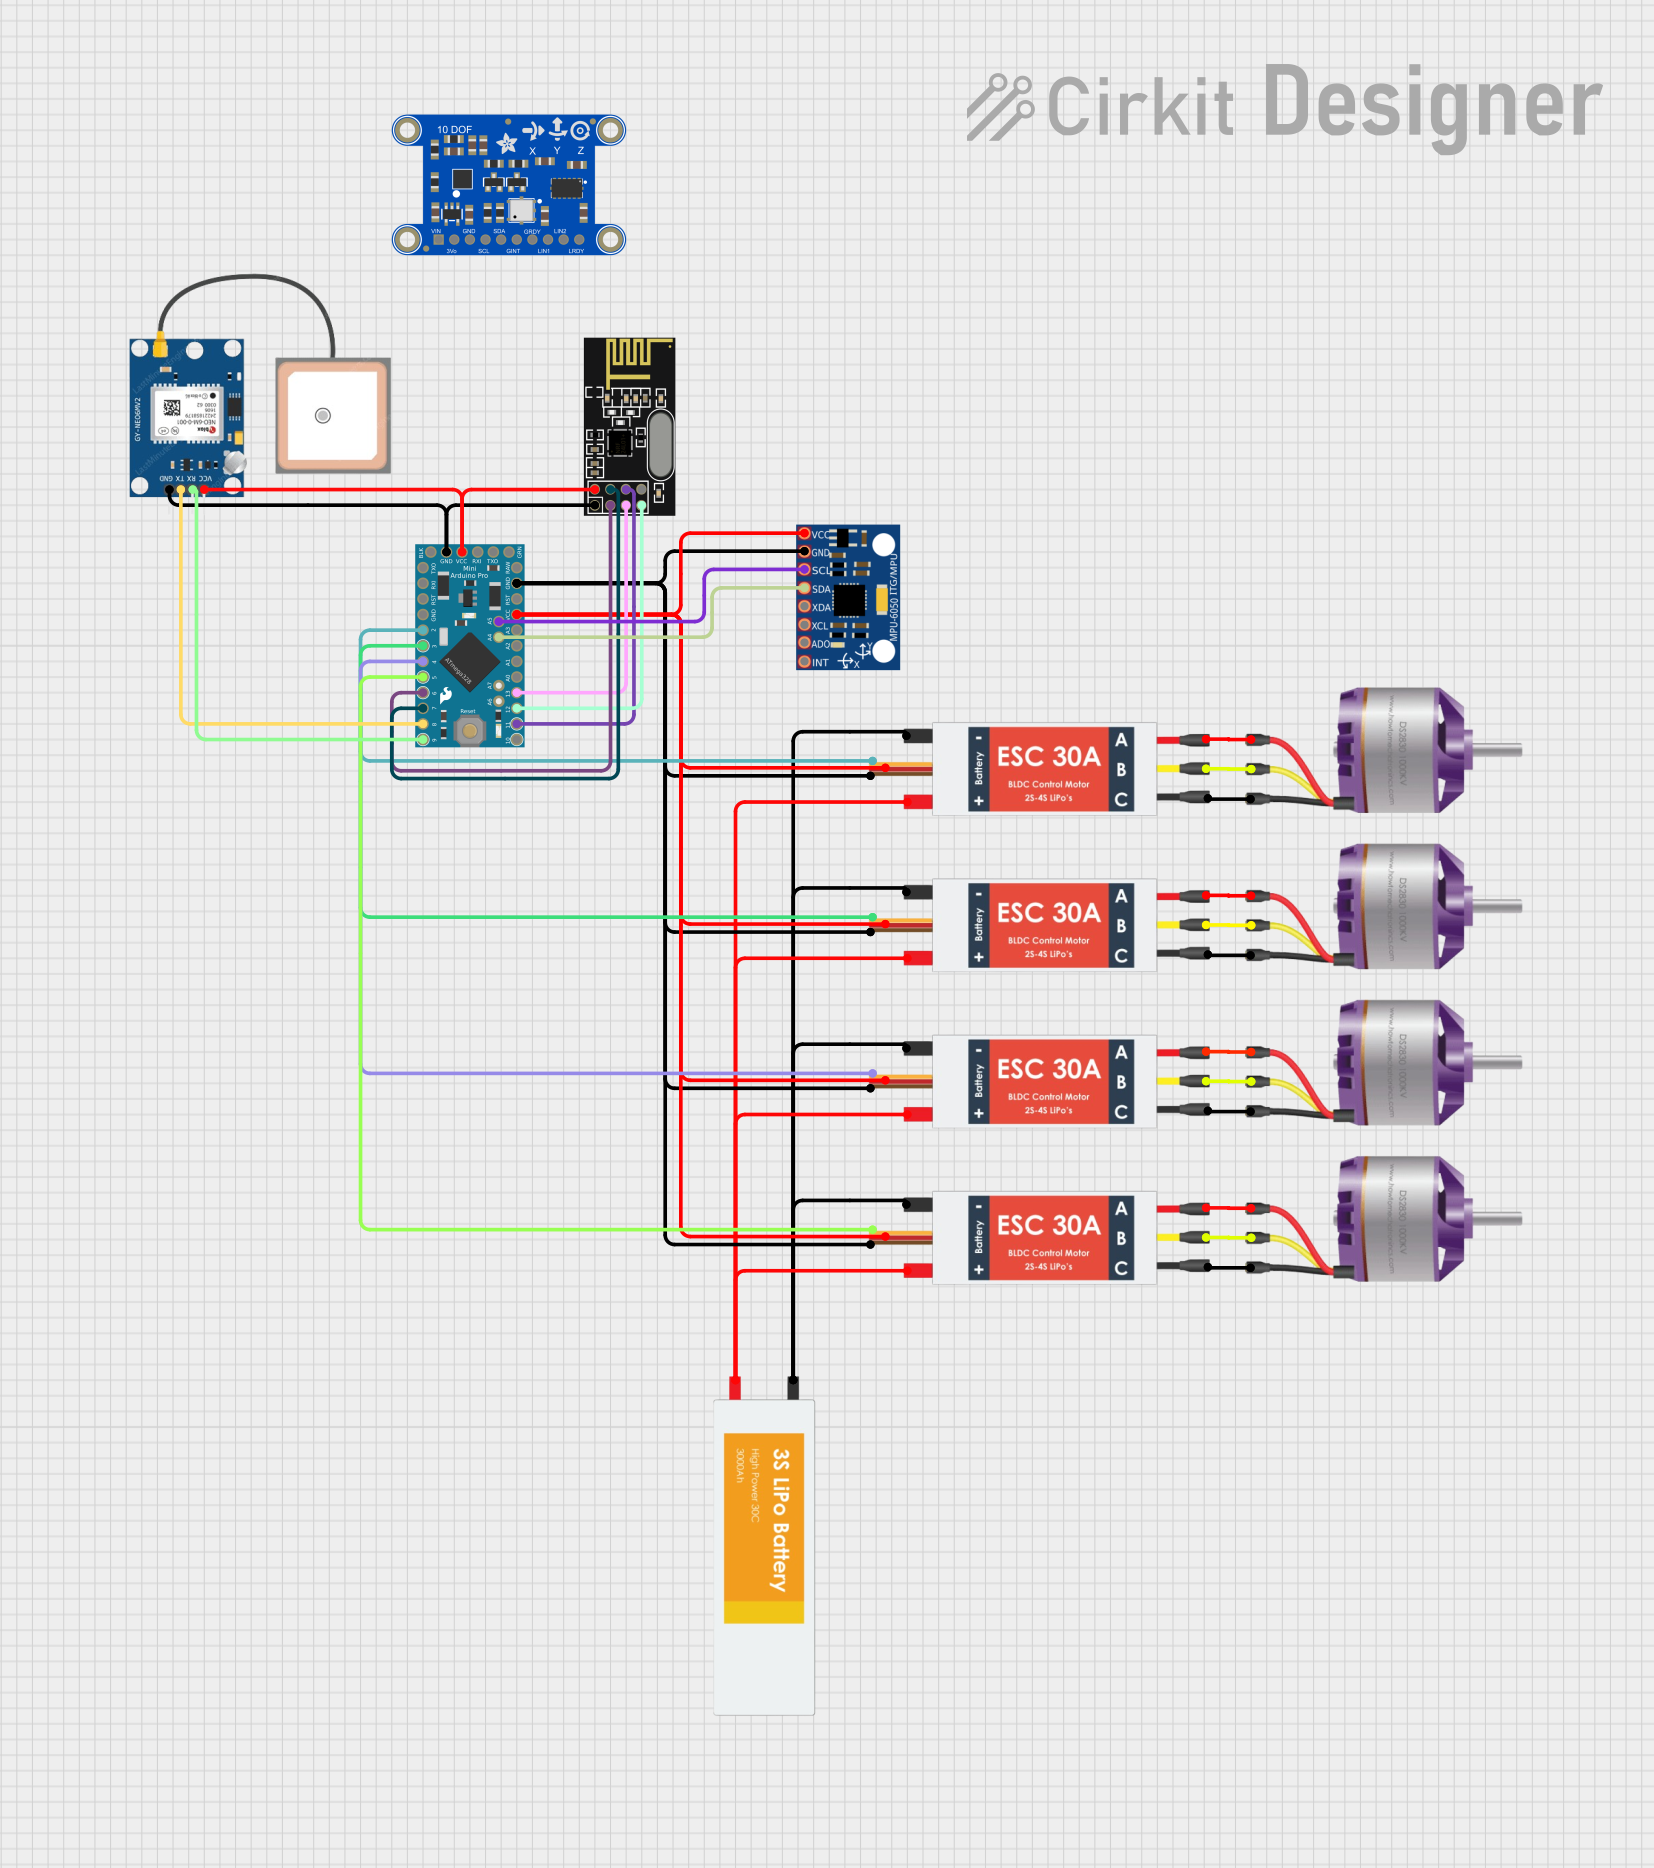
This circuit appears to be a control system for a quadcopter or similar multirotor aircraft, featuring an Arduino Pro Mini as the central microcontroller. It includes four Electronic Speed Controllers (ESCs) connected to four brushless motors, a MPU-6050 for motion sensing, a GPS module for positioning, and an NRF24L01 module for wireless communication. The ESCs receive power from a Lipo battery and control signals from the Arduino to manage the speed of the motors, while the Arduino communicates with the GPS and NRF24L01 for navigation and remote control.
Below are the general technical specifications for a typical ESC. Note that specific values may vary depending on the model and manufacturer.
Key Technical Details
Input Voltage Range: 6V to 50V (commonly 2S to 12S LiPo batteries)
Continuous Current Rating: 10A to 200A (depending on the model)
Peak Current Rating: Up to 300A (for short durations)
Supported Motor Types: Brushless DC (BLDC) or Brushed DC motors
Control Signal Input: PWM (Pulse Width Modulation) signal, typically 1ms to 2ms pulse width
BEC (Battery Eliminator Circuit): 5V or 6V output for powering external devices (optional, depending on the ESC)
Operating Temperature: -20°C to 85°C (varies by model)
Pin Configuration and Descriptions
The pin configuration of an ESC typically includes the following connections:
Pin Name
Description
Power Input (+)
Positive terminal for battery connection (e.g., LiPo battery).
Power Input (-)
Negative terminal for battery connection (ground).
Motor Phase A
First phase connection to the brushless motor.
Motor Phase B
Second phase connection to the brushless motor.
Motor Phase C
Third phase connection to the brushless motor.
Signal Input
PWM signal input from the flight controller, RC receiver, or microcontroller.
Ground (GND)
Ground connection for the signal input.
BEC Output (+)
Optional 5V or 6V output for powering external devices (e.g., servos, sensors).
BEC Output (-)
Ground connection for the BEC output.
Usage Instructions
How to Use the ESC in a Circuit
Connect the Power Supply:
Connect the positive and negative terminals of the ESC to the corresponding terminals of the battery.
Ensure the battery voltage is within the ESC's input voltage range.
Connect the Motor:
Attach the three motor phase wires (A, B, C) from the ESC to the brushless motor.
If the motor spins in the wrong direction, swap any two of the motor phase wires.
Connect the Signal Input:
Connect the signal input pin of the ESC to the PWM output pin of your microcontroller, RC receiver, or flight controller.
Connect the ground (GND) pin of the ESC to the ground of the control device.
Optional BEC Connection:
If the ESC has a built-in BEC, use the BEC output to power external devices like servos or sensors.
Calibrate the ESC:
Follow the manufacturer's instructions to calibrate the ESC. This typically involves setting the throttle range using your transmitter or microcontroller.
Test the Setup:
Power on the system and test the motor's response to the control signals. Ensure the motor operates smoothly and within the desired speed range.
Important Considerations and Best Practices
Cooling: Ensure proper ventilation or cooling for the ESC, especially in high-current applications.
Battery Compatibility: Use a battery that matches the ESC's voltage and current ratings.
Signal Quality: Use a clean and stable PWM signal to avoid erratic motor behavior.
Safety: Always disconnect the battery when making wiring changes to prevent accidental short circuits.
Example Code for Arduino UNO
Below is an example of how to control an ESC using an Arduino UNO:
#include <Servo.h> // Include the Servo library for generating PWM signals

Servo esc; // Create a Servo object to control the ESC

void setup() {
  esc.attach(9); // Attach the ESC signal wire to pin 9 on the Arduino
  esc.writeMicroseconds(1000); // Set the ESC to minimum throttle (1000us)
  delay(2000); // Wait for 2 seconds to allow the ESC to initialize
}

void loop() {
  esc.writeMicroseconds(1500); // Set throttle to mid-range (1500us)
  delay(5000); // Run the motor at mid-speed for 5 seconds

  esc.writeMicroseconds(2000); // Set throttle to maximum (2000us)
  delay(5000); // Run the motor at full speed for 5 seconds

  esc.writeMicroseconds(1000); // Set throttle to minimum (1000us)
  delay(5000); // Stop the motor for 5 seconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Spin:
Check all connections, especially the signal input and motor phase wires.
Ensure the ESC is receiving a valid PWM signal from the controller.
Verify that the battery voltage is within the ESC's operating range.
Motor Spins in the Wrong Direction:
Swap any two of the motor phase wires to reverse the motor's direction.
ESC Overheating:
Ensure proper cooling and ventilation.
Check if the motor is drawing excessive current and adjust the load if necessary.
Erratic Motor Behavior:
Verify the quality of the PWM signal. Use a stable and noise-free signal source.
Check for loose or damaged wires.
FAQs
Q: Can I use an ESC with a brushed motor?
A: Some ESCs are designed specifically for brushed motors, while others are for brushless motors. Ensure you use the correct type of ESC for your motor.
Q: What is the purpose of the BEC in an ESC?
A: The BEC (Battery Eliminator Circuit) provides a regulated voltage (e.g., 5V or 6V) to power external devices like servos or microcontrollers, eliminating the need for a separate power source.
Q: How do I calibrate my ESC?
A: Calibration typically involves setting the throttle range. Refer to the ESC's manual for specific instructions, as the process may vary by model.
Q: Can I use an ESC with an Arduino?
A: Yes, an ESC can be controlled using an Arduino by generating a PWM signal. Refer to the example code provided above for guidance.

 Open Project in Cirkit Designer