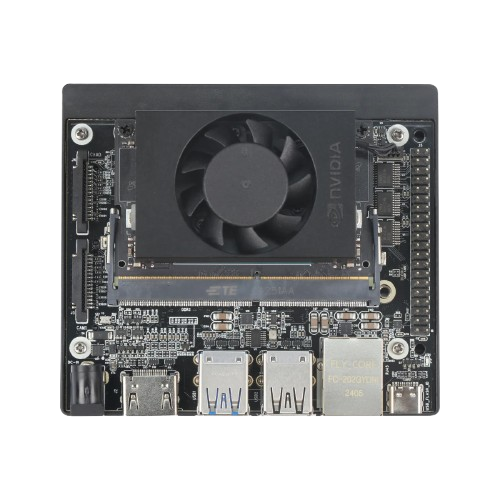
The Jetson Orin Nano is a compact AI computing platform designed for edge devices, featuring a powerful GPU and CPU architecture that supports advanced machine learning and computer vision applications. It is part of NVIDIA's Jetson family, offering high performance in a small form factor, making it ideal for robotics, IoT, smart cameras, and other AI-driven applications. With its energy-efficient design, the Jetson Orin Nano is well-suited for deployment in environments where power consumption and space are critical considerations.
Explore Projects Built with Jetson Orin Nano
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
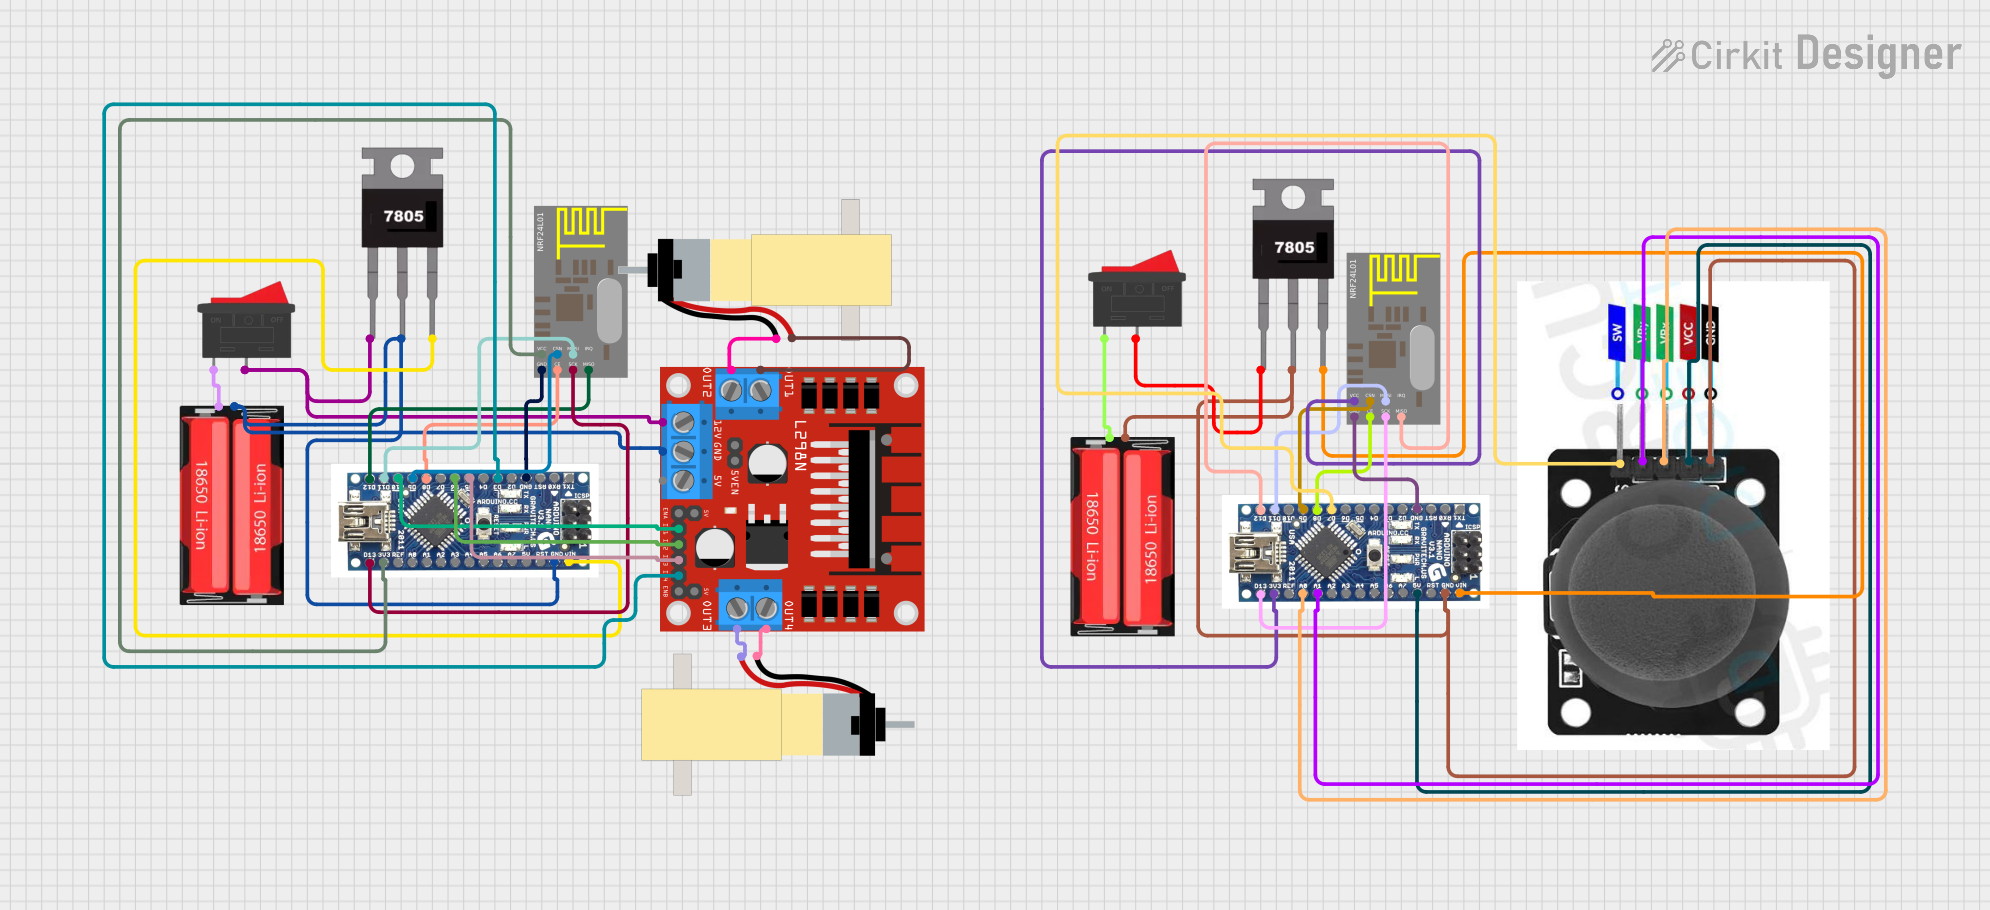
This circuit is a wireless controlled robotic vehicle system. It features two Arduino Nanos with nRF24L01 modules for remote communication, a joystick for control input, and a L298N motor driver to operate two DC gearmotors. Power is managed by 18650 Li-Ion batteries and 7805 voltage regulators, with rocker switches for power control.
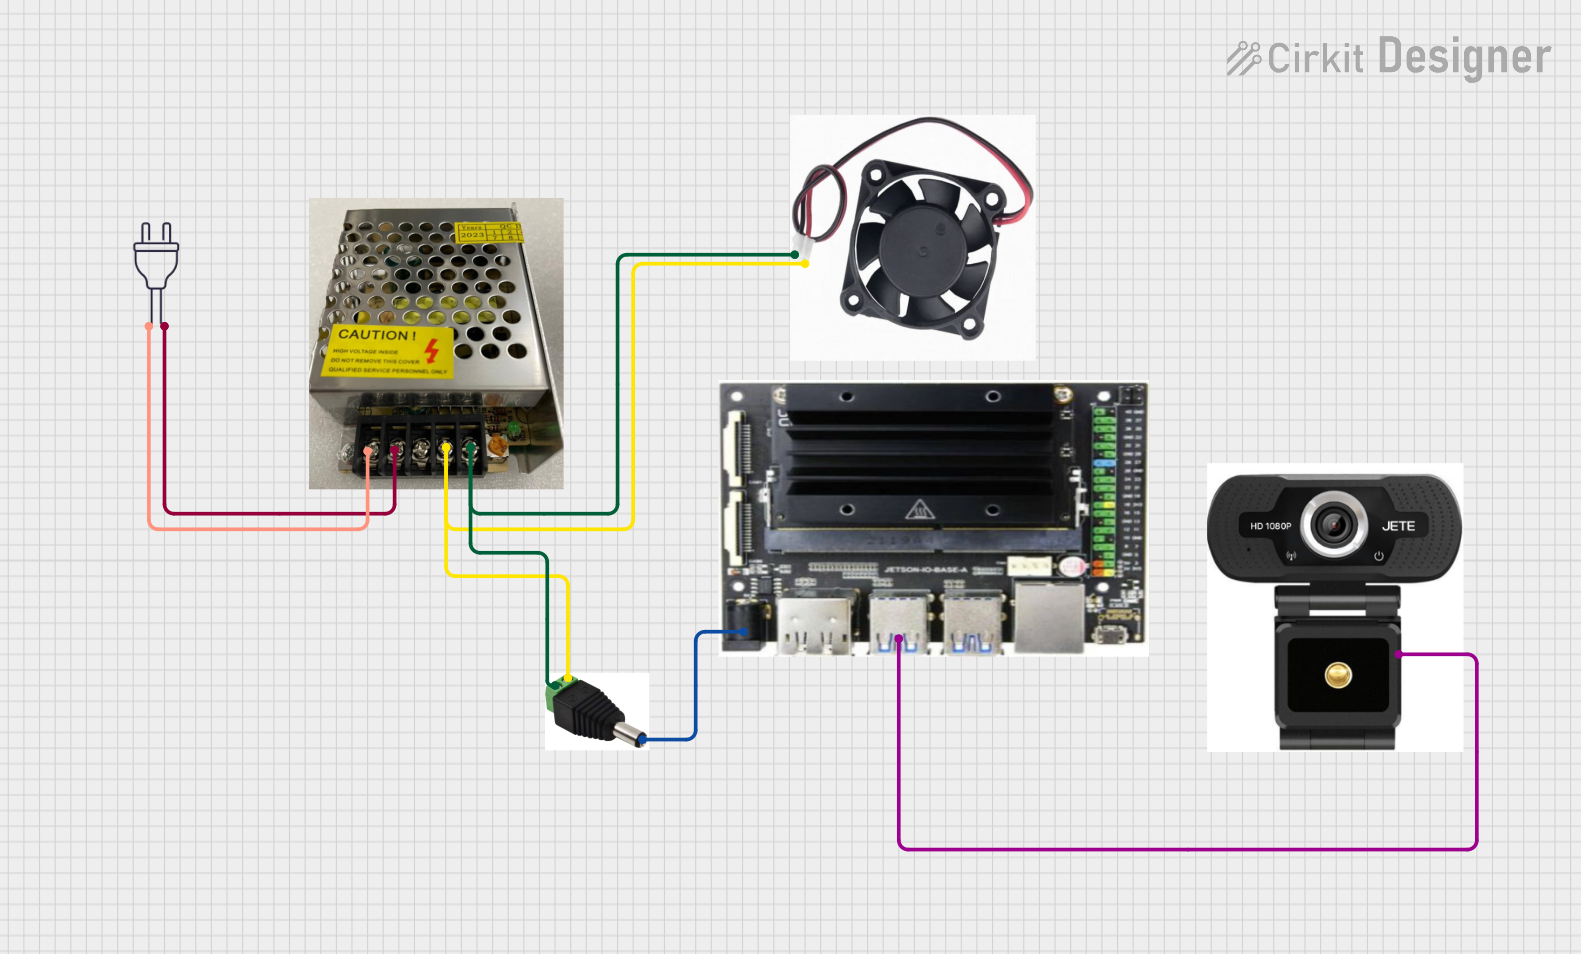
This circuit powers a Jetson Nano and a fan using a 220V AC power supply. The power supply converts the AC voltage to DC, which is then distributed to the Jetson Nano via a converter jack and to the fan. Additionally, a Jete w7 USB device is connected to the Jetson Nano.
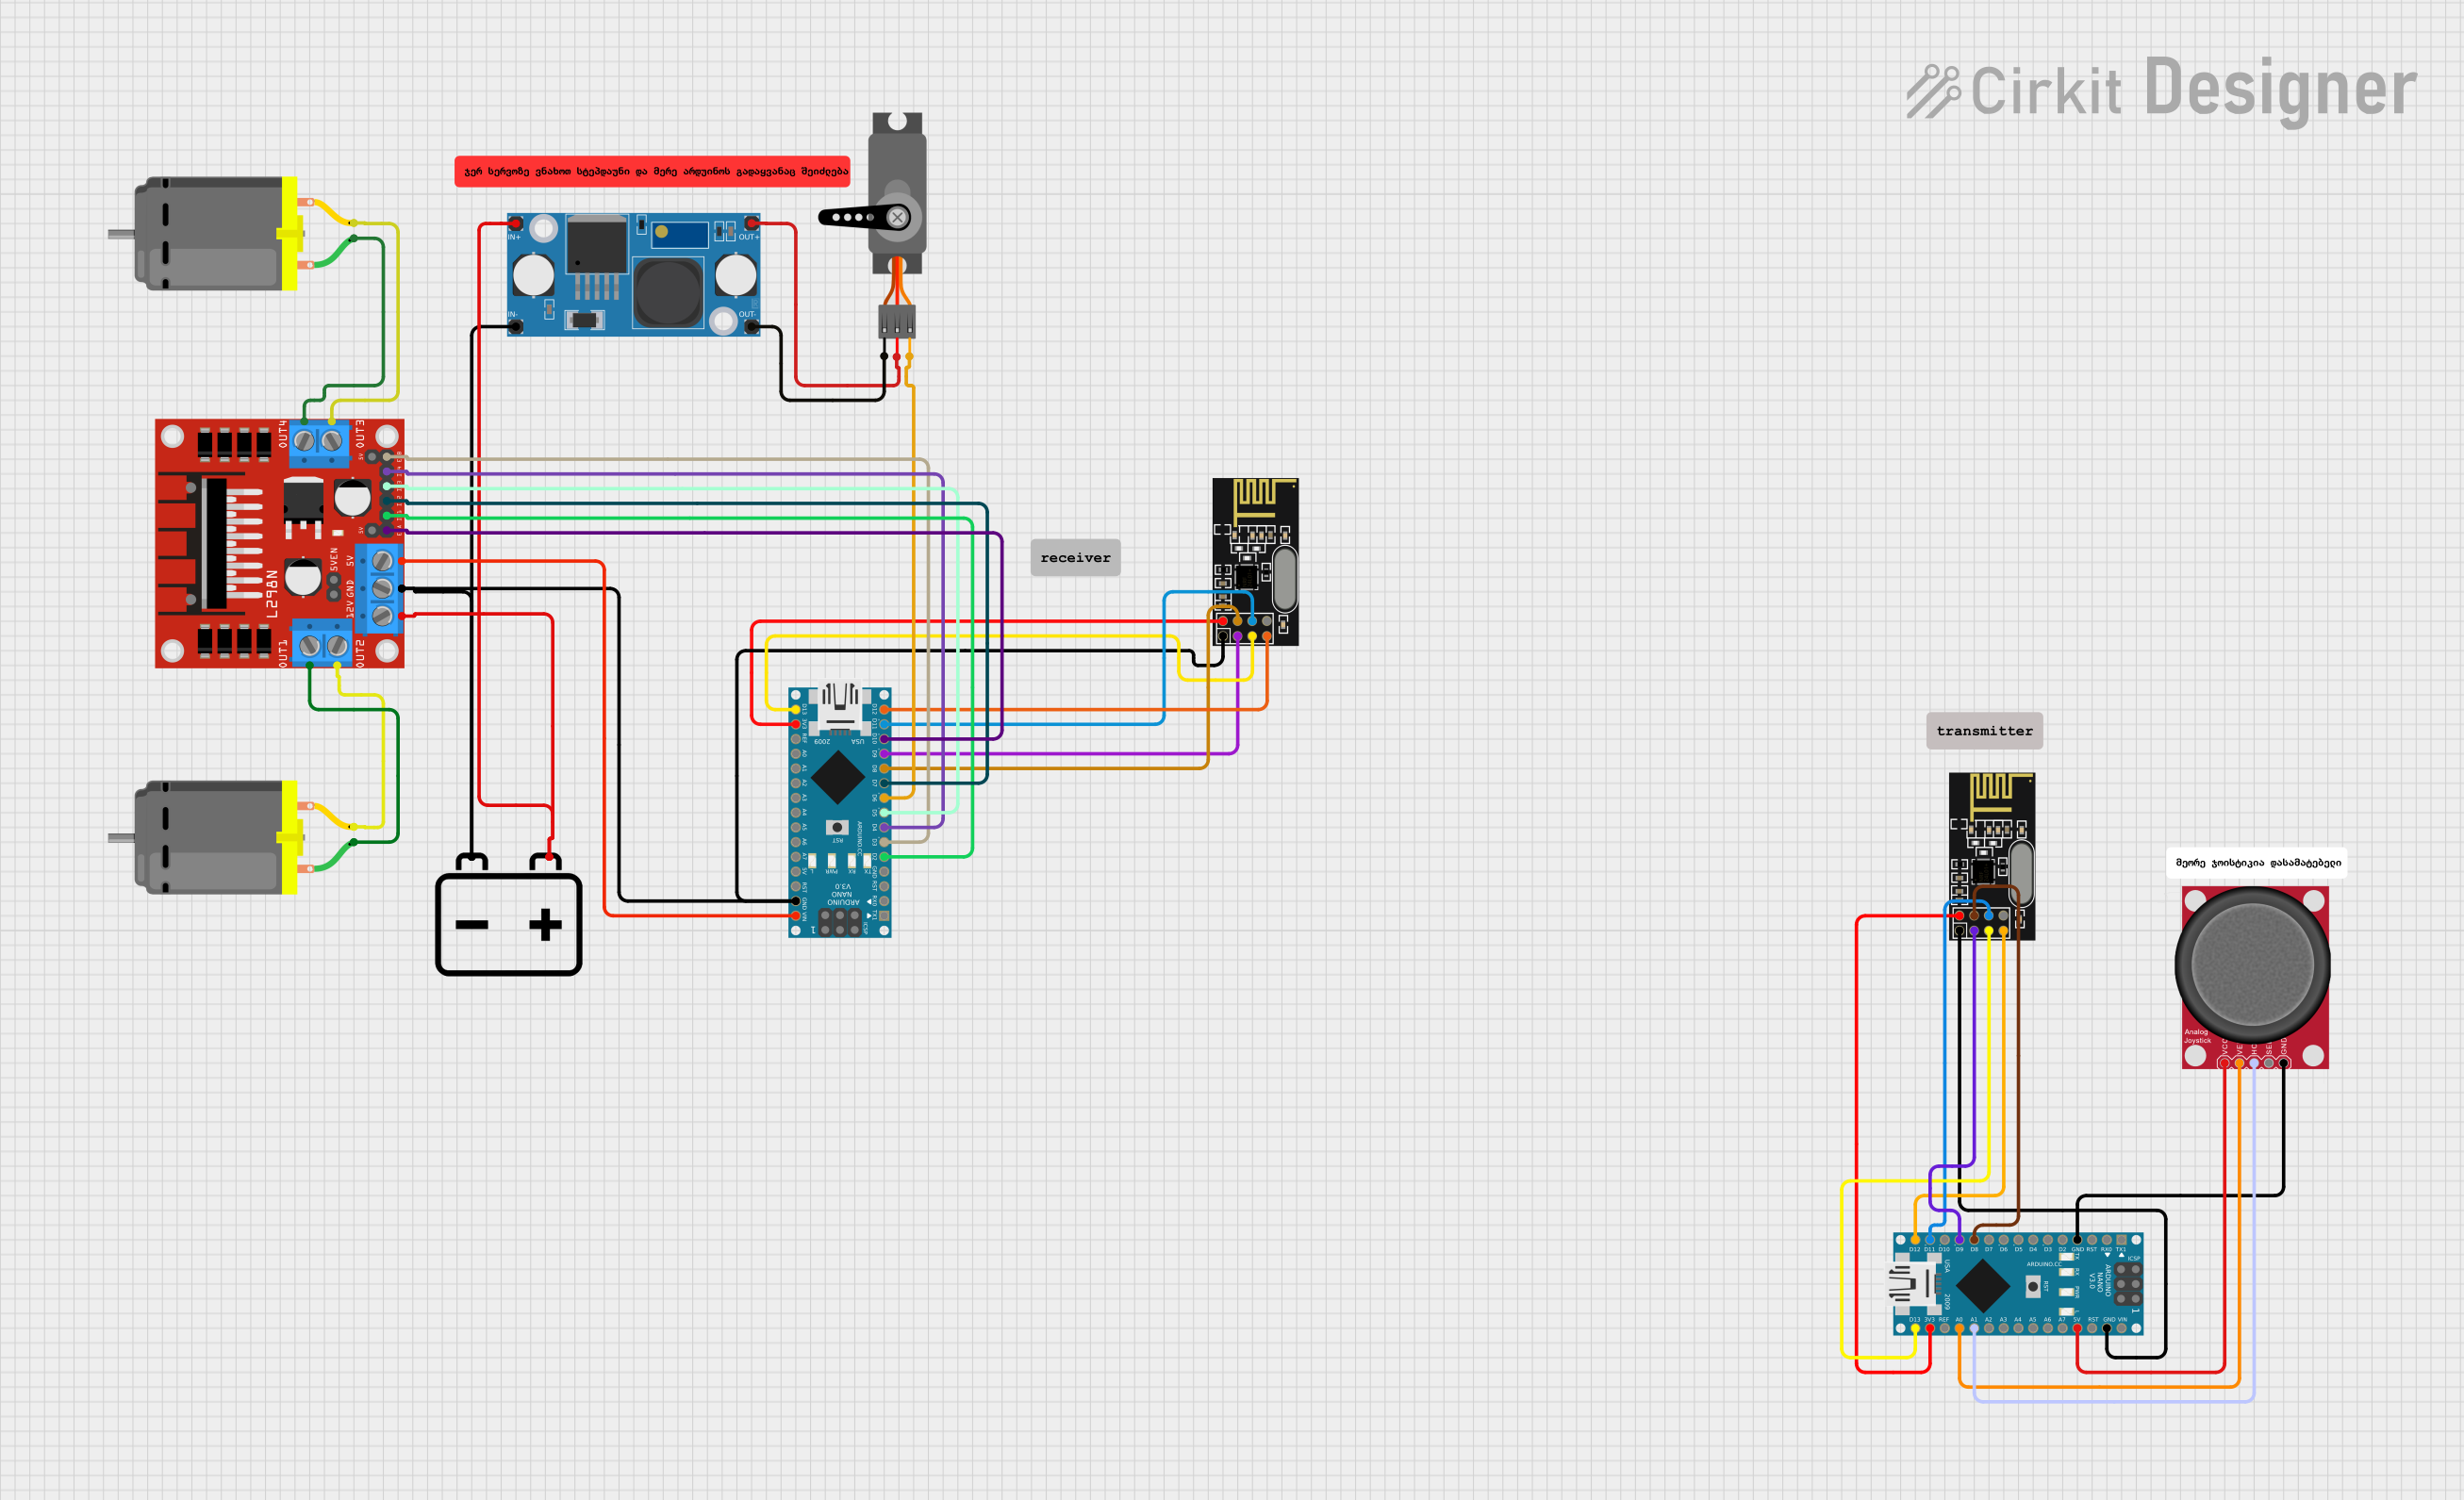
This circuit features two Arduino Nanos configured for wireless communication using NRF24L01 modules, with one acting as a transmitter and the other as a receiver. The transmitter Arduino reads input from an analog joystick and sends the data wirelessly to the receiver Arduino, which controls a servo motor and two DC motors via an L298N motor driver. The system is powered by a 12V battery, with a step-down module providing the appropriate voltage levels for the servo and logic components.
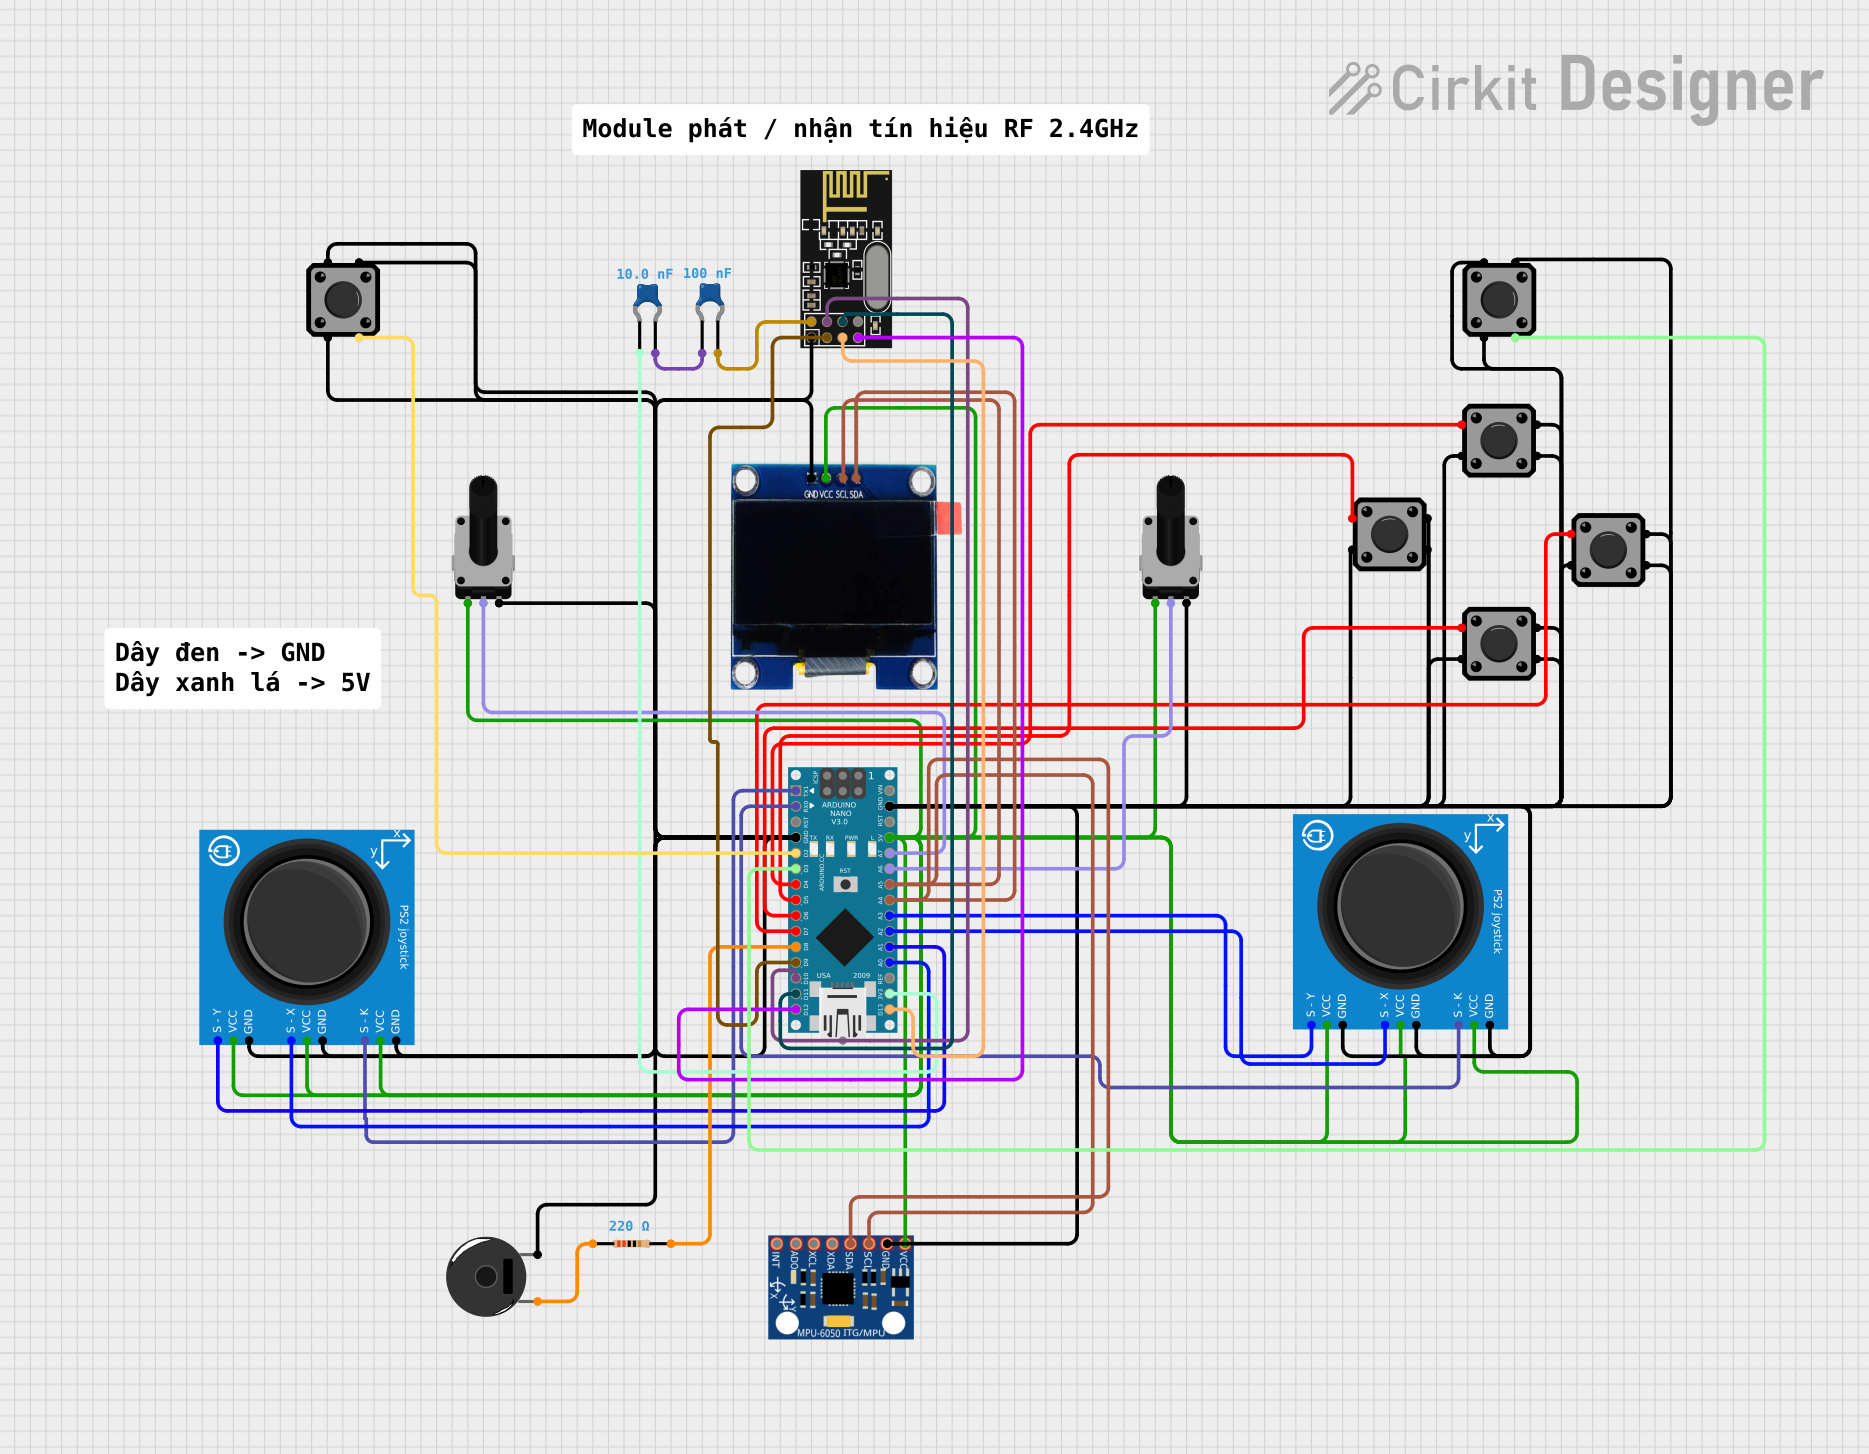
This is a multifunctional interactive device featuring dual-axis control via PS2 joysticks, visual feedback through an OLED display, and wireless communication using an NRF24L01 module. It includes a piezo buzzer for sound, tactile buttons for additional user input, rotary potentiometers for analog control, and an MPU-6050 for motion sensing. The Arduino Nano serves as the central processing unit, coordinating input and output functions, with capacitors for power stability.
Natural language processing and speech recognition
Technical Specifications
Key Technical Details
Specification
Value
GPU
NVIDIA Ampere architecture with 1024 CUDA cores and 32 Tensor Cores
CPU
6-core ARM Cortex-A78AE v8.2 64-bit CPU
Memory
8 GB LPDDR5
Storage
eMMC 5.1 (16 GB) + microSD card support
AI Performance
Up to 40 TOPS (Tera Operations Per Second)
Power Consumption
Configurable: 7W or 15W
Connectivity
1x Gigabit Ethernet, USB 3.2, I2C, SPI, UART
Display Support
HDMI 2.1, DP 1.2
Operating System
NVIDIA JetPack SDK (based on Ubuntu Linux)
Dimensions
100 mm x 80 mm
Pin Configuration and Descriptions
The Jetson Orin Nano features a 260-pin SO-DIMM connector for interfacing with carrier boards. Below is a summary of key pin groups:
Pin Group
Description
GPIO
General-purpose input/output pins for custom interfacing
I2C
Inter-Integrated Circuit for communication with sensors and peripherals
SPI
Serial Peripheral Interface for high-speed device communication
UART
Universal Asynchronous Receiver-Transmitter for serial communication
USB
USB 3.2 for high-speed data transfer and peripheral connectivity
Ethernet
Gigabit Ethernet for network connectivity
Power
Pins for supplying power to the module (3.3V, 5V, and GND)
For a detailed pinout, refer to the official NVIDIA Jetson Orin Nano datasheet.
Usage Instructions
How to Use the Jetson Orin Nano in a Circuit
Power Supply: Ensure a stable power source of 5V with sufficient current capacity (minimum 4A for 15W mode).
Carrier Board: Mount the Jetson Orin Nano onto a compatible carrier board. NVIDIA provides official carrier boards, or you can use third-party options.
Peripherals: Connect peripherals such as a keyboard, mouse, and monitor via USB and HDMI/DisplayPort.
Storage: Insert a microSD card with the JetPack SDK pre-installed or use the onboard eMMC storage.
Booting: Power on the device. The Jetson Orin Nano will boot into the JetPack SDK environment.
Development: Use tools like TensorFlow, PyTorch, or NVIDIA DeepStream SDK for AI model development and deployment.
Important Considerations and Best Practices
Cooling: Use an appropriate heatsink and fan to prevent thermal throttling during intensive workloads.
Power Mode: Configure the power mode (7W or 15W) based on your application requirements using the nvpmodel tool.
Software Updates: Regularly update the JetPack SDK to access the latest features and security patches.
Peripheral Compatibility: Verify compatibility of sensors and peripherals with the Jetson Orin Nano before integration.
Example: Using Jetson Orin Nano with an Arduino UNO
The Jetson Orin Nano can communicate with an Arduino UNO via UART. Below is an example Python script for sending data from the Jetson Orin Nano to the Arduino UNO:
import serial
import time

# Initialize serial communication with Arduino
# Replace '/dev/ttyUSB0' with the correct port for your Arduino
arduino = serial.Serial(port='/dev/ttyUSB0', baudrate=9600, timeout=1)

def send_data(data):
    """
    Sends data to the Arduino via UART.
    Args:
        data (str): The string data to send.
    """
    arduino.write(data.encode())  # Encode the string to bytes
    time.sleep(0.1)  # Short delay to ensure data is sent

try:
    while True:
        # Example: Send a message to the Arduino
        send_data("Hello, Arduino!")
        print("Data sent to Arduino.")
        time.sleep(1)  # Wait 1 second before sending the next message
except KeyboardInterrupt:
    print("Exiting program.")
finally:
    arduino.close()  # Close the serial connection
Note: Ensure the Arduino is programmed to receive and process the data sent from the Jetson Orin Nano.
Troubleshooting and FAQs
Common Issues and Solutions
Device Not Booting
Cause: Insufficient power supply or improperly seated module.
Solution: Verify the power source and ensure the module is securely mounted on the carrier board.
Overheating
Cause: Inadequate cooling during high-performance tasks.
Solution: Install a heatsink and fan, and ensure proper airflow around the device.
Peripheral Not Detected
Cause: Incompatible or improperly connected peripheral.
Solution: Check the compatibility of the peripheral and ensure proper connections.
UART Communication Issues
Cause: Incorrect baud rate or port configuration.
Solution: Verify the baud rate and port settings in the code and hardware.
FAQs
Q: Can the Jetson Orin Nano run on battery power?
A: Yes, but ensure the battery can provide a stable 5V output with sufficient current (minimum 4A for 15W mode).
Q: What is the maximum resolution supported for displays?
A: The Jetson Orin Nano supports up to 4K resolution via HDMI 2.1 or DisplayPort 1.2.
Q: Can I use the Jetson Orin Nano for real-time object detection?
A: Yes, the Jetson Orin Nano is capable of real-time object detection using frameworks like NVIDIA DeepStream or TensorFlow.
Q: How do I switch between power modes?
A: Use the nvpmodel tool to configure the power mode. For example, run sudo nvpmodel -m 0 for 15W mode or sudo nvpmodel -m 1 for 7W mode.
For additional support, refer to the official NVIDIA Jetson Orin Nano documentation and community forums.

 Open Project in Cirkit Designer