Introduction
The Moto Driver 6600 is a versatile motor driver IC designed to control both DC motors and stepper motors. It provides the necessary current and voltage to drive motors efficiently based on input control signals. This component is widely used in robotics, automation systems, and other motor control applications due to its reliability and ease of use.
Common Applications
- Robotics and automation
- CNC machines
- Electric vehicles
- Conveyor belt systems
- DIY motorized projects
Technical Specifications
Key Technical Details
- Operating Voltage Range: 4.5V to 36V
- Output Current: Up to 3A per channel (continuous)
- Peak Current: 4A per channel (short duration)
- Number of Channels: Dual H-Bridge (can control 2 DC motors or 1 stepper motor)
- Control Logic Voltage: 3.3V or 5V compatible
- PWM Frequency: Up to 100 kHz
- Thermal Shutdown Protection: Yes
- Overcurrent Protection: Yes
- Operating Temperature Range: -40°C to 85°C
Pin Configuration and Descriptions
The Moto Driver 6600 typically comes in a 16-pin package. Below is the pin configuration:
Usage Instructions
How to Use the Moto Driver 6600 in a Circuit
Power Connections:
- Connect the motor power supply (VM) to the appropriate voltage source (4.5V to 36V).
- Connect the logic voltage supply (VCC) to 3.3V or 5V, depending on your microcontroller.
- Ensure all ground pins (GND) are connected to the common ground of the circuit.
Motor Connections:
- Connect the motor terminals to the output pins (OUT1, OUT2 for Motor 1; OUT3, OUT4 for Motor 2).
Control Signals:
- Use the input pins (IN1, IN2 for Motor 1; IN3, IN4 for Motor 2) to control the motor direction and speed.
- Apply a PWM signal to the input pins for speed control.
- Use the enable pins (ENA, ENB) to activate or deactivate the motors.
Logic Control:
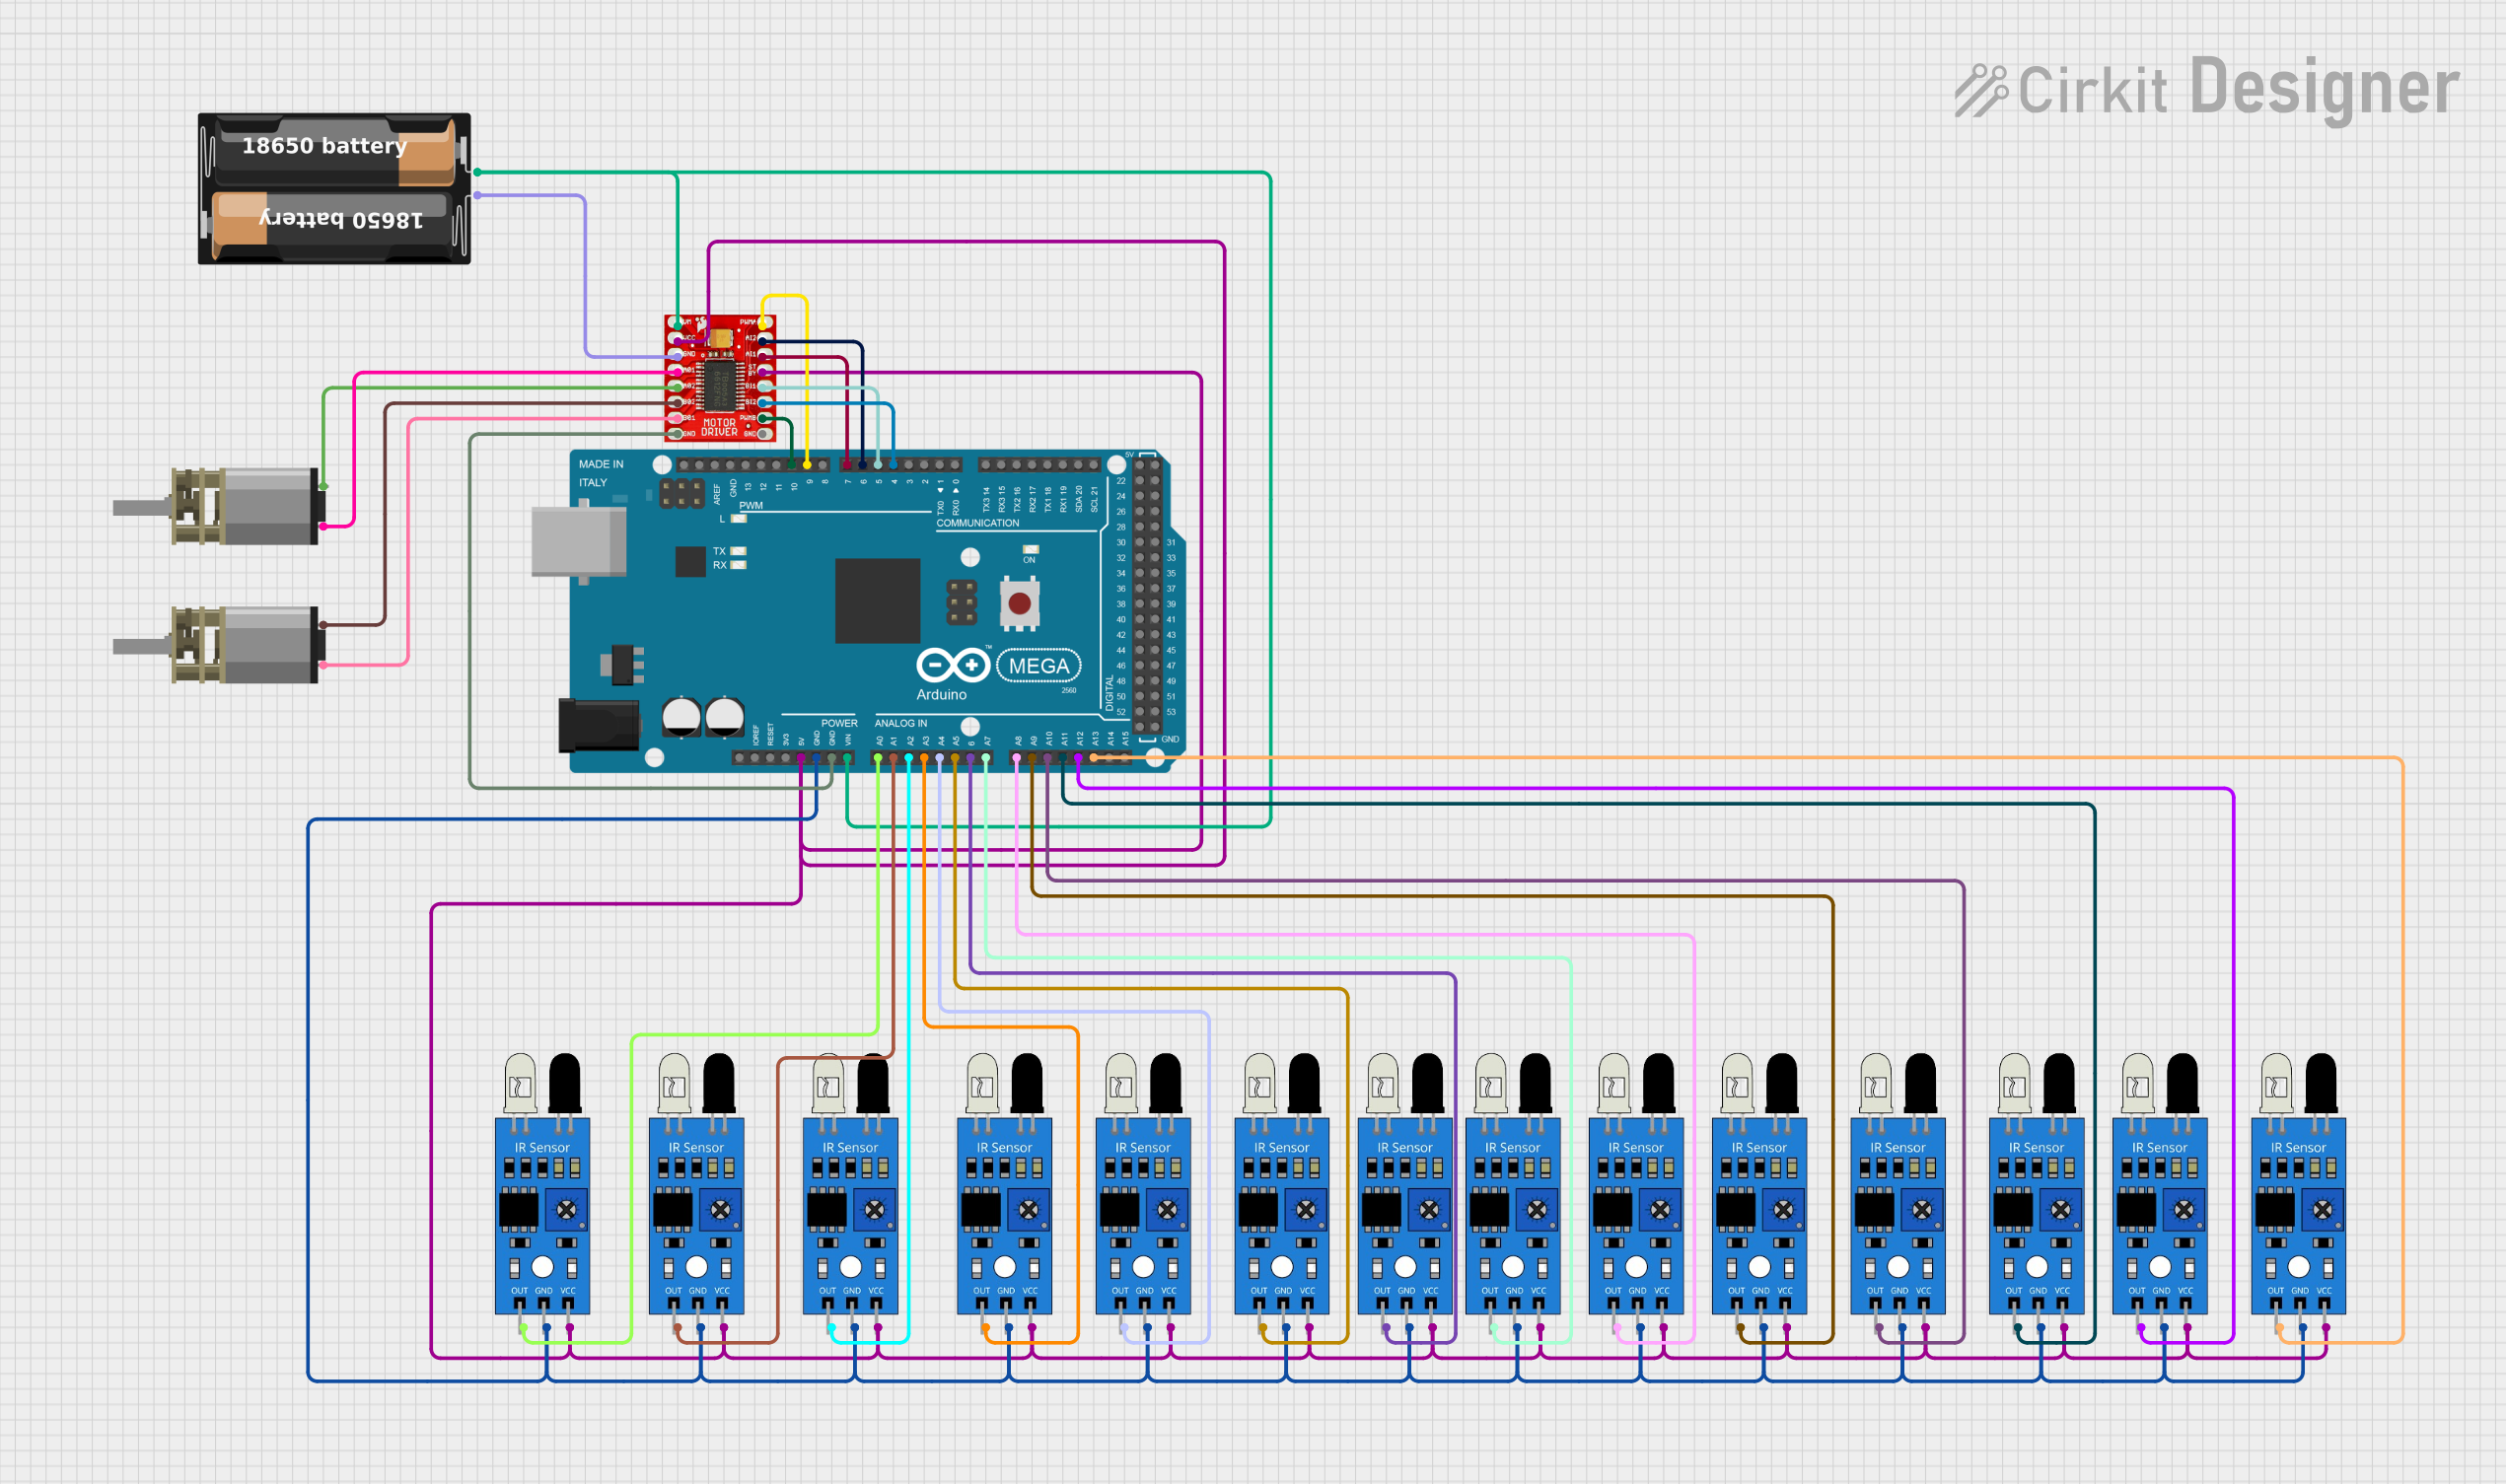
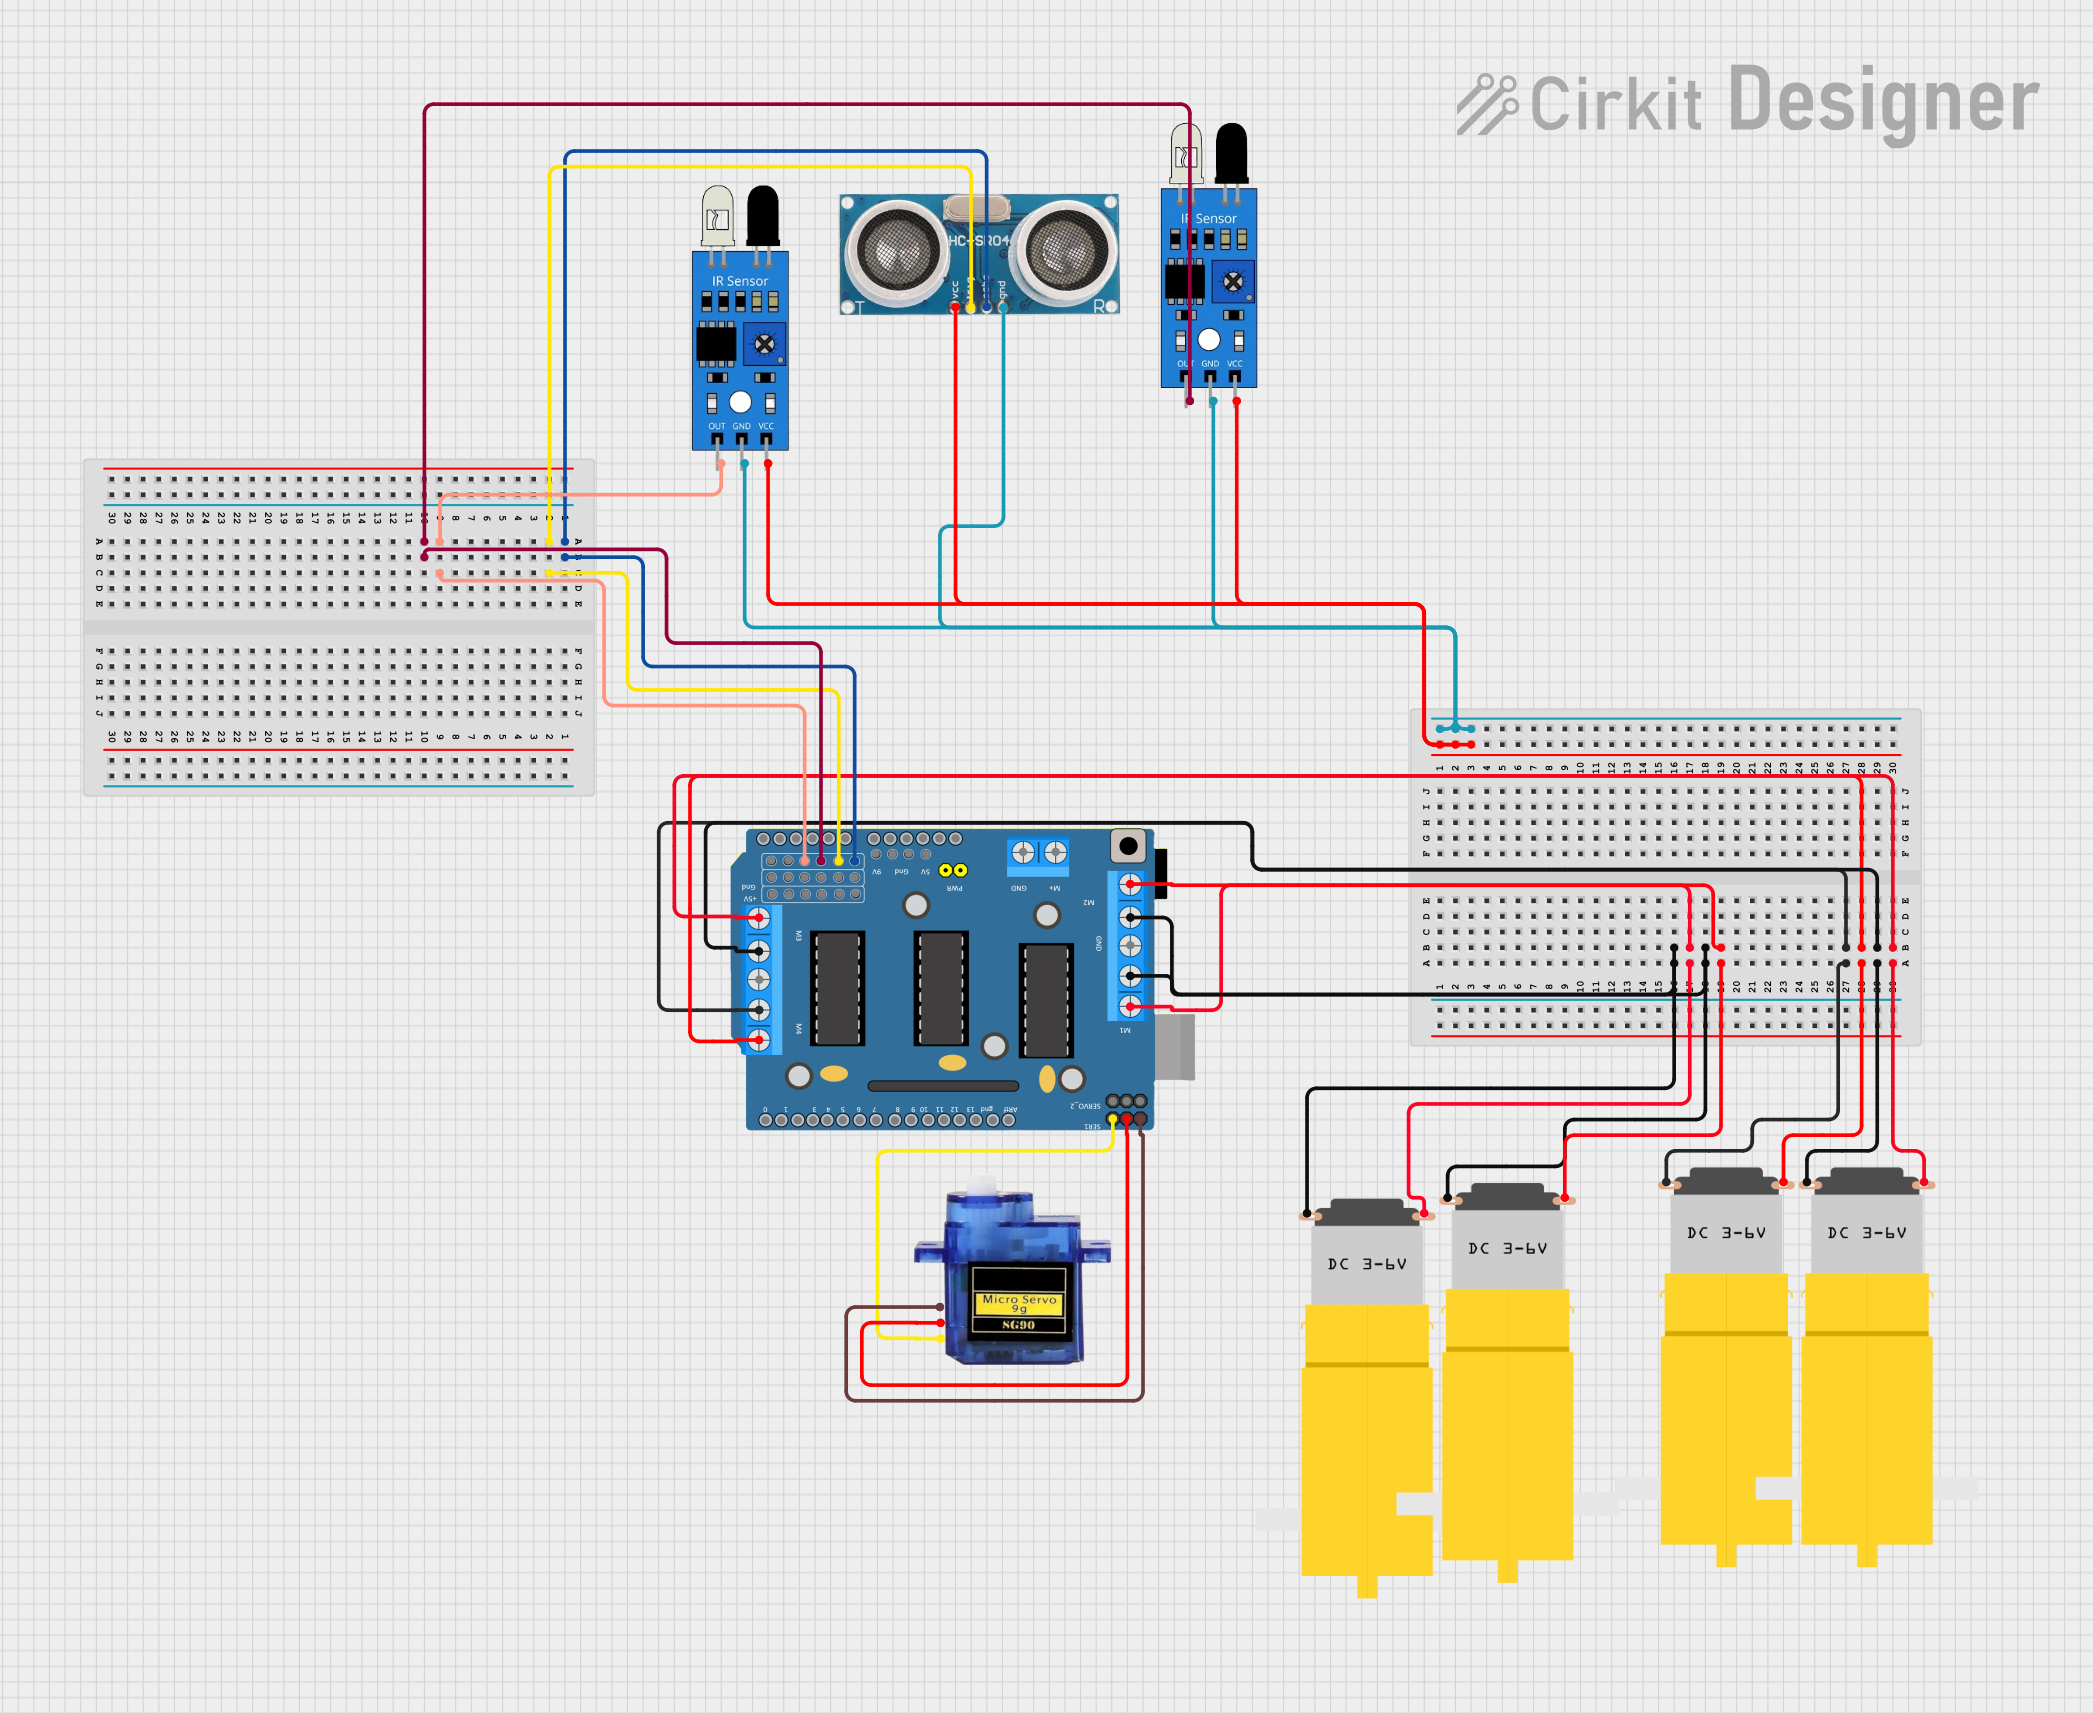
- Use a microcontroller (e.g., Arduino UNO) to send control signals to the input and enable pins.
Important Considerations
- Ensure the motor power supply voltage matches the motor's rated voltage.
- Use appropriate heat sinks or cooling mechanisms if operating at high currents.
- Avoid exceeding the maximum current rating to prevent damage to the IC.
- Use decoupling capacitors near the power supply pins to reduce noise.
Example Arduino Code
Below is an example of how to control a DC motor using the Moto Driver 6600 and an Arduino UNO:
// Define motor control pins
const int ENA = 9;  // Enable pin for Motor 1
const int IN1 = 7;  // Input 1 for Motor 1
const int IN2 = 8;  // Input 2 for Motor 1

void setup() {
  // Set motor control pins as outputs
  pinMode(ENA, OUTPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);

  // Initialize motor in stopped state
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, LOW);
  analogWrite(ENA, 0);  // Set speed to 0
}

void loop() {
  // Rotate motor forward at 50% speed
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);
  analogWrite(ENA, 128);  // 50% duty cycle (0-255)

  delay(2000);  // Run for 2 seconds

  // Rotate motor backward at 75% speed
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, HIGH);
  analogWrite(ENA, 192);  // 75% duty cycle

  delay(2000);  // Run for 2 seconds

  // Stop the motor
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, LOW);
  analogWrite(ENA, 0);  // Set speed to 0

  delay(2000);  // Wait for 2 seconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Running:
- Check the power supply connections (VM and VCC).
- Ensure the enable pin (ENA or ENB) is set to HIGH.
- Verify the input control signals (IN1, IN2, IN3, IN4).
Motor Running in the Wrong Direction:
- Swap the logic levels of the input pins (e.g., IN1 and IN2) to reverse the direction.
Overheating:
- Ensure the current drawn by the motor does not exceed the IC's maximum rating.
- Use a heat sink or cooling fan if necessary.
PWM Signal Not Working:
- Verify the PWM frequency is within the supported range (up to 100 kHz).
- Check the microcontroller's PWM pin configuration.
FAQs
Can the Moto Driver 6600 control stepper motors?
Yes, it can control stepper motors by driving the two H-bridges in a coordinated manner.
What is the maximum motor voltage supported?
The IC supports motor voltages up to 36V.
Is it compatible with 3.3V logic?
Yes, the Moto Driver 6600 is compatible with both 3.3V and 5V logic levels.
Does it have built-in protection features?
Yes, it includes thermal shutdown and overcurrent protection for safe operation.

 Open Project in Cirkit Designer