AMT103 Magnetic Encoder Documentation
1. Introduction
The AMT103 is a non-contact magnetic encoder designed to provide precise angular position feedback. It operates using a Hall effect sensor to detect the position of a rotating magnet, ensuring high accuracy and reliability. This encoder is widely used in motion control systems, robotics, industrial automation, and other applications requiring precise rotational measurements.
Key Features:
- Non-contact magnetic sensing for durability and reliability.
- High-resolution angular position feedback.
- Compact and lightweight design.
- Easy integration with microcontrollers and motor control systems.
Common Applications:
- Robotics (e.g., joint position feedback).
- Industrial automation (e.g., motor shaft position monitoring).
- CNC machines and 3D printers.
- Servo motor control systems.
- Precision measurement devices.
2. Technical Specifications
The following table outlines the key technical details of the AMT103 magnetic encoder:
Pin Configuration
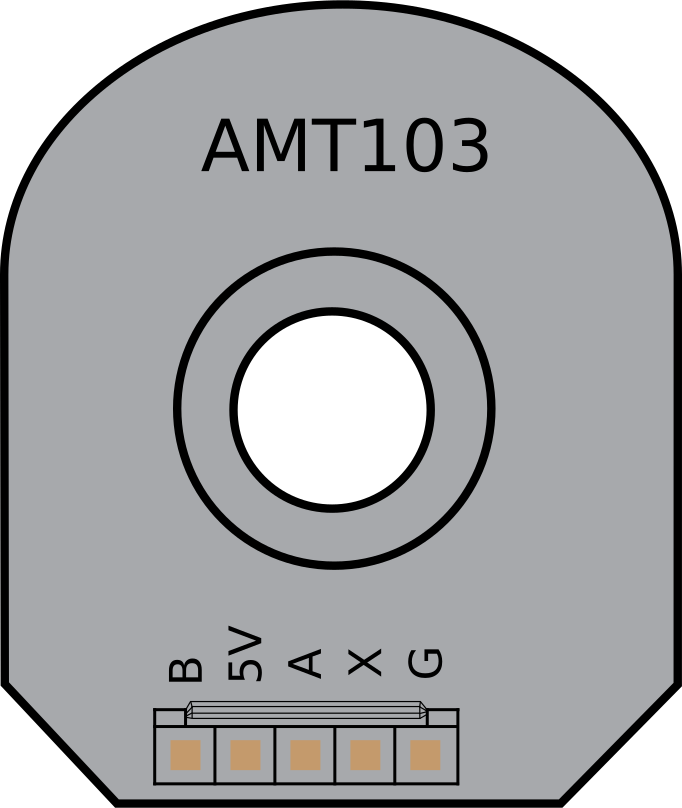
The AMT103 has a 5-pin interface. The pinout and descriptions are as follows:
3. Usage Instructions
Connecting the AMT103 to a Circuit
To use the AMT103, follow these steps:
- Power Supply: Connect the VCC pin to a 3.3V or 5V power source and the GND pin to the ground.
- Signal Outputs: Connect the A and B pins to the digital input pins of your microcontroller or motor controller. These pins provide the quadrature signals for position and direction detection.
- Index Pulse (Optional): If your application requires an index pulse, connect the Index pin to a digital input pin on your microcontroller.
Example Circuit Diagram
Below is a simple connection diagram for interfacing the AMT103 with an Arduino UNO:
AMT103 Encoder       Arduino UNO
----------------     ------------
VCC (Pin 1)   --->   5V
GND (Pin 2)   --->   GND
A (Pin 3)     --->   Digital Pin 2
B (Pin 4)     --->   Digital Pin 3
Index (Pin 5) --->   Digital Pin 4 (optional)
Important Considerations:
- Ensure the encoder is mounted securely to avoid misalignment during operation.
- Use pull-up resistors on the A and B signal lines if required by your microcontroller.
- Avoid placing the encoder near strong magnetic fields, as they may interfere with its operation.
4. Arduino Example Code
The following example demonstrates how to read the quadrature signals from the AMT103 using an Arduino UNO. This code calculates the position and direction of rotation.
// AMT103 Encoder Example Code
// Connect A to Pin 2, B to Pin 3, and Index (optional) to Pin 4.

#define ENCODER_PIN_A 2  // Quadrature signal A
#define ENCODER_PIN_B 3  // Quadrature signal B

volatile int encoderPosition = 0;  // Tracks the encoder position
volatile int lastEncoded = 0;      // Stores the last encoder state

void setup() {
  pinMode(ENCODER_PIN_A, INPUT);
  pinMode(ENCODER_PIN_B, INPUT);
  digitalWrite(ENCODER_PIN_A, HIGH);  // Enable pull-up resistor
  digitalWrite(ENCODER_PIN_B, HIGH);  // Enable pull-up resistor

  // Attach interrupts to handle encoder signals
  attachInterrupt(digitalPinToInterrupt(ENCODER_PIN_A), updateEncoder, CHANGE);
  attachInterrupt(digitalPinToInterrupt(ENCODER_PIN_B), updateEncoder, CHANGE);

  Serial.begin(9600);  // Initialize serial communication
}

void loop() {
  // Print the encoder position to the Serial Monitor
  Serial.print("Encoder Position: ");
  Serial.println(encoderPosition);
  delay(100);  // Update every 100ms
}

void updateEncoder() {
  int MSB = digitalRead(ENCODER_PIN_A);  // Most significant bit
  int LSB = digitalRead(ENCODER_PIN_B);  // Least significant bit

  int encoded = (MSB << 1) | LSB;        // Combine A and B signals
  int sum = (lastEncoded << 2) | encoded;  // Track state changes

  // Determine direction and update position
  if (sum == 0b1101 || sum == 0b0100 || sum == 0b0010 || sum == 0b1011) {
    encoderPosition++;
  } else if (sum == 0b1110 || sum == 0b0111 || sum == 0b0001 || sum == 0b1000) {
    encoderPosition--;
  }

  lastEncoded = encoded;  // Update the last state
}
Code Explanation:
- The
updateEncoder function is triggered by interrupts on the A and B pins.
- The function calculates the direction of rotation based on the quadrature signals.
- The
encoderPosition variable tracks the current position of the encoder.
5. Troubleshooting and FAQs
Common Issues and Solutions
FAQs
Can the AMT103 operate at 3.3V?
- Yes, the AMT103 supports a supply voltage range of 3.3V to 5.5V.
What is the maximum resolution of the AMT103?
- The AMT103 supports resolutions up to 2048 pulses per revolution (PPR).
How do I configure the resolution?
- The resolution can be configured using the encoder's onboard DIP switches. Refer to the manufacturer's datasheet for details.
Can I use the AMT103 with other microcontrollers?
- Yes, the AMT103 is compatible with any microcontroller that can read digital signals.
This documentation provides a comprehensive guide to using the AMT103 magnetic encoder. For further details, refer to the manufacturer's datasheet or contact technical support.

 Open Project in Cirkit Designer