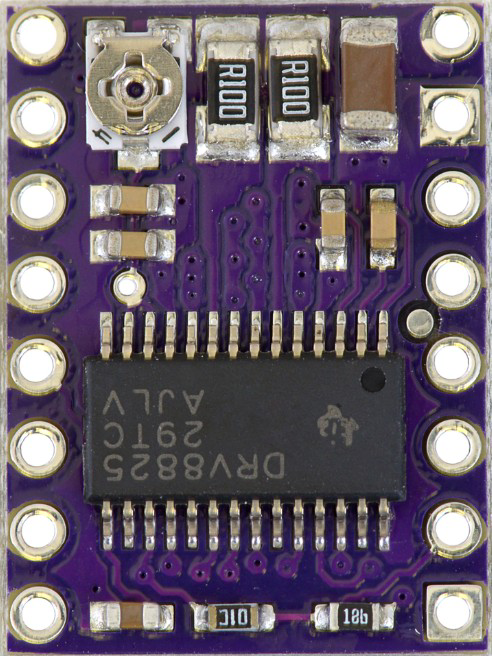
The DVR8825 is a high-performance microstepping driver designed for controlling stepper motors. It features adjustable current control, enabling smooth motor operation and reduced noise. With support for up to 2.5A per phase and multiple microstepping modes (full, half, quarter, eighth, and sixteenth), the DVR8825 is ideal for applications requiring precise motor control. Common use cases include robotics, 3D printers, CNC machines, and other automation systems.
Explore Projects Built with DVR8825 Stepper Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
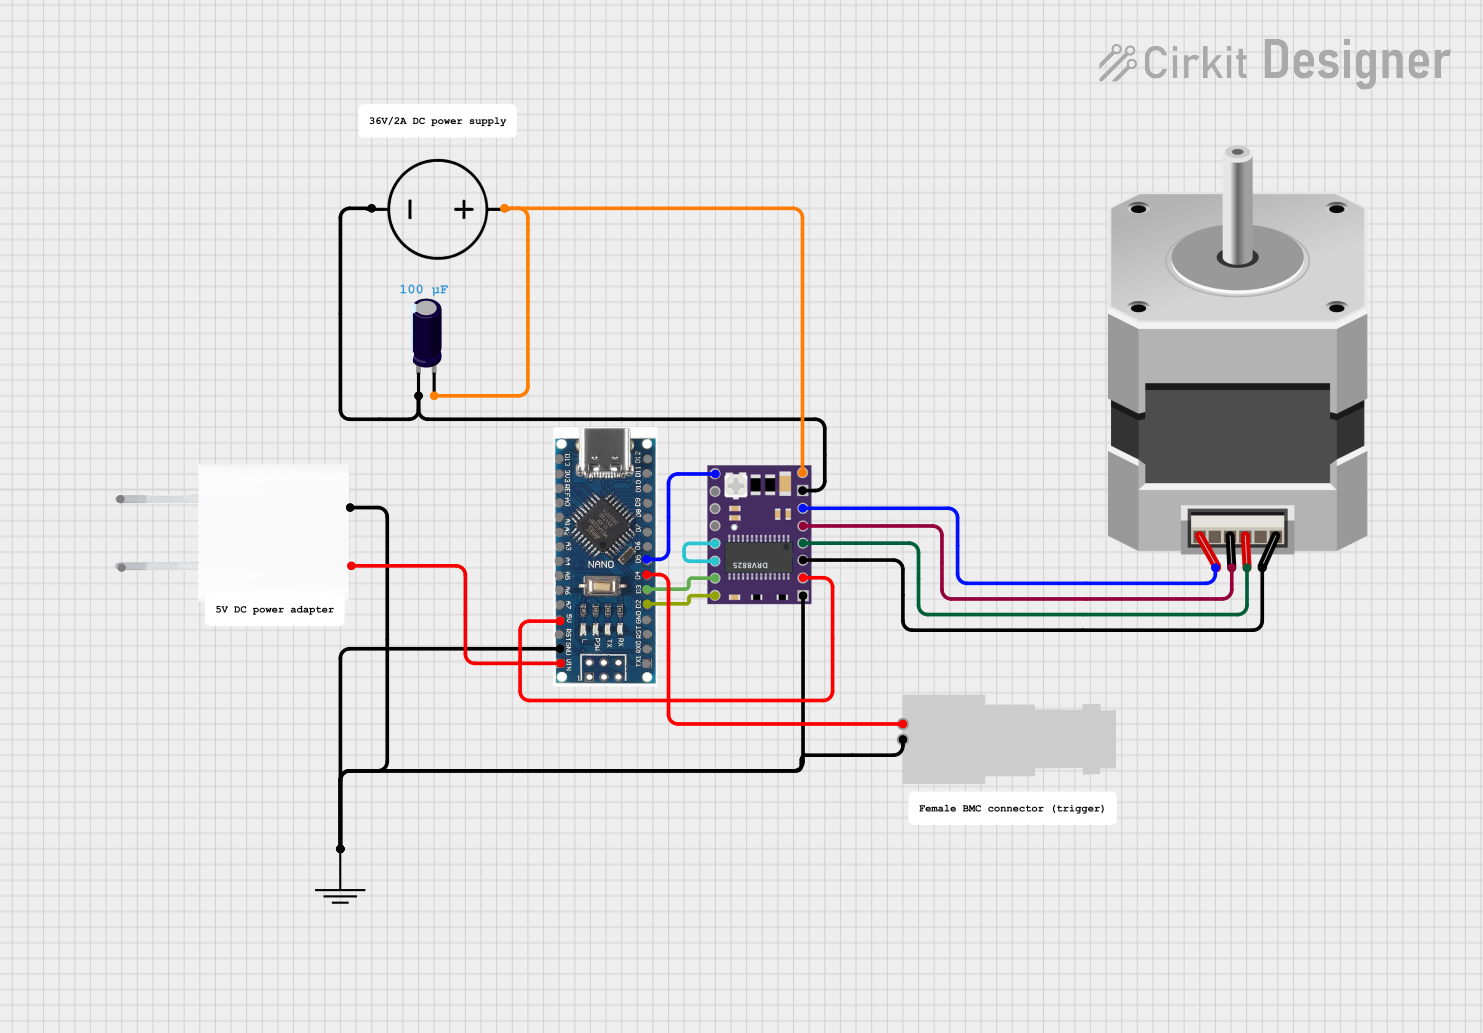
This circuit is designed to control a bipolar stepper motor using a DRV8825 stepper motor driver, which is interfaced with a Nano 3.0 ATmega328P microcontroller. The microcontroller sends step and direction signals to the DRV8825, which in turn drives the stepper motor's coils. Power is supplied to the system through a 5V adapter for the logic and a DC power source for the motor, with an electrolytic capacitor for voltage smoothing on the motor supply.
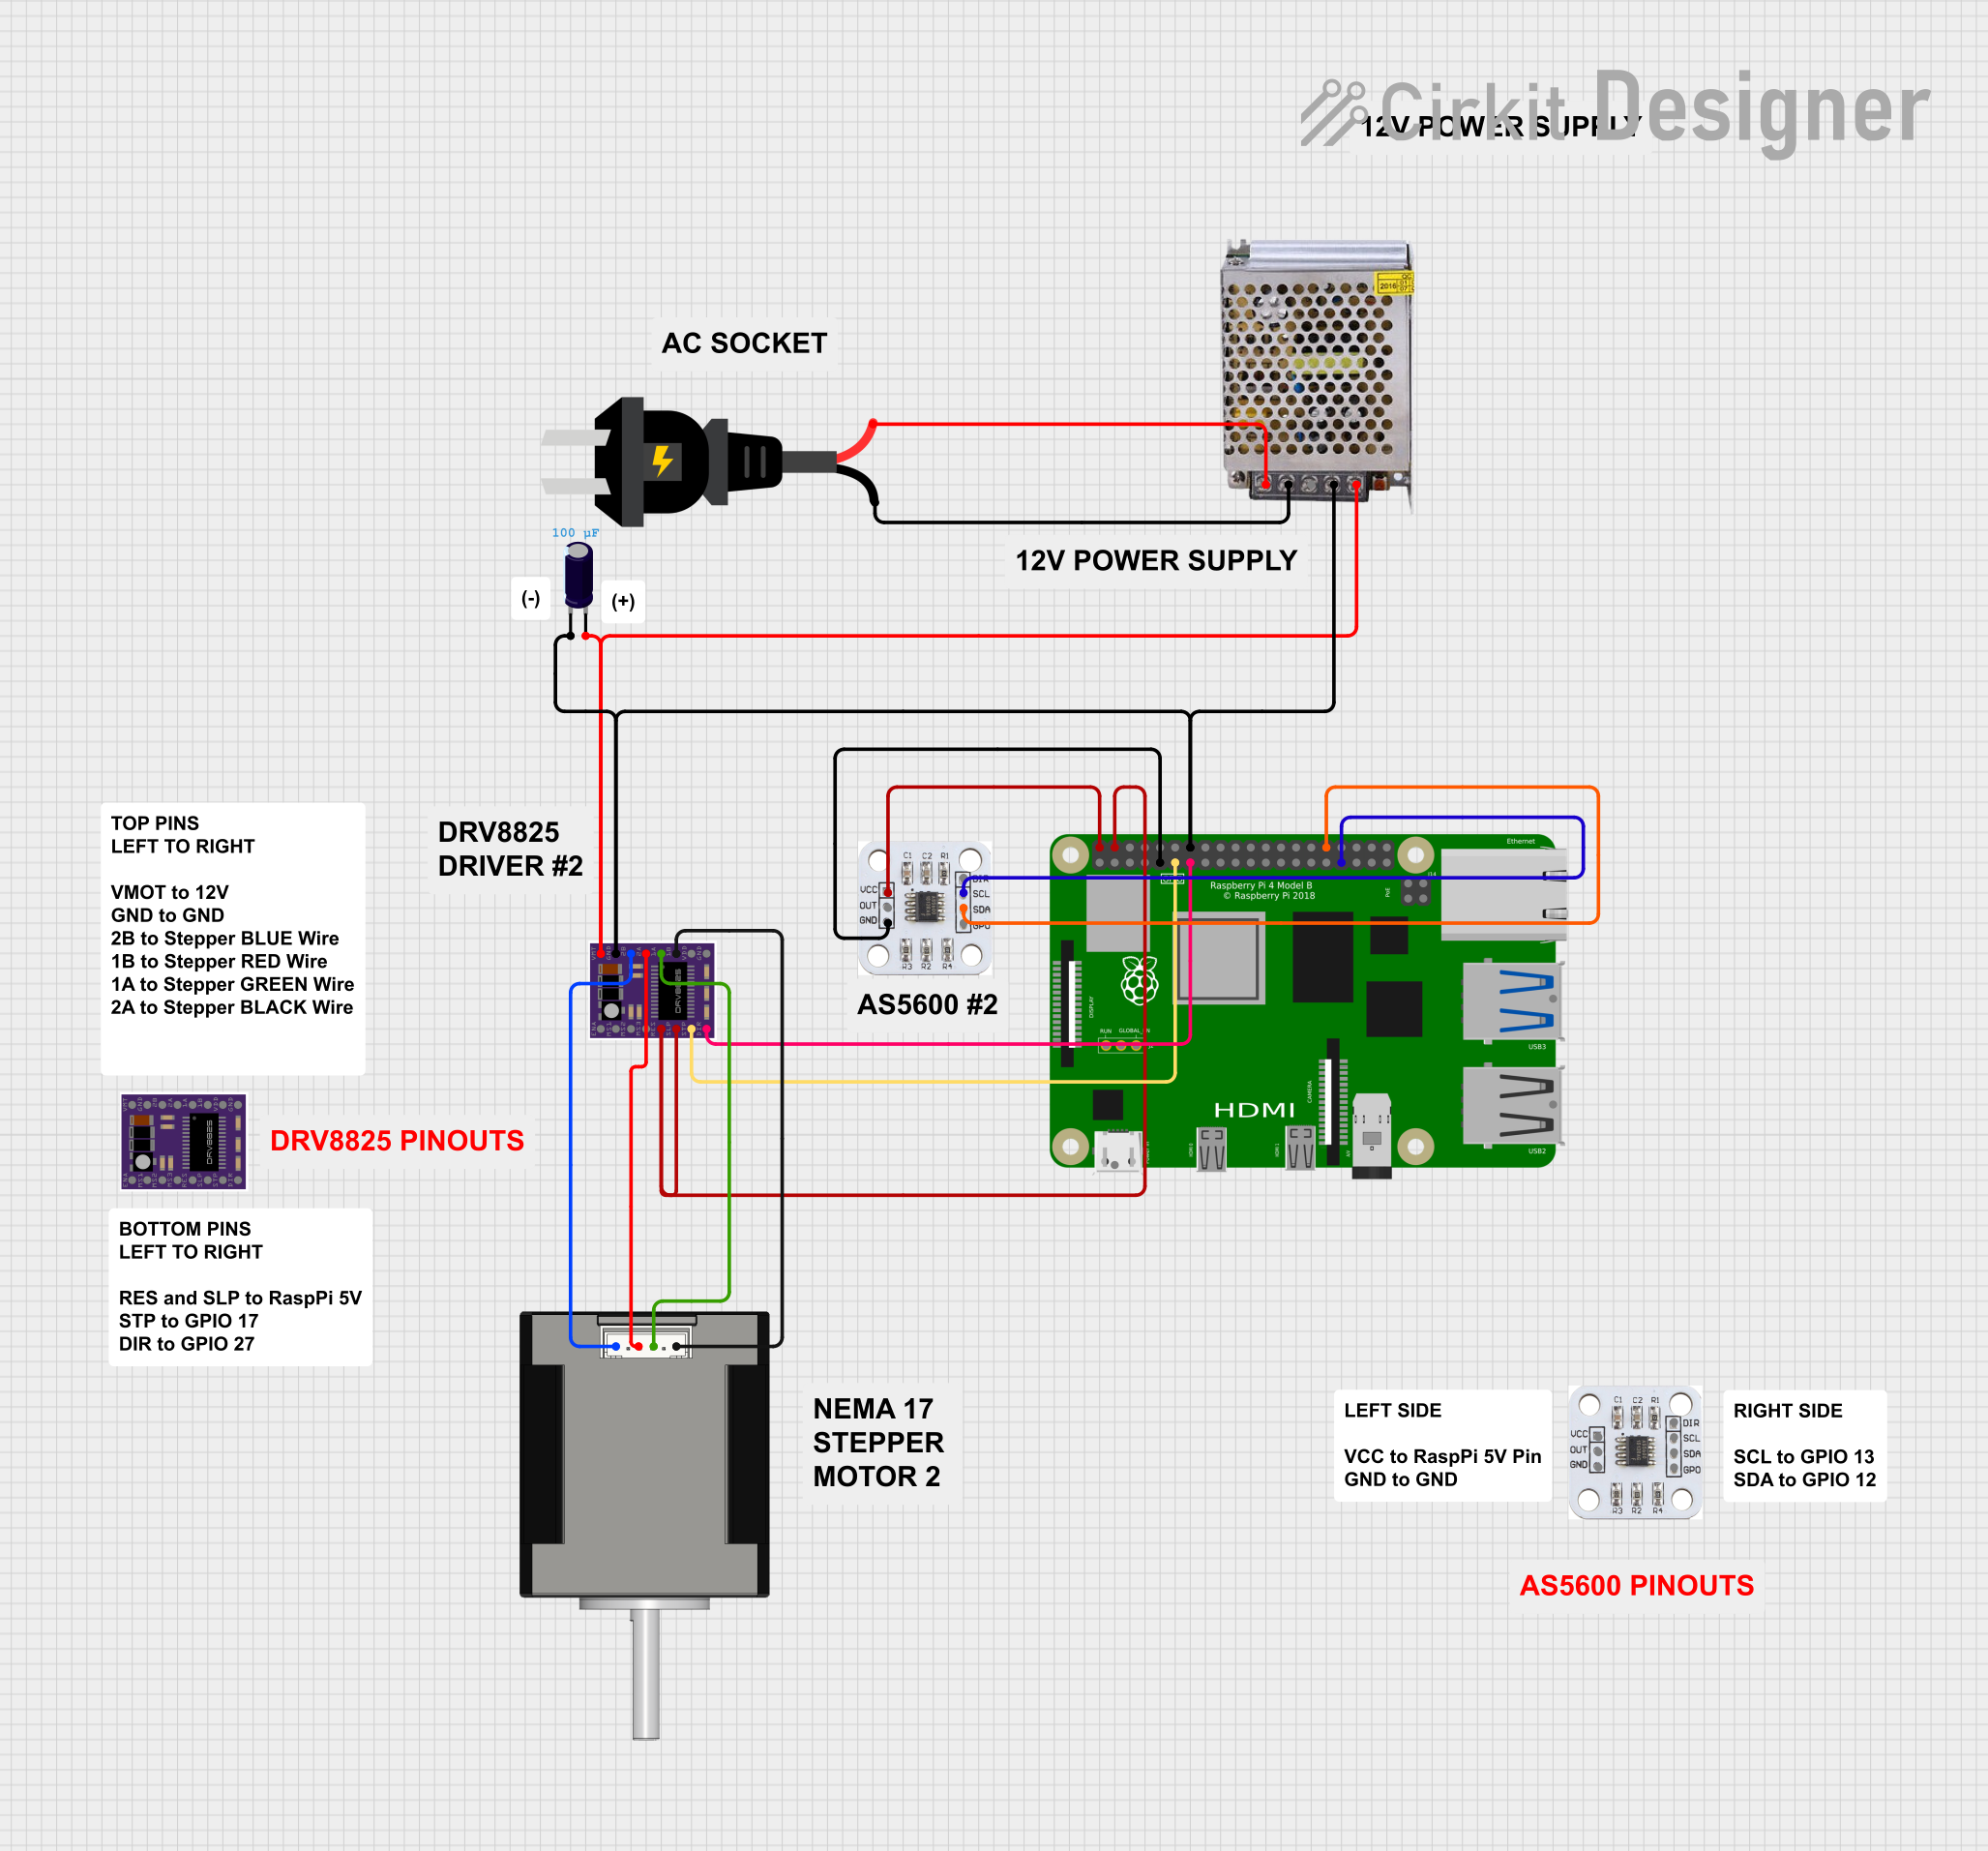
This circuit is designed to control a Nema 17 stepper motor using a DRV8825 driver, powered by a 12V power supply, and managed by a Raspberry Pi 4B. The Raspberry Pi interfaces with an AS5600 magnetic encoder for precise motor position feedback and controls the motor driver through GPIO pins.
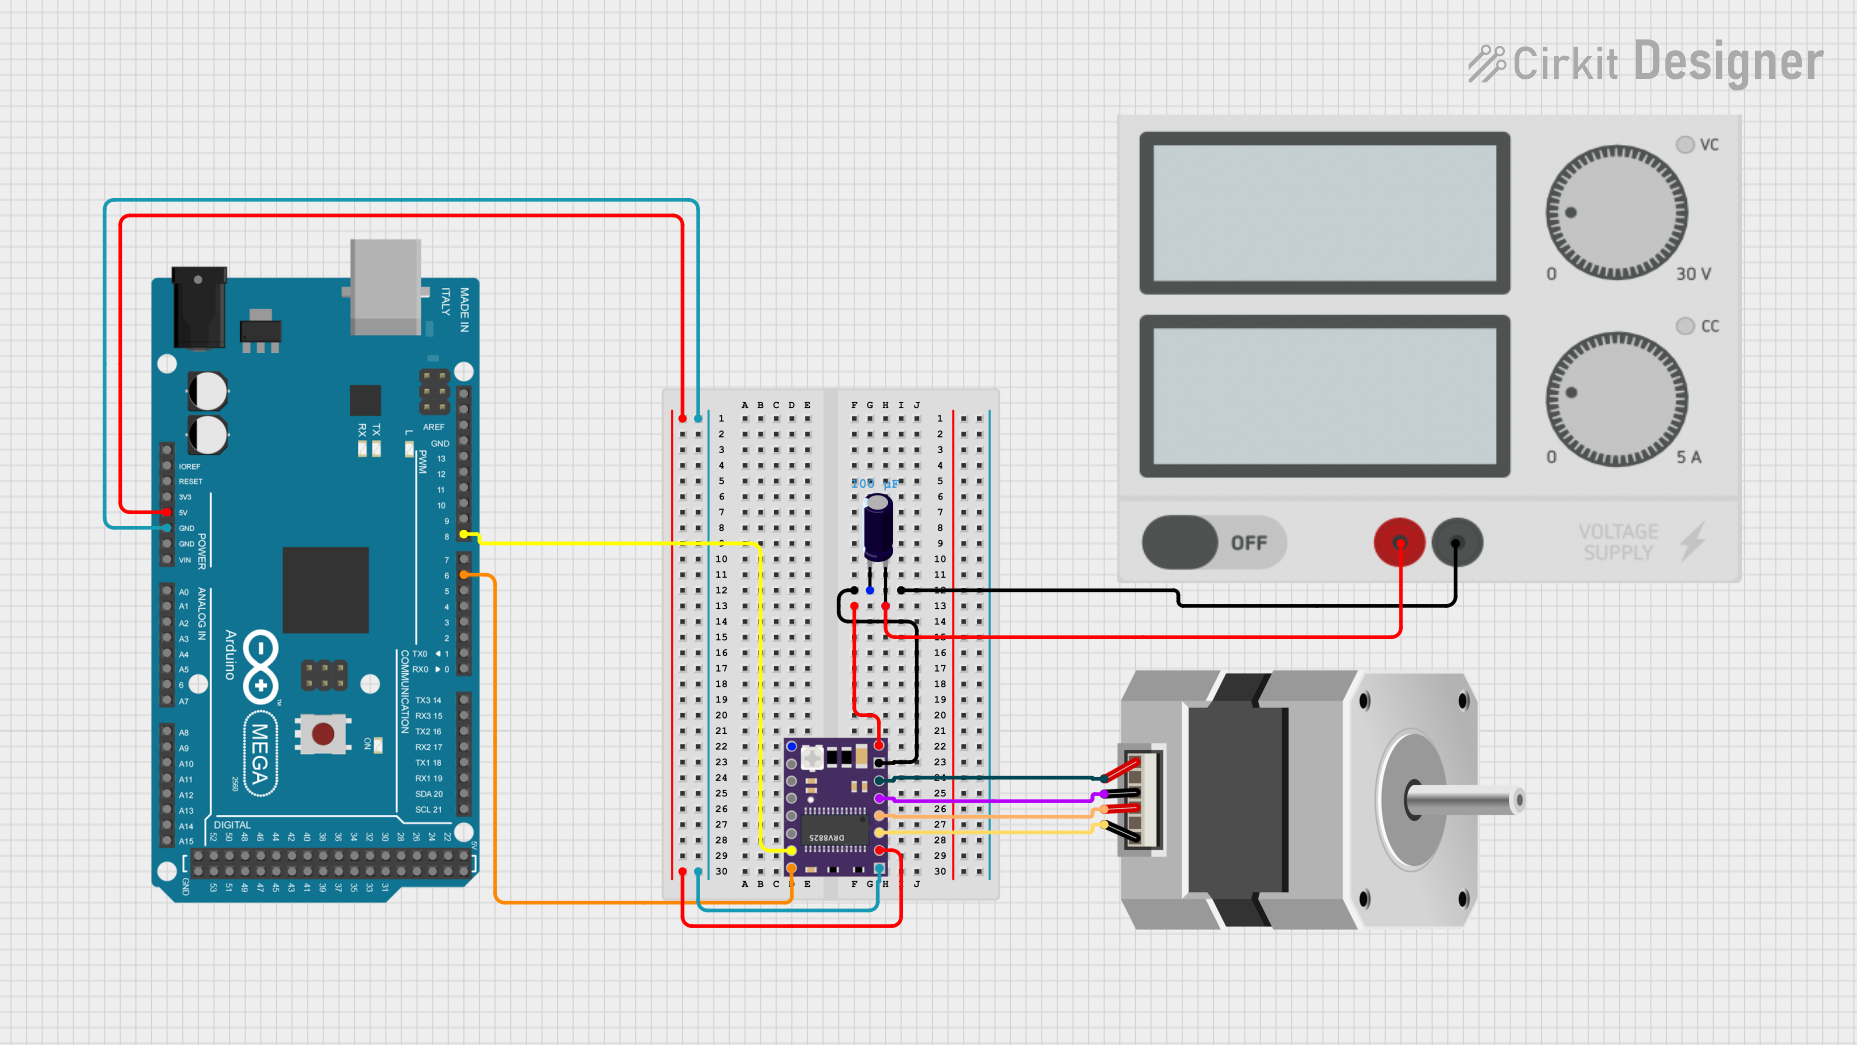
This circuit controls a bipolar stepper motor using an Arduino Mega 2560 and a DRV 8825 stepper motor driver. The Arduino provides control signals to the DRV 8825, which in turn drives the stepper motor, with power supplied by an external power source and stabilized by an electrolytic capacitor.
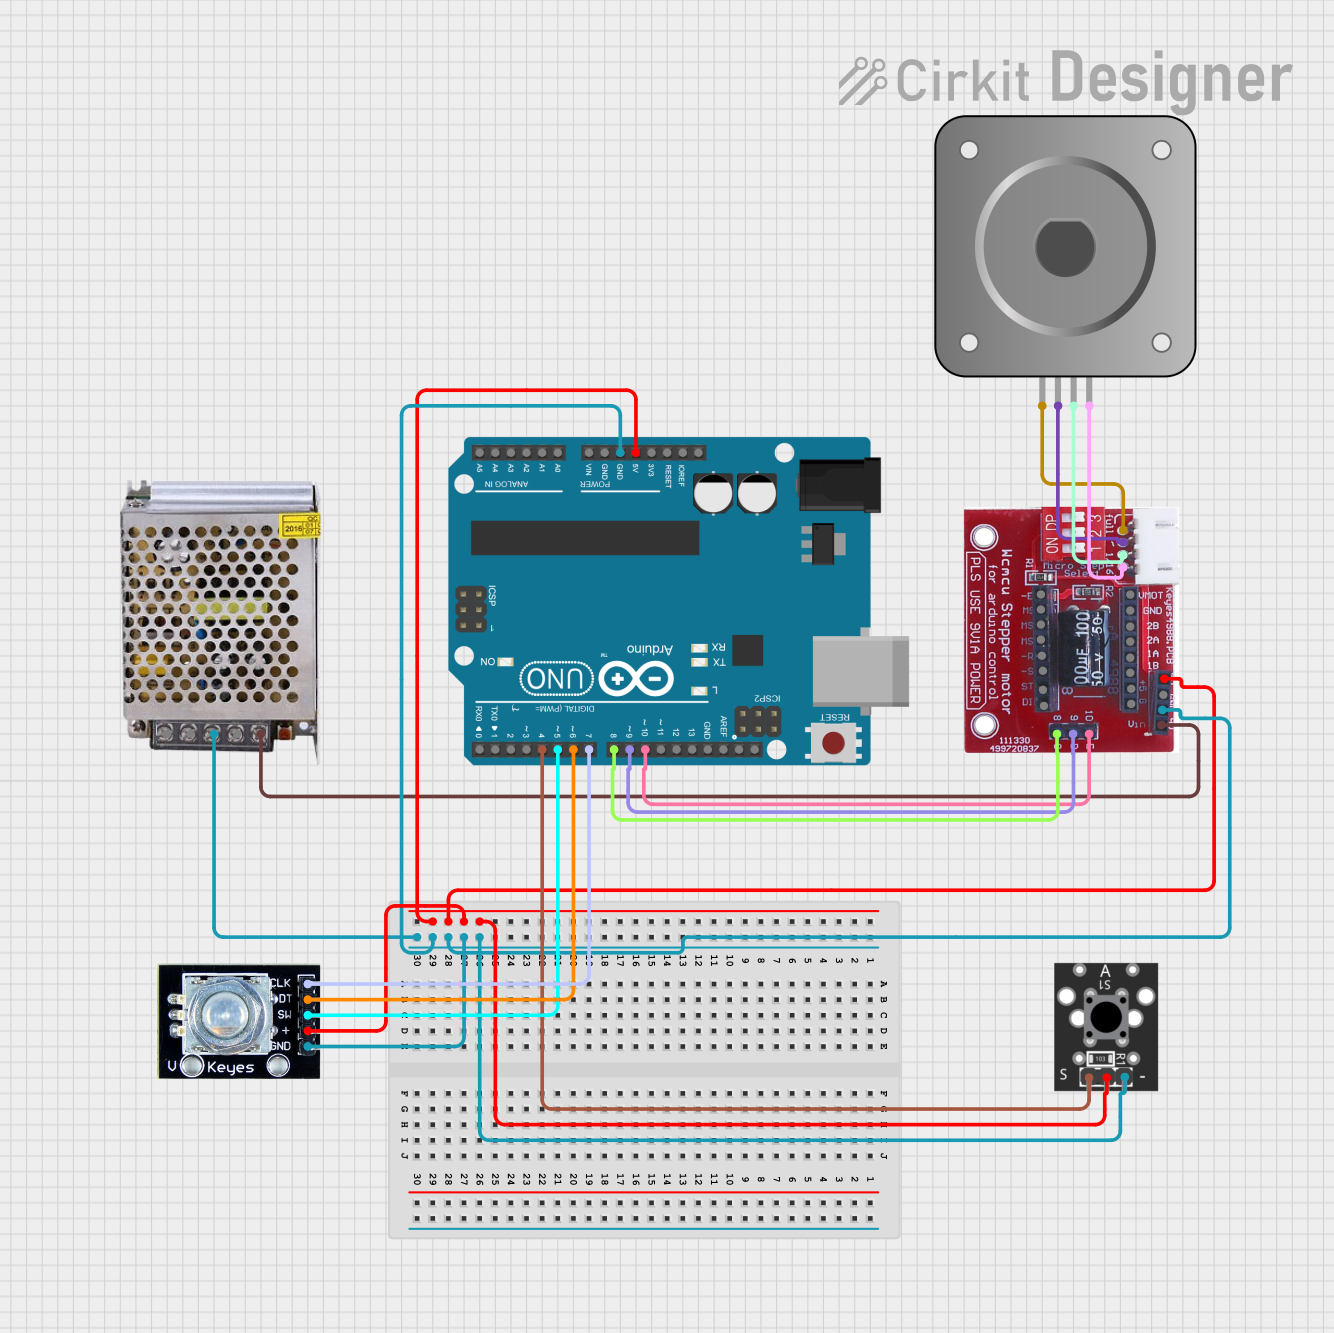
This circuit controls a bipolar stepper motor using an Arduino UNO and a DRV8825 stepper motor driver. The Arduino reads inputs from a rotary encoder and a key switch module to manage the motor's direction and steps, powered by a 12V power supply.
Maximum Current per Phase: 2.5A (with sufficient cooling)
Microstepping Modes: Full, 1/2, 1/4, 1/8, 1/16
Logic Voltage: 3.3V or 5V compatible
Thermal Shutdown Protection: Yes
Overcurrent Protection: Yes
Dimensions: 15mm x 20mm (approx.)
Pin Configuration and Descriptions
The DVR8825 has 16 pins, which are typically arranged as follows:
Pin Name
Description
VMOT
Motor power supply (8.2V to 45V). Connect to the positive terminal of the motor power supply.
GND
Ground for motor power supply. Connect to the negative terminal of the motor power supply.
B2, B1
Outputs for connecting to one coil of the stepper motor.
A1, A2
Outputs for connecting to the other coil of the stepper motor.
VDD
Logic power supply (3.3V or 5V).
GND
Ground for logic power supply.
STEP
Step input. A rising edge on this pin advances the motor by one step.
DIR
Direction input. High or low signal determines the rotation direction.
ENABLE
Enable input. Pull low to enable the driver; pull high to disable it.
MS1, MS2, MS3
Microstepping mode selection pins. Configure these to set the desired microstepping mode.
RESET
Reset input. Pull low to reset the driver.
SLEEP
Sleep mode input. Pull low to put the driver into low-power sleep mode.
FAULT
Fault output. Goes low when a fault condition (e.g., overcurrent) occurs.
Microstepping Mode Configuration
The microstepping mode is determined by the states of the MS1, MS2, and MS3 pins:
MS1
MS2
MS3
Microstepping Mode
Low
Low
Low
Full Step
High
Low
Low
Half Step
Low
High
Low
Quarter Step
High
High
Low
Eighth Step
High
High
High
Sixteenth Step
Usage Instructions
How to Use the DVR8825 in a Circuit
Power Supply: Connect the motor power supply (8.2V to 45V) to the VMOT and GND pins. Add a decoupling capacitor (e.g., 100µF) across these pins to reduce voltage spikes.
Motor Connection: Connect the stepper motor coils to the A1, A2, B1, and B2 pins. Ensure the correct pairing of the motor wires.
Logic Power: Connect the VDD pin to the logic voltage (3.3V or 5V) and the GND pin to the logic ground.
Control Signals: Connect the STEP and DIR pins to your microcontroller or control circuit. Use the ENABLE pin to enable or disable the driver as needed.
Microstepping Configuration: Set the MS1, MS2, and MS3 pins to configure the desired microstepping mode.
Current Adjustment: Use the onboard potentiometer to adjust the current limit. Start with a low setting and gradually increase it while monitoring the motor's performance and temperature.
Important Considerations and Best Practices
Heat Dissipation: The DVR8825 can handle up to 2.5A per phase with adequate cooling. Use a heatsink or active cooling to prevent overheating.
Current Limiting: Set the current limit to match your stepper motor's rated current to avoid damaging the motor or driver.
Decoupling Capacitors: Always use a capacitor (e.g., 100µF) across the VMOT and GND pins to protect the driver from voltage spikes.
Sleep Mode: Use the SLEEP pin to reduce power consumption when the driver is not in use.
Fault Handling: Monitor the FAULT pin to detect and respond to fault conditions.
Example Code for Arduino UNO
Below is an example of how to control a stepper motor using the DVR8825 and an Arduino UNO:
// Define pin connections
#define STEP_PIN 3  // Connect to the STEP pin of the DVR8825
#define DIR_PIN 4   // Connect to the DIR pin of the DVR8825

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output

  digitalWrite(DIR_PIN, HIGH); // Set initial direction (HIGH = one direction)
}

void loop() {
  // Generate a step pulse
  digitalWrite(STEP_PIN, HIGH); // Set STEP pin HIGH
  delayMicroseconds(500);       // Wait for 500 microseconds
  digitalWrite(STEP_PIN, LOW);  // Set STEP pin LOW
  delayMicroseconds(500);       // Wait for 500 microseconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Check the power supply connections to VMOT and GND.
Verify the STEP and DIR signals from the microcontroller.
Ensure the motor coils are correctly connected to A1, A2, B1, and B2.
Overheating:
Ensure the current limit is set correctly using the potentiometer.
Add a heatsink or active cooling to the driver.
Driver Not Enabling:
Check the ENABLE pin. It should be pulled low to enable the driver.
Verify the logic power supply (VDD and GND).
Fault Condition (FAULT Pin Low):
Check for overcurrent or thermal shutdown conditions.
Reduce the current limit or improve cooling.
Motor Vibrating but Not Rotating:
Verify the microstepping mode configuration (MS1, MS2, MS3).
Ensure the motor coils are correctly paired.
FAQs
Can I use the DVR8825 with a 12V power supply?
Yes, the DVR8825 supports motor power supplies from 8.2V to 45V, so 12V is within the acceptable range.
How do I set the current limit?
Use the onboard potentiometer. Measure the VREF voltage and calculate the current limit using the formula: Current Limit = VREF × 2 (for DVR8825).
What happens if I exceed the current limit?
The driver will enter overcurrent protection mode, and the FAULT pin will go low. Reduce the current limit or improve cooling to resolve this.
Can I use the DVR8825 with a 3.3V microcontroller?
Yes, the DVR8825 is compatible with both 3.3V and 5V logic levels.

 Open Project in Cirkit Designer