Cirkit Designer LogoCirkit DesignerYour all-in-one circuit design IDE Launch Cirkit Designer App

How to Use Servo: Examples, Pinouts, and Specs

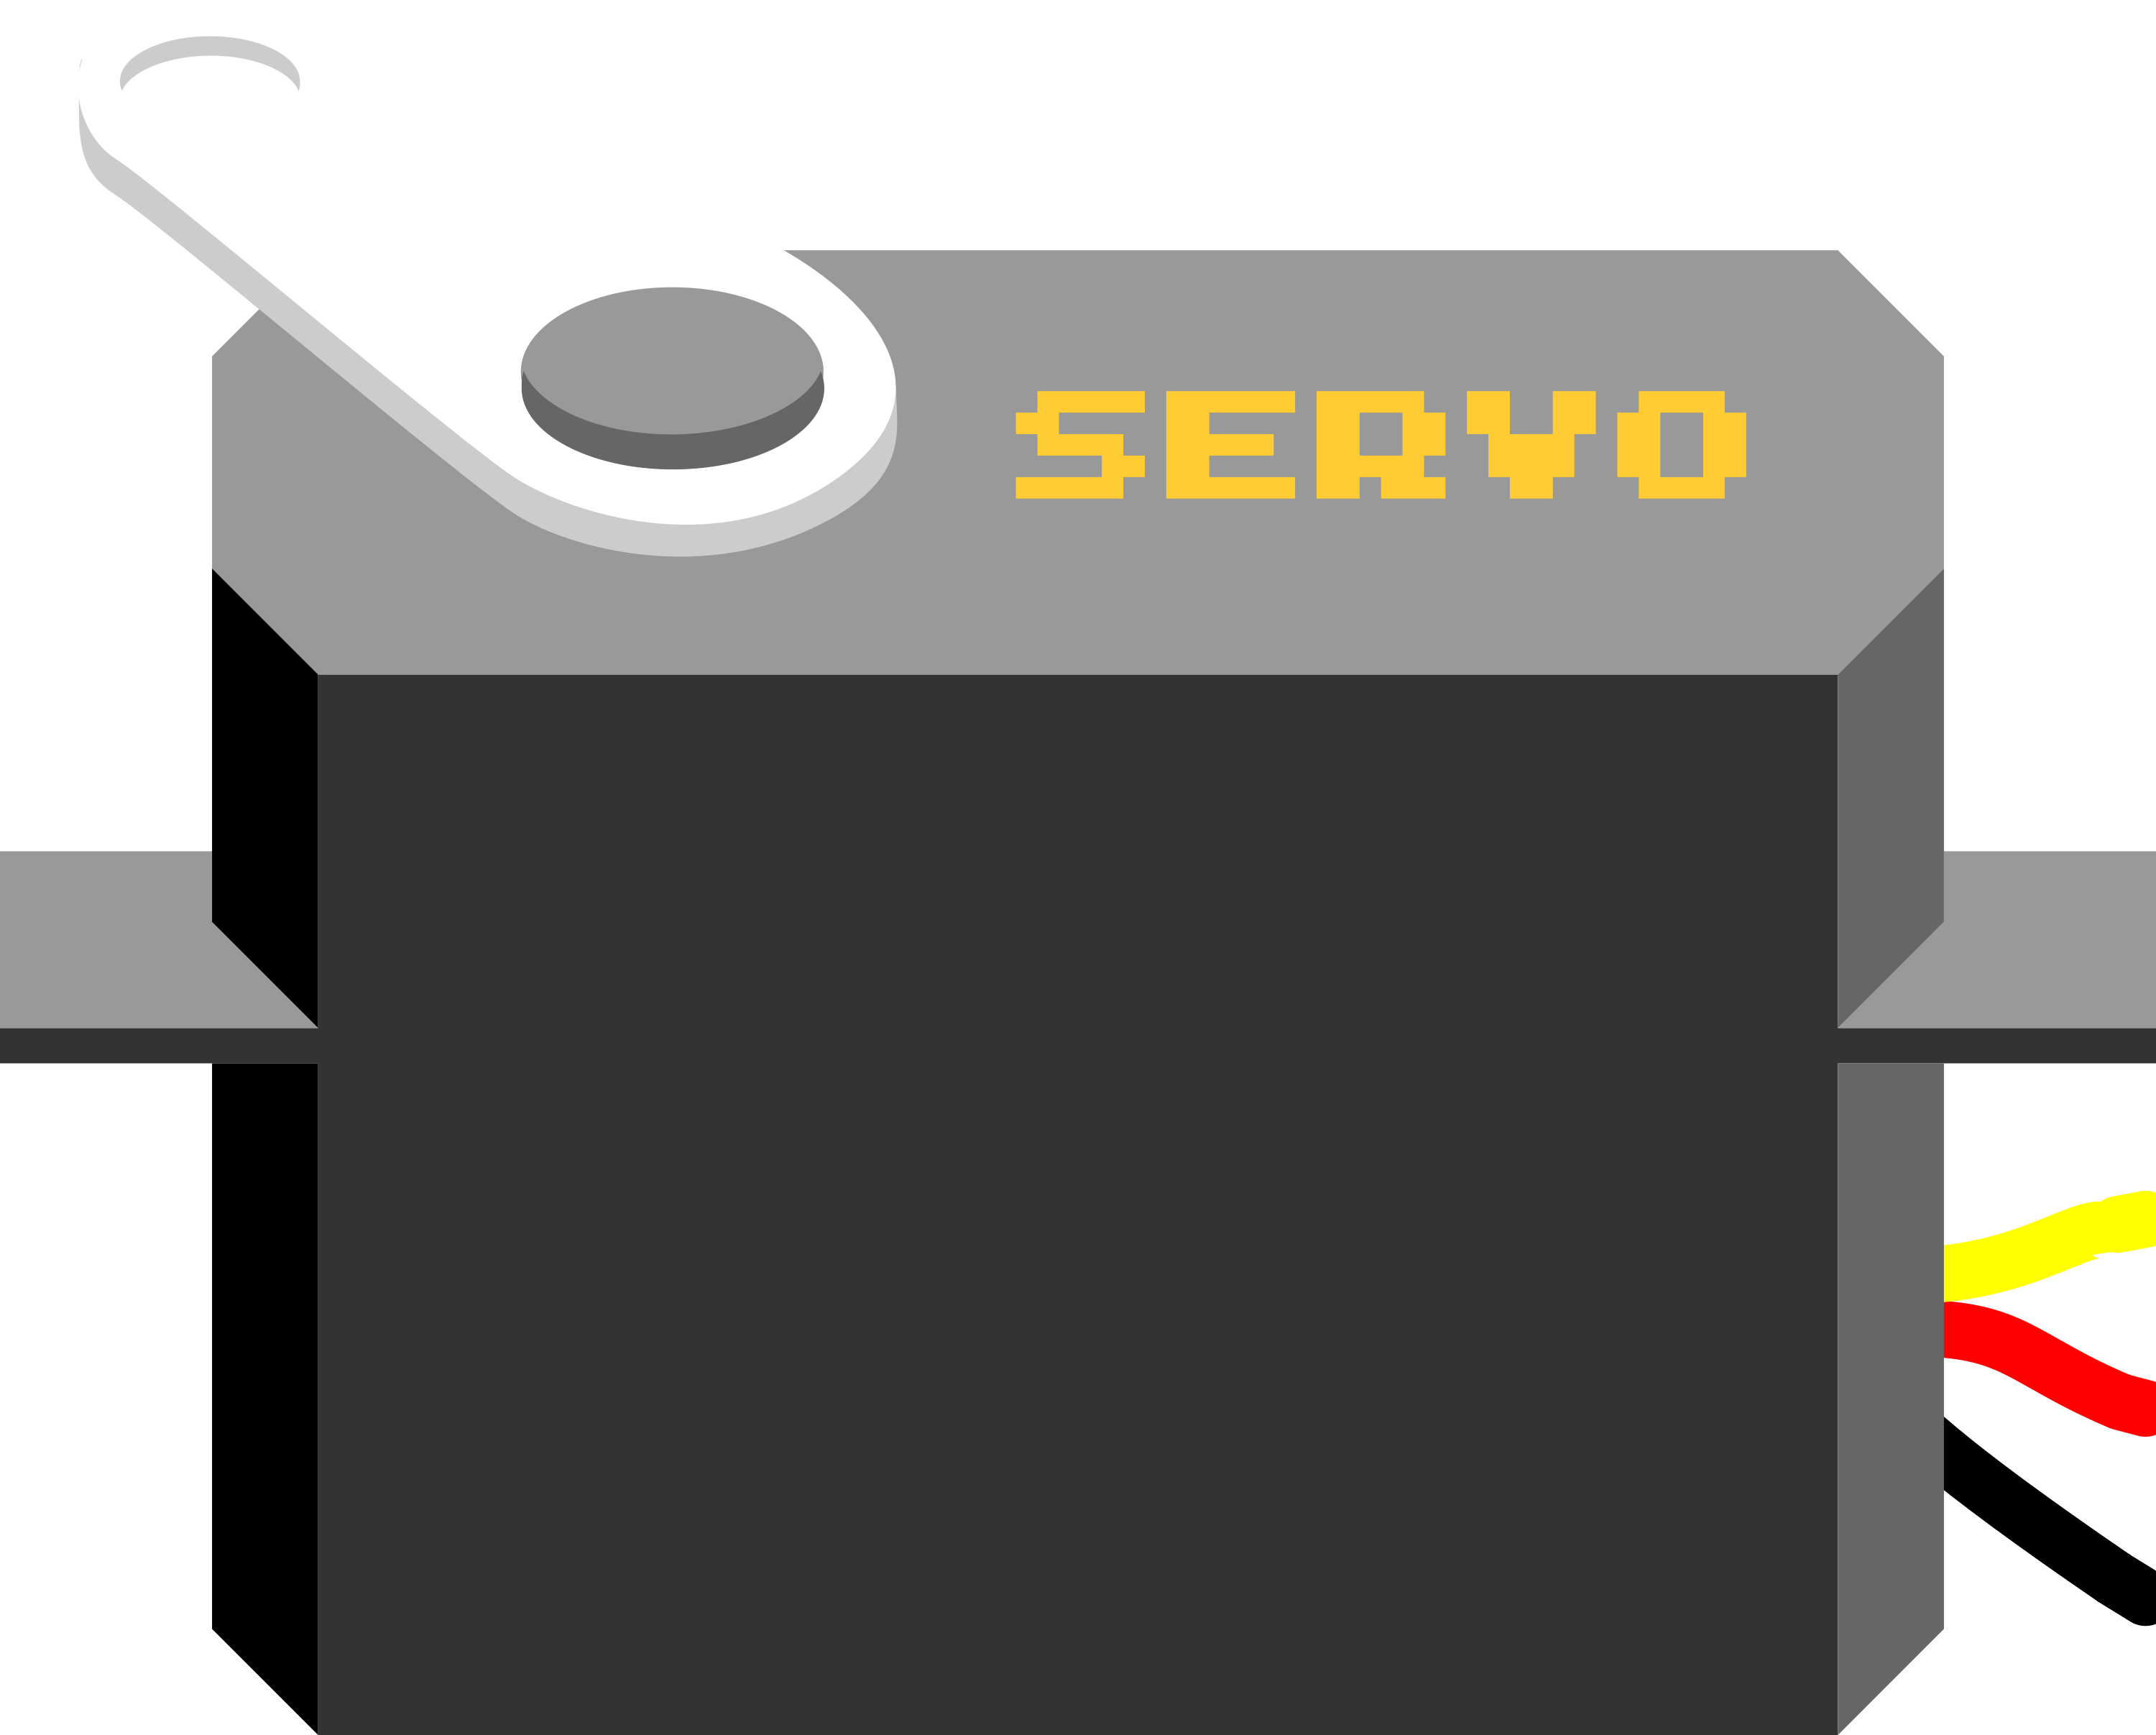
Image of ServoDesign with Servo in Cirkit Designer

Introduction

A servo is a rotary actuator that allows for precise control of angular position, velocity, and acceleration. It consists of a motor coupled to a sensor for position feedback, along with a control circuit. Servos are widely used in robotics, automation, remote-controlled vehicles, and other applications requiring precise movement and positioning.

Explore Projects Built with Servo

Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
Image of Arduino Mega 2560 Controlled Multi-Servo Random Positioning System: A project utilizing Servo in a practical application

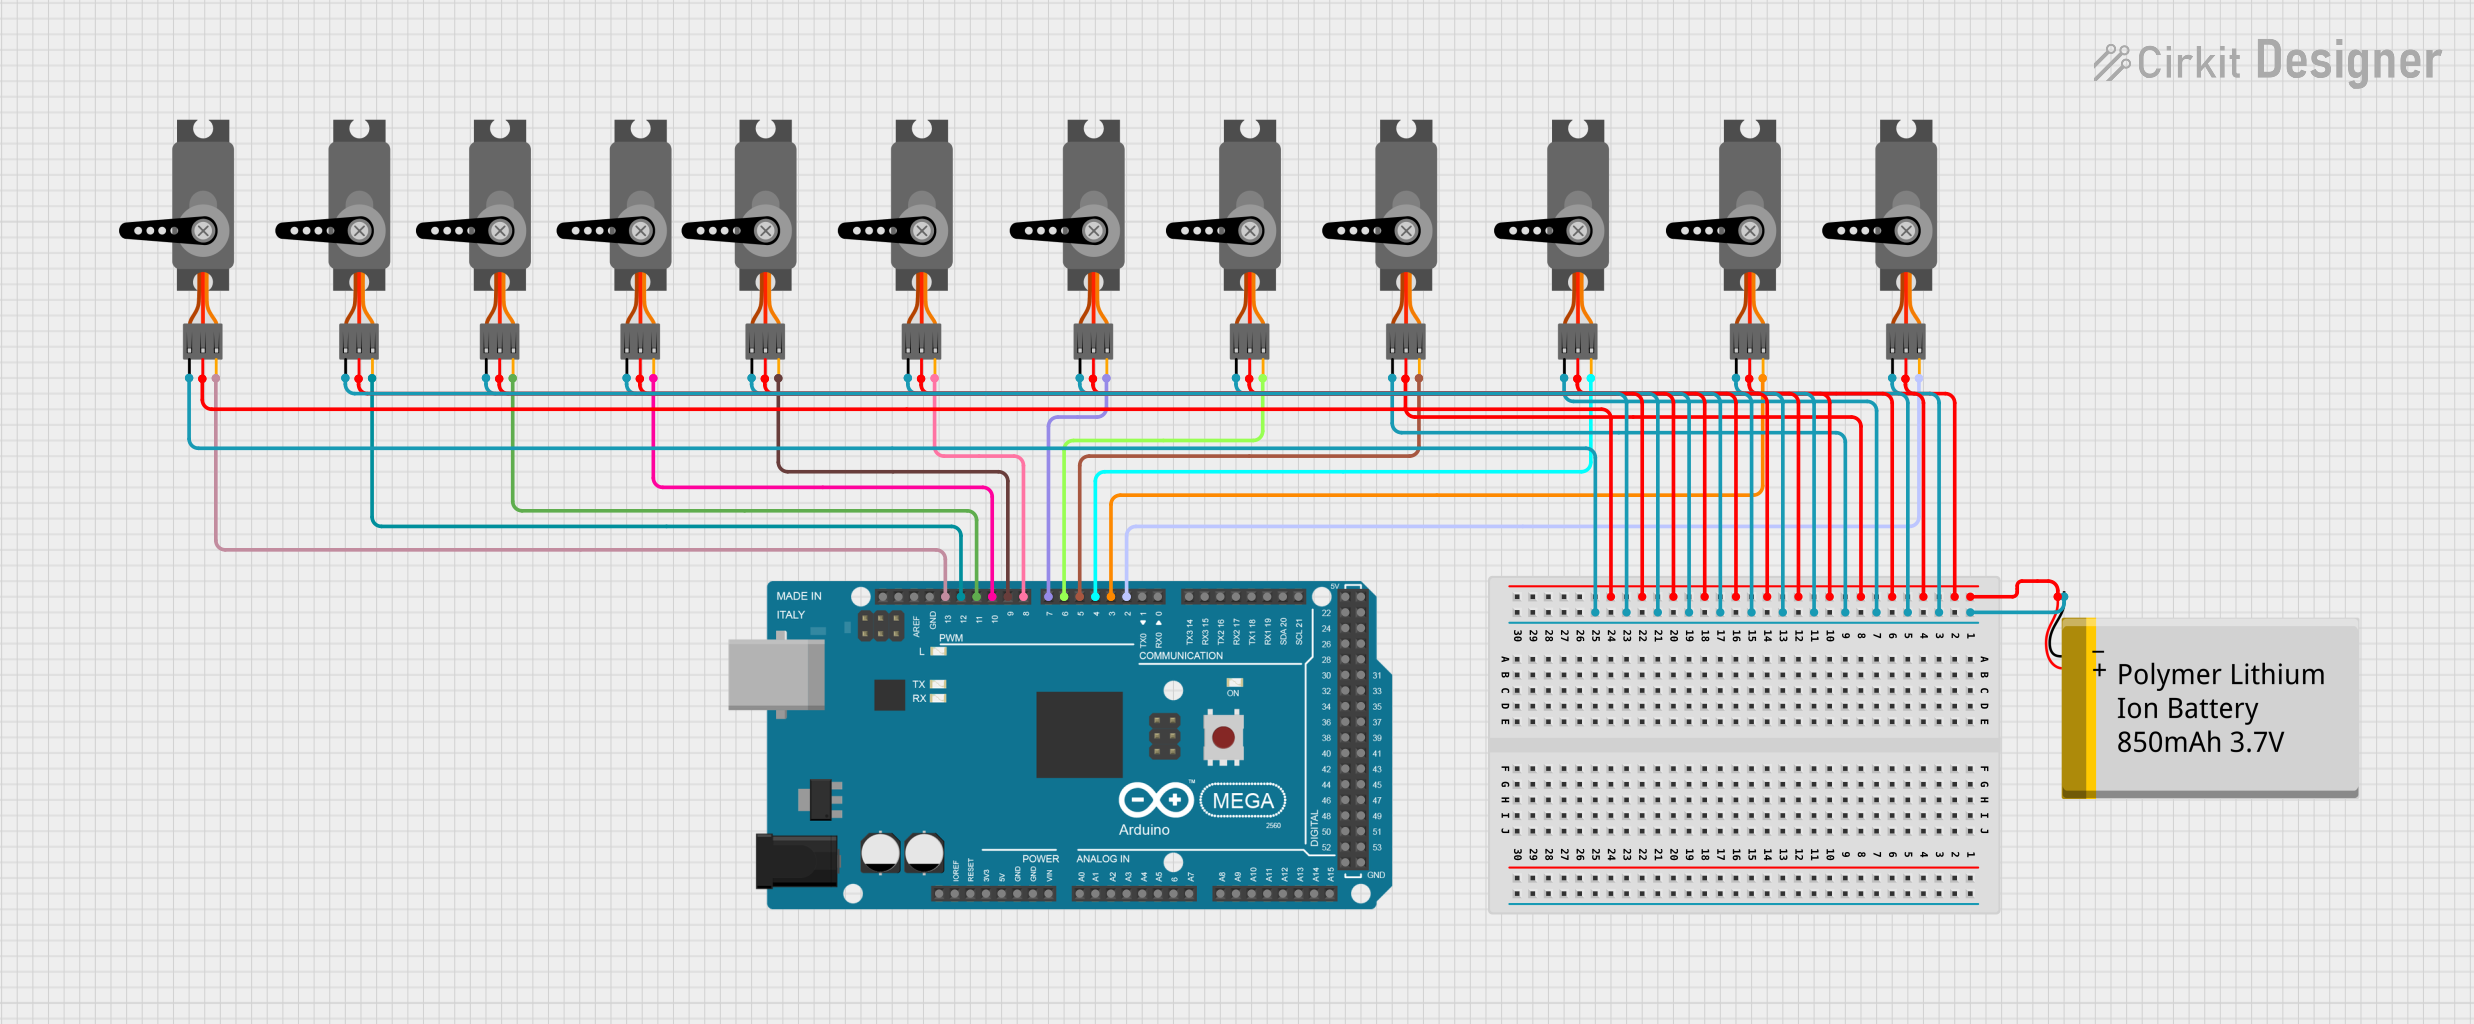
Arduino Mega 2560 Controlled Multi-Servo Random Positioning System

This circuit consists of an Arduino Mega 2560 microcontroller connected to twelve servo motors, each individually controlled by a distinct PWM pin on the Arduino. The servos are powered by a single Polymer Lithium Ion Battery, with all servos sharing a common power (VCC) and ground (GND) connection. The embedded code on the Arduino is designed to randomly position each servo within a 0 to 180-degree range, with a random delay between movements, demonstrating a multi-servo control system possibly for applications like robotics or animatronics.

Open Project in Cirkit Designer
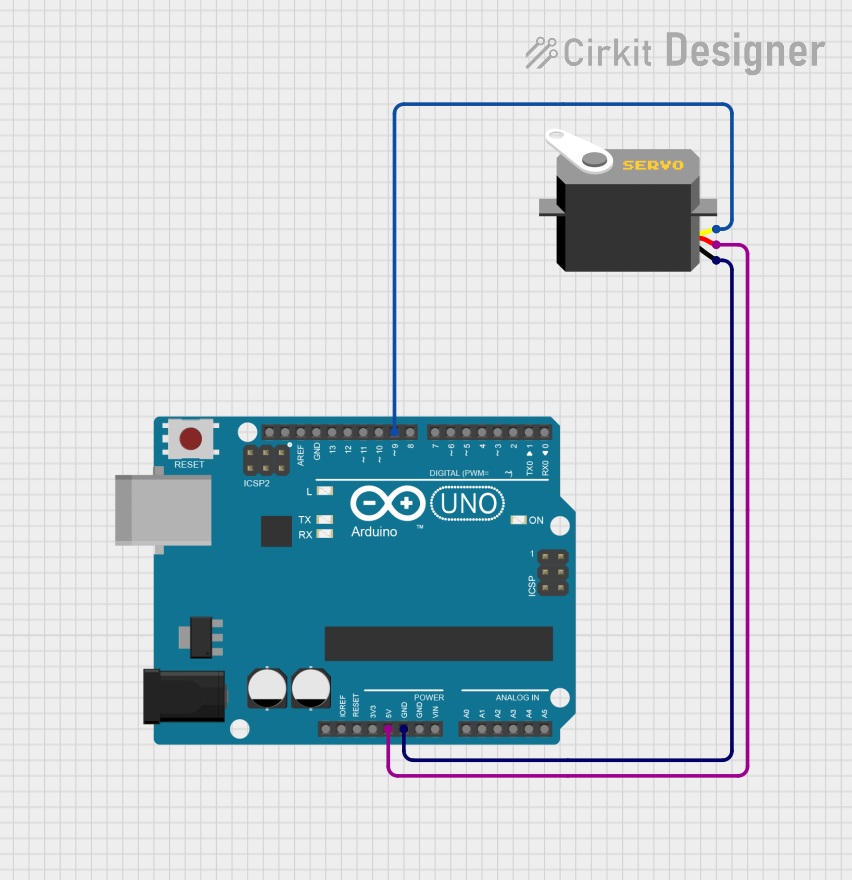
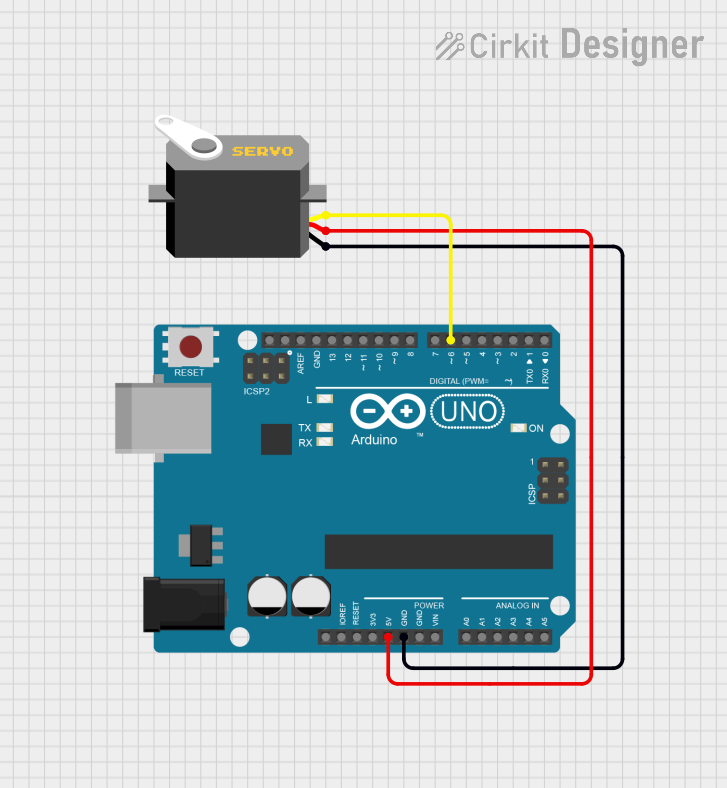
Image of Arduino UNO Servo Motor Controller: A project utilizing Servo in a practical application
Arduino UNO Servo Motor Controller

This circuit consists of an Arduino UNO microcontroller connected to a servo motor. The Arduino provides power (5V and GND) to the servo and controls its position through a pulse signal on pin D9. The embedded code on the Arduino is programmed to smoothly move the servo between 0 and 180 degrees, creating a sweeping motion.

Open Project in Cirkit Designer
Image of Arduino UNO Controlled Servo Motor: A project utilizing Servo in a practical application
Arduino UNO Controlled Servo Motor

This circuit consists of an Arduino UNO microcontroller connected to a servo motor. The Arduino provides power (5V) and ground connections to the servo, as well as a control signal through one of its digital pins (D6). The embedded code on the Arduino is set up to control the servo's position, sending it to a fixed angle upon each loop iteration.

Open Project in Cirkit Designer
Image of Arduino-Controlled Multi-Servo System: A project utilizing Servo in a practical application
Arduino-Controlled Multi-Servo System

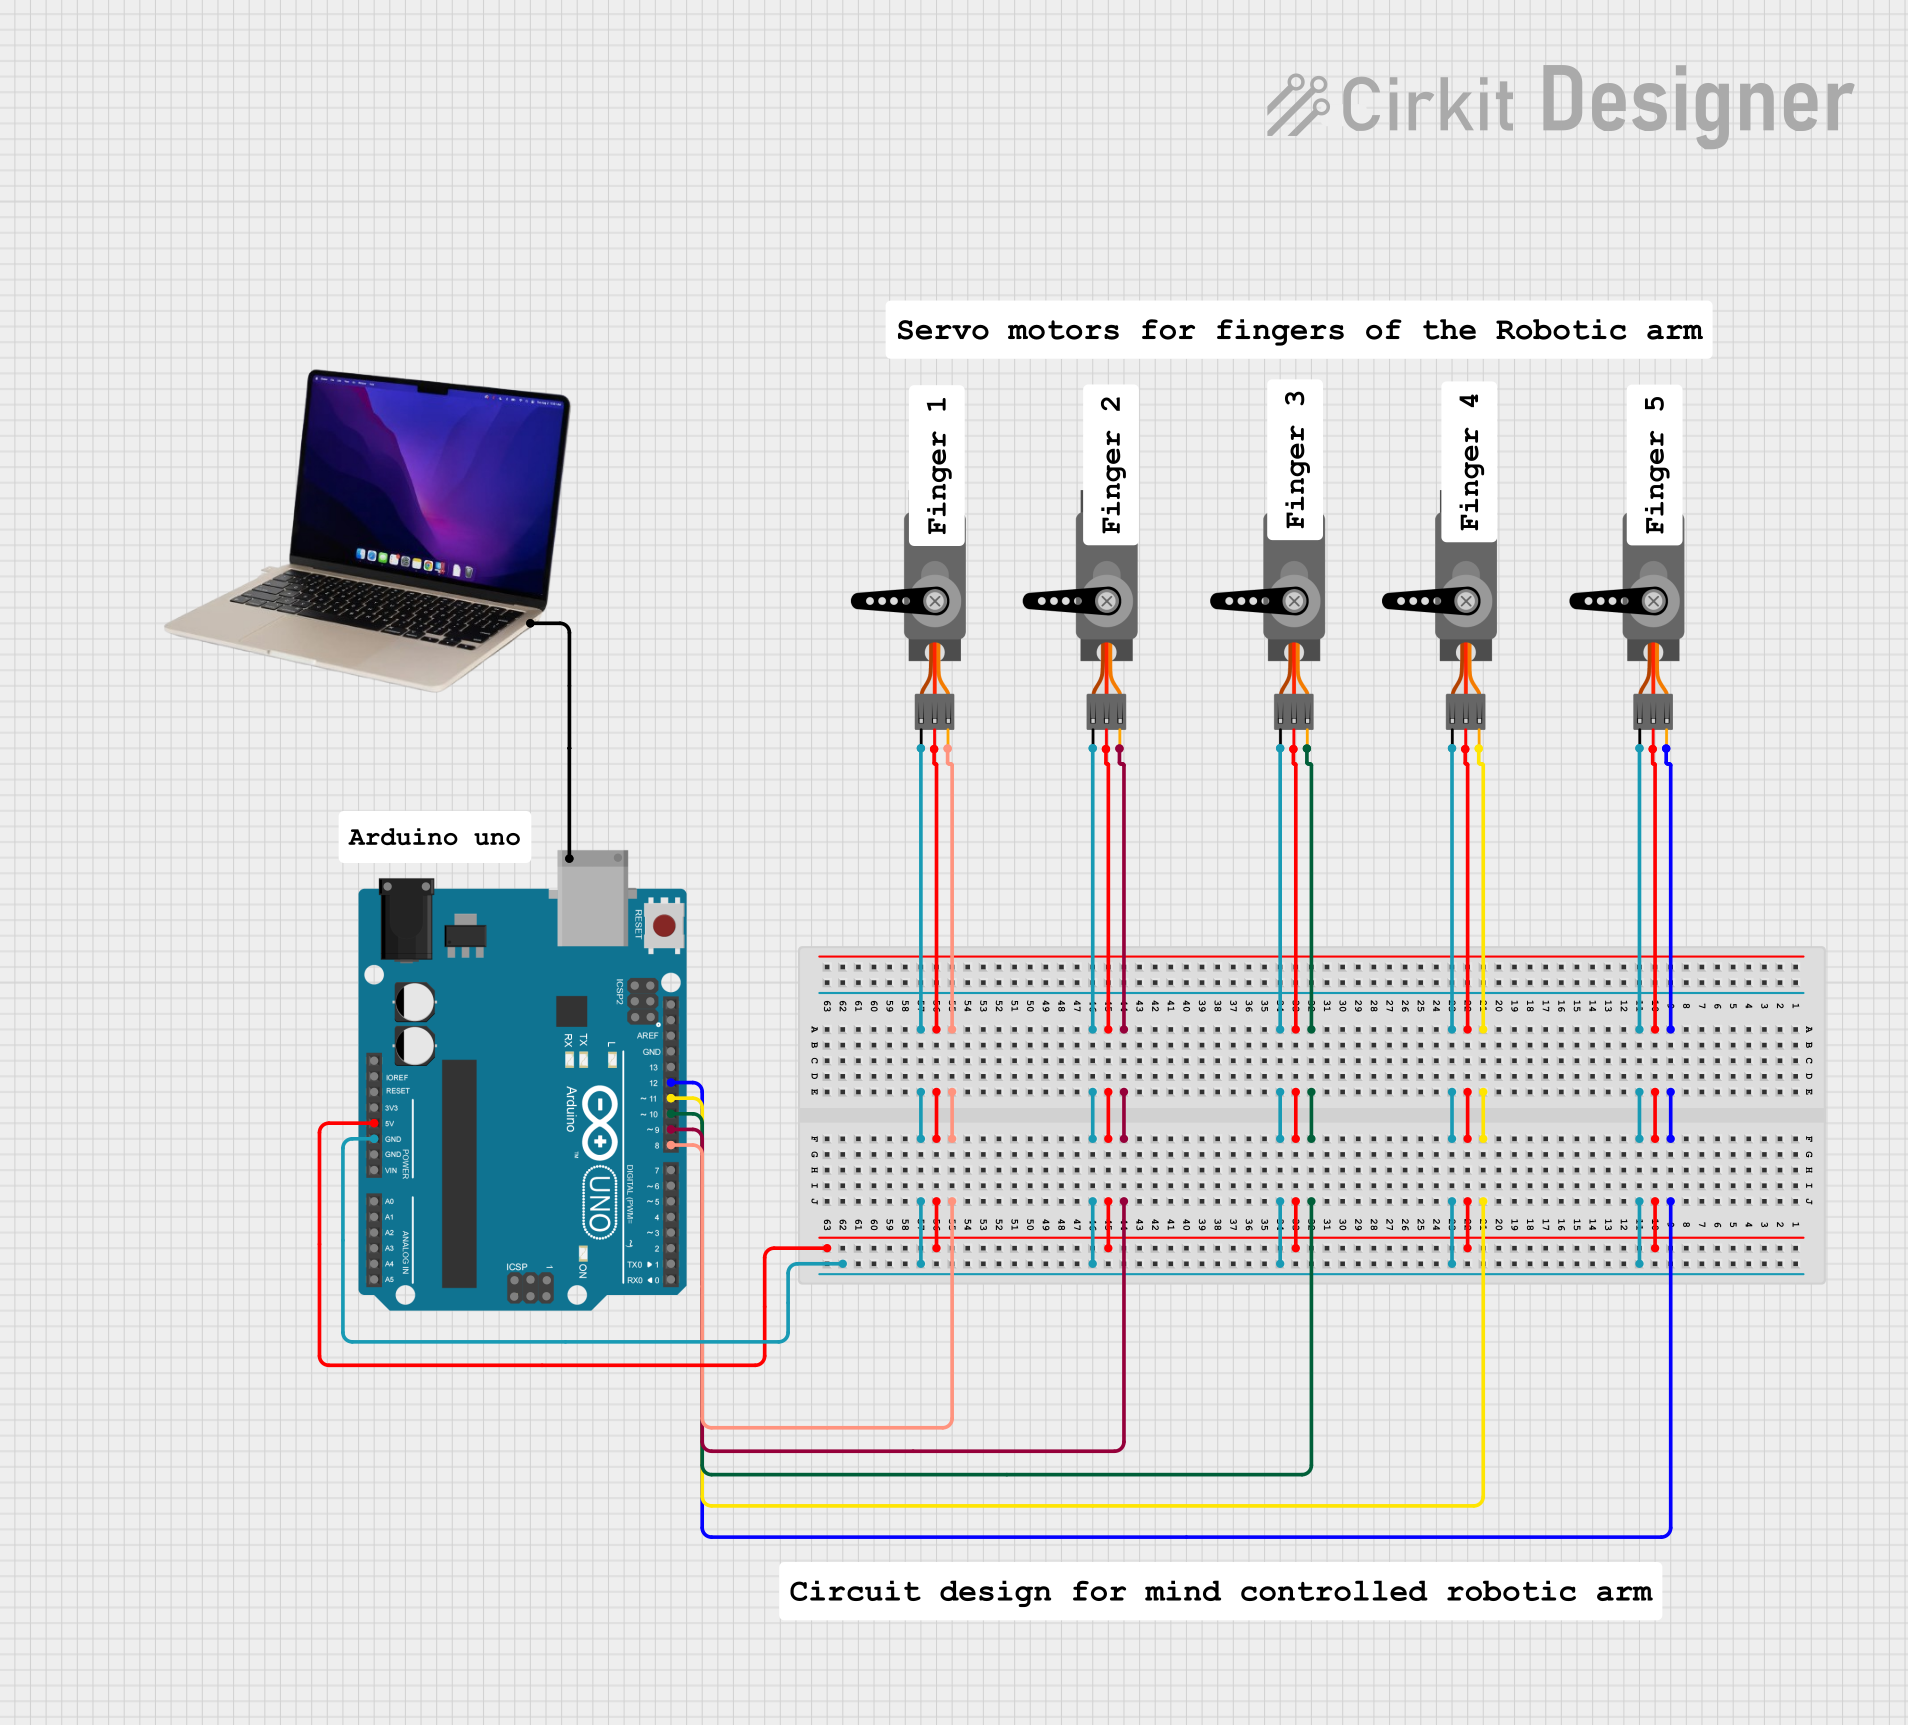
This circuit consists of an Arduino UNO microcontroller connected to five servo motors. The servos are powered by the Arduino's 5V output and share a common ground. Each servo's PWM control pin is individually connected to a digital pin on the Arduino (D8, D9, D10, D11, D12), allowing for independent control of each servo's position. The Arduino is also connected to a laptop via USB for programming and power.

Open Project in Cirkit Designer

Common Applications:

Technical Specifications

Below are the general technical specifications for a standard hobby servo. Note that specifications may vary depending on the specific model and manufacturer.

Key Technical Details:

Pin Configuration:

The servo typically has a 3-pin connector with the following pinout:

Pin Number Name Description
1 Signal Receives PWM signal for position control
2 VCC Power supply (4.8V to 6V)
3 GND Ground connection

Usage Instructions

How to Use a Servo in a Circuit:

  1. Power the Servo: Connect the VCC pin to a 5V or 6V power source and the GND pin to the ground of your circuit.
  2. Control Signal: Connect the Signal pin to a microcontroller (e.g., Arduino) or a PWM signal generator.
  3. PWM Signal: Send a PWM signal to the Signal pin to control the servo's position. The pulse width determines the angle:
    • A pulse width of ~1ms corresponds to 0°.
    • A pulse width of ~1.5ms corresponds to 90° (center position).
    • A pulse width of ~2ms corresponds to 180°.

Important Considerations:

Example: Connecting a Servo to an Arduino UNO

Below is an example of how to control a servo using an Arduino UNO:

#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object

void setup() {
  myServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000);      // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000);       // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000);        // Wait for 1 second
}

Notes:

Troubleshooting and FAQs

Common Issues and Solutions:

  1. Servo Not Moving:

    • Cause: Incorrect wiring or insufficient power supply.
    • Solution: Double-check the connections and ensure the power supply meets the servo's requirements.
  2. Jittery Movements:

    • Cause: Unstable PWM signal or electrical noise.
    • Solution: Use a decoupling capacitor across the power supply and ensure the PWM signal is stable.
  3. Overheating:

    • Cause: Overloading the servo or running it continuously at high torque.
    • Solution: Reduce the load on the servo or use a higher-torque model.
  4. Limited Range of Motion:

    • Cause: Mechanical obstruction or incorrect PWM signal.
    • Solution: Check for physical obstructions and verify the PWM signal's pulse width.

FAQs:

By following this documentation, you can effectively integrate and troubleshoot a servo in your projects!