A servo is a rotary actuator that allows for precise control of angular position, velocity, and acceleration. It consists of a motor coupled to a sensor for position feedback, along with a control circuit. Servos are widely used in robotics, automation, remote-controlled vehicles, and industrial machinery due to their ability to provide accurate and repeatable motion.
Explore Projects Built with SERVO
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
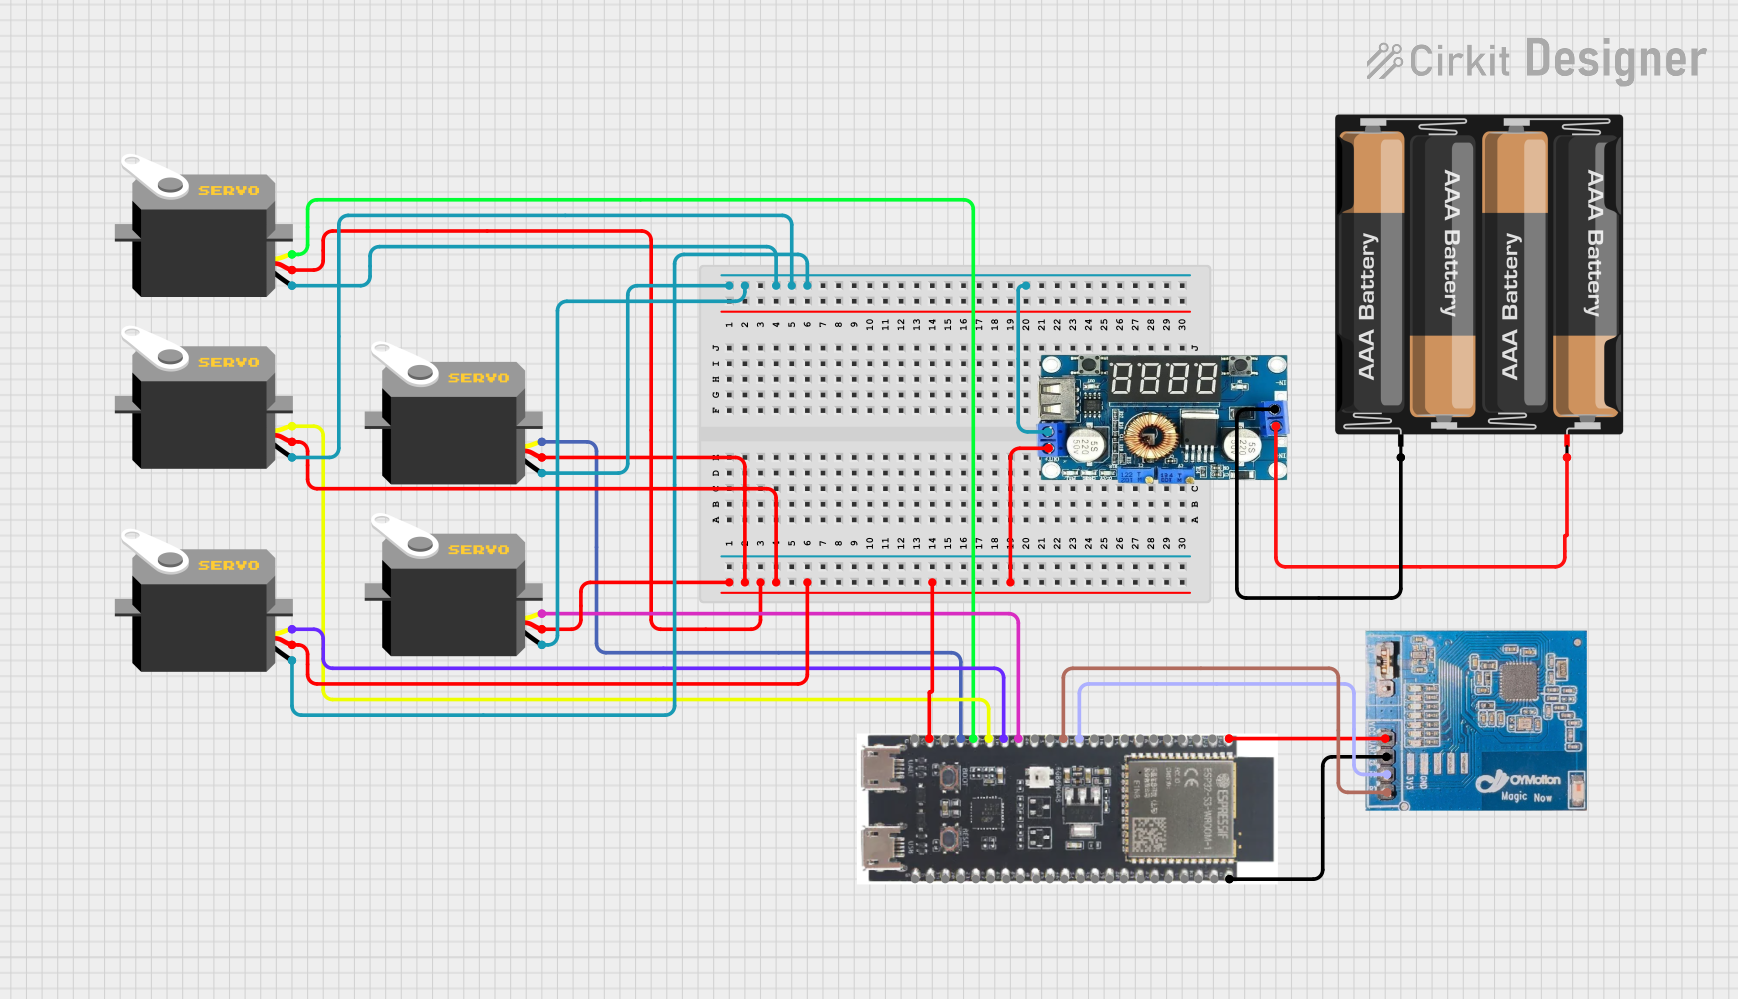
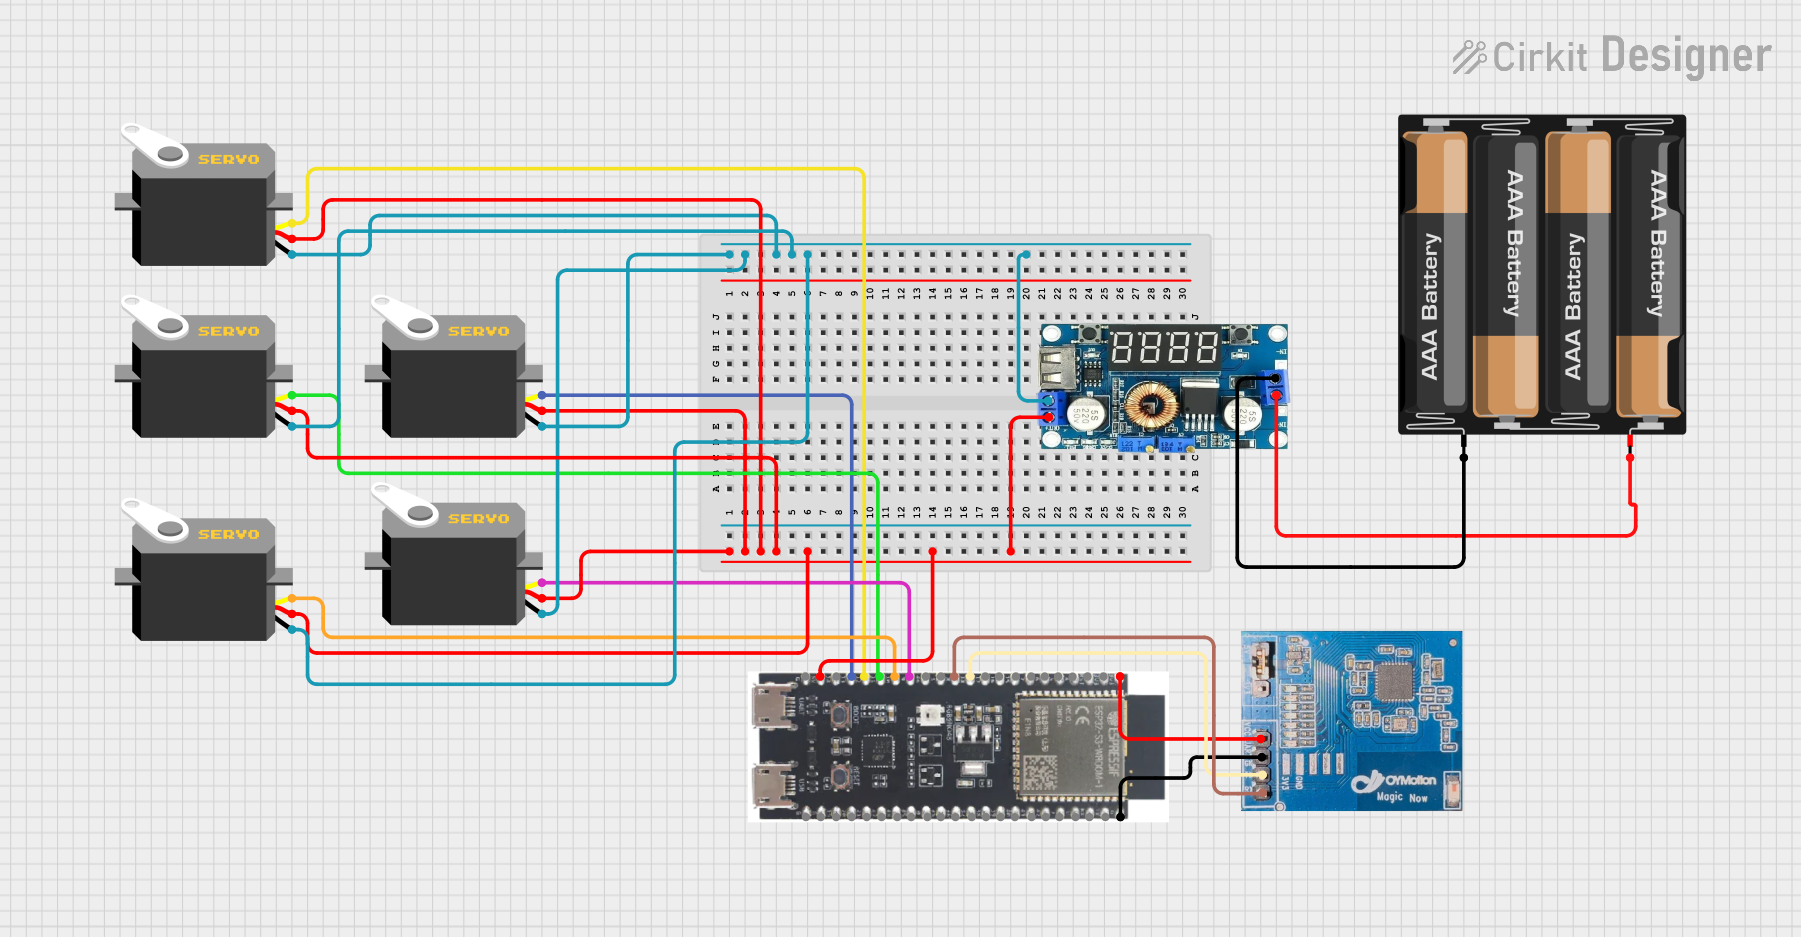
This circuit is a servo control system powered by a 4 x AAA battery pack, regulated by a step-down DC regulator. An ESP32-S3 microcontroller controls five servos and communicates with a gForceJoint UART sensor, enabling precise servo movements based on sensor inputs.
This circuit is designed to control five servos using an ESP32-S3 microcontroller, powered by a 4 x AAA battery pack through a step-down regulator. The ESP32-S3 also interfaces with a gForceJoint UART 111 sensor for additional input.
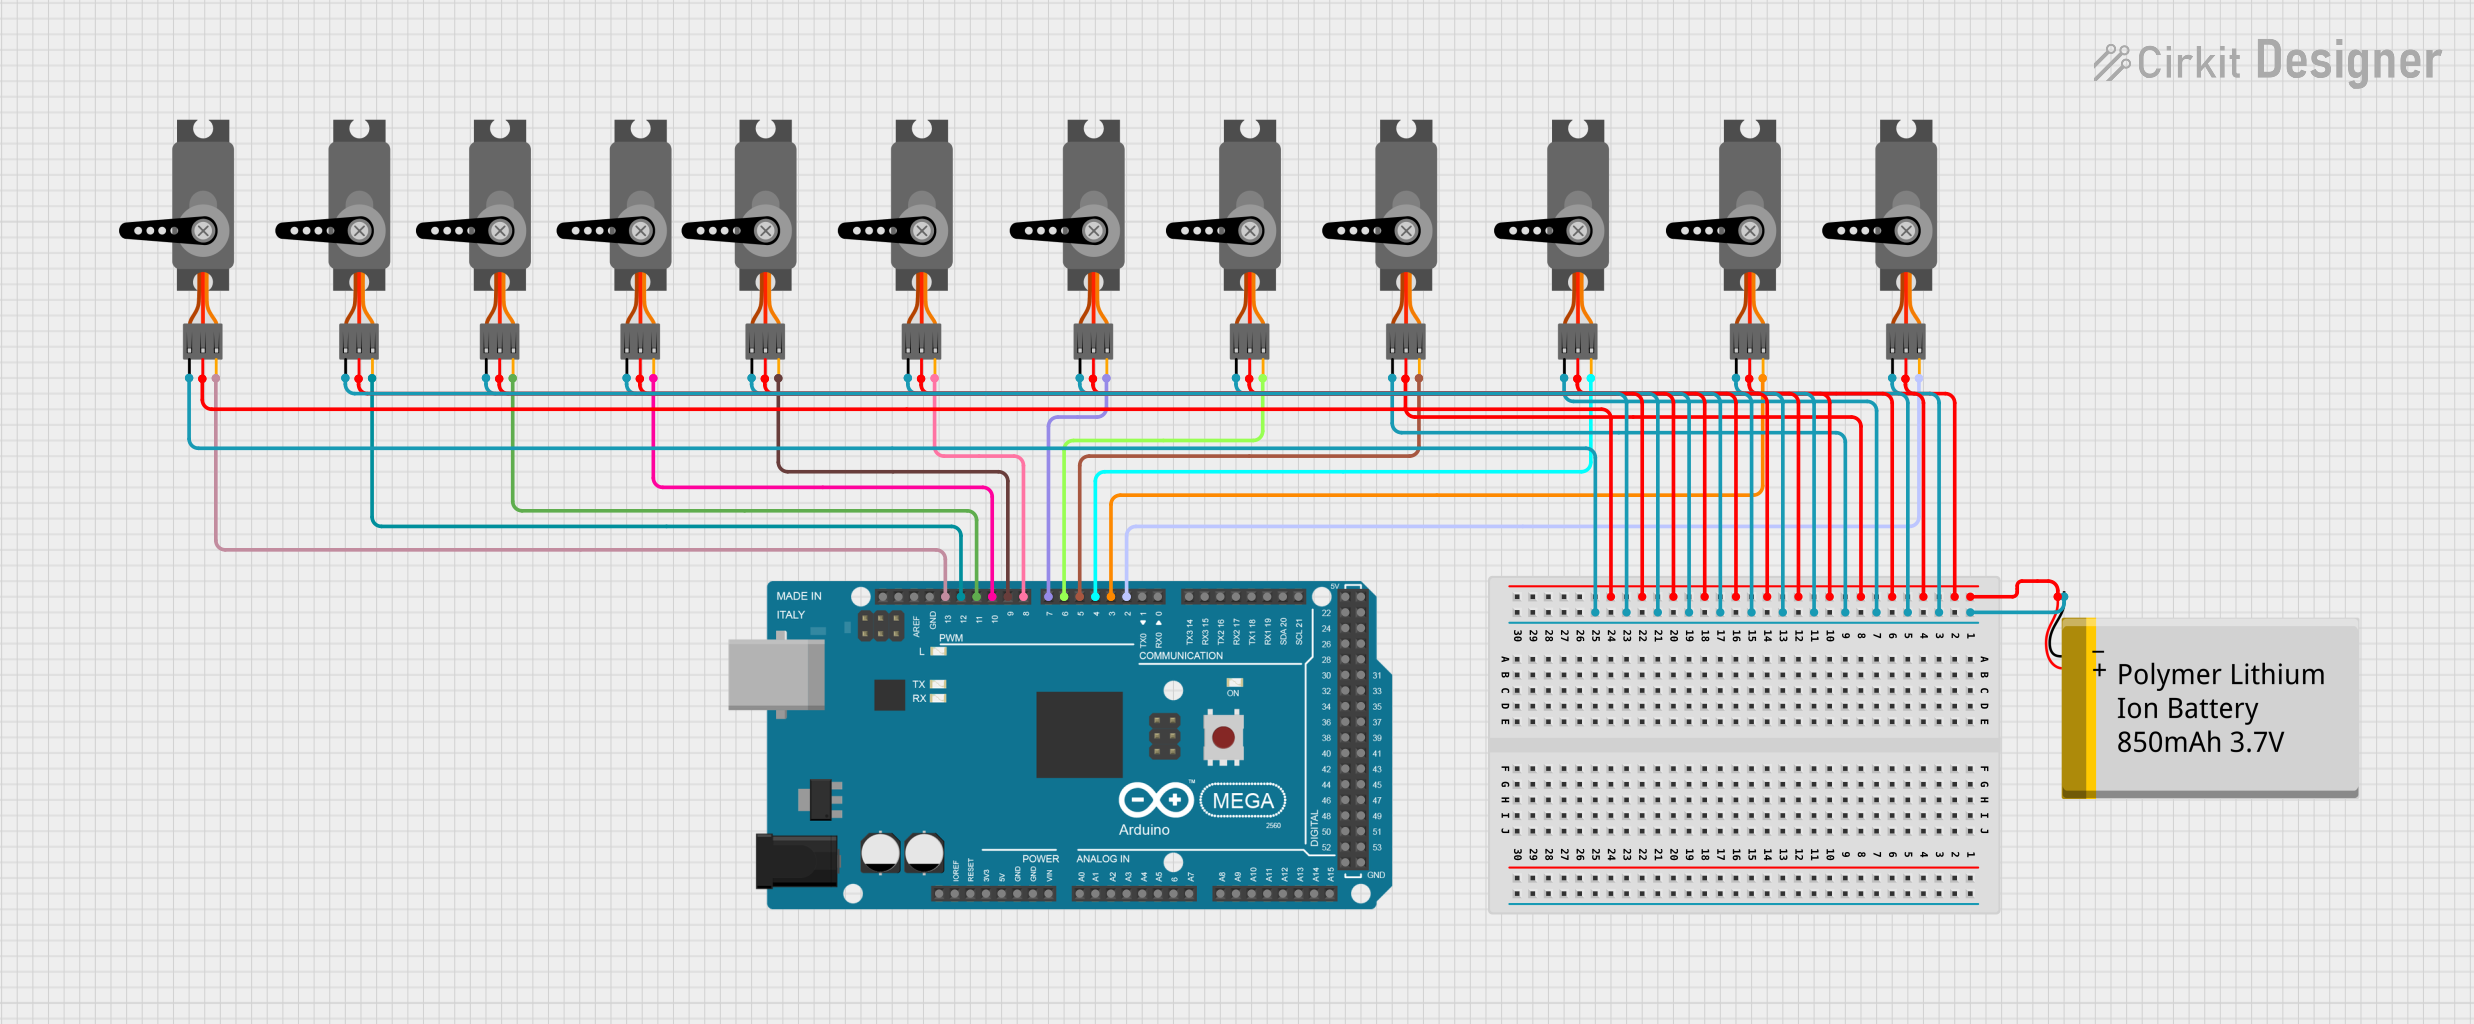
This circuit consists of an Arduino Mega 2560 microcontroller connected to twelve servo motors, each individually controlled by a distinct PWM pin on the Arduino. The servos are powered by a single Polymer Lithium Ion Battery, with all servos sharing a common power (VCC) and ground (GND) connection. The embedded code on the Arduino is designed to randomly position each servo within a 0 to 180-degree range, with a random delay between movements, demonstrating a multi-servo control system possibly for applications like robotics or animatronics.
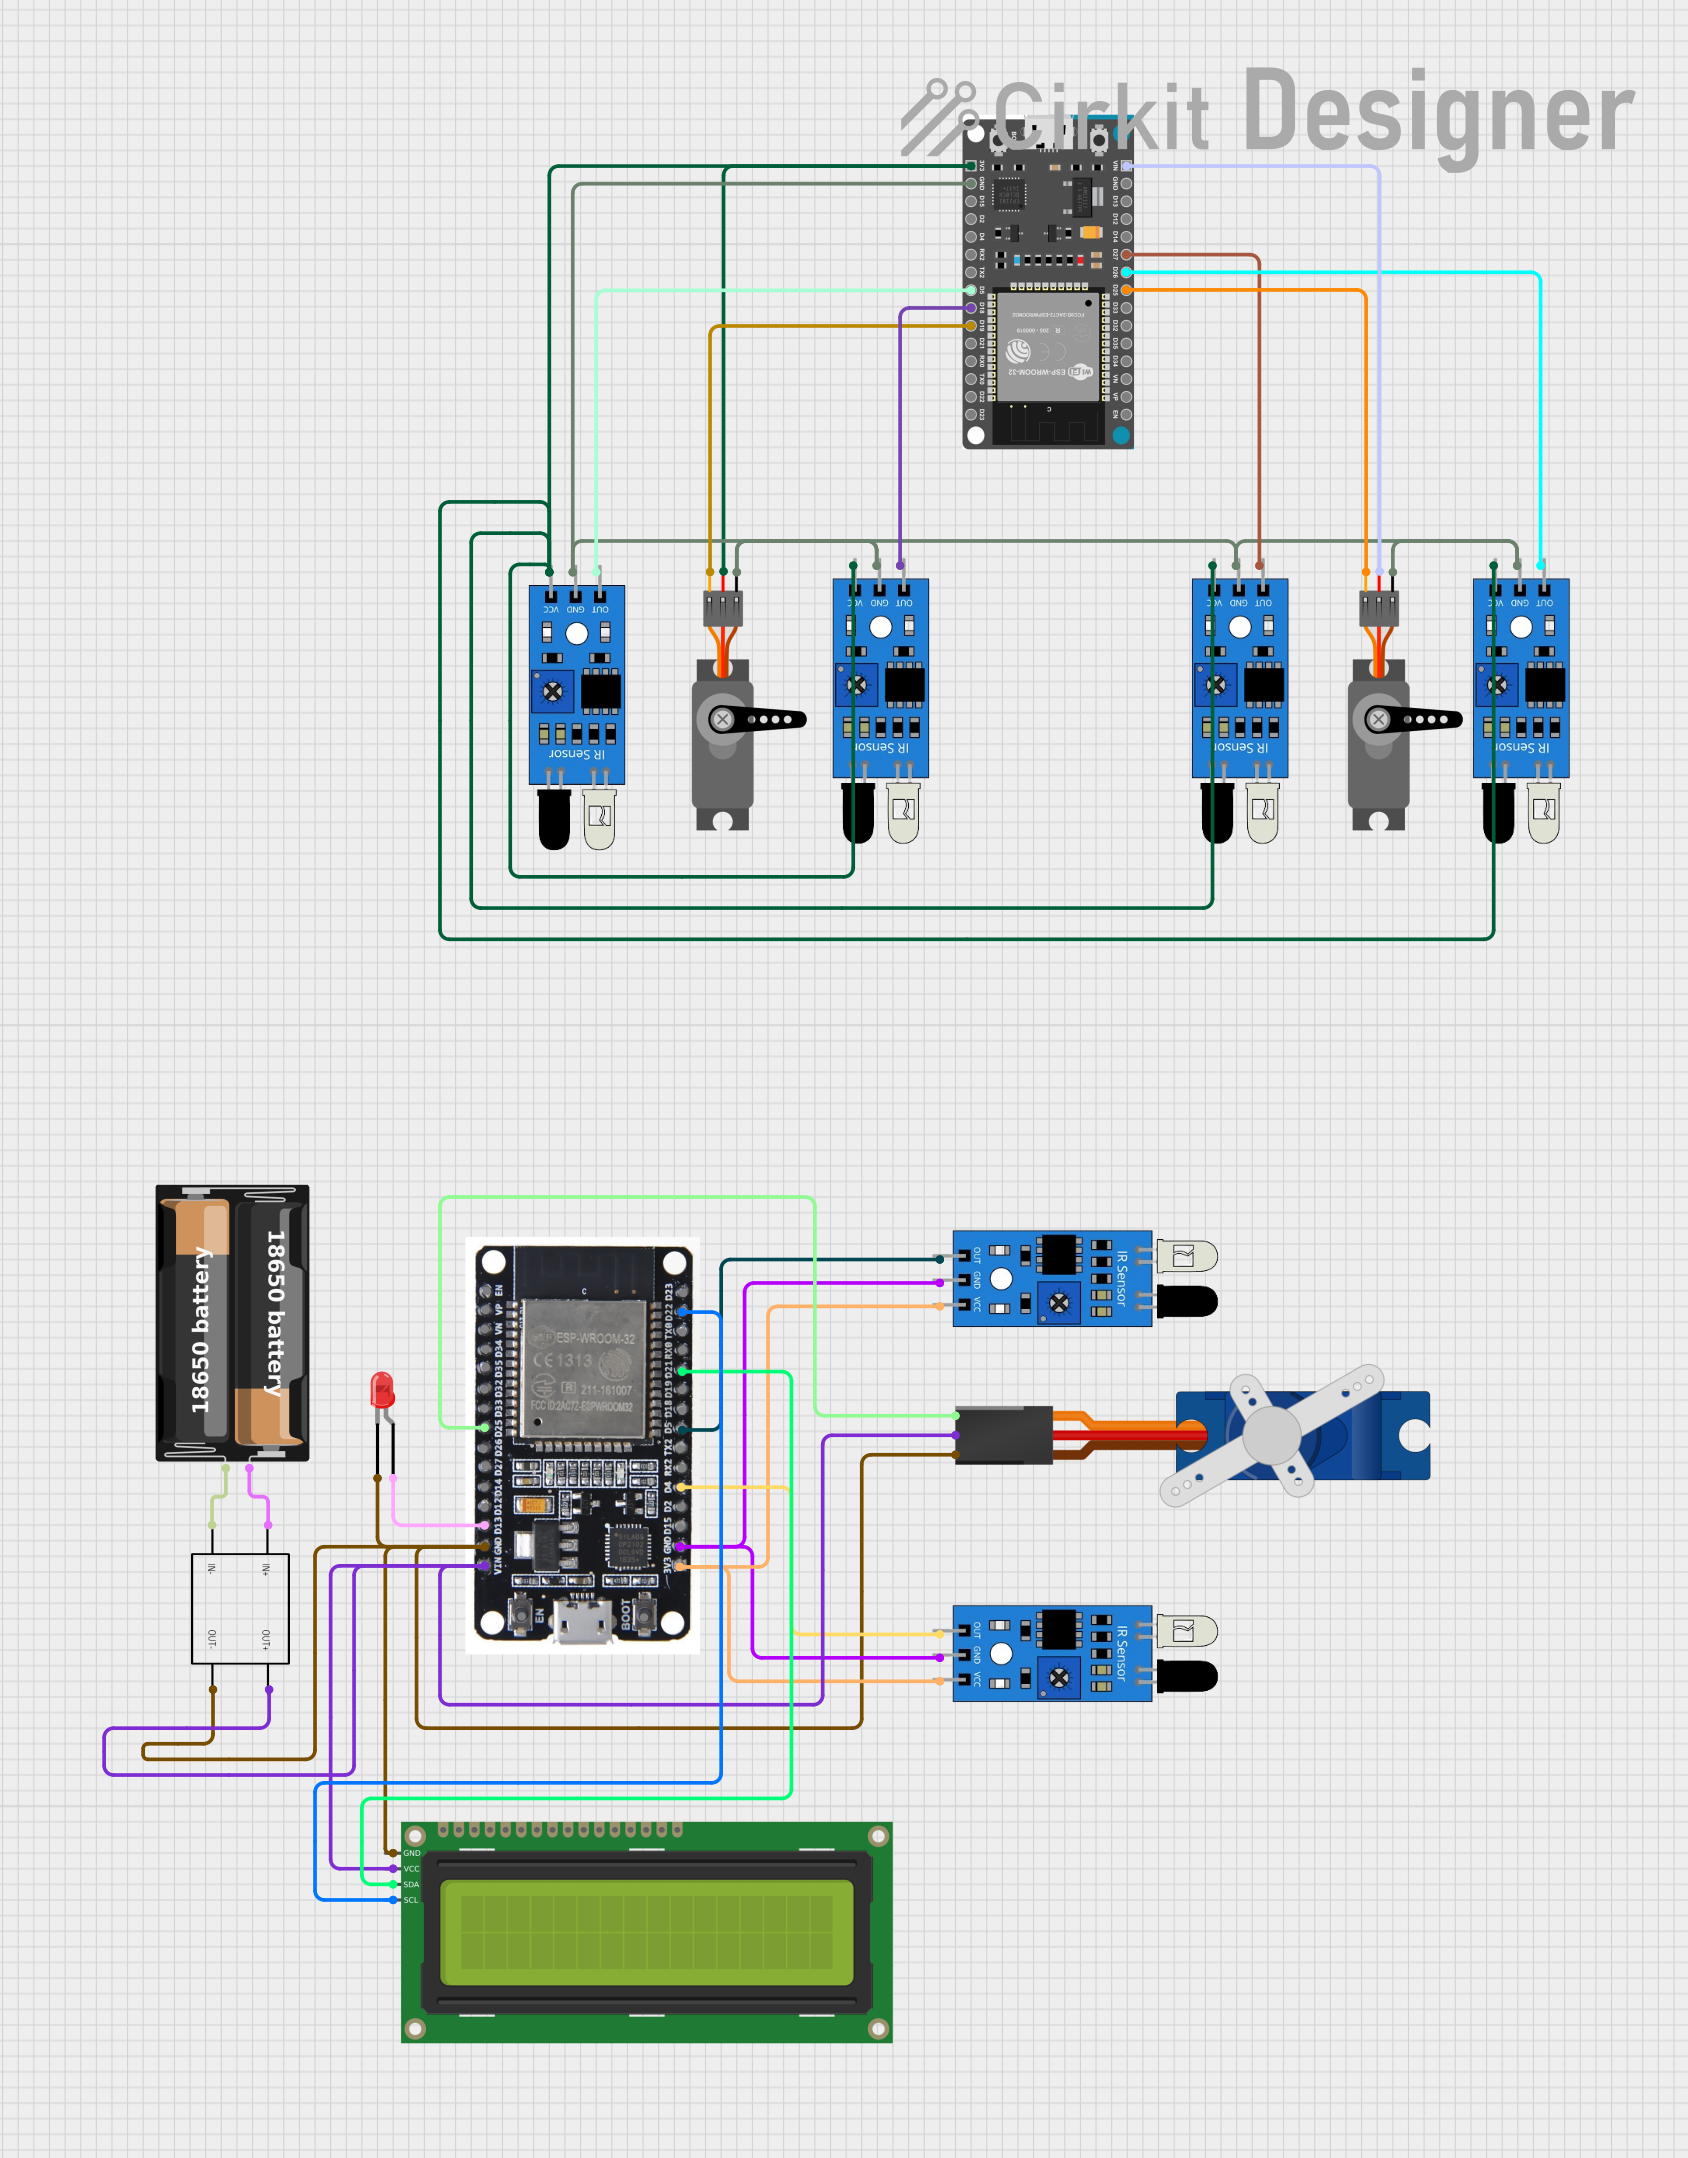
This circuit is designed to control servos and read inputs from IR sensors using an ESP32 Devkit V1 microcontroller. It features a step-down converter for voltage regulation, an I2C LCD for display purposes, and a red LED as an indicator. The system is likely used for automation tasks that require object detection and actuator control.
Robotics: Controlling robotic arms, grippers, and joints.
Remote-controlled vehicles: Steering systems and throttle control.
Automation: Conveyor belt positioning and sorting mechanisms.
Model building: Aircraft flaps, rudders, and other moving parts.
Camera gimbals: Stabilizing and positioning cameras.
Technical Specifications
Below are the general technical specifications for a standard hobby servo. Note that specifications may vary depending on the specific model and manufacturer.
Key Technical Details
Operating Voltage: 4.8V to 6V (typical for standard servos)
Operating Current: 100mA to 1A (depending on load)
Torque: 1.5 kg·cm to 25 kg·cm (varies by model)
Speed: 0.1s to 0.2s per 60° (at no load)
Control Signal: Pulse Width Modulation (PWM)
Angle Range: 0° to 180° (standard), some models support 360° continuous rotation
Connector Type: 3-pin (Signal, VCC, GND)
Pin Configuration and Descriptions
The servo typically has a 3-pin connector with the following configuration:
Pin Number
Name
Description
1
Signal
Receives PWM signal for position control
2
VCC
Power supply (4.8V to 6V)
3
GND
Ground connection
Usage Instructions
How to Use the Servo in a Circuit
Power Supply: Connect the VCC pin to a 5V power source and the GND pin to the ground of your circuit. Ensure the power supply can handle the current requirements of the servo.
Signal Input: Connect the Signal pin to a PWM-capable pin on your microcontroller (e.g., Arduino).
PWM Signal: Generate a PWM signal with a pulse width between 1ms and 2ms:
1ms corresponds to 0°.
1.5ms corresponds to 90° (neutral position).
2ms corresponds to 180°.
Important Considerations and Best Practices
Power Supply: Use a separate power supply for the servo if it draws significant current, as this can prevent voltage drops in your circuit.
Avoid Overloading: Do not exceed the torque rating of the servo to avoid damage.
Signal Stability: Ensure the PWM signal is stable and within the specified range to prevent erratic behavior.
Mounting: Secure the servo properly to avoid vibrations or misalignment during operation.
Example: Connecting a Servo to an Arduino UNO
Below is an example of how to control a servo using an Arduino UNO:
#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object to control the servo

void setup() {
  myServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000);      // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000);       // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000);        // Wait for 1 second
}
Explanation of the Code:
The Servo library simplifies controlling the servo.
The attach() function links the servo to a specific PWM pin.
The write() function sets the servo's position in degrees (0° to 180°).
Delays are used to allow the servo to reach the desired position before the next command.
Troubleshooting and FAQs
Common Issues and Solutions
Servo Not Moving:
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check the connections and ensure the power supply meets the servo's requirements.
Erratic Movement:
Cause: Unstable PWM signal or electrical noise.
Solution: Use a decoupling capacitor near the servo's power pins and ensure the PWM signal is stable.
Overheating:
Cause: Excessive load or continuous operation at high torque.
Solution: Reduce the load or allow the servo to rest periodically.
Limited Range of Motion:
Cause: Mechanical obstruction or incorrect PWM signal range.
Solution: Check for physical obstructions and ensure the PWM signal is within the 1ms to 2ms range.
FAQs
Q: Can I control multiple servos with one Arduino?
A: Yes, you can control multiple servos using different PWM-capable pins. However, ensure your power supply can handle the combined current draw.
Q: Can I use a servo with a 3.3V microcontroller?
A: Most servos require a 5V signal for proper operation. Use a logic level shifter if your microcontroller operates at 3.3V.
Q: What happens if I send a PWM signal outside the 1ms to 2ms range?
A: The servo may behave unpredictably or attempt to move beyond its physical limits, potentially causing damage.
Q: Can I use a servo for continuous rotation?
A: Yes, some servos are designed for continuous rotation. These are controlled by varying the PWM signal to adjust speed and direction instead of position.

 Open Project in Cirkit Designer