Introduction
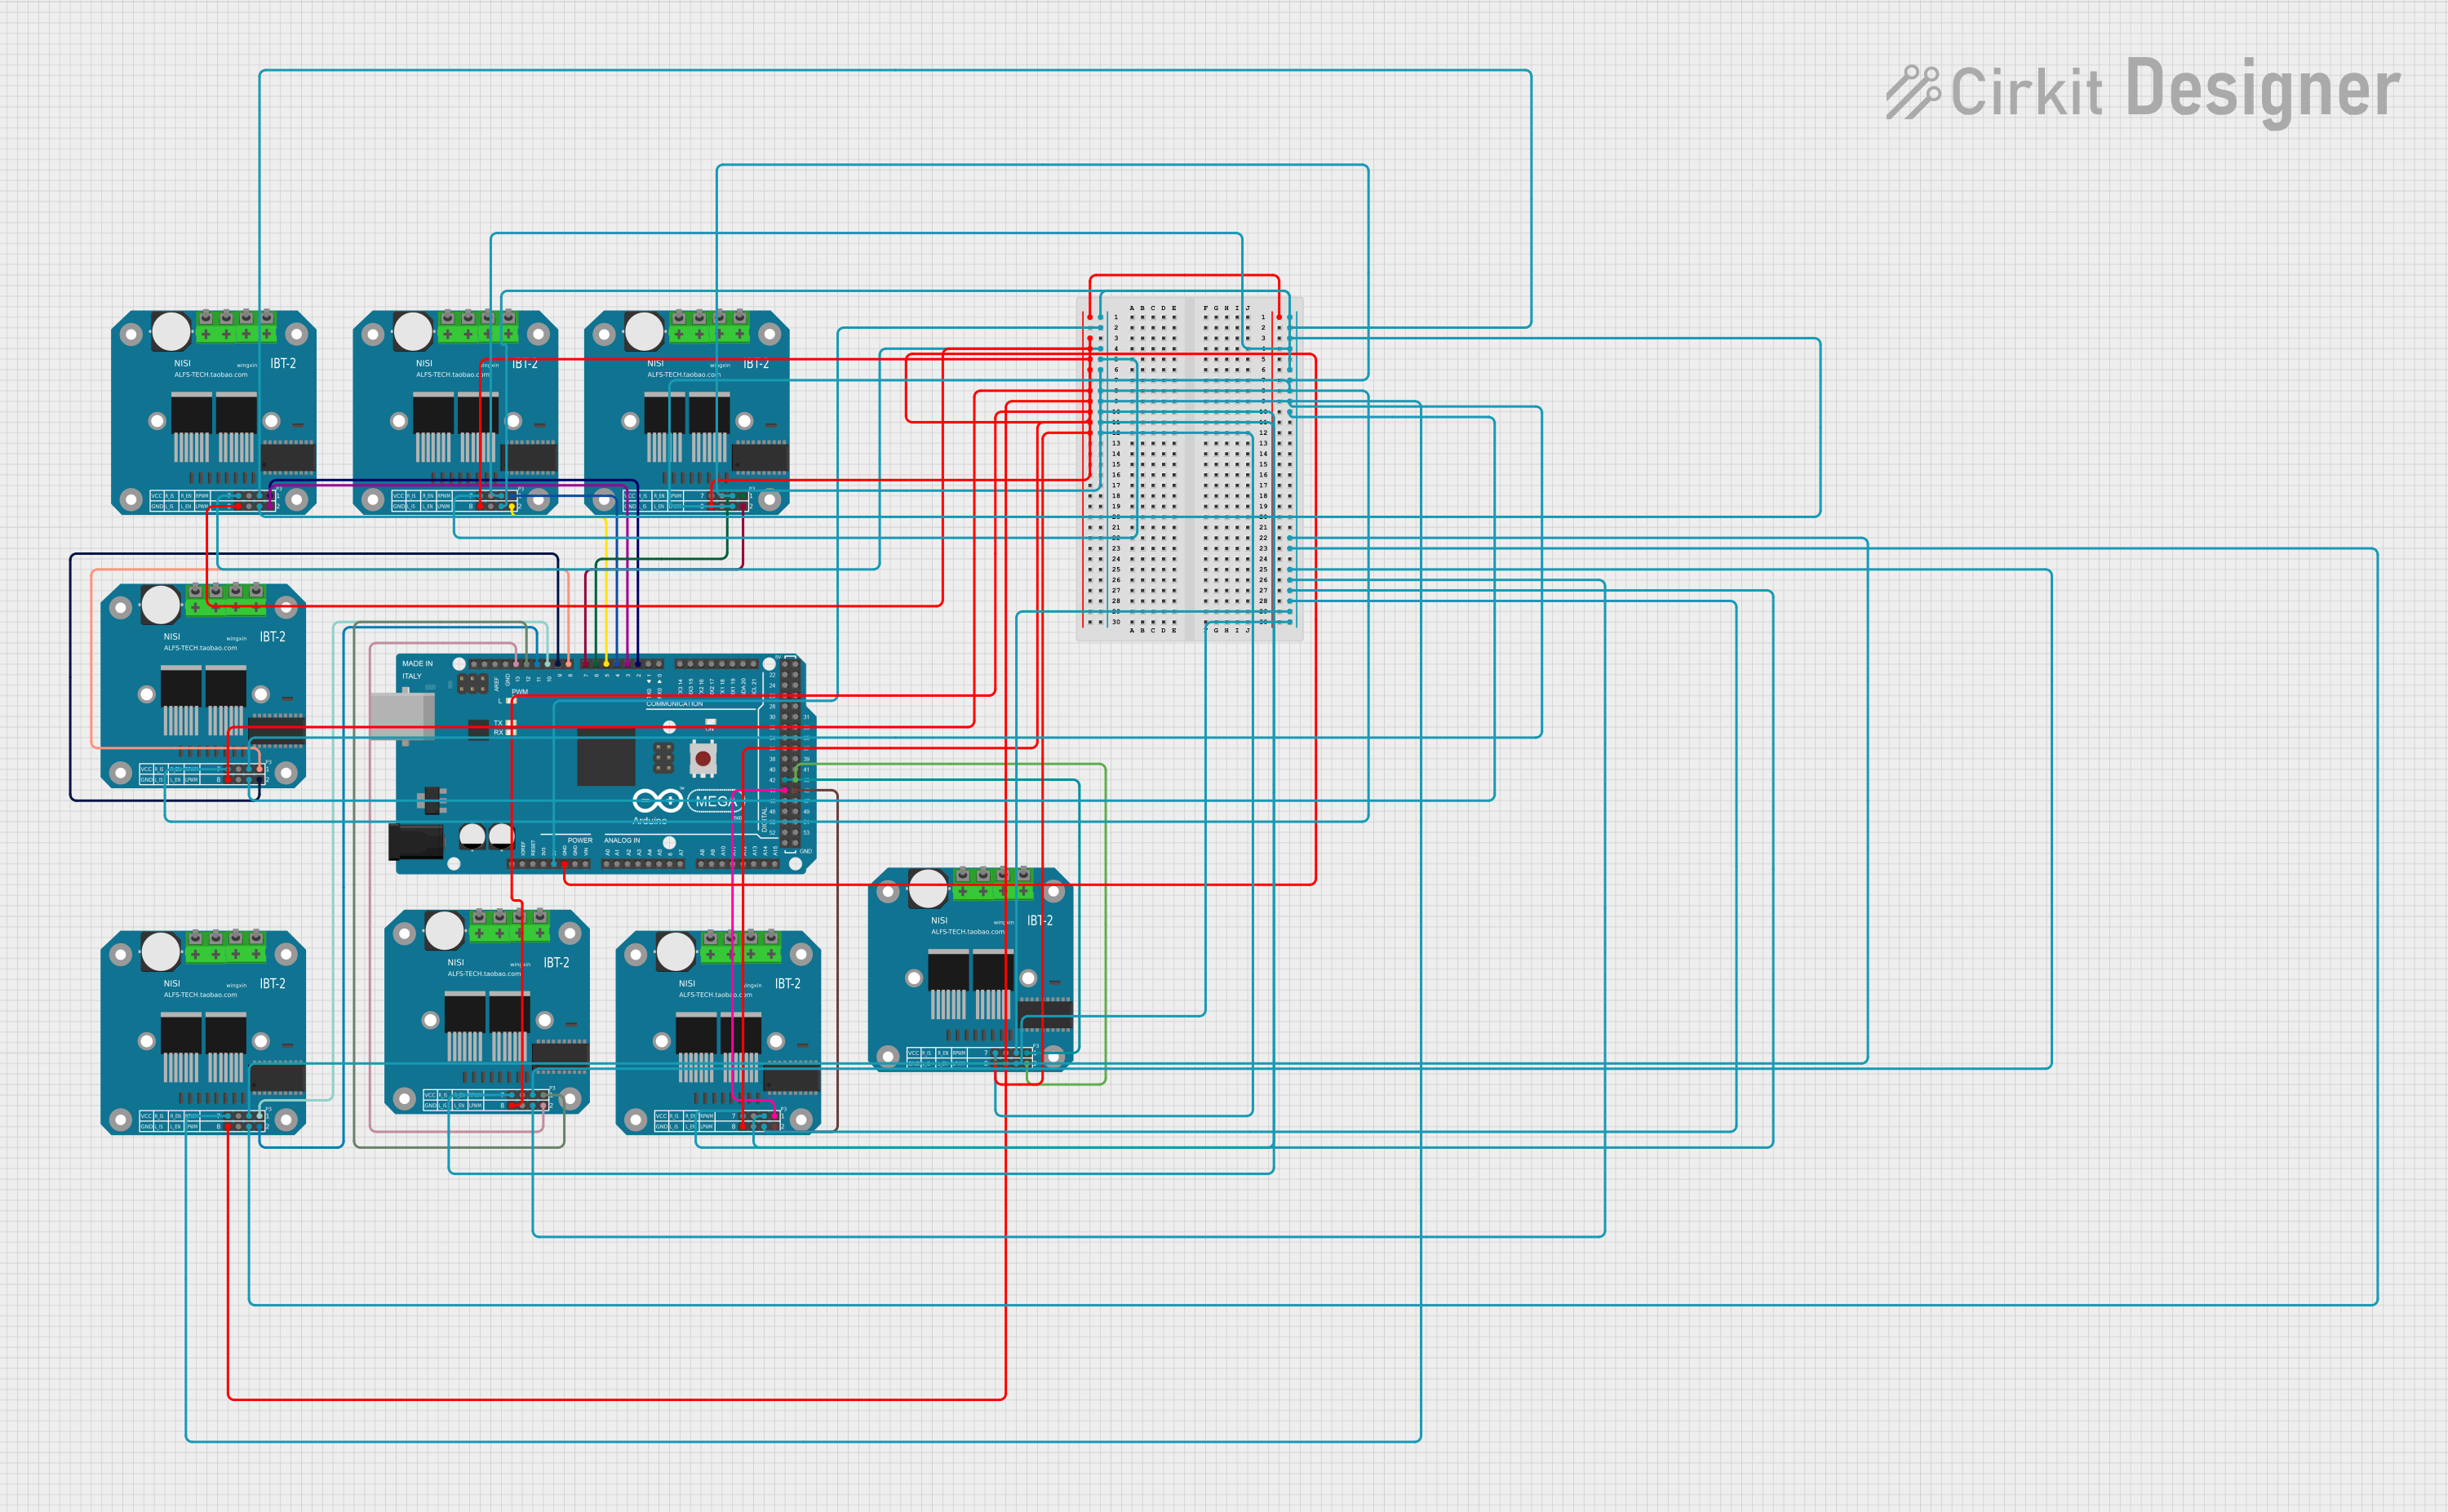
The BTS7960 is a high-current H-bridge motor driver designed to control DC motors and stepper motors. It is capable of handling high currents (up to 43A) and features built-in protection mechanisms such as overcurrent protection, thermal shutdown, and undervoltage lockout. These features make the BTS7960 a reliable choice for applications requiring robust motor control.
Common Applications
- Robotics and automation systems
- Electric vehicles and motorized carts
- Conveyor belts and industrial machinery
- Remote-controlled cars and boats
- CNC machines and 3D printers
Technical Specifications
The BTS7960 motor driver is designed to handle high-power motor control with precision and safety. Below are its key technical specifications:
Pin Configuration and Descriptions
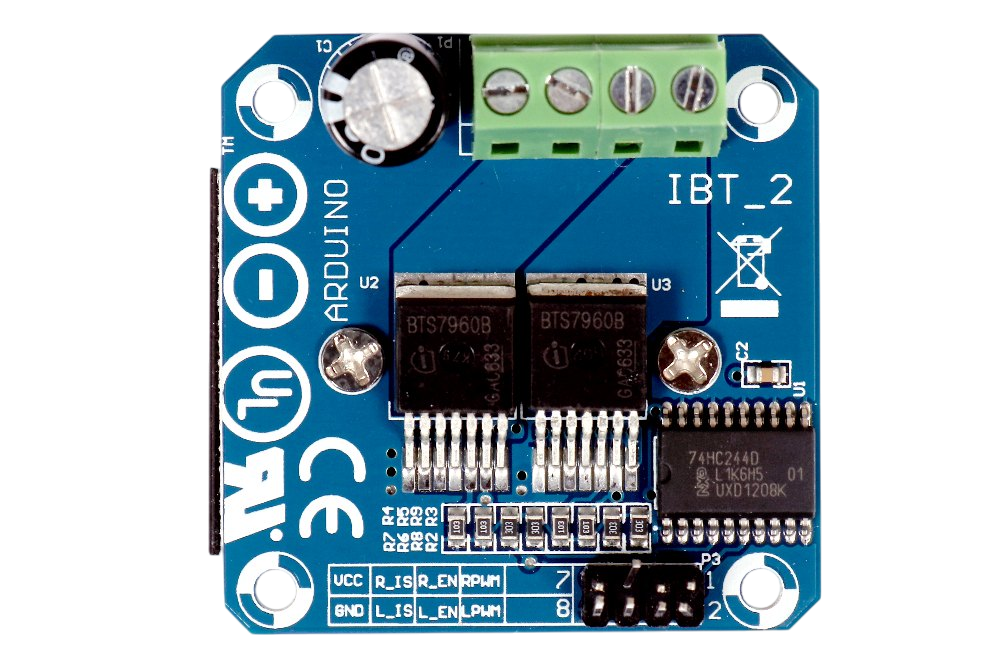
The BTS7960 module has several pins for motor control and power input. Below is the pin configuration:
Usage Instructions
The BTS7960 motor driver is straightforward to use in motor control applications. Below are the steps and considerations for using the module:
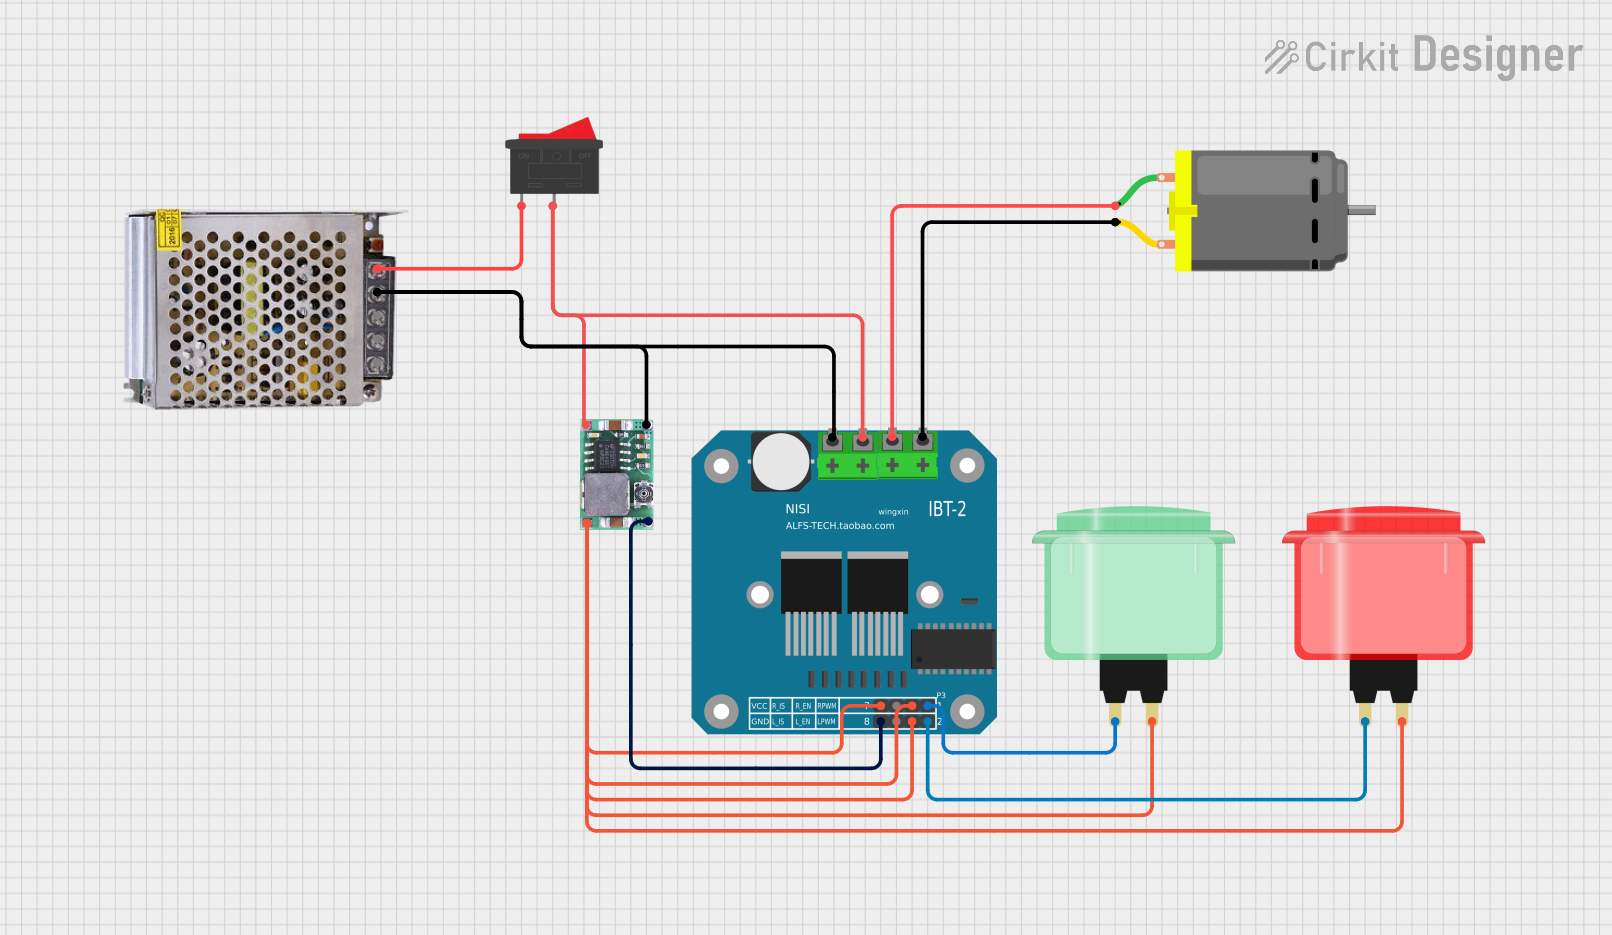
Connecting the BTS7960
- Power Supply: Connect the motor power supply (5.5V to 27V) to the
VCC (Motor) pin and the ground to the GND pin.
- Logic Voltage: Connect the logic voltage (3.3V or 5V) to the
VCC pin.
- Motor Connections: Connect the motor terminals to the
OUT1 and OUT2 pins.
- Control Pins: Connect the
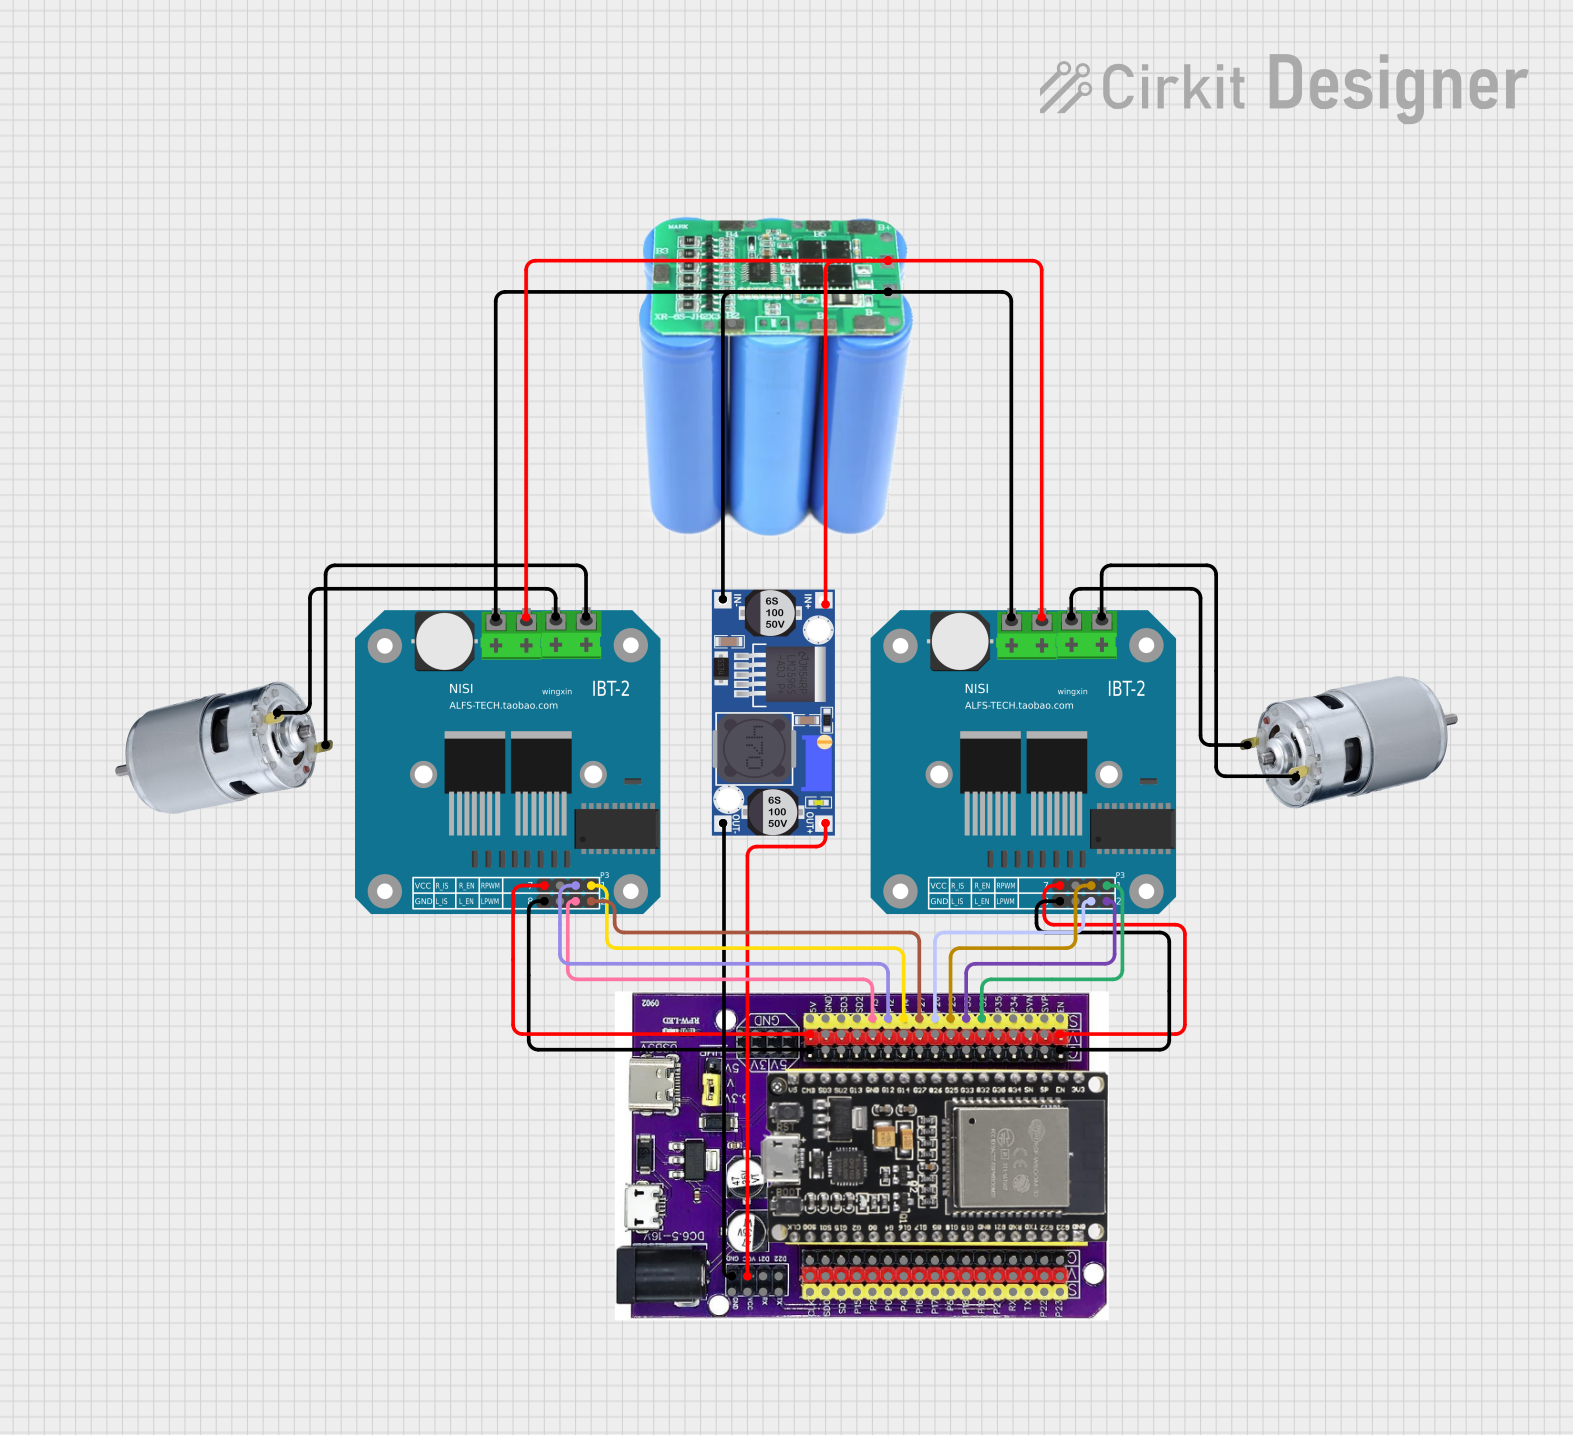
RPWM, LPWM, R_EN, and L_EN pins to the microcontroller's GPIO pins.
Controlling the Motor
- Use the
RPWM and LPWM pins to send PWM signals for speed and direction control.
- Enable the H-bridge by setting
R_EN and L_EN pins HIGH.
- Adjust the duty cycle of the PWM signals to control motor speed.
Example: Using BTS7960 with Arduino UNO
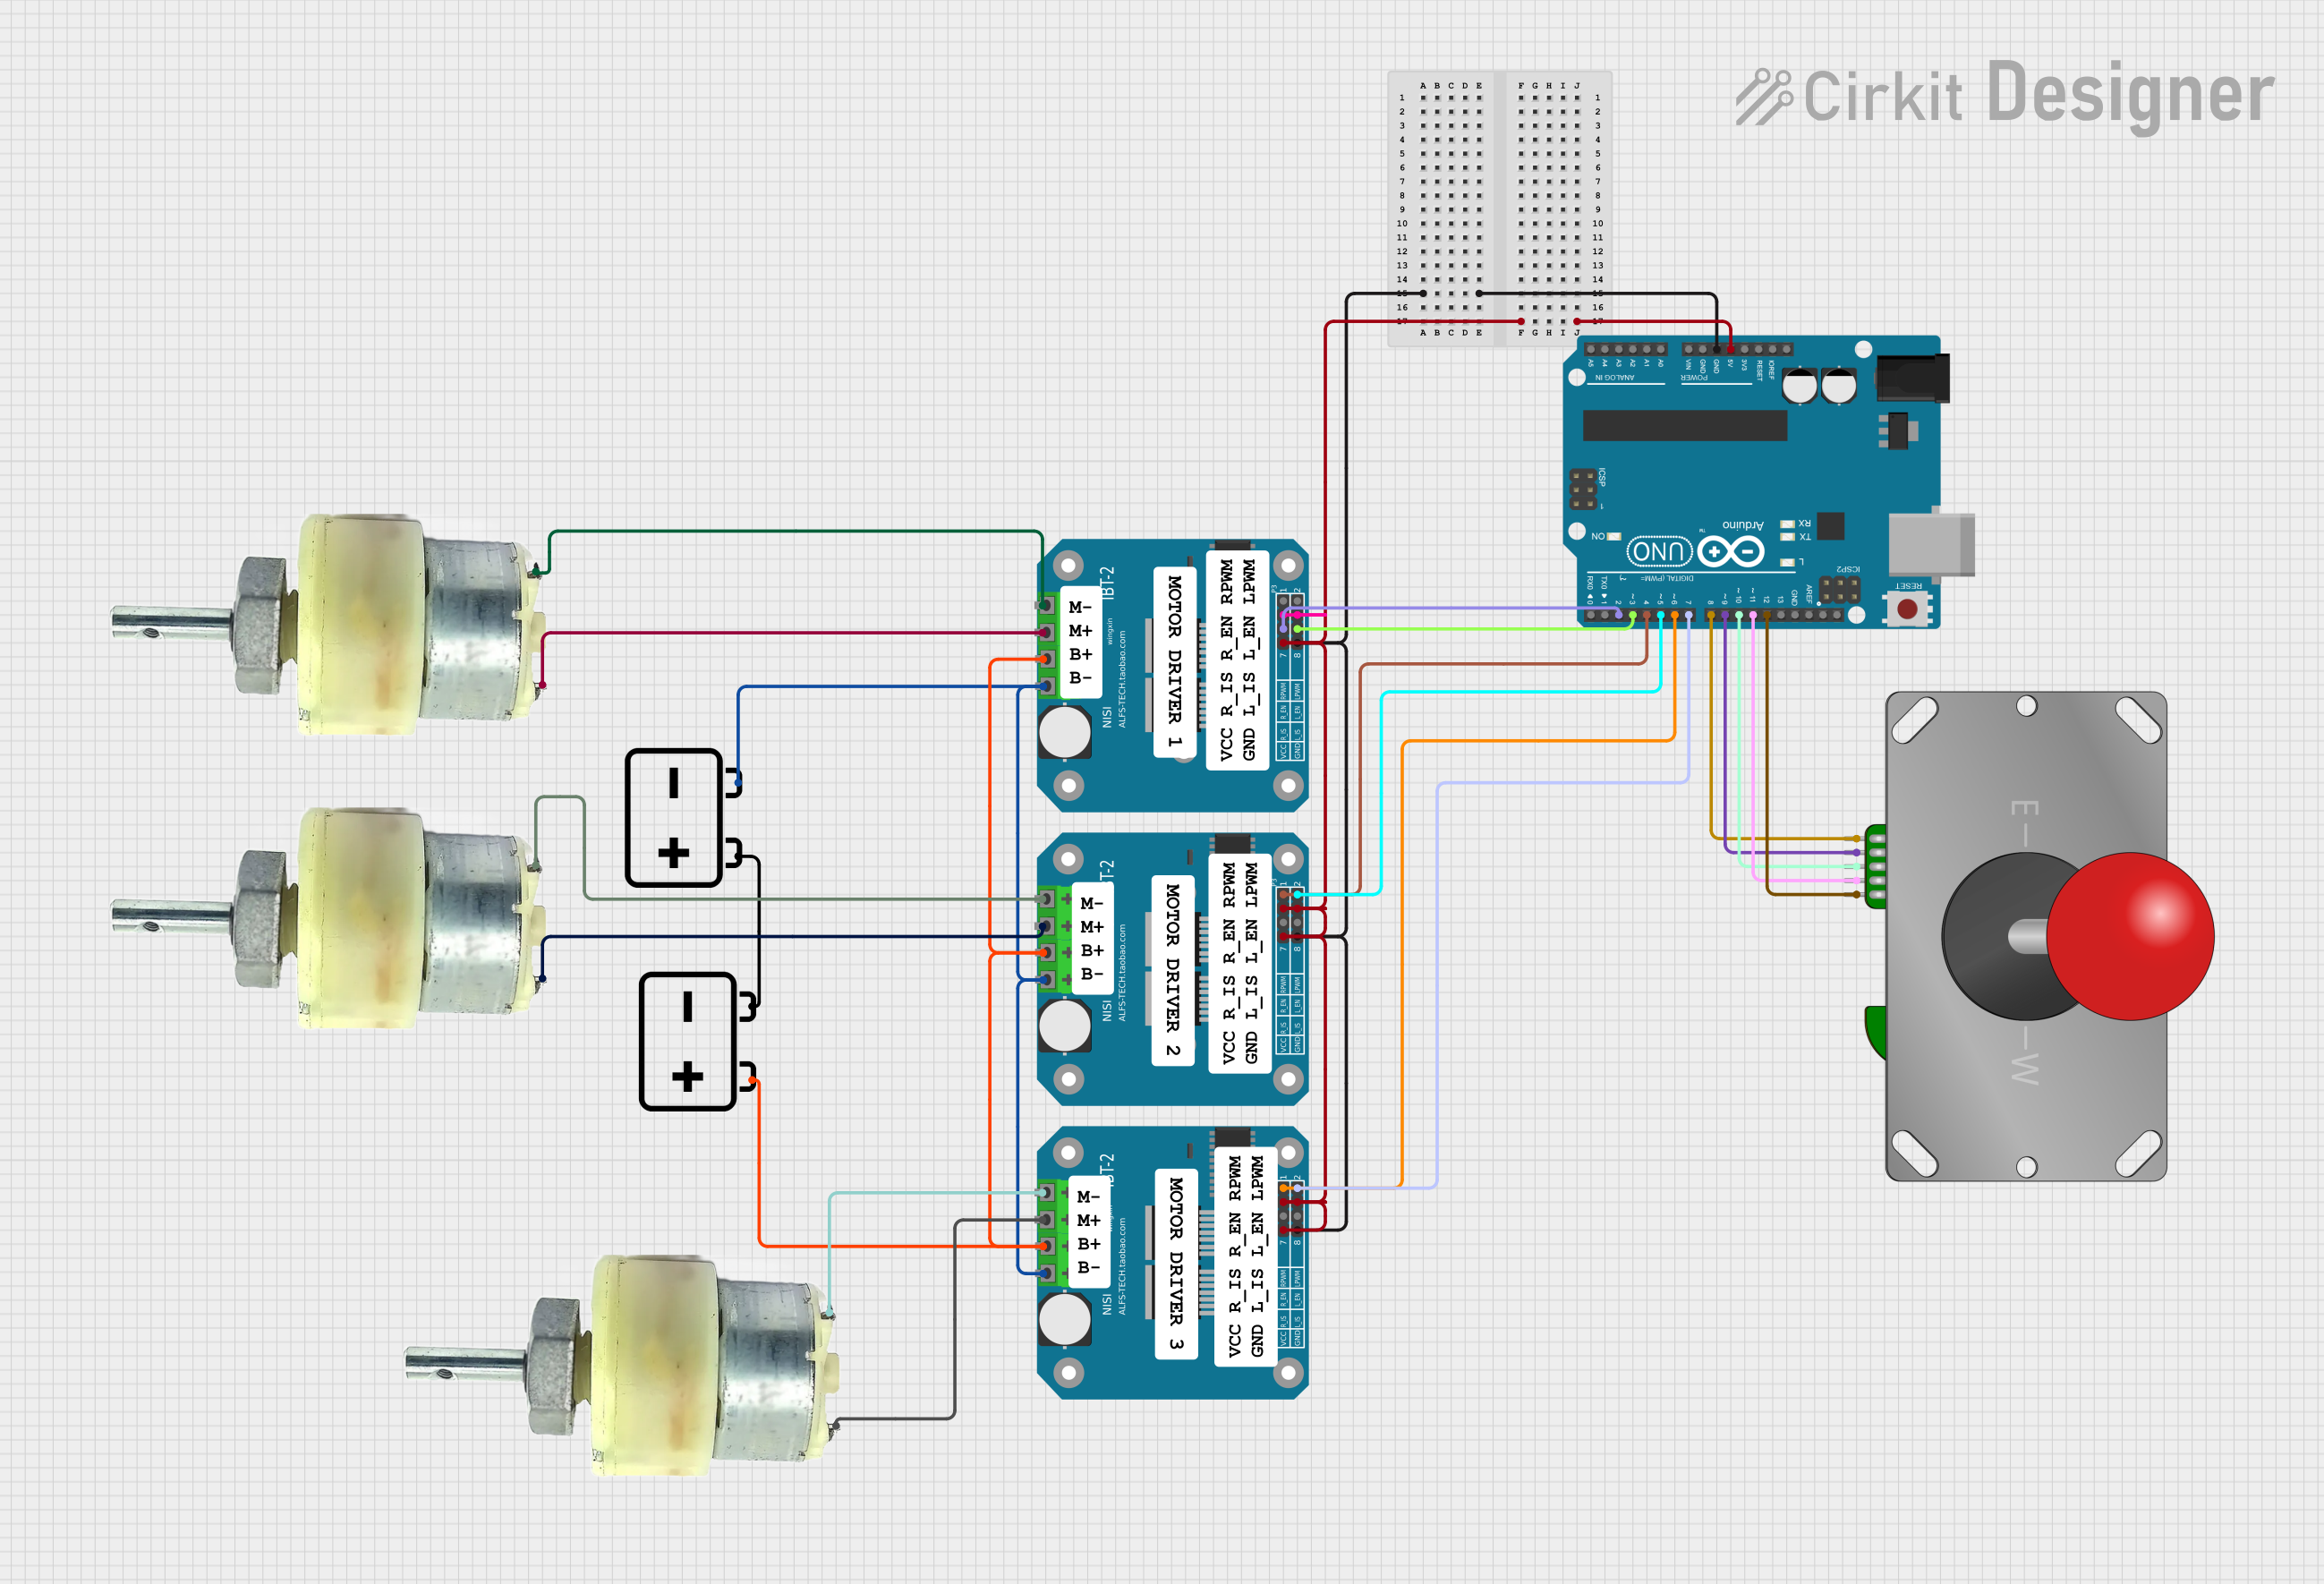
Below is an example code snippet to control a DC motor using the BTS7960 and Arduino UNO:
// Define control pins for the BTS7960 motor driver
#define RPWM 9   // PWM pin for forward rotation
#define LPWM 10  // PWM pin for reverse rotation
#define R_EN 8   // Enable pin for right H-bridge
#define L_EN 7   // Enable pin for left H-bridge

void setup() {
  // Set control pins as outputs
  pinMode(RPWM, OUTPUT);
  pinMode(LPWM, OUTPUT);
  pinMode(R_EN, OUTPUT);
  pinMode(L_EN, OUTPUT);

  // Enable both sides of the H-bridge
  digitalWrite(R_EN, HIGH);
  digitalWrite(L_EN, HIGH);
}

void loop() {
  // Rotate motor forward at 50% speed
  analogWrite(RPWM, 128); // 50% duty cycle
  analogWrite(LPWM, 0);   // No reverse rotation
  delay(2000);            // Run for 2 seconds

  // Rotate motor backward at 75% speed
  analogWrite(RPWM, 0);   // No forward rotation
  analogWrite(LPWM, 192); // 75% duty cycle
  delay(2000);            // Run for 2 seconds

  // Stop the motor
  analogWrite(RPWM, 0);
  analogWrite(LPWM, 0);
  delay(2000);            // Wait for 2 seconds
}
Best Practices
- Ensure the motor power supply voltage matches the motor's rated voltage.
- Use a heatsink or cooling fan if operating at high currents for extended periods.
- Avoid sudden changes in direction at high speeds to prevent damage to the motor or driver.
- Use appropriate fuses or circuit breakers for additional protection.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Running
- Cause: Incorrect wiring or insufficient power supply.
- Solution: Double-check all connections and ensure the power supply meets the voltage and current requirements.
Overheating
- Cause: Prolonged operation at high currents without proper cooling.
- Solution: Add a heatsink or cooling fan to the BTS7960 module.
Erratic Motor Behavior
- Cause: Noise or interference in PWM signals.
- Solution: Use shielded cables for signal lines and ensure a stable power supply.
No Response from the Driver
- Cause: Logic voltage not supplied or enable pins not set HIGH.
- Solution: Verify that the
VCC, R_EN, and L_EN pins are correctly connected and powered.
FAQs
Q1: Can the BTS7960 drive stepper motors?
Yes, the BTS7960 can drive stepper motors, but you will need additional control logic to generate the required step and direction signals.
Q2: What is the maximum PWM frequency supported?
The BTS7960 supports PWM frequencies up to 25kHz.
Q3: Can I use the BTS7960 with a 3.3V microcontroller?
Yes, the BTS7960 is compatible with both 3.3V and 5V logic levels.
Q4: How do I measure motor current using the IS pin?
The IS pin provides a voltage proportional to the motor current. Refer to the datasheet for the exact scaling factor.
By following this documentation, you can effectively use the BTS7960 motor driver in your projects.

 Open Project in Cirkit Designer