The TMC2226 is a high-performance stepper motor driver manufactured by Trinamic (TMC). It is designed for precise and efficient control of stepper motors, offering advanced features such as microstepping, current control, and low-noise operation. The TMC2226 is particularly well-suited for applications requiring smooth and quiet motor operation, such as 3D printers, CNC machines, and robotics.
Explore Projects Built with TMC2226 Stepper Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
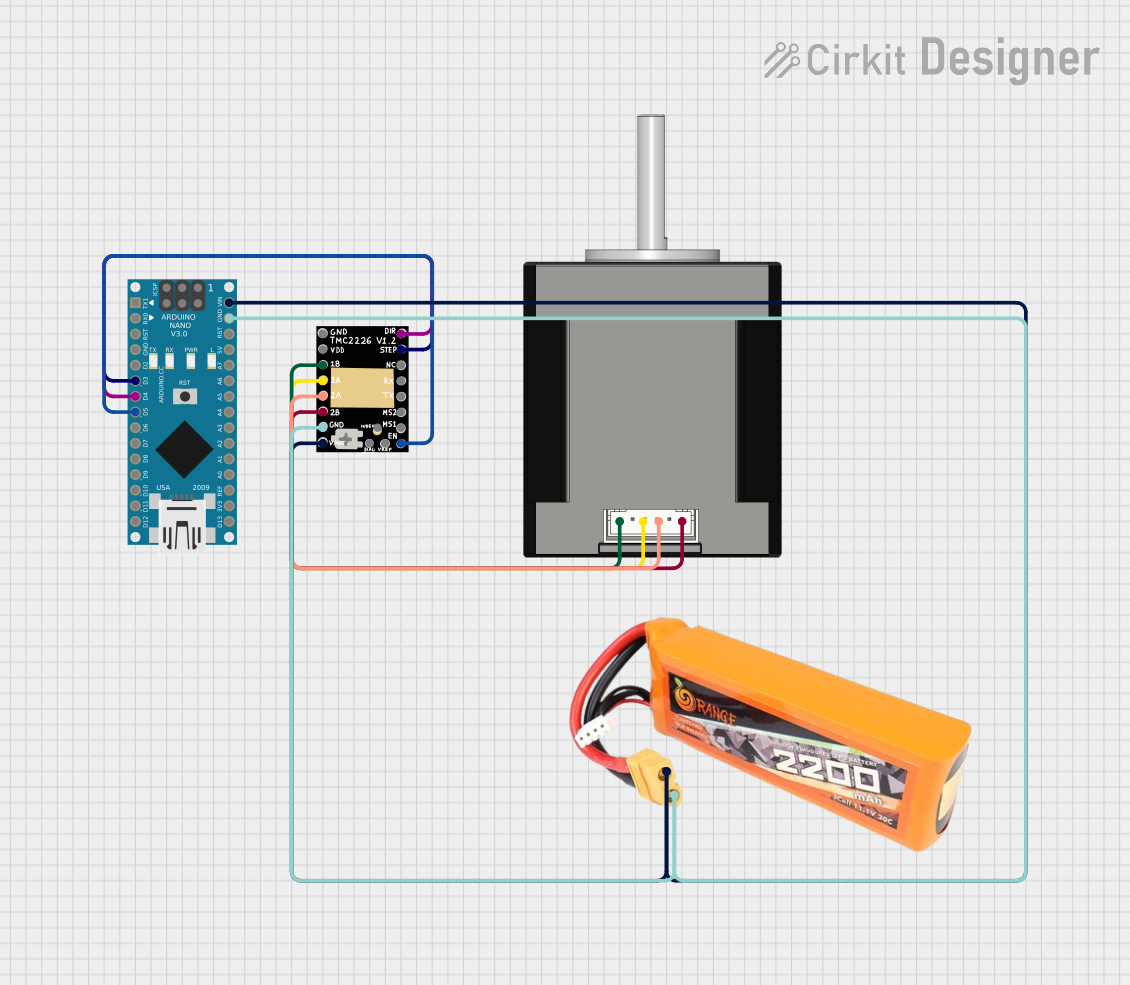
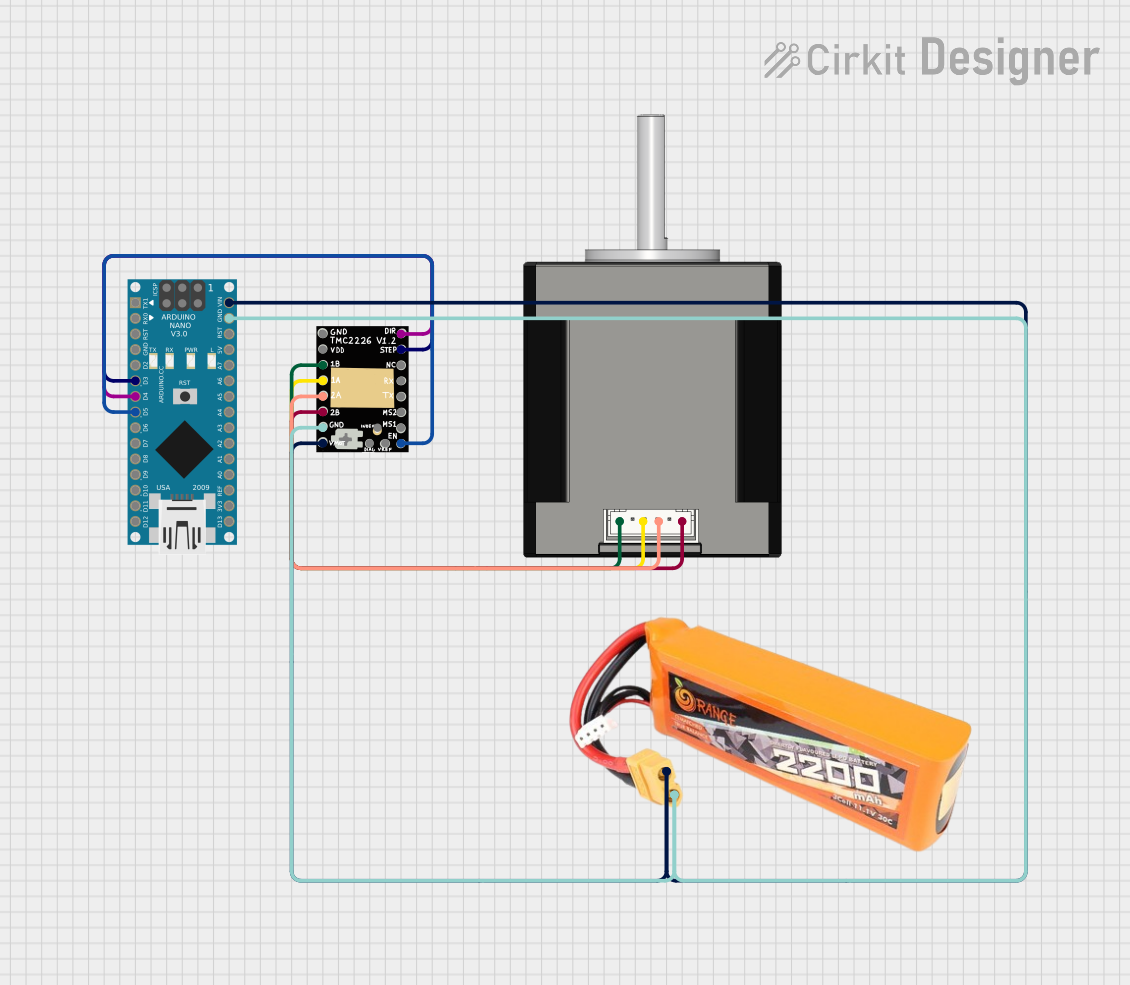
This circuit is designed to control a Nema 17 stepper motor using an Arduino Nano and a TMC2226 stepper driver. The Arduino Nano is interfaced with the TMC2226 driver to send step, direction, and enable signals, allowing for precise control of the motor's movements. Power is supplied to the motor driver and the Arduino through a connection to a lipo battery, ensuring that the motor receives the necessary voltage for operation.
This circuit controls a Nema 17 stepper motor using an Arduino Nano and a TMC2226 stepper driver, powered by a LiPo battery. The Arduino Nano sends step and direction signals to the TMC2226 driver to control the motor's movement. The setup is designed for applications requiring precise motor control, such as robotics or CNC machines.
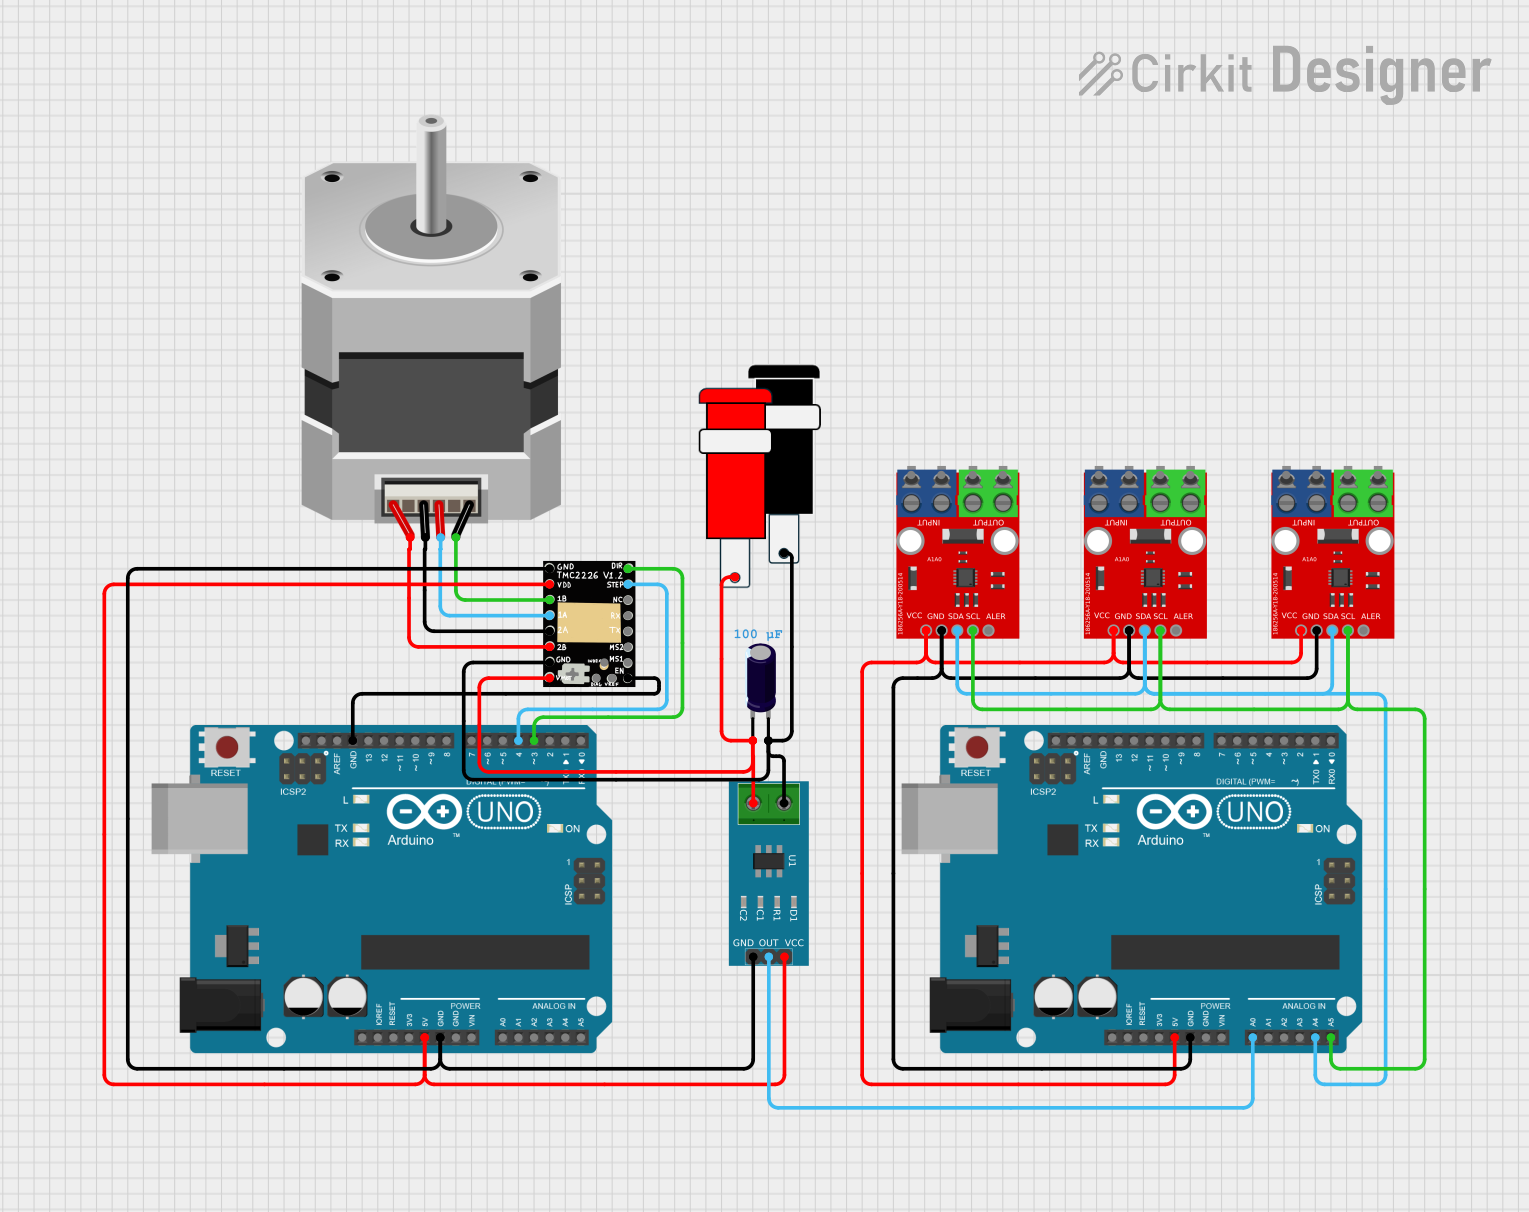
This circuit controls a bipolar stepper motor using a TMC2226 stepper driver, which is managed by an Arduino UNO. The circuit also includes a current sensor to monitor the motor's current, and multiple Nazarbayev University components are interconnected for additional functionality. Power is supplied through a 5V connector, and an electrolytic capacitor is used for voltage stabilization.
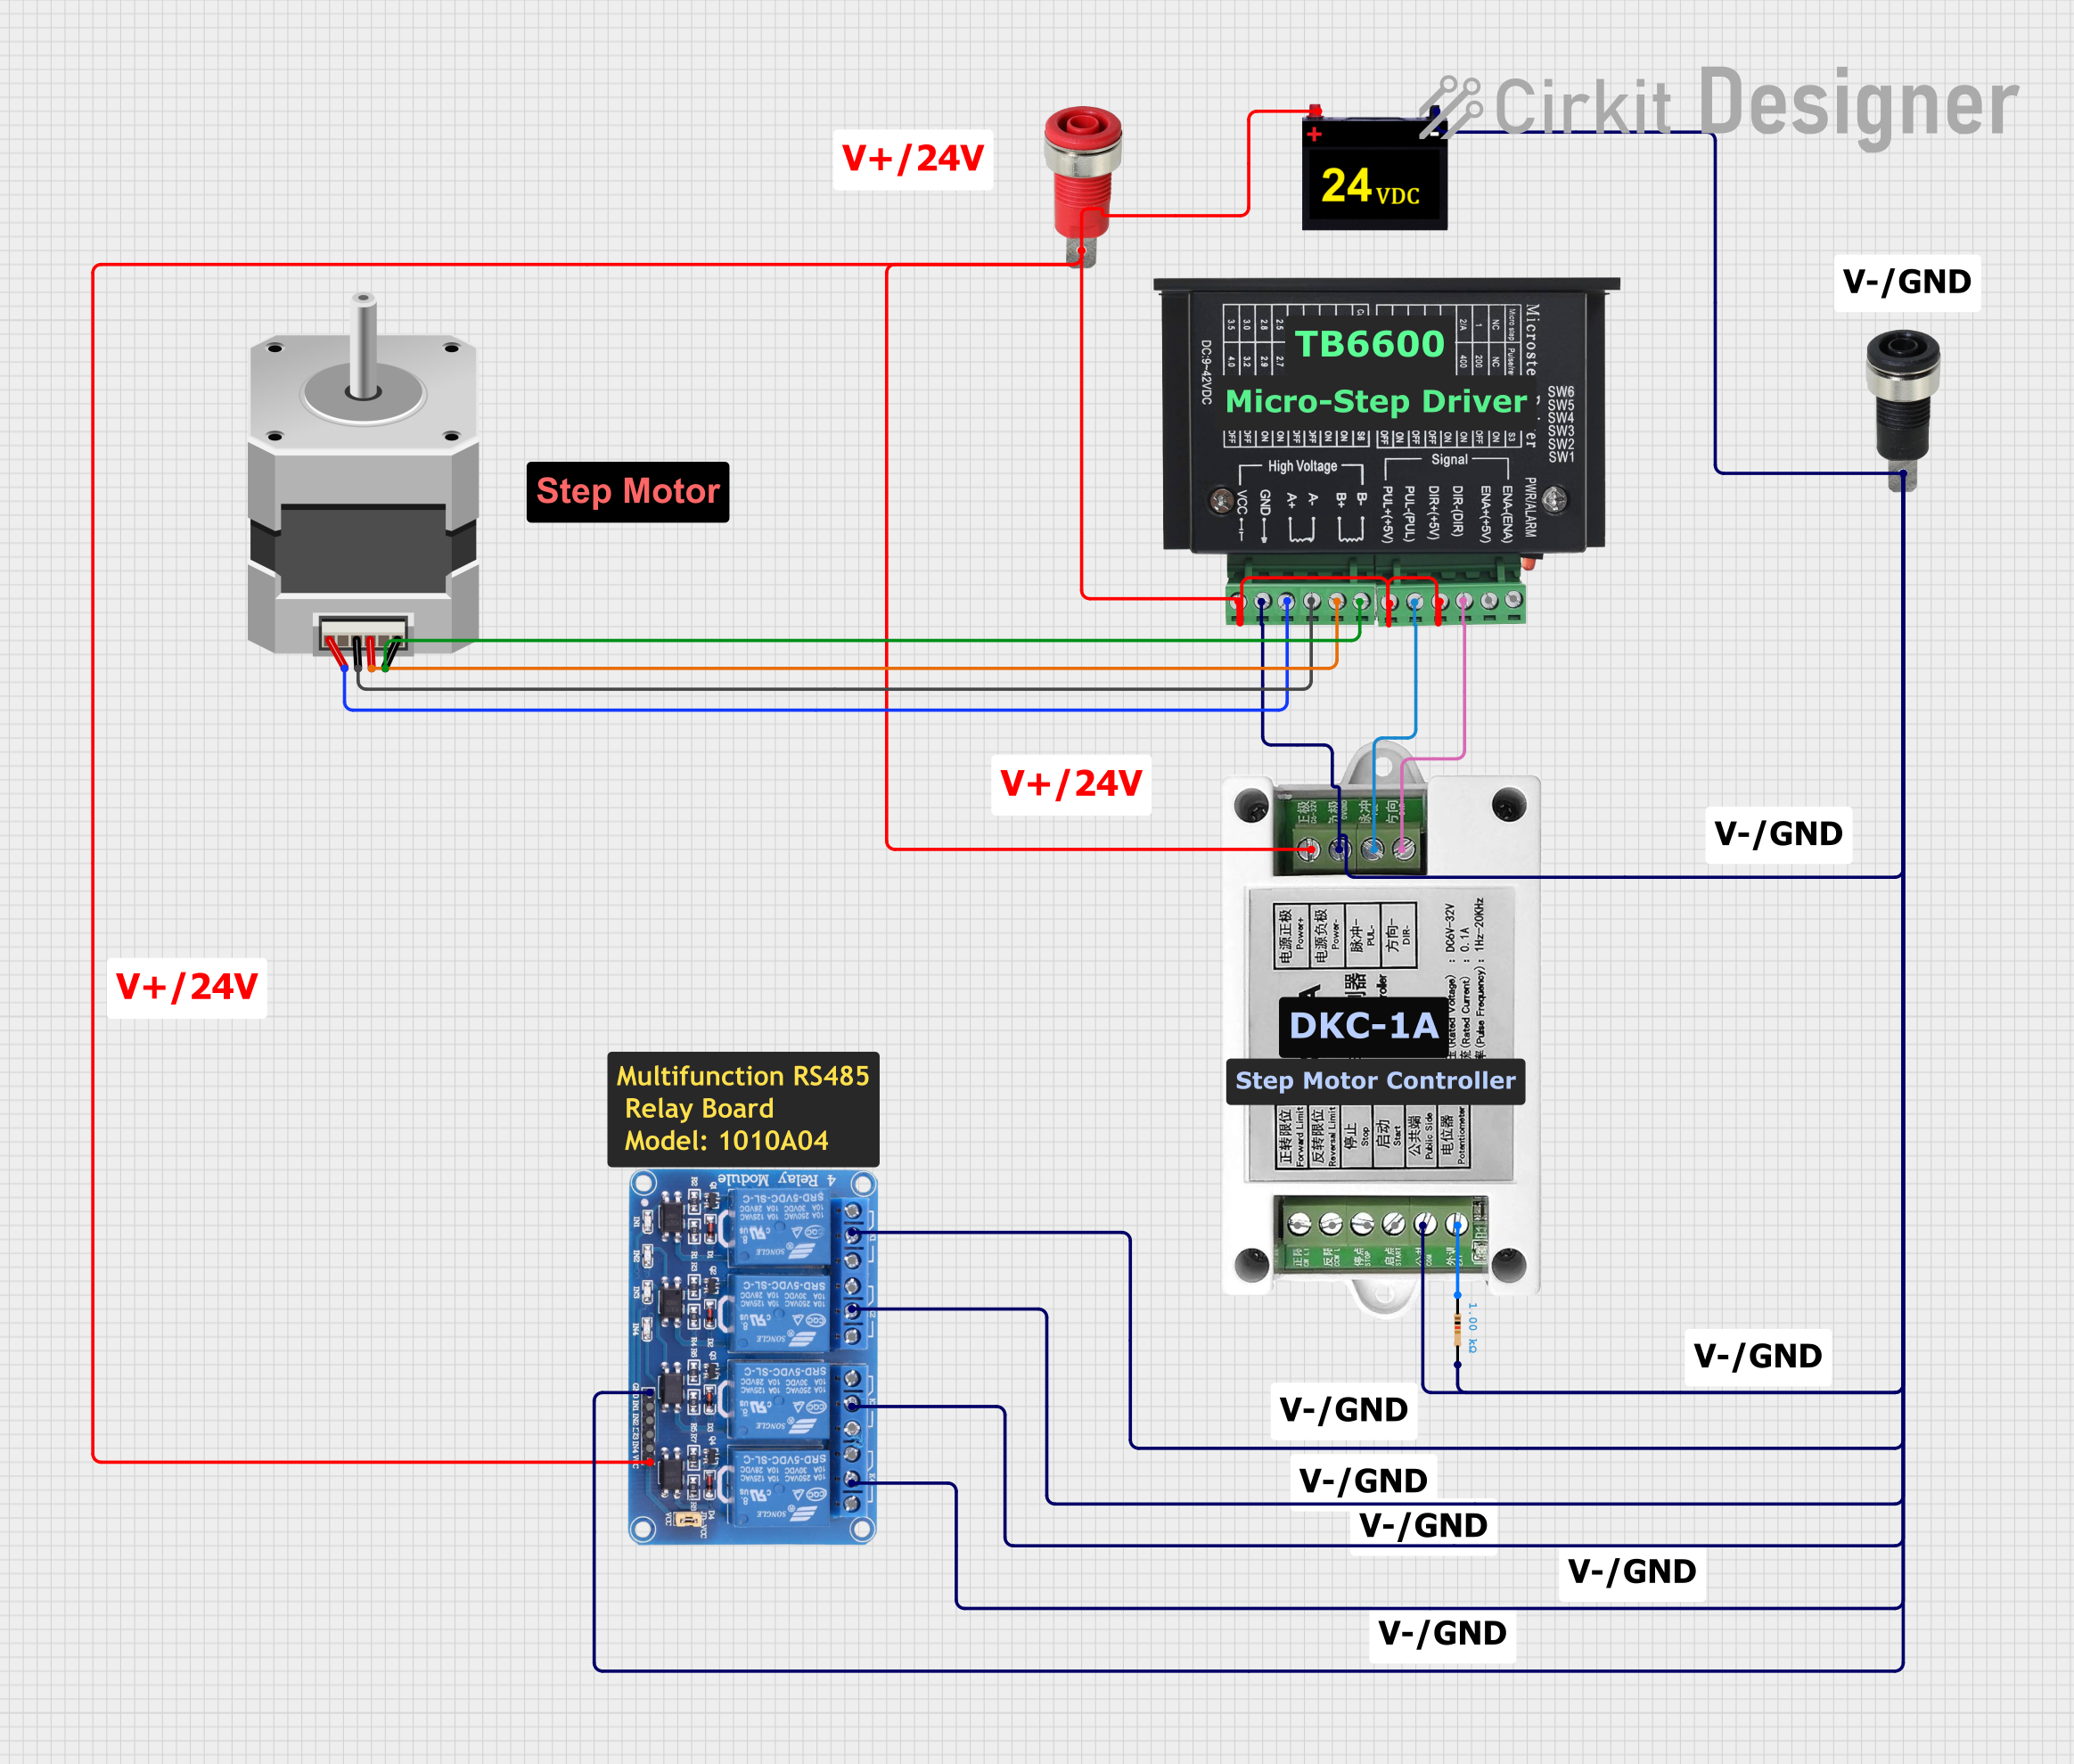
This circuit controls a bipolar stepper motor using a tb6600 micro stepping motor driver and a DKC-1A stepper motor controller. The system is powered by a 24VDC power supply and includes a relay module for additional control functionalities.
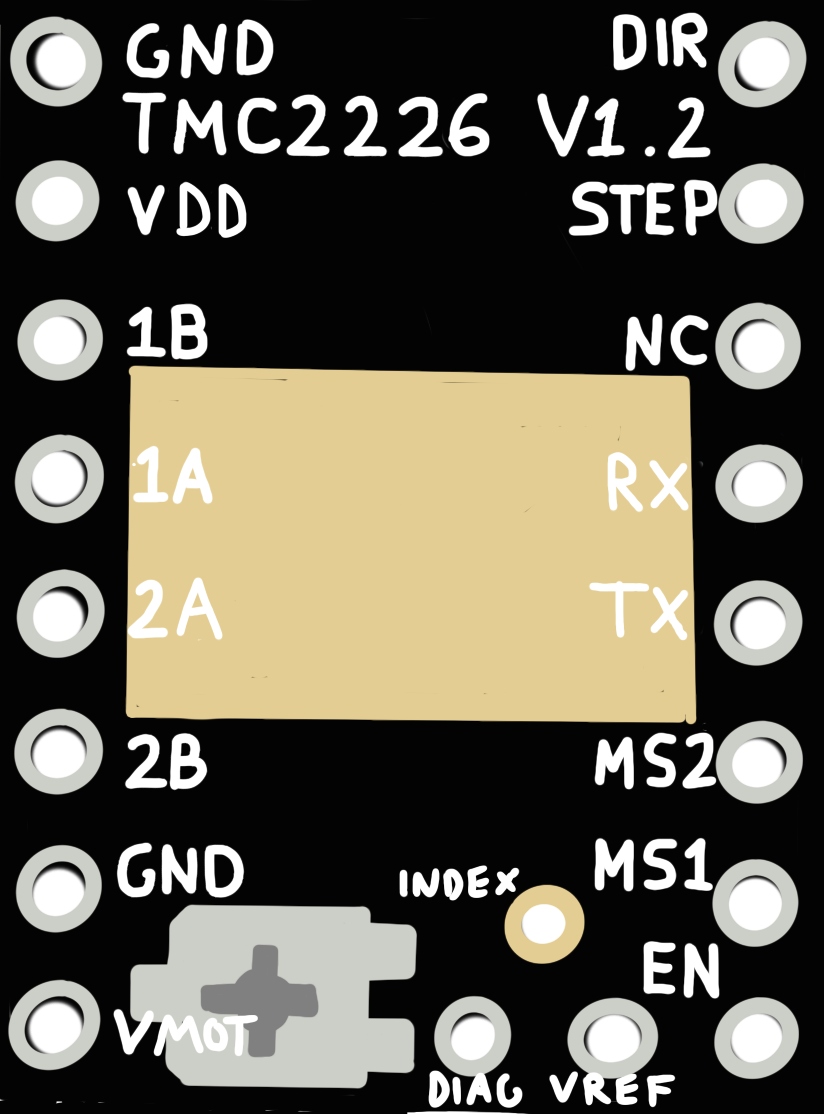
The TMC2226 comes in a 28-pin HTSSOP package. Below is the pin configuration and description:
Pin Number
Pin Name
Description
1
V_M
Motor power supply (4.75V to 29V)
2
GND
Ground connection
3
ENN
Enable input (active low)
4
DIR
Direction input for motor rotation
5
STEP
Step pulse input
6
UART
UART data input/output for configuration and diagnostics
7
V_IO
Logic voltage supply (3.3V or 5V)
8
MS1
Microstep resolution selection input 1
9
MS2
Microstep resolution selection input 2
10
DIAG
Diagnostic output (e.g., stall detection)
11-28
Various
Motor phase outputs, additional configuration, and power connections
Refer to the TMC2226 datasheet for a complete pinout and detailed descriptions.
Usage Instructions
How to Use the TMC2226 in a Circuit
Power Supply: Connect the motor power supply (V_M) to a voltage source between 4.75V and 29V. Ensure the logic voltage (V_IO) matches your microcontroller's logic level (3.3V or 5V).
Motor Connections: Connect the stepper motor's two coils to the appropriate motor phase output pins.
Control Signals: Use the STEP and DIR pins to control the motor's movement and direction. Optionally, configure microstepping using the MS1 and MS2 pins.
UART Configuration: For advanced features like StealthChop2™ or StallGuard4™, connect the UART pin to your microcontroller for communication.
Enable Pin: Pull the ENN pin low to enable the driver.
Important Considerations and Best Practices
Heat Dissipation: The TMC2226 can generate heat during operation. Use a heatsink or ensure proper ventilation to prevent overheating.
Microstepping: For smoother motor operation, configure the driver for higher microstepping resolutions (e.g., 1/16 or 1/256 steps).
Current Limiting: Set the motor current limit appropriately to avoid damaging the motor or driver.
Noise Reduction: Enable StealthChop2™ mode for ultra-quiet operation, especially in noise-sensitive applications.
Example: Using the TMC2226 with an Arduino UNO
Below is an example of how to control a stepper motor using the TMC2226 and an Arduino UNO:
// Include necessary libraries
#include <TMCStepper.h>

// Define TMC2226 pins
#define EN_PIN 8    // Enable pin
#define DIR_PIN 5   // Direction pin
#define STEP_PIN 6  // Step pin
#define SERIAL_PORT Serial  // UART communication port

// Define motor current (in milliamps)
#define R_SENSE 0.11  // Sense resistor value
TMC2226Stepper driver(&SERIAL_PORT, R_SENSE);  // Initialize driver

void setup() {
  pinMode(EN_PIN, OUTPUT);
  pinMode(DIR_PIN, OUTPUT);
  pinMode(STEP_PIN, OUTPUT);

  digitalWrite(EN_PIN, LOW);  // Enable the driver

  SERIAL_PORT.begin(115200);  // Initialize UART communication
  driver.begin();             // Initialize TMC2226
  driver.toff(5);             // Enable driver
  driver.rms_current(800);    // Set motor current to 800mA
  driver.microsteps(16);      // Set microstepping to 1/16
}

void loop() {
  digitalWrite(DIR_PIN, HIGH);  // Set direction
  for (int i = 0; i < 200; i++) {
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(1000);  // Step delay
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(1000);
  }
  delay(1000);  // Wait before changing direction

  digitalWrite(DIR_PIN, LOW);  // Reverse direction
  for (int i = 0; i < 200; i++) {
    digitalWrite(STEP_PIN, HIGH);
    delayMicroseconds(1000);
    digitalWrite(STEP_PIN, LOW);
    delayMicroseconds(1000);
  }
  delay(1000);
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Ensure the ENN pin is pulled low to enable the driver.
Verify the STEP and DIR signals are being sent correctly.
Check the motor connections and ensure the power supply is adequate.
Overheating:
Use a heatsink or improve ventilation around the driver.
Reduce the motor current limit using the UART interface or configuration pins.
Noisy Operation:
Enable StealthChop2™ mode for quieter operation.
Check for loose connections or mechanical issues with the motor.
Stall Detection Not Working:
Ensure StallGuard4™ is enabled and properly configured via UART.
Verify the motor current and load conditions are within the recommended range.
FAQs
Q: Can the TMC2226 operate without UART?
A: Yes, the TMC2226 can operate in standalone mode using the STEP, DIR, and microstepping pins. However, UART is required for advanced features like StealthChop2™ and StallGuard4™.
Q: What is the maximum microstepping resolution?
A: The TMC2226 supports up to 1/256 microstepping for ultra-smooth motor operation.
Q: How do I set the motor current limit?
A: The motor current limit can be set via UART or by adjusting the sense resistor value (R_SENSE).
Q: Is the TMC2226 compatible with 5V logic?
A: Yes, the TMC2226 supports both 3.3V and 5V logic levels for compatibility with a wide range of microcontrollers.

 Open Project in Cirkit Designer