The Polulu N20 Motor is a small, high-torque DC motor designed for robotics and automation applications. Its compact size and availability in various gear ratios make it a versatile choice for projects requiring precise control of speed and torque. This motor is widely used in robotics, small vehicles, and other applications where space is limited but reliable performance is essential.
Explore Projects Built with Polulu N20 Motor
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
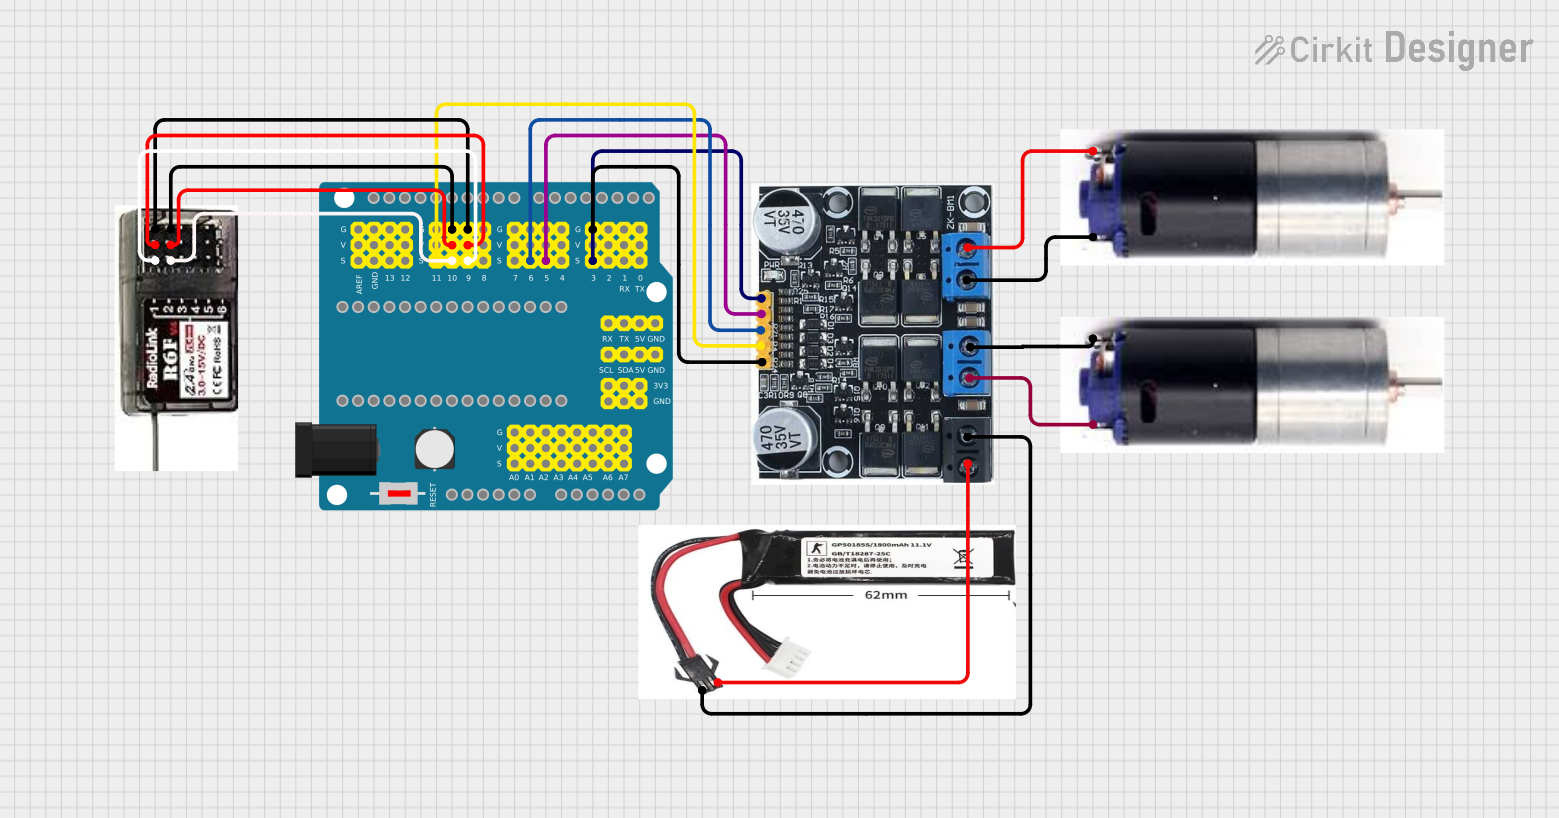
This circuit is designed to control two GM25 DC motors using a ZK-BM1 10A motor driver, which is managed by a NANO Shield Board. The NANO Shield Board receives input signals from an R6FG receiver and is powered by an 11.1V LiPo battery.
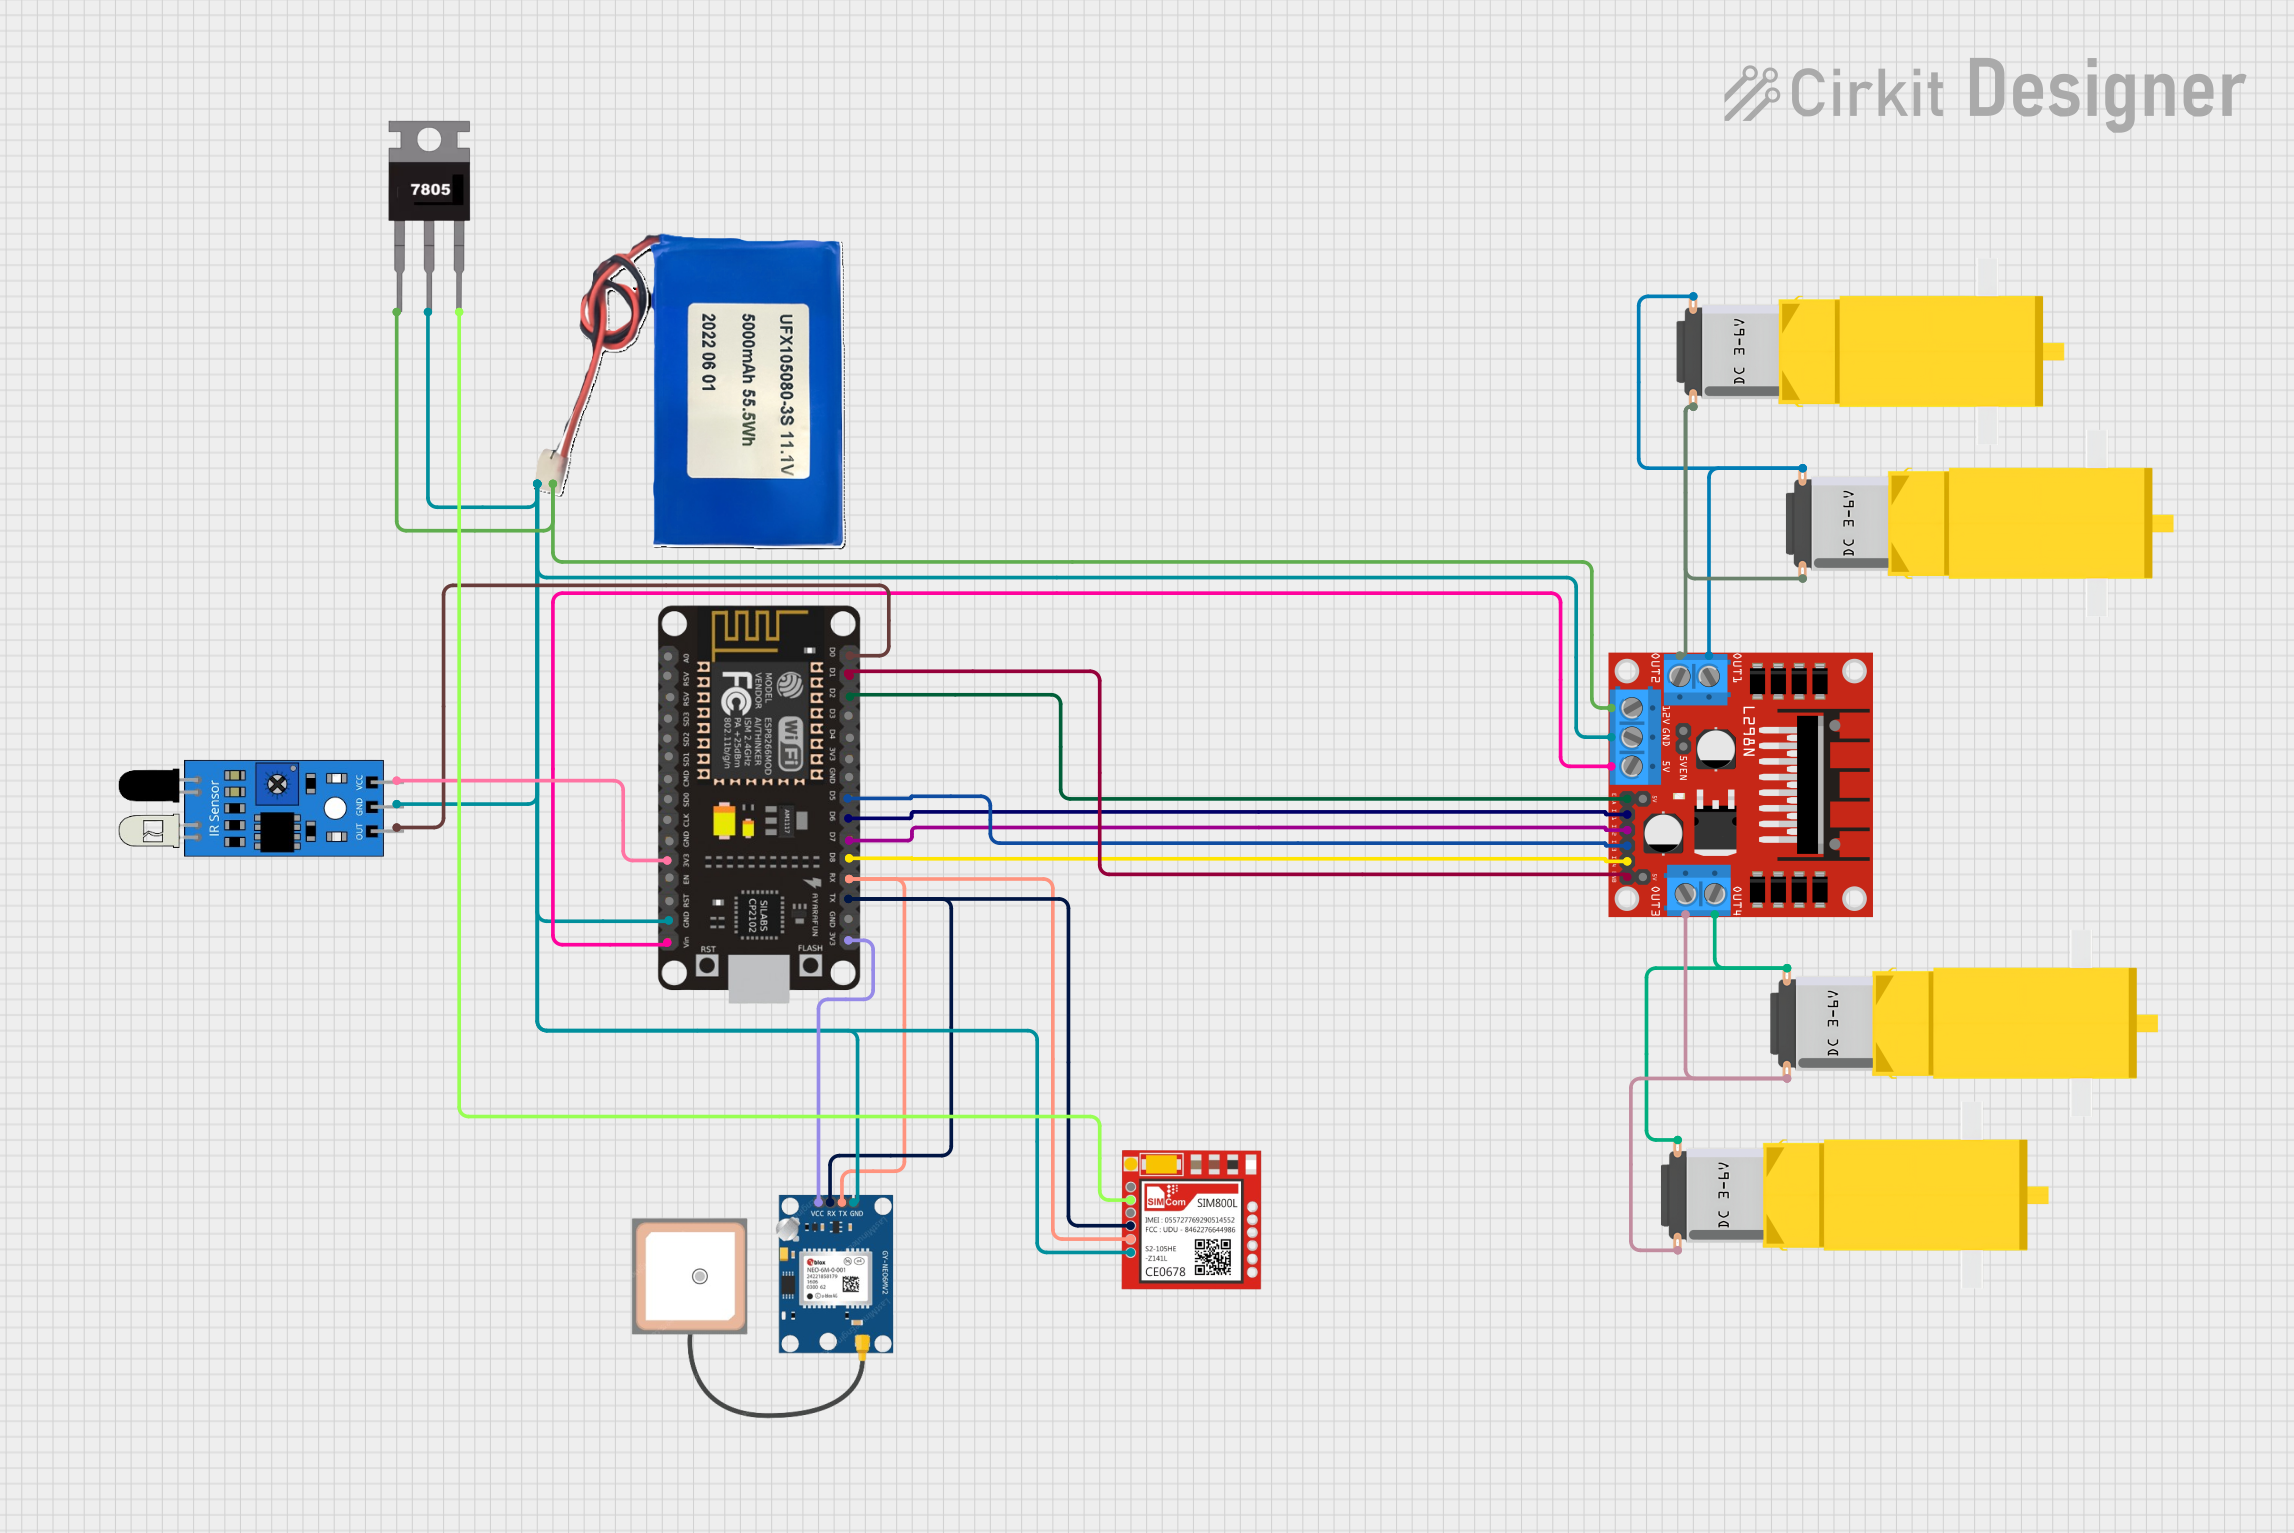
This circuit is designed for a 4-wheeled WiFi-controlled car with a basket, which uses an ESP8266 NodeMCU microcontroller for logic control. It features an IR sensor for basket full detection, a GPS module for location tracking, and a GSM module (Sim800l) for sending SMS notifications. The L298N motor driver controls four DC gearmotors for movement, and the system is powered by a Li-ion battery with a 7805 voltage regulator providing stable power to the GSM module.
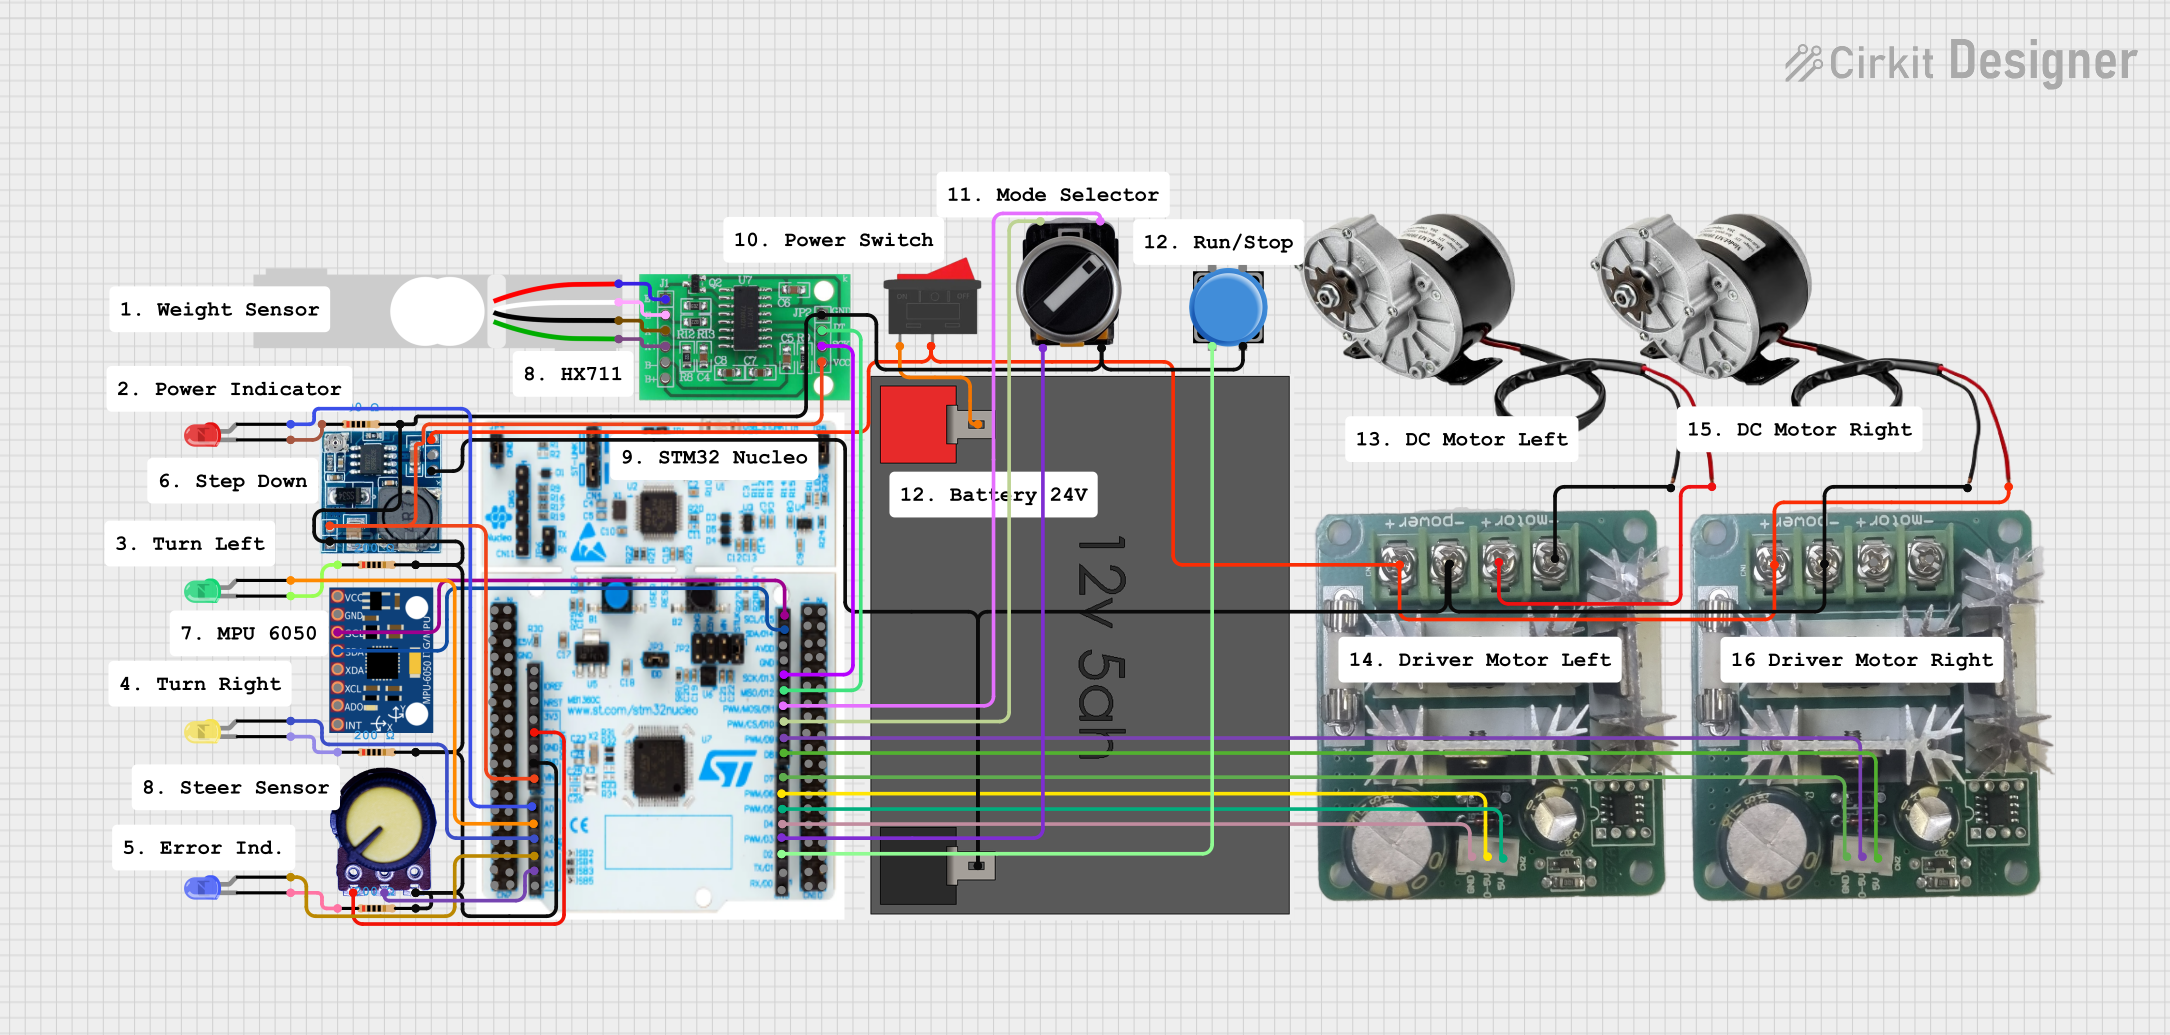
This circuit is a self-balancing scooter system that uses an MPU-6050 sensor to detect tilt and control two DC motors via PWM motor controllers to maintain balance. The STM32 Nucleo F303RE microcontroller processes the sensor data and adjusts the motor speeds accordingly. Additional components include a potentiometer, LEDs for status indication, and a load cell interface for potential weight measurement.
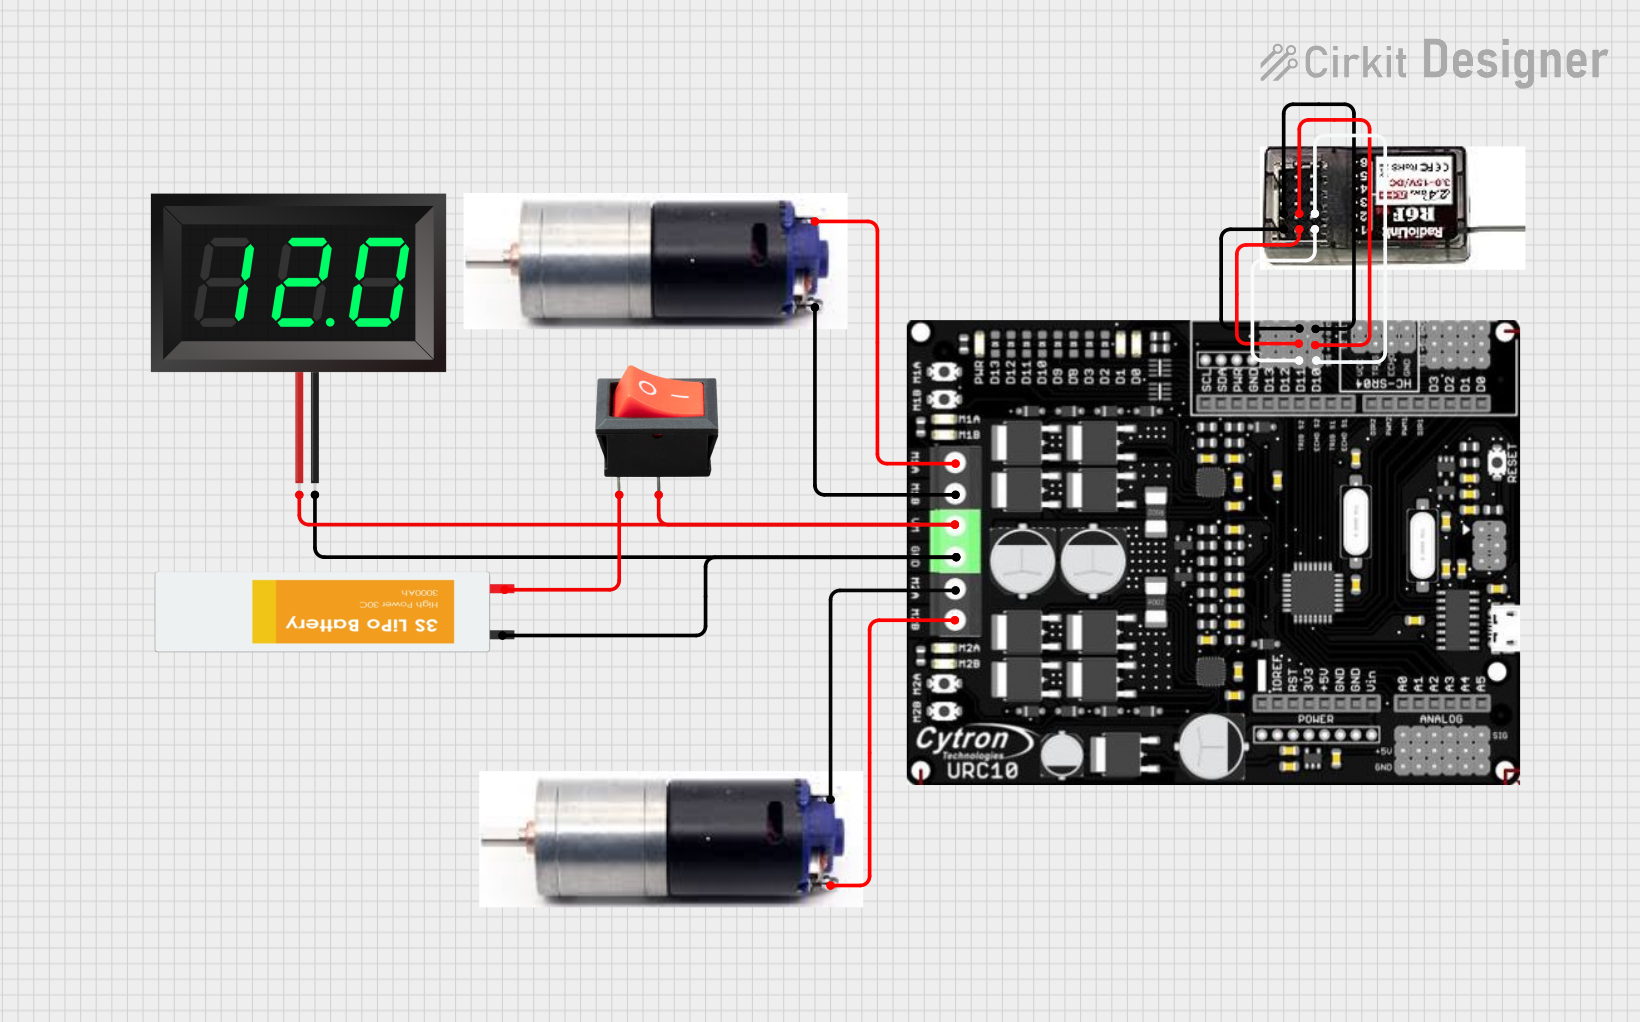
This circuit is a remote-controlled dual DC motor driver system powered by a 3S LiPo battery. It uses a Cytron URC10 motor driver to control two GM25 DC motors based on signals received from an R6FG receiver, with a rocker switch for power control and a 7-segment panel voltmeter for monitoring the battery voltage.
Automated systems (e.g., conveyor belts, small mechanisms)
DIY projects (e.g., RC cars, robotic arms)
Educational kits and prototyping
Technical Specifications
Below are the key technical details for the Polulu N20 Motor. Note that specific values may vary depending on the gear ratio and model variant.
General Specifications
Manufacturer Part ID: Polulu N20 Motor
Operating Voltage: 3V to 12V (recommended: 6V)
No-Load Speed: 30 RPM to 1000 RPM (depending on gear ratio)
Stall Torque: Up to 1.5 kg·cm (varies by model)
Stall Current: ~1.5A (at 6V)
No-Load Current: ~40mA (at 6V)
Motor Dimensions: 12mm x 10mm x 26mm (excluding shaft)
Shaft Diameter: 3mm
Weight: ~10g
Pin Configuration and Descriptions
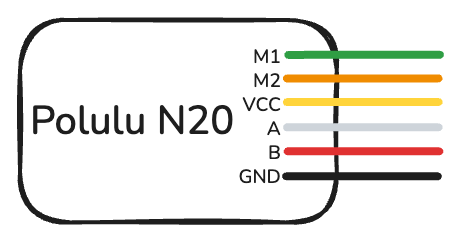
The Polulu N20 Motor has two terminals for electrical connections. These terminals are not polarized, meaning the motor's direction of rotation depends on the polarity of the applied voltage.
Pin
Description
Pin 1
Positive terminal (V+)
Pin 2
Negative terminal (GND)
Usage Instructions
How to Use the Polulu N20 Motor in a Circuit
Power Supply: Connect the motor to a DC power source within the operating voltage range (3V to 12V). A 6V power supply is recommended for optimal performance.
Polarity Control: To control the direction of rotation, reverse the polarity of the voltage applied to the motor terminals.
Motor Driver: For precise control (e.g., speed and direction), use an H-bridge motor driver such as the L298N or L293D. These drivers allow you to interface the motor with microcontrollers like Arduino.
PWM Control: Use Pulse Width Modulation (PWM) to control the motor's speed. This can be achieved by connecting the motor driver to a microcontroller's PWM-capable pin.
Example: Connecting the Polulu N20 Motor to an Arduino UNO
Below is an example of how to control the Polulu N20 Motor using an Arduino UNO and an L298N motor driver.
Circuit Connections
Connect the motor terminals to the output pins of the L298N motor driver (e.g., OUT1 and OUT2).
Connect the L298N's input pins (e.g., IN1 and IN2) to Arduino digital pins (e.g., D9 and D10).
Connect the L298N's enable pin (e.g., ENA) to an Arduino PWM pin (e.g., D5).
Provide power to the motor driver and Arduino.
Arduino Code
// Define motor control pins
const int motorPin1 = 9; // IN1 on L298N
const int motorPin2 = 10; // IN2 on L298N
const int enablePin = 5; // ENA on L298N (PWM pin)

void setup() {
  // Set motor control pins as outputs
  pinMode(motorPin1, OUTPUT);
  pinMode(motorPin2, OUTPUT);
  pinMode(enablePin, OUTPUT);
}

void loop() {
  // Rotate motor forward
  digitalWrite(motorPin1, HIGH); // Set IN1 high
  digitalWrite(motorPin2, LOW);  // Set IN2 low
  analogWrite(enablePin, 128);   // Set speed (0-255)

  delay(2000); // Run motor for 2 seconds

  // Rotate motor backward
  digitalWrite(motorPin1, LOW);  // Set IN1 low
  digitalWrite(motorPin2, HIGH); // Set IN2 high
  analogWrite(enablePin, 128);   // Set speed (0-255)

  delay(2000); // Run motor for 2 seconds

  // Stop motor
  digitalWrite(motorPin1, LOW);  // Set IN1 low
  digitalWrite(motorPin2, LOW);  // Set IN2 low
  analogWrite(enablePin, 0);     // Set speed to 0

  delay(2000); // Wait for 2 seconds
}
Important Considerations
Current Limiting: Ensure your power supply or motor driver can handle the stall current (~1.5A) to avoid damage.
Heat Management: Prolonged operation at high loads may cause the motor to overheat. Allow cooling periods if necessary.
Gear Ratio Selection: Choose a gear ratio that balances speed and torque for your application.
Troubleshooting and FAQs
Common Issues
Motor Does Not Spin
Cause: Insufficient voltage or loose connections.
Solution: Verify the power supply voltage and ensure all connections are secure.
Motor Spins in the Wrong Direction
Cause: Incorrect polarity of the applied voltage.
Solution: Reverse the connections to the motor terminals.
Motor Overheats
Cause: Prolonged operation at high loads or stall conditions.
Solution: Reduce the load or allow the motor to cool periodically.
Motor Vibrates but Does Not Rotate
Cause: Gearbox damage or obstruction.
Solution: Inspect the gearbox for debris or damage and clean/replace as needed.
FAQs
Can I run the motor directly from an Arduino pin?
No, the Arduino cannot supply enough current to drive the motor. Use a motor driver or external power source.
What is the maximum load the motor can handle?
The maximum load depends on the gear ratio and operating voltage. Refer to the stall torque specification for your specific model.
Can I use the motor with a battery?
Yes, the motor can be powered by batteries within the operating voltage range. Ensure the battery can supply sufficient current.
How do I choose the right gear ratio?
Higher gear ratios provide more torque but lower speed, while lower gear ratios provide higher speed but less torque. Select based on your application's requirements.

 Open Project in Cirkit Designer