Cirkit Designer LogoCirkit DesignerYour all-in-one circuit design IDE Launch Cirkit Designer App

How to Use MPU6050: Examples, Pinouts, and Specs

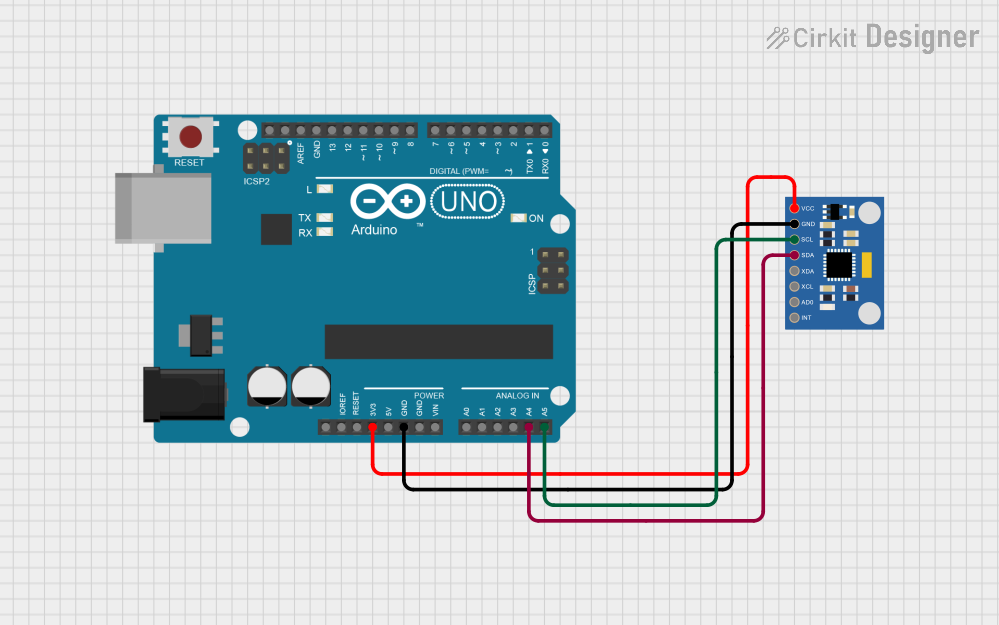
Image of MPU6050Design with MPU6050 in Cirkit Designer

Introduction

The MPU6050 is a 6-axis motion tracking device that integrates a 3-axis gyroscope and a 3-axis accelerometer into a single chip. This compact and versatile sensor is widely used in applications requiring motion sensing and orientation detection. Its ability to measure angular velocity and linear acceleration makes it ideal for robotics, drones, gaming devices, and mobile applications. Additionally, the MPU6050 features a Digital Motion Processor (DMP) that can process complex motion algorithms on-chip, reducing the computational load on the host microcontroller.

Explore Projects Built with MPU6050

Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
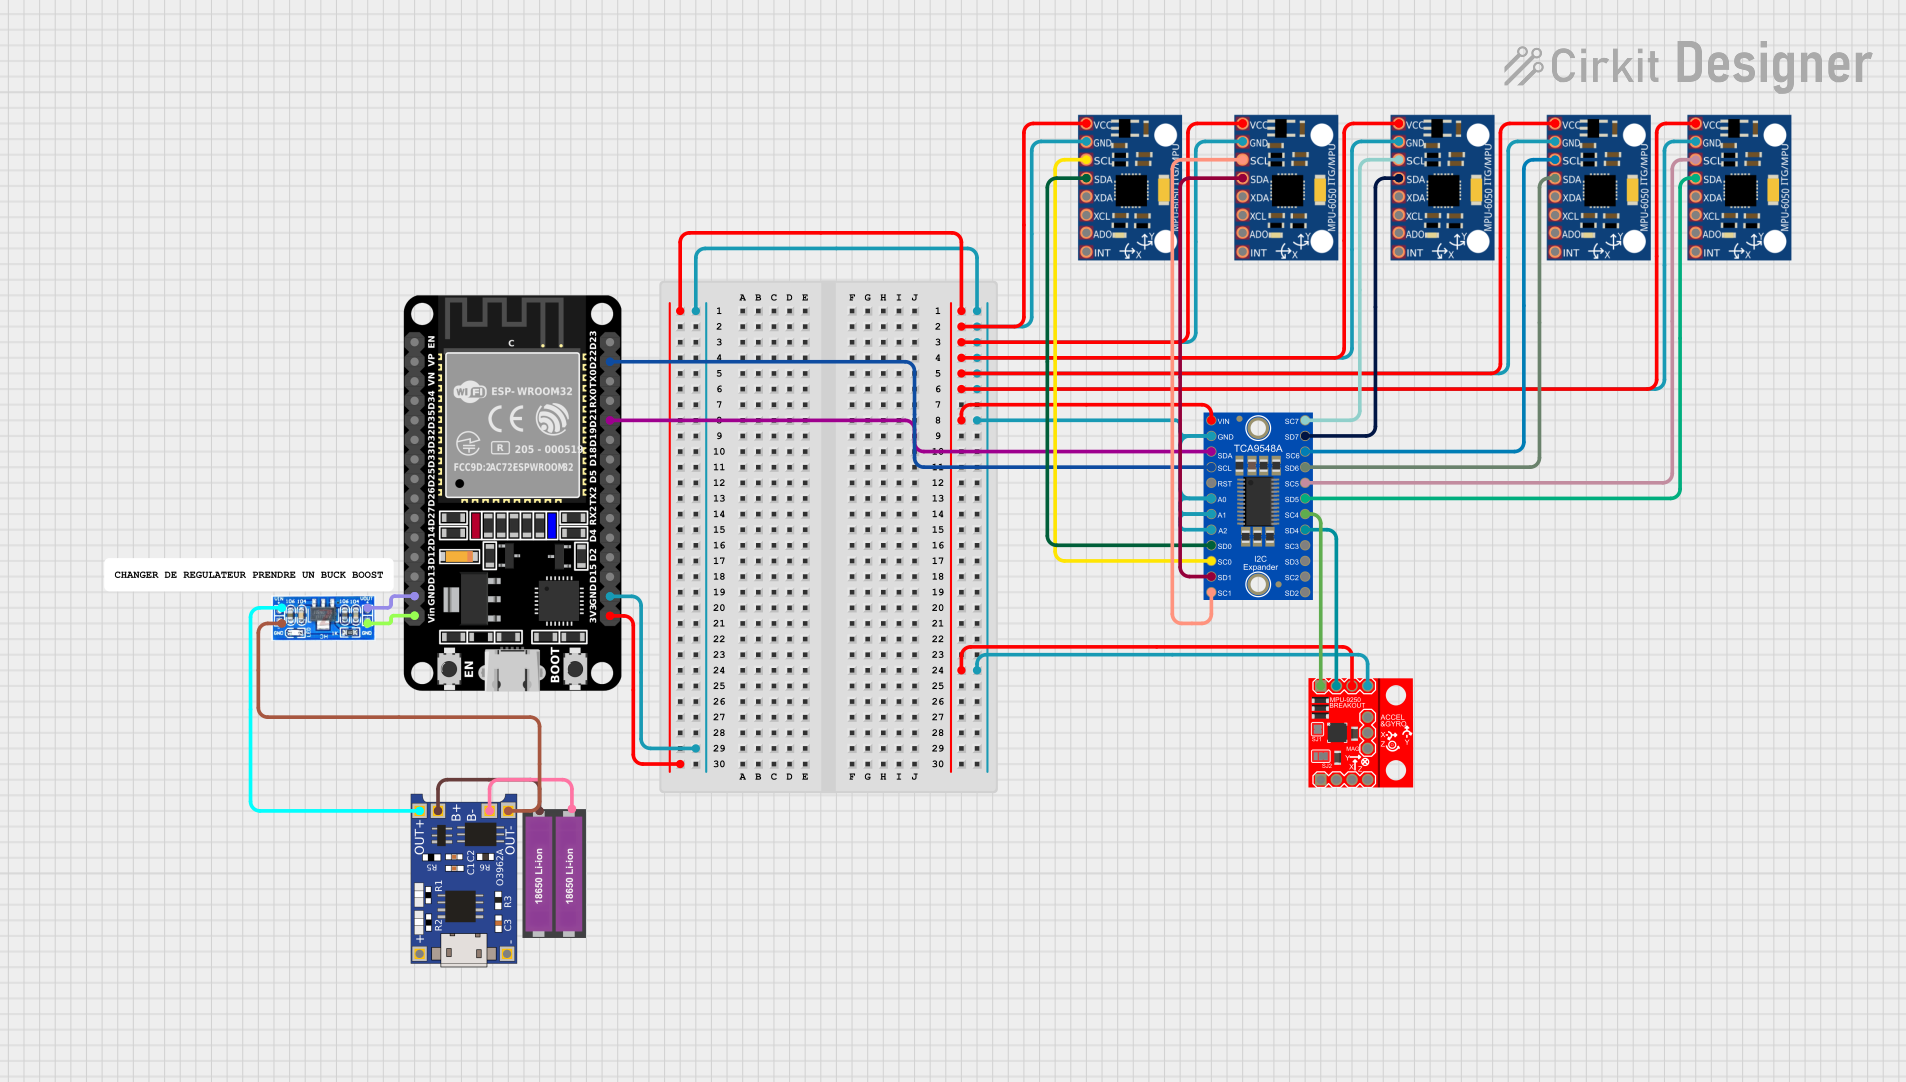
Image of ESP32-Controlled Multi-MPU6050 and MPU9250 IMU Data Aggregator: A project utilizing MPU6050 in a practical application

ESP32-Controlled Multi-MPU6050 and MPU9250 IMU Data Aggregator

This circuit features an ESP32 microcontroller interfaced with multiple MPU-6050 sensors and a single MPU-9250 sensor through an Adafruit TCA9548A I2C multiplexer, allowing for the reading of multiple inertial measurement units (IMUs) over the same I2C bus. The ESP32 collects and processes acceleration and gyroscopic data from the sensors to calculate angles in the X and Y axes. Power management is handled by a TP4056 charging module and an AMS1117 voltage regulator, which together with two 18650 Li-ion batteries, provide a stable power supply for the microcontroller and sensors.

Open Project in Cirkit Designer
Technical Specifications

The following are the key technical details of the MPU6050:

Pin Configuration and Descriptions

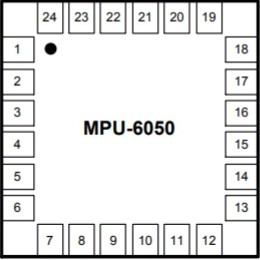
The MPU6050 has 8 primary pins for operation. Below is the pinout description:

Pin Name Description
1 VCC Power supply input (2.375V to 3.46V, typically 3.3V).
2 GND Ground connection.
3 SCL I2C clock line. Connect to the microcontroller's I2C clock pin.
4 SDA I2C data line. Connect to the microcontroller's I2C data pin.
5 AD0 I2C address select. Connect to GND (address 0x68) or VCC (address 0x69).
6 INT Interrupt output. Used to signal data availability or motion detection events.
7 FSYNC Frame synchronization input. Optional, typically left unconnected.
8 RESV Reserved. Do not connect.

Usage Instructions

How to Use the MPU6050 in a Circuit

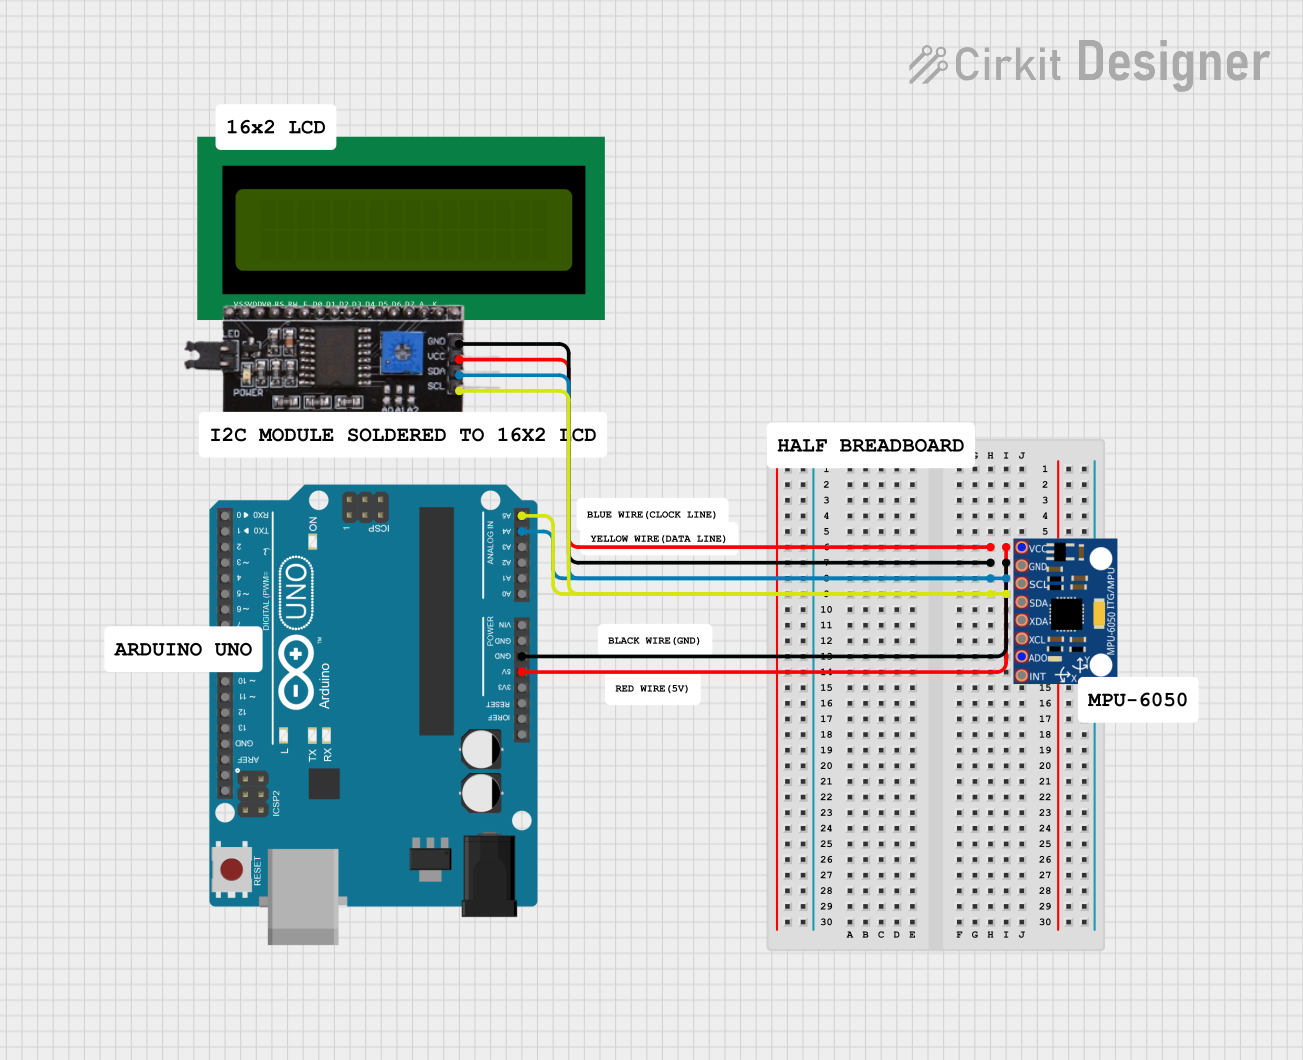
  1. Power Supply: Connect the VCC pin to a 3.3V power source and the GND pin to ground.
  2. I2C Communication: Connect the SCL and SDA pins to the corresponding I2C pins on your microcontroller. Use pull-up resistors (typically 4.7kΩ) on both lines if not already present on your board.
  3. I2C Address Selection: Set the AD0 pin to GND for the default I2C address (0x68) or to VCC for the alternate address (0x69).
  4. Interrupts (Optional): Connect the INT pin to a digital input pin on your microcontroller if you want to use interrupt-driven data reading.

Important Considerations and Best Practices

Example Code for Arduino UNO

Below is an example of how to interface the MPU6050 with an Arduino UNO using the I2C protocol:

#include <Wire.h>

// MPU6050 I2C address (default is 0x68 when AD0 is connected to GND)
const int MPU6050_ADDR = 0x68;

// MPU6050 register addresses
const int PWR_MGMT_1 = 0x6B; // Power management register
const int ACCEL_XOUT_H = 0x3B; // Accelerometer X-axis high byte

void setup() {
  Wire.begin(); // Initialize I2C communication
  Serial.begin(9600); // Start serial communication for debugging

  // Wake up the MPU6050 (it starts in sleep mode)
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(PWR_MGMT_1); // Access power management register
  Wire.write(0); // Set to 0 to wake up the sensor
  Wire.endTransmission();

  Serial.println("MPU6050 initialized");
}

void loop() {
  // Request accelerometer data
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(ACCEL_XOUT_H); // Start reading at ACCEL_XOUT_H register
  Wire.endTransmission(false); // Send repeated start condition
  Wire.requestFrom(MPU6050_ADDR, 6); // Request 6 bytes (X, Y, Z high and low)

  if (Wire.available() == 6) {
    int16_t accelX = (Wire.read() << 8) | Wire.read(); // Combine high and low bytes
    int16_t accelY = (Wire.read() << 8) | Wire.read();
    int16_t accelZ = (Wire.read() << 8) | Wire.read();

    // Print accelerometer values
    Serial.print("Accel X: "); Serial.print(accelX);
    Serial.print(" | Accel Y: "); Serial.print(accelY);
    Serial.print(" | Accel Z: "); Serial.println(accelZ);
  }

  delay(500); // Wait 500ms before the next reading
}

Troubleshooting and FAQs

Common Issues

  1. No Data from the Sensor:

    • Ensure the MPU6050 is powered correctly (3.3V on VCC and GND connected).
    • Verify the I2C connections (SCL and SDA) and check for proper pull-up resistors.
    • Confirm the I2C address (0x68 or 0x69) matches your configuration.
  2. Inconsistent or Noisy Readings:

    • Check for physical vibrations or shocks affecting the sensor.
    • Use software filtering or the DMP for more stable readings.
    • Ensure proper grounding and decoupling capacitors are in place.
  3. I2C Communication Errors:

    • Verify the I2C clock speed (should not exceed 400kHz).
    • Check for loose or incorrect wiring.

FAQs