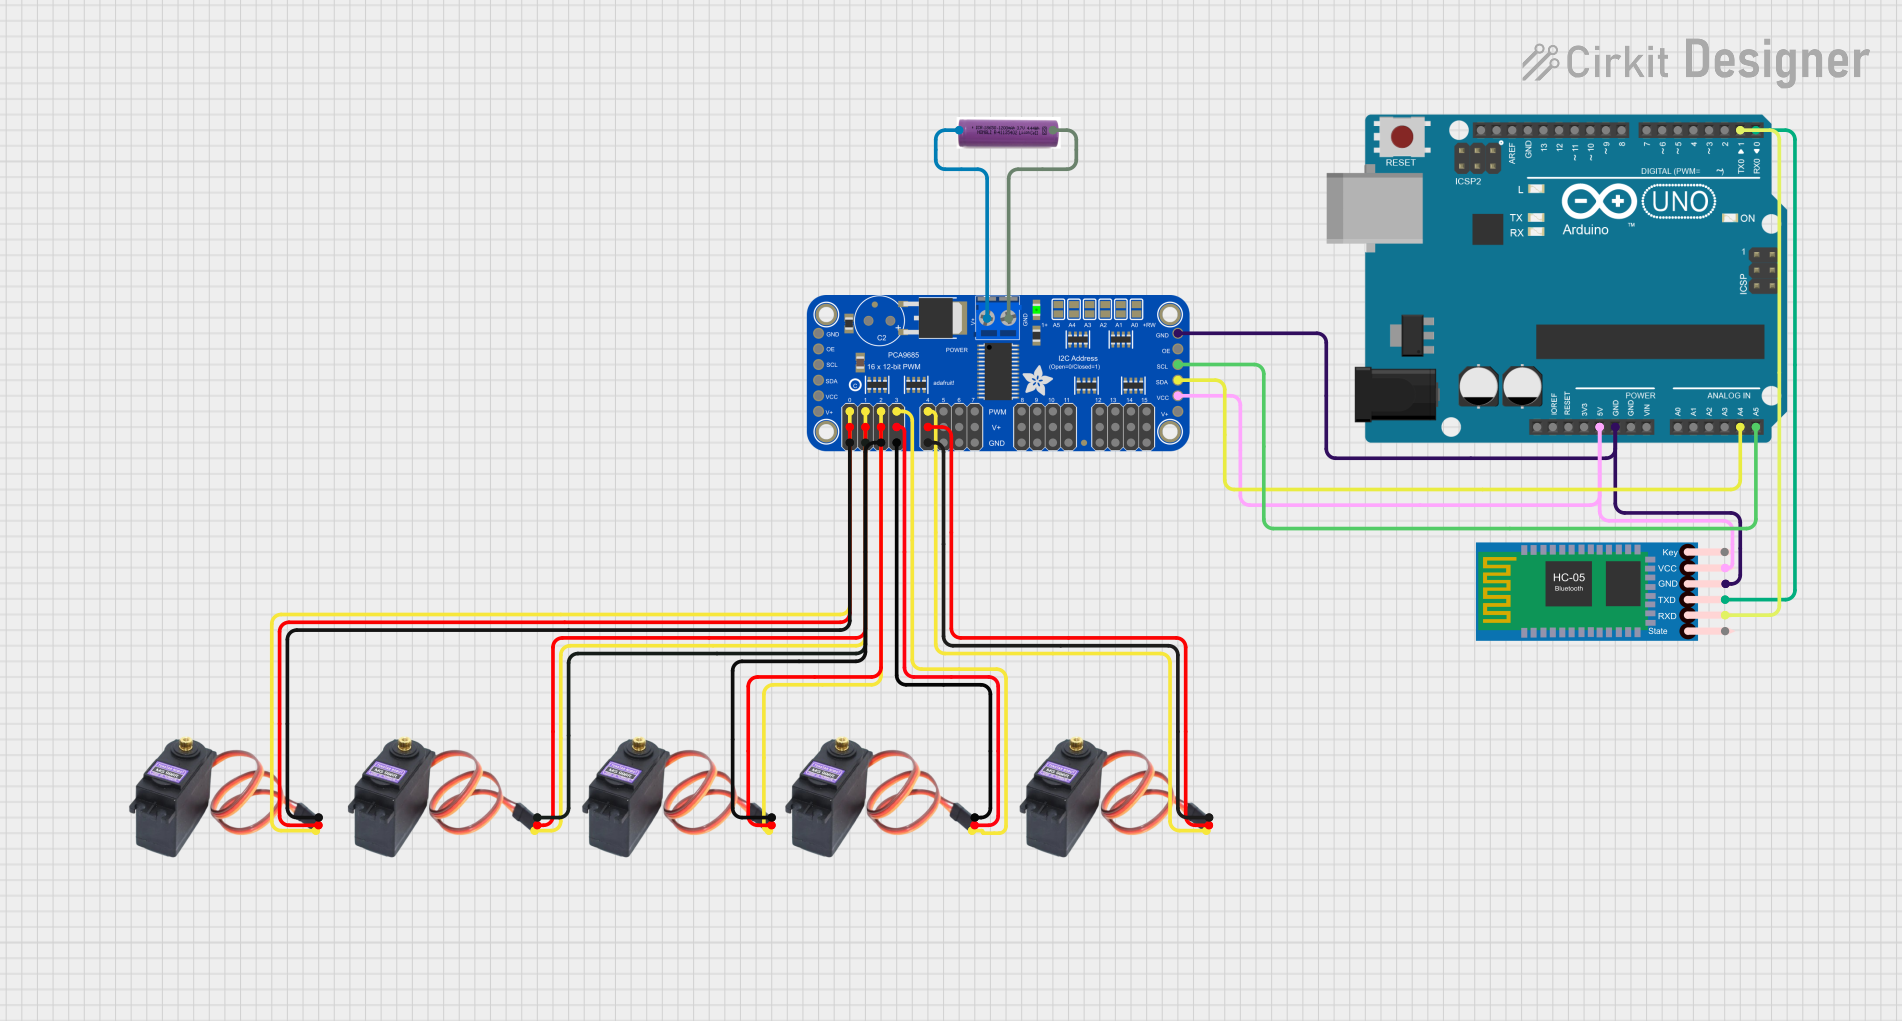
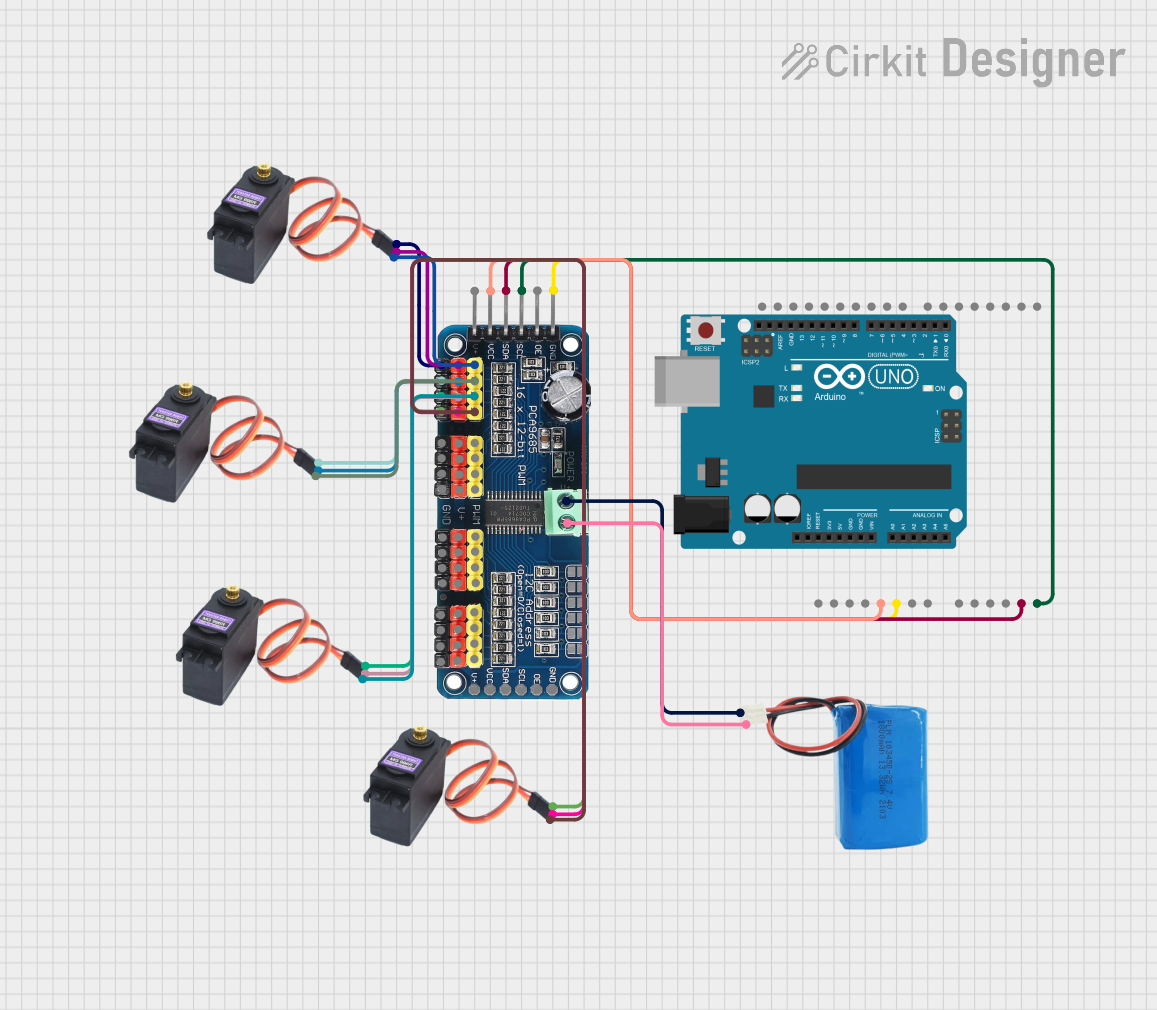
Introduction
The MG996R is a high-torque servo motor widely used in robotics, remote-controlled (RC) vehicles, and other applications requiring precise angular position control. It features a durable metal gear train, making it suitable for high-stress environments. With its wide operating voltage range and robust design, the MG996R is a reliable choice for both hobbyists and professionals.
Common Applications
- Robotic arms and grippers
- RC cars, boats, and planes
- Pan-tilt camera mounts
- Automated mechanisms requiring angular motion control
Technical Specifications
Key Specifications
Pin Configuration
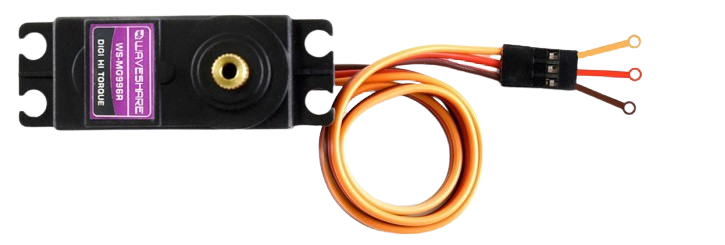
The MG996R servo motor has a 3-pin connector. The pinout is as follows:
Usage Instructions
Connecting the MG996R to a Circuit
- Power Supply: Connect the red wire to a power source (4.8V to 7.2V). Ensure the power supply can provide sufficient current (at least 2A) to handle the servo's peak load.
- Ground: Connect the brown wire to the ground (GND) of your circuit.
- Signal: Connect the orange wire to the PWM output pin of your microcontroller (e.g., Arduino).
Important Considerations
- Power Requirements: The MG996R can draw significant current, especially under load. Use a dedicated power source or a capacitor to stabilize the voltage.
- PWM Signal: The servo expects a PWM signal with a pulse width between 500µs (0°) and 2500µs (180°). A 1500µs pulse corresponds to the neutral position (90°).
- Avoid Overloading: Prolonged stalling or overloading can damage the motor or cause overheating.
Example: Using MG996R with Arduino UNO
Below is an example code to control the MG996R servo motor using an Arduino UNO:
#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object to control the MG996R

void setup() {
  myServo.attach(9); // Attach the servo signal pin to Arduino pin 9
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000);      // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000);       // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000);        // Wait for 1 second
}
Best Practices
- Use a separate power supply for the servo to avoid voltage drops on the microcontroller.
- Add a decoupling capacitor (e.g., 1000µF) across the power supply to smooth out voltage fluctuations.
- Avoid sudden, large movements to reduce stress on the servo and extend its lifespan.
Troubleshooting and FAQs
Common Issues and Solutions
Servo Not Moving:
- Cause: Incorrect wiring or insufficient power supply.
- Solution: Double-check the connections and ensure the power supply meets the voltage and current requirements.
Servo Jitters or Vibrations:
- Cause: Noise in the PWM signal or unstable power supply.
- Solution: Use a decoupling capacitor and ensure the PWM signal is clean and within the specified range.
Overheating:
- Cause: Prolonged stalling or excessive load.
- Solution: Reduce the load on the servo or allow it to cool down periodically.
Limited Range of Motion:
- Cause: Incorrect PWM pulse width or mechanical obstruction.
- Solution: Verify the PWM signal and ensure there are no physical obstructions.
FAQs
Q: Can I power the MG996R directly from the Arduino?
A: It is not recommended. The MG996R can draw more current than the Arduino can supply, especially under load. Use an external power source.
Q: What is the maximum angle the MG996R can rotate?
A: The MG996R can rotate up to 180°, controlled by a PWM signal.
Q: Can I use the MG996R for continuous rotation?
A: No, the MG996R is designed for positional control, not continuous rotation. For continuous rotation, use a servo specifically designed for that purpose.
Q: How do I prevent the servo from overheating?
A: Avoid overloading the servo and ensure it is not stalled for extended periods. Use proper cooling if necessary.

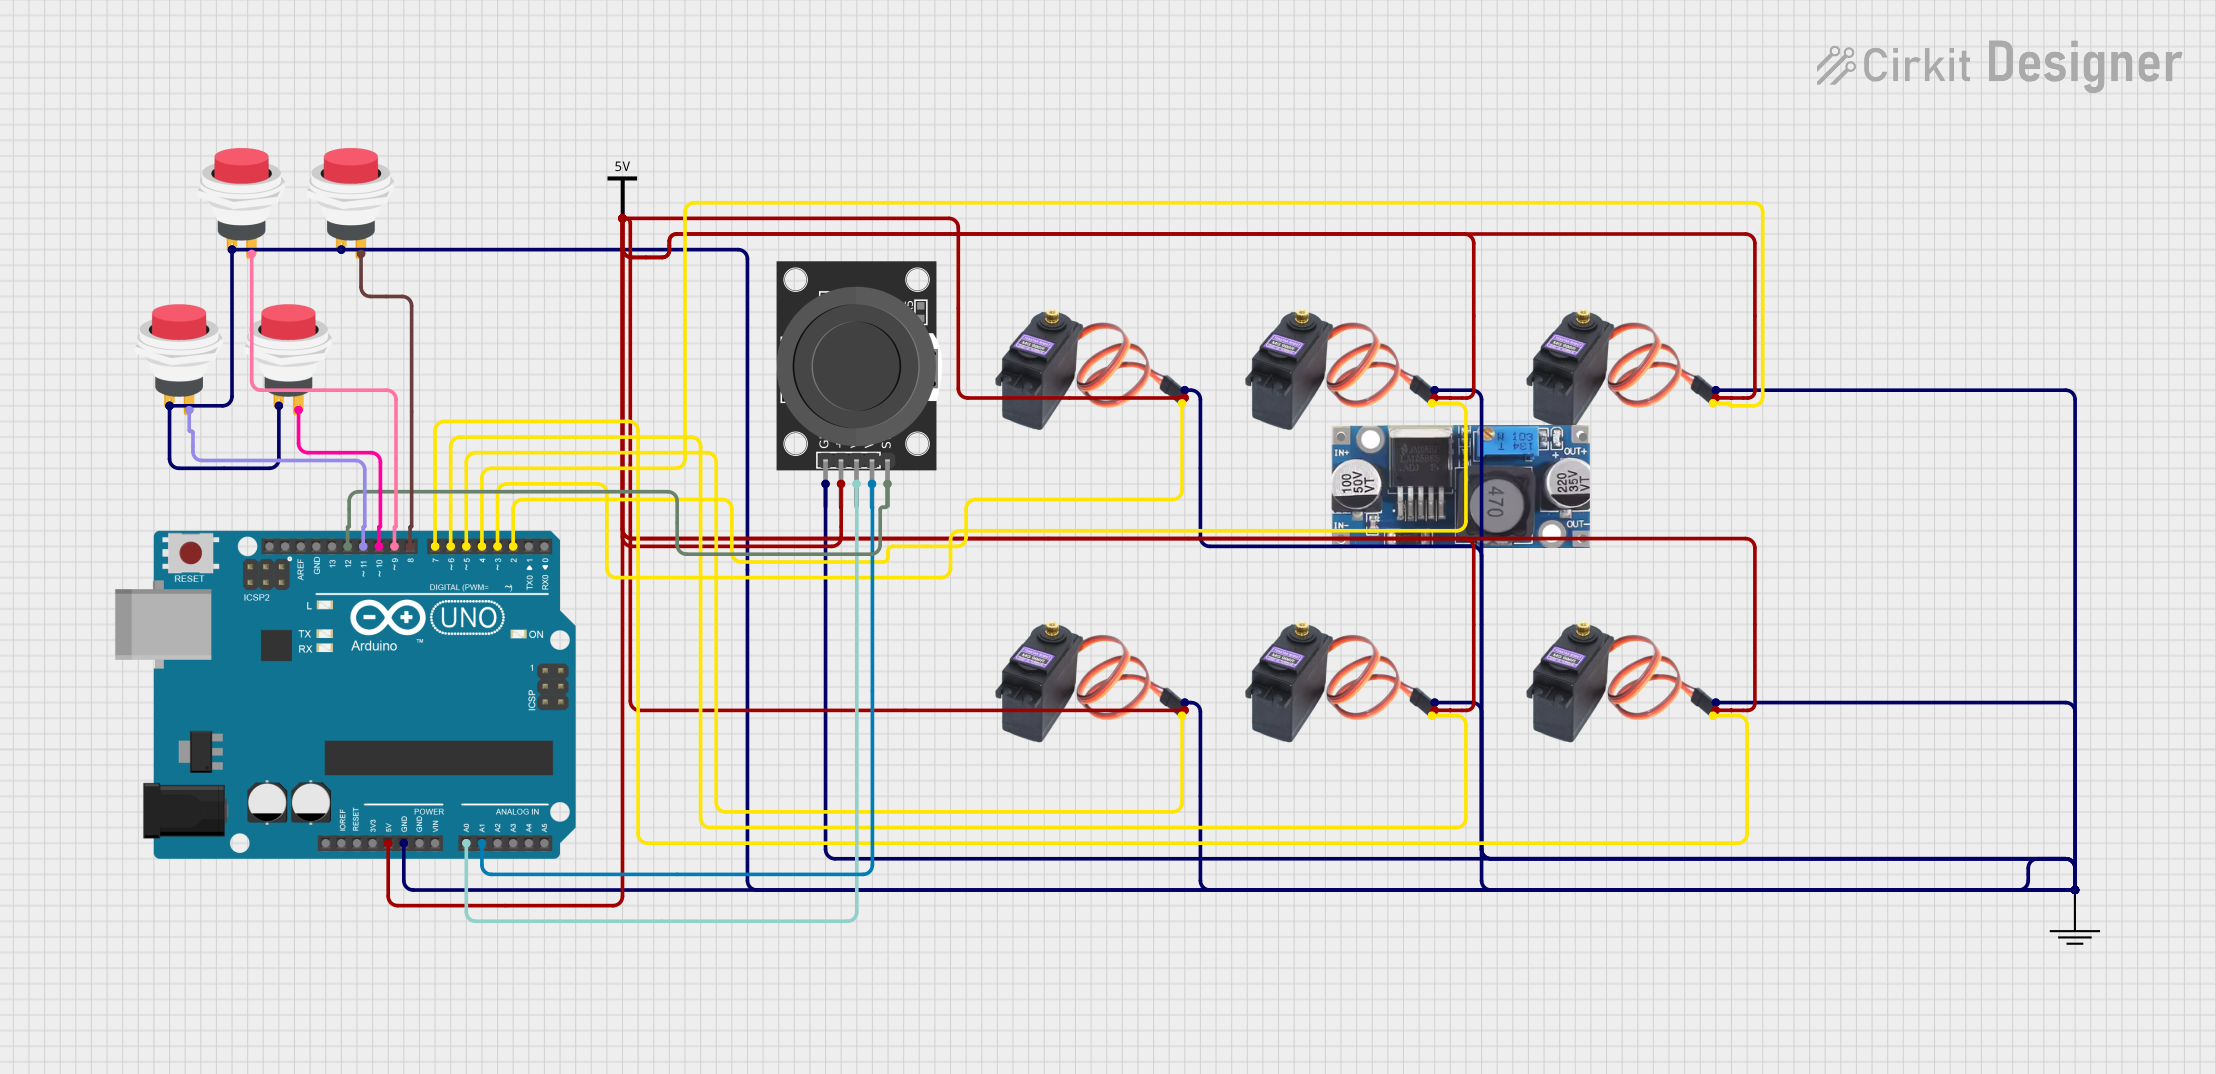
 Open Project in Cirkit Designer