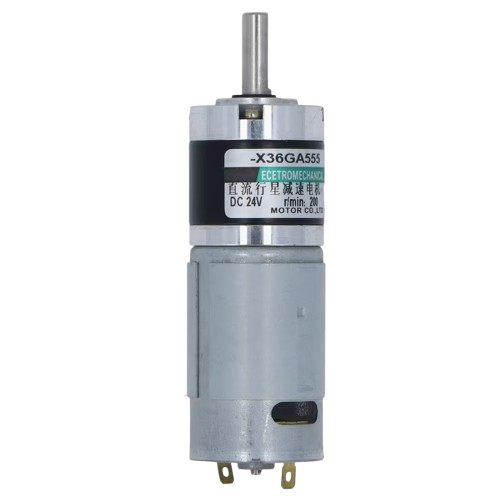
The MRB Planetary Gearbox Motor is a high-performance motor integrated with a planetary gearbox. This design provides a compact and efficient solution for applications requiring high torque, precise speed control, and accurate positioning. The planetary gearbox ensures uniform load distribution, high power density, and reduced backlash, making it ideal for demanding tasks.
Explore Projects Built with MRB Planetary gearbox motor
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
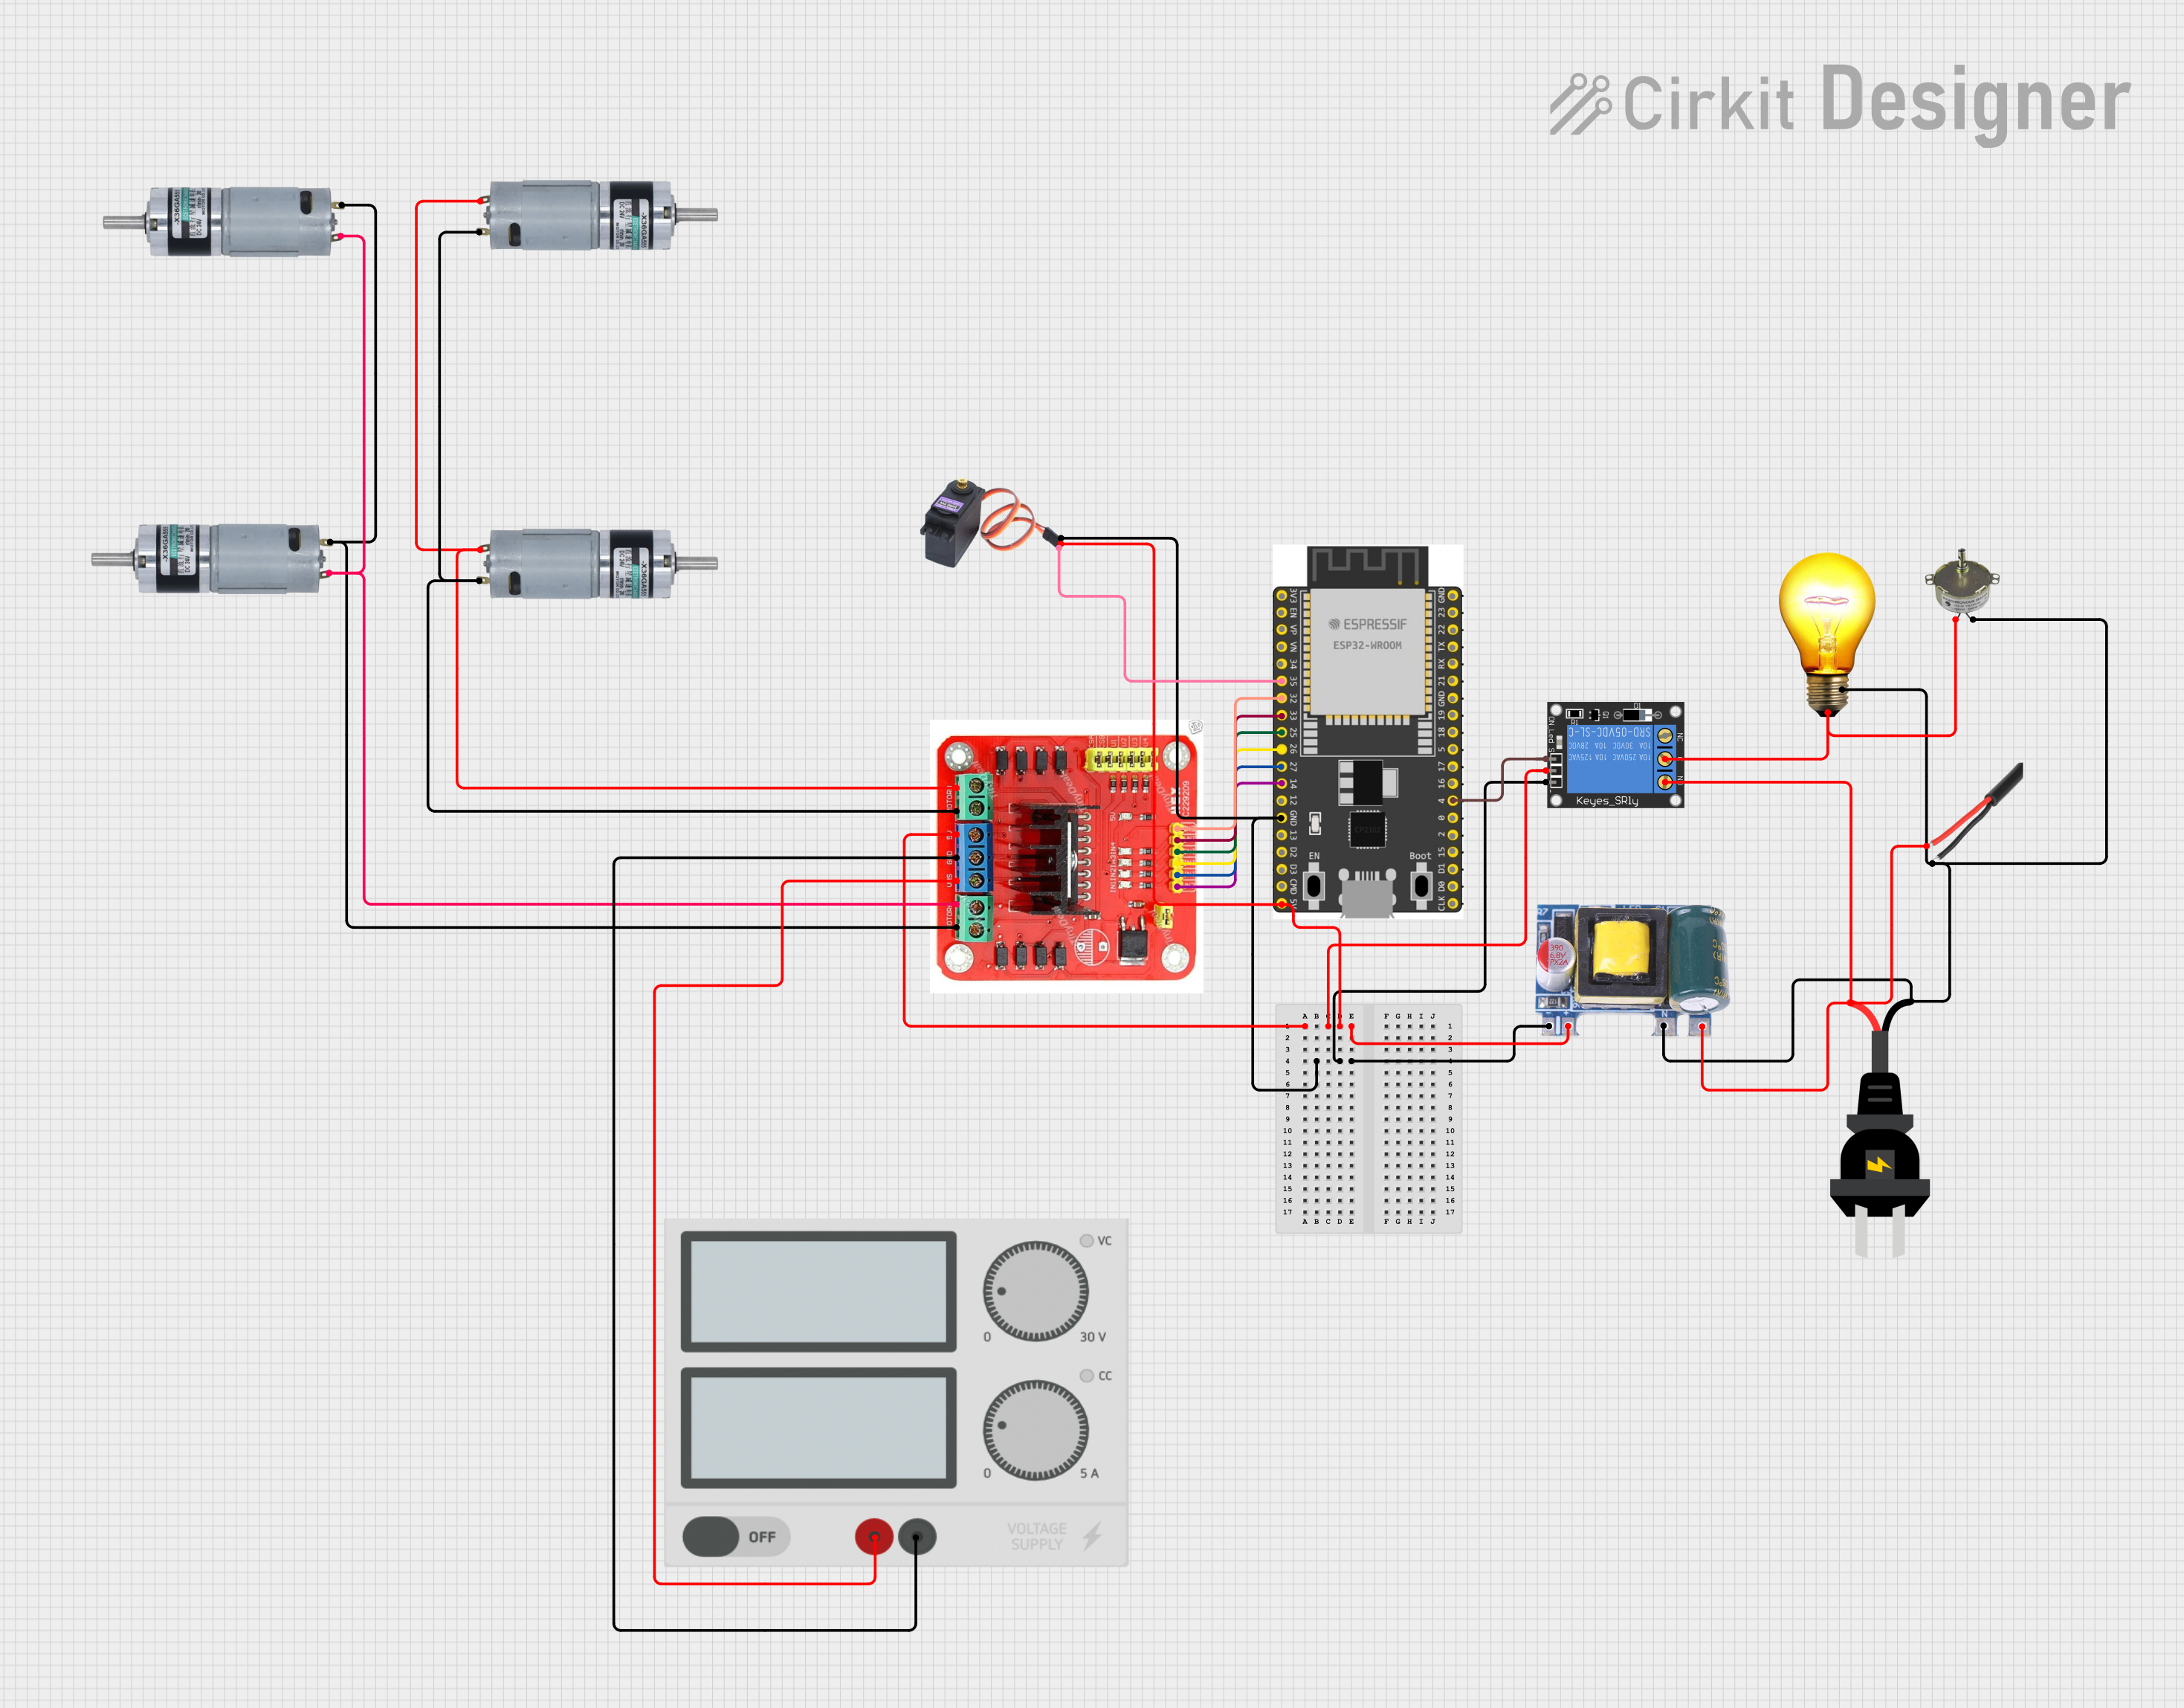
This circuit controls a set of MRB Planetary gearbox motors and an AC synchronous motor using an ESP32 microcontroller. The ESP32 interfaces with an L298N Dual H Bridge for motor control and a 1-Channel Relay to switch an AC bulb and the AC synchronous motor. A Mini AC-DC module provides 5V power to the ESP32, the relay, and the servo motor (MG996R), while the main power supply drives the L298N and the gearbox motors.
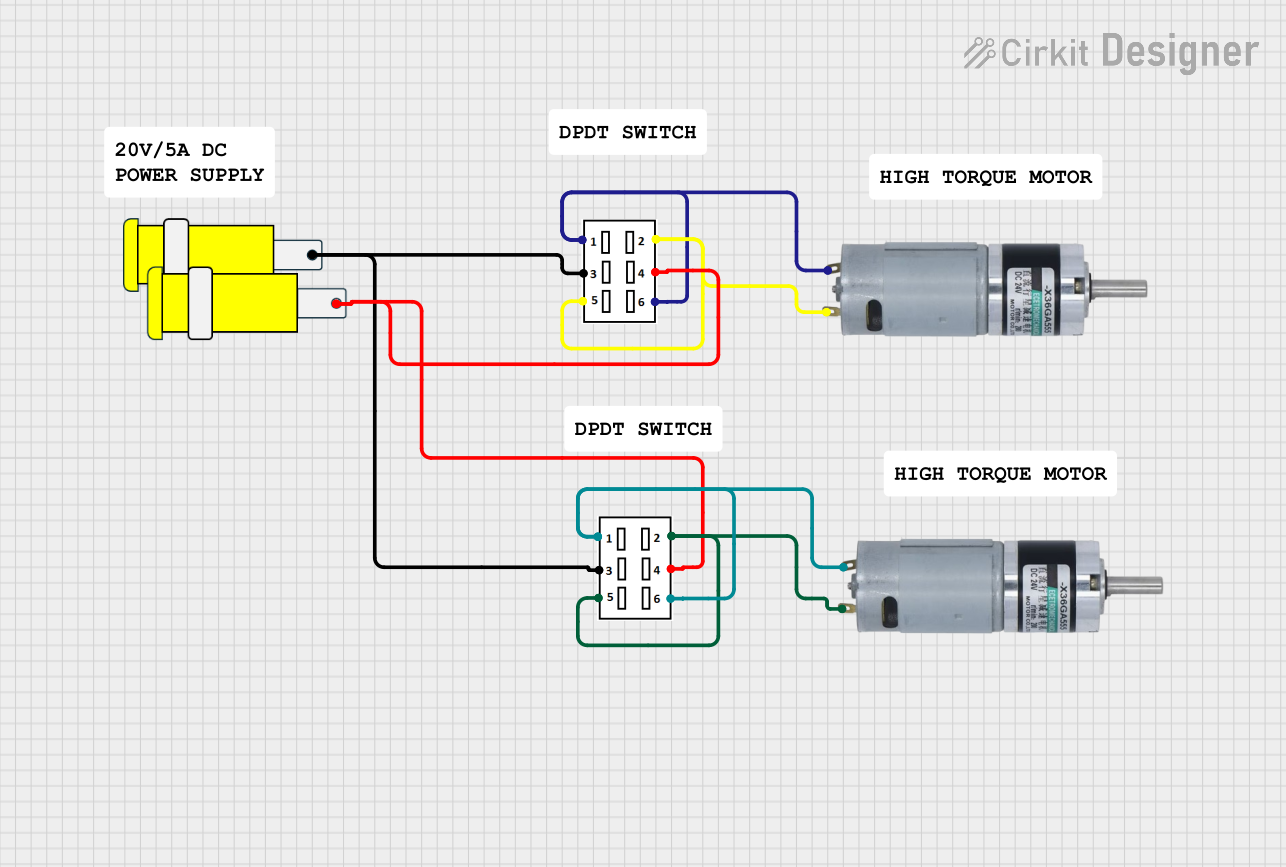
This circuit features two DPDT switches that control the direction of two MRB Planetary gearbox motors. The switches are connected to a connector, allowing for external control inputs to change the motor directions.
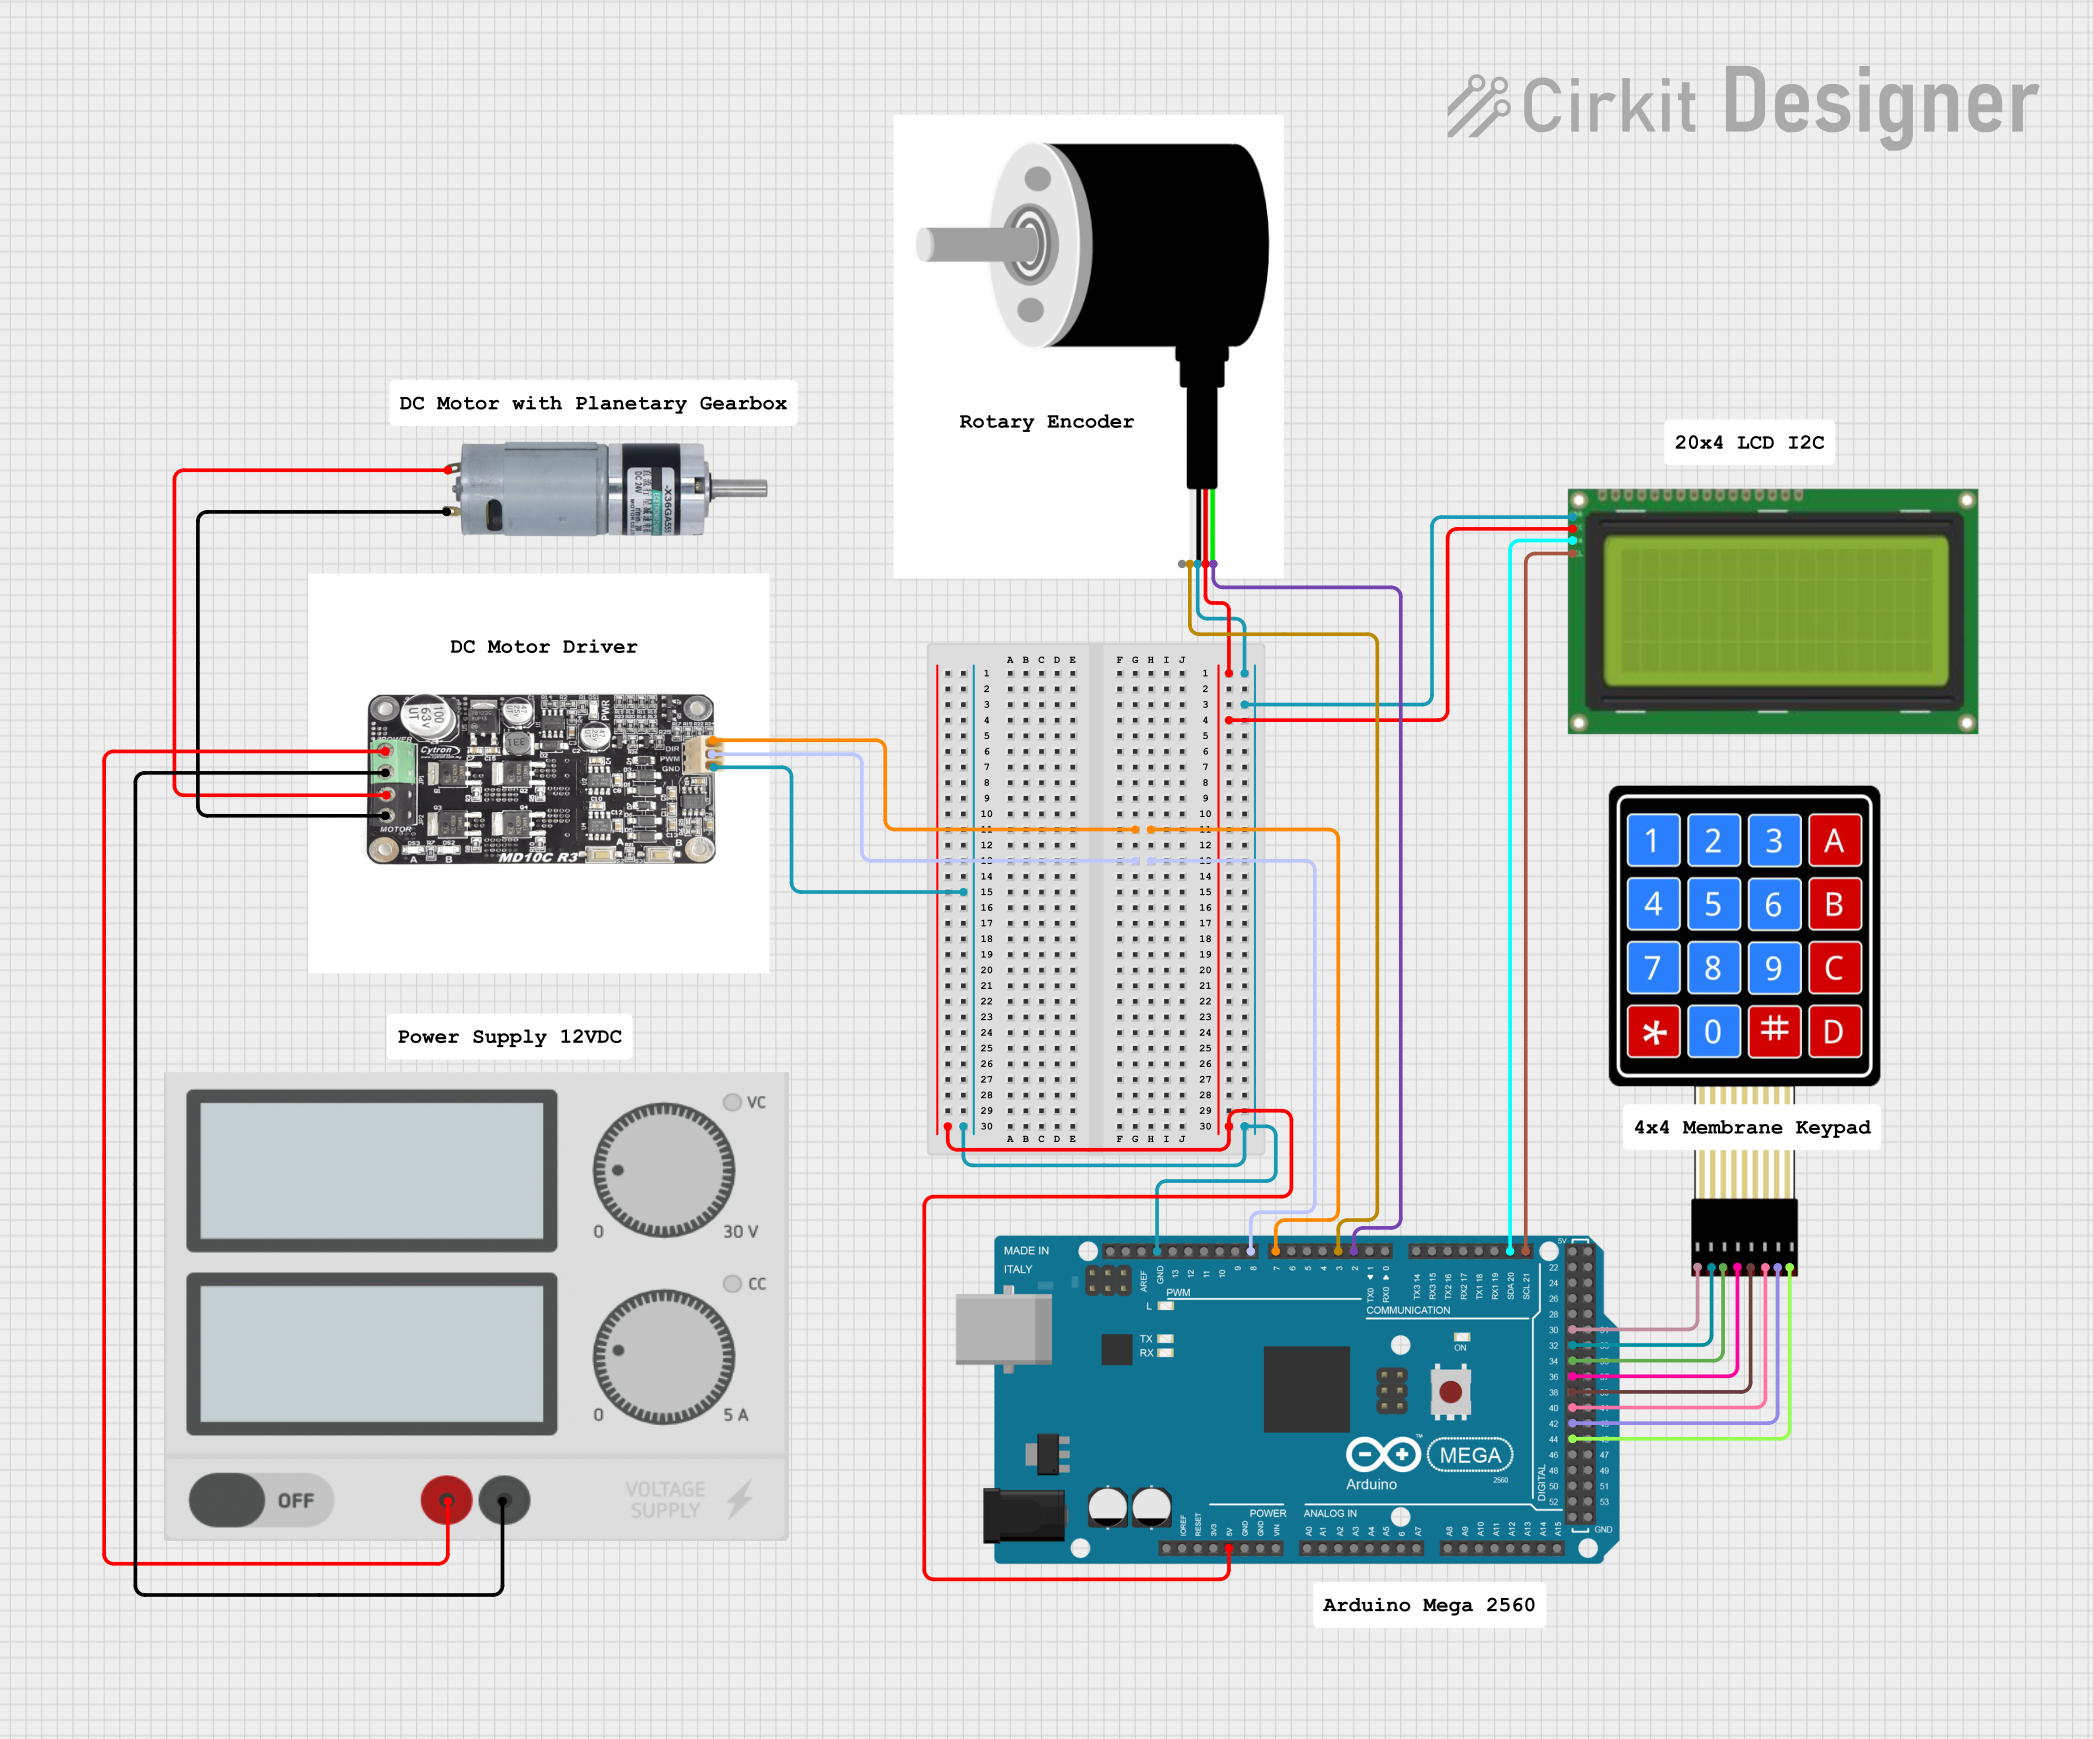
This circuit is a motor control system using an Arduino Mega 2560, which interfaces with a motor driver to control an MRB Planetary gearbox motor. It includes a rotary encoder for feedback, an LCD display for user interface, and a 4x4 membrane keypad for input, all powered by a central power supply.
This circuit features an Arduino UNO microcontroller interfaced with an L298N DC motor driver to control multiple MRB Planetary gearbox motors. The HC-05 Bluetooth Module is connected to the Arduino for wireless communication, allowing remote control of the motors. A 12V battery powers the system, with a buck converter stepping down the voltage to supply the Arduino and the Bluetooth module.
Industrial machinery requiring precise motion control
Actuators in aerospace and defense applications
Technical Specifications
Key Technical Details
Parameter
Value
Motor Type
DC motor with planetary gearbox
Gearbox Type
Planetary
Input Voltage Range
6V to 24V
Rated Torque
Up to 50 Nm (varies by model)
Gear Ratio Options
4:1, 16:1, 64:1, etc.
No-Load Speed
50 to 500 RPM (varies by model)
Efficiency
Up to 90%
Backlash
< 1°
Operating Temperature
-20°C to 60°C
Shaft Diameter
6 mm to 12 mm (varies by model)
Mounting Configuration
Flange-mounted
Pin Configuration and Descriptions
The MRB Planetary Gearbox Motor typically has two or three wires for electrical connections. Below is a general description of the pin configuration:
Pin/Wire Color
Function
Description
Red
Power (V+)
Connect to the positive terminal of the power supply.
Black
Ground (GND)
Connect to the negative terminal of the power supply.
Yellow (optional)
Encoder Signal A (if applicable)
Provides feedback for speed and position control.
Green (optional)
Encoder Signal B (if applicable)
Secondary feedback signal for direction sensing.
Note: The exact pin configuration may vary depending on the specific model. Refer to the datasheet for your motor.
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Ensure the power supply voltage matches the motor's input voltage range (6V to 24V). Use a regulated DC power source for optimal performance.
Connections:
Connect the red wire to the positive terminal of the power supply.
Connect the black wire to the ground terminal.
If the motor includes an encoder, connect the encoder wires (yellow and green) to the appropriate microcontroller pins for feedback.
Motor Driver: Use a motor driver or H-bridge circuit to control the motor's speed and direction. Ensure the driver can handle the motor's current and voltage requirements.
Control: For precise control, use a microcontroller (e.g., Arduino UNO) to send PWM signals to the motor driver.
Important Considerations and Best Practices
Gear Ratio Selection: Choose a gear ratio that balances speed and torque for your application.
Load Limits: Avoid exceeding the motor's rated torque to prevent damage.
Heat Management: Ensure proper ventilation or cooling if the motor operates continuously under high load.
Encoder Feedback: If using an encoder, calibrate it for accurate speed and position control.
Mounting: Securely mount the motor to prevent misalignment or vibration during operation.
Example: Connecting to an Arduino UNO
Below is an example of controlling the MRB Planetary Gearbox Motor using an Arduino UNO and an L298N motor driver.
// Example: Controlling MRB Planetary Gearbox Motor with Arduino UNO
// Ensure the motor driver is connected to the motor and power supply correctly.

#define ENA 9  // PWM pin for motor speed control
#define IN1 8  // Motor direction pin 1
#define IN2 7  // Motor direction pin 2

void setup() {
  pinMode(ENA, OUTPUT); // Set ENA as output
  pinMode(IN1, OUTPUT); // Set IN1 as output
  pinMode(IN2, OUTPUT); // Set IN2 as output
}

void loop() {
  // Rotate motor forward
  digitalWrite(IN1, HIGH);  // Set IN1 high
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 150);    // Set speed (0-255)

  delay(2000); // Run motor for 2 seconds

  // Rotate motor backward
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, HIGH);  // Set IN2 high
  analogWrite(ENA, 150);    // Set speed (0-255)

  delay(2000); // Run motor for 2 seconds

  // Stop motor
  digitalWrite(IN1, LOW);   // Set IN1 low
  digitalWrite(IN2, LOW);   // Set IN2 low
  analogWrite(ENA, 0);      // Set speed to 0

  delay(2000); // Wait for 2 seconds before repeating
}
Note: Adjust the analogWrite value to control the motor speed. Ensure the motor driver can handle the motor's current requirements.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Start:
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check all connections and ensure the power supply meets the motor's voltage and current requirements.
Motor Overheats:
Cause: Excessive load or prolonged operation at high torque.
Solution: Reduce the load or provide adequate cooling.
Inconsistent Speed or Position:
Cause: Encoder feedback not properly connected or calibrated.
Solution: Verify encoder connections and recalibrate the system.
Excessive Noise or Vibration:
Cause: Misalignment or loose mounting.
Solution: Securely mount the motor and check for proper alignment.
FAQs
Q: Can the motor run on a 12V battery?
A: Yes, as long as the battery can supply sufficient current for the motor's operation.
Q: How do I select the right gear ratio?
A: Consider the required speed and torque for your application. Higher gear ratios provide more torque but reduce speed.
Q: Is the motor compatible with other microcontrollers?
A: Yes, the motor can be controlled by any microcontroller capable of generating PWM signals, such as Raspberry Pi or ESP32.
Q: Can I use the motor without an encoder?
A: Yes, but you will lose precise speed and position control. An encoder is recommended for applications requiring feedback.
This concludes the documentation for the MRB Planetary Gearbox Motor. For further assistance, refer to the manufacturer's datasheet or contact technical support.

 Open Project in Cirkit Designer