The A4988 is a microstepping driver designed for controlling bipolar stepper motors. It enables precise control of motor position and speed, making it ideal for applications requiring high accuracy and smooth motion. The driver supports up to 2A per phase with adjustable current control, allowing for efficient operation of stepper motors. Additionally, the A4988 includes built-in protection features such as over-temperature shutdown, under-voltage lockout, and crossover-current protection, ensuring reliable performance.
Explore Projects Built with A4988
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
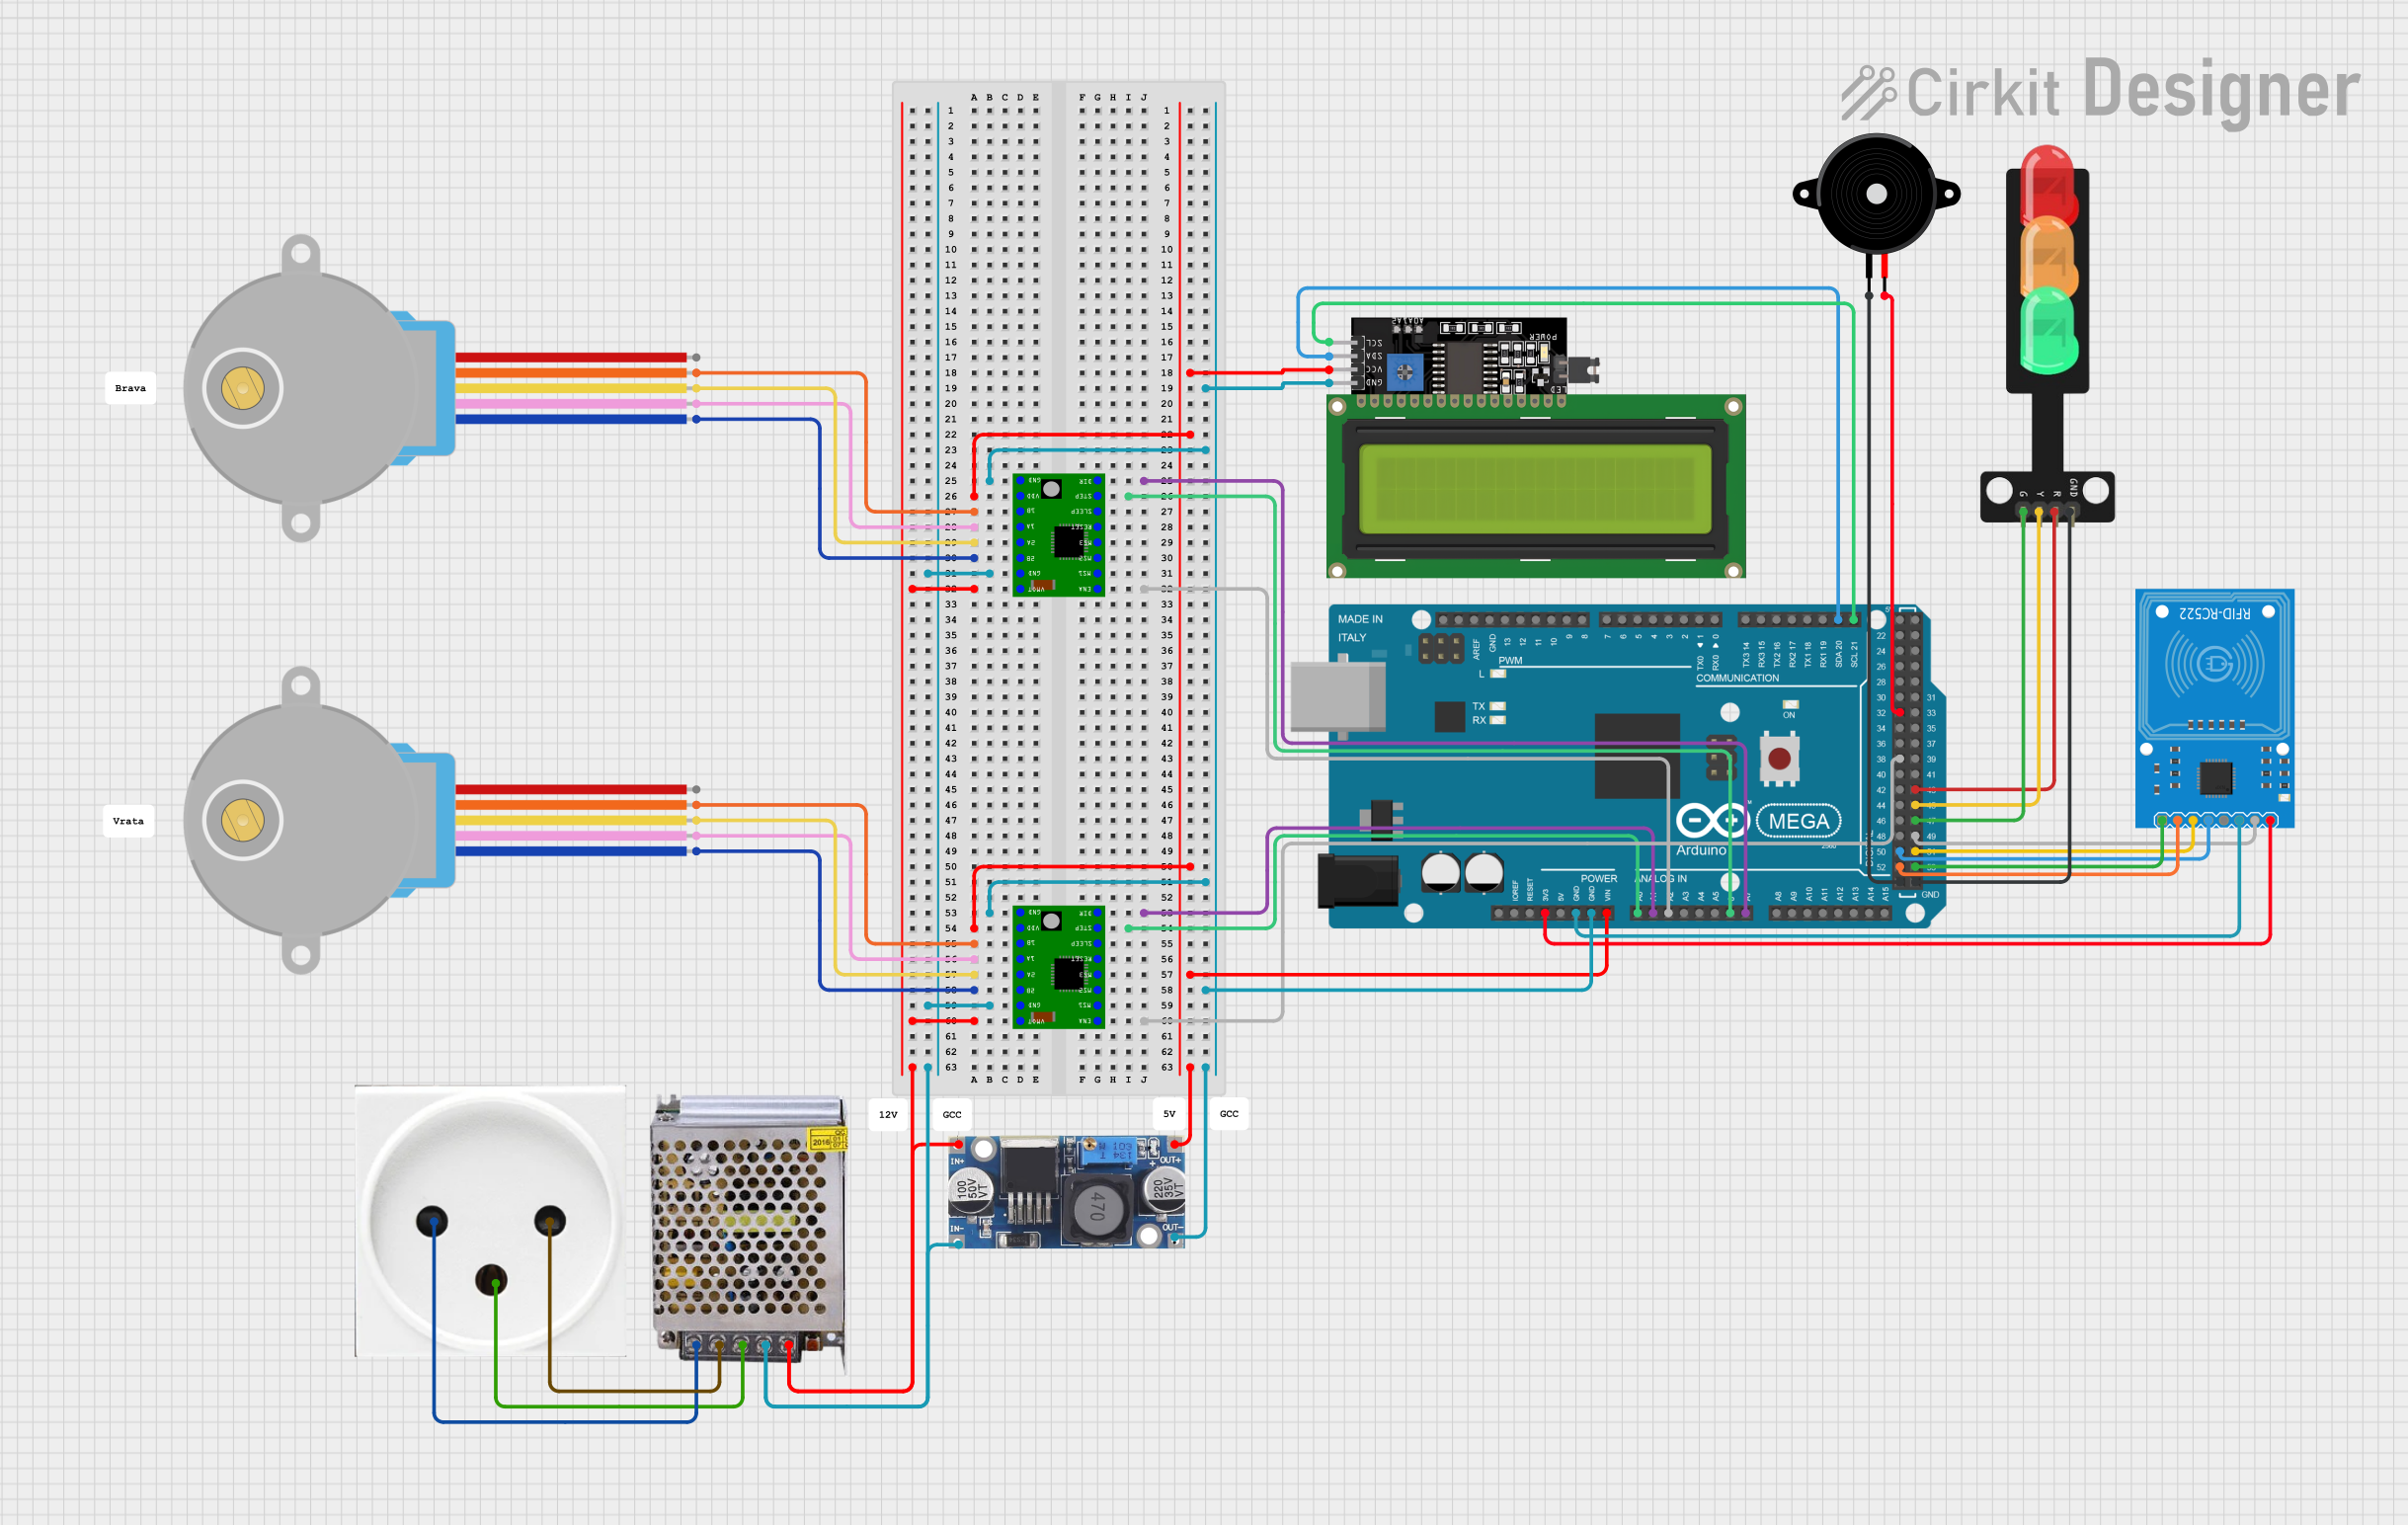
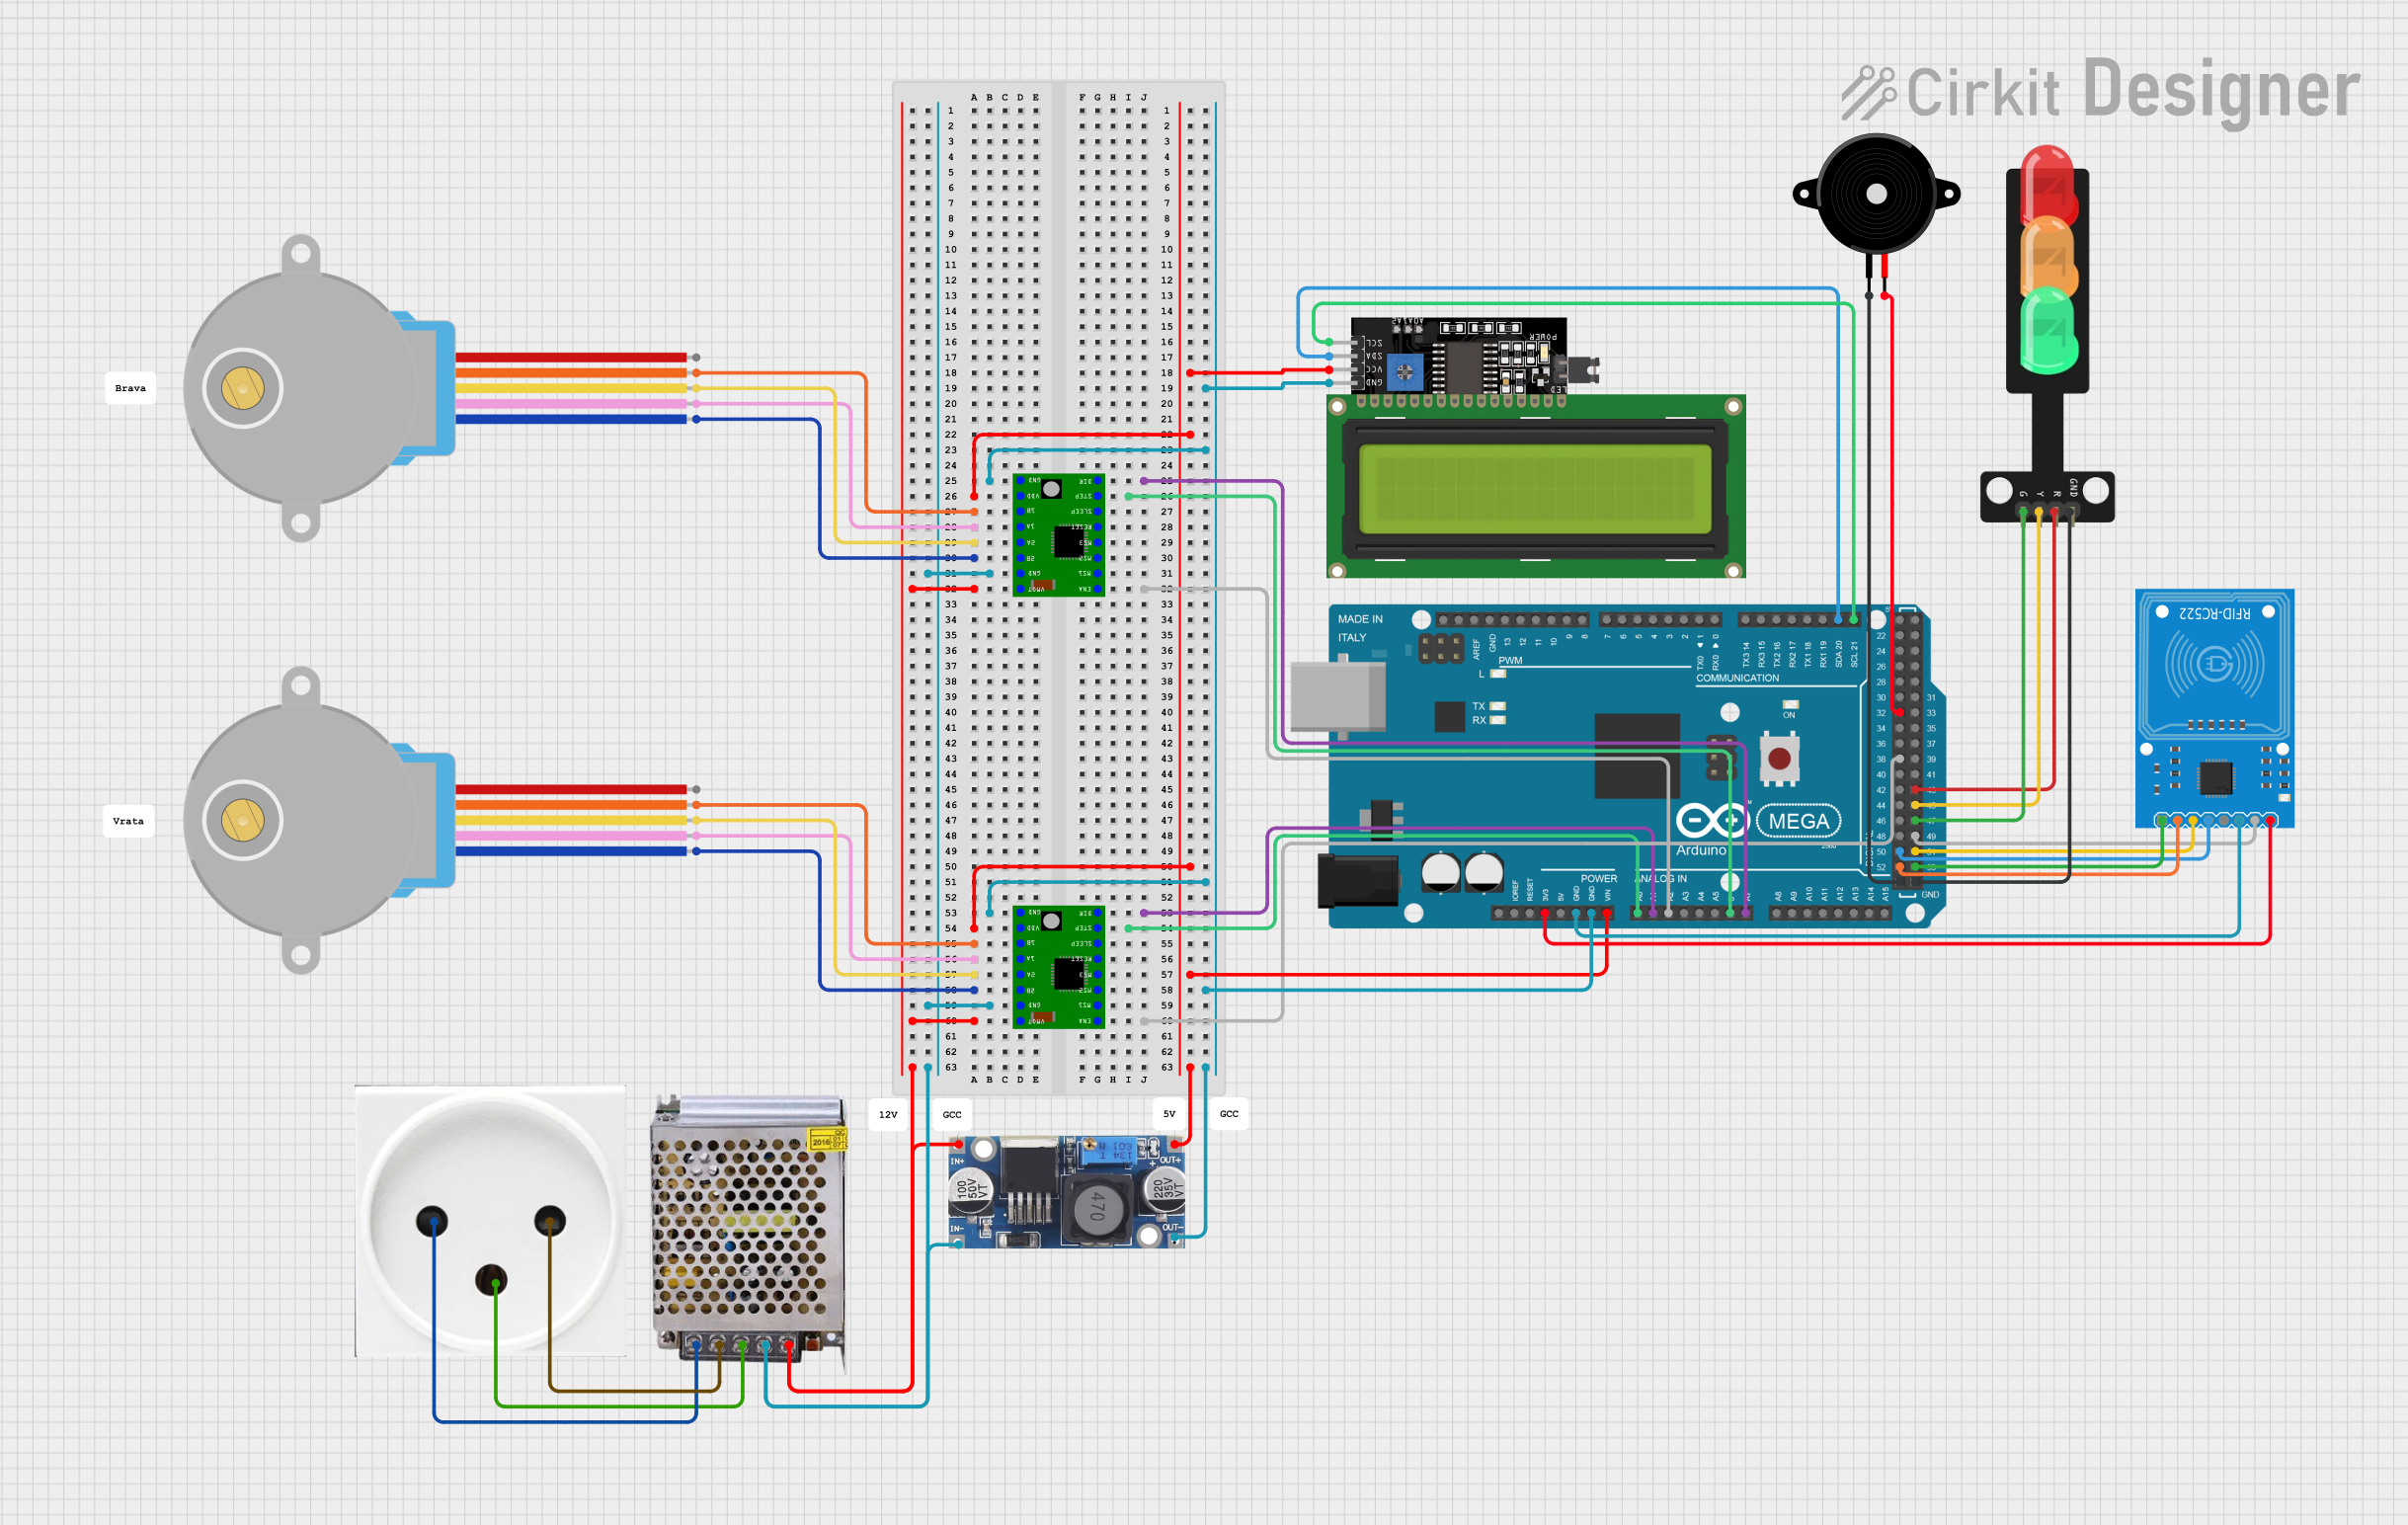
This circuit controls two 28BYJ-48 stepper motors using A4988 stepper motor driver carriers, interfaced with an Arduino Mega 2560 microcontroller. It features an RFID-RC522 module for RFID reading, a 16x4 LCD display with I2C interface for user interaction, and a piezo speaker for audio feedback. Additionally, there is a traffic light module controlled by the Arduino, and a 48V to 5V converter to step down voltage for the logic levels. The power supply provides 12V to the motor drivers and is connected to a standard power outlet.
This circuit is designed to control two 28BYJ-48 stepper motors using A4988 stepper motor driver carriers, with an Arduino Mega 2560 as the central microcontroller. It includes an RFID-RC522 module for RFID reading, an LCD display for user interface, and a traffic light and piezo speaker for visual and audio signaling. The circuit is powered by a 12V 5A power supply, which is stepped down to 5V for logic level components, and it interfaces with a power outlet for AC to DC conversion.
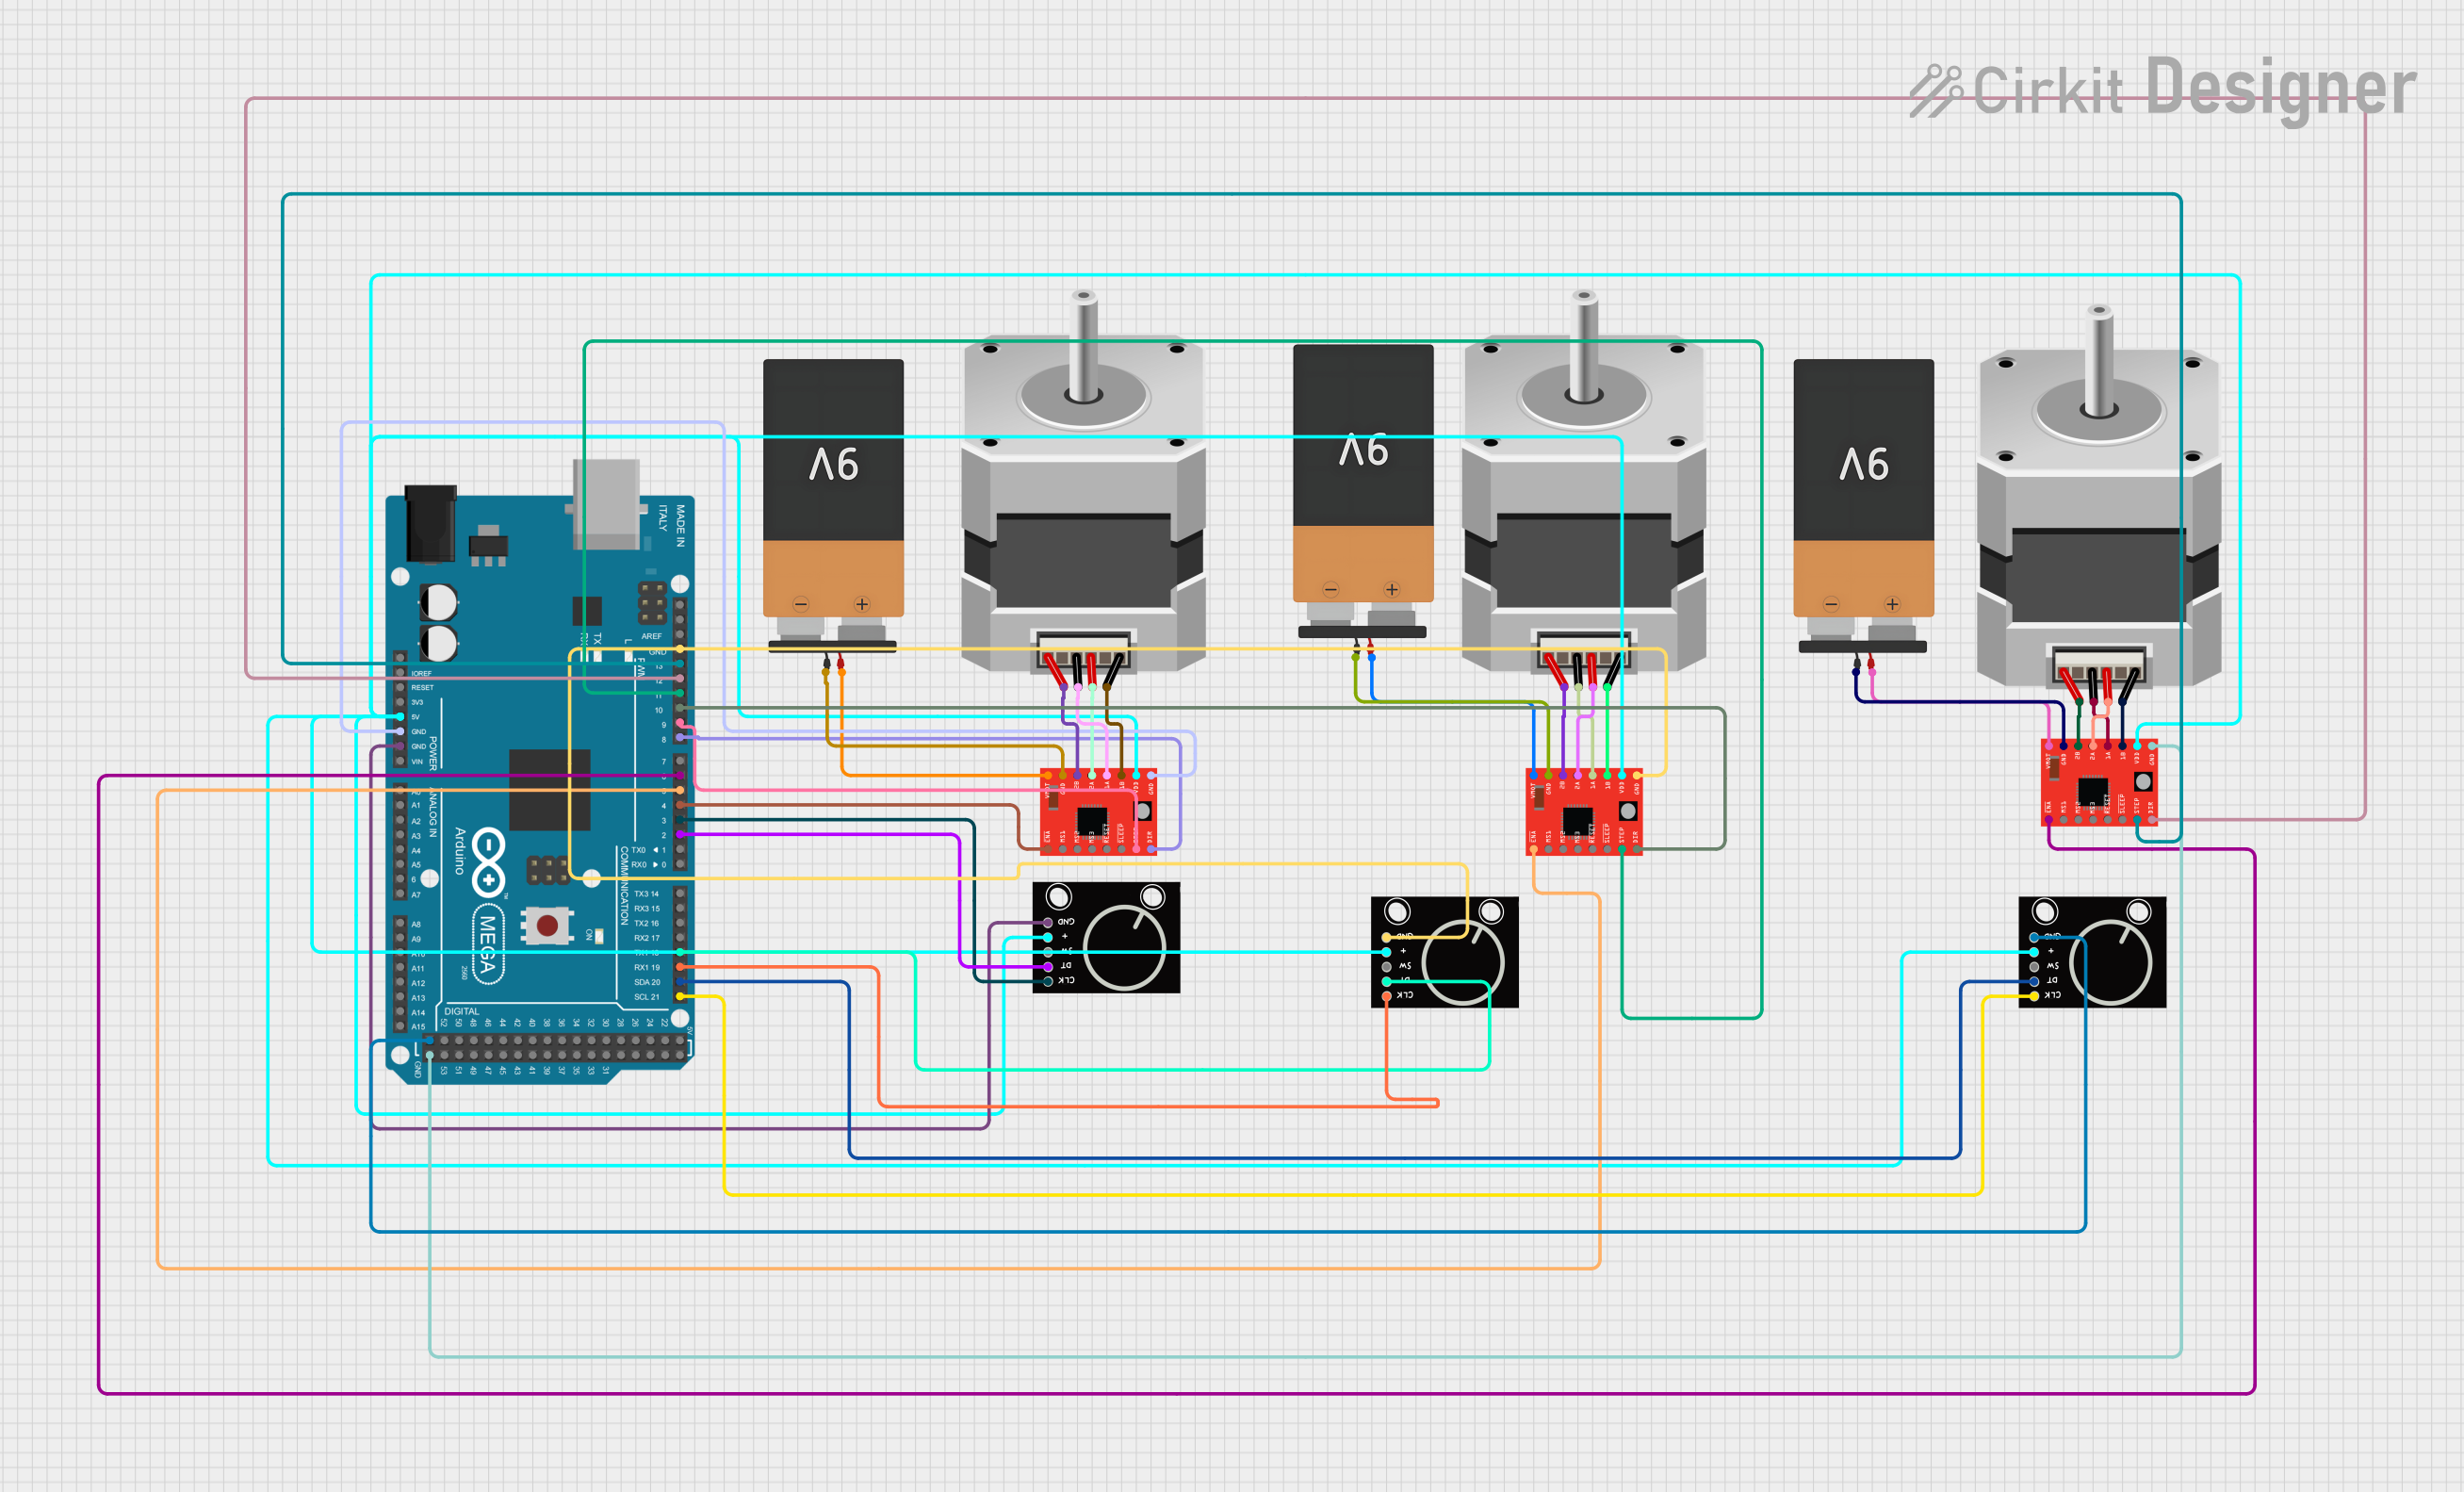
This is a multi-axis stepper motor control system managed by an Arduino Mega 2560, which interfaces with A4988 stepper motor drivers to control bipolar stepper motors. Rotary encoders provide user input for controlling motor parameters, and 9V batteries supply power to the system.
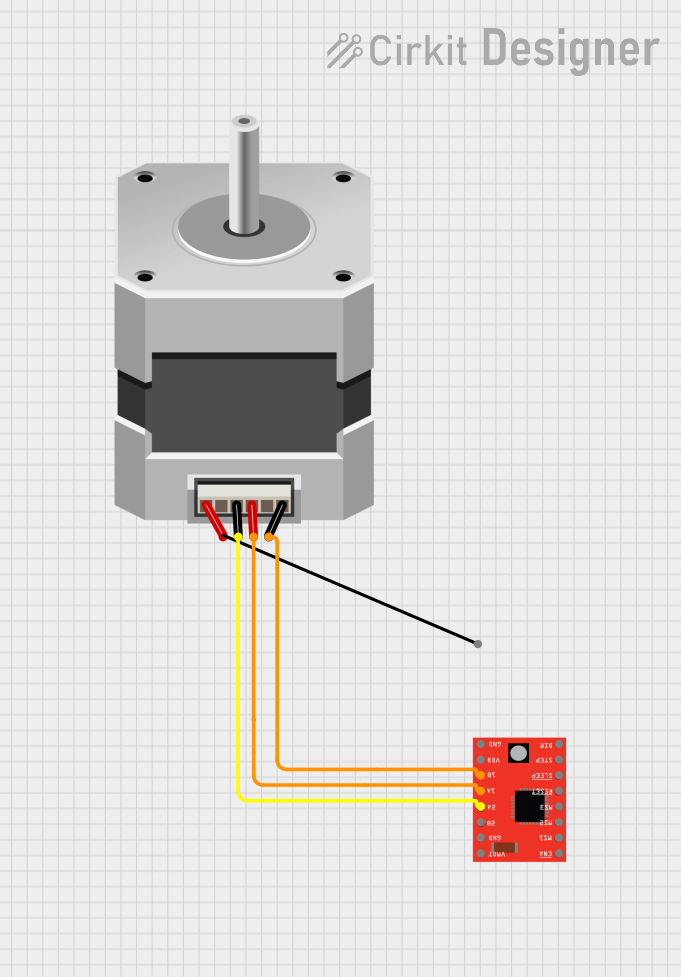
This circuit is designed to control a bipolar stepper motor using an A4988 stepper motor driver. The driver interfaces with the motor by connecting its output pins to the motor's coils, allowing precise control of the motor's movement.
Microstepping Modes: Full, 1/2, 1/4, 1/8, and 1/16 steps
Maximum Current per Phase: 2A (with sufficient cooling)
Logic Voltage (VDD): 3.3V to 5V
Motor Supply Voltage (VMOT): 8V to 35V
Current Control: Adjustable via potentiometer
Built-in Protections: Over-temperature, under-voltage lockout, and short-circuit protection
Pin Configuration and Descriptions
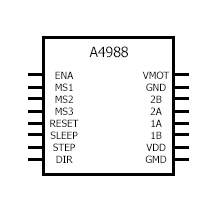
The A4988 has 16 pins, as described in the table below:
Pin Name
Type
Description
VMOT
Power Input
Motor power supply (8V to 35V). Connect a decoupling capacitor close to this pin.
GND
Power Ground
Ground connection for motor power supply.
VDD
Power Input
Logic power supply (3.3V to 5V).
GND
Power Ground
Ground connection for logic power supply.
1A, 1B
Motor Output
Connect to one coil of the stepper motor.
2A, 2B
Motor Output
Connect to the other coil of the stepper motor.
STEP
Logic Input
Controls the step signal for the motor. Each pulse moves the motor one step.
DIR
Logic Input
Controls the direction of motor rotation.
ENABLE
Logic Input
Enables or disables the motor driver (active low).
MS1, MS2, MS3
Logic Input
Microstepping resolution selection pins.
RESET
Logic Input
Resets the driver (active low).
SLEEP
Logic Input
Puts the driver into low-power sleep mode (active low).
REF
Analog Input
Reference voltage for current control. Adjusted via the onboard potentiometer.
Usage Instructions
How to Use the A4988 in a Circuit
Power Connections:
Connect VMOT to a power supply (8V to 35V) suitable for your stepper motor.
Connect VDD to a 3.3V or 5V logic power supply.
Ensure both GND pins are connected to the ground of their respective power supplies.
Motor Connections:
Connect the stepper motor coils to the 1A, 1B, 2A, and 2B pins. Refer to your motor's datasheet to identify the coil pairs.
Control Pins:
Connect the STEP and DIR pins to your microcontroller or control circuit.
Use the MS1, MS2, and MS3 pins to set the desired microstepping mode (refer to the table below).
MS1
MS2
MS3
Microstepping Mode
Low
Low
Low
Full Step
High
Low
Low
Half Step
Low
High
Low
Quarter Step
High
High
Low
Eighth Step
High
High
High
Sixteenth Step
Adjust Current Limit:
Use the onboard potentiometer to set the current limit. This prevents overheating and ensures safe operation of the motor.
Decoupling Capacitors:
Place a 100µF electrolytic capacitor close to the VMOT pin to reduce voltage spikes.
Add a 0.1µF ceramic capacitor near the VDD pin for logic power stability.
Example Code for Arduino UNO
Below is an example of how to control a stepper motor using the A4988 and an Arduino UNO:
// Define control pins
#define STEP_PIN 3  // Connect to STEP pin on A4988
#define DIR_PIN 4   // Connect to DIR pin on A4988

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output

  digitalWrite(DIR_PIN, HIGH); // Set initial direction (HIGH = clockwise)
}

void loop() {
  // Generate step pulses
  for (int i = 0; i < 200; i++) { // 200 steps for one revolution (1.8°/step motor)
    digitalWrite(STEP_PIN, HIGH); // Step pulse HIGH
    delayMicroseconds(1000);      // 1ms delay (adjust for speed control)
    digitalWrite(STEP_PIN, LOW);  // Step pulse LOW
    delayMicroseconds(1000);      // 1ms delay
  }

  delay(1000); // Wait 1 second before changing direction

  // Change direction
  digitalWrite(DIR_PIN, LOW); // Reverse direction (LOW = counterclockwise)
  delay(1000); // Wait 1 second before next loop
}
Important Considerations
Heat Management: The A4988 can get hot during operation. Use a heat sink or active cooling if necessary.
Current Limiting: Always set the current limit to match your motor's rated current to avoid damage.
Power Supply: Ensure your power supply can handle the motor's current requirements.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Check all connections, especially the motor coils and power supply.
Verify that the STEP pin is receiving pulses from the microcontroller.
Motor Vibrates but Doesn't Rotate:
Ensure the motor coils are connected correctly (1A/1B and 2A/2B pairs).
Check the microstepping mode settings (MS1, MS2, MS3).
Driver Overheating:
Reduce the current limit using the potentiometer.
Add a heat sink or active cooling to the A4988.
Erratic Motor Movement:
Verify the power supply voltage and current are stable.
Add decoupling capacitors near the VMOT and VDD pins.
FAQs
Can I use the A4988 with a unipolar stepper motor?
No, the A4988 is designed for bipolar stepper motors only.
What happens if I exceed the current limit?
Exceeding the current limit can cause the driver to overheat and enter thermal shutdown. Always set the current limit appropriately.
How do I calculate the current limit?
The current limit is set using the formula: Current Limit = VREF / (8 × RS)
where VREF is the voltage on the REF pin, and RS is the sense resistor value (typically 0.1Ω).
By following this documentation, you can effectively use the A4988 to control stepper motors in your projects.

 Open Project in Cirkit Designer