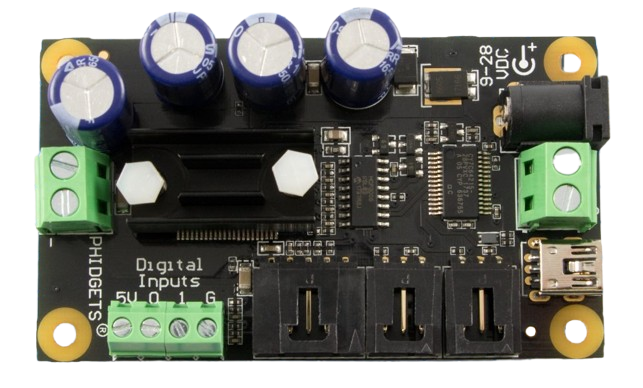
The Phidgets Motor Control (Part ID: 1-Motor) is a versatile interface designed for controlling DC motors. It allows for precise speed and direction control, making it an essential component in robotics, automation, and other motor-driven projects. This motor controller is ideal for applications requiring smooth motor operation, such as conveyor systems, robotic arms, and automated vehicles.
With its user-friendly interface and robust design, the Phidgets Motor Control is suitable for both beginners and experienced engineers. It can be easily integrated into microcontroller-based systems, including Arduino, Raspberry Pi, and other development platforms.
Explore Projects Built with Phidgets Motor Control
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
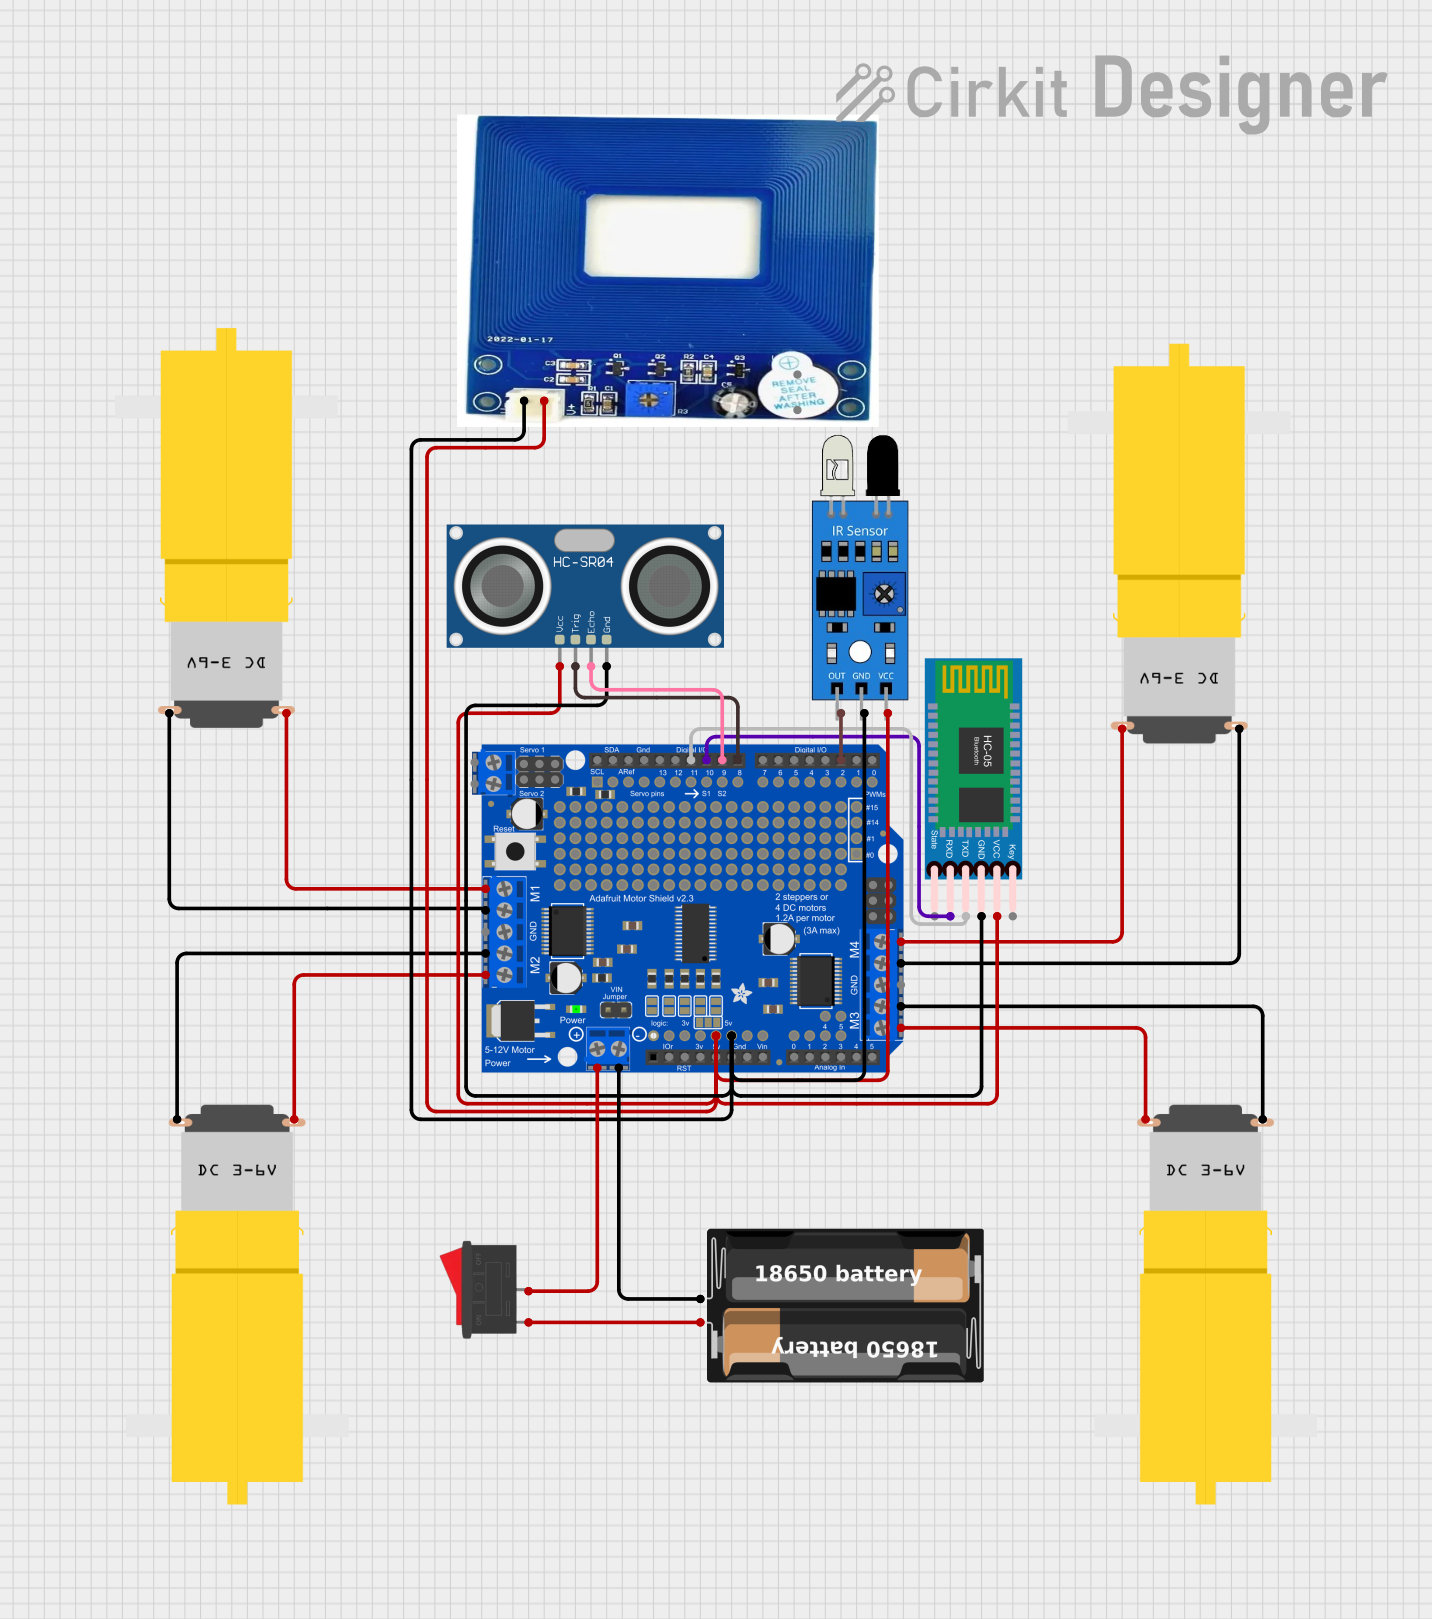
This circuit is a motor control system that uses an Adafruit Motor Shield to drive four hobby motors, with additional sensors including an IR sensor, an ultrasonic sensor, a metal detector, and a Bluetooth module for remote communication. The system is powered by a battery case and controlled via a rocker switch.
This circuit consists of a VINT Hub Phidget connected to four 4A Stepper Phidgets, which in turn are connected to four NEMA23 stepper motors. The VINT Hub Phidget interfaces with the stepper controllers, likely for the purpose of controlling the stepper motors. A power supply is connected to all the stepper controllers to provide the necessary voltage, and a Square FSR (Force Sensitive Resistor) with a resistor is connected to the VINT Hub, possibly for sensing force or pressure.
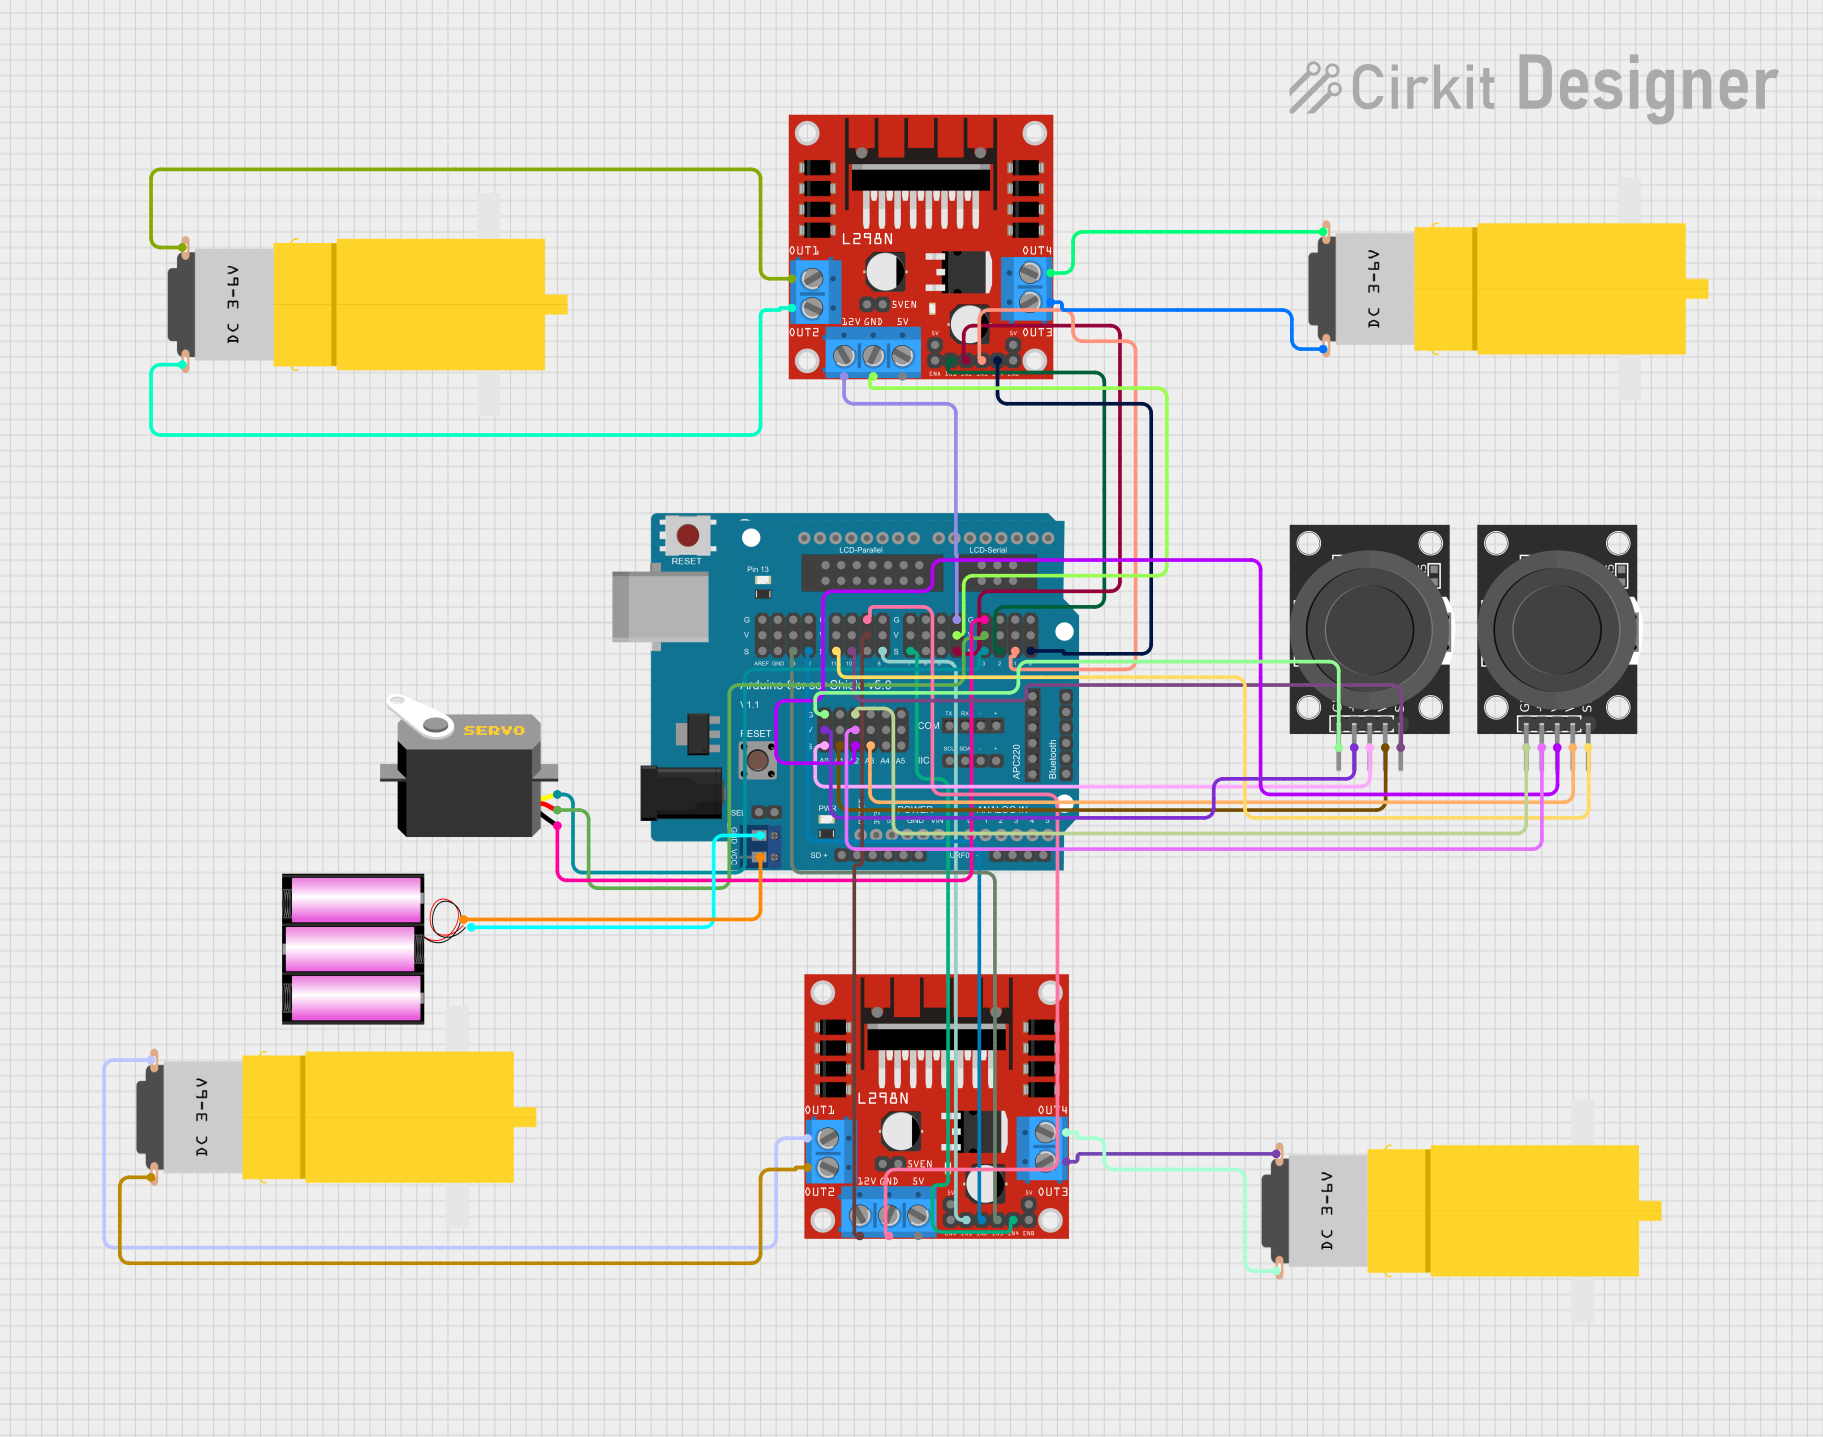
This circuit is a motor control system using an Arduino UNO and an Arduino Sensor Shield to interface with multiple L298N motor drivers and KY-023 Dual Axis Joystick Modules. The system is powered by a 12V battery and includes a servo motor, allowing for precise control of four DC motors based on joystick input.
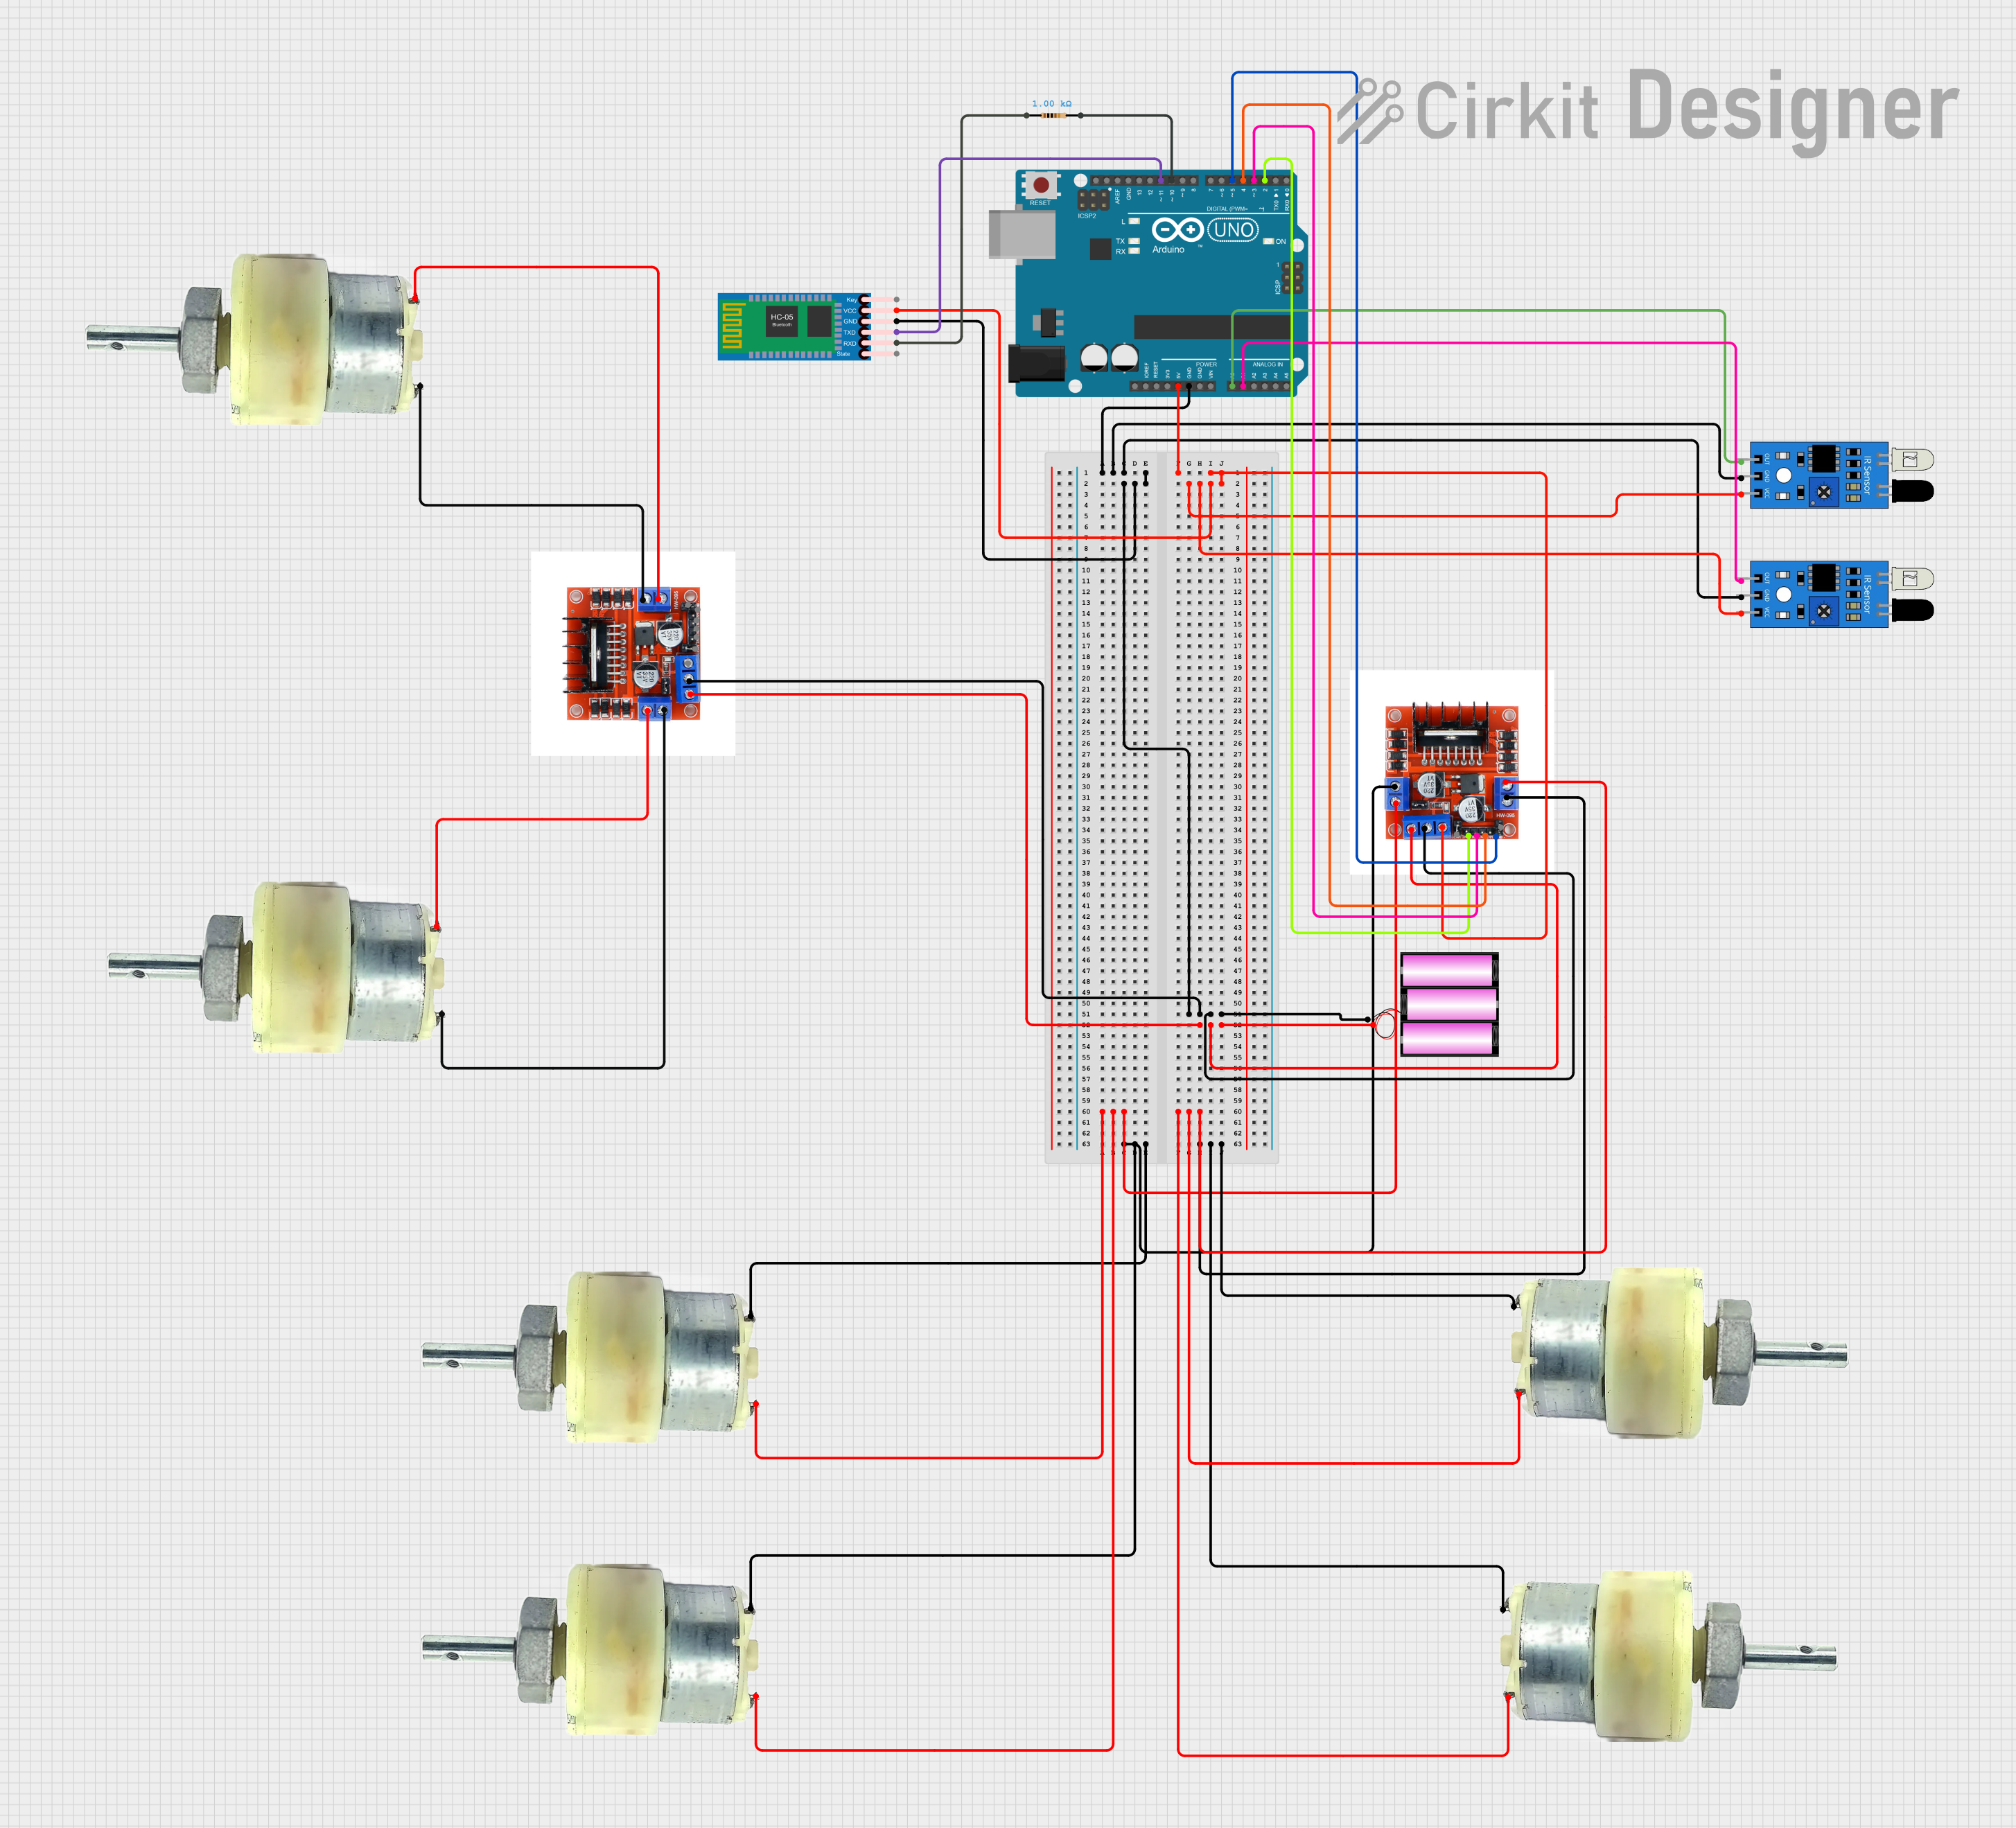
This circuit is a motor control system that uses an Arduino UNO to control multiple 12V geared motors via two L298N motor driver modules. The system includes IR sensors for obstacle detection and an HC-05 Bluetooth module for wireless communication, all powered by a 12V battery.
Below are the key technical details of the Phidgets Motor Control:
General Specifications
Manufacturer: Phidgets
Part ID: 1-Motor
Input Voltage Range: 6V to 15V DC
Maximum Continuous Current: 4A
Peak Current: 5A (for short durations)
Control Interface: USB or GPIO
Motor Type Supported: Brushed DC motors
Direction Control: Forward and reverse
Speed Control: PWM (Pulse Width Modulation) with 0% to 100% duty cycle
Operating Temperature: -20°C to 50°C
Pin Configuration and Descriptions
The Phidgets Motor Control has the following pin configuration:
Pin Name
Description
Type
V+
Positive motor power supply (6V-15V DC)
Power Input
GND
Ground connection
Power Input
M+
Positive motor terminal
Motor Output
M-
Negative motor terminal
Motor Output
DIR
Direction control input (HIGH/LOW)
Digital Input
PWM
Speed control input (PWM signal)
Digital Input
USB
USB interface for PC control
Communication
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Connect a DC power supply (6V to 15V) to the V+ and GND pins. Ensure the power supply can provide sufficient current for your motor.
Motor Connection: Connect the motor terminals to the M+ and M- pins. Ensure the motor is a brushed DC motor compatible with the controller.
Control Signals:
Use the DIR pin to control the motor's direction. Set it HIGH for forward and LOW for reverse.
Use the PWM pin to control the motor's speed. Provide a PWM signal with a duty cycle between 0% (stopped) and 100% (full speed).
USB Control: Optionally, connect the USB interface to a PC for software-based control using the Phidgets API.
Important Considerations and Best Practices
Heat Dissipation: The controller may heat up during operation. Ensure proper ventilation or use a heatsink if necessary.
Current Limiting: Avoid exceeding the maximum continuous current rating (4A) to prevent damage.
Signal Quality: Use a clean and stable PWM signal for precise speed control.
Polarity: Double-check the polarity of the power supply and motor connections to avoid damage.
Example: Using with Arduino UNO
Below is an example of how to control the Phidgets Motor Control using an Arduino UNO:
// Define pin connections
const int dirPin = 7;  // Direction control pin
const int pwmPin = 6;  // PWM speed control pin

void setup() {
  // Set pin modes
  pinMode(dirPin, OUTPUT);
  pinMode(pwmPin, OUTPUT);
}

void loop() {
  // Set motor direction to forward
  digitalWrite(dirPin, HIGH);

  // Gradually increase motor speed
  for (int speed = 0; speed <= 255; speed++) {
    analogWrite(pwmPin, speed);  // Send PWM signal to control speed
    delay(20);                   // Wait for 20ms
  }

  // Hold at full speed for 2 seconds
  delay(2000);

  // Gradually decrease motor speed
  for (int speed = 255; speed >= 0; speed--) {
    analogWrite(pwmPin, speed);  // Decrease PWM signal
    delay(20);                   // Wait for 20ms
  }

  // Set motor direction to reverse
  digitalWrite(dirPin, LOW);

  // Repeat the same speed ramp-up and ramp-down process
  for (int speed = 0; speed <= 255; speed++) {
    analogWrite(pwmPin, speed);
    delay(20);
  }
  delay(2000);
  for (int speed = 255; speed >= 0; speed--) {
    analogWrite(pwmPin, speed);
    delay(20);
  }
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Running:
Cause: Incorrect power supply or loose connections.
Solution: Verify the power supply voltage and current. Check all connections.
Motor Running in the Wrong Direction:
Cause: Incorrect DIR pin signal or reversed motor connections.
Solution: Check the DIR pin signal. Swap the motor connections if necessary.
Motor Speed Not Changing:
Cause: PWM signal not being sent or incorrect duty cycle.
Solution: Verify the PWM signal using an oscilloscope or multimeter.
Controller Overheating:
Cause: Exceeding the maximum current rating or poor ventilation.
Solution: Reduce the motor load or improve ventilation.
FAQs
Can I use this controller with a stepper motor?
No, the Phidgets Motor Control is designed for brushed DC motors only.
What software can I use with the USB interface?
You can use the Phidgets API, which supports multiple programming languages, including Python, C++, and Java.
Is reverse polarity protection included?
No, ensure correct polarity to avoid damaging the controller.
Can I control multiple motors with one controller?
No, this controller is designed for a single motor. Use additional controllers for multiple motors.
This documentation provides a comprehensive guide to using the Phidgets Motor Control effectively. For further assistance, refer to the official Phidgets support resources.

 Open Project in Cirkit Designer