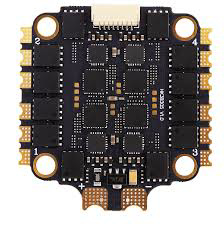
The ESC 60A by BelHelix is a high-performance Electronic Speed Controller designed to manage the speed, direction, and throttle of brushless motors. With a current rating of 60 Amperes, this ESC is ideal for applications requiring precise motor control, such as remote-controlled (RC) vehicles, drones, boats, and other robotics projects. Its robust design ensures reliable operation under demanding conditions, making it a popular choice for hobbyists and professionals alike.
Explore Projects Built with ESC 60A
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
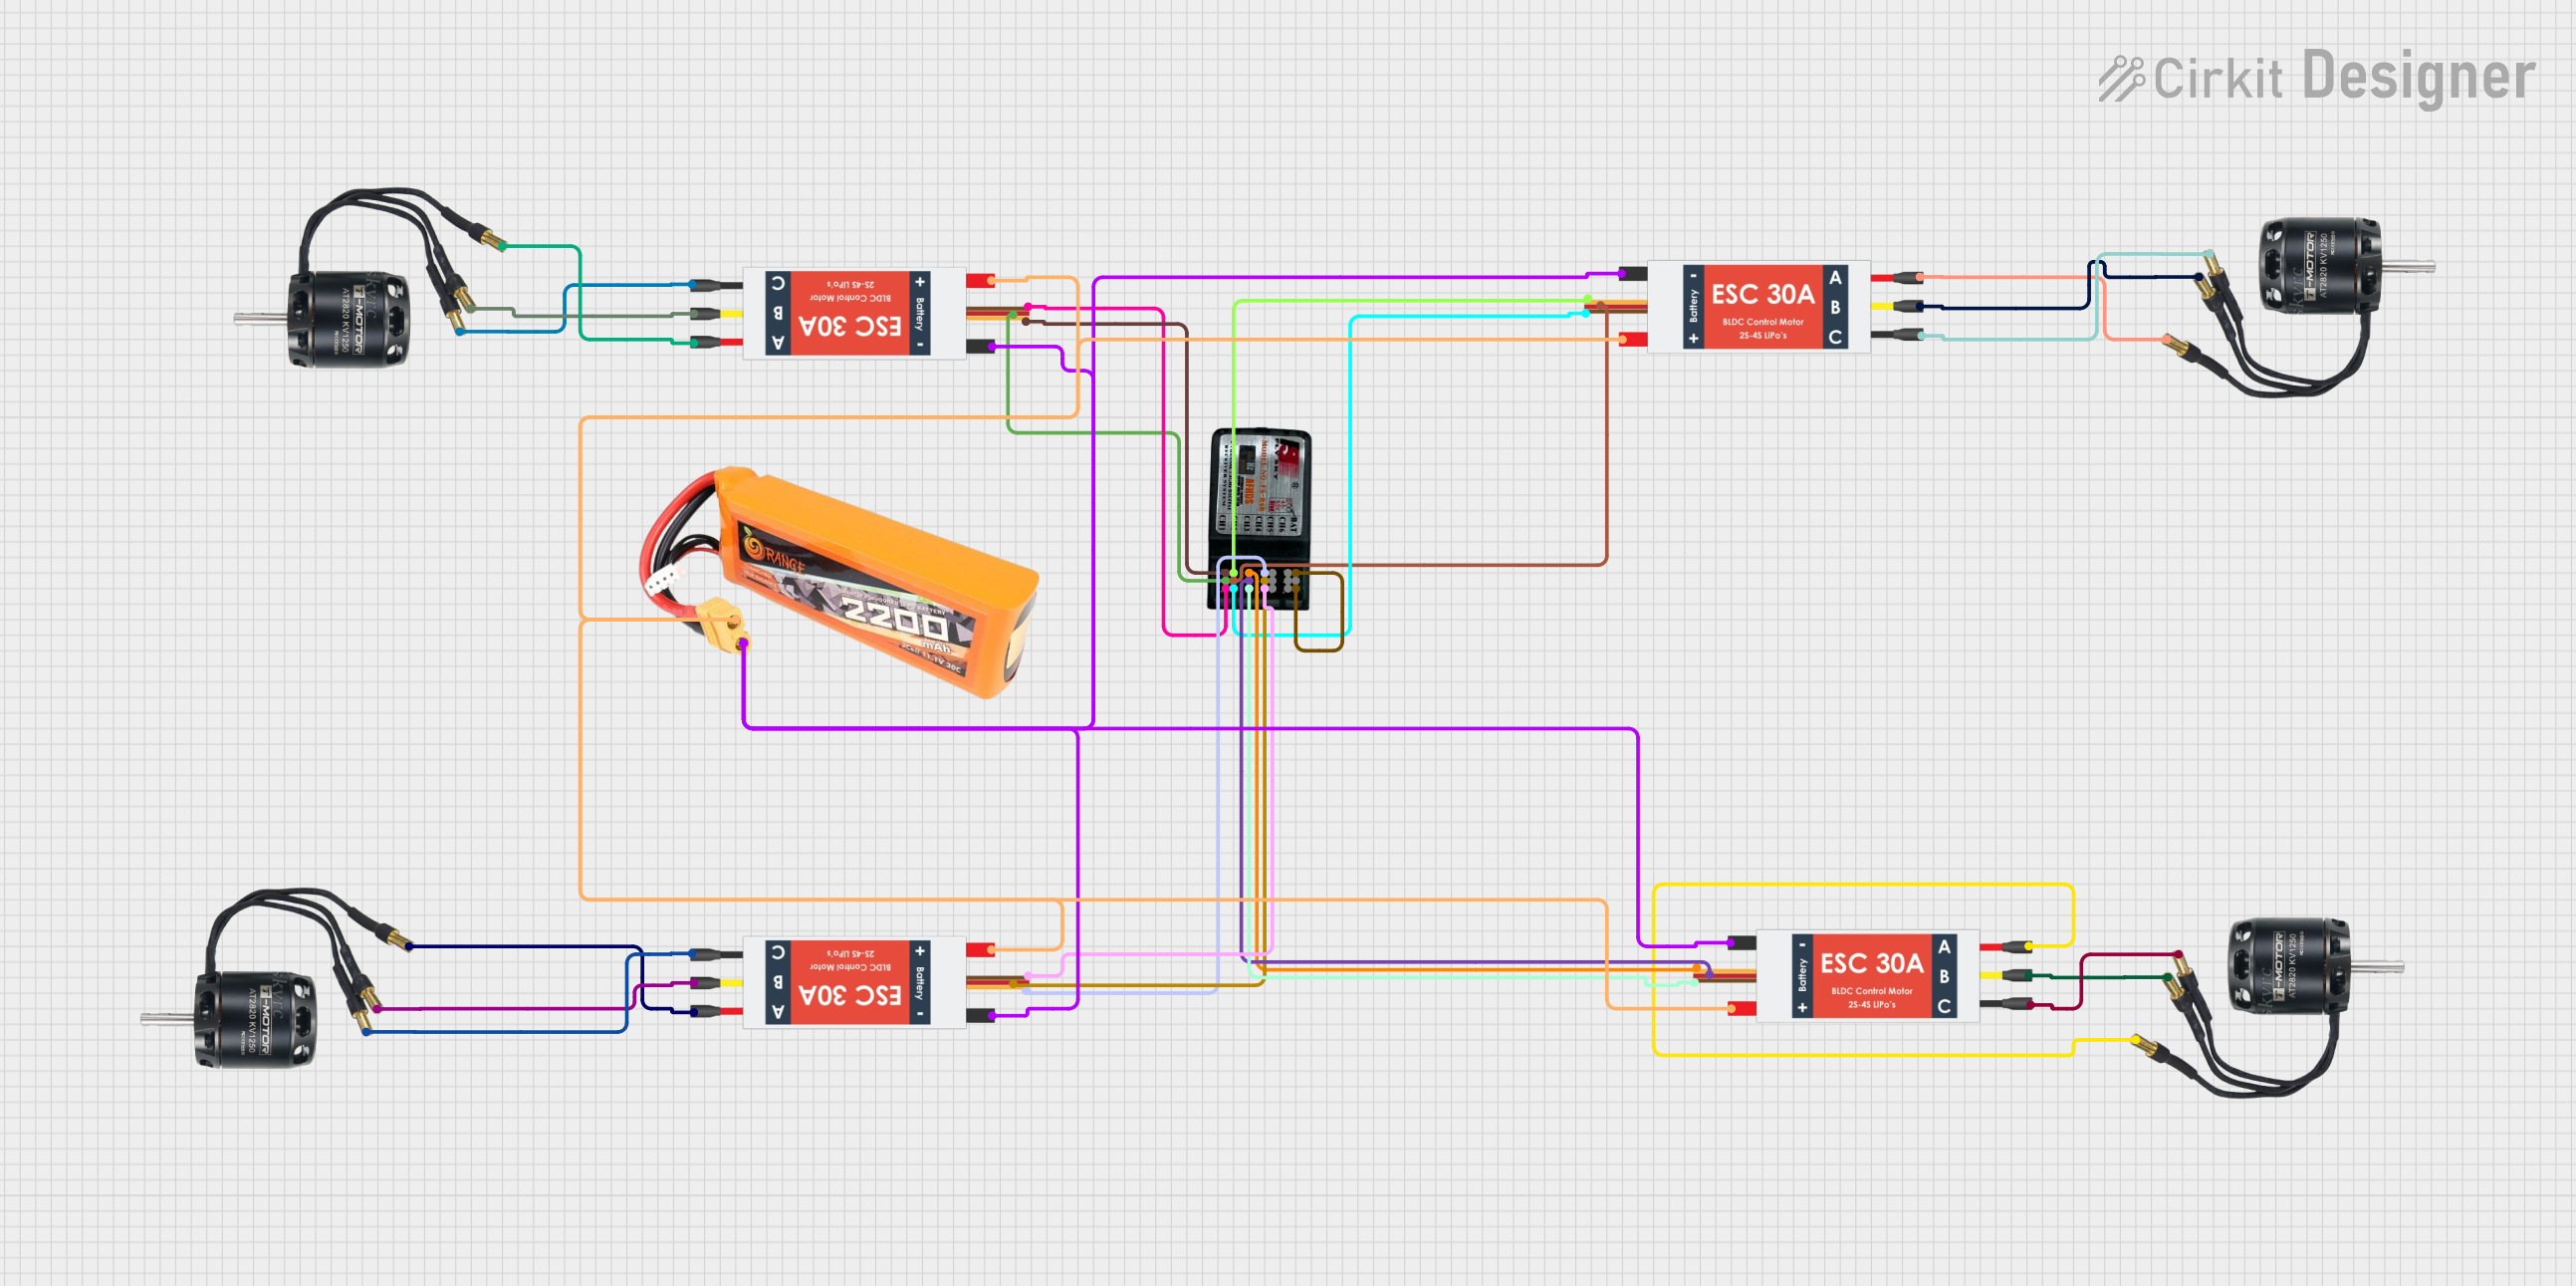
This circuit is designed to control four Brushless DC (BLDC) motors using corresponding Electronic Speed Controllers (ESCs). Each ESC receives power from a shared LiPo battery and control signals from an FS-CT6B receiver, which likely receives input from a remote transmitter for wireless control. The ESCs regulate the power supplied to the motors based on the received signals, enabling precise speed and direction control of the motors, typically used in applications such as drones or remote-controlled vehicles.
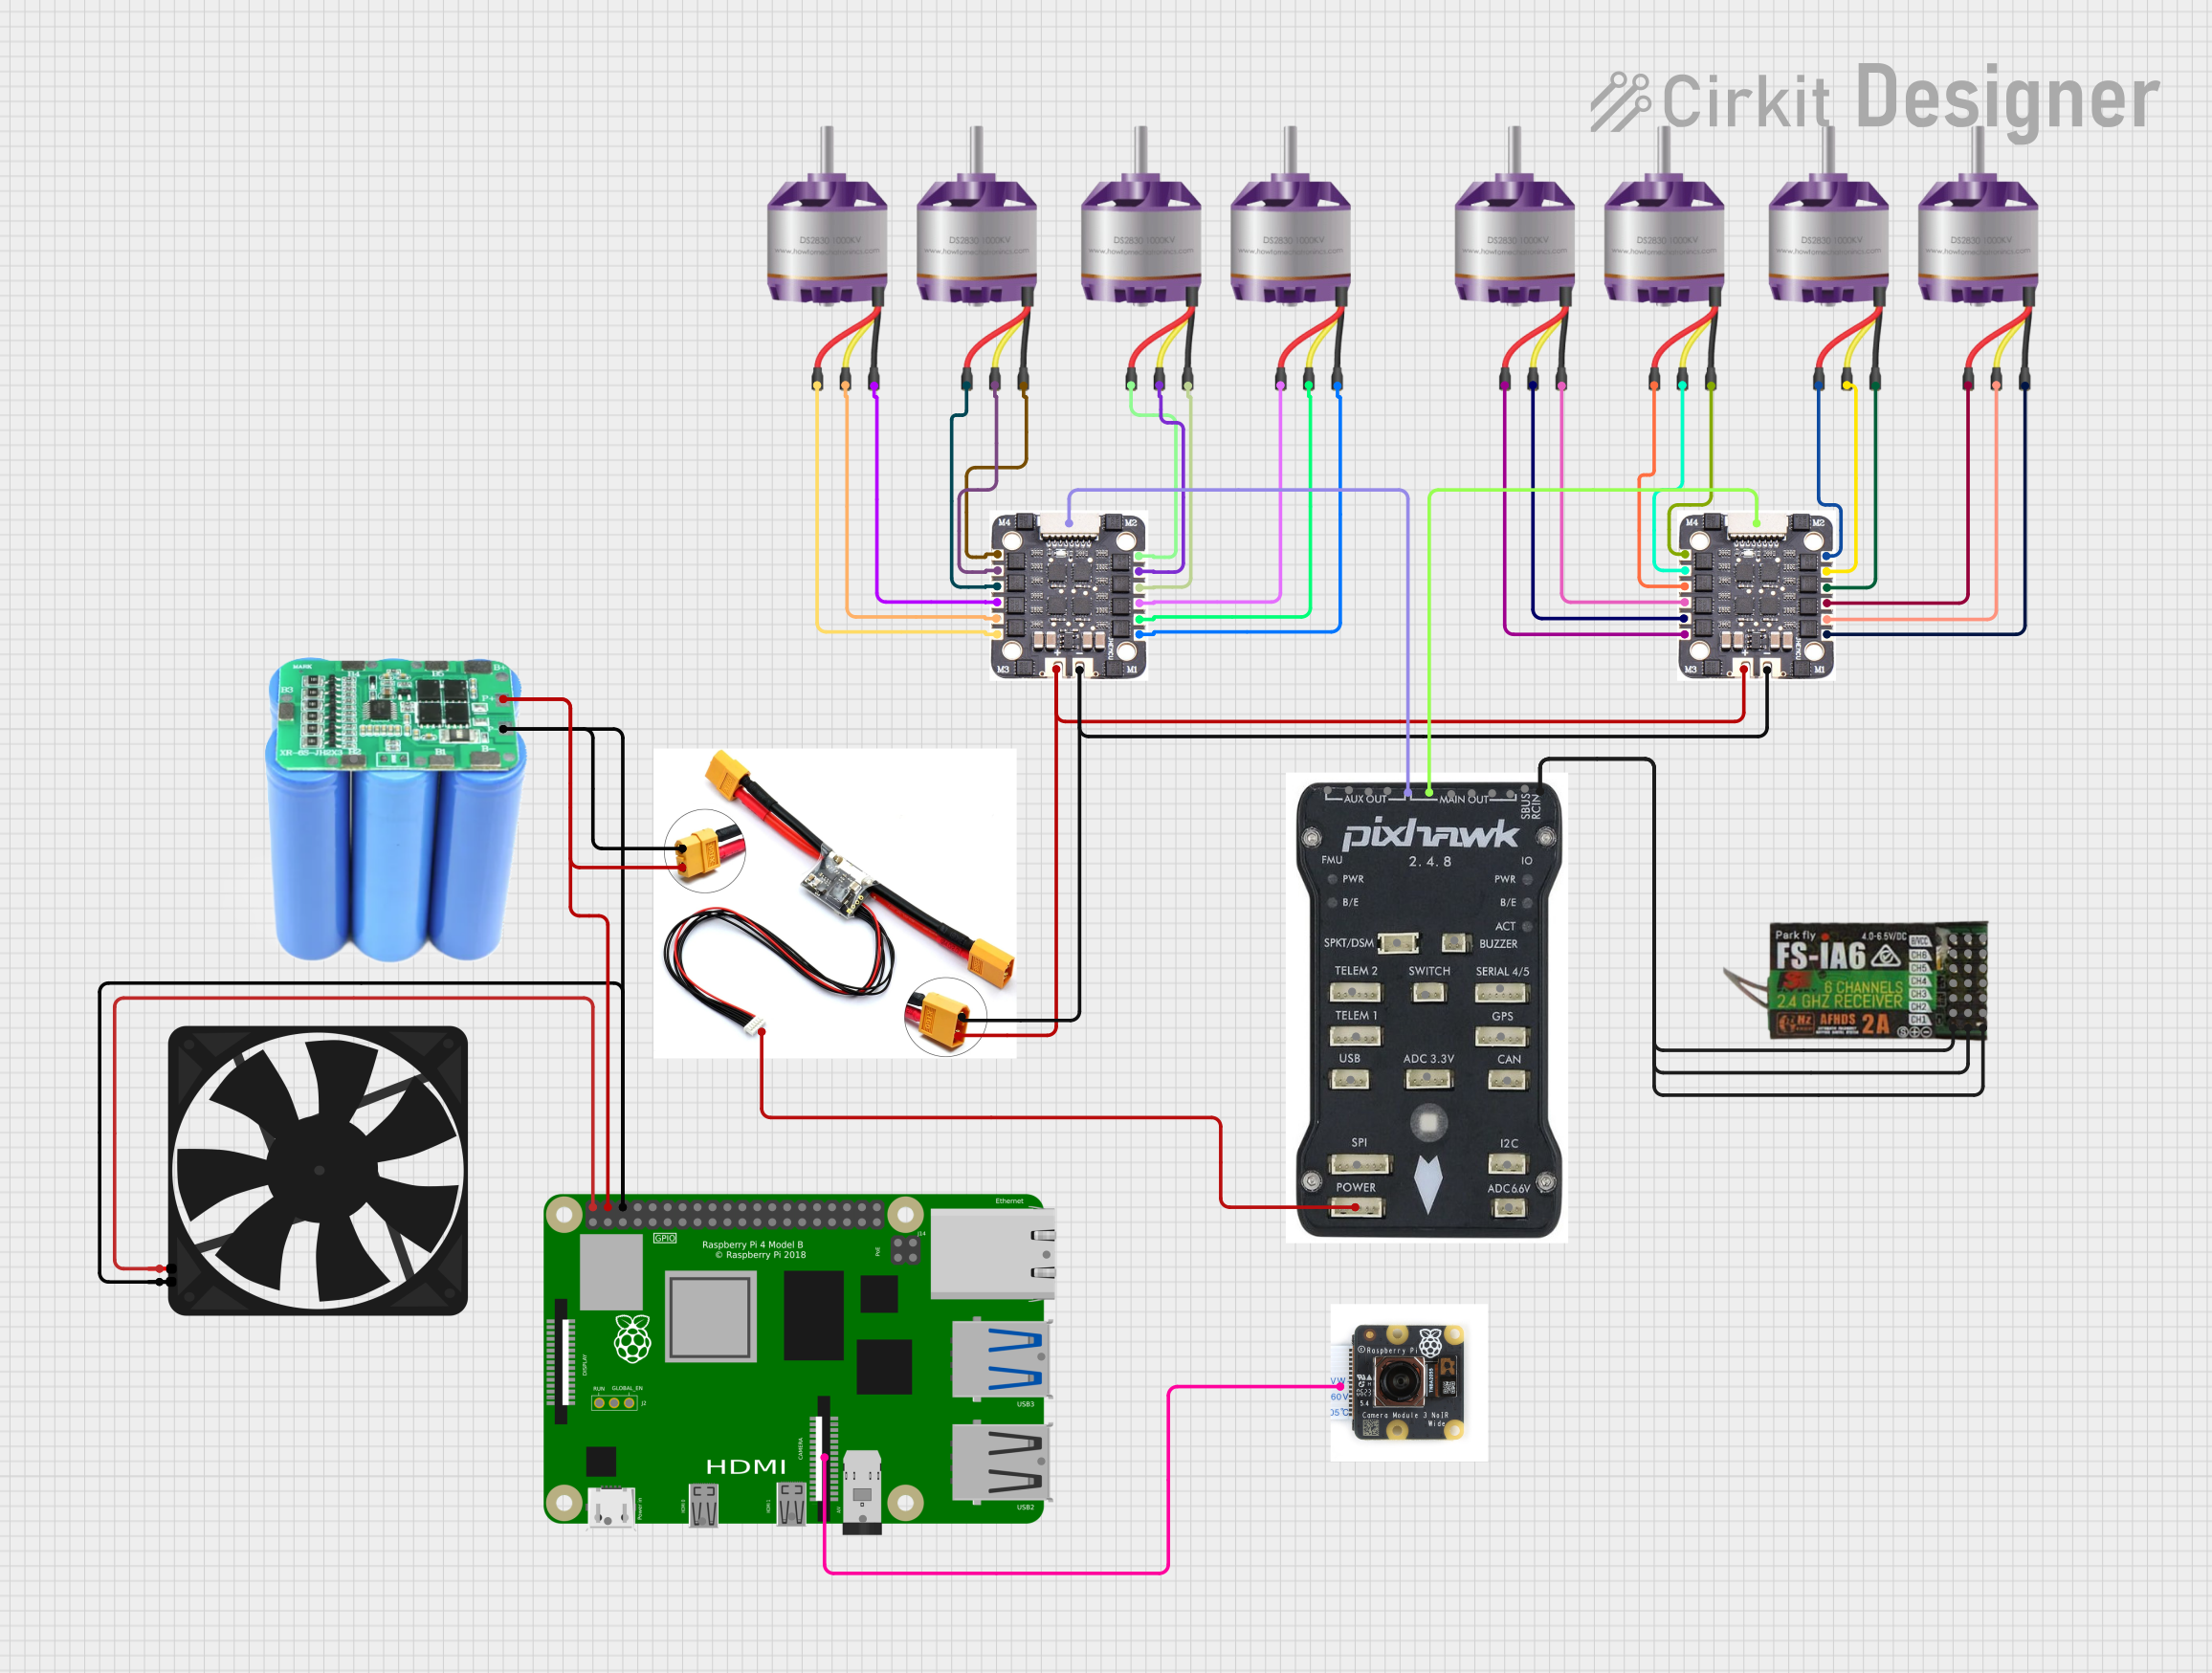
This circuit is designed for a multi-motor application, likely a drone or a similar vehicle, featuring eight brushless motors controlled by two 4-in-1 electronic speed controllers (ESCs). The ESCs are powered by a 3s2p 18650 battery pack and interfaced with a Pixhawk flight controller for motor management. Additionally, the system includes a Raspberry Pi 4B for advanced processing and control, which is connected to a NoIR camera module and a cooling fan, and a power module to supply and monitor the power to the Pixhawk.
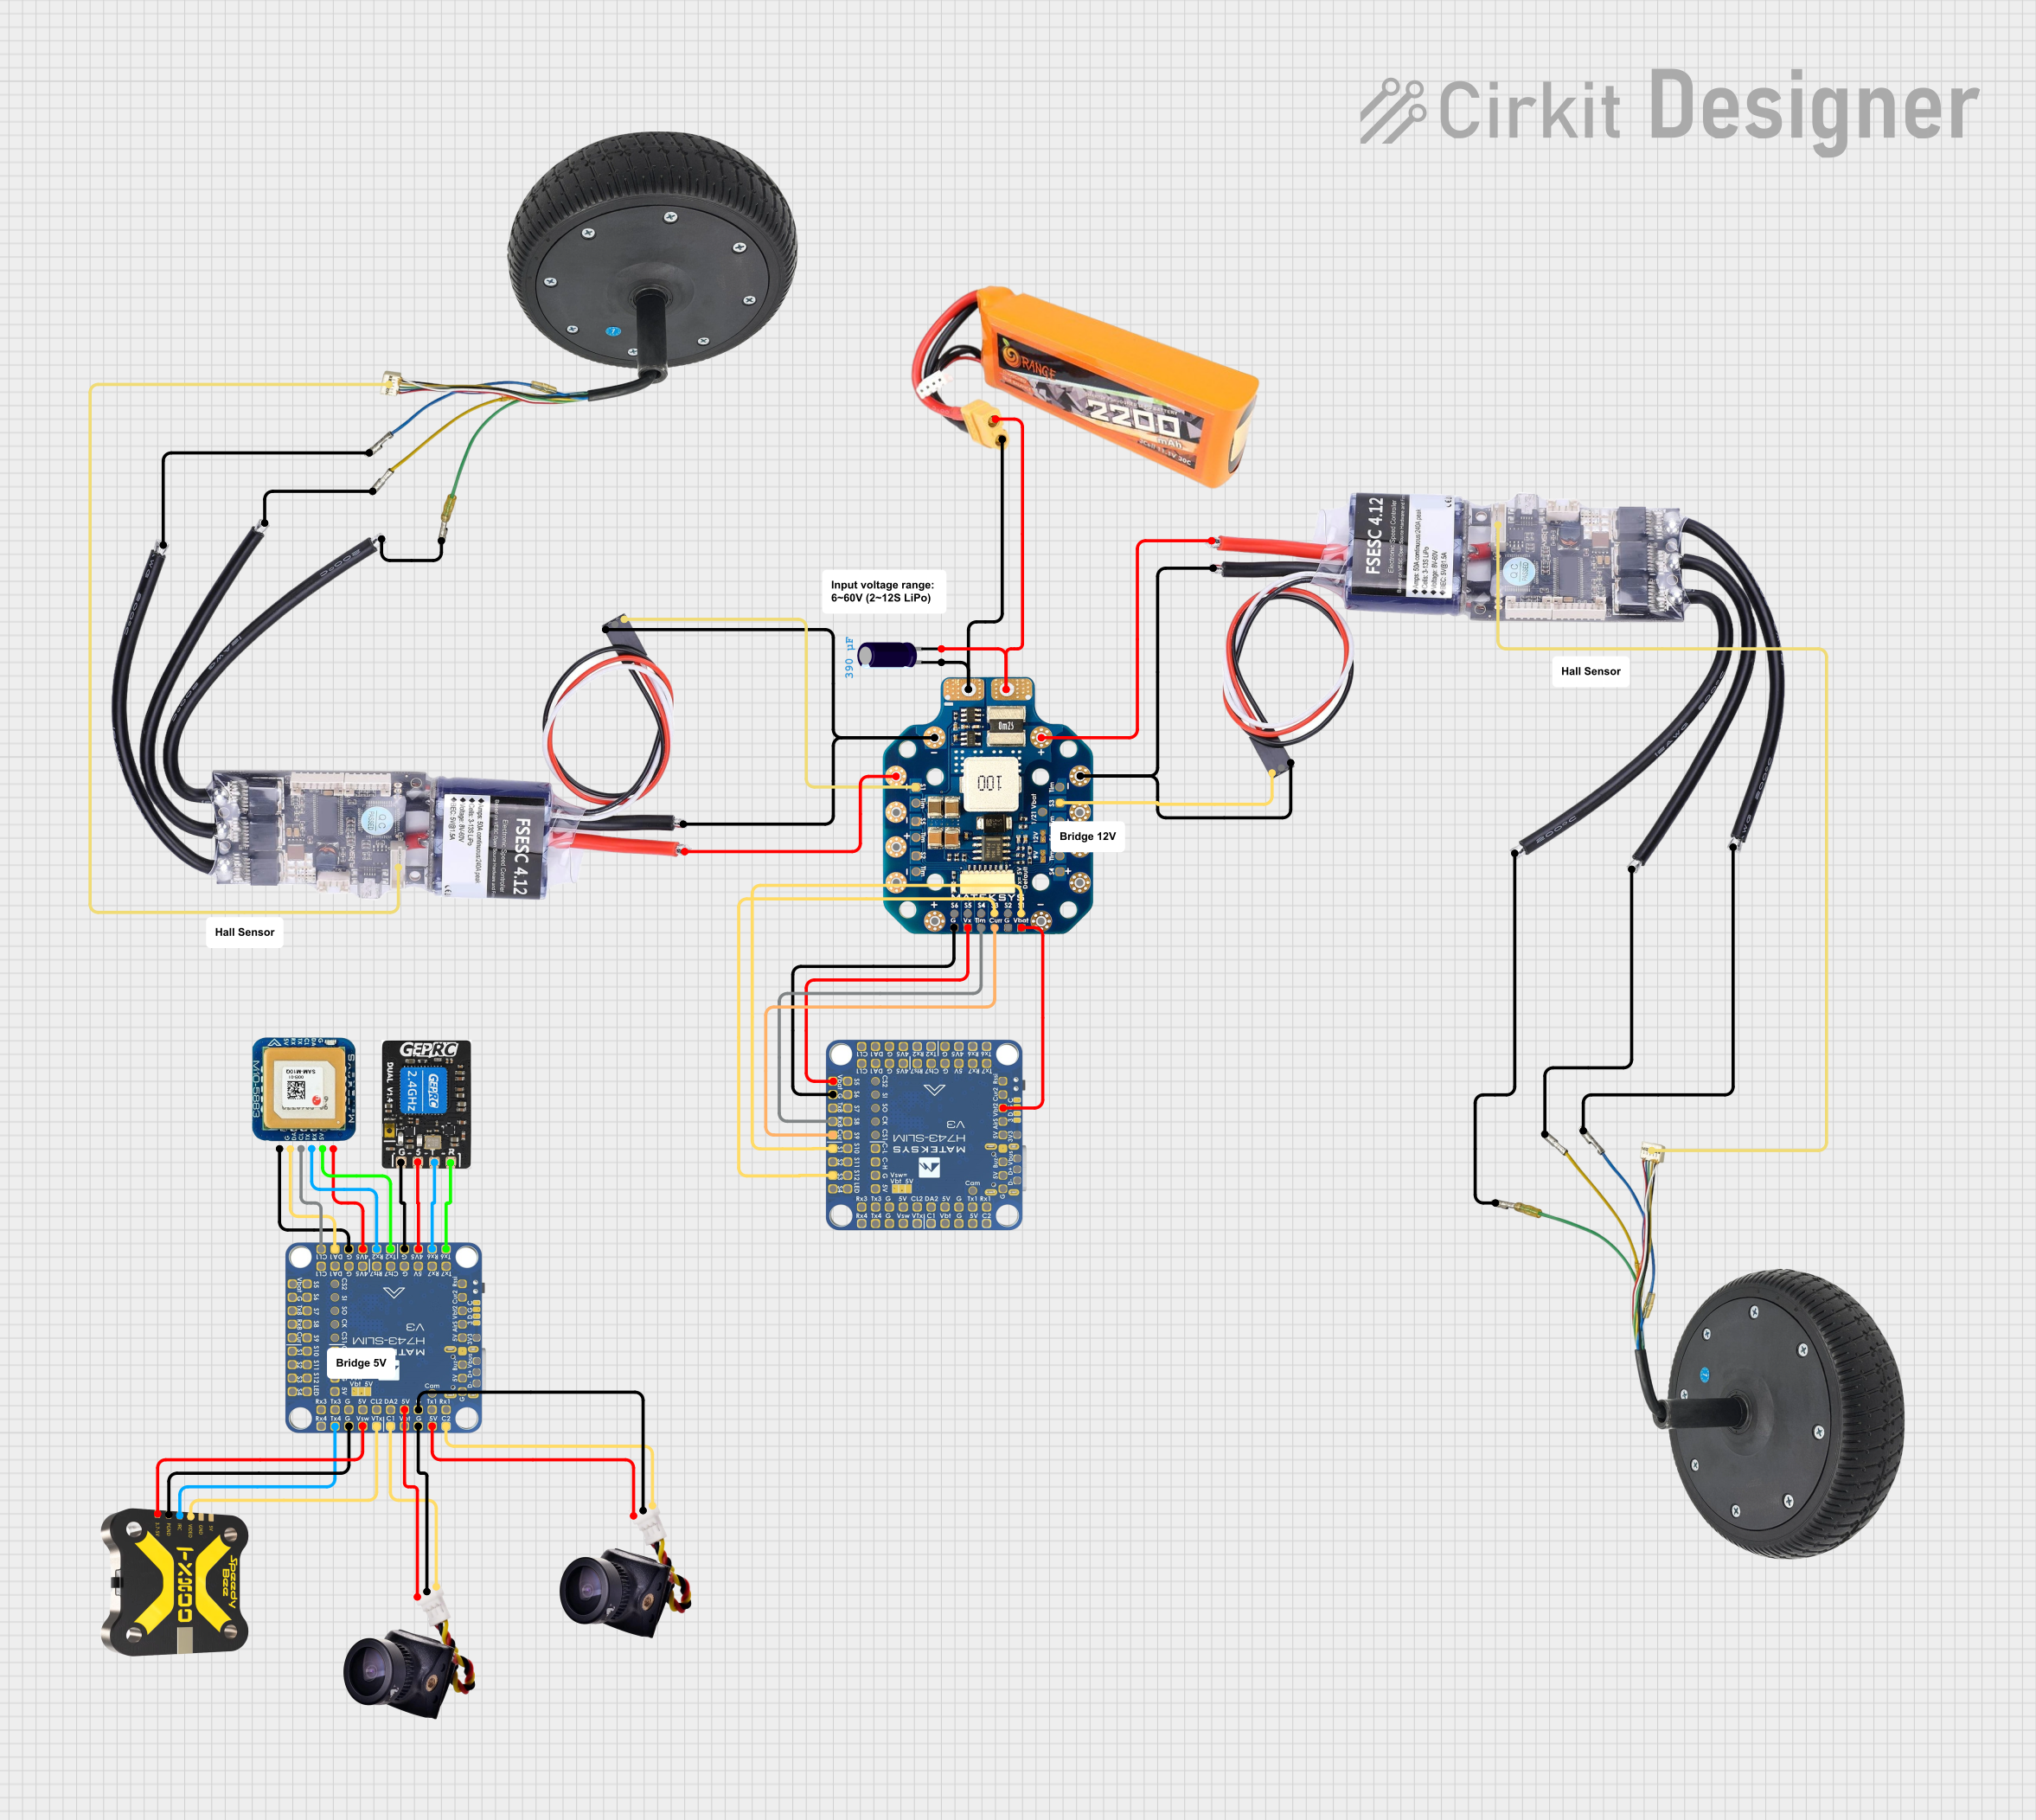
This circuit appears to be a power distribution and control system for a vehicle with two motorized wheels, possibly a drone or a robot. It includes a lipo battery connected to a Power Distribution Board (PDB) that distributes power to two Electronic Speed Controllers (ESCs) which in turn control the speed and direction of the motors. The system also integrates a flight controller (H743-SLIM V3) for managing various peripherals including GPS, FPV camera system, and a telemetry link (ExpressLRS).
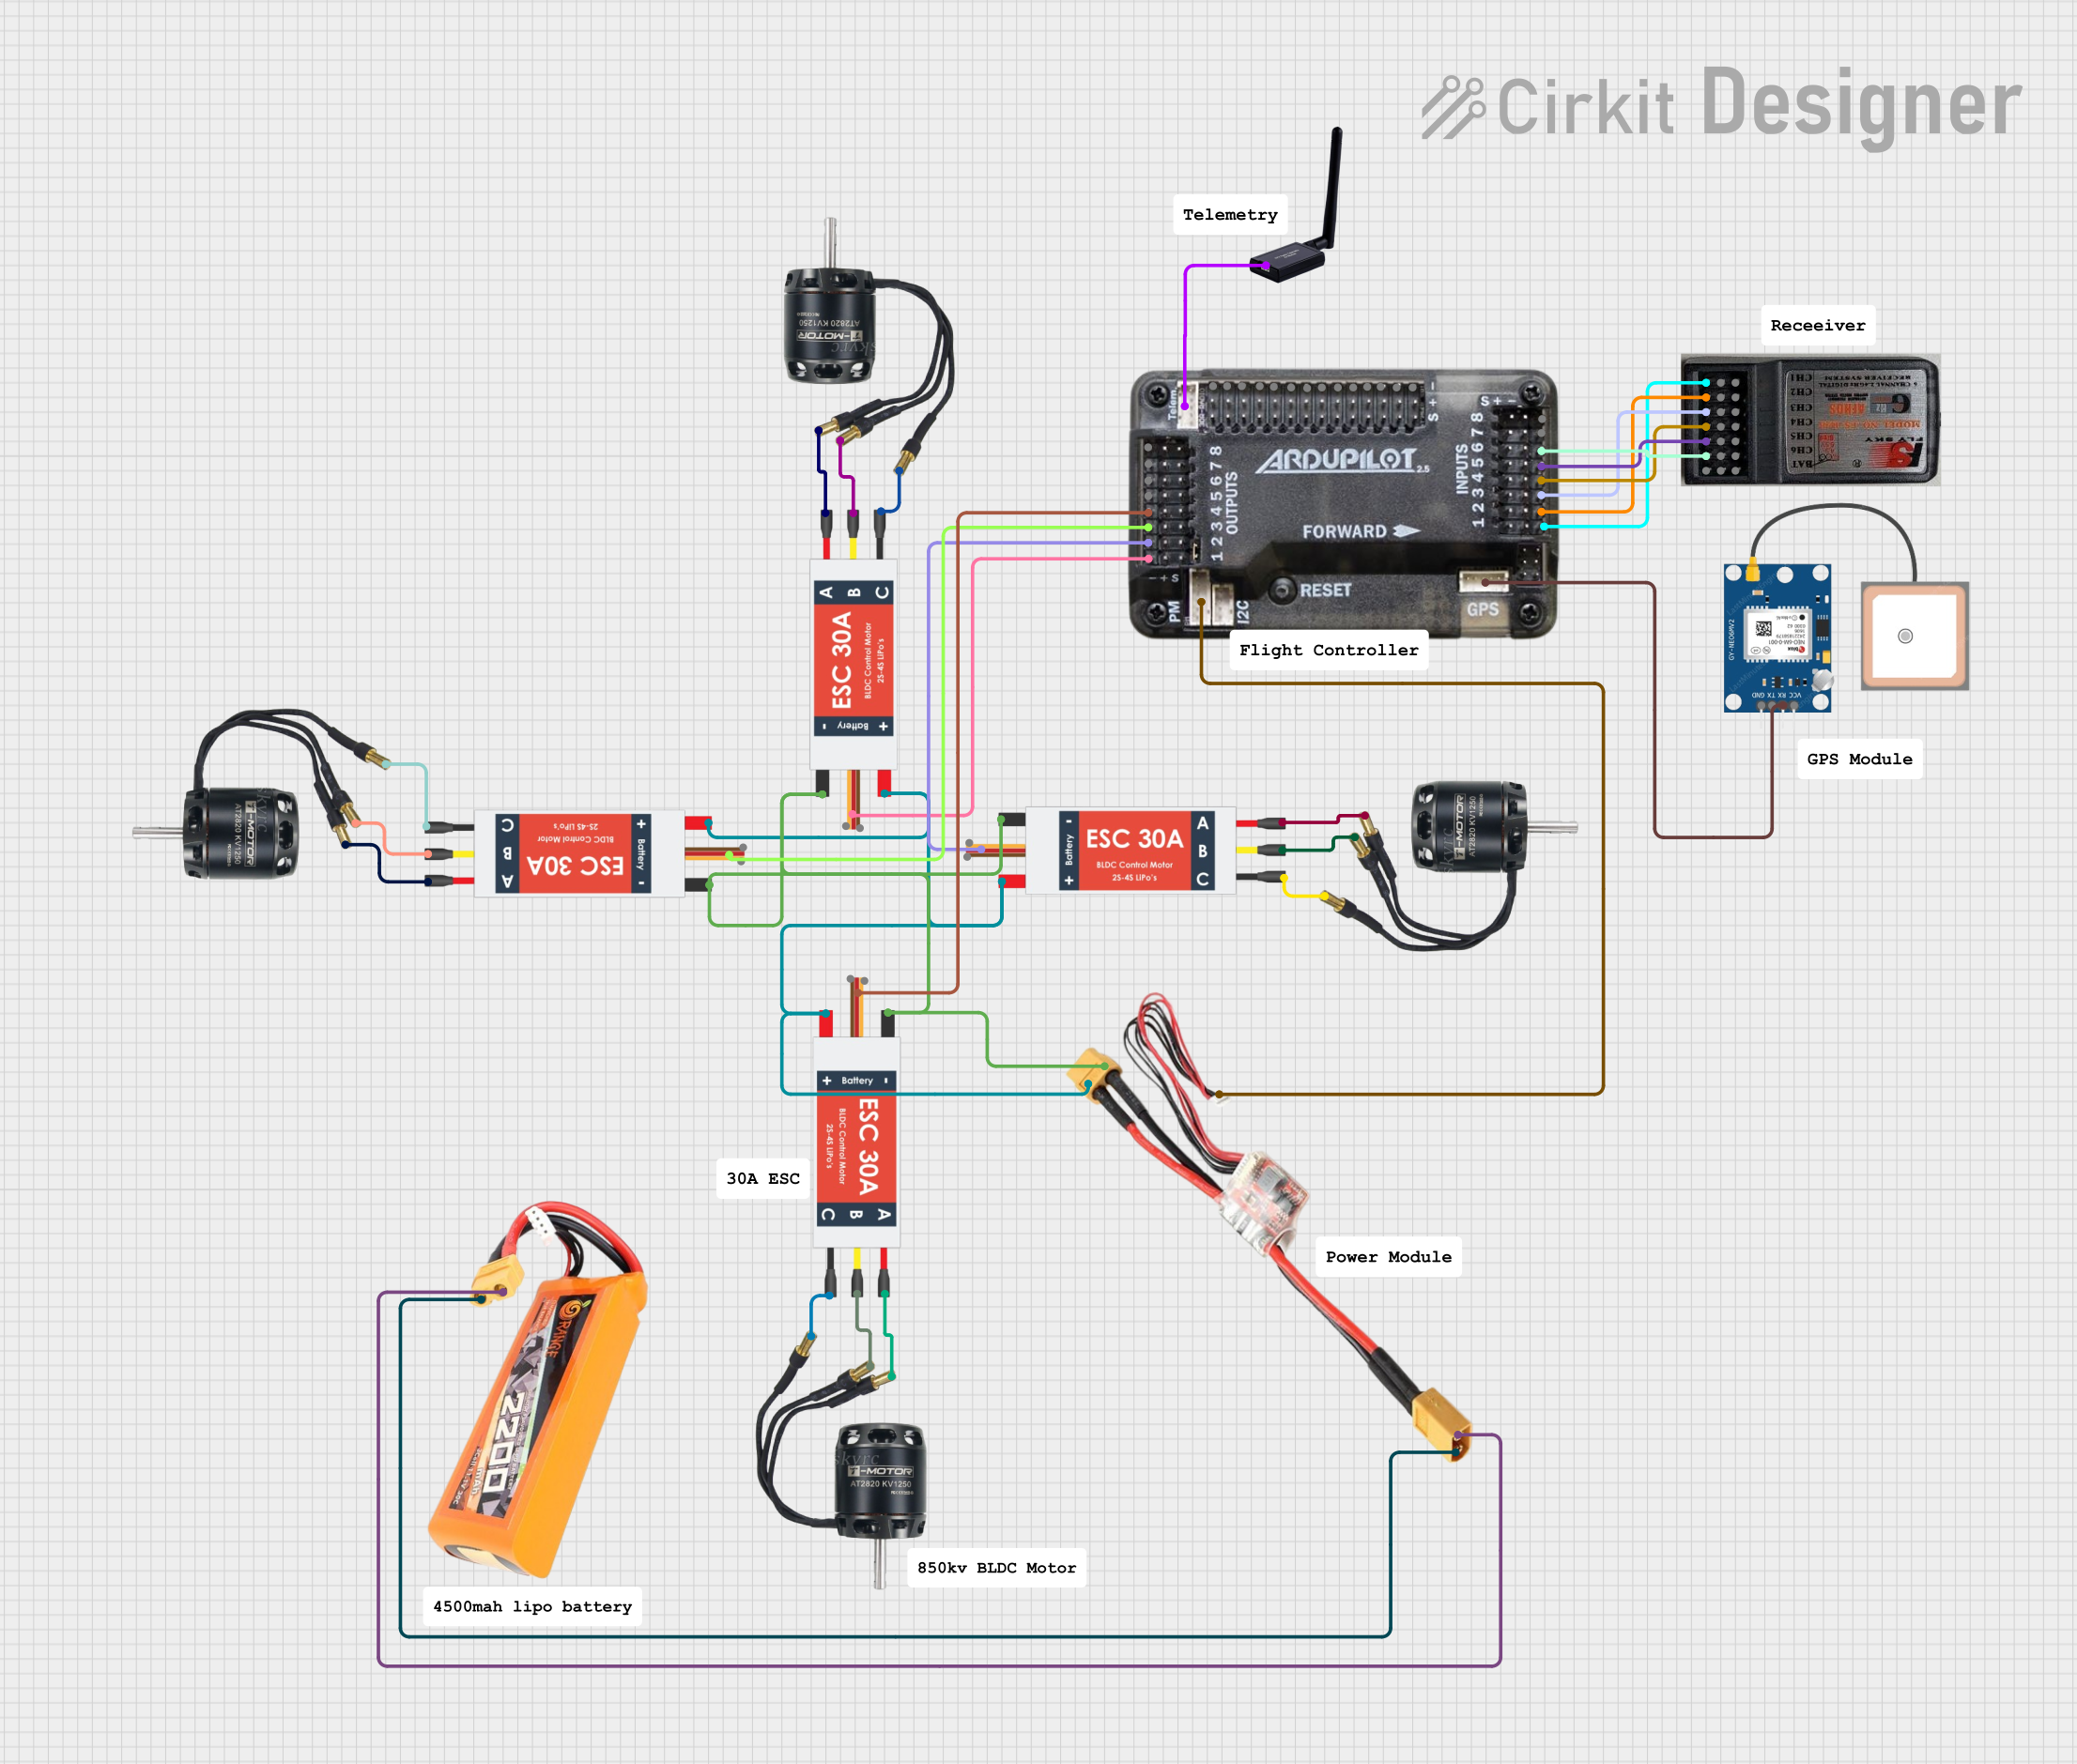
This circuit is designed for a quadcopter, featuring four BLDC motors each controlled by an Electronic Speed Controller (ESC). The ESCs are powered by a LiPo battery through a power module, and the system is managed by an APM 2.0 flight controller, which also interfaces with a GPS module, an RC receiver, and telemetry for communication.
Below are the key technical details for the ESC 60A:
Parameter
Value
Manufacturer
BelHelix
Part ID
ESC
Continuous Current Rating
60A
Peak Current Rating
80A (for 10 seconds)
Input Voltage Range
2S–6S LiPo (7.4V–22.2V)
Motor Compatibility
Brushless motors (sensorless)
BEC Output
5V/3A
PWM Signal Range
1ms–2ms (standard RC signal)
Dimensions
70mm x 35mm x 15mm
Weight
45g
Operating Temperature
-10°C to 60°C
Protection Features
Overcurrent, overheat, and low-voltage cutoff
Pin Configuration and Descriptions
The ESC 60A has the following connections:
Pin/Connector
Description
Power Input (+)
Positive terminal for battery connection (red wire).
Power Input (-)
Negative terminal for battery connection (black wire).
Motor Output A
Connects to one of the three brushless motor wires.
Motor Output B
Connects to one of the three brushless motor wires.
Motor Output C
Connects to one of the three brushless motor wires.
Signal Input
Receives PWM signal from the flight controller or RC receiver (white wire).
Ground (GND)
Ground connection for the signal input (black wire).
BEC Output (+)
Provides 5V power for external devices like an RC receiver or microcontroller.
Usage Instructions
How to Use the ESC 60A in a Circuit
Connect the Power Supply:
Attach the red wire to the positive terminal of your LiPo battery.
Attach the black wire to the negative terminal of your LiPo battery.
Ensure the battery voltage is within the supported range (7.4V–22.2V).
Connect the Motor:
Connect the three motor output wires (A, B, C) to the brushless motor.
If the motor spins in the wrong direction, swap any two of the motor wires.
Connect the Signal Input:
Connect the white signal wire to the PWM output of your RC receiver or flight controller.
Connect the black ground wire to the ground of your RC receiver or flight controller.
Power On:
Turn on the power supply. The ESC will emit a series of beeps to indicate initialization.
The number of beeps corresponds to the number of LiPo cells detected.
Throttle Calibration (Optional):
Set the throttle stick on your transmitter to maximum.
Power on the ESC and wait for a confirmation beep.
Move the throttle stick to the minimum position and wait for another confirmation beep.
The ESC is now calibrated.
Important Considerations and Best Practices
Cooling: Ensure adequate airflow or cooling to prevent overheating during operation.
Battery Compatibility: Use only LiPo batteries within the specified voltage range.
Signal Quality: Use a clean and stable PWM signal for optimal performance.
Wiring: Double-check all connections before powering on to avoid short circuits or damage.
Mounting: Secure the ESC in a vibration-free location to prevent damage during operation.
Example: Using the ESC 60A with an Arduino UNO
The ESC 60A can be controlled using an Arduino UNO by generating a PWM signal. Below is an example code snippet:
#include <Servo.h> // Include the Servo library to generate PWM signals

Servo esc; // Create a Servo object to control the ESC

void setup() {
  esc.attach(9); // Attach the ESC signal wire to pin 9 on the Arduino
  esc.writeMicroseconds(1000); // Send minimum throttle (1ms pulse)
  delay(2000); // Wait for the ESC to initialize
}

void loop() {
  esc.writeMicroseconds(1500); // Send mid-throttle (1.5ms pulse)
  delay(5000); // Run the motor at mid-speed for 5 seconds

  esc.writeMicroseconds(2000); // Send maximum throttle (2ms pulse)
  delay(5000); // Run the motor at full speed for 5 seconds

  esc.writeMicroseconds(1000); // Send minimum throttle to stop the motor
  delay(5000); // Wait for 5 seconds before repeating
}
Notes:
Ensure the ESC is properly calibrated before running the code.
Always test the setup without a propeller attached to the motor for safety.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Spin:
Check all connections, especially the signal wire.
Ensure the battery is charged and within the supported voltage range.
Verify that the ESC is receiving a valid PWM signal.
Motor Spins in the Wrong Direction:
Swap any two of the motor output wires (A, B, or C).
ESC Overheats:
Ensure proper cooling and avoid exceeding the continuous current rating.
Check for obstructions in the airflow or excessive load on the motor.
ESC Beeps Continuously:
This indicates a low-voltage or signal error. Verify the battery voltage and signal connection.
Throttle Calibration Fails:
Ensure the transmitter is set to the correct throttle range.
Repeat the calibration process carefully.
FAQs
Can I use the ESC 60A with a brushed motor?
No, this ESC is designed specifically for brushless motors.
What happens if I exceed the peak current rating?
The ESC may shut down temporarily to protect itself or could be permanently damaged. Always stay within the specified ratings.
Can I power my Arduino directly from the ESC's BEC output?
Yes, the 5V/3A BEC output can power an Arduino or other low-power devices.
How do I update the firmware on the ESC?
Firmware updates are not supported for this model.
By following this documentation, you can effectively use the ESC 60A by BelHelix in your projects. For further assistance, refer to the manufacturer's support resources.

 Open Project in Cirkit Designer