The TMC2209 is a high-performance stepper motor driver designed for precise and efficient control of stepper motors. Manufactured by Trinamic, this driver is widely used in applications requiring silent operation, smooth motion, and advanced motor control. It supports features such as StealthChop2 for quiet operation, SpreadCycle for high-speed performance, and configurable microstepping up to 1/256 steps. The TMC2209 is ideal for 3D printers, CNC machines, robotics, and other motion control systems.
Explore Projects Built with TMC2209 Stepper motor Driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
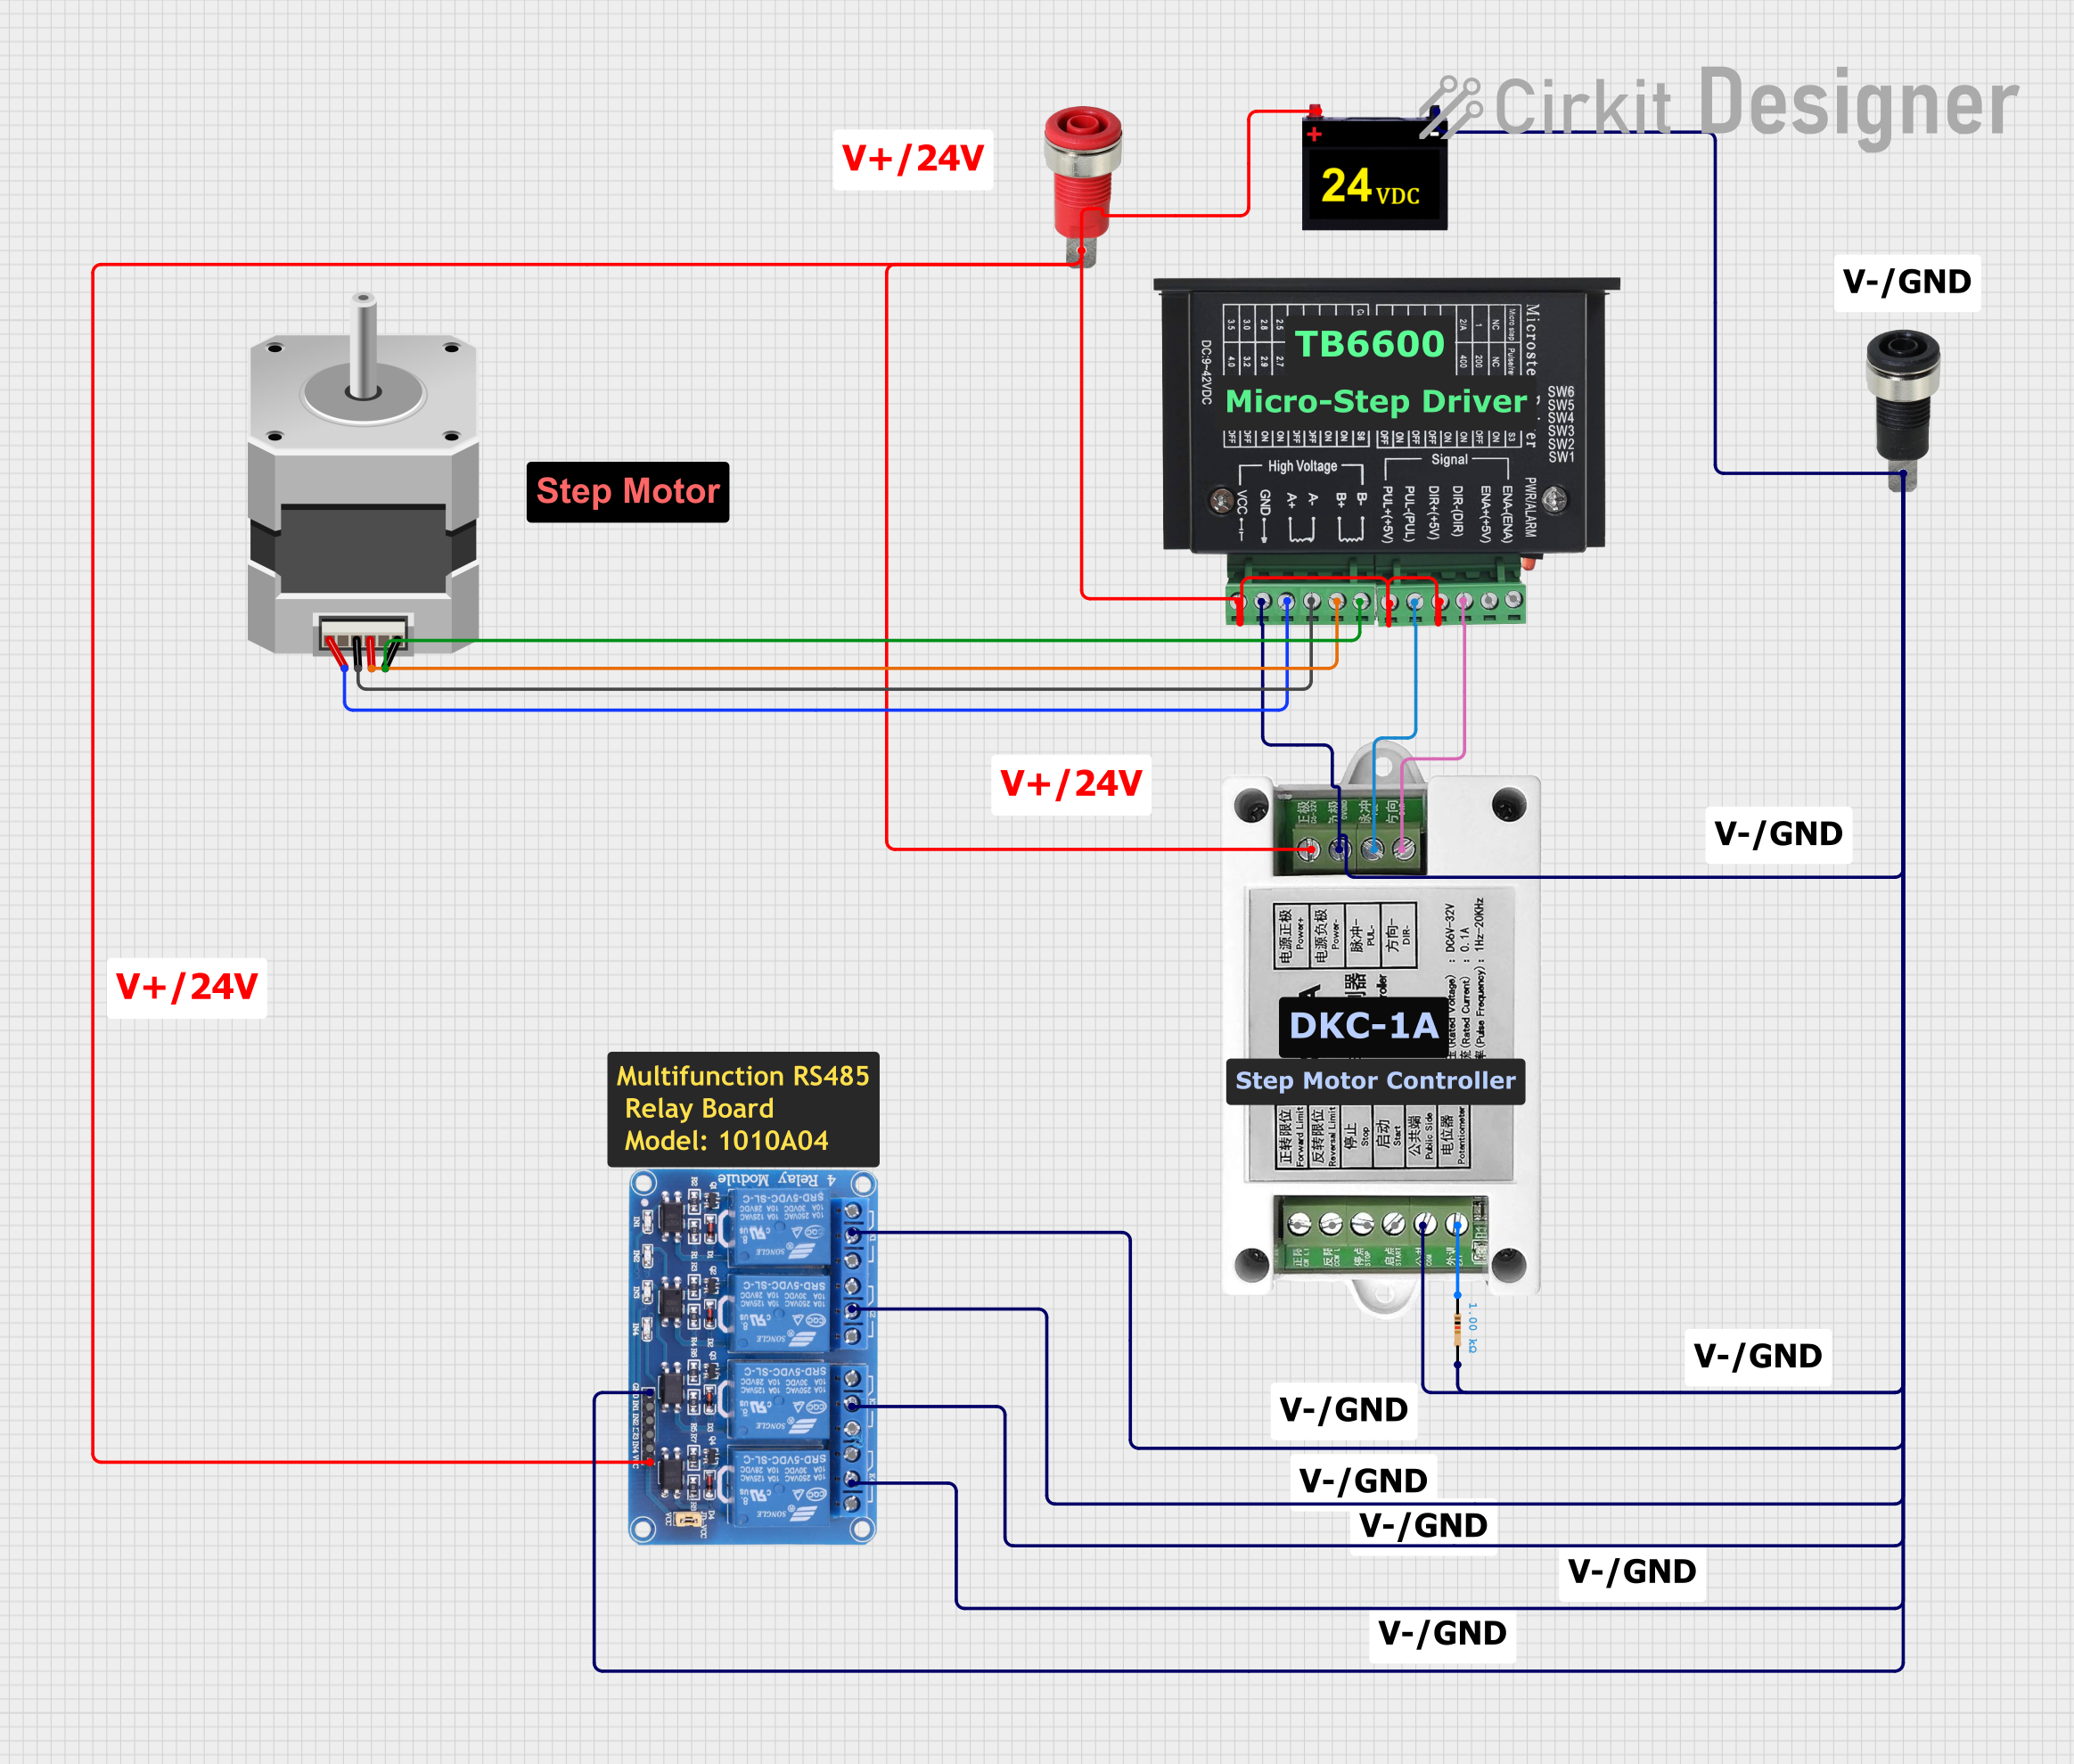
This circuit controls a bipolar stepper motor using a tb6600 micro stepping motor driver and a DKC-1A stepper motor controller. The system is powered by a 24VDC power supply and includes a relay module for additional control functionalities.
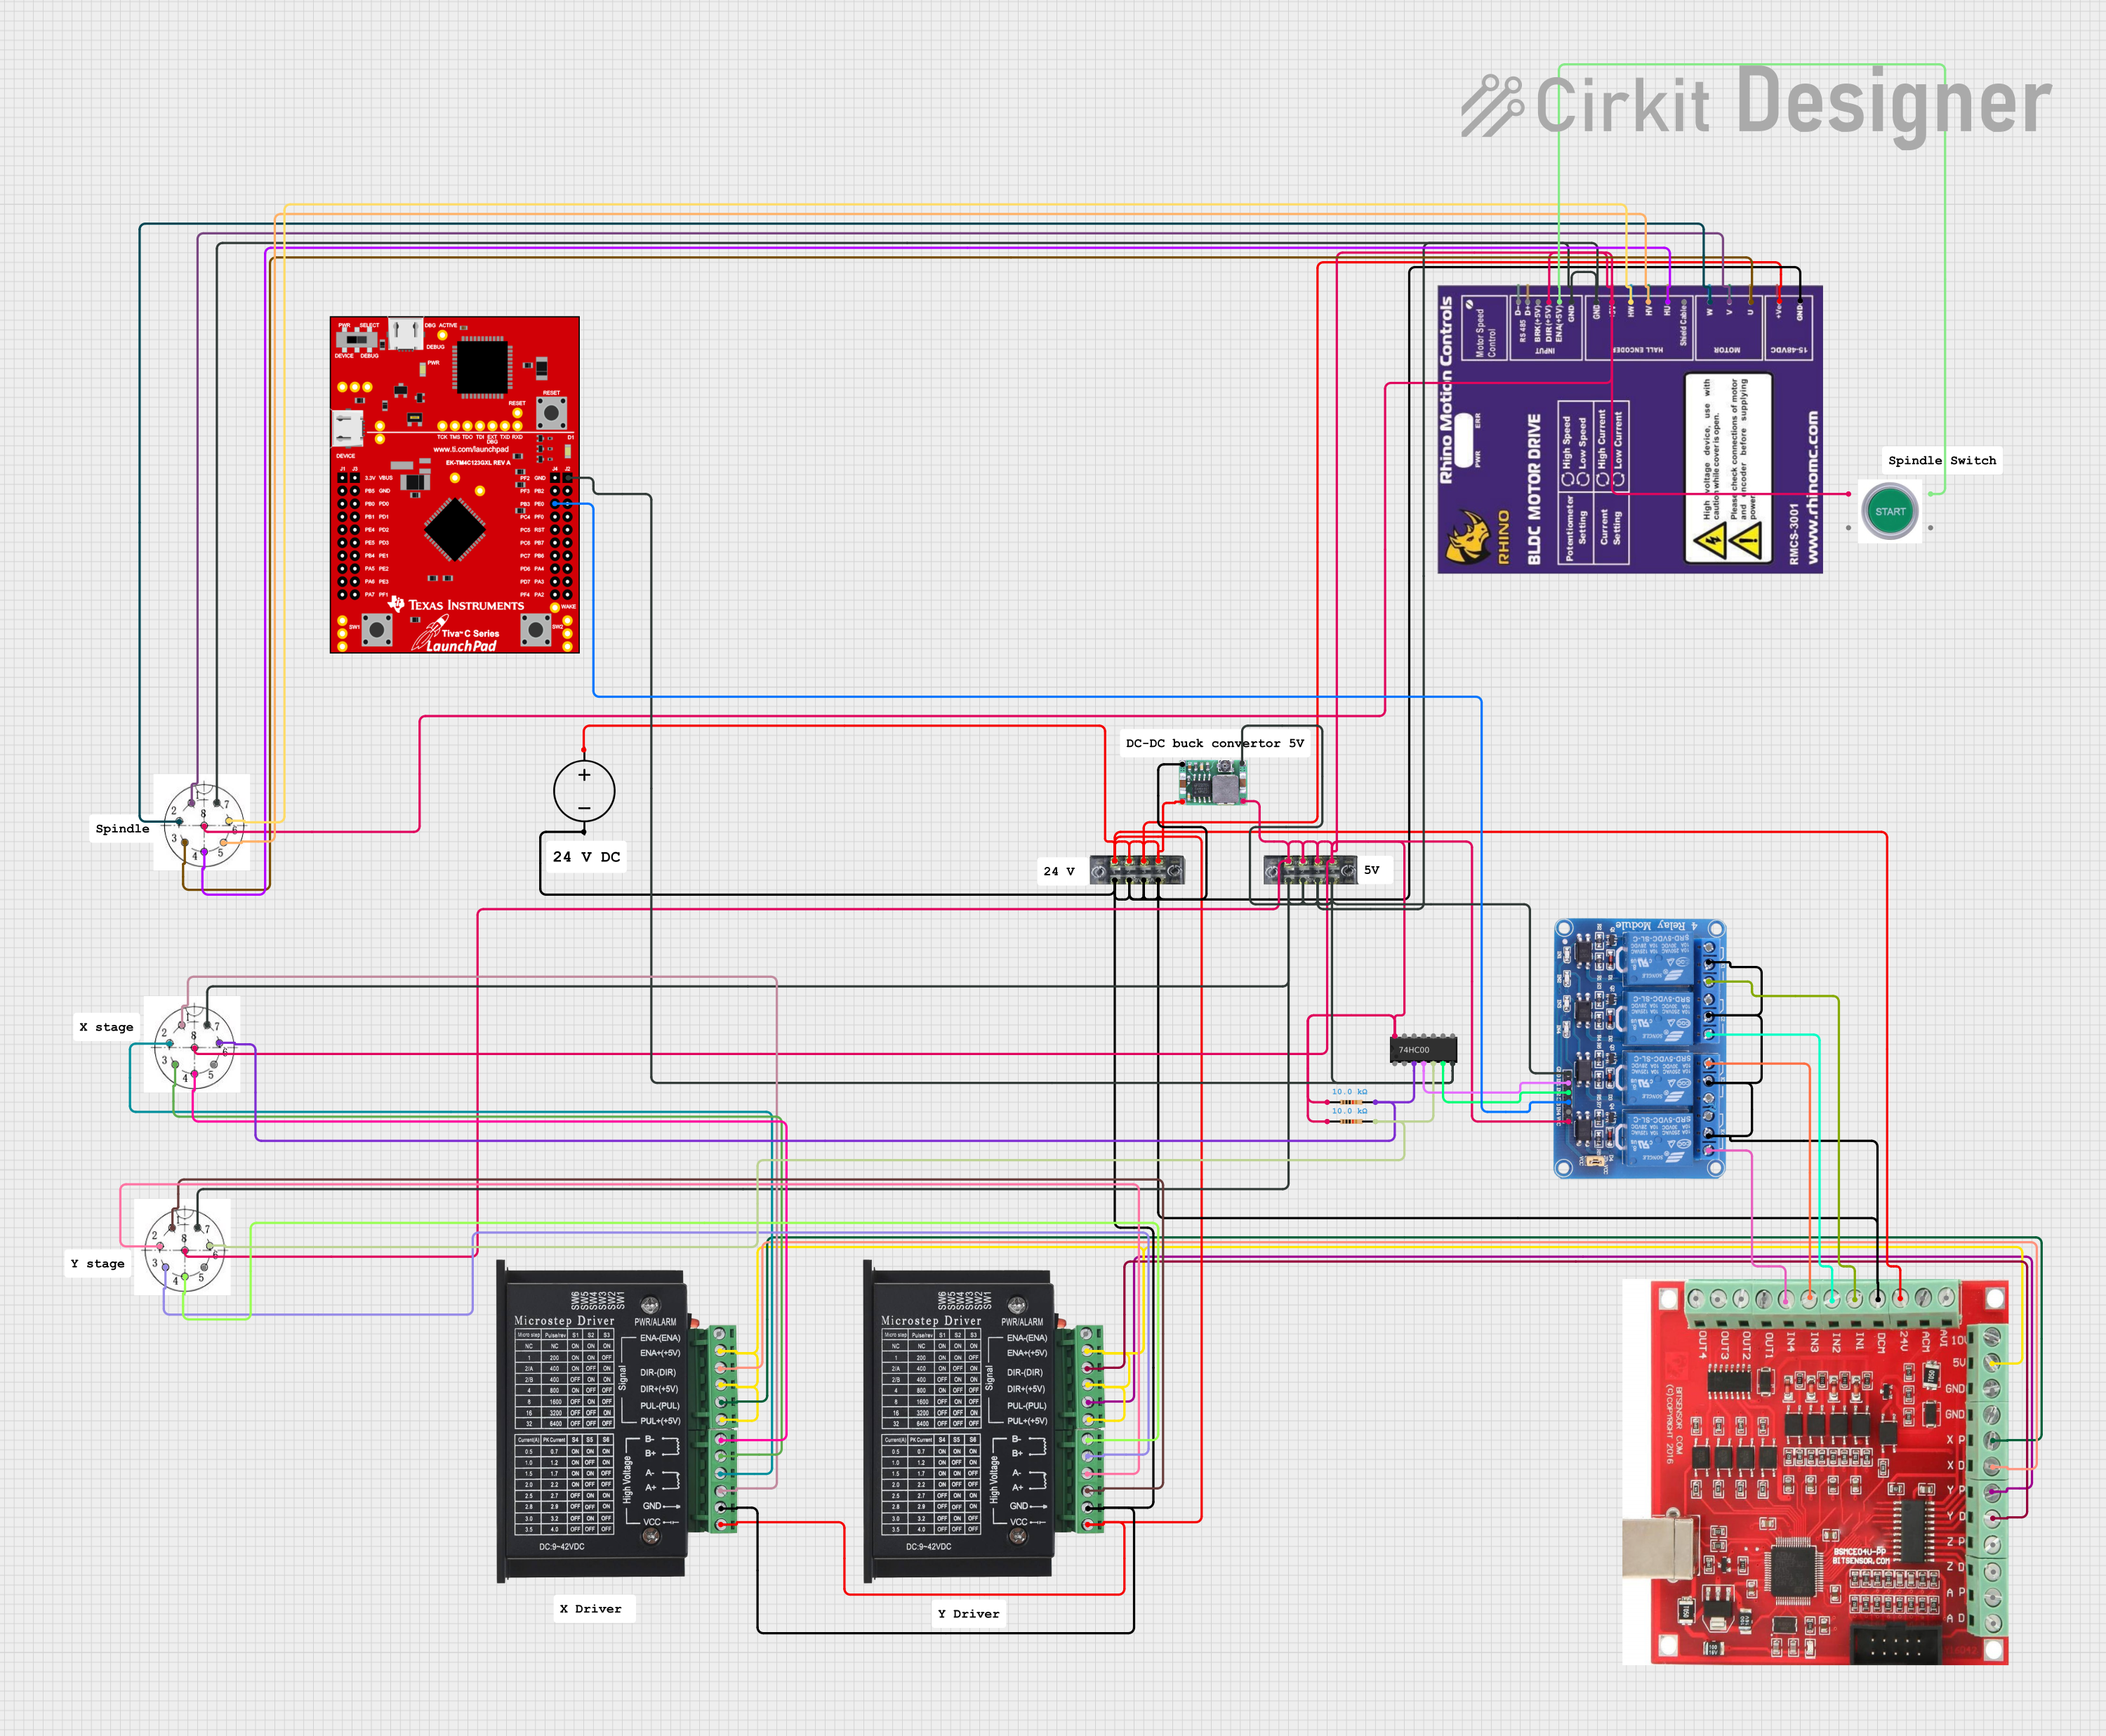
This circuit appears to be a control system for a CNC machine or similar automated equipment. It includes two tb6600 Micro Stepping Motor Drivers for controlling stepper motors, a DC power source with a step-down buck converter to provide the necessary voltage levels, and a 4-channel relay module for switching higher power loads. The MAch3 CNC USB interface suggests the system is designed to interface with computer numerical control software, and the RMCS_3001 BLDC Driver indicates the presence of a brushless DC motor control. The Tiva C launchpad microcontroller and various connectors imply that the system is modular and may be programmable for specific automation tasks.
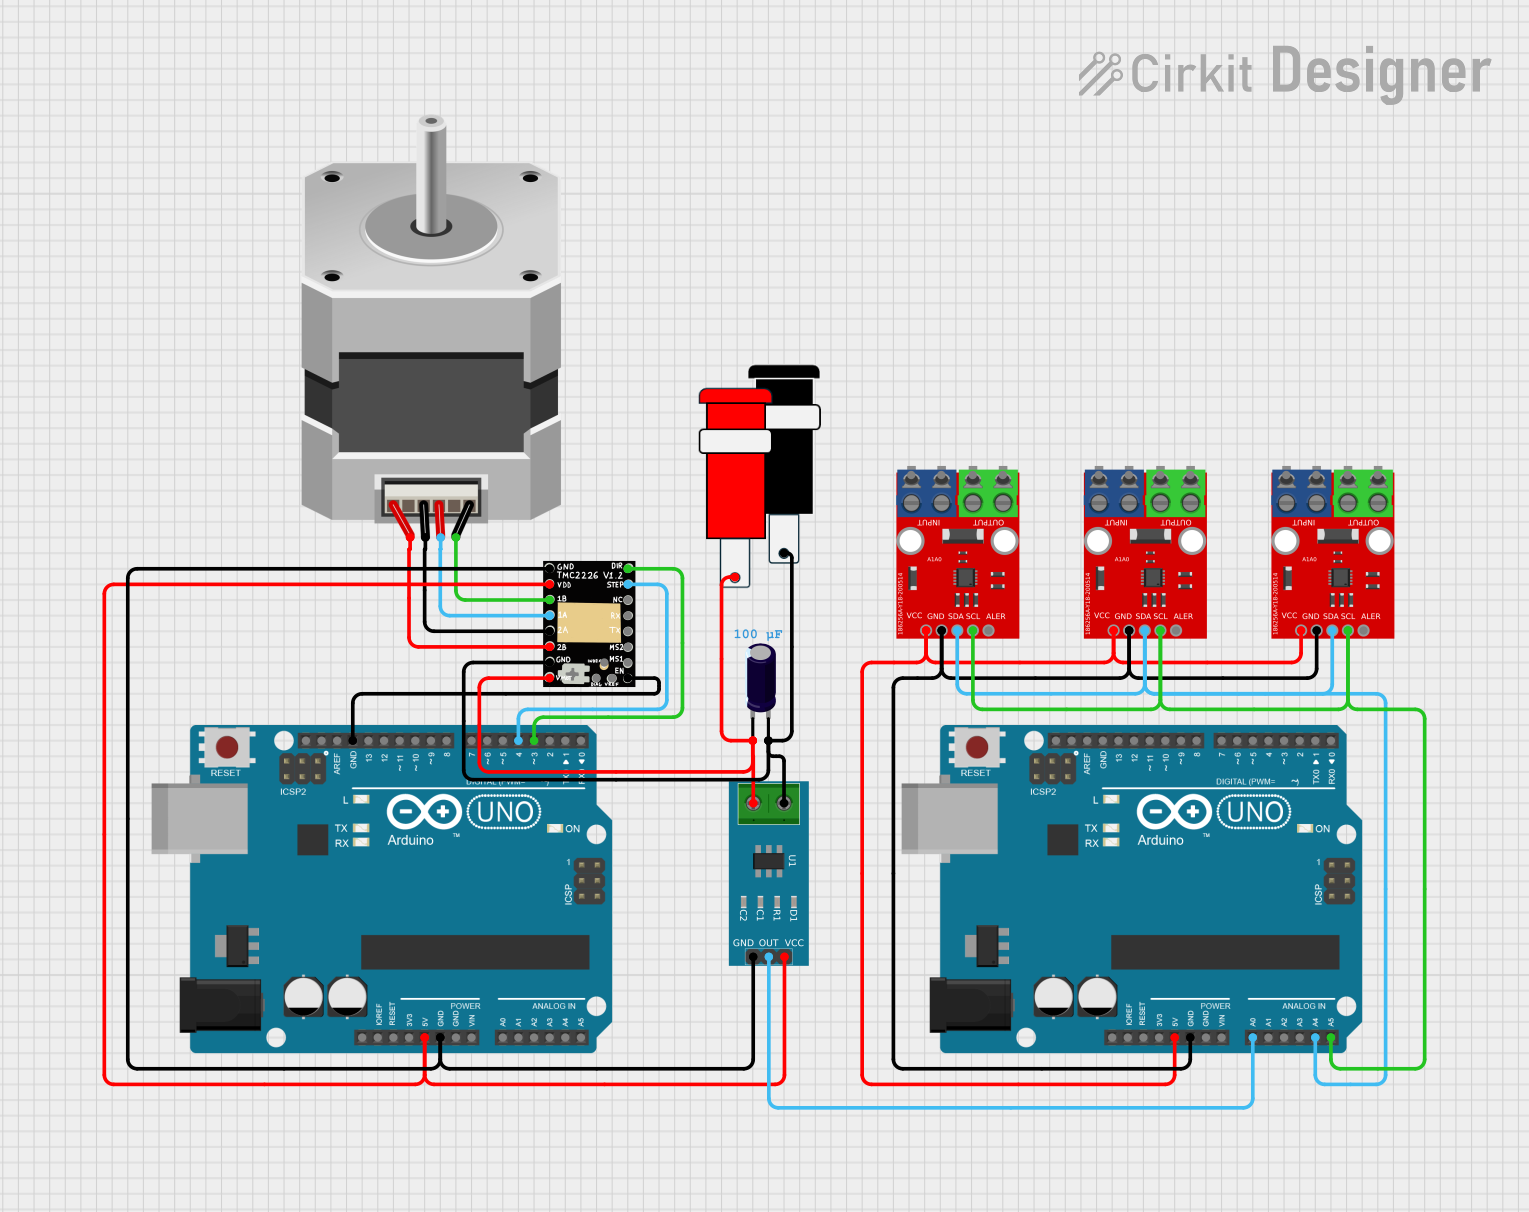
This circuit controls a bipolar stepper motor using a TMC2226 stepper driver, which is managed by an Arduino UNO. The circuit also includes a current sensor to monitor the motor's current, and multiple Nazarbayev University components are interconnected for additional functionality. Power is supplied through a 5V connector, and an electrolytic capacitor is used for voltage stabilization.
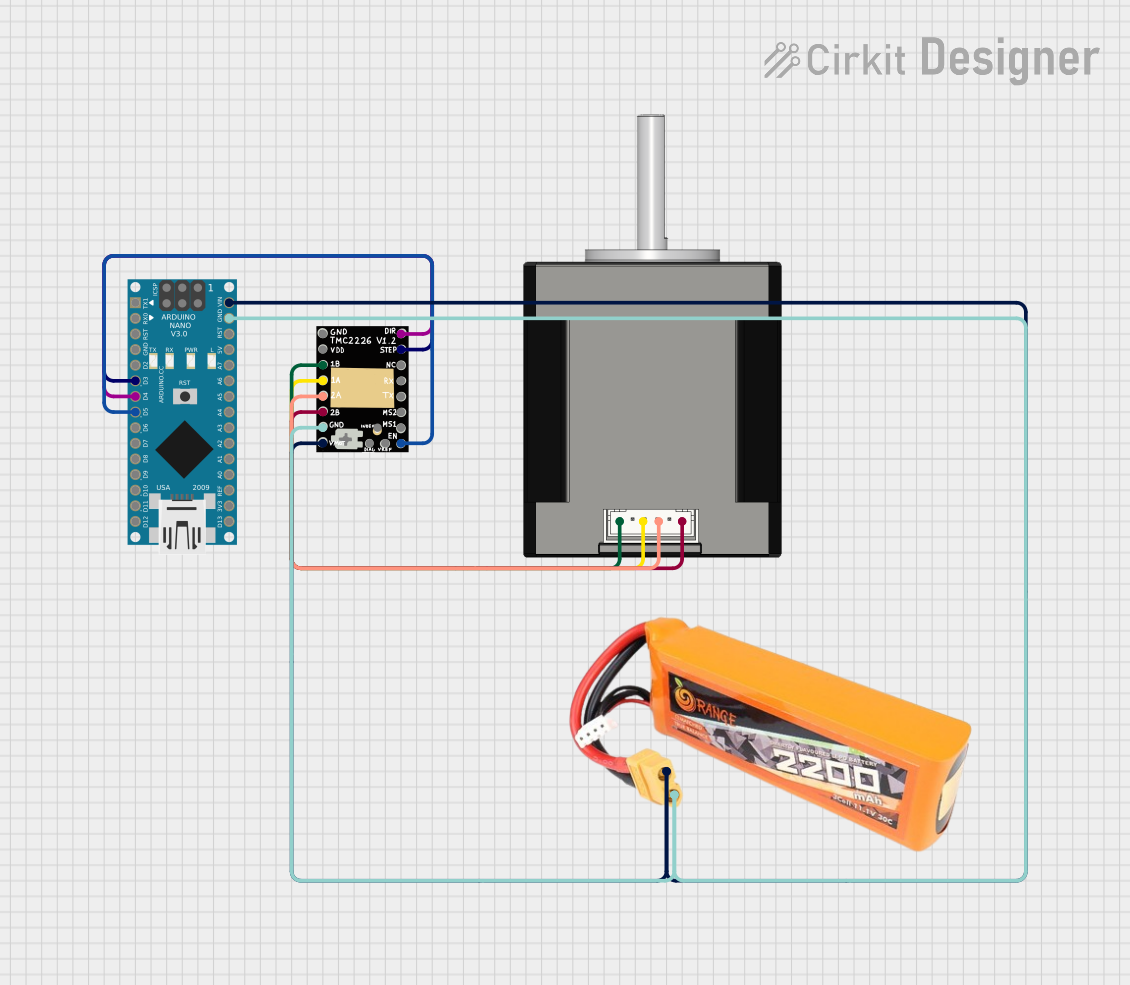
This circuit is designed to control a Nema 17 stepper motor using an Arduino Nano and a TMC2226 stepper driver. The Arduino Nano is interfaced with the TMC2226 driver to send step, direction, and enable signals, allowing for precise control of the motor's movements. Power is supplied to the motor driver and the Arduino through a connection to a lipo battery, ensuring that the motor receives the necessary voltage for operation.
Automated systems requiring advanced stepper motor control
Technical Specifications
Key Technical Details
Parameter
Value
Operating Voltage (VIO)
3.3V or 5V
Motor Supply Voltage (VM)
4.75V to 29V
Maximum Motor Current
2.0A RMS (2.8A peak)
Microstepping Modes
Up to 1/256 steps
Communication Interface
UART
Logic Levels
3.3V or 5V compatible
Features
StealthChop2, SpreadCycle, CoolStep, StallGuard4
Pin Configuration and Descriptions
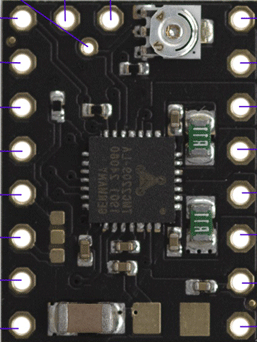
The TMC2209 is typically available in a 28-pin package. Below is the pin configuration:
Pin Number
Pin Name
Description
1
GND
Ground connection
2
VM
Motor power supply (4.75V to 29V)
3
VIO
Logic voltage input (3.3V or 5V)
4
EN
Enable pin (active low)
5
DIR
Direction control input
6
STEP
Step pulse input
7
UART
UART communication pin for configuration and diagnostics
8
MS1
Microstepping resolution selection
9
MS2
Microstepping resolution selection
10
DIAG
Diagnostic output (e.g., stall detection)
11
INDEX
Index output for step position
12
CFG1
Configuration pin 1
13
CFG2
Configuration pin 2
14
NC
Not connected
15-28
Motor Pins
Connections for motor coils (A1, A2, B1, B2)
Usage Instructions
How to Use the TMC2209 in a Circuit
Power Supply: Connect the motor power supply (VM) to a voltage source between 4.75V and 29V. Ensure the logic voltage (VIO) matches your microcontroller's logic level (3.3V or 5V).
Motor Connections: Connect the stepper motor coils to the motor pins (A1, A2, B1, B2). Ensure proper wiring to avoid incorrect motor operation.
Control Pins: Use the STEP and DIR pins to control the motor's movement and direction. Optionally, configure microstepping using the MS1 and MS2 pins.
UART Configuration: For advanced features like StealthChop2 or CoolStep, connect the UART pin to your microcontroller for communication and configuration.
Enable Pin: Use the EN pin to enable or disable the driver. Pull it low to enable the driver.
Important Considerations
Heat Dissipation: The TMC2209 can generate heat during operation. Use a heatsink or active cooling if necessary.
Current Limiting: Adjust the motor current using the onboard potentiometer or via UART to prevent overheating or motor damage.
Microstepping: Configure the microstepping mode based on your application's precision and speed requirements.
Stall Detection: Use the StallGuard4 feature for sensorless homing or stall detection.
Example Code for Arduino UNO
Below is an example of how to control the TMC2209 using an Arduino UNO:
// Example code to control a stepper motor with the TMC2209 driver
// Connect STEP to pin 2, DIR to pin 3, and EN to pin 4 on the Arduino UNO

#define STEP_PIN 2  // Pin connected to STEP
#define DIR_PIN 3   // Pin connected to DIR
#define EN_PIN 4    // Pin connected to EN

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output
  pinMode(EN_PIN, OUTPUT);   // Set EN pin as output

  digitalWrite(EN_PIN, LOW); // Enable the driver (active low)
  digitalWrite(DIR_PIN, HIGH); // Set direction (HIGH or LOW)
}

void loop() {
  // Generate step pulses to move the motor
  digitalWrite(STEP_PIN, HIGH); // Set STEP pin HIGH
  delayMicroseconds(500);       // Wait for 500 microseconds
  digitalWrite(STEP_PIN, LOW);  // Set STEP pin LOW
  delayMicroseconds(500);       // Wait for 500 microseconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Check the power supply connections (VM and VIO).
Ensure the STEP and DIR signals are being sent correctly.
Verify motor coil connections (A1, A2, B1, B2).
Overheating:
Reduce the motor current using the potentiometer or UART.
Add a heatsink or active cooling to the driver.
Noisy Operation:
Enable StealthChop2 mode via UART for silent operation.
Check for loose motor connections.
Stall Detection Not Working:
Ensure StallGuard4 is enabled and properly configured via UART.
Verify the motor current is set correctly for your application.
FAQs
Can the TMC2209 be used with 12V or 24V motors?
Yes, the TMC2209 supports motor supply voltages between 4.75V and 29V, making it compatible with 12V and 24V motors.
How do I configure microstepping?
Use the MS1 and MS2 pins or configure it via UART for finer control.
Is the TMC2209 compatible with 3.3V logic?
Yes, the TMC2209 supports both 3.3V and 5V logic levels.
What is the maximum current the TMC2209 can handle?
The TMC2209 can handle up to 2.0A RMS (2.8A peak) per phase.

 Open Project in Cirkit Designer