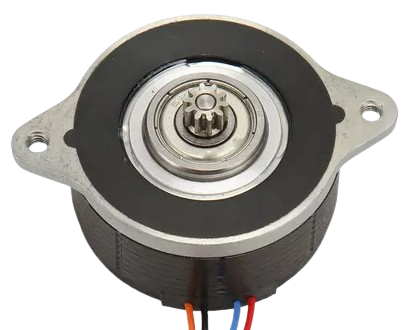
The Nema 14 36mm Pancake Stepper Motor is a compact and efficient stepper motor designed for precision motion control applications. With a body length of just 36mm, this motor is ideal for projects where space is limited but high torque and accurate positioning are required. Common applications include 3D printers, CNC machines, robotics, and other automated systems.
Explore Projects Built with Nema 14 36mm Pancake Stepper Motor
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
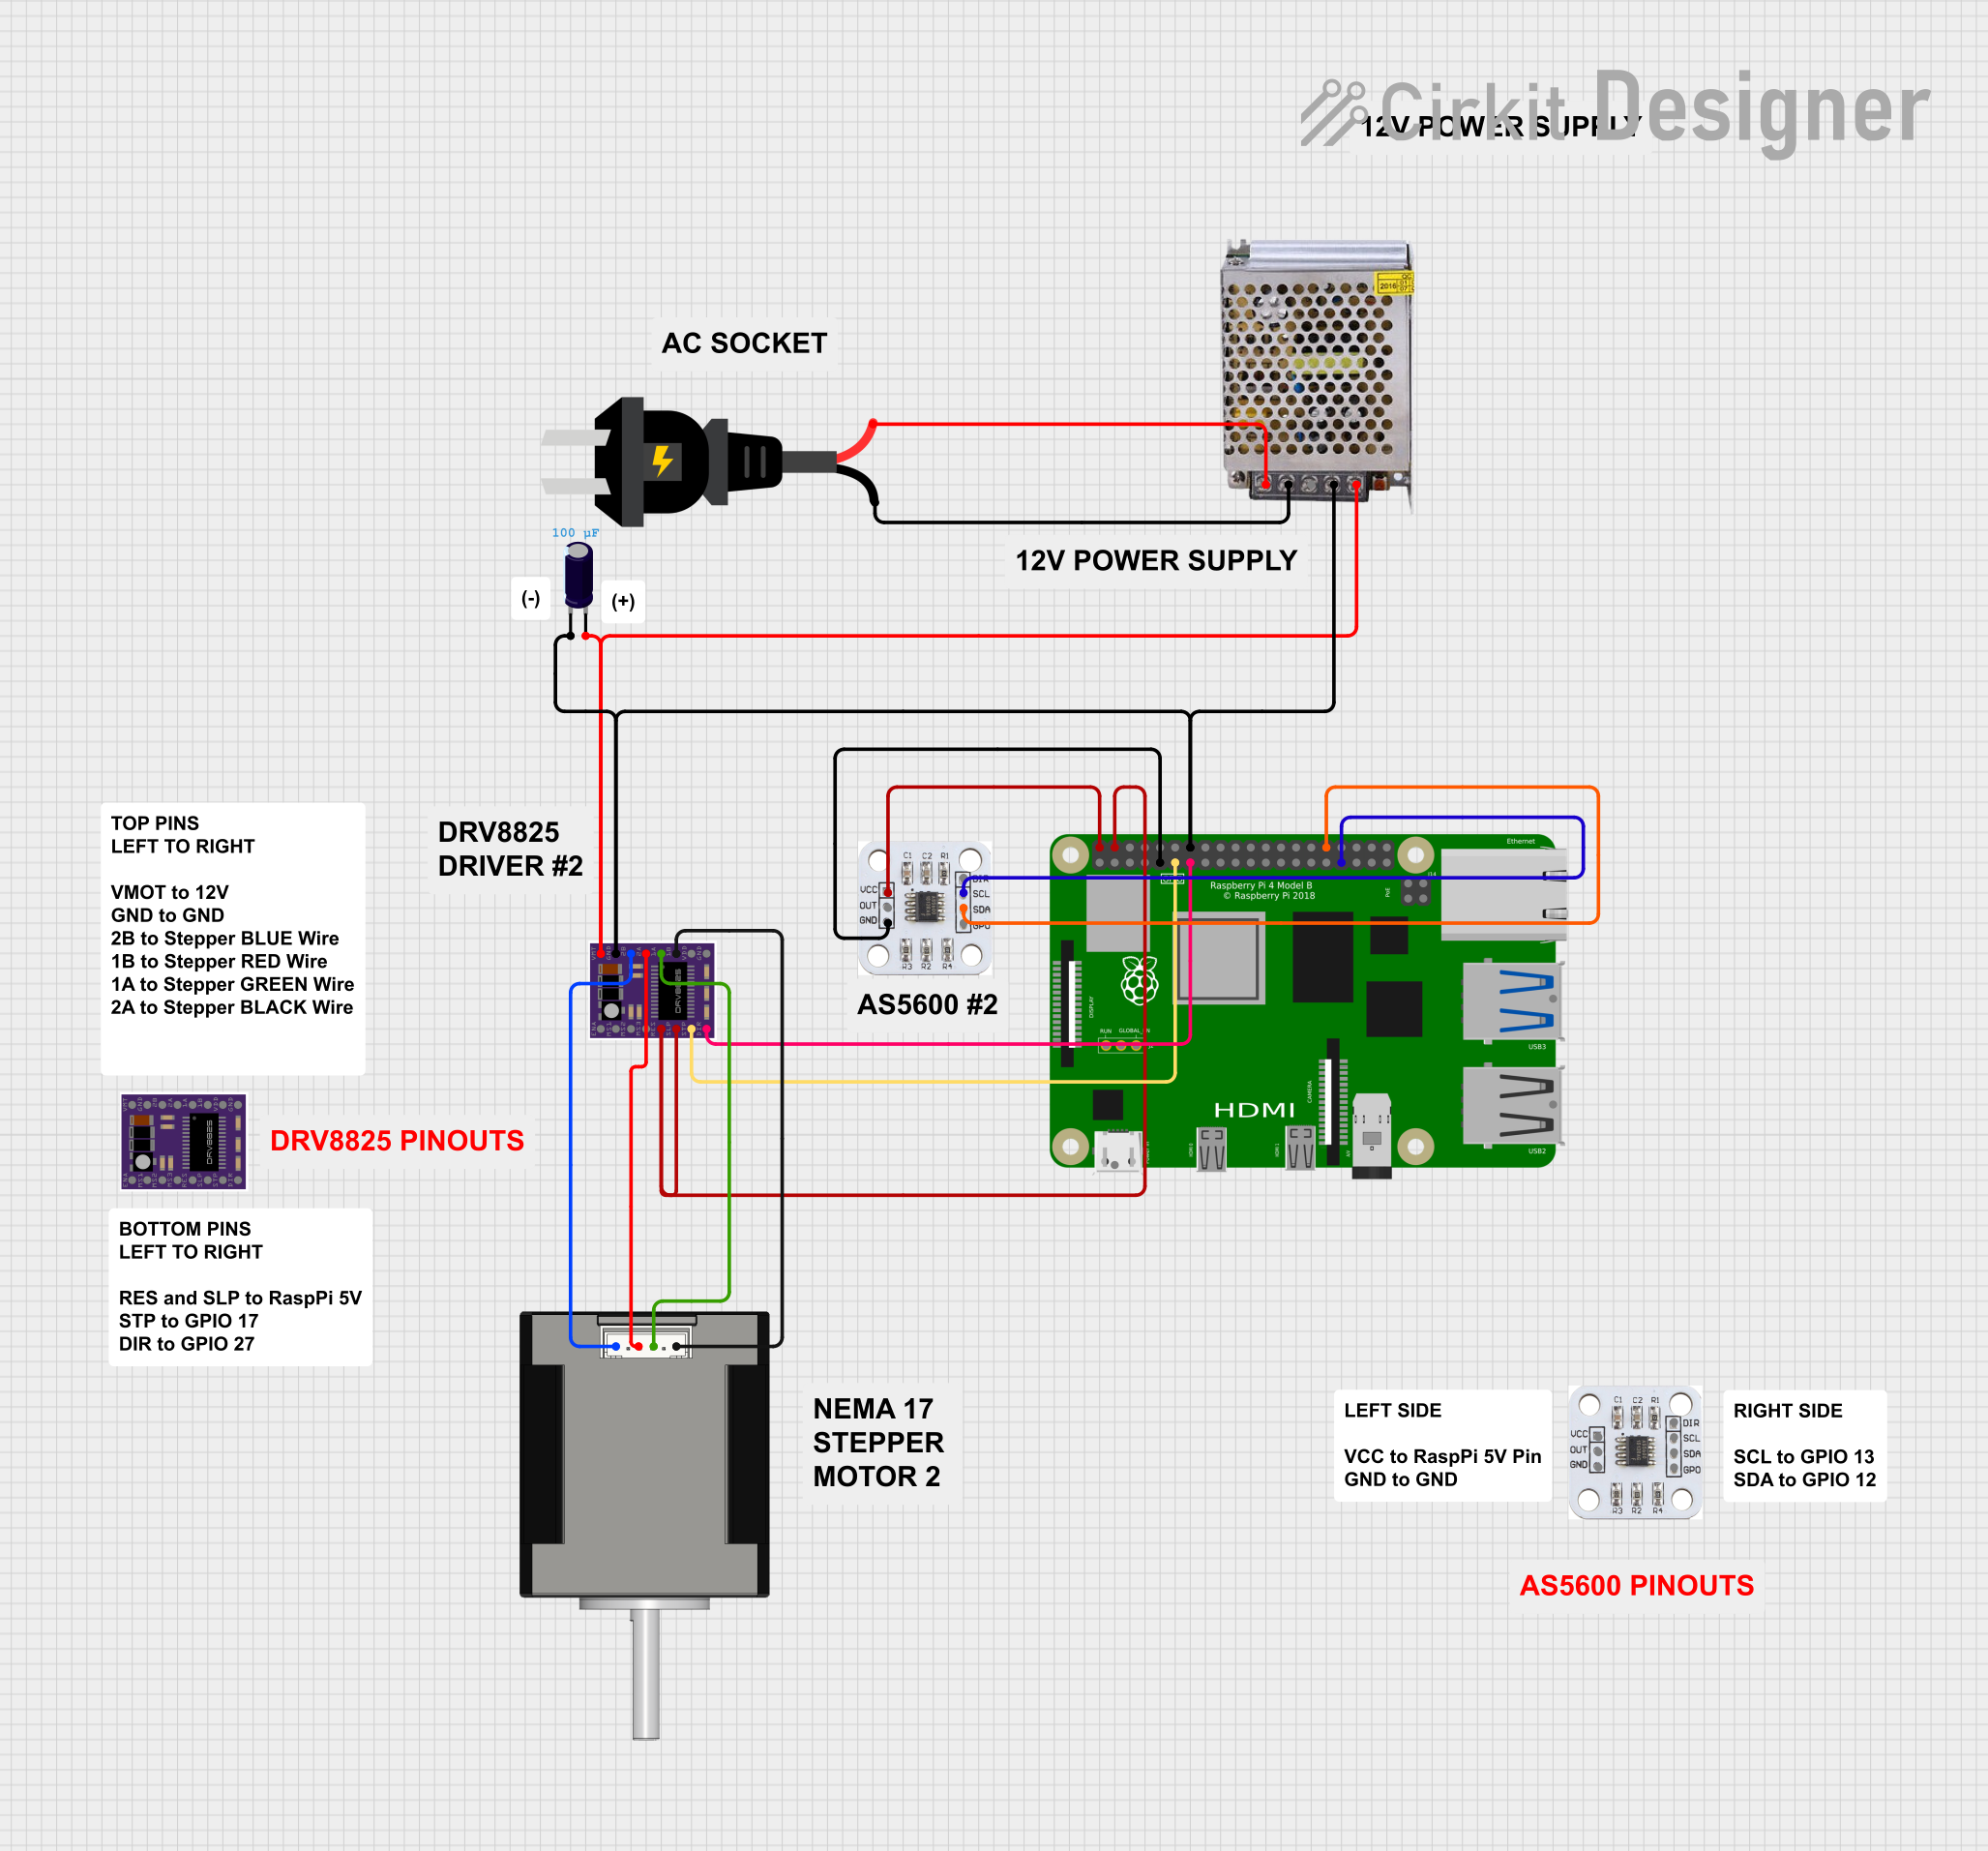
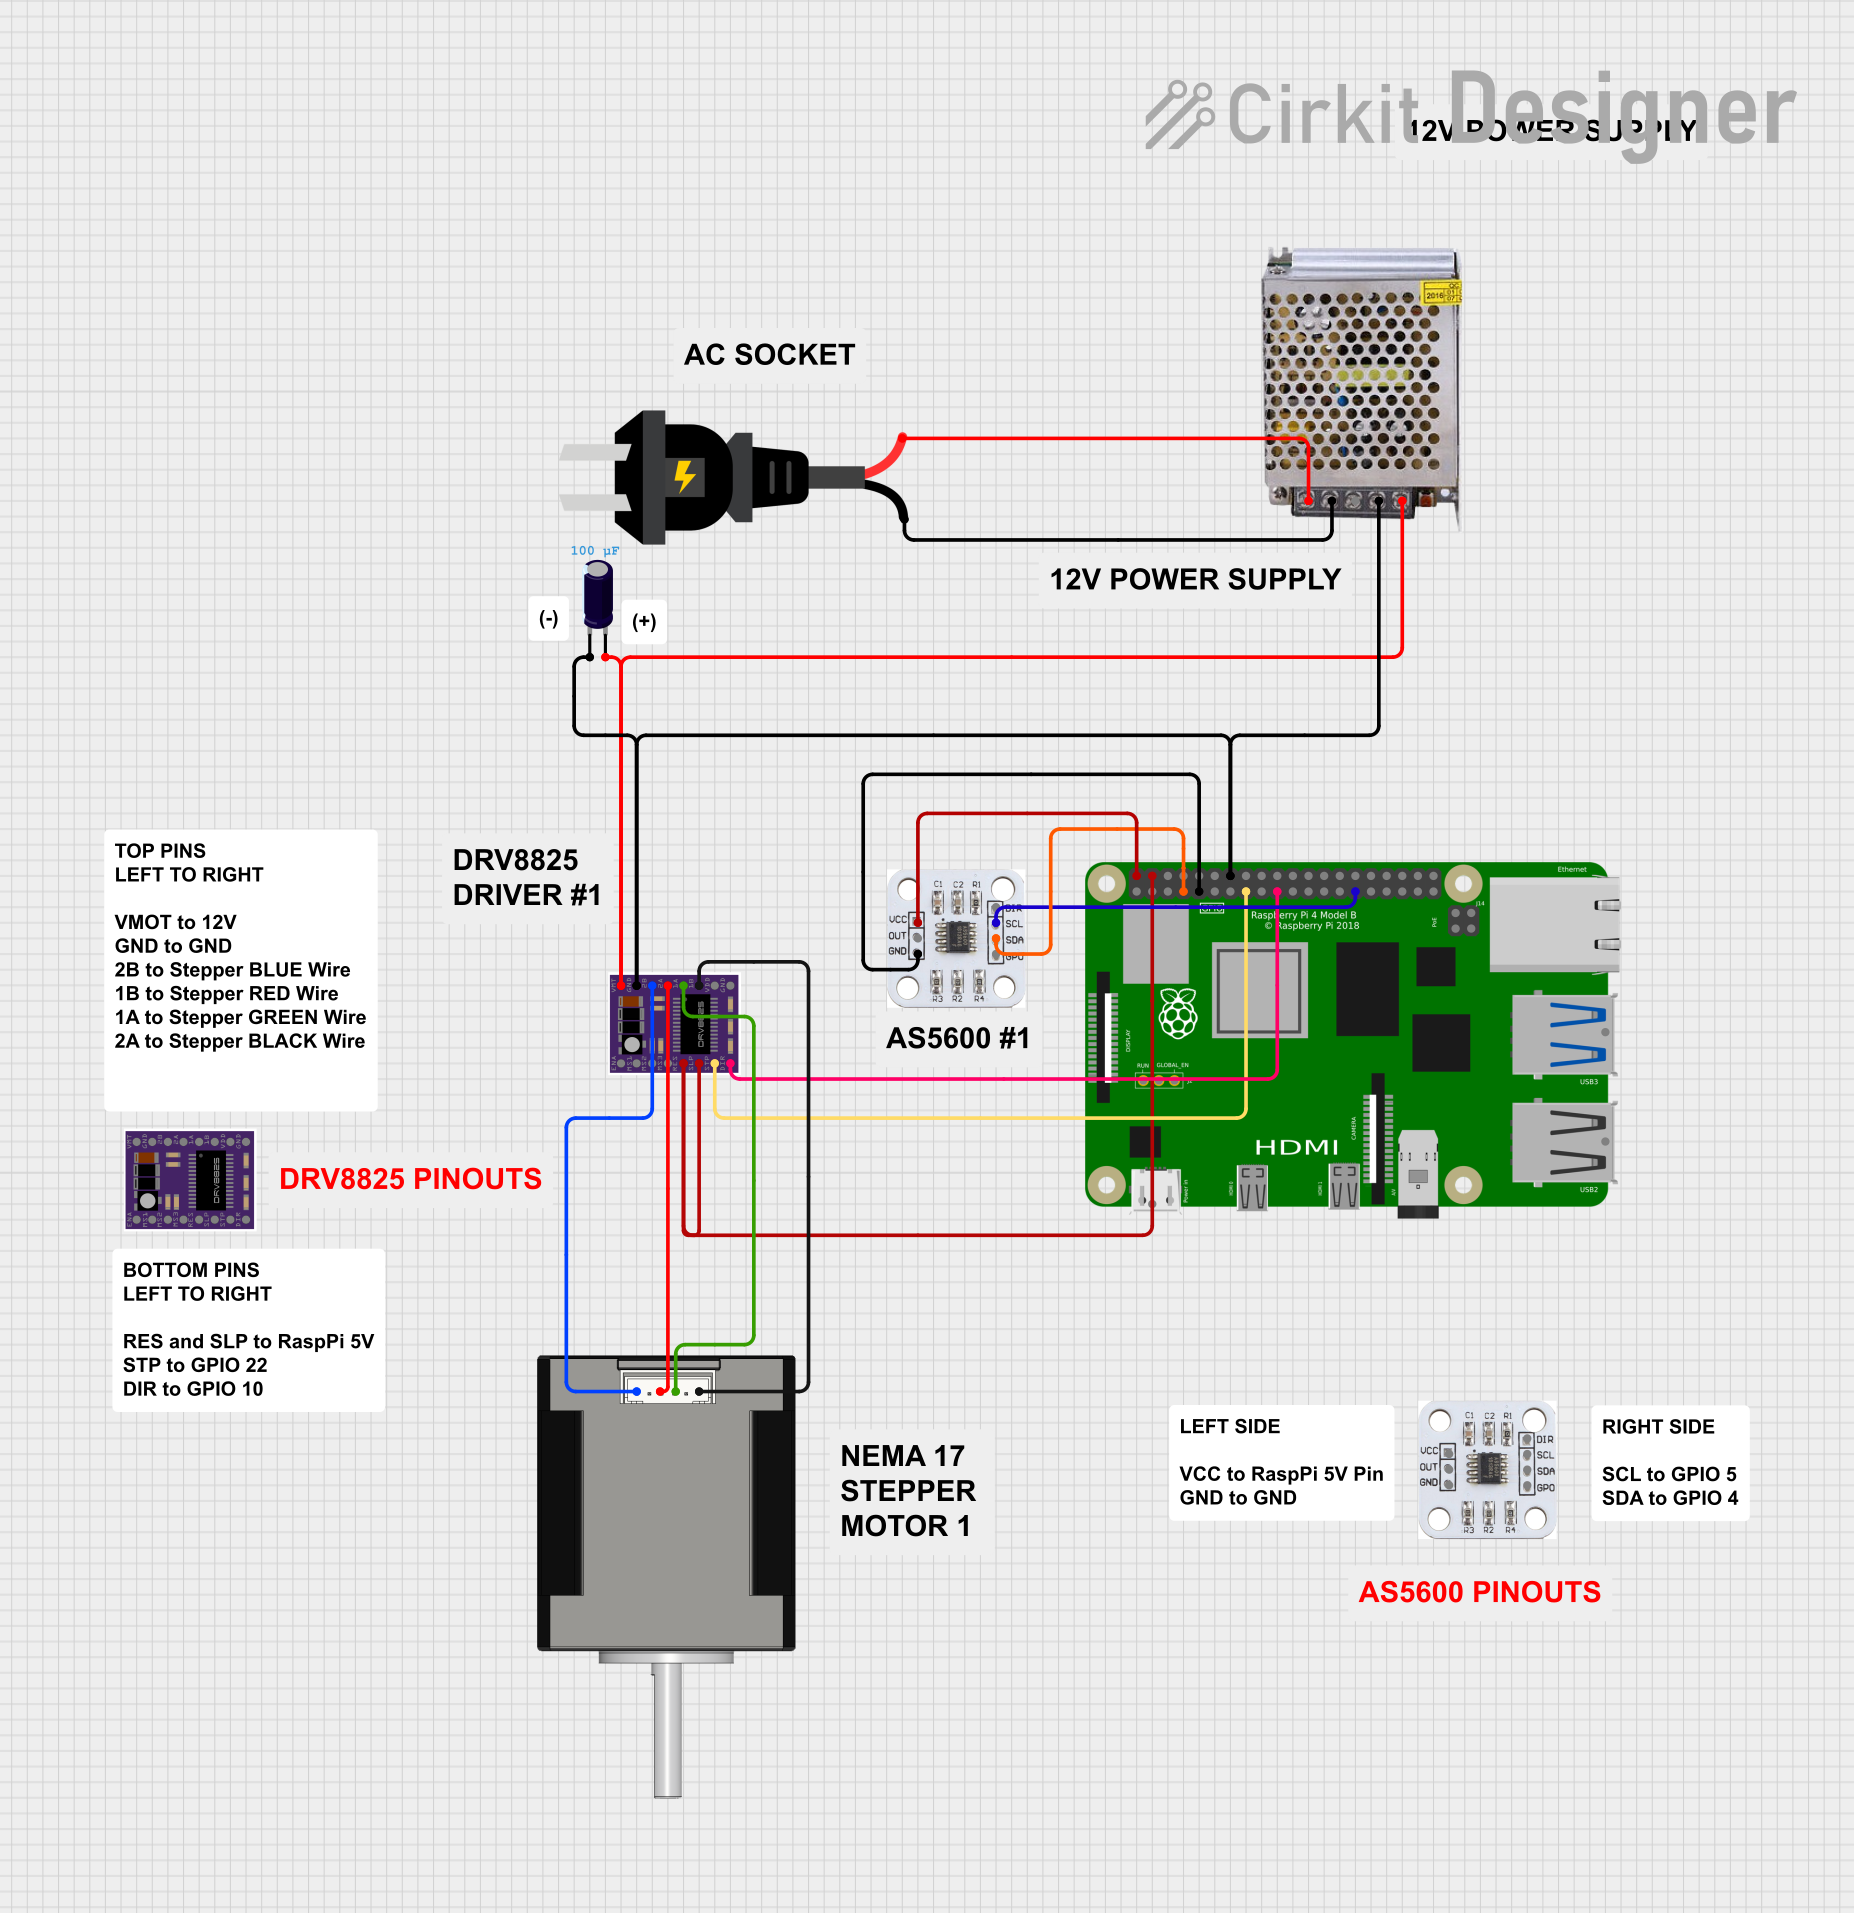
This circuit controls a Nema 17 stepper motor using a DRV8825 driver, powered by a 12V power supply, and managed by a Raspberry Pi 4B. The Raspberry Pi also interfaces with an AS5600 magnetic encoder for precise motor position feedback.
This circuit is designed to control a Nema 17 stepper motor using a DRV8825 driver, powered by a 12V power supply, and managed by a Raspberry Pi 4B. The Raspberry Pi interfaces with an AS5600 magnetic encoder for precise motor position feedback and controls the motor driver through GPIO pins.
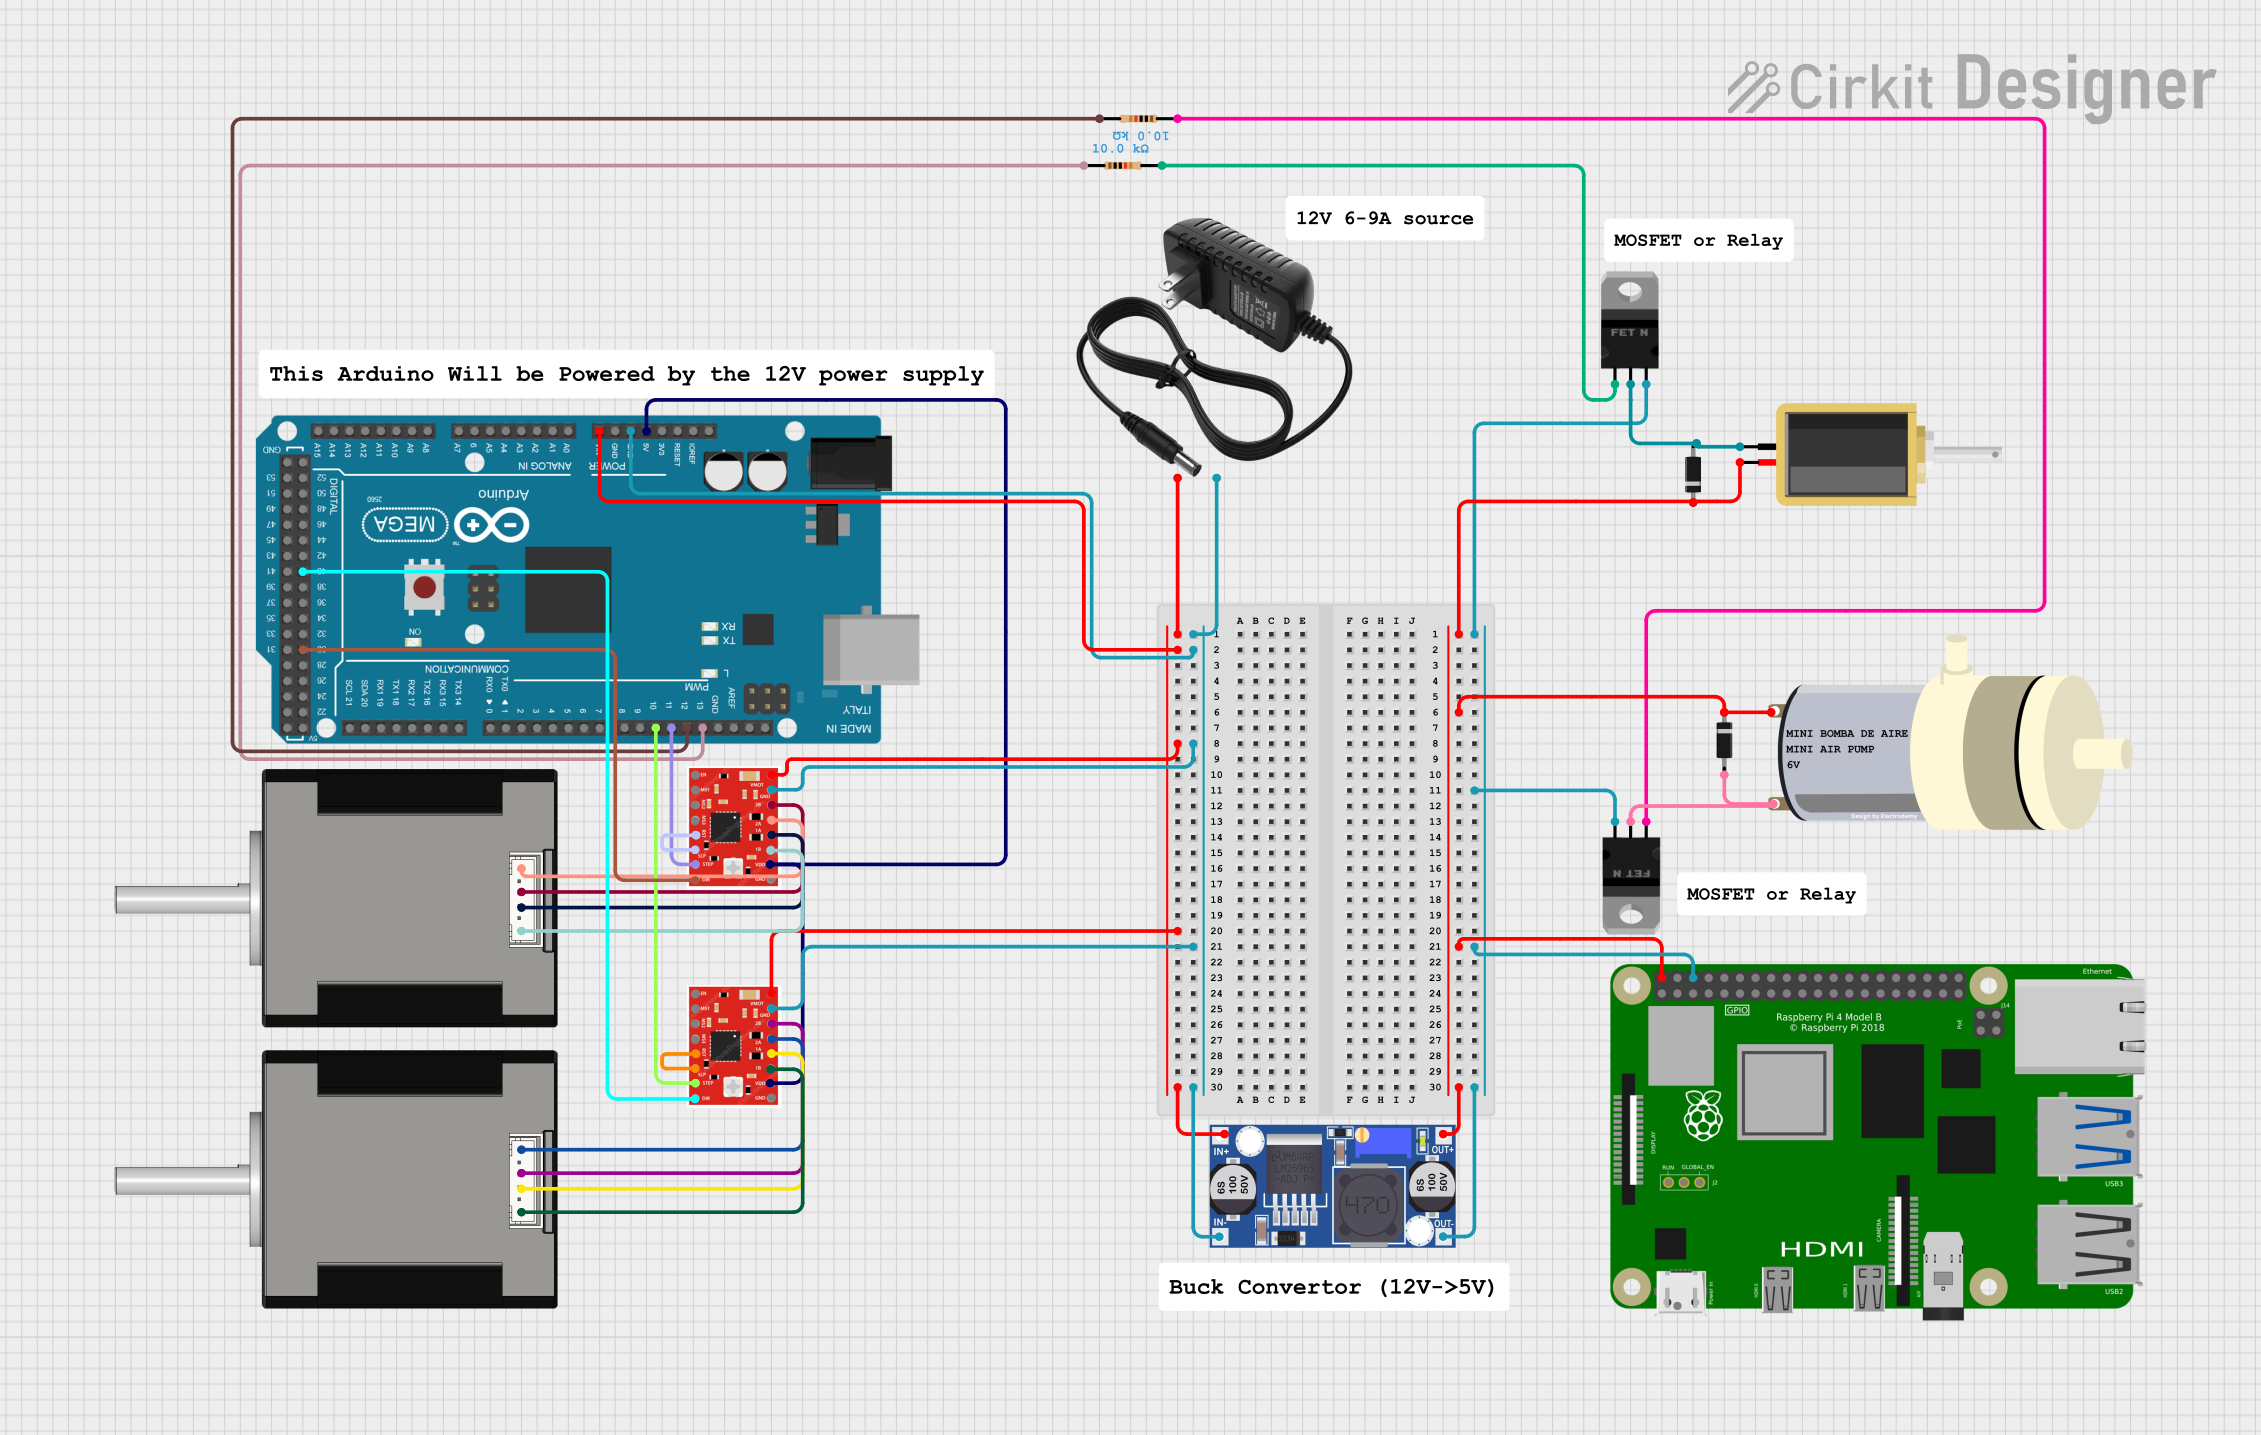
This is a stepper motor control circuit with an Arduino Mega 2560 microcontroller at its core, designed to drive two Nema 17 stepper motors via A988 drivers. It includes a buck converter for voltage regulation, MOSFETs for switching a solenoid and air pump, and diodes for protection. The system is powered by a 12V supply, and the Arduino's firmware is currently a placeholder for future development.
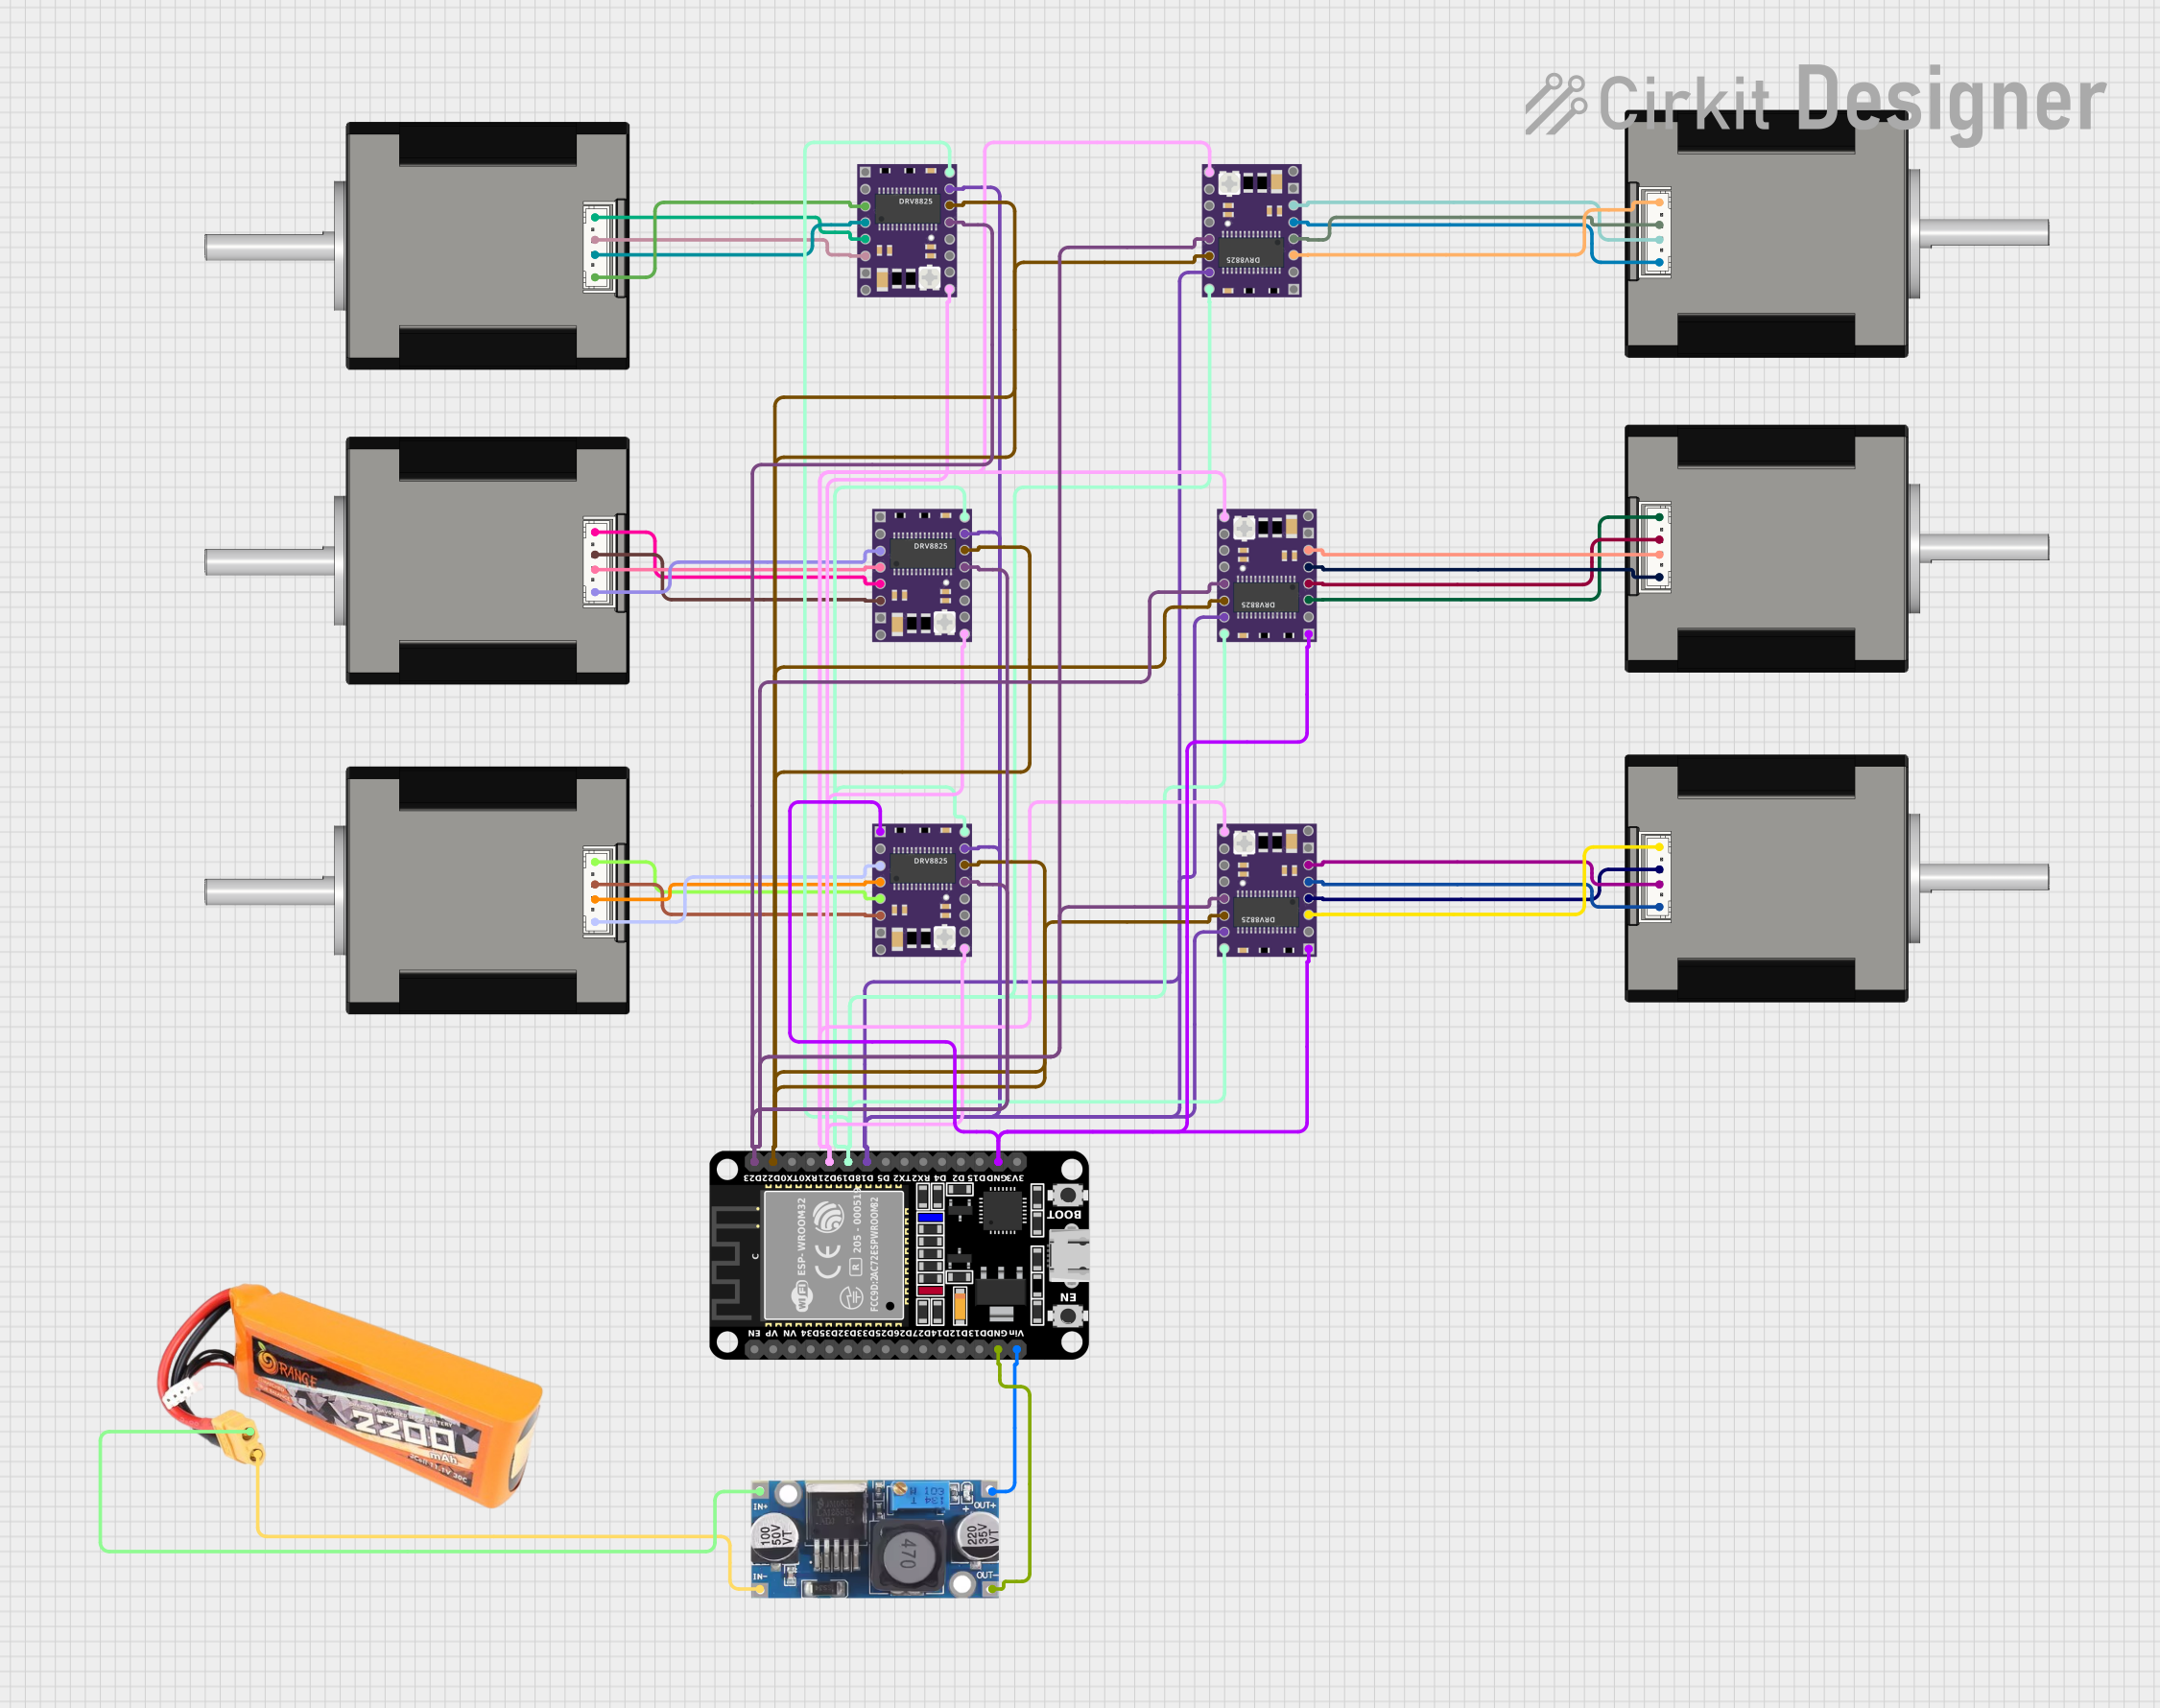
This is a multi-axis stepper motor control system using an ESP32 microcontroller to drive multiple DRV8825 stepper motor drivers, which control Nema 17 stepper motors. The system is powered by a LiPo battery with voltage regulation provided by a step-down buck converter. The ESP32 is responsible for the motor control logic, which is not yet implemented in the provided code.
To use the Nema 14 36mm Pancake Stepper Motor in a circuit, you will need a stepper motor driver, such as the A4988 or DRV8825, and a microcontroller, such as an Arduino UNO. Below is a basic setup guide:
Connect the Motor to the Driver:
Connect the Red wire to the A1 terminal of the driver.
Connect the Blue wire to the A2 terminal of the driver.
Connect the Green wire to the B1 terminal of the driver.
Connect the Black wire to the B2 terminal of the driver.
Connect the Driver to the Arduino:
Connect the STEP pin of the driver to a digital pin on the Arduino (e.g., D2).
Connect the DIR pin of the driver to another digital pin on the Arduino (e.g., D3).
Connect the EN (Enable) pin to ground (GND) if not used.
Connect the VDD and GND pins of the driver to the 5V and GND pins of the Arduino, respectively.
Connect the VMOT and GND pins of the driver to an external power supply (e.g., 12V).
Arduino Code Example:
// Define stepper motor connections and steps per revolution
#define dirPin 3
#define stepPin 2
#define stepsPerRevolution 200

void setup() {
  // Set the direction and step pins as outputs
  pinMode(stepPin, OUTPUT);
  pinMode(dirPin, OUTPUT);
}

void loop() {
  // Set the direction clockwise
  digitalWrite(dirPin, HIGH);

  // Step the motor one revolution
  for (int i = 0; i < stepsPerRevolution; i++) {
    digitalWrite(stepPin, HIGH);
    delayMicroseconds(1000); // Adjust delay for speed control
    digitalWrite(stepPin, LOW);
    delayMicroseconds(1000);
  }

  delay(1000); // Wait for a second

  // Set the direction counterclockwise
  digitalWrite(dirPin, LOW);

  // Step the motor one revolution
  for (int i = 0; i < stepsPerRevolution; i++) {
    digitalWrite(stepPin, HIGH);
    delayMicroseconds(1000);
    digitalWrite(stepPin, LOW);
    delayMicroseconds(1000);
  }

  delay(1000); // Wait for a second
}
Important Considerations and Best Practices
Current Limiting: Ensure that the current limit on the stepper driver is set correctly to prevent overheating and damage to the motor.
Power Supply: Use an appropriate power supply that matches the voltage and current requirements of the motor.
Cooling: Provide adequate cooling for the stepper driver, especially if running the motor at high currents.
Microstepping: Utilize microstepping settings on the driver for smoother and more precise motor movements.
Troubleshooting and FAQs
Common Issues Users Might Face
Motor Not Moving:
Check all connections between the motor, driver, and Arduino.
Ensure the power supply is connected and providing the correct voltage.
Verify that the current limit on the driver is set correctly.
Motor Vibrating or Making Noise:
Check for loose connections or wiring issues.
Ensure the motor is not overloaded or stalled.
Adjust the microstepping settings on the driver for smoother operation.
Overheating:
Ensure the current limit on the driver is set correctly.
Provide adequate cooling for the driver and motor.
Solutions and Tips for Troubleshooting
Double-Check Wiring: Ensure all connections are secure and correctly matched to the pin configuration.
Use a Multimeter: Measure the voltage and current to ensure they are within the specified range.
Consult the Datasheet: Refer to the motor and driver datasheets for detailed specifications and troubleshooting tips.
Test with Simple Code: Use basic code examples to isolate and identify issues before integrating into a larger project.
By following this documentation, users can effectively utilize the Nema 14 36mm Pancake Stepper Motor in their projects, ensuring reliable and precise motion control.

 Open Project in Cirkit Designer