How to Use L298N Dual H-Bridge Motor Driver: Examples, Pinouts, and Specs
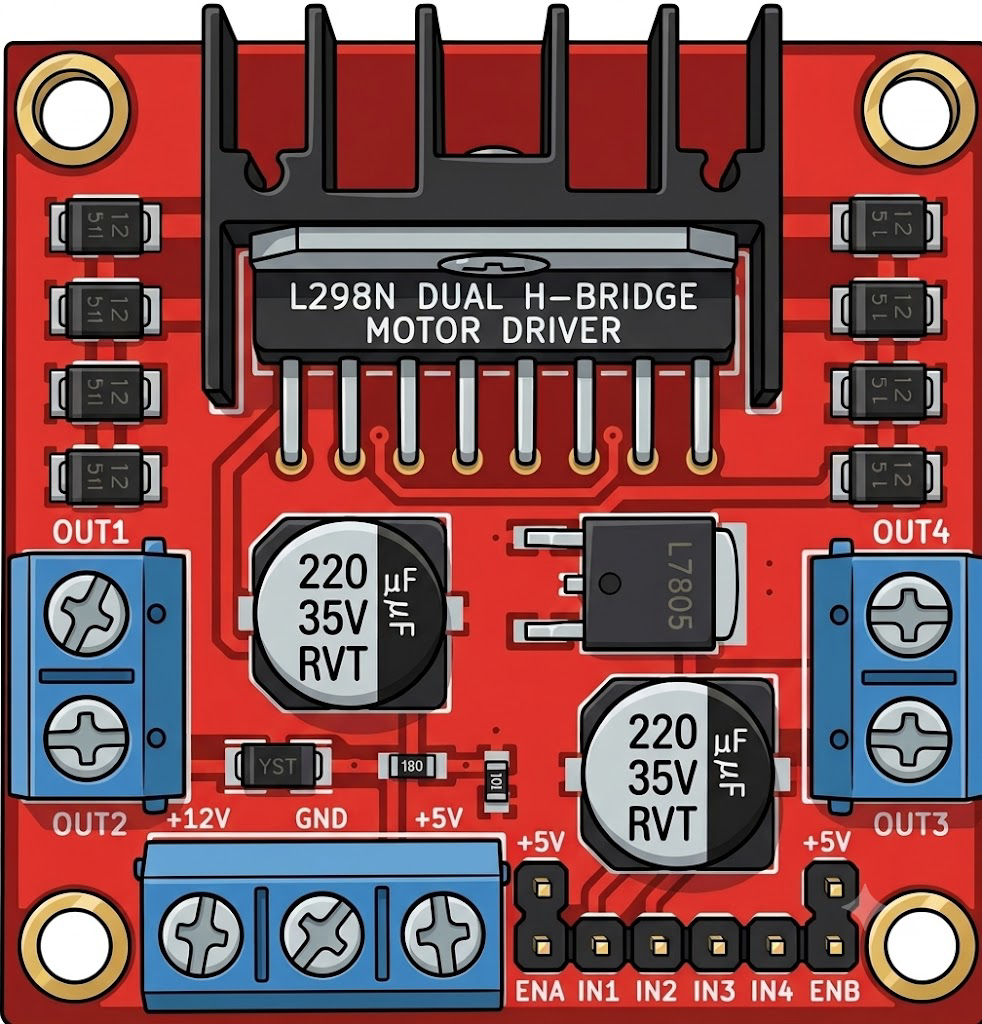
 Design with L298N Dual H-Bridge Motor Driver in Cirkit Designer
Introduction
The L298N is a dual H-bridge motor driver module designed to control the direction and speed of two DC motors or one stepper motor. It is widely used in robotics, automation, and other motor control applications due to its versatility and ease of use. The module can handle motor supply voltages ranging from 5V to 35V and supports a maximum current of 2A per channel. Its compact design and onboard features make it a popular choice for hobbyists and professionals alike.
Explore Projects Built with L298N Dual H-Bridge Motor Driver
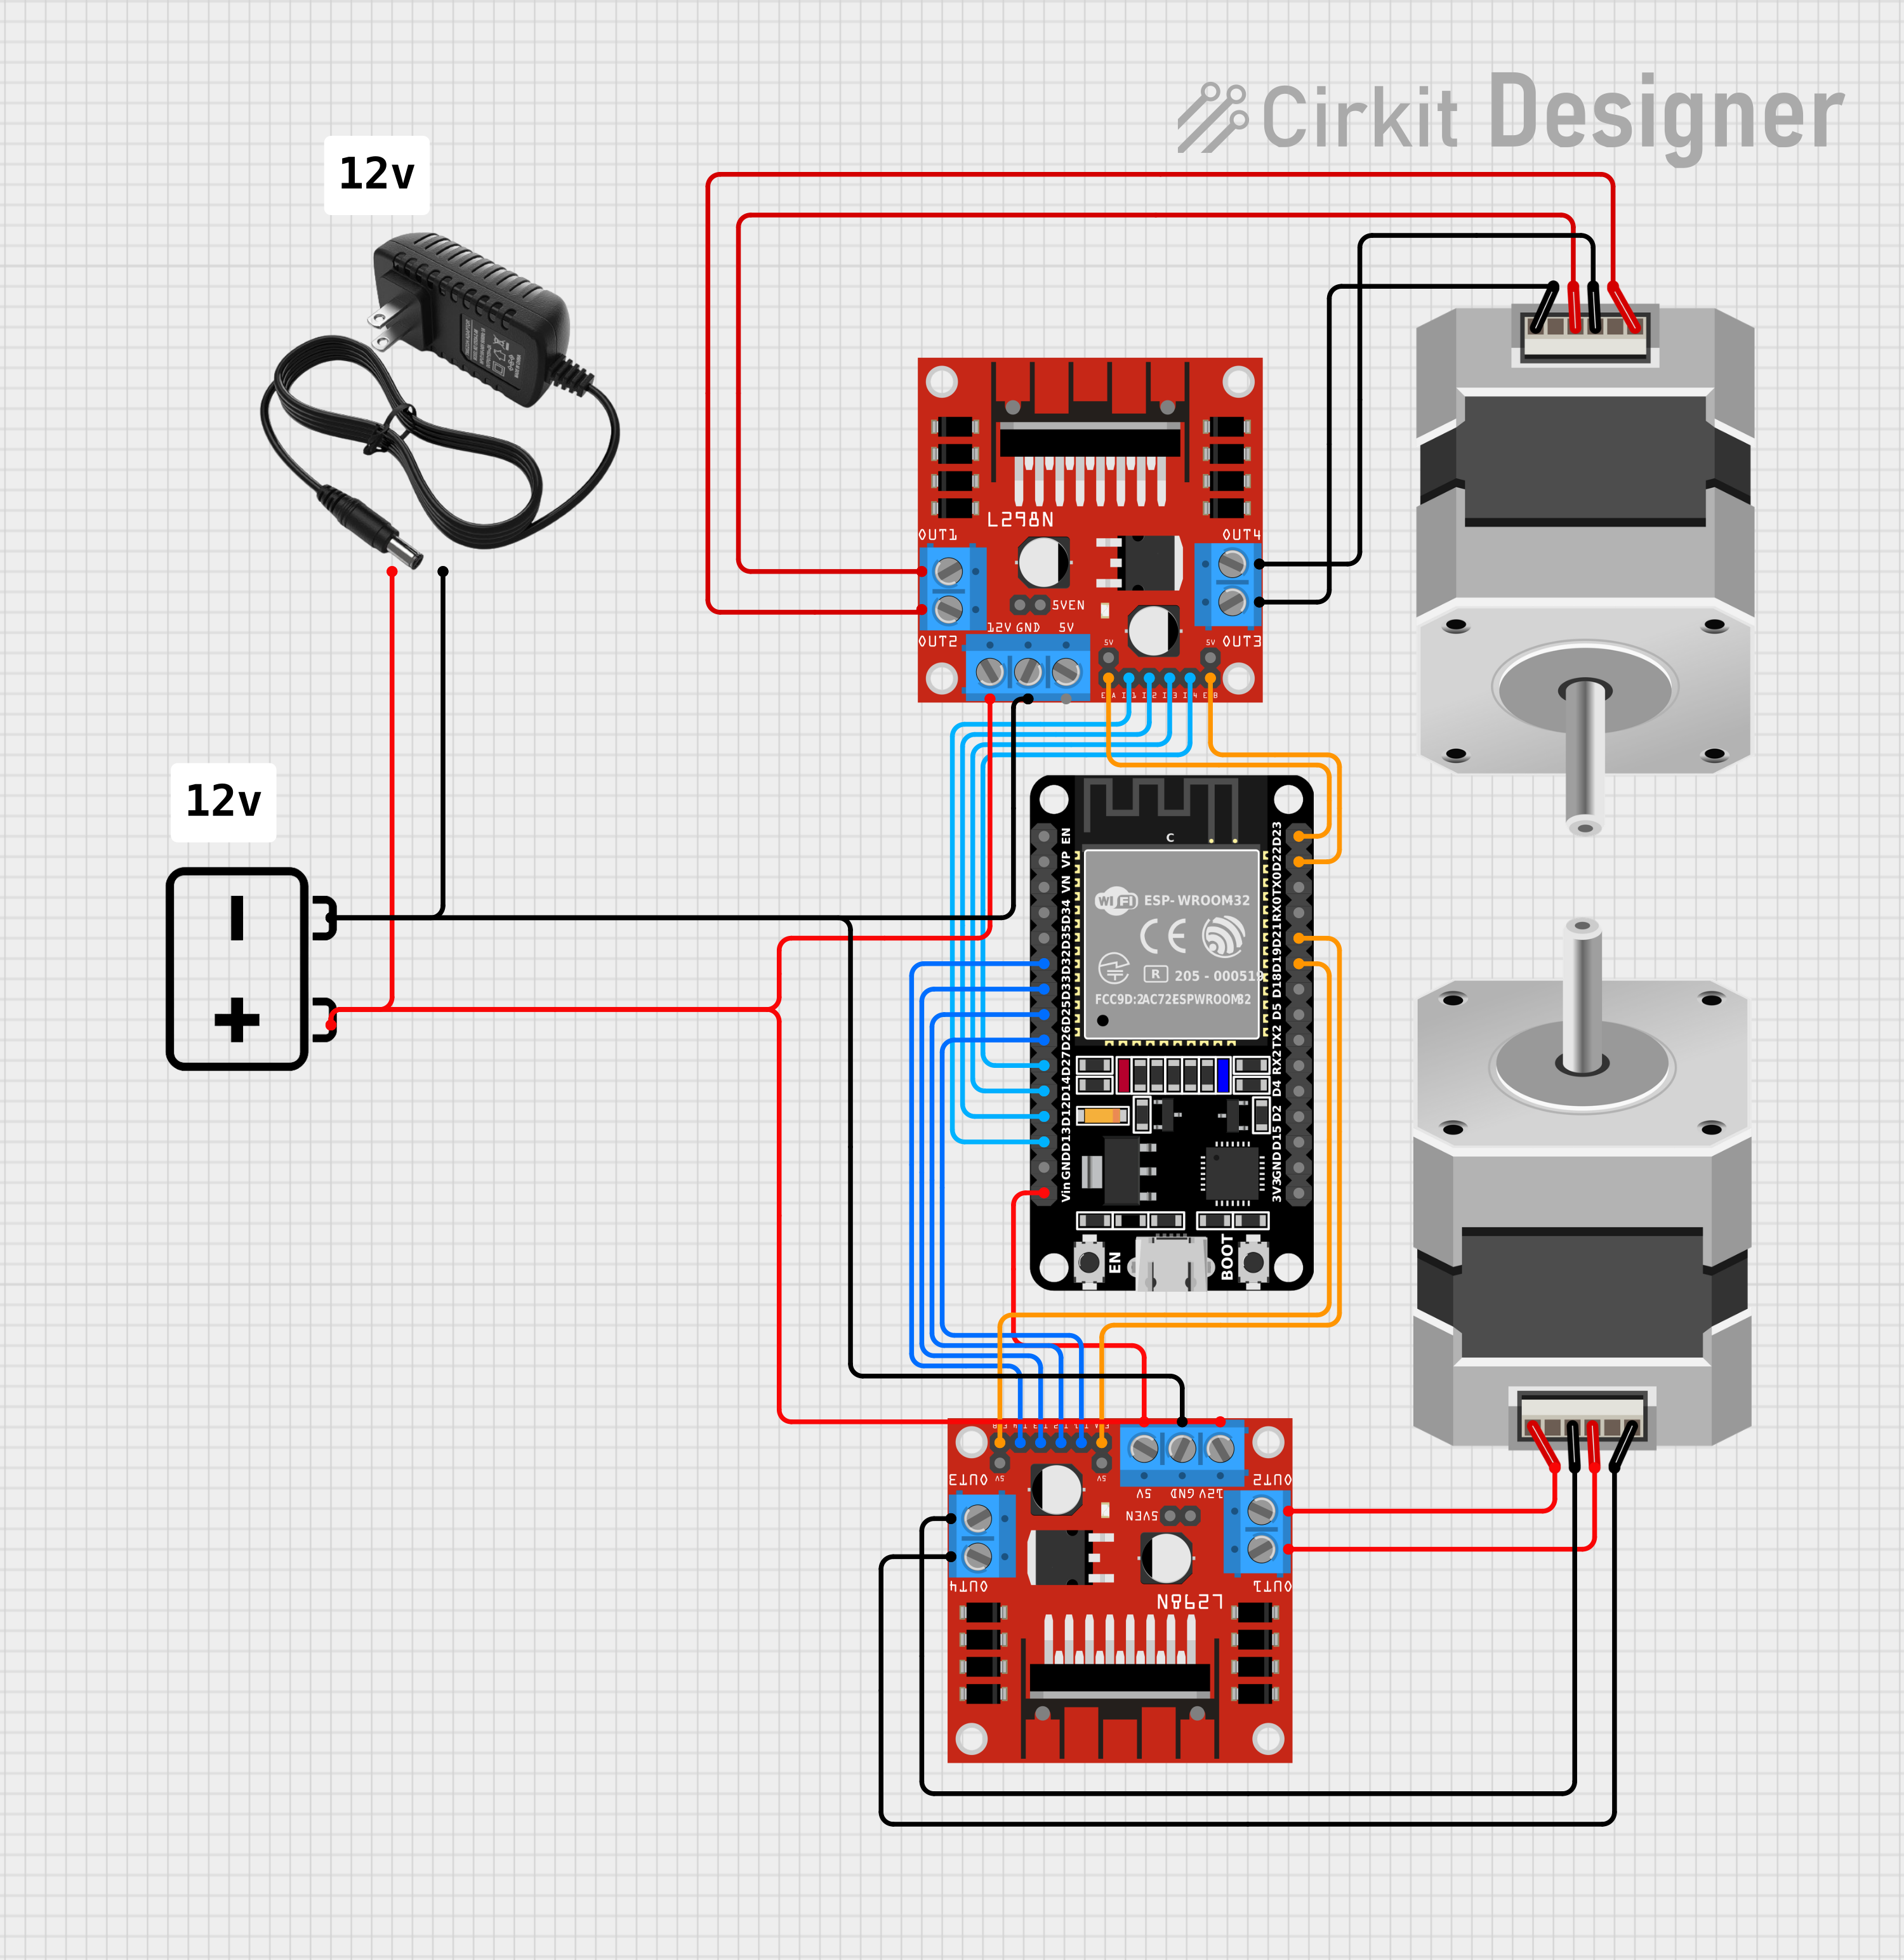 Open Project in Cirkit Designer
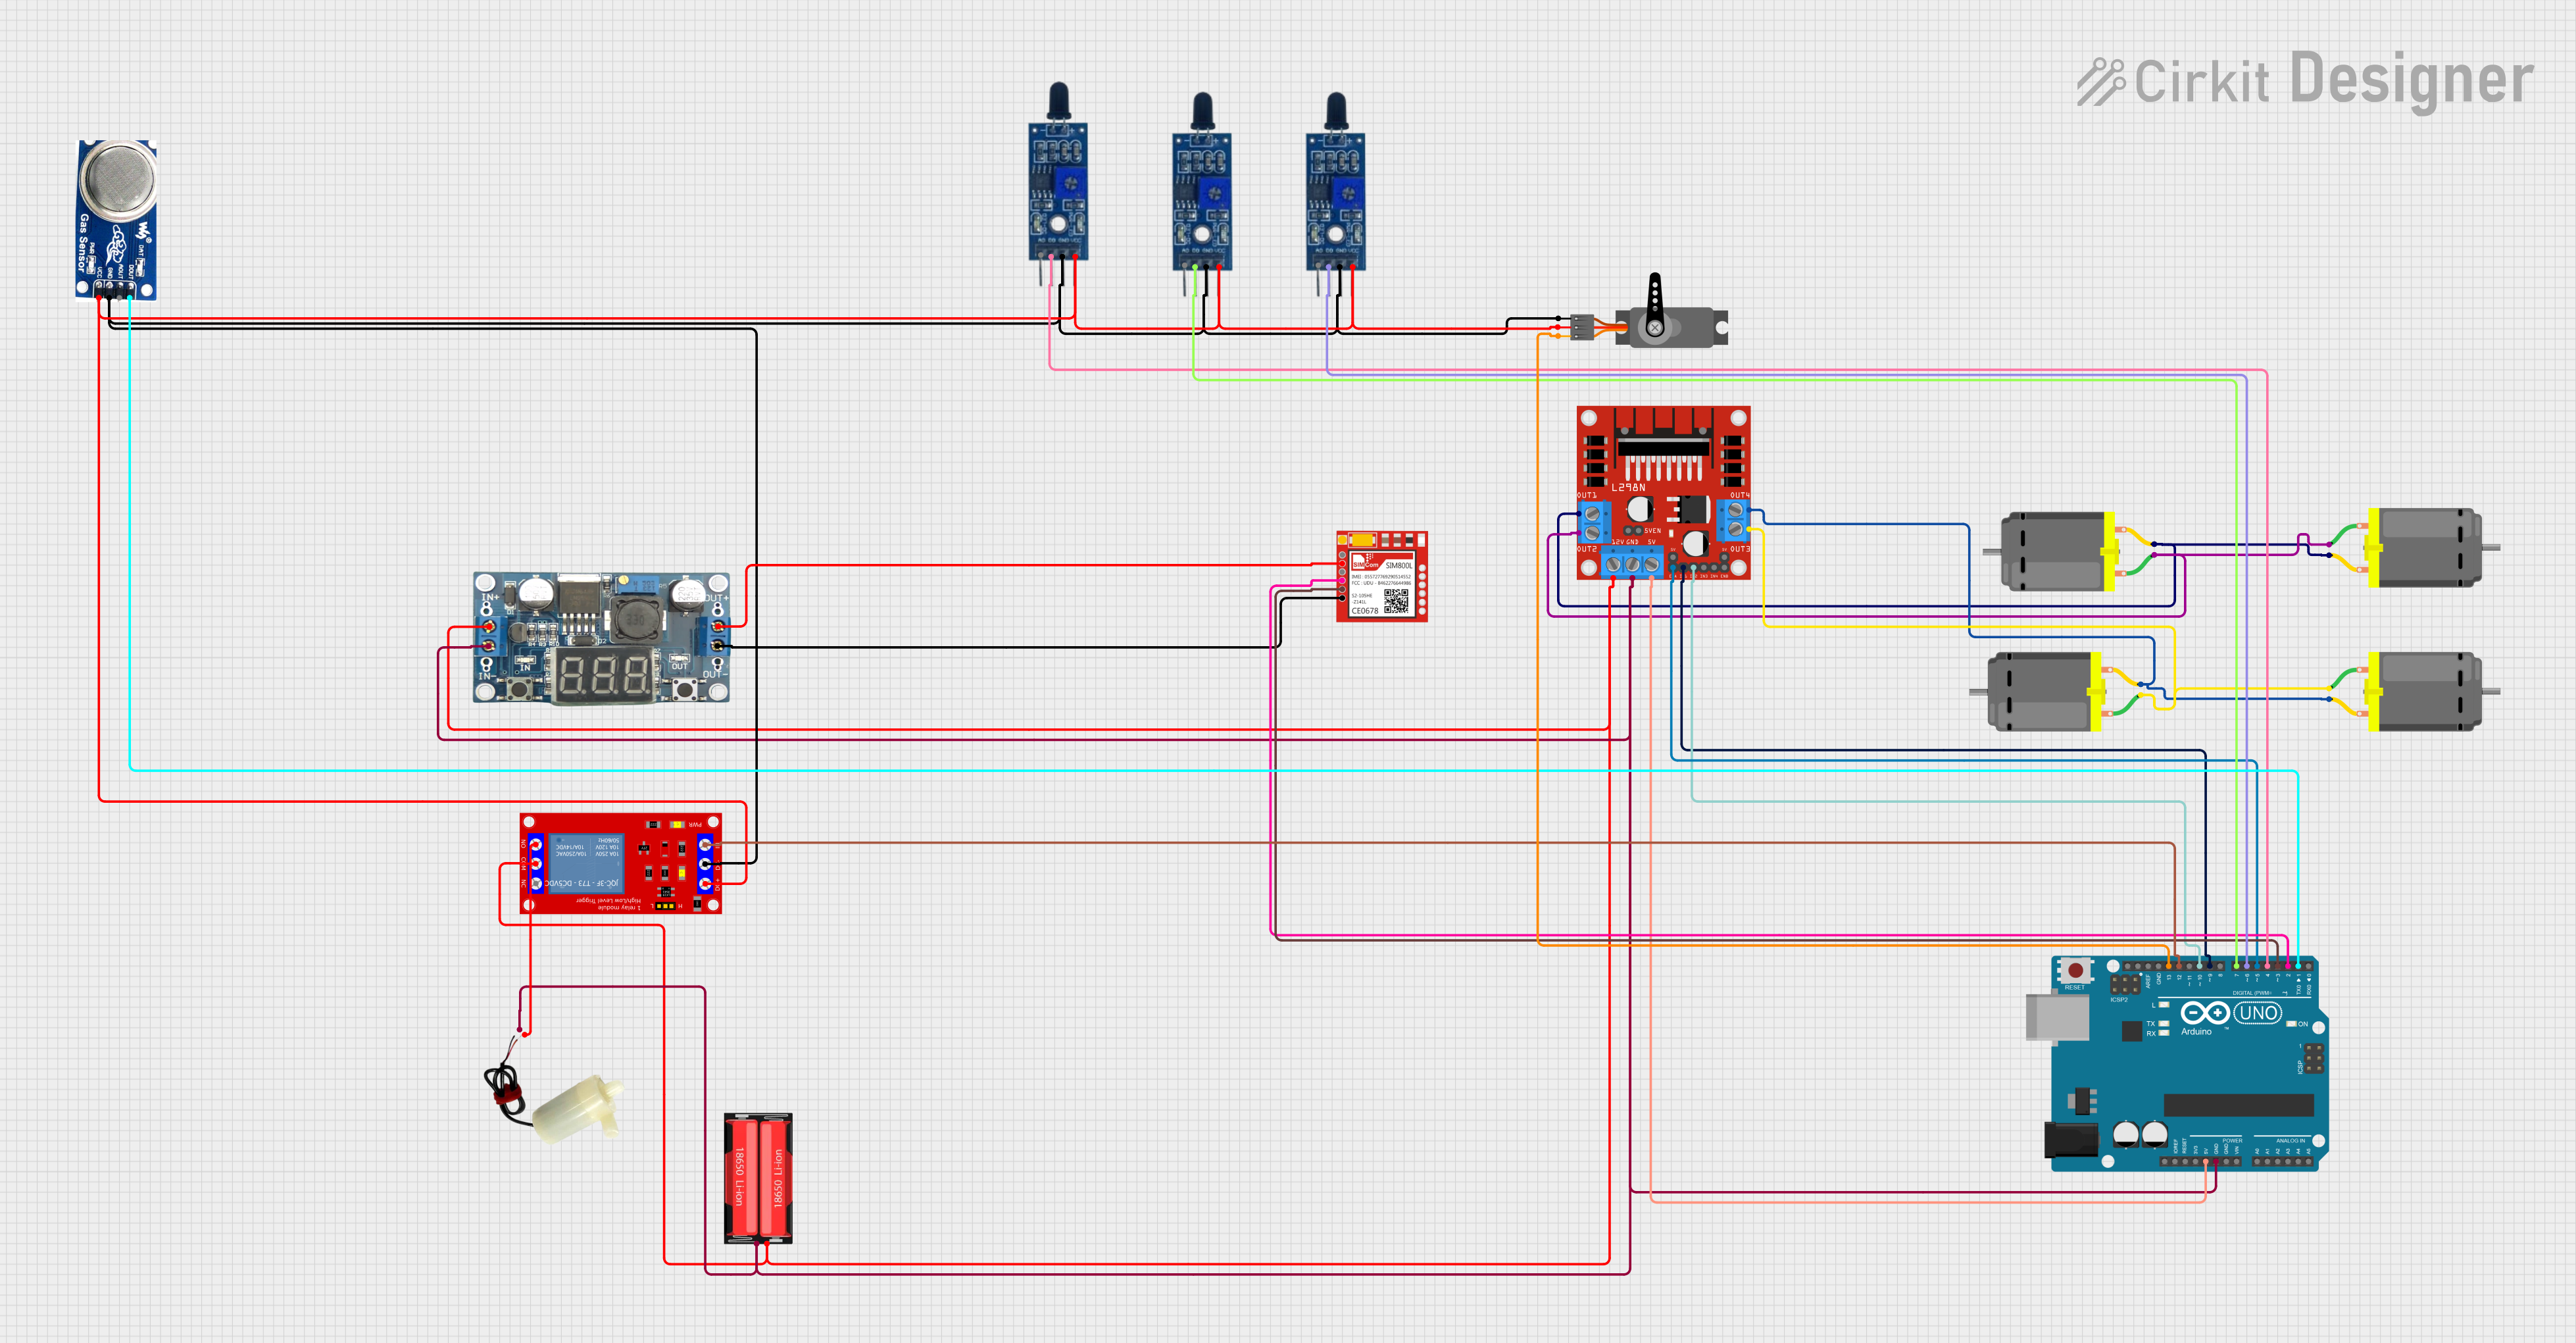 Open Project in Cirkit Designer
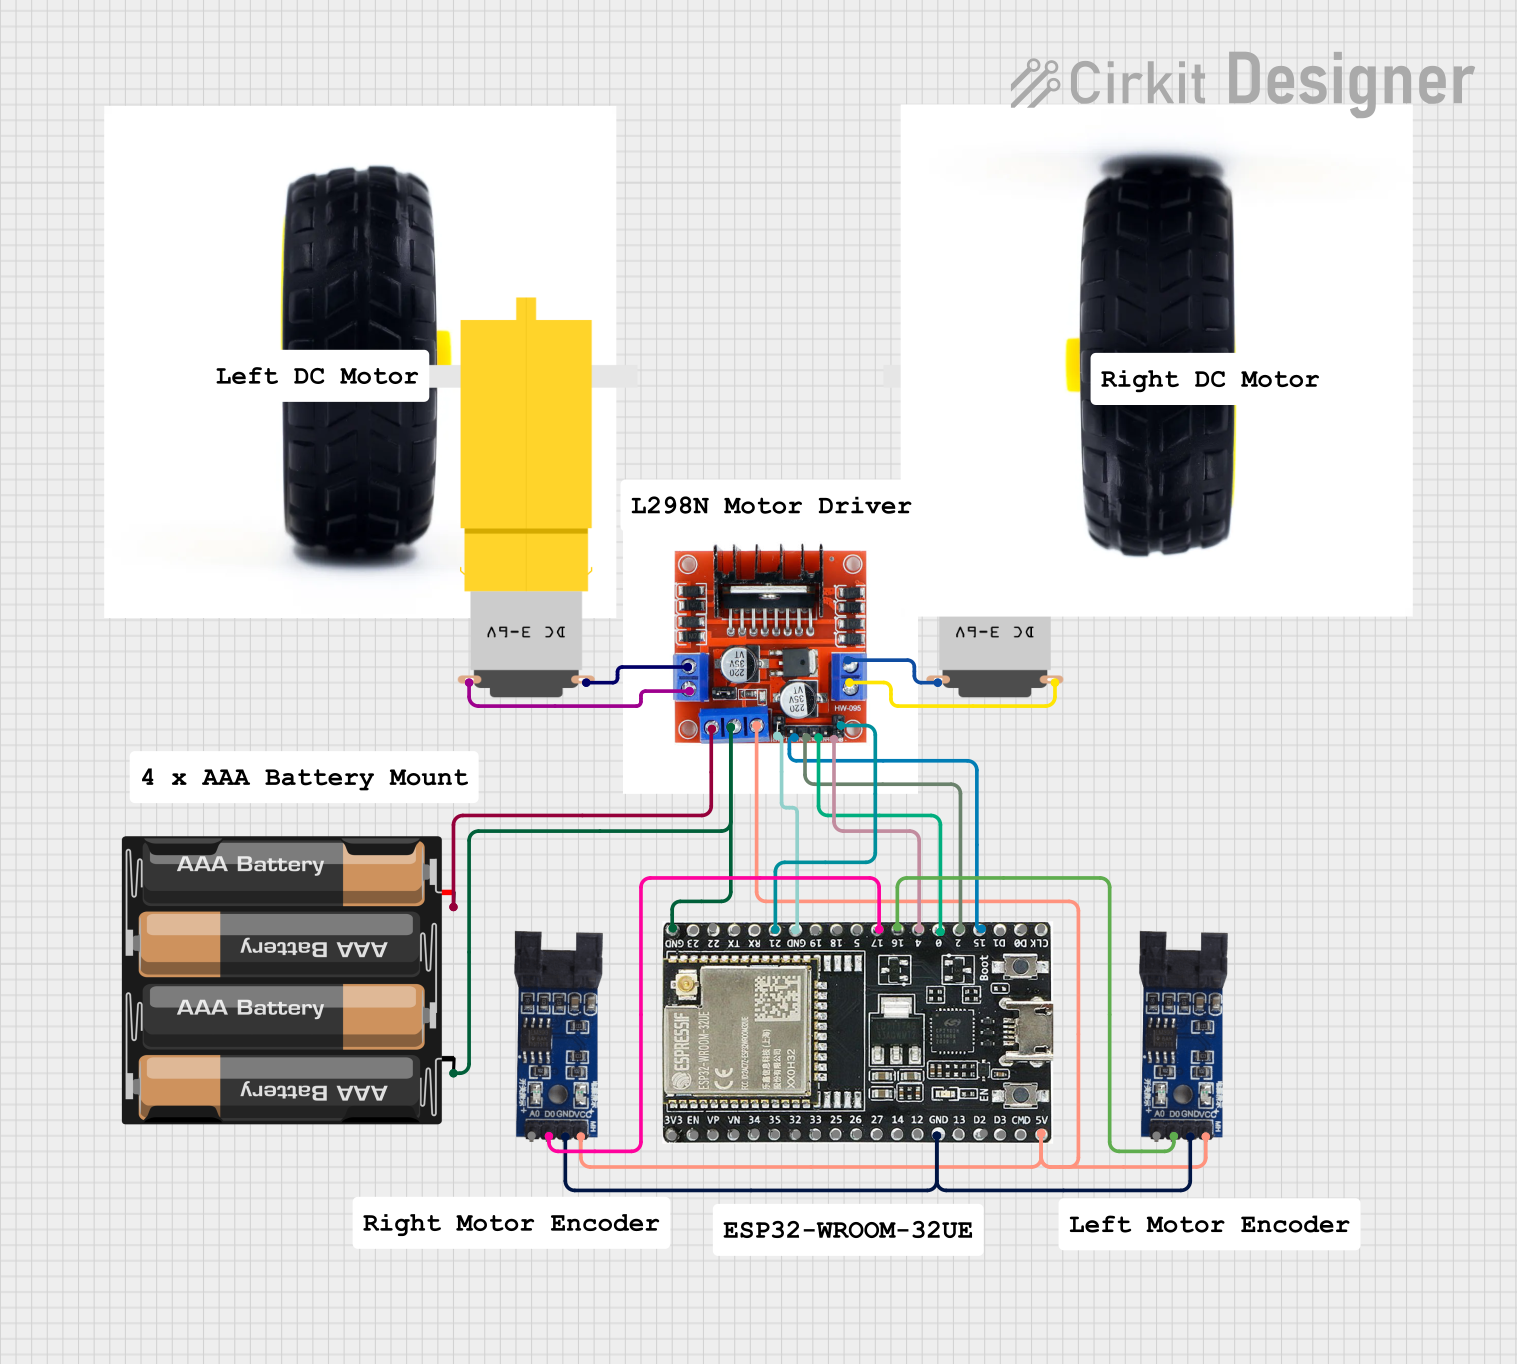 Open Project in Cirkit Designer
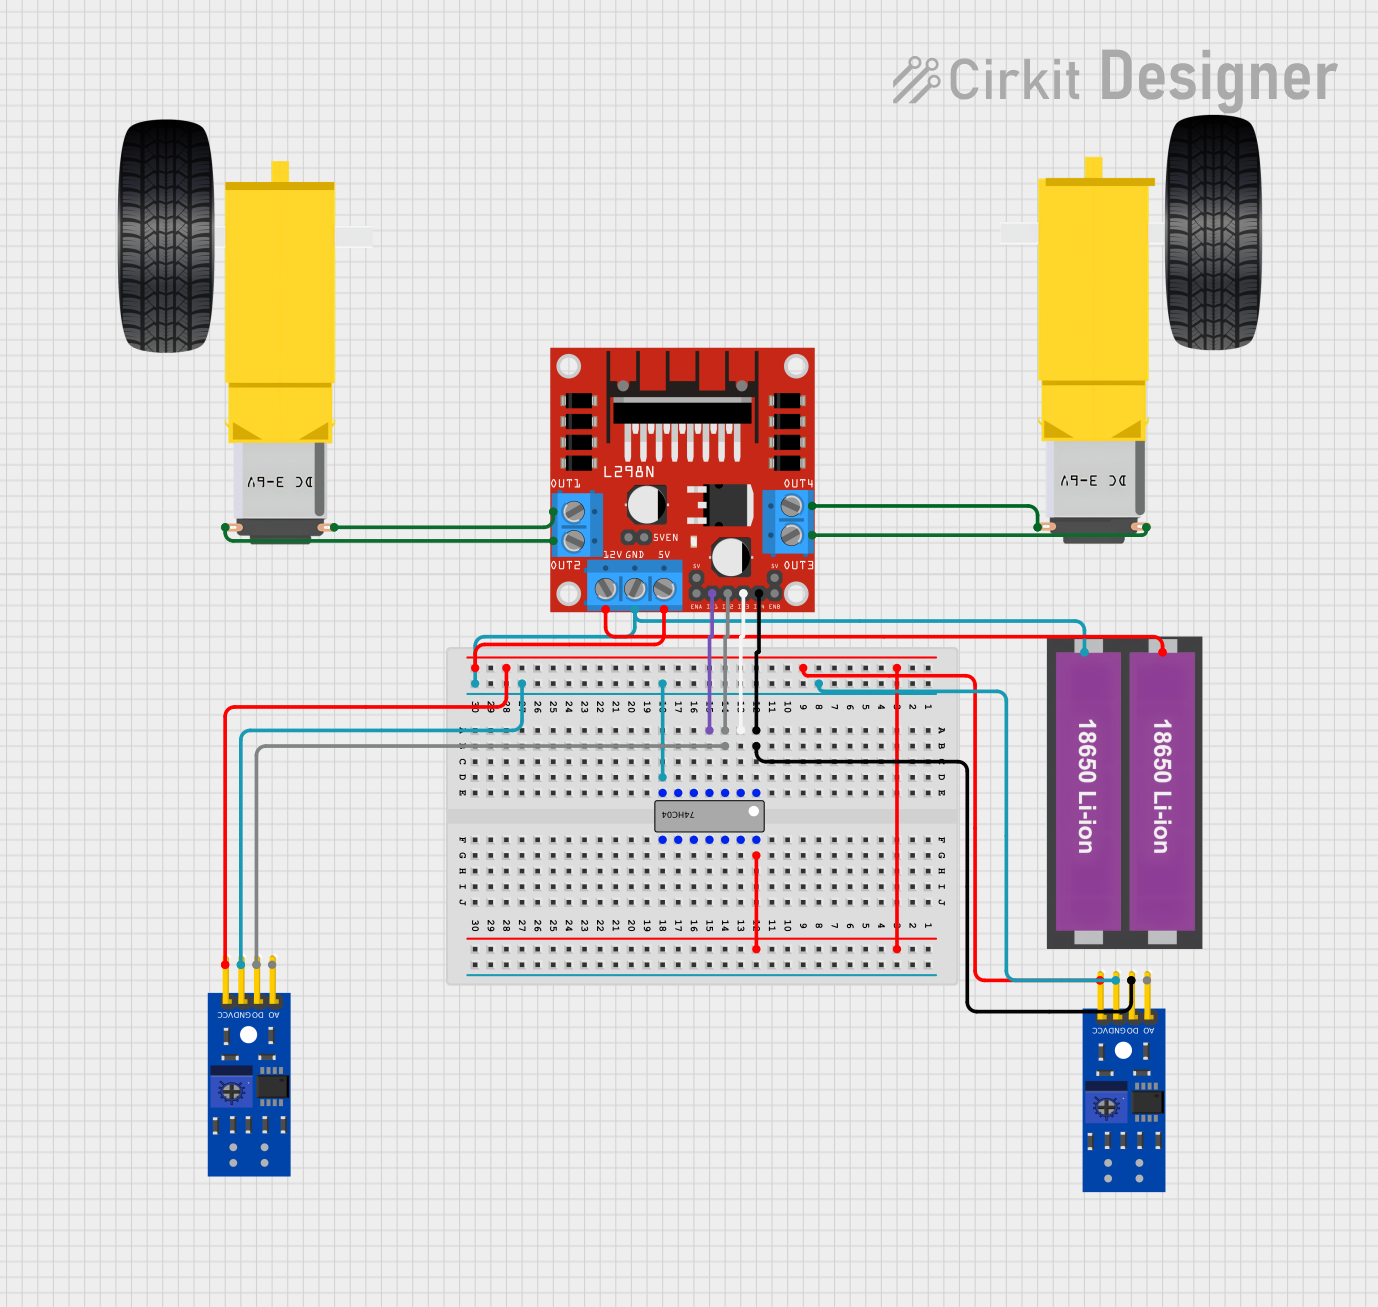 Open Project in Cirkit Designer
Explore Projects Built with L298N Dual H-Bridge Motor Driver
Open Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerCommon Applications
- Robotics: Driving wheels or tracks of robots
- Automation: Controlling conveyor belts or actuators
- DIY Projects: Building RC cars, robotic arms, or CNC machines
- Stepper Motor Control: Driving stepper motors for precise positioning
Technical Specifications
The L298N module is built around the L298N IC, which is a high-power dual H-bridge driver. Below are the key technical details:
Key Specifications
| Parameter | Value |
|---|---|
| Motor Supply Voltage | 5V to 35V |
| Logic Voltage | 5V |
| Maximum Current (per channel) | 2A |
| Number of Channels | 2 |
| Control Logic Levels | High (5V), Low (0V) |
| Power Dissipation | 25W (with proper heat sink) |
| Dimensions | ~43mm x 43mm x 27mm |
Pin Configuration and Descriptions
The L298N module has several pins and terminals for motor control and power supply. Below is a detailed description:
Power and Motor Terminals
| Pin/Terminal | Description |
|---|---|
| VCC | Motor power supply (5V to 35V) |
| GND | Ground connection |
| 5V | Logic power supply (optional, if jumper removed) |
| OUT1 | Output for Motor 1 (positive terminal) |
| OUT2 | Output for Motor 1 (negative terminal) |
| OUT3 | Output for Motor 2 (positive terminal) |
| OUT4 | Output for Motor 2 (negative terminal) |
Control Pins
| Pin | Description |
|---|---|
| ENA | Enable pin for Motor 1 (PWM input for speed control) |
| IN1 | Input 1 for Motor 1 (direction control) |
| IN2 | Input 2 for Motor 1 (direction control) |
| ENB | Enable pin for Motor 2 (PWM input for speed control) |
| IN3 | Input 3 for Motor 2 (direction control) |
| IN4 | Input 4 for Motor 2 (direction control) |
Usage Instructions
How to Use the L298N in a Circuit
Power Connections:
- Connect the motor power supply to the
VCCterminal (5V to 35V). - Connect the ground of the power supply to the
GNDterminal. - If the logic circuit requires 5V, you can use the onboard 5V regulator by keeping the 5V jumper in place. If an external 5V logic supply is used, remove the jumper and connect the external 5V to the
5Vpin.
- Connect the motor power supply to the
Motor Connections:
- Connect the terminals of Motor 1 to
OUT1andOUT2. - Connect the terminals of Motor 2 to
OUT3andOUT4.
- Connect the terminals of Motor 1 to
Control Connections:
- Connect the
ENAandENBpins to PWM-capable pins of a microcontroller (e.g., Arduino) for speed control. - Connect
IN1,IN2,IN3, andIN4to digital pins of the microcontroller for direction control.
- Connect the
Programming:
- Use the microcontroller to send PWM signals to
ENAandENBfor speed control. - Set the logic levels of
IN1/IN2andIN3/IN4to control the direction of the motors.
- Use the microcontroller to send PWM signals to
Example Arduino Code
Below is an example of how to control two DC motors using an Arduino UNO and the L298N module:
// Define control pins for Motor 1
#define ENA 9  // PWM pin for speed control
#define IN1 8  // Direction control pin 1
#define IN2 7  // Direction control pin 2

// Define control pins for Motor 2
#define ENB 10 // PWM pin for speed control
#define IN3 6  // Direction control pin 1
#define IN4 5  // Direction control pin 2

void setup() {
  // Set motor control pins as outputs
  pinMode(ENA, OUTPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  pinMode(ENB, OUTPUT);
  pinMode(IN3, OUTPUT);
  pinMode(IN4, OUTPUT);
}

void loop() {
  // Motor 1: Forward at 50% speed
  analogWrite(ENA, 128); // Set speed (0-255)
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);

  // Motor 2: Reverse at 75% speed
  analogWrite(ENB, 192); // Set speed (0-255)
  digitalWrite(IN3, LOW);
  digitalWrite(IN4, HIGH);

  delay(2000); // Run motors for 2 seconds

  // Stop both motors
  analogWrite(ENA, 0);
  analogWrite(ENB, 0);

  delay(2000); // Wait for 2 seconds
}
Important Considerations
- Heat Dissipation: The L298N IC can get hot during operation. Use a heat sink or active cooling for high-current applications.
- Power Supply: Ensure the motor power supply voltage matches the motor's specifications.
- Current Limitations: Do not exceed 2A per channel to avoid damaging the module.
- Jumper Settings: The onboard 5V regulator is enabled by default. Remove the jumper if using an external 5V logic supply.
Troubleshooting and FAQs
Common Issues and Solutions
Motors Not Running:
- Check all power and ground connections.
- Verify that the
ENAandENBpins are receiving PWM signals. - Ensure the motor power supply voltage is within the specified range.
Overheating:
- Use a heat sink or fan to cool the L298N IC.
- Reduce the motor load or current draw.
Erratic Motor Behavior:
- Check for loose or faulty connections.
- Verify the logic levels on
IN1,IN2,IN3, andIN4.
No Output on 5V Pin:
- Ensure the 5V jumper is in place.
- If using an external 5V supply, remove the jumper to avoid conflicts.
FAQs
Q: Can the L298N drive stepper motors?
A: Yes, the L298N can drive a bipolar stepper motor by controlling the two H-bridge channels.
Q: Can I use the L298N with a 3.3V microcontroller?
A: The L298N is designed for 5V logic levels. Use a level shifter or ensure the control signals are compatible.
Q: What is the maximum motor voltage I can use?
A: The maximum motor supply voltage is 35V. Ensure your motor is rated for this voltage.
Q: How do I control motor speed?
A: Use PWM signals on the ENA and ENB pins to control the speed of the motors.