The TMC2208 is a high-performance stepper motor driver manufactured by Analog Devices Inc. It is designed to provide smooth and quiet operation for stepper motors, making it ideal for applications requiring precision and low noise. The TMC2208 features advanced technologies such as stealthChop for silent operation and coolStep for intelligent current control, ensuring efficient and reliable performance.
Explore Projects Built with TMC2208 Stepper driver
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
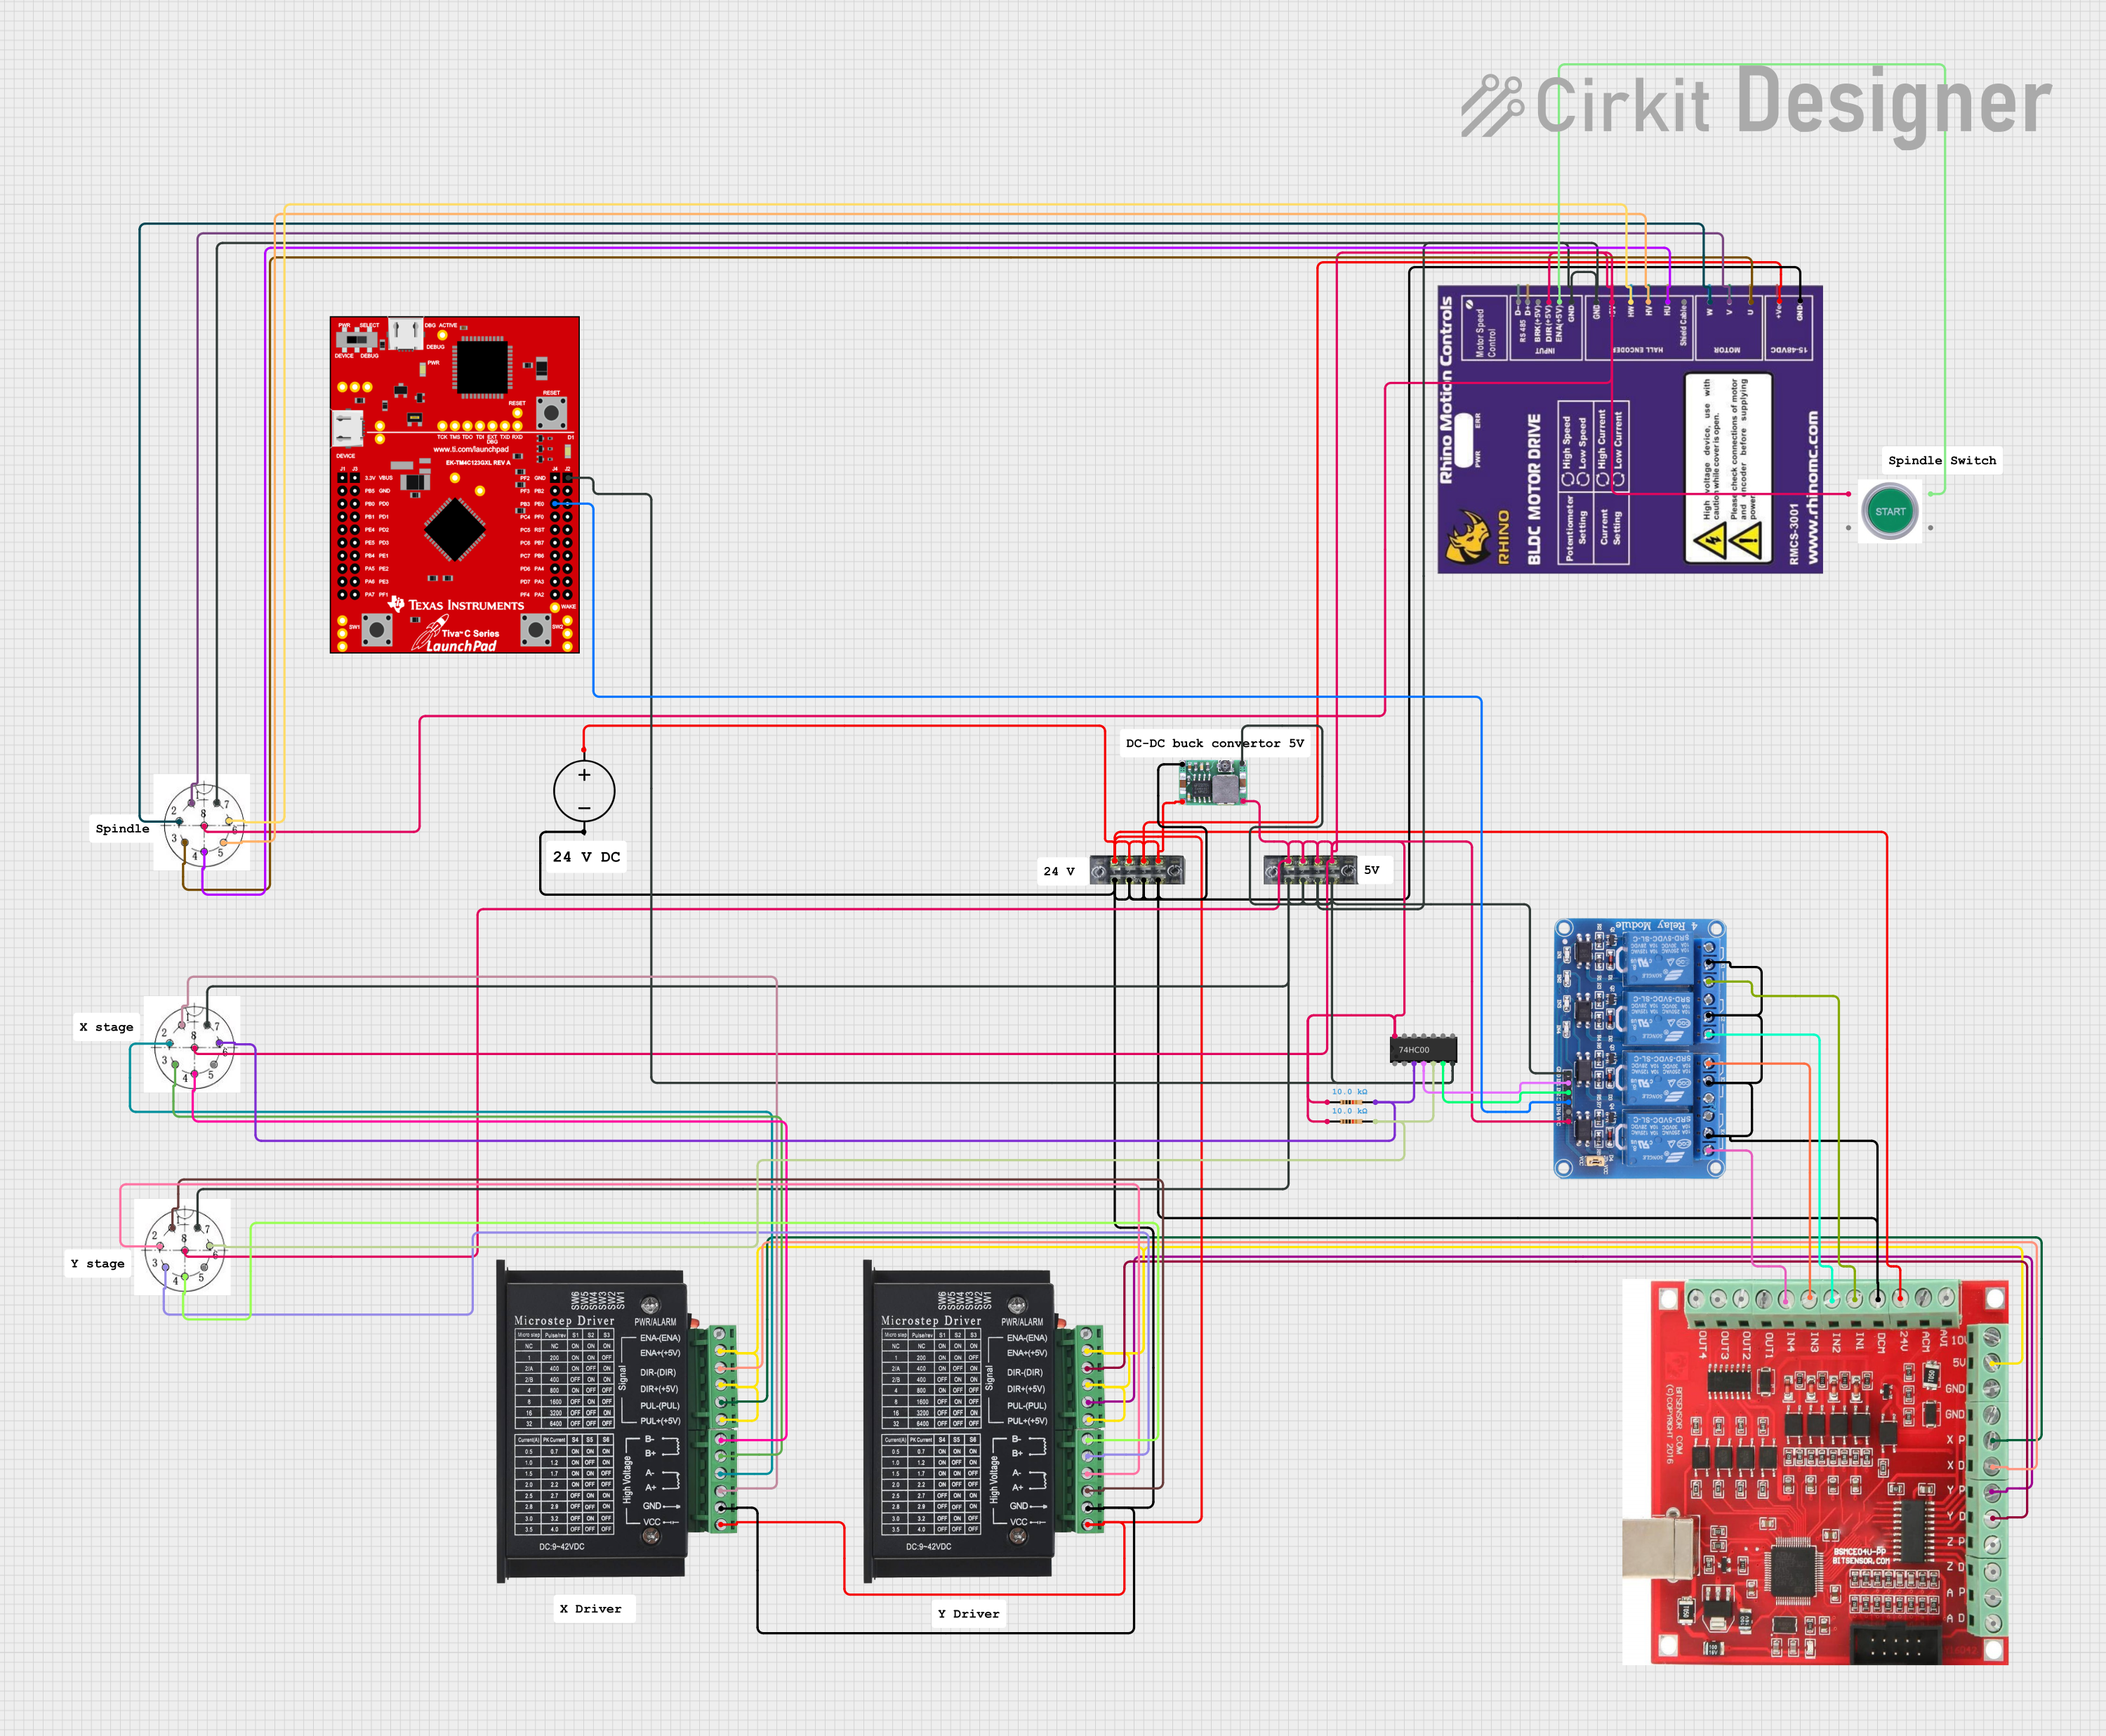
This circuit appears to be a control system for a CNC machine or similar automated equipment. It includes two tb6600 Micro Stepping Motor Drivers for controlling stepper motors, a DC power source with a step-down buck converter to provide the necessary voltage levels, and a 4-channel relay module for switching higher power loads. The MAch3 CNC USB interface suggests the system is designed to interface with computer numerical control software, and the RMCS_3001 BLDC Driver indicates the presence of a brushless DC motor control. The Tiva C launchpad microcontroller and various connectors imply that the system is modular and may be programmable for specific automation tasks.
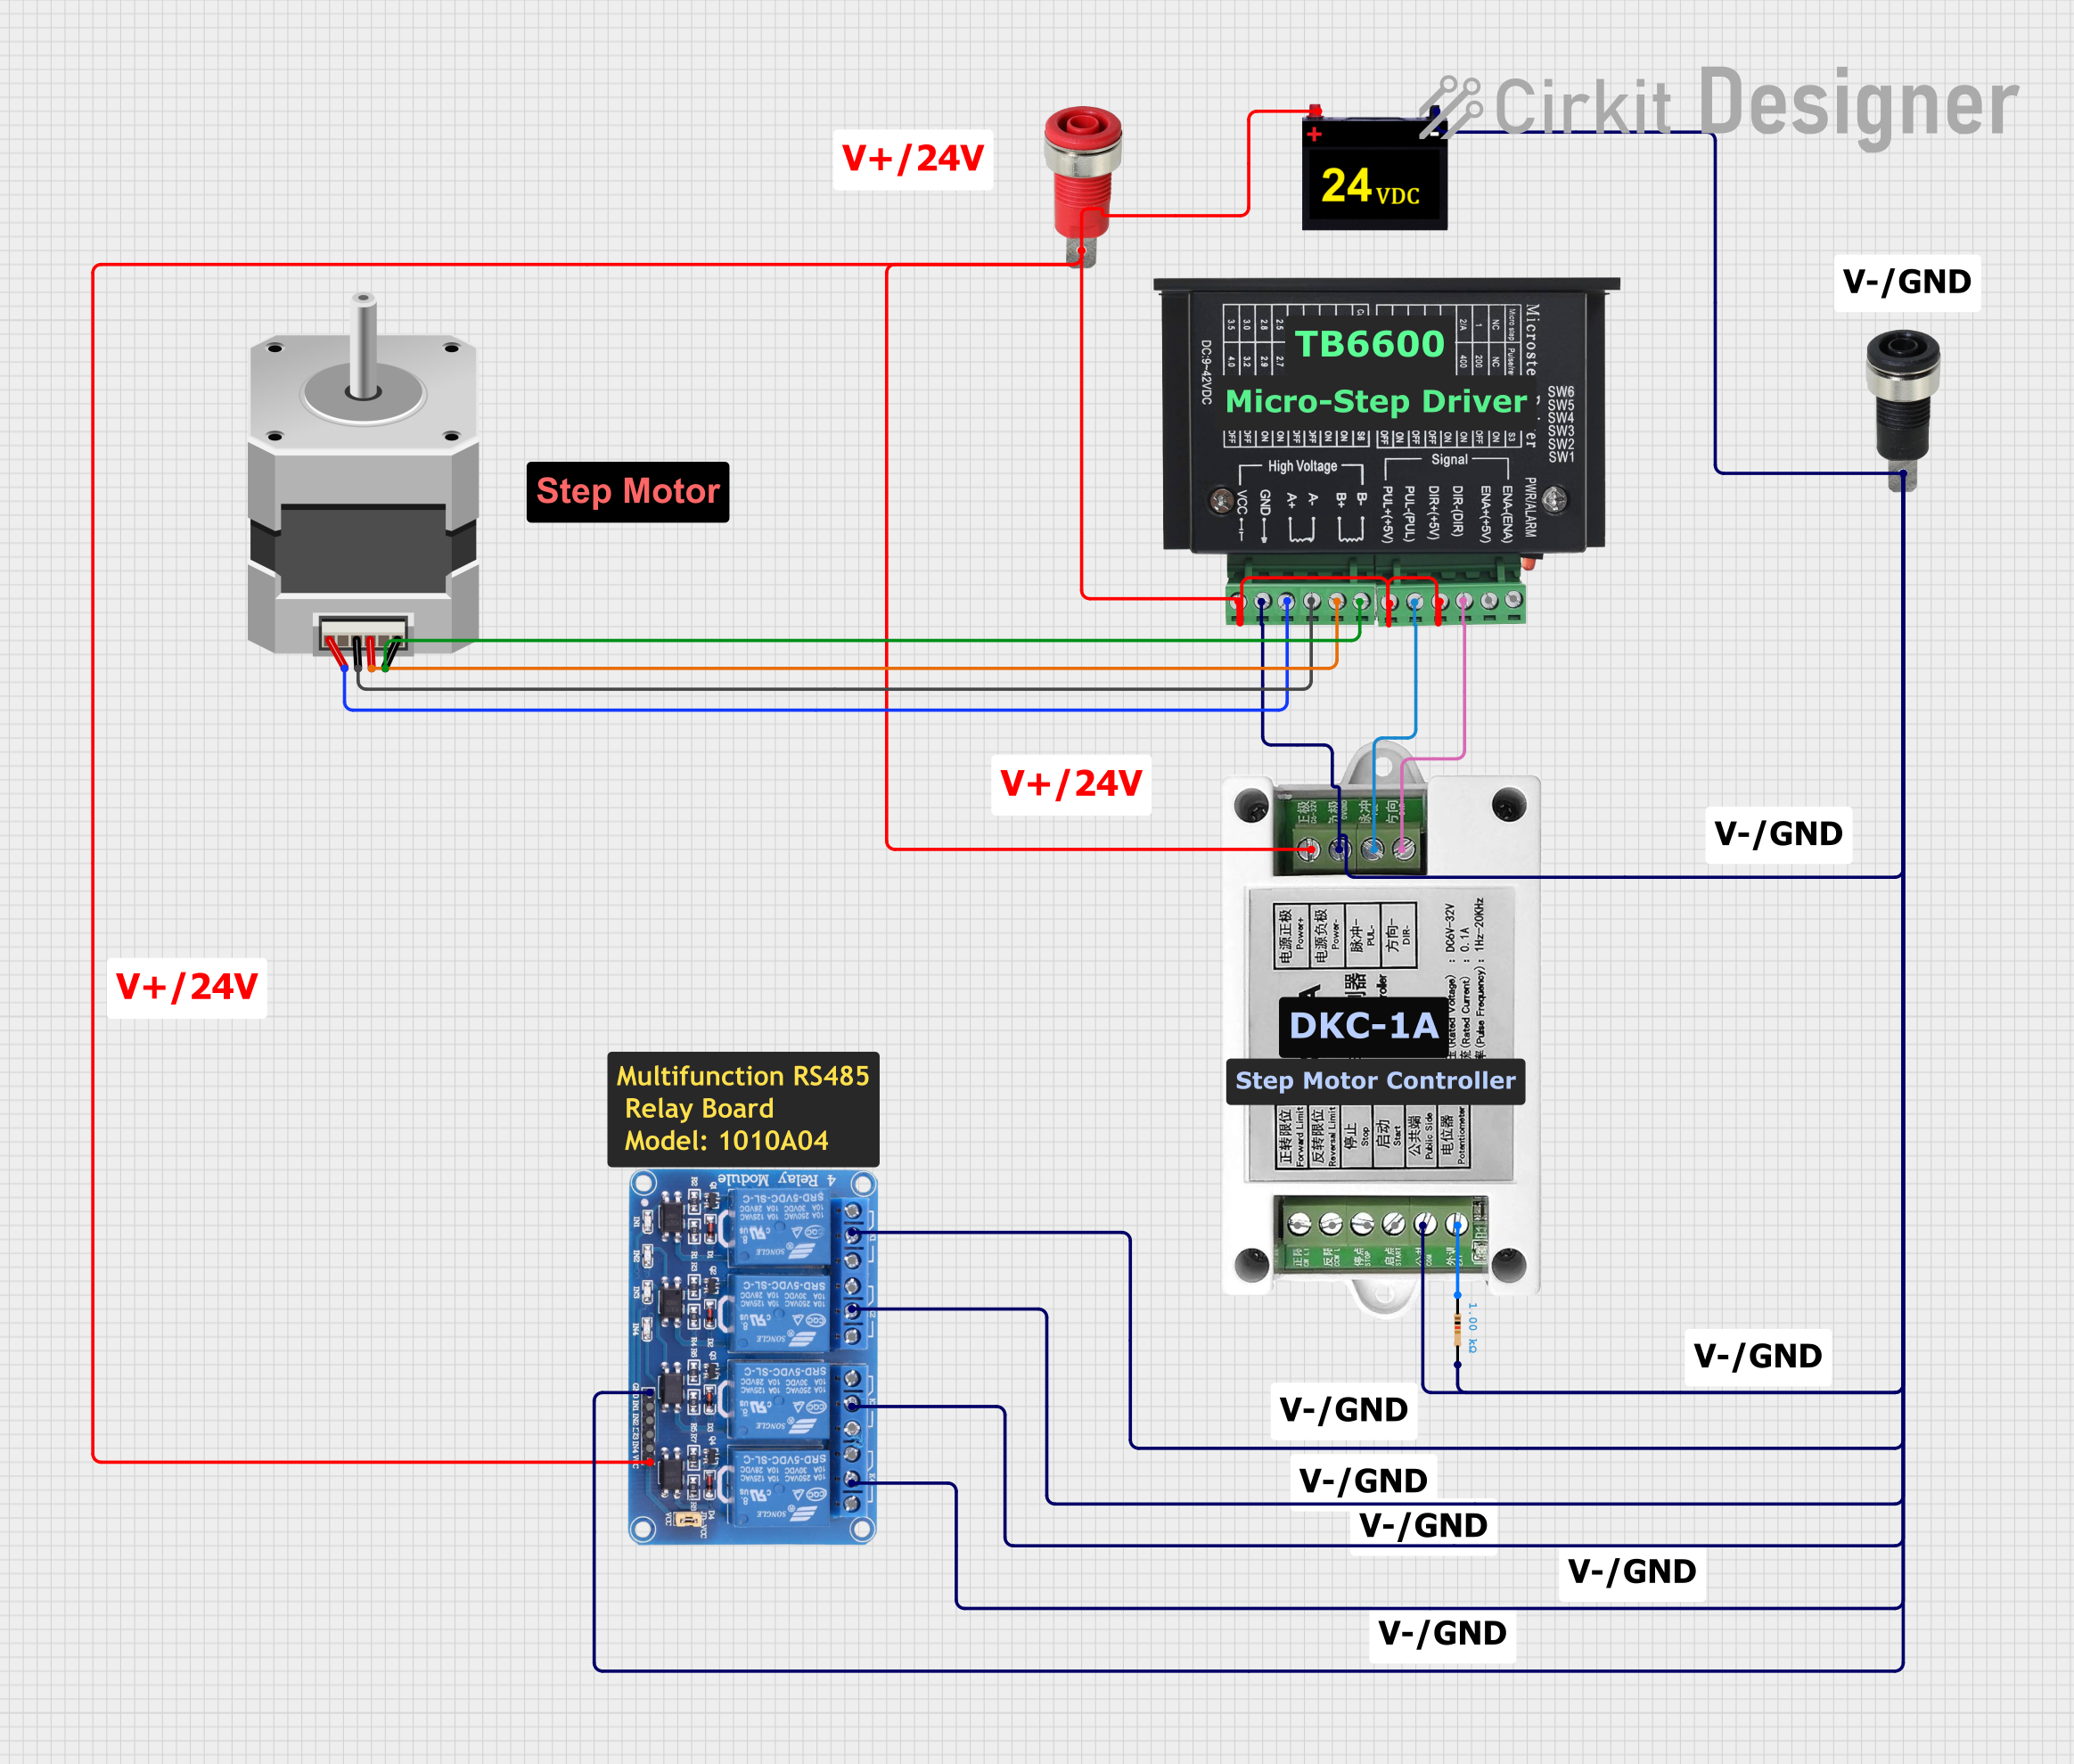
This circuit controls a bipolar stepper motor using a tb6600 micro stepping motor driver and a DKC-1A stepper motor controller. The system is powered by a 24VDC power supply and includes a relay module for additional control functionalities.
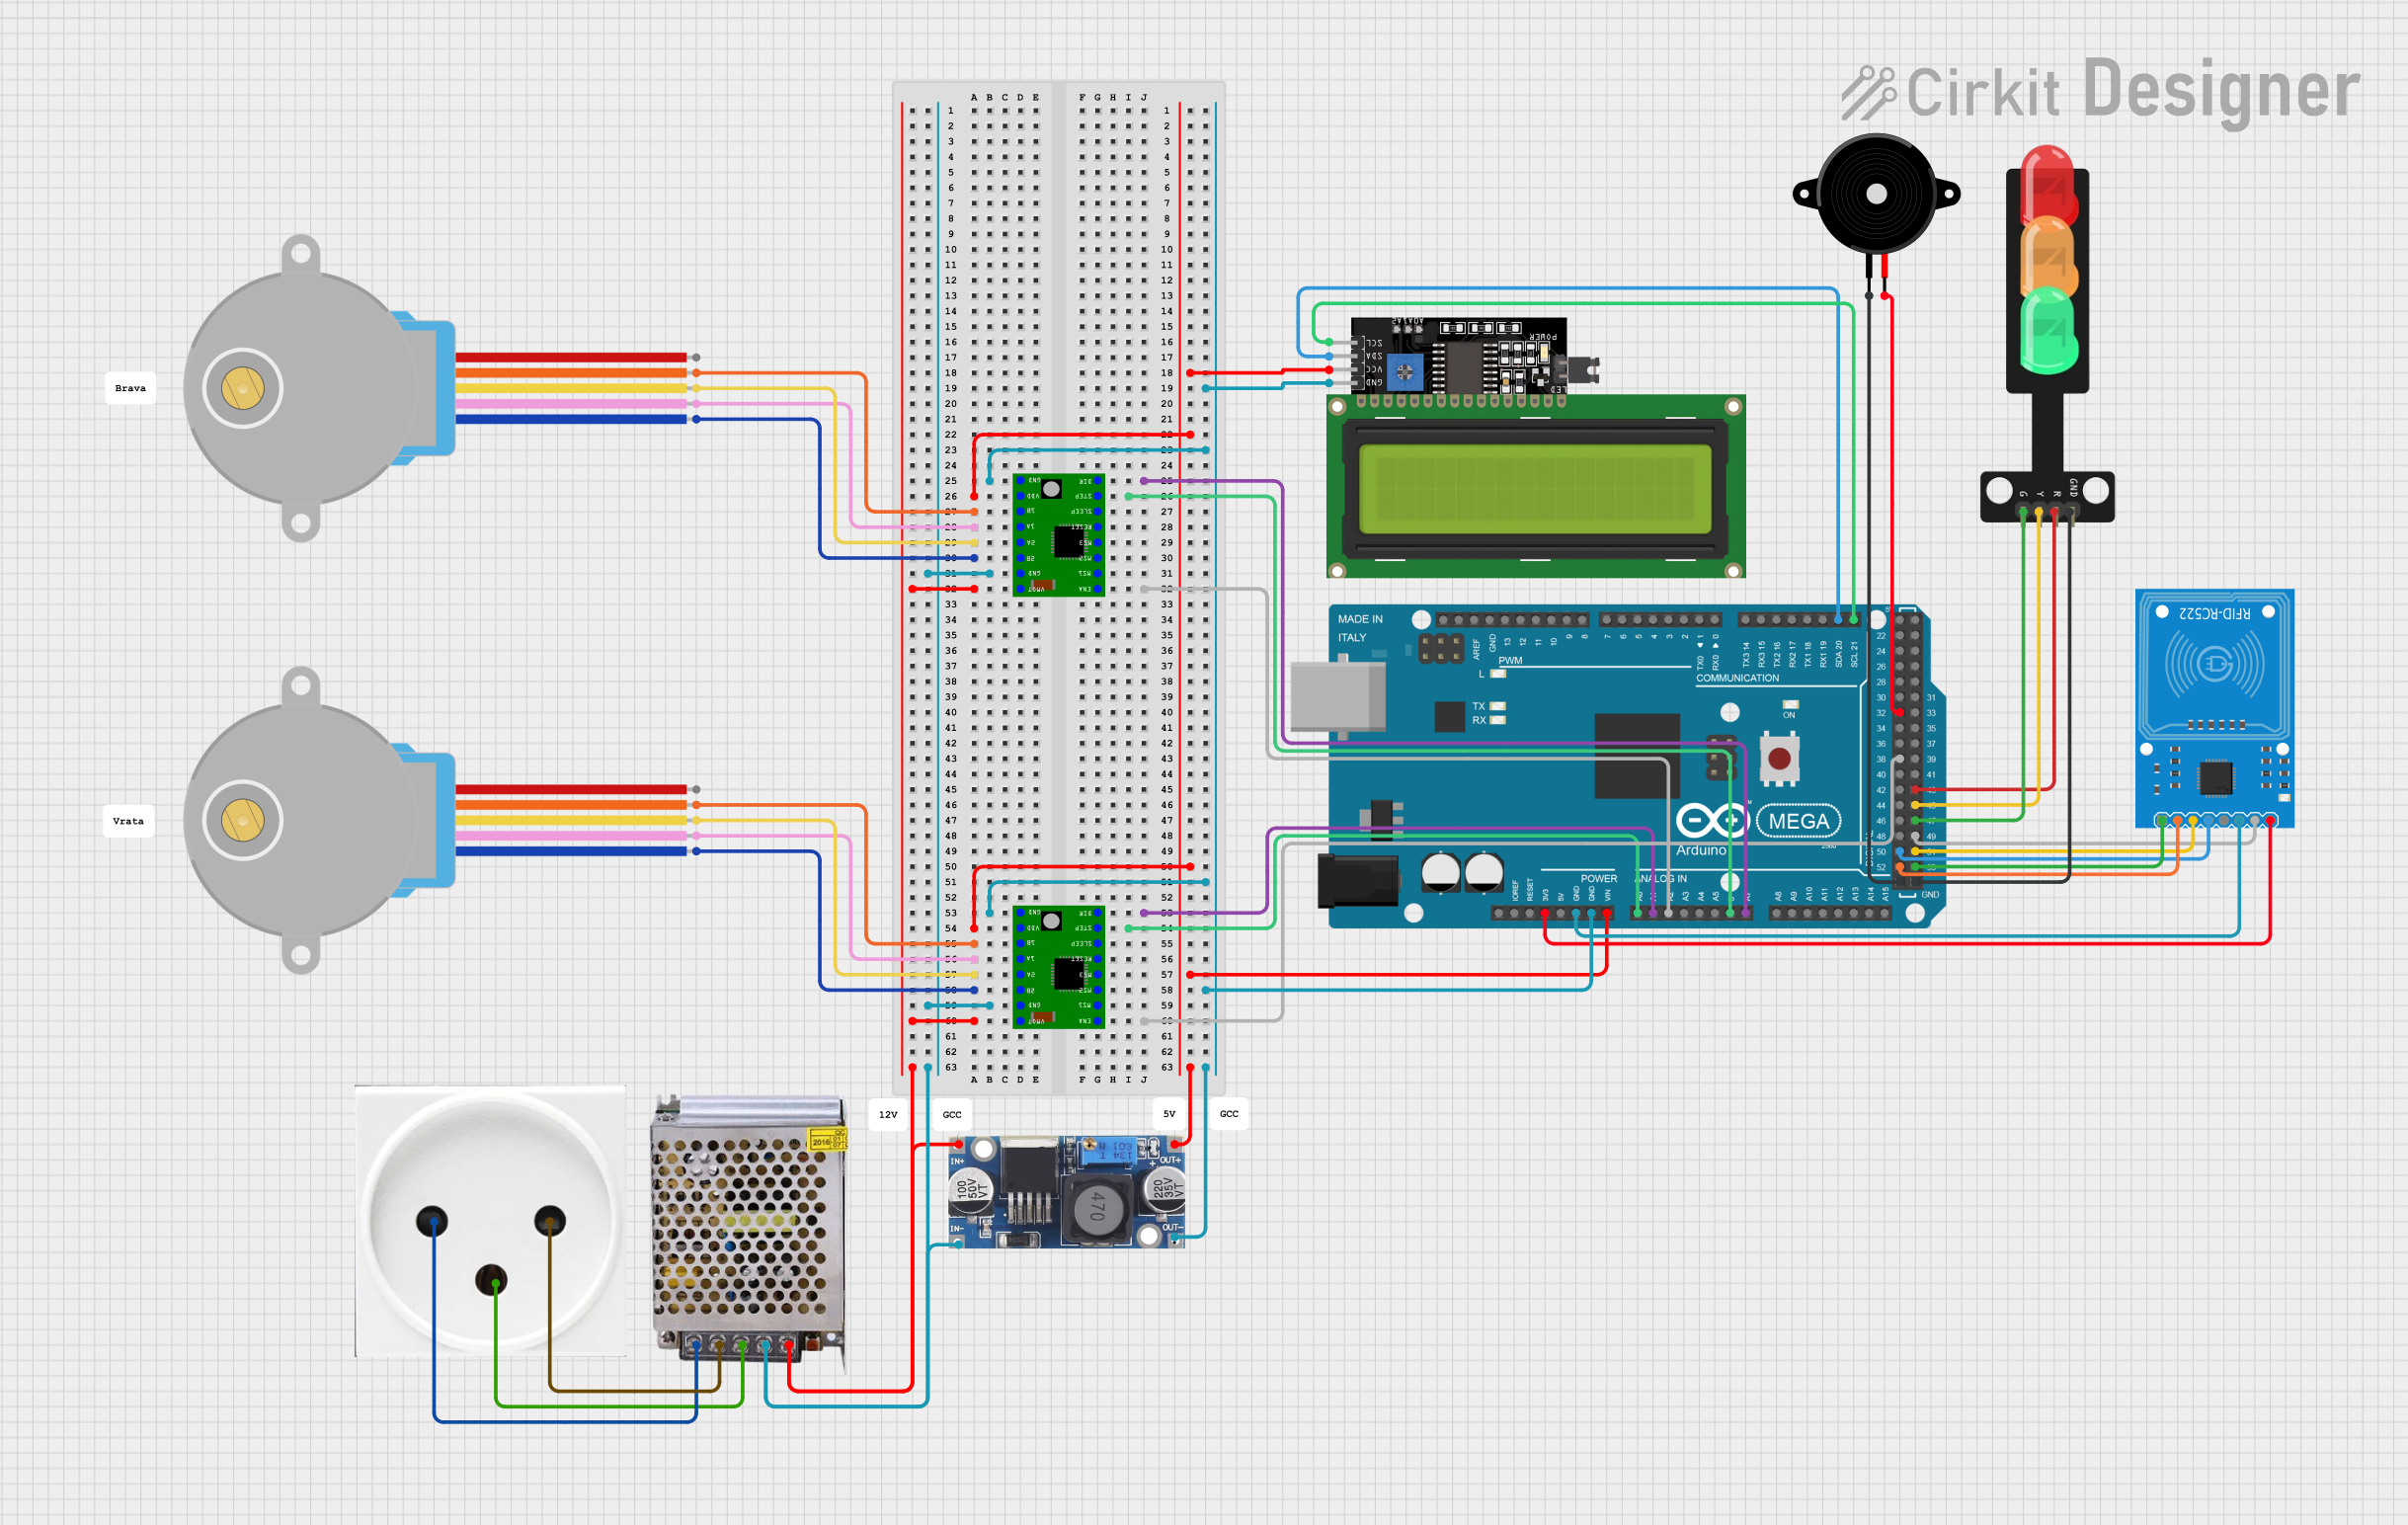
This circuit controls two 28BYJ-48 stepper motors using A4988 stepper motor driver carriers, interfaced with an Arduino Mega 2560 microcontroller. It features an RFID-RC522 module for RFID reading, a 16x4 LCD display with I2C interface for user interaction, and a piezo speaker for audio feedback. Additionally, there is a traffic light module controlled by the Arduino, and a 48V to 5V converter to step down voltage for the logic levels. The power supply provides 12V to the motor drivers and is connected to a standard power outlet.
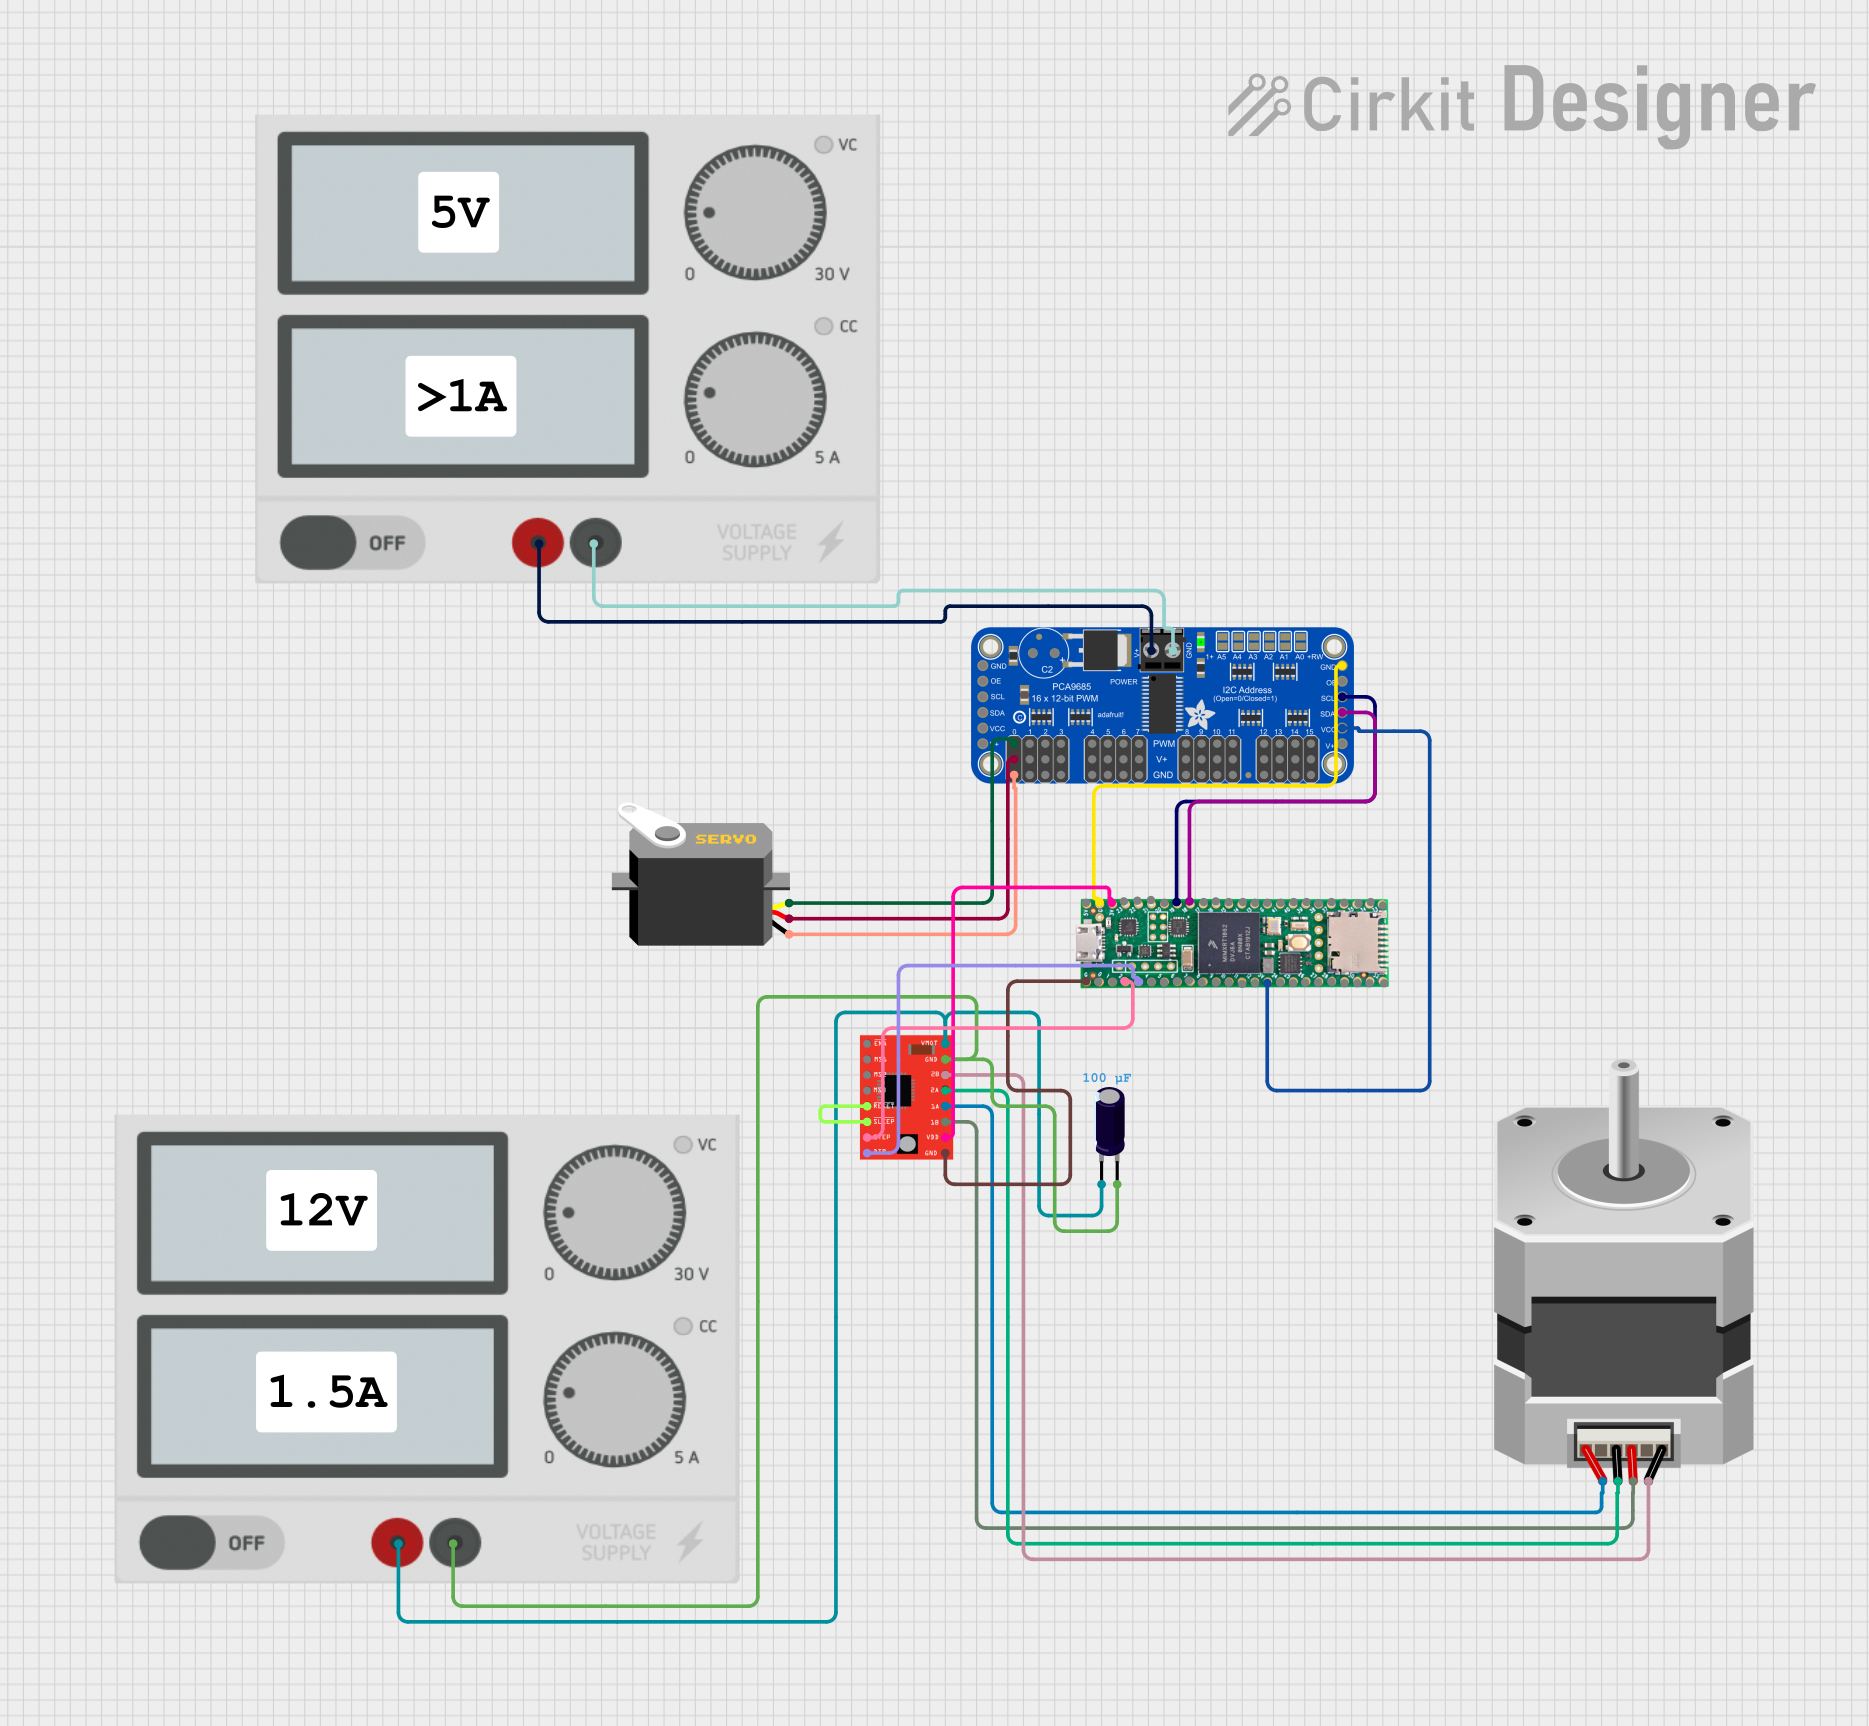
This circuit controls a bipolar stepper motor using an A4988 Stepper Motor Driver, which is interfaced with a Teensy 4.1 microcontroller. The Teensy sends step and direction signals to the driver, while the driver's RESET and SLEEP pins are tied together, likely for simplified control. Additionally, the circuit includes an Adafruit PCA9685 PWM Servo Breakout board, which is connected to a servo motor and communicates with the Teensy via I2C, and both the driver and the breakout board are powered by separate power supplies with decoupling provided by an electrolytic capacitor.
The TMC2208 is a versatile and feature-rich stepper motor driver. Below are its key technical specifications:
Parameter
Value
Supply Voltage (V_M)
4.75V to 36V
Logic Voltage (V_IO)
3.3V or 5V
Maximum Motor Current
1.2A RMS (2.0A peak)
Microstepping Resolution
Up to 256 microsteps per full step
Communication Interface
UART
Operating Temperature
-40°C to +125°C
Features
stealthChop, coolStep, spreadCycle
Pin Configuration and Descriptions
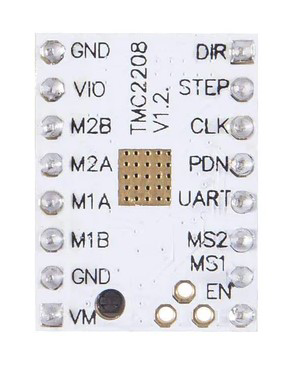
The TMC2208 comes in a compact package with the following pin configuration:
Pin
Name
Description
1
GND
Ground connection
2
V_M
Motor power supply (4.75V to 36V)
3
V_IO
Logic voltage input (3.3V or 5V)
4
EN
Enable pin (active low)
5
DIR
Direction control input
6
STEP
Step pulse input
7
UART_TX
UART transmit pin for communication
8
UART_RX
UART receive pin for communication
9
MS1
Microstepping resolution selection pin 1
10
MS2
Microstepping resolution selection pin 2
11
NC
Not connected
12
OUT1A
Motor coil 1 output A
13
OUT1B
Motor coil 1 output B
14
OUT2A
Motor coil 2 output A
15
OUT2B
Motor coil 2 output B
Usage Instructions
How to Use the TMC2208 in a Circuit
Power Supply: Connect the motor power supply (V_M) to a voltage source between 4.75V and 36V. Ensure the logic voltage (V_IO) matches your microcontroller's logic level (3.3V or 5V).
Motor Connection: Connect the stepper motor coils to the OUT1A, OUT1B, OUT2A, and OUT2B pins.
Control Pins: Use the STEP and DIR pins to control the motor's movement. The STEP pin receives pulses to move the motor, while the DIR pin sets the rotation direction.
Microstepping: Configure the microstepping resolution using the MS1 and MS2 pins or via UART communication.
UART Communication: Connect the UART_TX and UART_RX pins to your microcontroller for advanced configuration and monitoring.
Enable Pin: Use the EN pin to enable or disable the driver. Pull it low to enable the driver.
Important Considerations and Best Practices
Use decoupling capacitors near the V_M and V_IO pins to stabilize the power supply.
Ensure proper heat dissipation by using a heatsink or adequate ventilation, especially for high-current applications.
Avoid exceeding the maximum current and voltage ratings to prevent damage to the driver.
Use shielded cables for motor connections to minimize electromagnetic interference (EMI).
Example: Using the TMC2208 with an Arduino UNO
Below is an example of how to control a stepper motor using the TMC2208 and an Arduino UNO:
// Example: Controlling a stepper motor with TMC2208 and Arduino UNO

#define STEP_PIN 3  // Pin connected to STEP on TMC2208
#define DIR_PIN 4   // Pin connected to DIR on TMC2208
#define EN_PIN 5    // Pin connected to EN on TMC2208

void setup() {
  pinMode(STEP_PIN, OUTPUT); // Set STEP pin as output
  pinMode(DIR_PIN, OUTPUT);  // Set DIR pin as output
  pinMode(EN_PIN, OUTPUT);   // Set EN pin as output

  digitalWrite(EN_PIN, LOW); // Enable the TMC2208 driver
  digitalWrite(DIR_PIN, HIGH); // Set initial direction (HIGH = clockwise)
}

void loop() {
  // Generate step pulses to move the motor
  digitalWrite(STEP_PIN, HIGH); // Step pulse HIGH
  delayMicroseconds(500);       // Wait 500 microseconds
  digitalWrite(STEP_PIN, LOW);  // Step pulse LOW
  delayMicroseconds(500);       // Wait 500 microseconds
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving:
Ensure the EN pin is pulled low to enable the driver.
Verify the STEP and DIR signals are being sent correctly.
Check the motor connections to the OUT1A, OUT1B, OUT2A, and OUT2B pins.
Overheating:
Use a heatsink or active cooling to dissipate heat.
Reduce the motor current using the UART interface or configuration pins.
Noisy Operation:
Enable stealthChop mode for silent operation.
Check for loose connections or EMI interference.
UART Communication Issues:
Verify the UART_TX and UART_RX connections.
Ensure the baud rate matches the TMC2208's default or configured value.
FAQs
Q: Can the TMC2208 operate without UART communication?
A: Yes, the TMC2208 can operate in standalone mode using the STEP, DIR, and MS1/MS2 pins for basic control.
Q: How do I configure the microstepping resolution?
A: You can set the microstepping resolution using the MS1 and MS2 pins or via UART commands.
Q: What is the maximum current the TMC2208 can handle?
A: The TMC2208 supports up to 1.2A RMS (2.0A peak) per motor coil. Ensure proper cooling for high-current applications.

 Open Project in Cirkit Designer