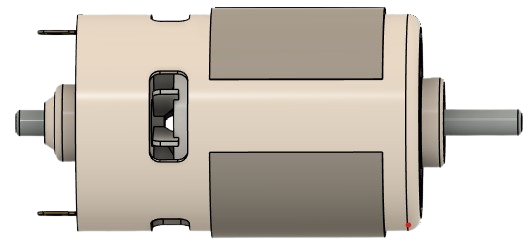
The RS 775 DC Motor is a high-power, brushed DC motor manufactured by Generic. It is known for its high torque and speed capabilities, making it a popular choice in various applications. This motor operates at 12V and can achieve speeds up to 3000 RPM. It is commonly used in robotics, industrial machinery, and other applications requiring reliable and powerful motor performance.
Explore Projects Built with RS 775 DC MOTOR
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
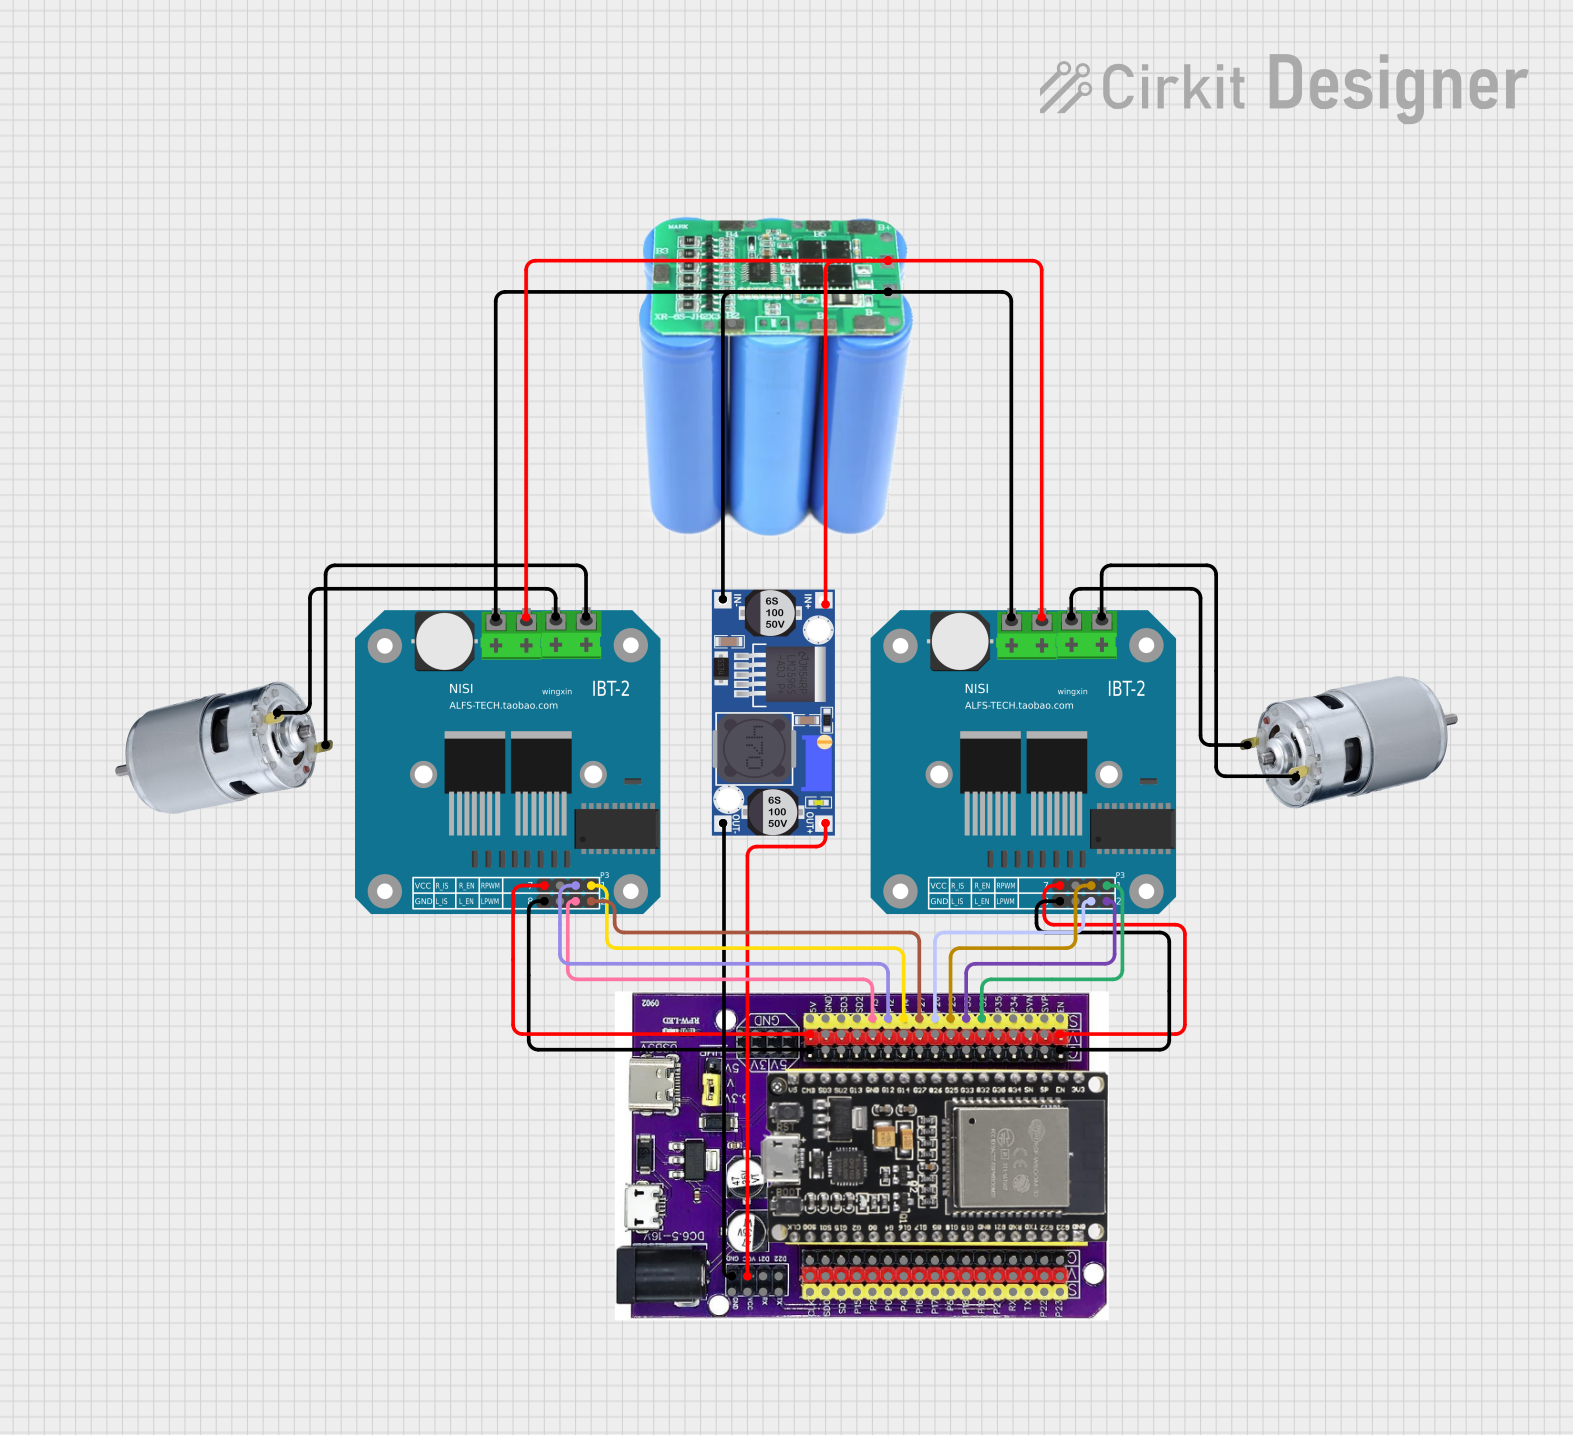
This circuit is designed to control two 775 motors using two BTS7960 motor drivers, which are managed by an ESP32 microcontroller. The power is supplied by a 18650 3s2p battery pack, regulated through a buck converter to provide appropriate voltage levels for the components.
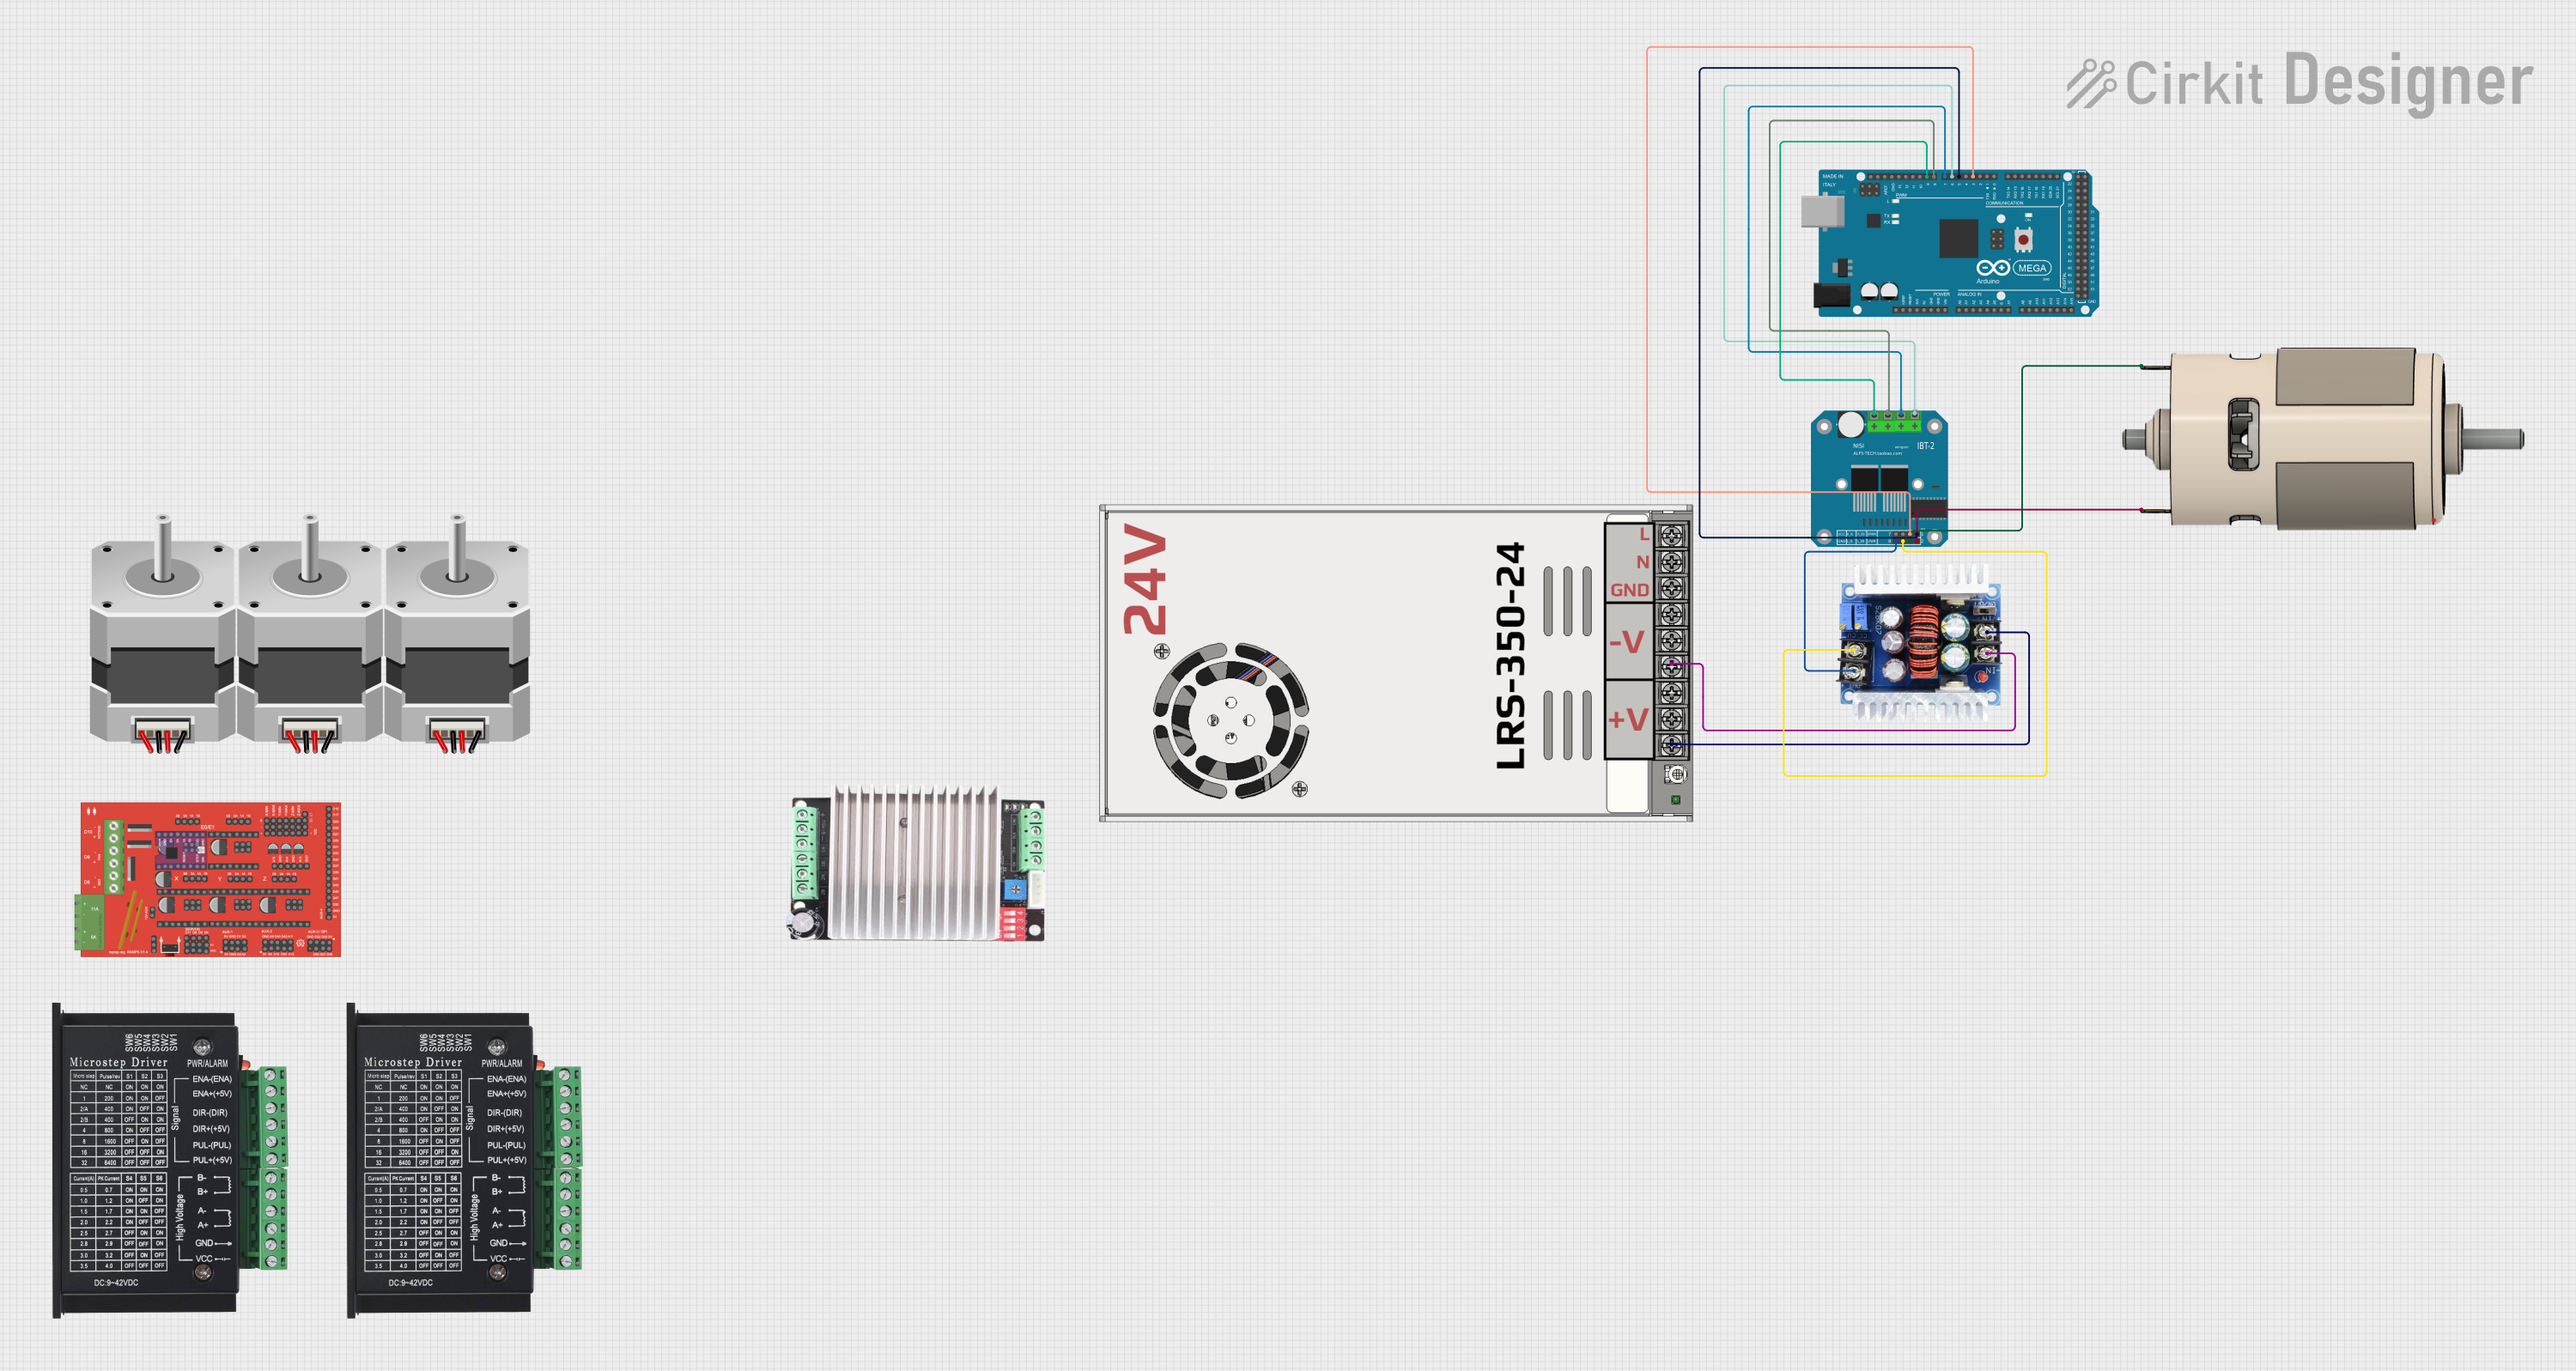
This circuit controls a high-power DC motor using an Arduino Mega 2560 and a BTS7960 motor driver. The Arduino generates PWM signals to control the speed of the motor, while a step-down buck converter provides the necessary voltage to the motor driver from a 24V power supply.
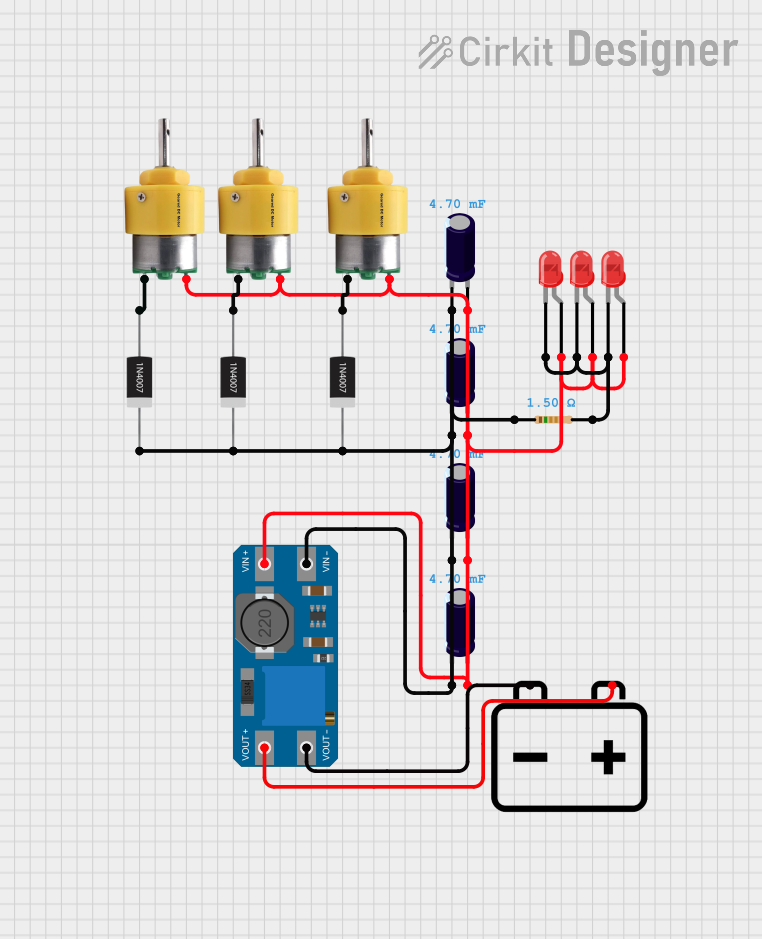
This circuit consists of three Center Shaft Metal Geared Motors, each protected by a 1N4007 Rectifier Diode, and powered by a 12V battery through an MT3608 boost converter. The circuit also includes multiple electrolytic capacitors for filtering and three red LEDs with a current-limiting resistor, indicating the operational status of the motors.
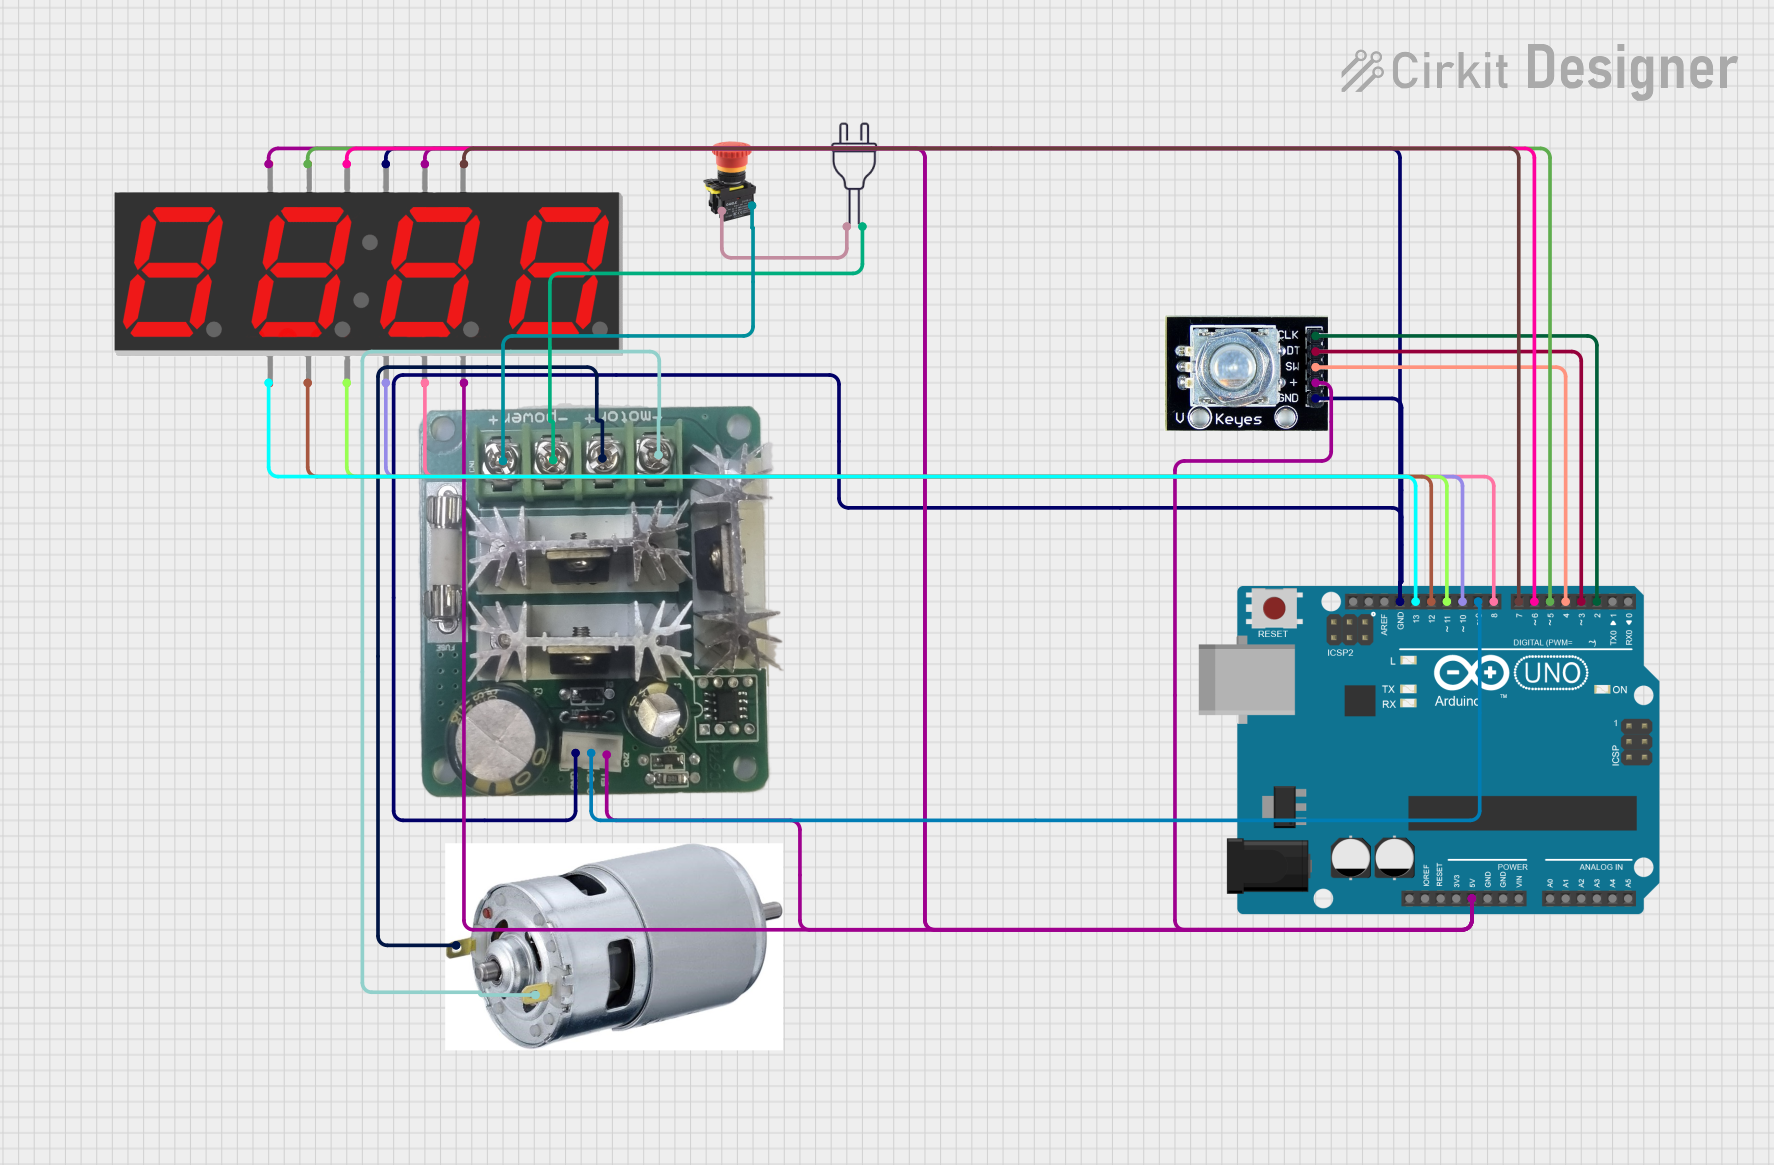
This circuit controls a 775 motor using an Arduino UNO and a PWM DC motor controller, with user input from a rotary encoder to set the runtime. The runtime is displayed on a 4-digit 7-segment display, and the motor operation is initiated by pressing the rotary encoder's button.
Robotics: Used for driving wheels, arms, and other moving parts.
Industrial Machinery: Employed in conveyor belts, drills, and other equipment.
DIY Projects: Ideal for hobbyists building custom machines or vehicles.
Electric Vehicles: Utilized in small electric vehicles for propulsion.
Technical Specifications
Key Technical Details
Parameter
Value
Voltage Rating
12V
Speed
3000 RPM
Current Rating
1.2A (no load)
Stall Current
12A
Power Output
30W
Torque
0.5 Nm
Shaft Diameter
5 mm
Motor Diameter
42 mm
Motor Length
66 mm
Weight
320 g
Pin Configuration and Descriptions
Pin Number
Description
1
Positive Terminal (+)
2
Negative Terminal (-)
Usage Instructions
How to Use the Component in a Circuit
Power Supply: Connect the positive terminal of the power supply to the positive terminal of the motor (Pin 1) and the negative terminal of the power supply to the negative terminal of the motor (Pin 2).
Motor Driver: For better control, use a motor driver like the L298N. Connect the motor terminals to the output pins of the driver.
Control with Arduino: Connect the motor driver to an Arduino UNO for precise control. Use PWM (Pulse Width Modulation) to control the speed of the motor.
Important Considerations and Best Practices
Heat Dissipation: Ensure proper ventilation or heat sinks to prevent overheating.
Current Limiting: Use a current-limiting resistor or a fuse to protect the motor from overcurrent.
Power Supply: Use a stable power supply to avoid voltage fluctuations that could damage the motor.
Mounting: Securely mount the motor to prevent vibrations and ensure smooth operation.
Example Code for Arduino UNO
// Example code to control RS 775 DC Motor with Arduino UNO and L298N motor driver

const int enA = 9; // PWM pin to control speed
const int in1 = 8; // Control pin 1
const int in2 = 7; // Control pin 2

void setup() {
  pinMode(enA, OUTPUT); // Set PWM pin as output
  pinMode(in1, OUTPUT); // Set control pin 1 as output
  pinMode(in2, OUTPUT); // Set control pin 2 as output
}

void loop() {
  // Rotate motor clockwise
  digitalWrite(in1, HIGH); // Set control pin 1 high
  digitalWrite(in2, LOW);  // Set control pin 2 low
  analogWrite(enA, 255);   // Set speed to maximum (255)

  delay(2000); // Run motor for 2 seconds

  // Stop motor
  digitalWrite(in1, LOW);  // Set control pin 1 low
  digitalWrite(in2, LOW);  // Set control pin 2 low
  analogWrite(enA, 0);     // Set speed to 0

  delay(1000); // Wait for 1 second

  // Rotate motor counterclockwise
  digitalWrite(in1, LOW);  // Set control pin 1 low
  digitalWrite(in2, HIGH); // Set control pin 2 high
  analogWrite(enA, 255);   // Set speed to maximum (255)

  delay(2000); // Run motor for 2 seconds

  // Stop motor
  digitalWrite(in1, LOW);  // Set control pin 1 low
  digitalWrite(in2, LOW);  // Set control pin 2 low
  analogWrite(enA, 0);     // Set speed to 0

  delay(1000); // Wait for 1 second
}
Troubleshooting and FAQs
Common Issues Users Might Face
Motor Not Spinning:
Solution: Check the power supply connections and ensure the voltage is correct. Verify that the motor driver is functioning properly.
Overheating:
Solution: Ensure proper ventilation and consider adding a heat sink. Check for overcurrent conditions and use a current-limiting resistor if necessary.
Inconsistent Speed:
Solution: Use a stable power supply and ensure the PWM signal from the Arduino is consistent. Check for loose connections.
Excessive Noise:
Solution: Securely mount the motor and check for any mechanical obstructions. Lubricate the motor bearings if needed.
FAQs
Q: Can I run the RS 775 DC Motor at a voltage higher than 12V?
A: It is not recommended to exceed the rated voltage of 12V as it may damage the motor.
Q: How can I reverse the direction of the motor?
A: Swap the connections of the positive and negative terminals or use a motor driver to control the direction programmatically.
Q: What is the maximum current the motor can handle?
A: The stall current is 12A. Ensure your power supply and motor driver can handle this current to avoid damage.
Q: Can I control the speed of the motor?
A: Yes, you can use PWM (Pulse Width Modulation) to control the speed of the motor.
This documentation provides a comprehensive guide to using the RS 775 DC Motor. Whether you are a beginner or an experienced user, following these instructions and best practices will help you achieve optimal performance and longevity from your motor.

 Open Project in Cirkit Designer