The PIC18F458 is an 8-bit microcontroller developed by Microchip Technology. It features a 16-bit instruction set, 32 KB of Flash memory, 1.5 KB of RAM, and a wide range of I/O ports. This microcontroller is designed for embedded applications that demand high performance and low power consumption. Its robust feature set makes it suitable for automotive, industrial, and consumer electronics applications.
Explore Projects Built with PIC18F458
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
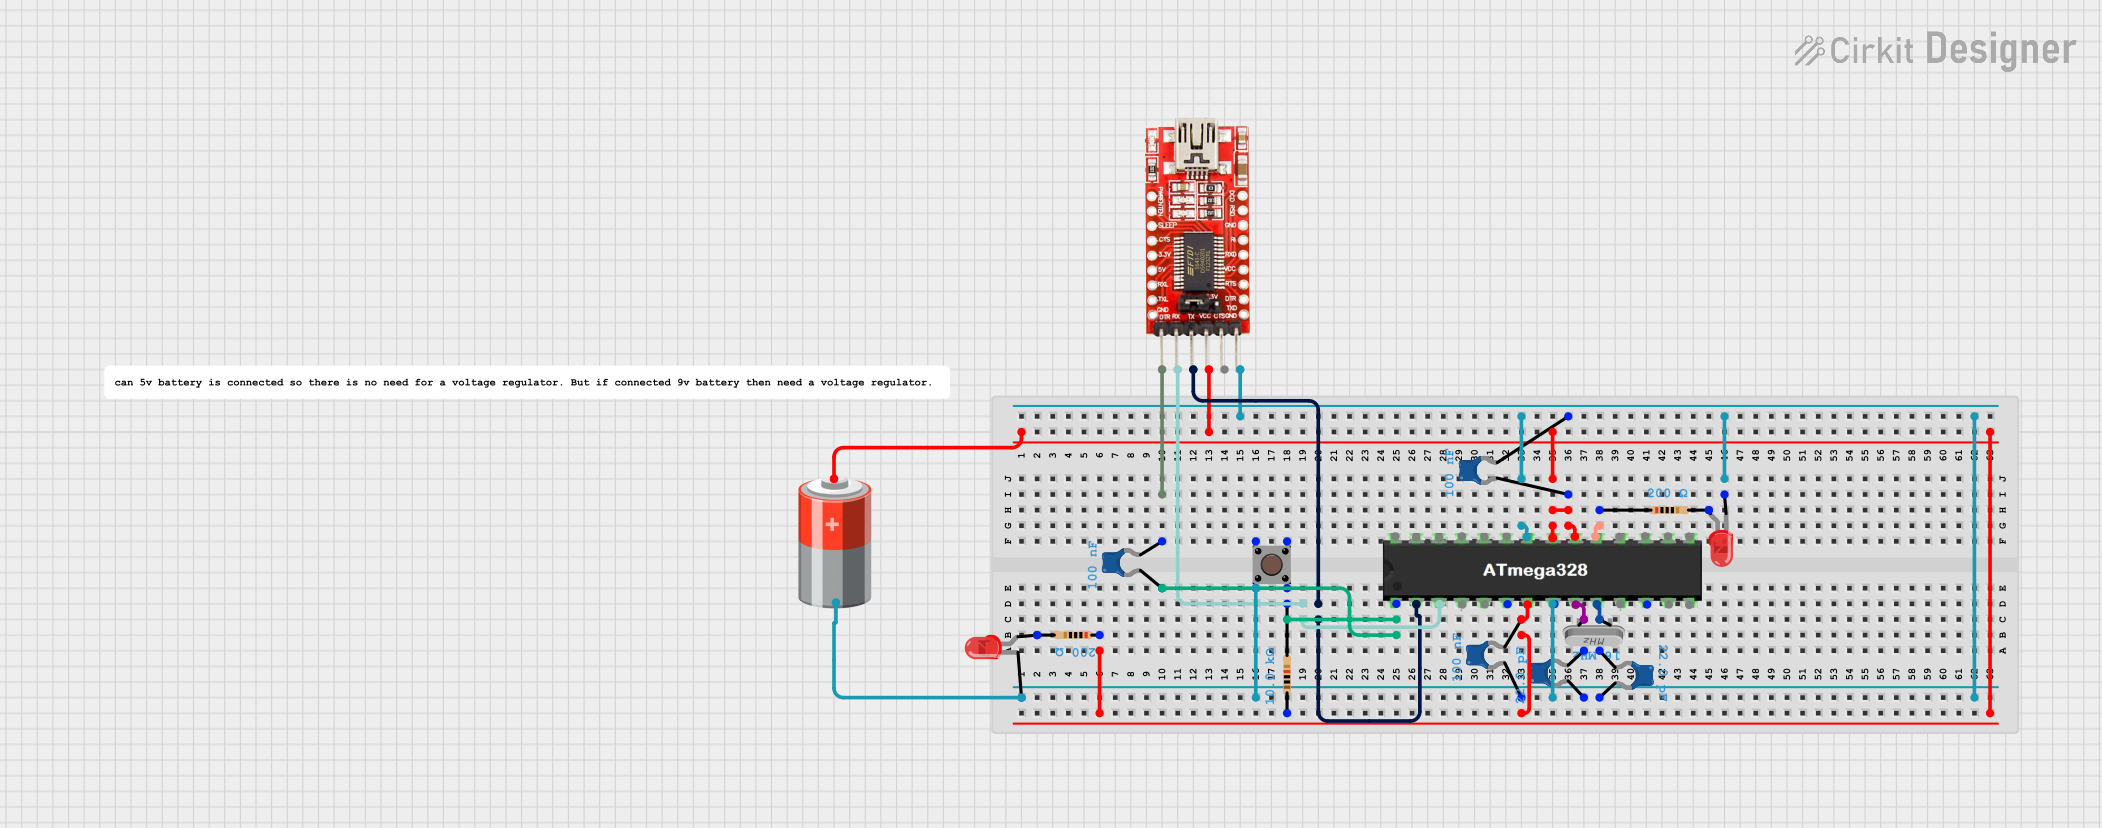
This circuit is a basic microcontroller setup using an ATMEGA328, powered by a 5V battery, and includes an FTDI programmer for serial communication. It features a pushbutton for reset functionality and two LEDs controlled by the microcontroller, with one LED blinking at a 1-second interval as programmed.
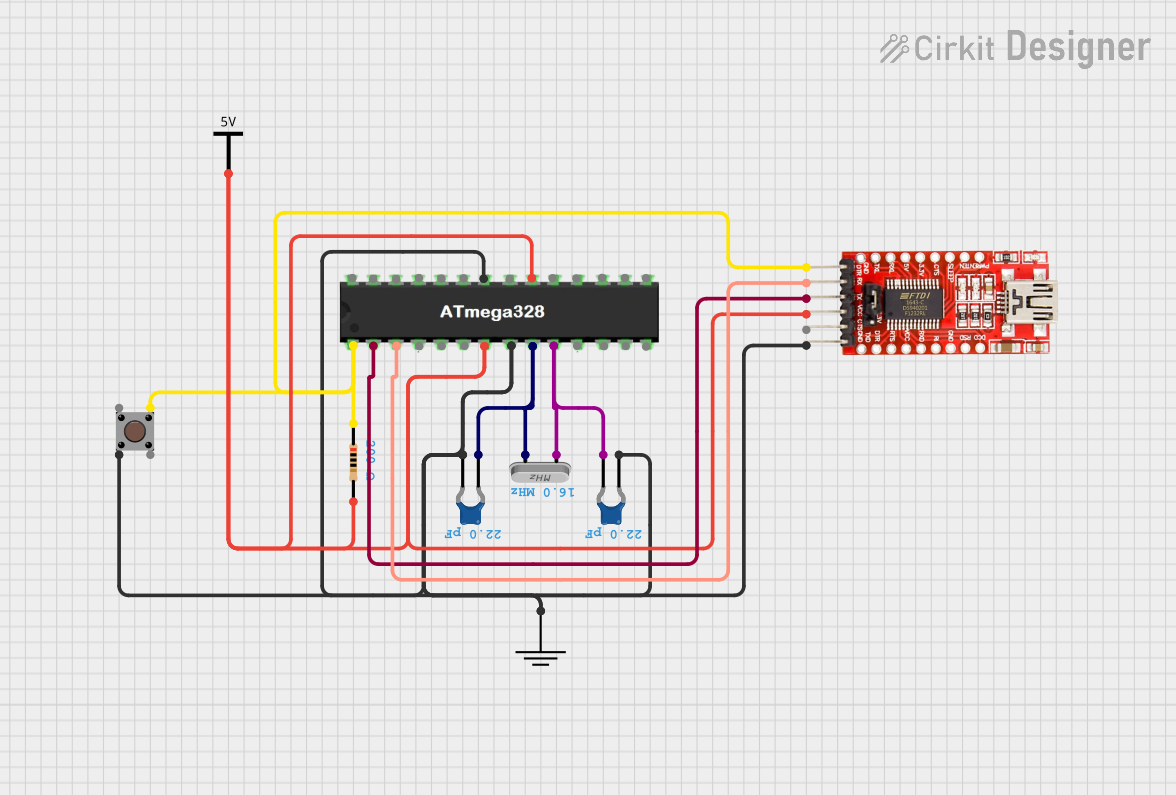
This circuit features an ATMEGA328 microcontroller configured with a crystal oscillator for precise timing, and a pushbutton for reset functionality. An FTDI Programmer is connected for serial communication, allowing for programming and data exchange with the microcontroller.
This circuit is a data acquisition and communication system powered by a LiPoly battery and managed by a Raspberry Pi Pico. It includes sensors (BMP280, MPU9250) for environmental data, a GPS module for location tracking, an SD card for data storage, and a WLR089-CanSAT for wireless communication. The TP4056 module handles battery charging, and a toggle switch controls power distribution.
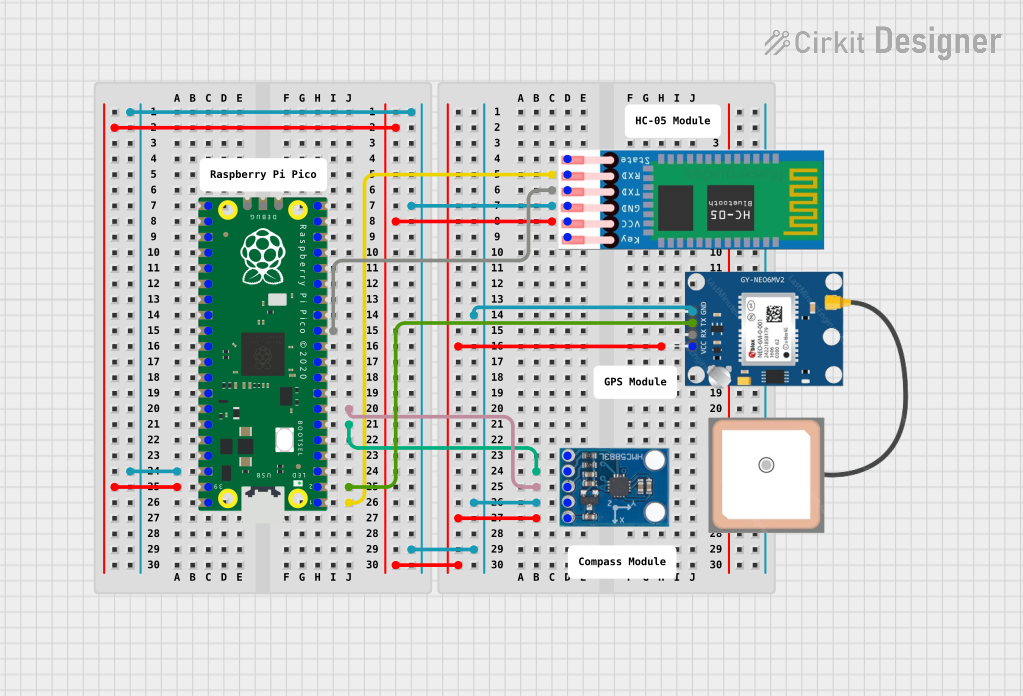
This circuit features a Raspberry Pi Pico microcontroller interfaced with an HC-05 Bluetooth module for wireless communication, an HMC5883L compass module for magnetic field measurement, and a GPS NEO 6M module for location tracking. The Pico is configured to communicate with the HC-05 via serial connection (TX/RX), with the compass module via I2C (SCL/SDA), and with the GPS module via serial (TX/RX). Common power (VCC) and ground (GND) lines are shared among all modules, indicating a unified power system.
Embedded systems requiring low power and high performance
Technical Specifications
Key Technical Details
Parameter
Specification
CPU Architecture
8-bit
Instruction Set
16-bit
Flash Memory
32 KB
RAM
1.5 KB
EEPROM
256 Bytes
Operating Voltage Range
4.2V to 5.5V
Clock Speed
Up to 40 MHz
I/O Pins
36
Communication Interfaces
CAN, SPI, I²C, USART
Timers
4 (8-bit and 16-bit)
ADC Resolution
10-bit (8 channels)
Package Types
PDIP, QFN, TQFP
Pin Configuration and Descriptions
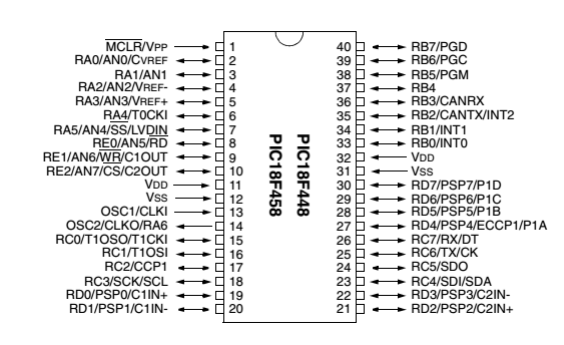
The PIC18F458 is available in a 40-pin PDIP package. Below is the pin configuration and description:
Pin Number
Pin Name
Type
Description
1
MCLR/VPP
Input
Master Clear (Reset) or Programming Voltage
2
RA0/AN0
I/O, Analog
General Purpose I/O or Analog Input 0
3
RA1/AN1
I/O, Analog
General Purpose I/O or Analog Input 1
4
RA2/AN2/VREF-
I/O, Analog
General Purpose I/O, Analog Input 2, or Voltage Reference (-)
5
RA3/AN3/VREF+
I/O, Analog
General Purpose I/O, Analog Input 3, or Voltage Reference (+)
6
RA4/T0CKI
I/O
General Purpose I/O or Timer0 Clock Input
7
RA5/AN4
I/O, Analog
General Purpose I/O or Analog Input 4
8
RE0/AN5
I/O, Analog
General Purpose I/O or Analog Input 5
9
RE1/AN6
I/O, Analog
General Purpose I/O or Analog Input 6
10
RE2/AN7
I/O, Analog
General Purpose I/O or Analog Input 7
...
...
...
...
40
VDD
Power
Positive Supply Voltage
For the complete pinout, refer to the official datasheet.
Usage Instructions
How to Use the PIC18F458 in a Circuit
Power Supply: Connect the VDD pin to a 5V power source and the VSS pin to ground.
Reset Circuit: Use a pull-up resistor (typically 10 kΩ) on the MCLR pin to enable proper reset functionality.
Oscillator Configuration: Connect an external crystal oscillator (e.g., 20 MHz) to the OSC1 and OSC2 pins, along with appropriate capacitors.
Programming: Use an ICSP (In-Circuit Serial Programming) tool to program the microcontroller via the MCLR, PGD, and PGC pins.
I/O Configuration: Configure the I/O pins as input or output in the software, depending on the application.
Peripheral Setup: Initialize peripherals such as ADC, UART, or CAN as required by your application.
Important Considerations and Best Practices
Ensure the operating voltage is within the specified range (4.2V to 5.5V).
Use decoupling capacitors (e.g., 0.1 µF) near the VDD and VSS pins to reduce noise.
Avoid leaving unused pins floating; configure them as outputs or connect them to ground via pull-down resistors.
For CAN communication, ensure proper termination resistors (120 Ω) are used on the CAN bus.
Example Code for Interfacing with an Arduino UNO
Although the PIC18F458 is a standalone microcontroller, it can communicate with an Arduino UNO via UART. Below is an example of how to send data from the PIC18F458 to an Arduino UNO:
PIC18F458 Code (MPLAB XC8):
#include <xc.h>

// Configuration bits
#pragma config OSC = HS        // High-speed oscillator
#pragma config WDT = OFF       // Watchdog Timer disabled
#pragma config LVP = OFF       // Low Voltage Programming disabled

#define _XTAL_FREQ 20000000    // Define crystal frequency (20 MHz)

void UART_Init(void) {
    TRISC6 = 0;                // TX pin as output
    TRISC7 = 1;                // RX pin as input
    SPBRG = 31;                // Baud rate 9600 for 20 MHz clock
    TXSTAbits.SYNC = 0;        // Asynchronous mode
    TXSTAbits.BRGH = 1;        // High-speed baud rate
    RCSTAbits.SPEN = 1;        // Enable serial port
    TXSTAbits.TXEN = 1;        // Enable transmission
}

void UART_Send(char data) {
    while (!TXSTAbits.TRMT);   // Wait until transmit buffer is empty
    TXREG = data;              // Transmit data
}

void main(void) {
    UART_Init();               // Initialize UART
    while (1) {
        UART_Send('A');        // Send character 'A'
        __delay_ms(1000);      // Delay 1 second
    }
}
Arduino UNO Code:
void setup() {
  Serial.begin(9600);          // Initialize serial communication at 9600 baud
}

void loop() {
  if (Serial.available() > 0) { // Check if data is available
    char received = Serial.read(); // Read the received character
    Serial.print("Received: ");    // Print the received data
    Serial.println(received);
  }
}
Troubleshooting and FAQs
Common Issues and Solutions
Microcontroller Not Responding
Cause: Incorrect power supply or missing decoupling capacitors.
Solution: Verify the power supply voltage and add 0.1 µF capacitors near the VDD and VSS pins.
Programming Failure
Cause: Incorrect ICSP connections or configuration.
Solution: Double-check the connections to the MCLR, PGD, and PGC pins. Ensure the programmer is compatible with the PIC18F458.
UART Communication Not Working
Cause: Mismatched baud rates or incorrect wiring.
Solution: Ensure both devices use the same baud rate and verify the TX and RX connections.
Analog Inputs Not Reading Correctly
Cause: Improper ADC configuration or noisy input signals.
Solution: Verify the ADC setup in the code and use proper filtering for the input signals.
FAQs
Q: Can the PIC18F458 operate at 3.3V?
A: No, the PIC18F458 requires a minimum operating voltage of 4.2V.
Q: How do I enable the CAN module?
A: The CAN module can be enabled by configuring the appropriate registers (e.g., CANCON, CIOCON) in the software. Refer to the datasheet for detailed instructions.
Q: What is the maximum clock speed of the PIC18F458?
A: The maximum clock speed is 40 MHz when using an external oscillator.
Q: Can I use the PIC18F458 for low-power applications?
A: Yes, the PIC18F458 supports power-saving modes such as Sleep mode, making it suitable for low-power applications.

 Open Project in Cirkit Designer