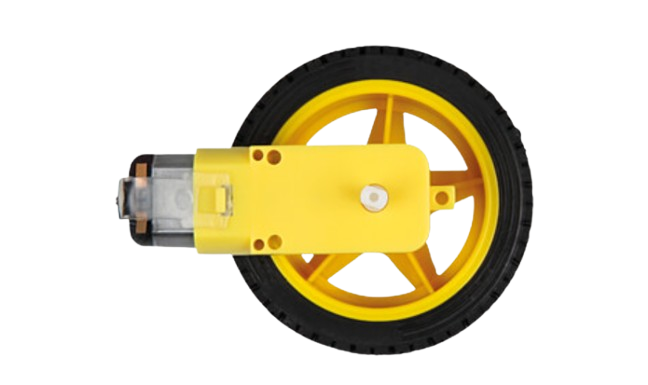
A gear motor is an electric motor integrated with a gear system to reduce speed and increase torque. This combination makes it ideal for applications requiring high torque at low speeds. Gear motors are widely used in robotics, conveyor systems, industrial machinery, and automotive applications. They are particularly valued for their ability to deliver precise motion control and high power efficiency.
Manufacturer: Rajesh Shah
Part ID: motor
Explore Projects Built with gear motor
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
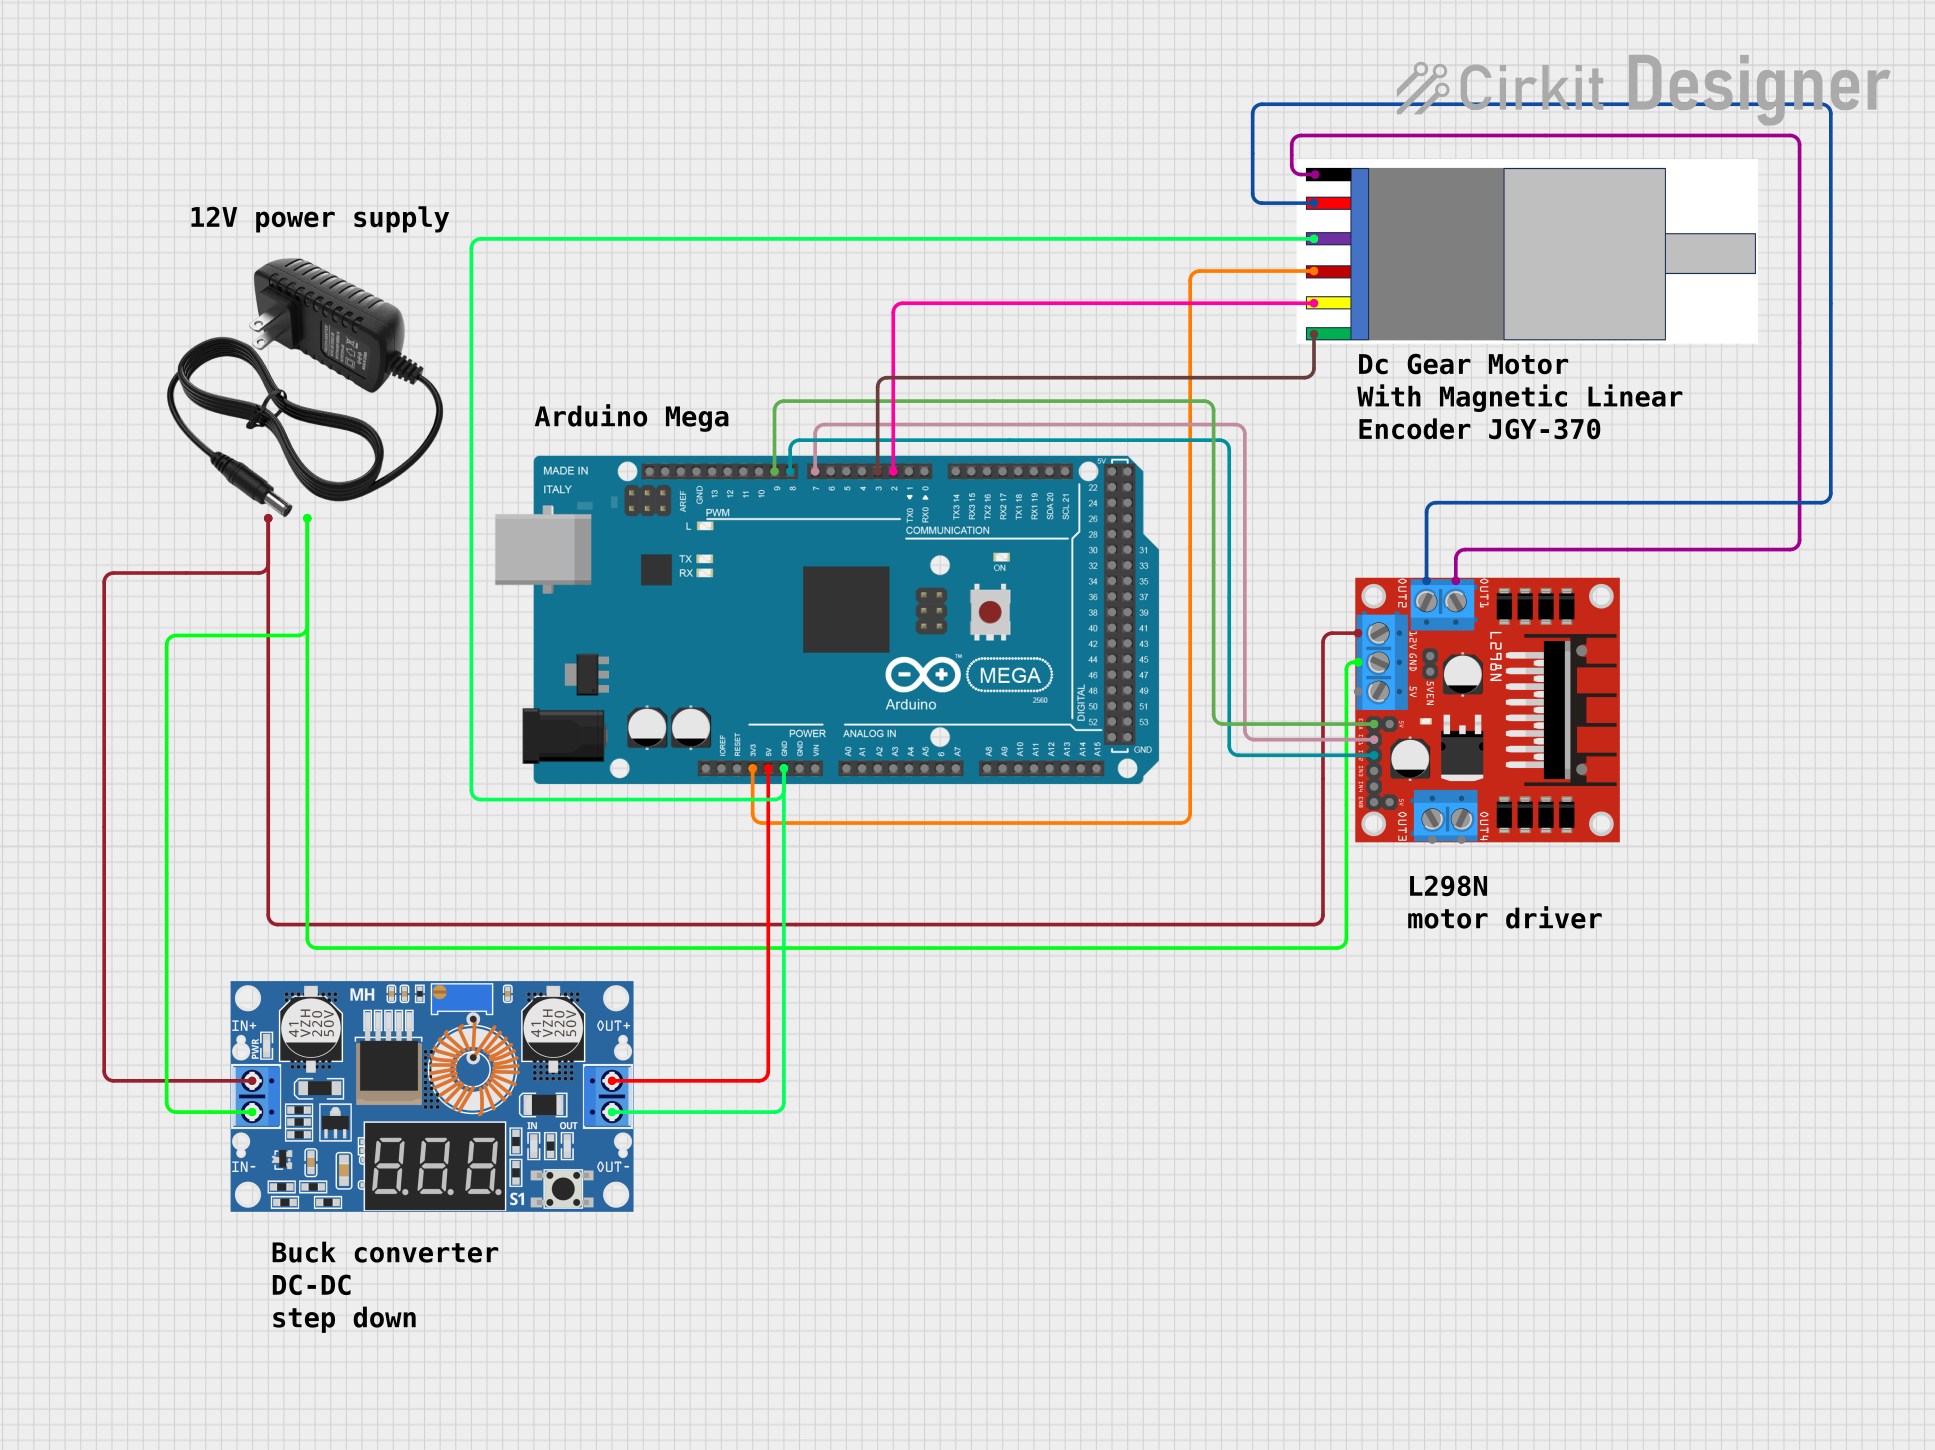
This circuit controls a gear motor with an integrated encoder using an L298N DC motor driver, which is interfaced with an Arduino Mega 2560 microcontroller. The motor's power is supplied by a 12V power source, which is also connected to an XL4015 DC Buck Step-down converter to provide a regulated 5V supply to the Arduino. The encoder outputs are connected to the Arduino for position or speed feedback, and the Arduino is programmed to manage the motor's speed and direction.
This circuit is a simple control circuit for a gear motor, powered by a 9V battery. The rocker switch is used to turn the motor on and off by completing or breaking the circuit between the battery and the motor. There is no microcontroller or complex logic involved, making it a straightforward power control circuit.
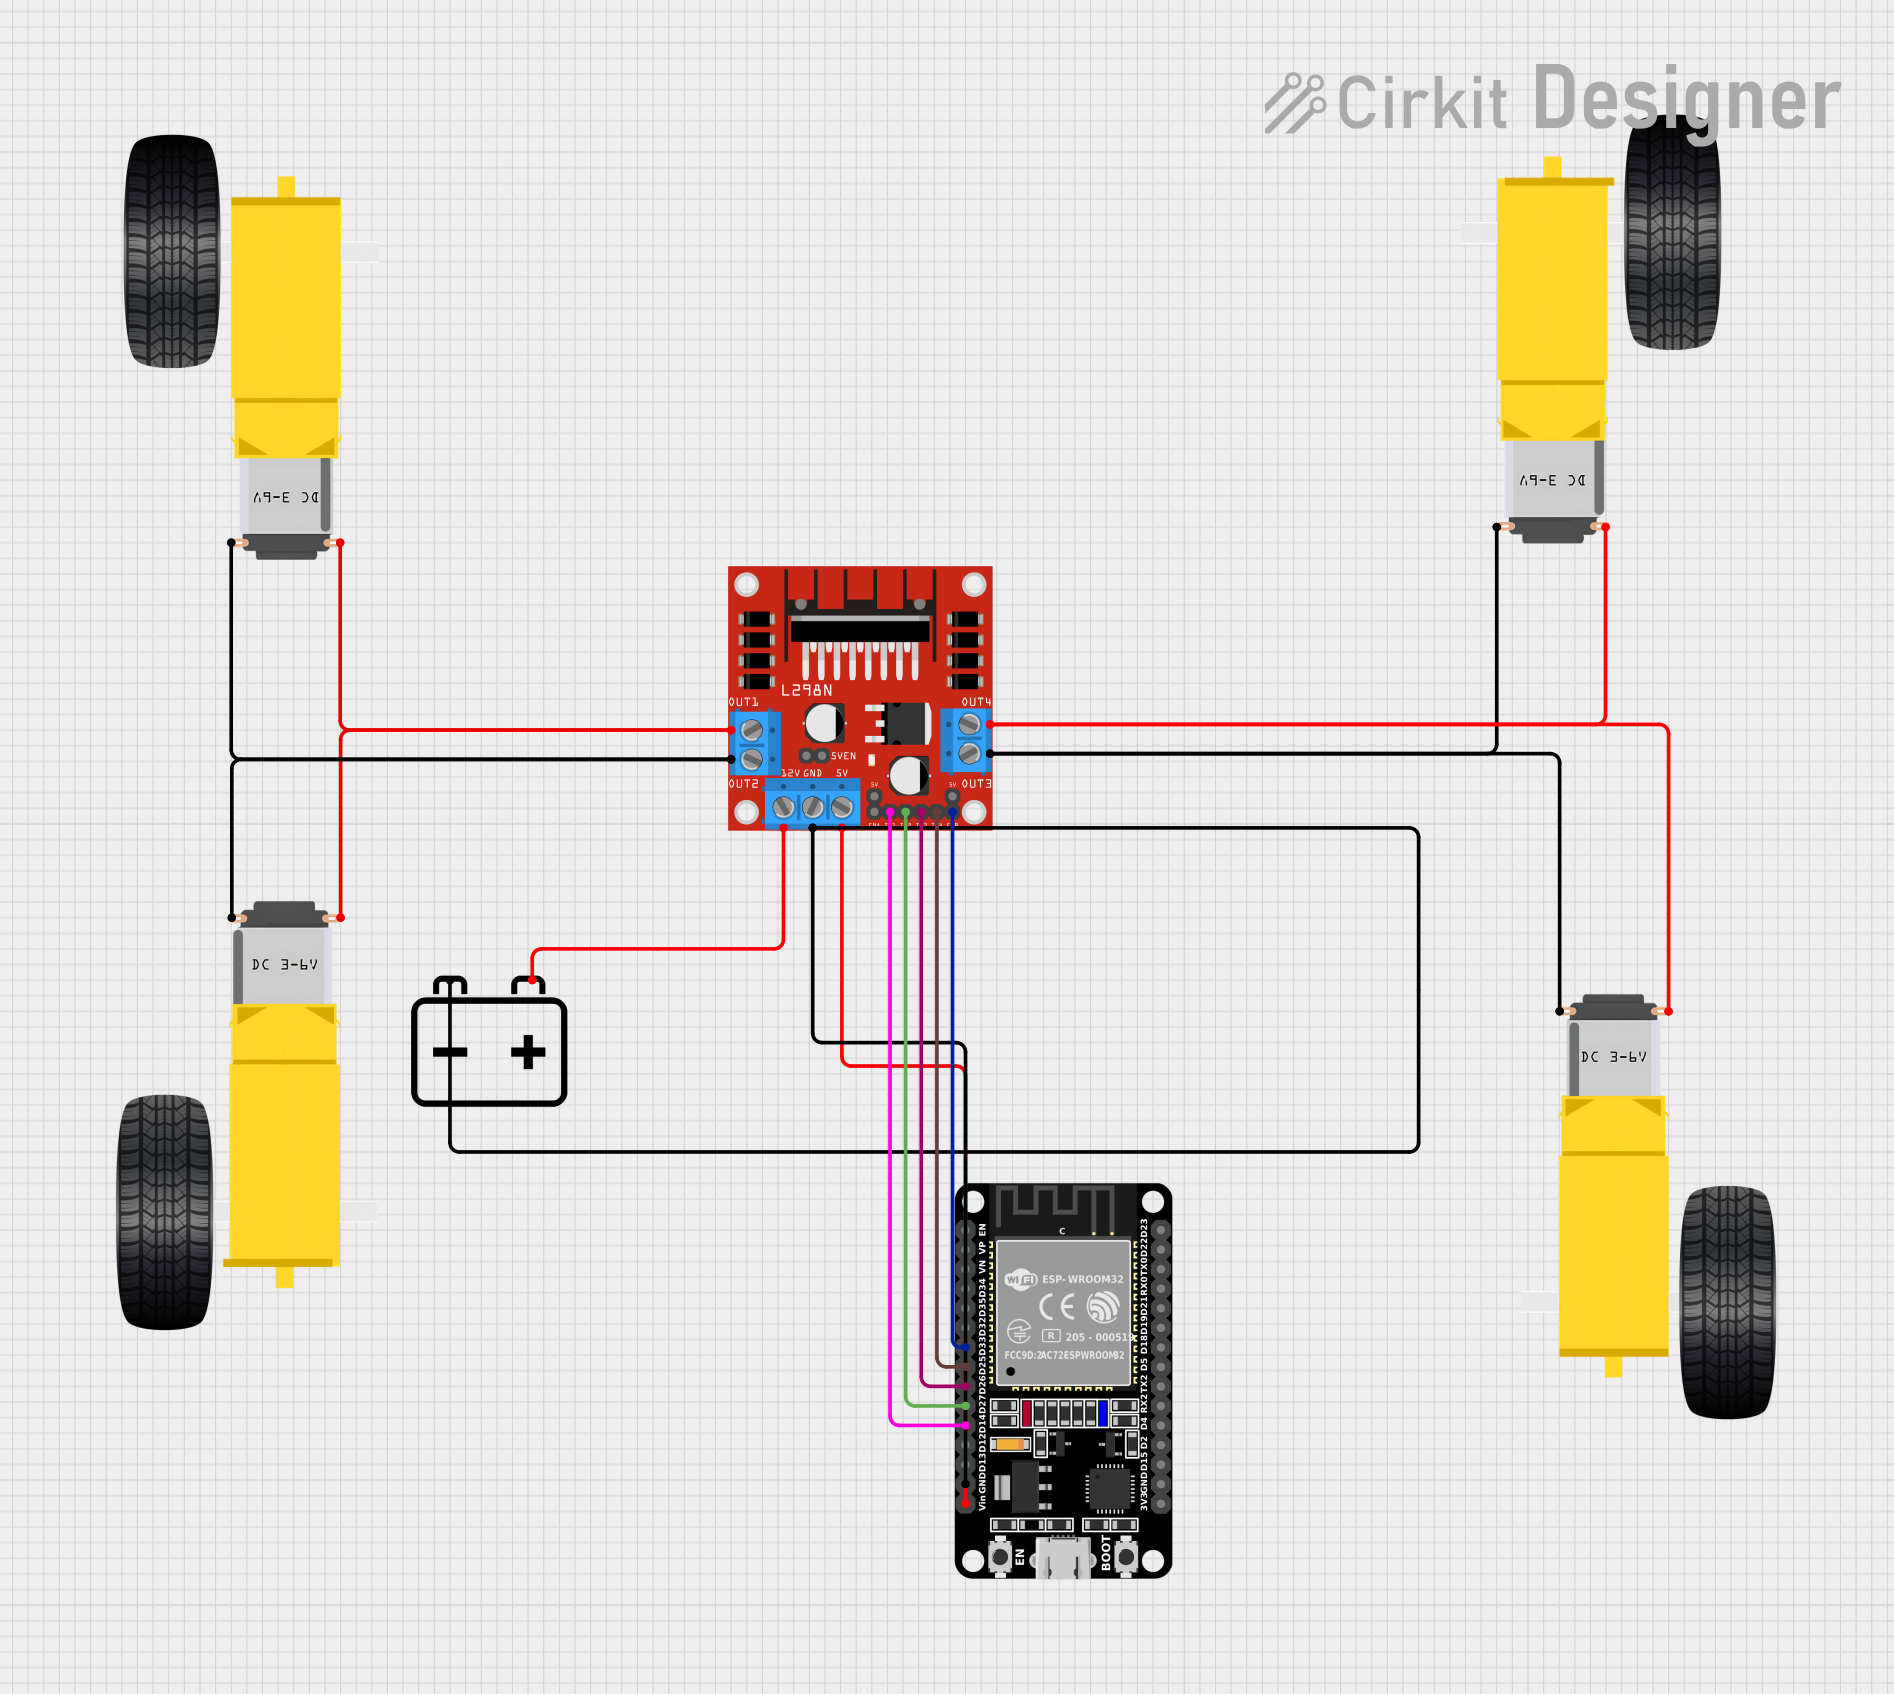
This circuit is a motor control system powered by a 12V battery, utilizing an L298N motor driver to control four DC gearmotors. An ESP32 microcontroller is used to send control signals to the motor driver, enabling precise control of the motors for applications such as a robotic vehicle.
This circuit is designed to remotely control two DC gearmotors using an Arduino UNO and an L298N motor driver, with an HC-05 Bluetooth module for wireless communication. It includes a JSN-SR04T ultrasonic sensor for distance measurement and a TM1637 display for output. Power management is handled by an 18650 Li-Ion battery and rocker switches.
Below are the key technical details for the gear motor:
Parameter
Value
Operating Voltage
6V - 12V
Rated Torque
5 kg·cm - 20 kg·cm
No-Load Speed
30 RPM - 300 RPM
Gear Ratio
10:1 to 100:1 (varies by model)
Current Consumption
100 mA (no load) to 2 A (max load)
Shaft Diameter
6 mm
Motor Type
Brushed DC Motor
Operating Temperature
-10°C to 50°C
Weight
150 g
Pin Configuration and Descriptions
The gear motor typically has two terminals for electrical connections. The table below describes the pin configuration:
Pin
Description
Pin 1
Positive terminal (+) for power input
Pin 2
Negative terminal (-) for power input
Usage Instructions
How to Use the Gear Motor in a Circuit
Power Supply: Connect the gear motor to a DC power supply within the specified voltage range (6V - 12V). Ensure the power supply can provide sufficient current for the motor's load requirements.
Polarity: The direction of rotation depends on the polarity of the power supply. Reversing the polarity will reverse the motor's rotation.
Motor Driver: For precise control, use a motor driver (e.g., L298N or L293D) to interface the gear motor with a microcontroller like an Arduino UNO.
Load Considerations: Avoid overloading the motor beyond its rated torque to prevent damage to the motor or gear system.
Important Considerations and Best Practices
Avoid Stalling: Prolonged stalling can cause overheating and damage the motor.
Use Proper Mounting: Secure the motor firmly to prevent vibrations or misalignment.
Add a Flyback Diode: When using a motor driver, include a flyback diode to protect the circuit from voltage spikes caused by the motor's inductive load.
Lubrication: Periodically check and lubricate the gear system to ensure smooth operation and longevity.
Example: Connecting the Gear Motor to an Arduino UNO
Below is an example of how to control the gear motor using an Arduino UNO and an L298N motor driver:
// Example: Controlling a gear motor with Arduino UNO and L298N motor driver

// Define motor control pins
const int motorPin1 = 9; // IN1 on L298N
const int motorPin2 = 10; // IN2 on L298N
const int enablePin = 11; // ENA on L298N

void setup() {
  // Set motor control pins as outputs
  pinMode(motorPin1, OUTPUT);
  pinMode(motorPin2, OUTPUT);
  pinMode(enablePin, OUTPUT);

  // Initialize motor in stopped state
  digitalWrite(motorPin1, LOW);
  digitalWrite(motorPin2, LOW);
  analogWrite(enablePin, 0); // Set speed to 0
}

void loop() {
  // Rotate motor forward at 50% speed
  digitalWrite(motorPin1, HIGH);
  digitalWrite(motorPin2, LOW);
  analogWrite(enablePin, 128); // Speed range: 0 (stopped) to 255 (full speed)
  delay(3000); // Run for 3 seconds

  // Stop the motor
  digitalWrite(motorPin1, LOW);
  digitalWrite(motorPin2, LOW);
  analogWrite(enablePin, 0);
  delay(1000); // Pause for 1 second

  // Rotate motor backward at 75% speed
  digitalWrite(motorPin1, LOW);
  digitalWrite(motorPin2, HIGH);
  analogWrite(enablePin, 192); // Speed range: 0 (stopped) to 255 (full speed)
  delay(3000); // Run for 3 seconds

  // Stop the motor
  digitalWrite(motorPin1, LOW);
  digitalWrite(motorPin2, LOW);
  analogWrite(enablePin, 0);
  delay(1000); // Pause for 1 second
}
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Rotate:
Cause: Insufficient power supply or incorrect wiring.
Solution: Verify the power supply voltage and current. Check the wiring connections.
Motor Overheats:
Cause: Overloading or prolonged stalling.
Solution: Reduce the load on the motor. Ensure the motor is not stalled for extended periods.
Motor Rotates in the Wrong Direction:
Cause: Incorrect polarity of the power supply.
Solution: Reverse the polarity of the power supply or adjust the motor driver control signals.
Noisy Operation:
Cause: Worn-out gears or lack of lubrication.
Solution: Inspect the gear system and apply appropriate lubrication.
FAQs
Q: Can I use the gear motor with a 5V power supply? A: No, the motor requires a minimum of 6V for proper operation. Using a 5V supply may result in insufficient torque or failure to start.
Q: How do I calculate the required torque for my application? A: Determine the load's weight and the distance from the motor's shaft. Use the formula:
Torque (kg·cm) = Load (kg) × Distance (cm).
Q: Can I control the speed of the gear motor? A: Yes, you can control the speed using PWM (Pulse Width Modulation) signals from a motor driver or microcontroller.
Q: Is the gear motor waterproof? A: No, this gear motor is not waterproof. Avoid exposing it to water or moisture.
By following this documentation, you can effectively use and maintain the gear motor for various applications.

 Open Project in Cirkit Designer