How to Use MAX485: Examples, Pinouts, and Specs
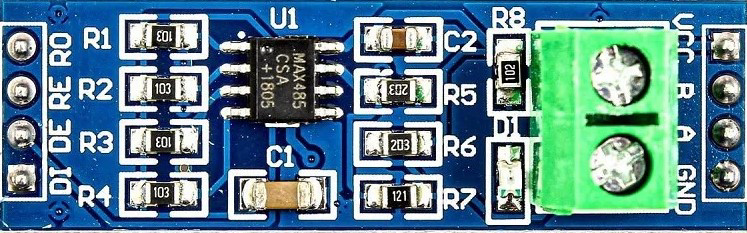
 Design with MAX485 in Cirkit Designer
Introduction
The MAX485 is a low-power, half-duplex RS-485 transceiver designed for robust communication over long distances in noisy environments. Manufactured by Arduino, this component is ideal for industrial and commercial applications requiring reliable data transmission. It supports data rates of up to 2.5 Mbps and operates on a single 5V power supply, making it both efficient and versatile.
Explore Projects Built with MAX485
 Open Project in Cirkit Designer
 Open Project in Cirkit Designer
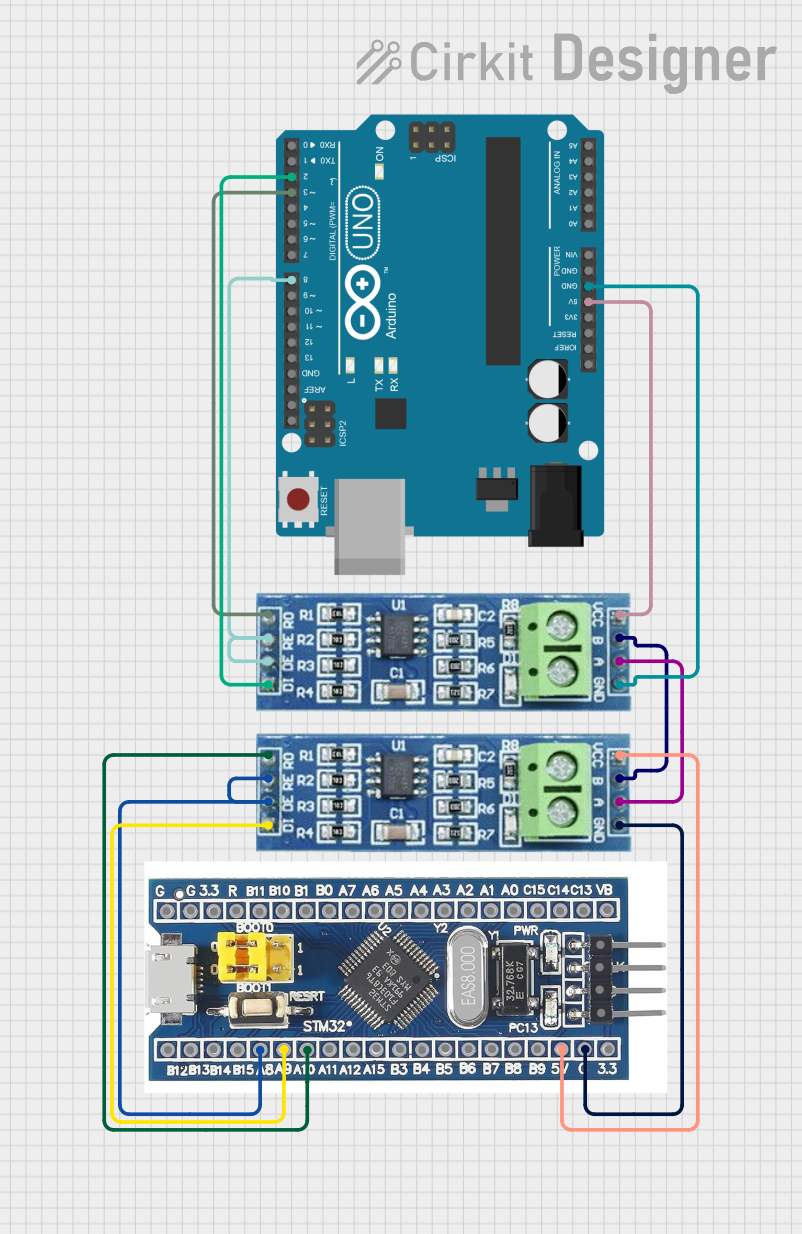 Open Project in Cirkit Designer
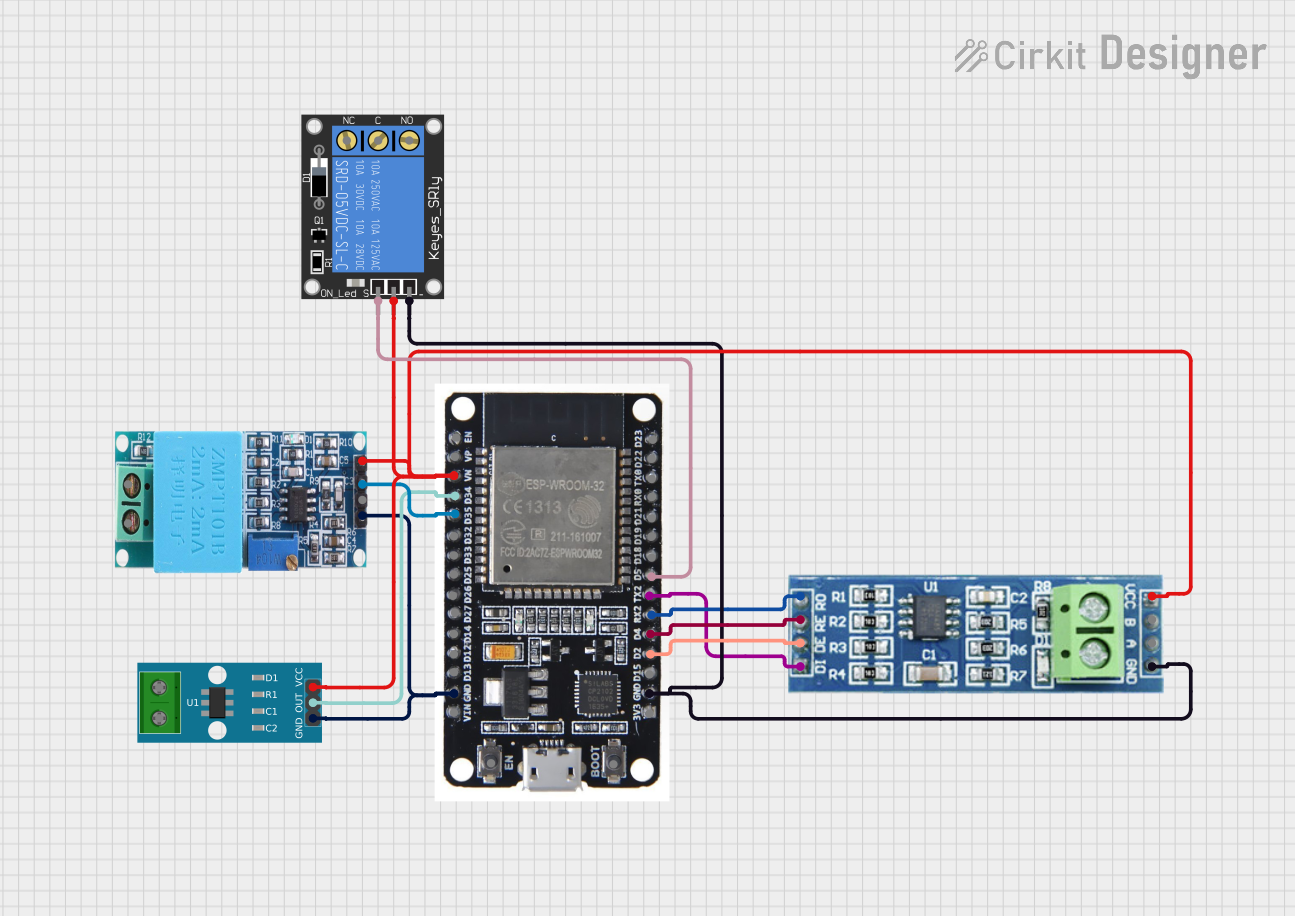 Open Project in Cirkit Designer
Explore Projects Built with MAX485
Open Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerCommon Applications
- Industrial automation and control systems
- Building automation (e.g., HVAC systems)
- Long-distance data communication
- RS-485 network interfaces
- Point-to-point or multipoint communication systems
Technical Specifications
The MAX485 is designed to meet the requirements of RS-485 and RS-422 communication standards. Below are its key technical details:
Key Features
- Operating Voltage: 4.75V to 5.25V
- Data Rate: Up to 2.5 Mbps
- Power Consumption: Low-power operation with a typical supply current of 300 µA
- Communication Mode: Half-duplex
- Input Impedance: 12 kΩ (minimum)
- Driver Output Voltage: ±1.5V (minimum) with a 54Ω load
- Receiver Sensitivity: ±200 mV
- Operating Temperature Range: -40°C to +85°C
- ESD Protection: ±15 kV (Human Body Model)
Pin Configuration and Descriptions
The MAX485 is available in an 8-pin DIP or SOIC package. Below is the pinout and description:
| Pin Number | Pin Name | Description |
|---|---|---|
| 1 | RO | Receiver Output: Outputs the received data from the RS-485 bus. |
| 2 | RE̅ | Receiver Enable: Active-low input. Enables the receiver when low. |
| 3 | DE | Driver Enable: Active-high input. Enables the driver when high. |
| 4 | DI | Driver Input: Accepts the data to be transmitted on the RS-485 bus. |
| 5 | GND | Ground: Connect to the system ground. |
| 6 | A | Non-inverting Driver Output / Receiver Input: Connect to the RS-485 bus line. |
| 7 | B | Inverting Driver Output / Receiver Input: Connect to the RS-485 bus line. |
| 8 | VCC | Power Supply: Connect to a 5V DC power source. |
Usage Instructions
The MAX485 is straightforward to use in RS-485 communication systems. Below are the steps and considerations for integrating it into your circuit.
Circuit Connection
- Power Supply: Connect the VCC pin to a 5V DC power source and the GND pin to the system ground.
- Bus Lines: Connect the A and B pins to the RS-485 bus lines. Use a twisted-pair cable for long-distance communication to minimize noise.
- Driver and Receiver Control:
- To enable the driver, set the DE pin high.
- To enable the receiver, set the RE̅ pin low.
- For half-duplex communication, toggle DE and RE̅ as needed to switch between transmitting and receiving modes.
- Data Input/Output:
- Send data to the DI pin for transmission.
- Read received data from the RO pin.
Example Circuit with Arduino UNO
Below is an example of how to connect the MAX485 to an Arduino UNO for RS-485 communication:
Wiring
- Connect MAX485's DI to Arduino's D3 (digital pin 3).
- Connect MAX485's RO to Arduino's D2 (digital pin 2).
- Connect MAX485's DE and RE̅ to Arduino's D4 (digital pin 4).
- Connect MAX485's VCC to Arduino's 5V pin and GND to Arduino's GND.
- Connect the A and B pins to the RS-485 bus.
Arduino Code Example
// Include SoftwareSerial library for RS-485 communication
#include <SoftwareSerial.h>

// Define MAX485 connections
#define RO_PIN 2  // Receiver Output
#define DI_PIN 3  // Driver Input
#define RE_DE_PIN 4  // Receiver Enable and Driver Enable

// Initialize SoftwareSerial for RS-485 communication
SoftwareSerial RS485Serial(RO_PIN, DI_PIN);

void setup() {
  // Set RE_DE_PIN as output
  pinMode(RE_DE_PIN, OUTPUT);

  // Start serial communication
  Serial.begin(9600);  // For debugging
  RS485Serial.begin(9600);  // For RS-485 communication

  // Set MAX485 to receive mode initially
  digitalWrite(RE_DE_PIN, LOW);  // RE̅ = LOW, DE = LOW
}

void loop() {
  // Example: Send data over RS-485
  digitalWrite(RE_DE_PIN, HIGH);  // Enable driver (DE = HIGH)
  RS485Serial.println("Hello, RS-485!");  // Send data
  delay(100);  // Wait for data to be sent
  digitalWrite(RE_DE_PIN, LOW);  // Enable receiver (RE̅ = LOW)

  // Example: Receive data over RS-485
  if (RS485Serial.available()) {
    String receivedData = RS485Serial.readString();
    Serial.println("Received: " + receivedData);  // Print received data
  }

  delay(1000);  // Wait before next iteration
}
Best Practices
- Use a termination resistor (typically 120Ω) at both ends of the RS-485 bus to minimize signal reflections.
- Ensure proper grounding between all devices on the RS-485 network.
- Avoid long stubs (branch connections) on the RS-485 bus to maintain signal integrity.
Troubleshooting and FAQs
Common Issues
No Communication Between Devices
- Cause: Incorrect wiring or mismatched baud rates.
- Solution: Verify all connections and ensure both devices use the same baud rate.
Data Corruption
- Cause: Missing or incorrect termination resistors.
- Solution: Add 120Ω termination resistors at both ends of the RS-485 bus.
High Power Consumption
- Cause: DE pin left high when not transmitting.
- Solution: Set DE low when the driver is not in use to reduce power consumption.
Intermittent Communication Failures
- Cause: Noise or improper grounding.
- Solution: Use twisted-pair cables and ensure all devices share a common ground.
FAQs
Q1: Can the MAX485 be used for full-duplex communication?
A1: No, the MAX485 is a half-duplex transceiver. For full-duplex communication, consider using a full-duplex RS-485 transceiver like the MAX488.
Q2: What is the maximum communication distance for the MAX485?
A2: The maximum distance depends on the data rate and cable quality. At lower data rates (e.g., 100 kbps), it can communicate over distances up to 1200 meters.
Q3: Can I connect multiple devices to the same RS-485 bus?
A3: Yes, the MAX485 supports multipoint communication with up to 32 devices on the same bus.
Q4: Is the MAX485 compatible with 3.3V systems?
A4: No, the MAX485 requires a 5V power supply. Use a level shifter if interfacing with 3.3V systems.
By following this documentation, you can effectively integrate the MAX485 into your RS-485 communication projects.