The PCA9685, manufactured by Adafruit, is a 16-channel, 12-bit PWM (Pulse Width Modulation) controller designed for precise control of servos, LEDs, and other devices requiring PWM signals. It communicates via the I2C protocol, making it easy to integrate with microcontrollers like the Arduino UNO. This component is widely used in robotics, automation, and lighting projects where multiple PWM outputs are needed without consuming significant microcontroller resources.
Explore Projects Built with PCA9685 16*12 Bit
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
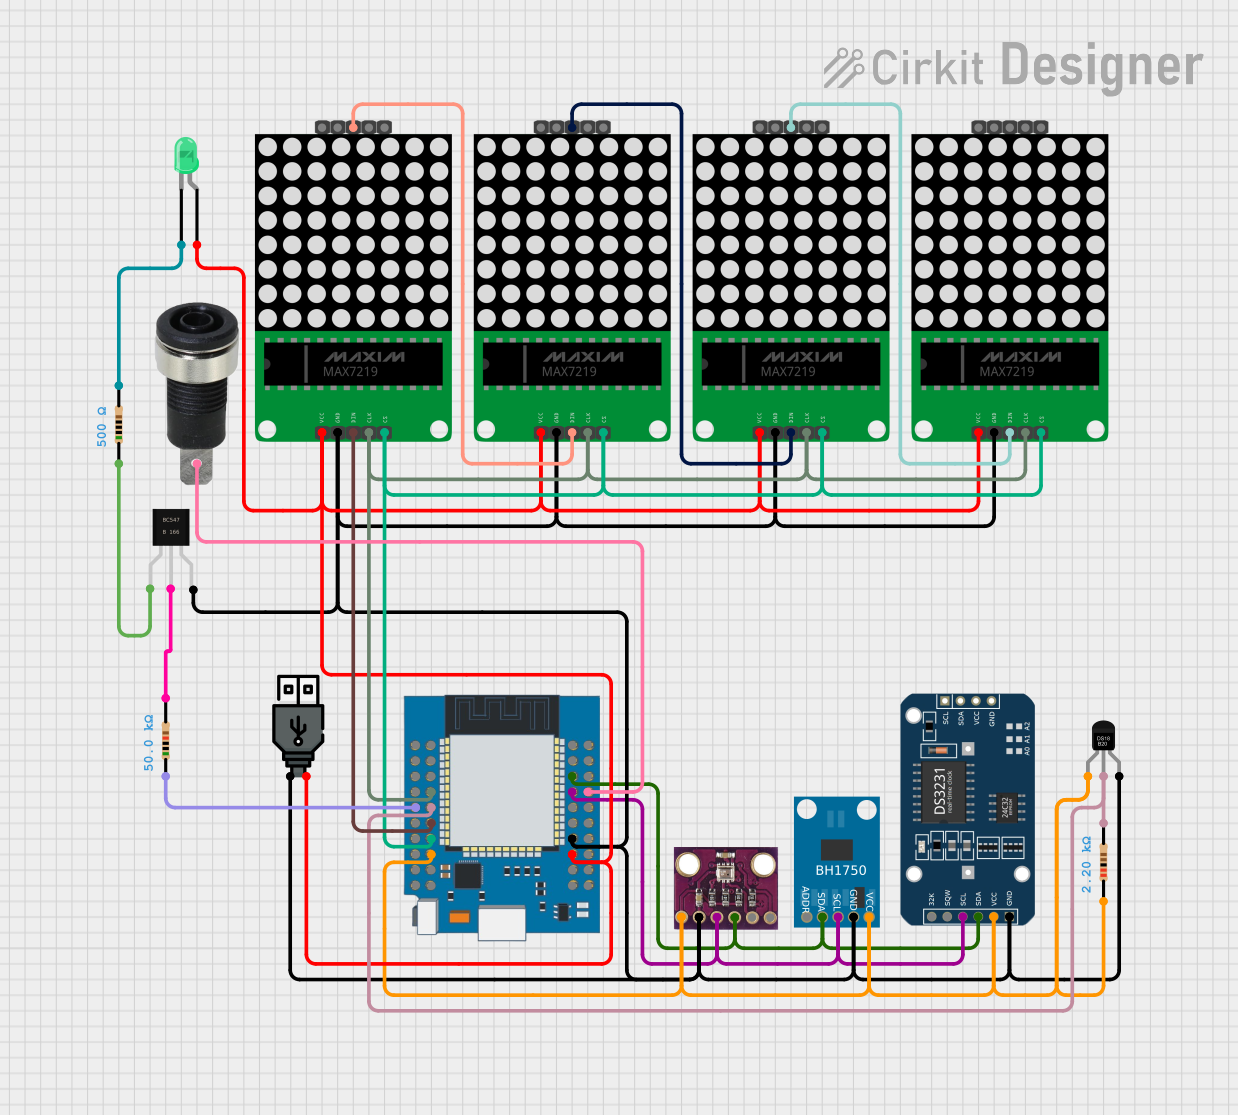
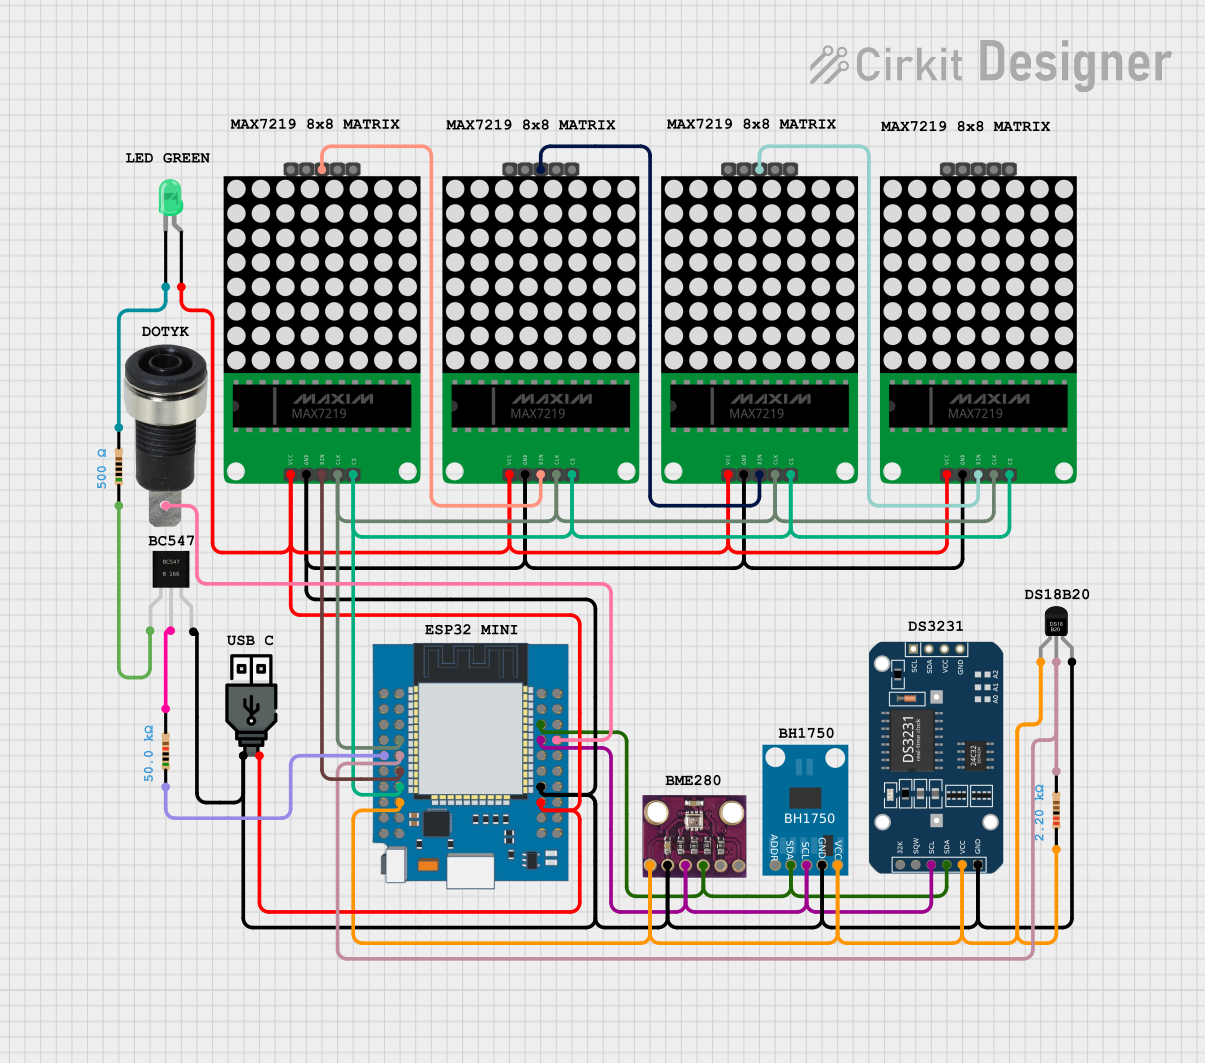
This circuit is a sensor and display system powered by an ESP32 microcontroller. It integrates multiple sensors (BH1750 light sensor, BMP280 pressure sensor, DS3231 RTC, and DS18B20 temperature sensor) and drives a series of MAX7219 8x8 LED matrices for visual output. The ESP32 communicates with the sensors via I2C and controls the LED matrices to display data.
This circuit is a multi-sensor data acquisition system using an ESP32 microcontroller. It integrates various sensors including a BH1750 light sensor, BMP280 pressure sensor, DS3231 RTC, and DS18B20 temperature sensor, and displays data on a series of MAX7219 8x8 LED matrices. The system is powered via USB and includes a green LED indicator.
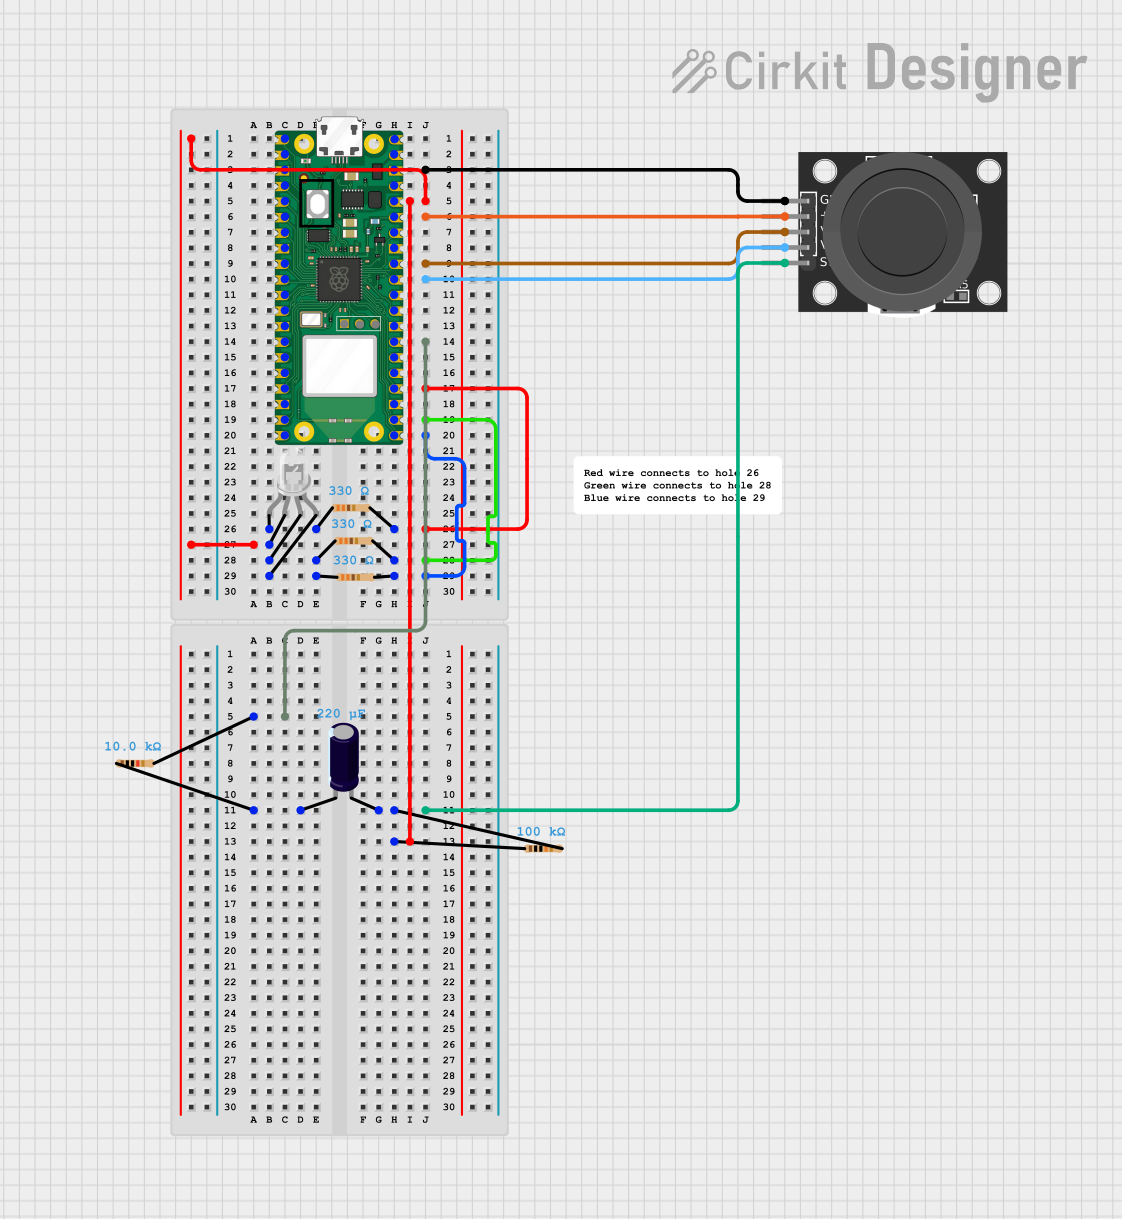
This circuit features a Raspberry Pi Pico W microcontroller interfaced with a KY-023 Dual Axis Joystick Module and a four-pin RGB LED. The joystick's position controls the color of the RGB LED through PWM signals, with resistors limiting current to the LED's cathodes and a capacitor potentially used for debouncing the joystick's switch. The embedded code cycles through color sequences based on the joystick's Y-axis position, creating a dynamic lighting effect.
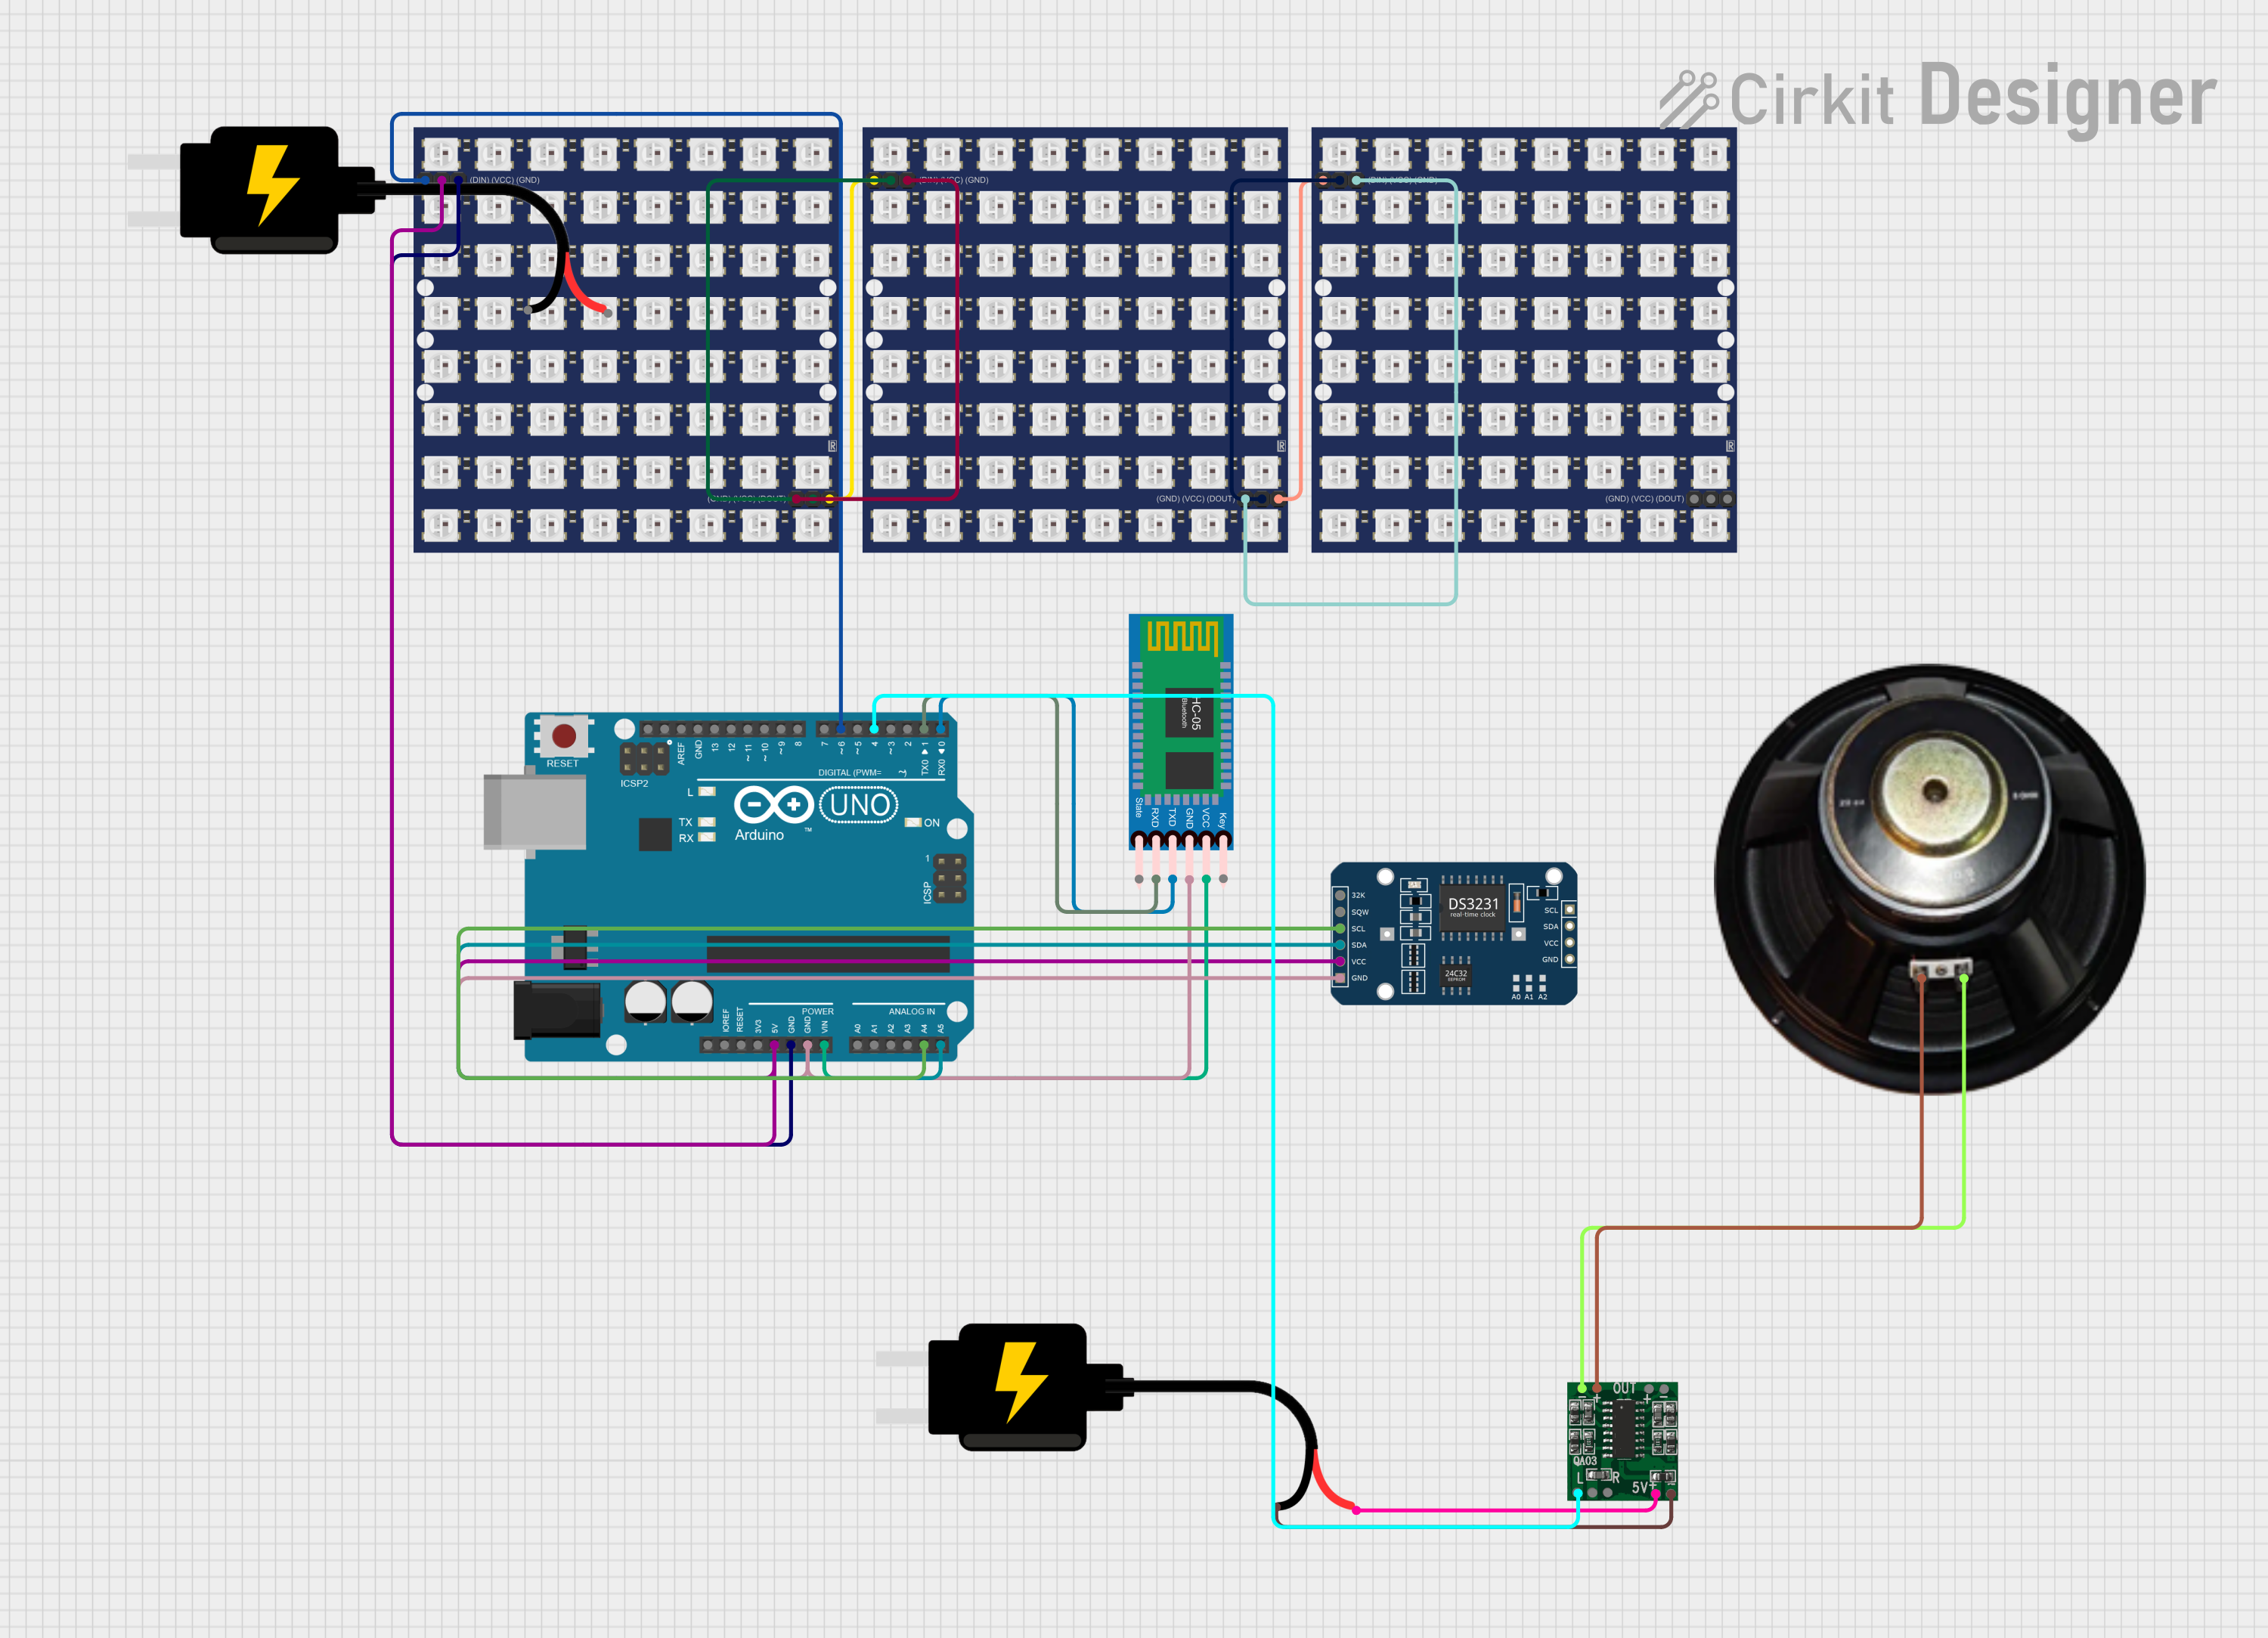
This is an interactive display and communication circuit. It uses an Arduino UNO to drive multiple WS2812 RGB LED matrices for visual output, interfaces with a DS3231 RTC for time-related functions, and communicates wirelessly via an HC-05 Bluetooth module. Additionally, it features audio output capabilities through a speaker connected to a PAM8403 audio amplifier.
Controlling multiple servo motors in robotic arms or drones
LED dimming and lighting effects in decorative or functional lighting systems
Motor speed control in automation projects
Signal generation for devices requiring PWM inputs
Technical Specifications
The PCA9685 is a versatile and powerful PWM controller. Below are its key technical details:
Key Technical Details
Channels: 16 independent PWM outputs
Resolution: 12-bit (4096 steps per channel)
Communication Protocol: I2C (up to 1 MHz)
Operating Voltage: 2.3V to 5.5V
Output Voltage: Up to 6V (external power supply required for higher voltages)
Output Current: 25mA per channel (maximum)
Frequency Range: Adjustable from 24 Hz to 1526 Hz
Addressing: Configurable I2C address (up to 62 devices on the same bus)
Operating Temperature: -40°C to +85°C
Pin Configuration and Descriptions
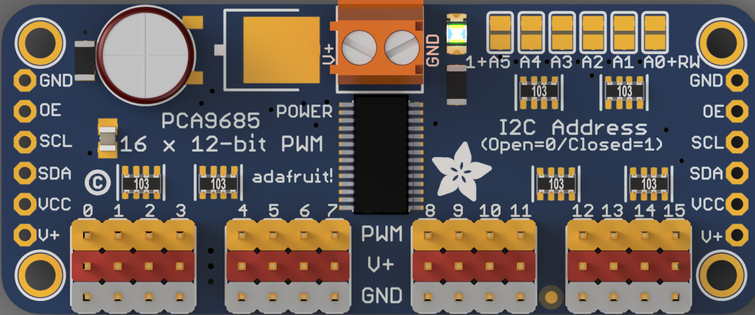
The PCA9685 module typically comes with 18 pins. Below is the pinout description:
Pin Name
Type
Description
VCC
Power Input
2.3V to 5.5V power supply for the PCA9685 logic.
GND
Ground
Ground connection.
SDA
I2C Data Line
Serial data line for I2C communication.
SCL
I2C Clock Line
Serial clock line for I2C communication.
OE
Input (Active Low)
Output enable pin. Pull low to enable PWM outputs, high to disable.
PWM 0-15
PWM Outputs
16 PWM output pins for controlling servos, LEDs, or other devices.
V+
Power Input
External power supply for driving servos or LEDs (up to 6V).
A0-A5
Address Pins
Configurable I2C address pins (used to set the I2C address of the module).
Usage Instructions
The PCA9685 is straightforward to use in a circuit, especially when paired with an Arduino or similar microcontroller. Below are the steps and best practices for using the component:
Connecting the PCA9685
Power the Module: Connect the VCC pin to the 3.3V or 5V output of your microcontroller. Connect the GND pin to the ground of your circuit.
I2C Communication: Connect the SDA and SCL pins to the corresponding I2C pins on your microcontroller. For an Arduino UNO, connect:
SDA to A4
SCL to A5
External Power Supply: If driving servos or high-power LEDs, connect an external power supply (up to 6V) to the V+ pin. Ensure the ground of the external power supply is connected to the module's GND.
Address Configuration: If using multiple PCA9685 modules, configure their I2C addresses using the A0-A5 pins.
Example Code for Arduino UNO
Below is an example of how to use the PCA9685 with an Arduino UNO to control a servo motor:
#include <Wire.h>
#include <Adafruit_PWMServoDriver.h>

// Create an instance of the PCA9685 driver
Adafruit_PWMServoDriver pwm = Adafruit_PWMServoDriver();

// Define the servo parameters
#define SERVOMIN 150 // Minimum pulse length for the servo
#define SERVOMAX 600 // Maximum pulse length for the servo

void setup() {
  Serial.begin(9600);
  Serial.println("Initializing PCA9685...");

  // Initialize the PCA9685 module
  pwm.begin();
  pwm.setPWMFreq(50); // Set PWM frequency to 50 Hz for servos
}

void loop() {
  // Sweep the servo from minimum to maximum position
  for (uint16_t pulselen = SERVOMIN; pulselen < SERVOMAX; pulselen++) {
    pwm.setPWM(0, 0, pulselen); // Set PWM on channel 0
    delay(10); // Small delay for smooth movement
  }

  // Sweep the servo back from maximum to minimum position
  for (uint16_t pulselen = SERVOMAX; pulselen > SERVOMIN; pulselen--) {
    pwm.setPWM(0, 0, pulselen); // Set PWM on channel 0
    delay(10); // Small delay for smooth movement
  }
}
Best Practices
Use decoupling capacitors near the VCC and V+ pins to stabilize the power supply.
Avoid exceeding the maximum current rating of 25mA per channel.
Use a level shifter if your microcontroller operates at 3.3V and the PCA9685 is powered at 5V.
Ensure proper grounding between the PCA9685, microcontroller, and external power supply.
Troubleshooting and FAQs
Common Issues and Solutions
No Response from the PCA9685
Cause: Incorrect I2C wiring or address mismatch.
Solution: Verify SDA and SCL connections. Check the I2C address using a scanner sketch.
Servos or LEDs Not Responding
Cause: Insufficient power supply or incorrect PWM frequency.
Solution: Ensure the external power supply is adequate. Set the correct PWM frequency for your application.
Overheating
Cause: Exceeding the current rating of the module.
Solution: Limit the current draw per channel to 25mA or use external drivers for high-power devices.
Flickering LEDs
Cause: Unstable power supply or incorrect PWM settings.
Solution: Add decoupling capacitors and verify the PWM frequency.
FAQs
Q: Can I use the PCA9685 with a Raspberry Pi?
A: Yes, the PCA9685 is compatible with the Raspberry Pi via the I2C interface.
Q: How many PCA9685 modules can I connect to a single I2C bus?
A: Up to 62 modules can be connected by configuring unique I2C addresses using the A0-A5 pins.
Q: What is the maximum voltage I can use for the V+ pin?
A: The V+ pin supports up to 6V for driving servos or LEDs.
Q: Can I control DC motors with the PCA9685?
A: Yes, but you will need an external motor driver to handle the higher current requirements of DC motors.
By following this documentation, you can effectively integrate the PCA9685 into your projects for precise and reliable PWM control.

 Open Project in Cirkit Designer