Introduction
The 37mm DC Motor is a compact and versatile direct current motor with a diameter of 37mm. It is widely used in robotics, small machinery, and other applications requiring the conversion of electrical energy into mechanical motion. This motor is known for its reliability, ease of use, and ability to deliver consistent torque, making it a popular choice for hobbyists and professionals alike.
Common Applications and Use Cases
- Robotics: Driving wheels, arms, or other moving parts.
- Small machinery: Powering conveyor belts, pumps, or fans.
- DIY projects: Building motorized toys, tools, or gadgets.
- Educational purposes: Demonstrating principles of electromagnetism and motion.
Technical Specifications
The following table outlines the key technical details of the 37mm DC Motor:
Pin Configuration and Descriptions
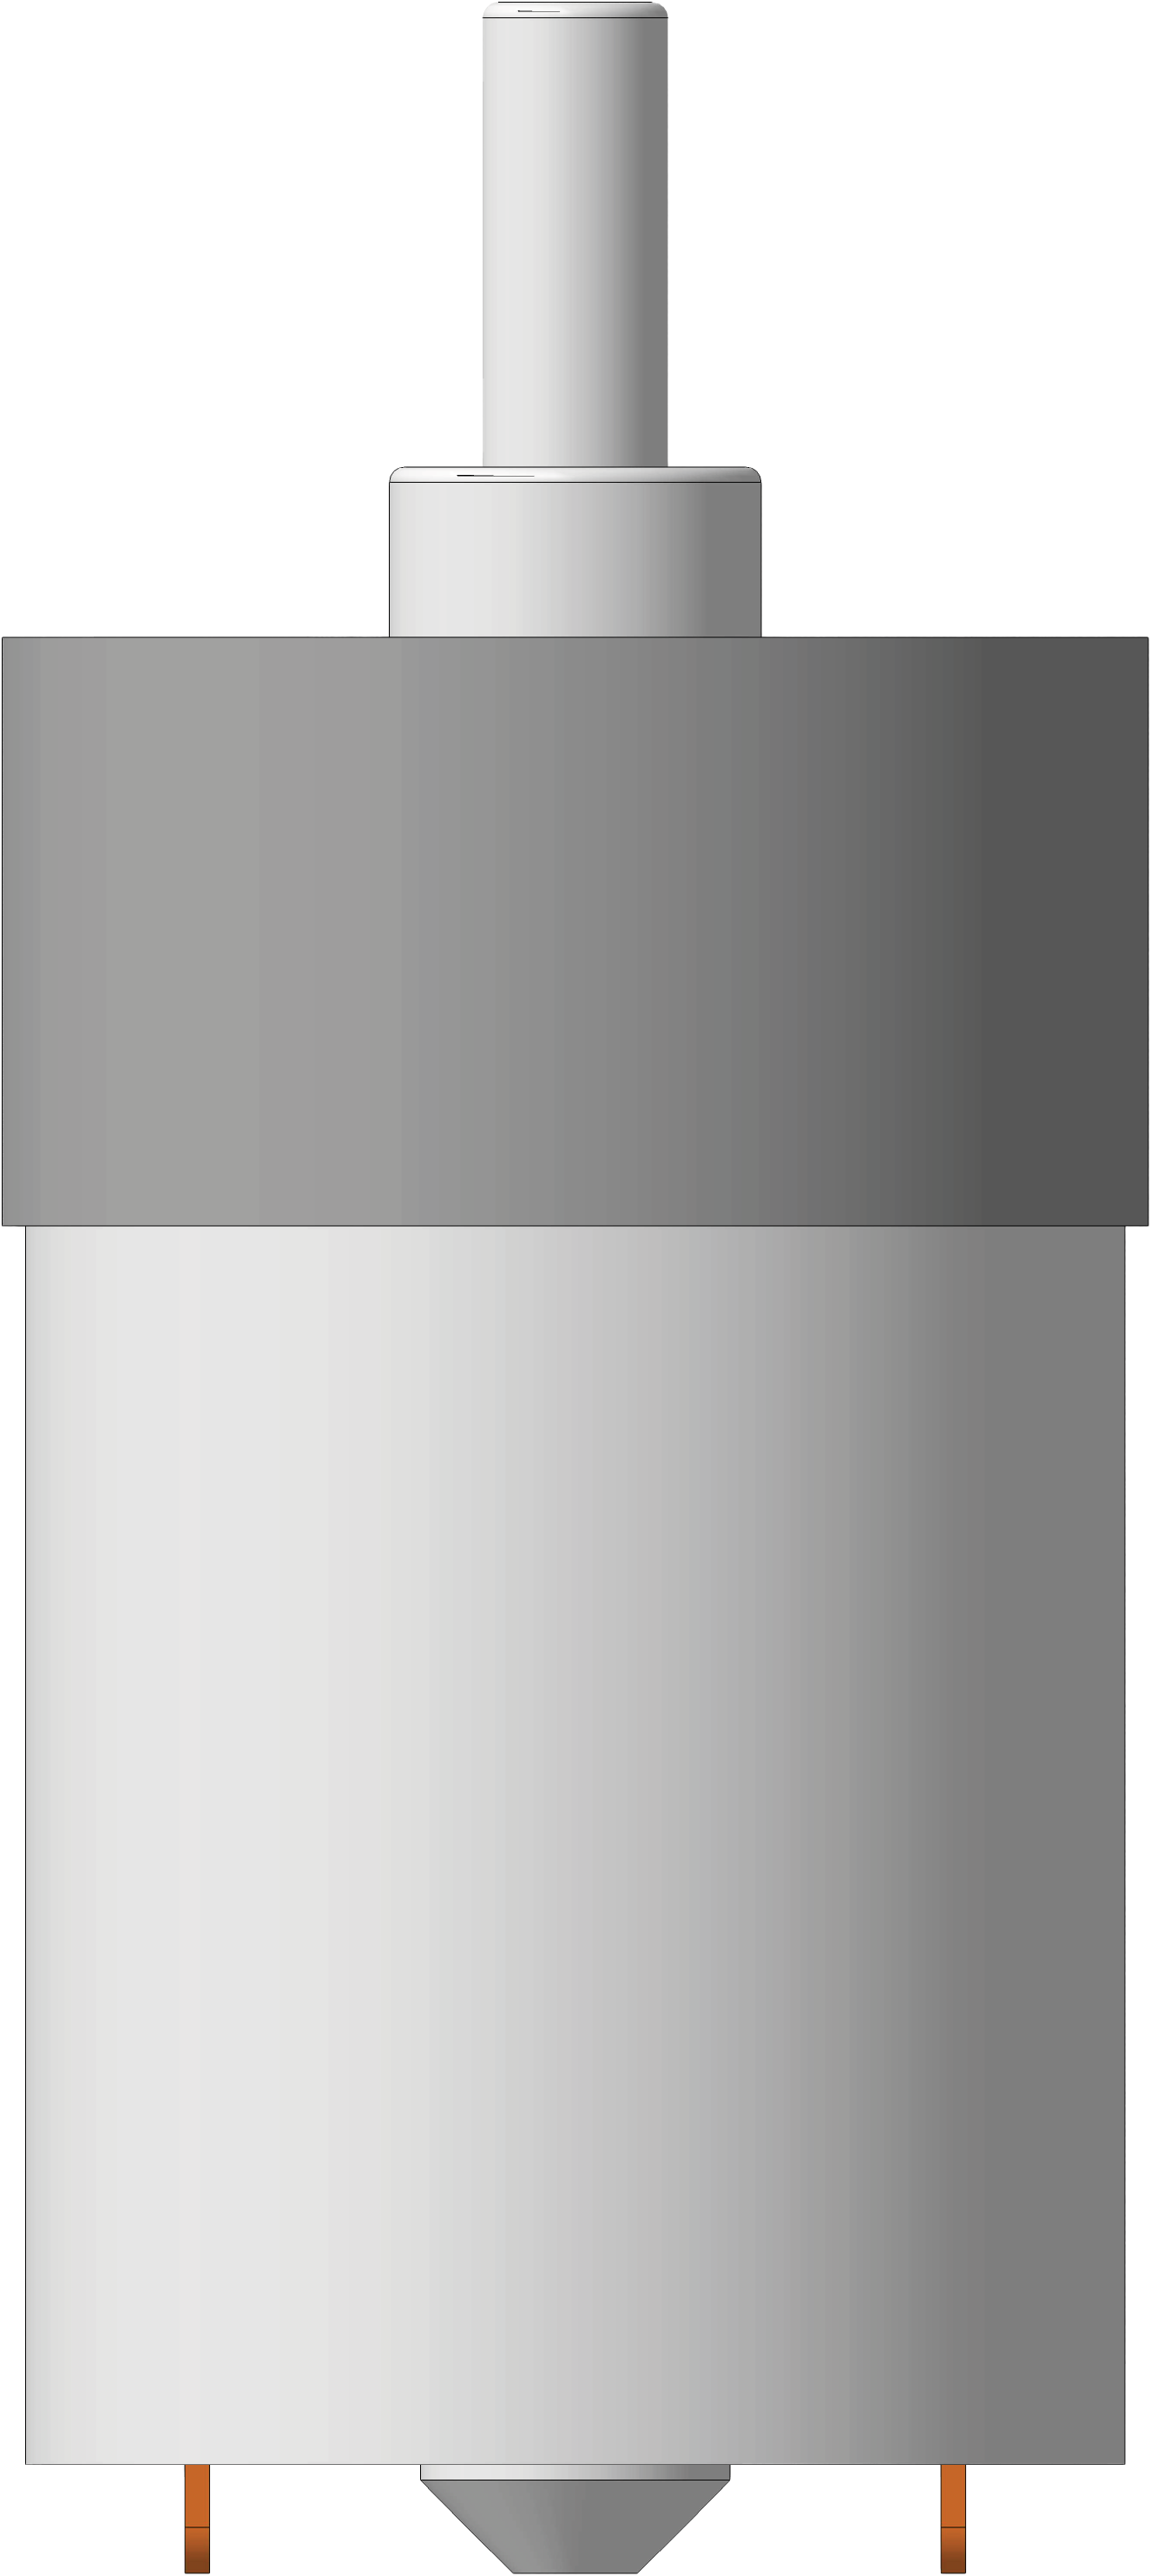
The 37mm DC Motor typically has two terminals for electrical connections:
Note: The motor's direction of rotation can be reversed by swapping the polarity of the connections.
Usage Instructions
How to Use the 37mm DC Motor in a Circuit
- Power Supply: Ensure the motor is powered within its operating voltage range (6V to 12V). Exceeding this range may damage the motor.
- Motor Driver: Use a motor driver (e.g., L298N or L293D) to control the motor's speed and direction. Directly connecting the motor to a microcontroller is not recommended due to high current requirements.
- Polarity: Connect the motor's terminals to the motor driver's output pins. Reversing the polarity will change the motor's rotation direction.
- Speed Control: Use Pulse Width Modulation (PWM) signals from a microcontroller (e.g., Arduino UNO) to control the motor's speed.
Important Considerations and Best Practices
- Current Handling: Ensure the power supply and motor driver can handle the motor's stall current to prevent overheating or damage.
- Heat Dissipation: Prolonged operation at high loads may cause the motor to heat up. Allow adequate cooling time if necessary.
- Noise Suppression: Add capacitors (e.g., 0.1µF) across the motor terminals to reduce electrical noise.
- Mounting: Secure the motor using appropriate brackets or mounts to prevent vibration or misalignment.
Example: Controlling the 37mm DC Motor with Arduino UNO
Below is an example of how to control the motor's speed and direction using an Arduino UNO and an L298N motor driver:
// Define motor driver pins
const int ENA = 9;  // PWM pin for speed control
const int IN1 = 8;  // Direction control pin 1
const int IN2 = 7;  // Direction control pin 2

void setup() {
  // Set motor driver pins as outputs
  pinMode(ENA, OUTPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
}

void loop() {
  // Rotate motor clockwise at 50% speed
  analogWrite(ENA, 128); // Set speed (0-255, 128 = 50%)
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);
  delay(2000); // Run for 2 seconds

  // Stop the motor
  analogWrite(ENA, 0);
  delay(1000); // Pause for 1 second

  // Rotate motor counterclockwise at 75% speed
  analogWrite(ENA, 192); // Set speed (0-255, 192 = 75%)
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, HIGH);
  delay(2000); // Run for 2 seconds

  // Stop the motor
  analogWrite(ENA, 0);
  delay(1000); // Pause for 1 second
}
Note: Adjust the ENA value to control the motor's speed. Higher values result in faster rotation.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Does Not Spin:
- Cause: Insufficient power supply or incorrect wiring.
- Solution: Verify the power supply voltage and current. Check all connections.
Motor Spins in the Wrong Direction:
- Cause: Polarity of the motor terminals is reversed.
- Solution: Swap the connections to the motor terminals.
Motor Overheats:
- Cause: Prolonged operation at high loads or insufficient cooling.
- Solution: Reduce the load or allow the motor to cool periodically.
Excessive Noise or Interference:
- Cause: Electrical noise from the motor.
- Solution: Add capacitors (e.g., 0.1µF) across the motor terminals.
Motor Driver Overheats:
- Cause: Motor driver is not rated for the motor's stall current.
- Solution: Use a motor driver with a higher current rating.
FAQs
Q: Can I connect the motor directly to an Arduino?
A: No, the motor's current requirements exceed the Arduino's output capacity. Use a motor driver.
Q: How do I increase the motor's torque?
A: Use a gearbox or reduce the motor's speed to increase torque.
Q: Can I power the motor with a battery?
A: Yes, ensure the battery provides sufficient voltage and current for the motor.
Q: What is the lifespan of the motor?
A: The lifespan depends on usage conditions, but regular maintenance (e.g., cleaning and lubrication) can extend it.
This concludes the documentation for the 37mm DC Motor.

 Open Project in Cirkit Designer