How to Use MPU6050: Examples, Pinouts, and Specs
 Design with MPU6050 in Cirkit Designer
Introduction
The MPU6050 is a 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer on a single chip. This compact and versatile sensor is widely used in applications requiring motion sensing and orientation detection. Its ability to measure angular velocity and linear acceleration makes it an essential component in robotics, drones, mobile devices, and gaming controllers. Additionally, the MPU6050 features an onboard Digital Motion Processor (DMP) that can process complex motion algorithms, reducing the computational load on the host microcontroller.
Explore Projects Built with MPU6050
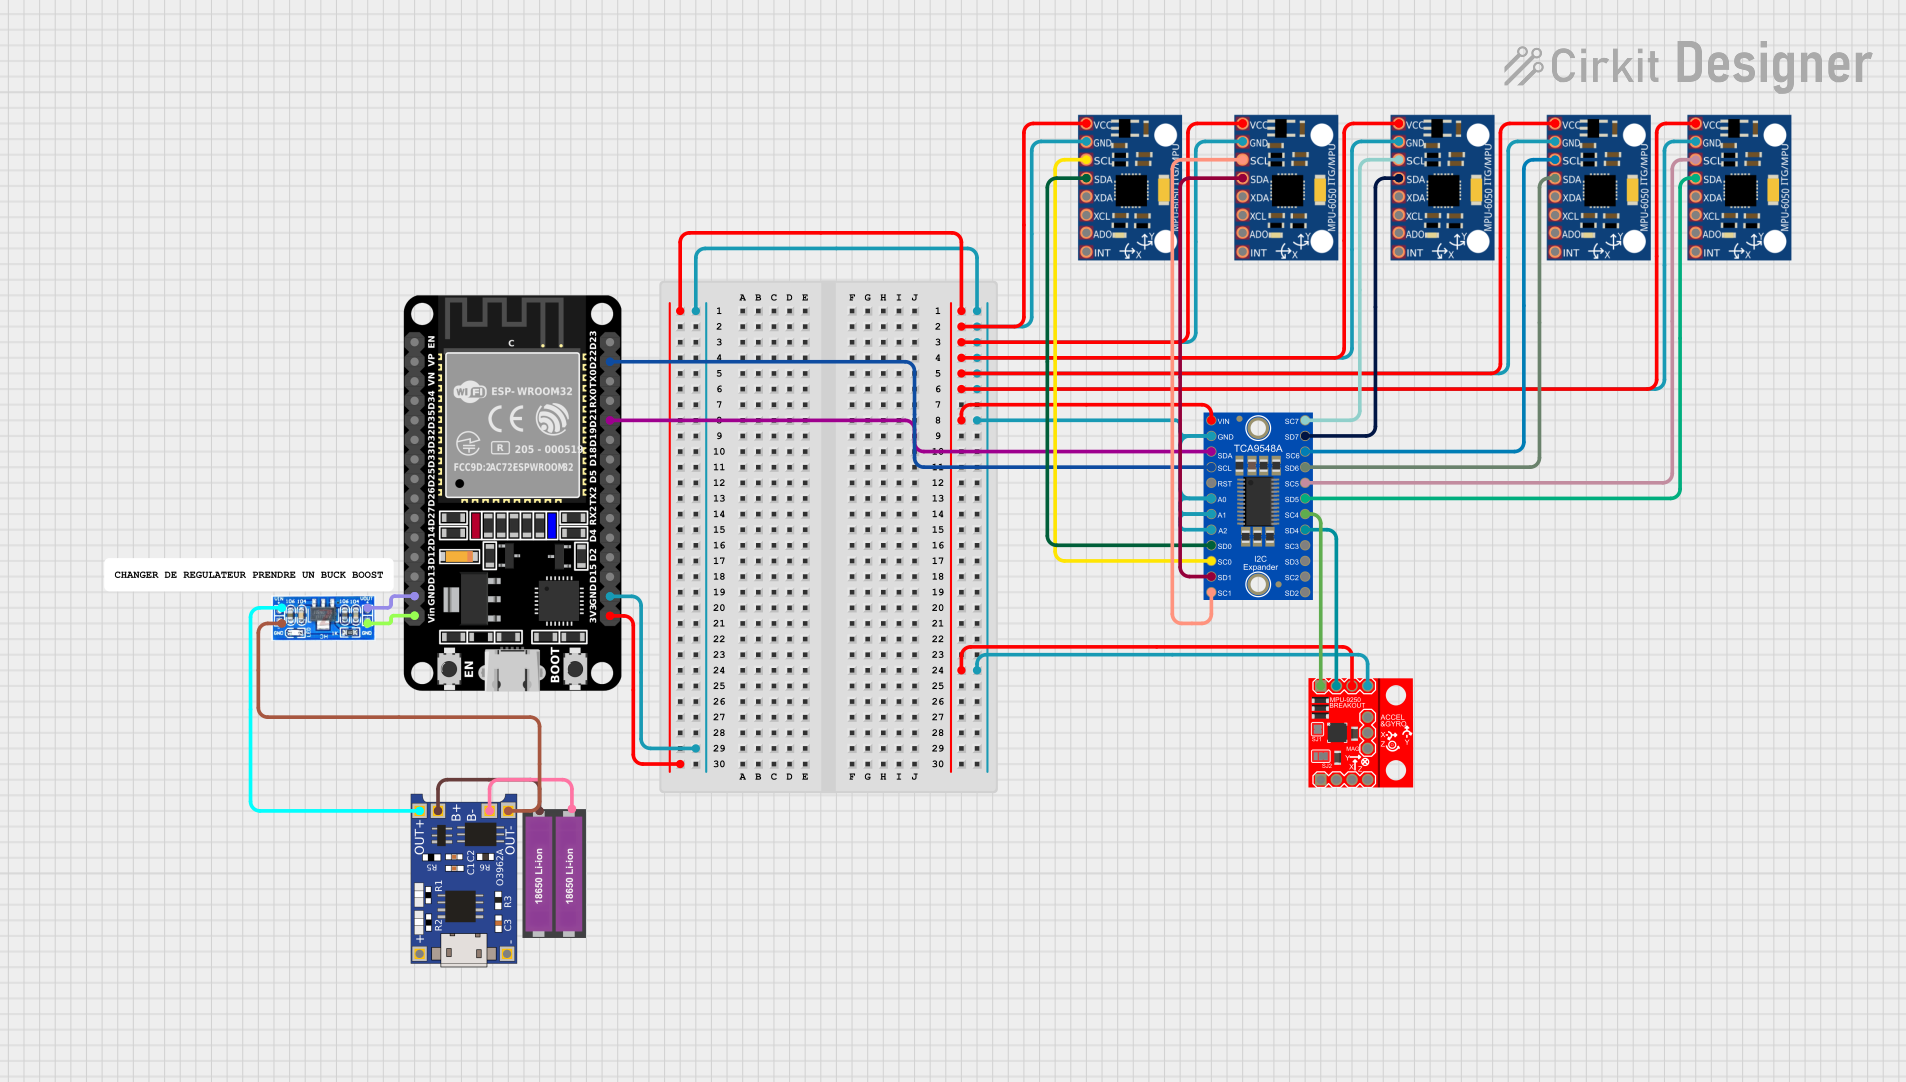 Open Project in Cirkit Designer
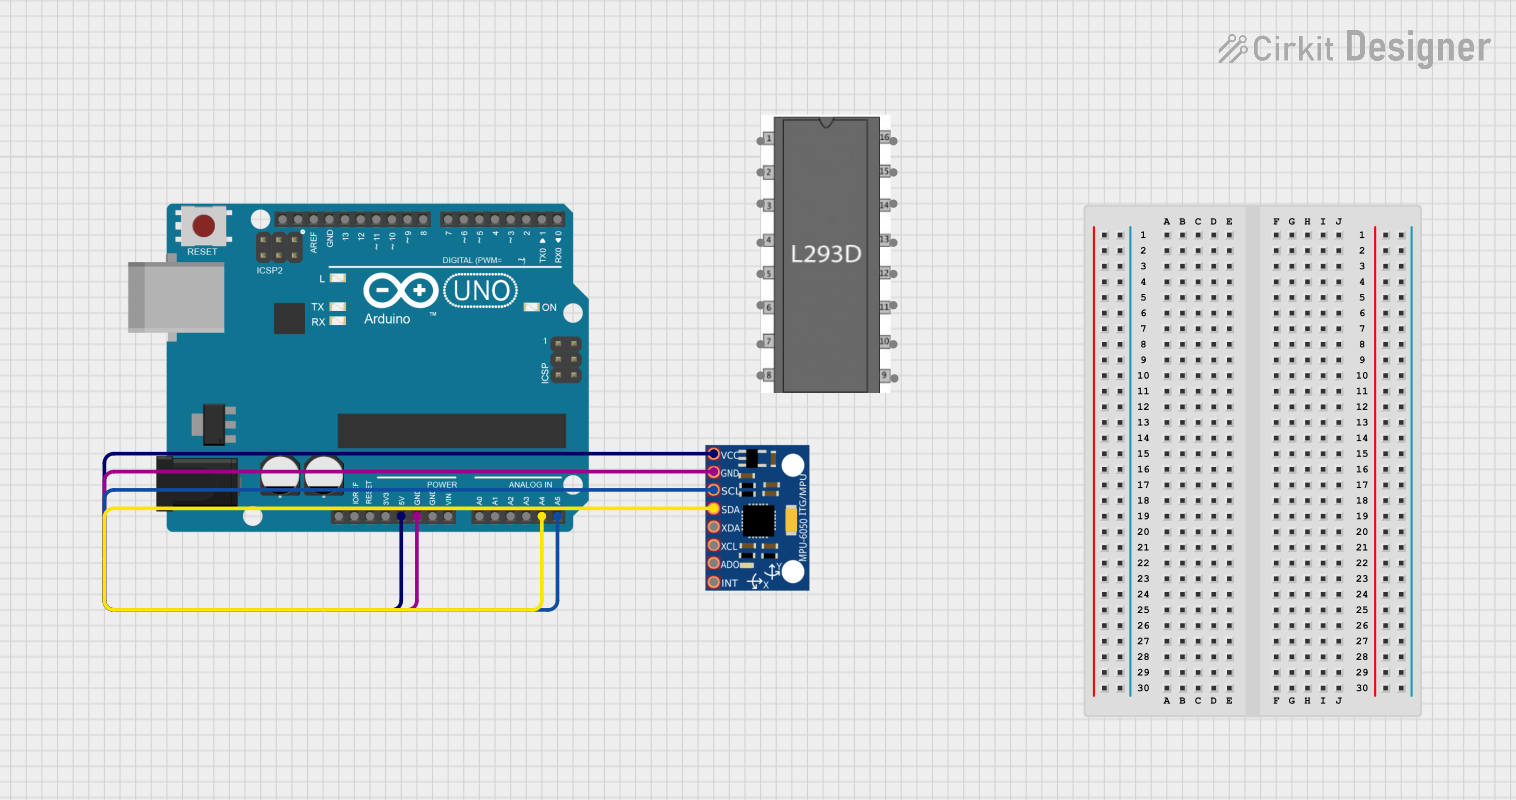 Open Project in Cirkit Designer
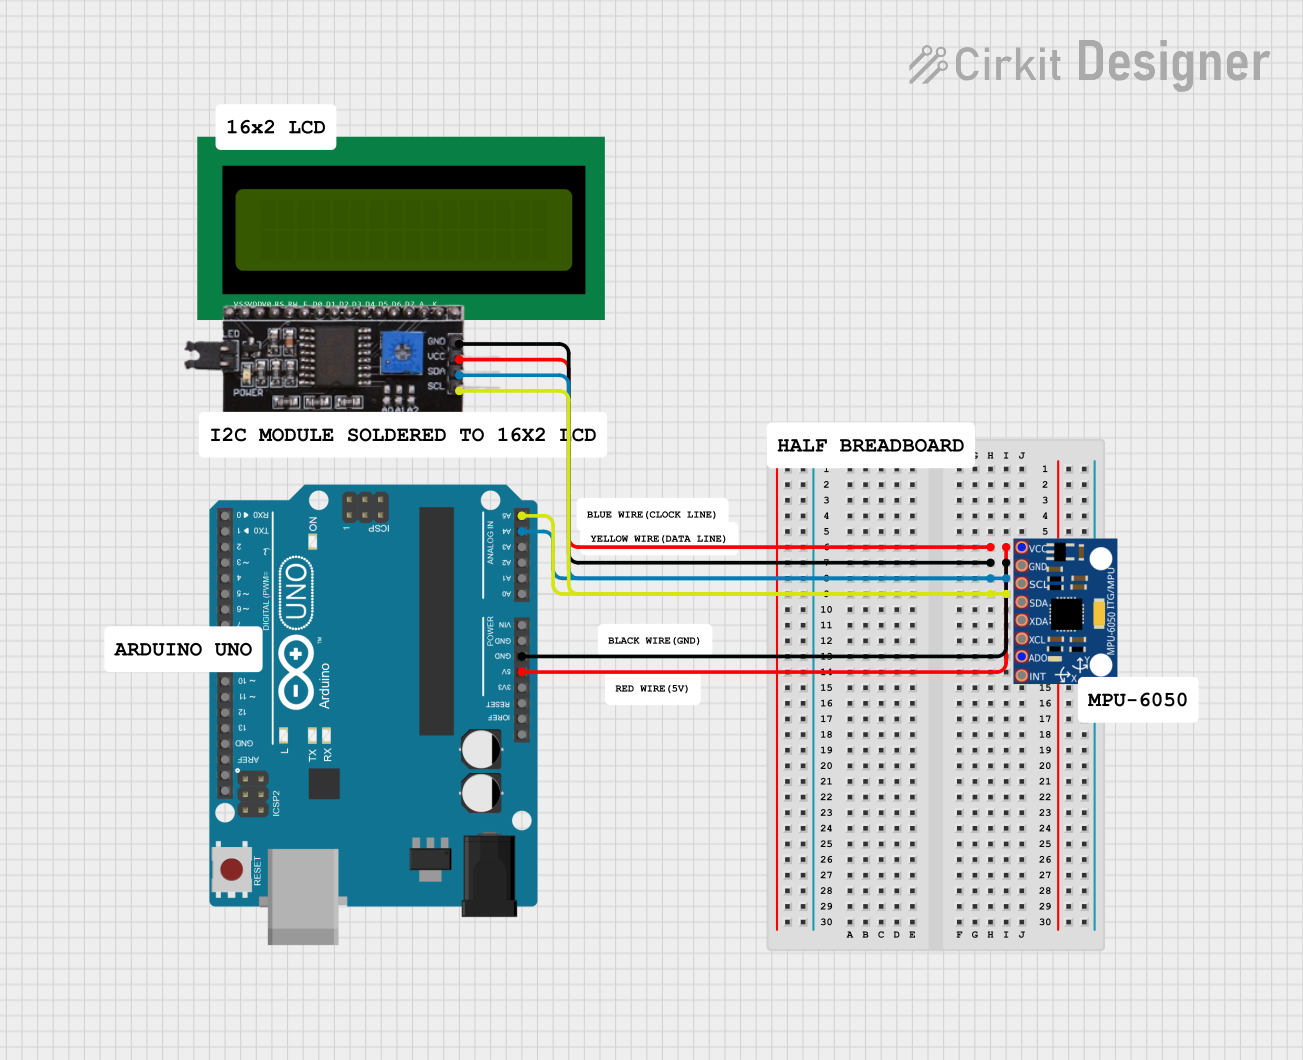 Open Project in Cirkit Designer
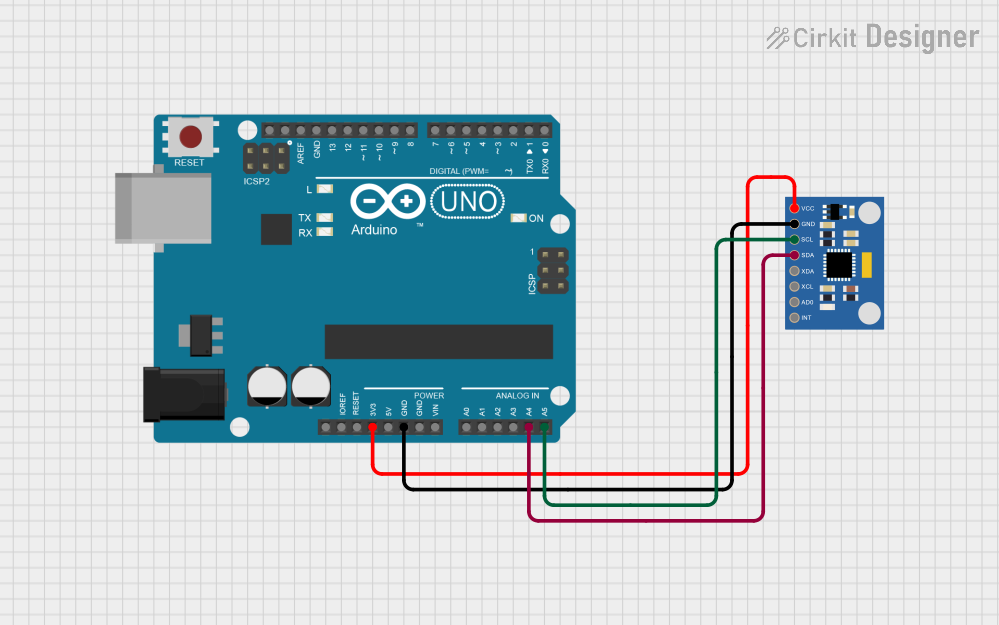 Open Project in Cirkit Designer
Explore Projects Built with MPU6050
Open Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerTechnical Specifications
Below are the key technical details of the MPU6050:
- Supply Voltage: 2.375V to 3.46V (typically 3.3V)
- Communication Interface: I2C (up to 400kHz)
- Gyroscope Range: ±250, ±500, ±1000, ±2000 degrees/second
- Accelerometer Range: ±2g, ±4g, ±8g, ±16g
- Operating Temperature: -40°C to +85°C
- Power Consumption: 3.9mA (typical in active mode)
- Package: 4x4x0.9mm QFN
Pin Configuration and Descriptions
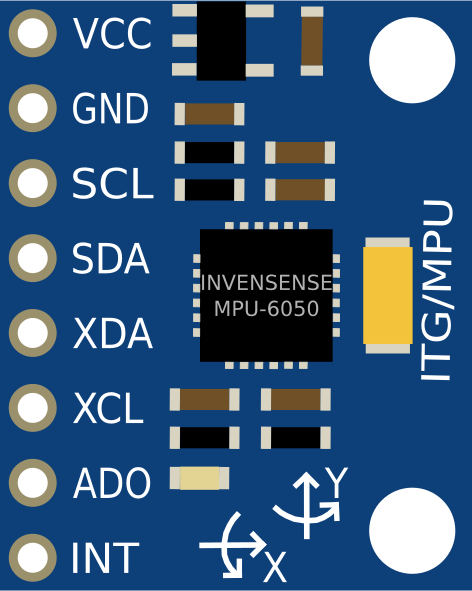
The MPU6050 has 8 pins, as described in the table below:
| Pin Number | Pin Name | Description |
|---|---|---|
| 1 | VCC | Power supply input (2.375V to 3.46V, typically 3.3V). |
| 2 | GND | Ground connection. |
| 3 | SCL | I2C clock line. Connect to the SCL pin of the microcontroller. |
| 4 | SDA | I2C data line. Connect to the SDA pin of the microcontroller. |
| 5 | XDA | Auxiliary I2C data line (used for connecting additional sensors). |
| 6 | XCL | Auxiliary I2C clock line (used for connecting additional sensors). |
| 7 | AD0 | I2C address selection pin. Connect to GND for address 0x68 or VCC for 0x69. |
| 8 | INT | Interrupt output pin. Used to signal data availability or motion detection. |
Usage Instructions
How to Use the MPU6050 in a Circuit
- Power Supply: Connect the VCC pin to a 3.3V power source and the GND pin to ground.
- I2C Communication: Connect the SCL and SDA pins to the corresponding I2C pins on your microcontroller. Use pull-up resistors (typically 4.7kΩ) on the SCL and SDA lines if not already present.
- Address Selection: Set the AD0 pin to GND for the default I2C address (0x68) or to VCC for the alternate address (0x69).
- Interrupt Pin: Optionally, connect the INT pin to a digital input on your microcontroller to handle interrupts.
Important Considerations and Best Practices
- Use decoupling capacitors (e.g., 0.1µF) near the VCC pin to stabilize the power supply.
- Ensure proper pull-up resistors are used on the I2C lines for reliable communication.
- Avoid excessive vibrations or shocks to the sensor, as they may affect accuracy.
- Calibrate the sensor for your specific application to improve measurement accuracy.
Example Code for Arduino UNO
Below is an example of how to interface the MPU6050 with an Arduino UNO using the I2C protocol:
#include <Wire.h>
#include <MPU6050.h>

// Create an MPU6050 object
MPU6050 mpu;

// Variables to store sensor data
int16_t ax, ay, az; // Accelerometer data
int16_t gx, gy, gz; // Gyroscope data

void setup() {
  Serial.begin(9600); // Initialize serial communication
  Wire.begin();       // Initialize I2C communication

  // Initialize the MPU6050
  if (!mpu.begin(MPU6050_SCALE_2000DPS, MPU6050_RANGE_2G)) {
    Serial.println("Could not find a valid MPU6050 sensor, check connections!");
    while (1); // Halt the program if initialization fails
  }

  Serial.println("MPU6050 initialized successfully!");
}

void loop() {
  // Read accelerometer and gyroscope data
  mpu.getMotion6(&ax, &ay, &az, &gx, &gy, &gz);

  // Print accelerometer data
  Serial.print("Accel X: "); Serial.print(ax);
  Serial.print(" | Accel Y: "); Serial.print(ay);
  Serial.print(" | Accel Z: "); Serial.println(az);

  // Print gyroscope data
  Serial.print("Gyro X: "); Serial.print(gx);
  Serial.print(" | Gyro Y: "); Serial.print(gy);
  Serial.print(" | Gyro Z: "); Serial.println(gz);

  delay(500); // Delay for readability
}
Troubleshooting and FAQs
Common Issues and Solutions
Problem: The MPU6050 is not detected on the I2C bus.
- Solution: Check the wiring, especially the SCL and SDA connections. Ensure pull-up resistors are present on the I2C lines. Verify the I2C address (default is 0x68).
Problem: Inconsistent or noisy sensor readings.
- Solution: Ensure the sensor is mounted securely to avoid vibrations. Use software filtering or averaging to smooth the data.
Problem: The sensor overheats or does not power on.
- Solution: Verify the supply voltage is within the specified range (2.375V to 3.46V). Check for shorts or incorrect connections.
FAQs
Q: Can the MPU6050 be used with 5V logic microcontrollers?
- A: Yes, but you need a logic level shifter to safely interface the 3.3V I2C lines with 5V logic.
Q: How do I calibrate the MPU6050?
- A: Calibration involves collecting raw data while the sensor is stationary and calculating offsets for the accelerometer and gyroscope. Many libraries include built-in calibration functions.
Q: Can I connect multiple MPU6050 sensors to the same I2C bus?
- A: Yes, but each sensor must have a unique I2C address. Use the AD0 pin to set different addresses (0x68 or 0x69).