The ultrasonic sensor is an electronic component that uses high-frequency sound waves to measure distances or detect objects. It operates by emitting ultrasonic waves and measuring the time it takes for the echo to return after bouncing off an object. This time-of-flight measurement is then used to calculate the distance to the object.
Explore Projects Built with ULTASONIC
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
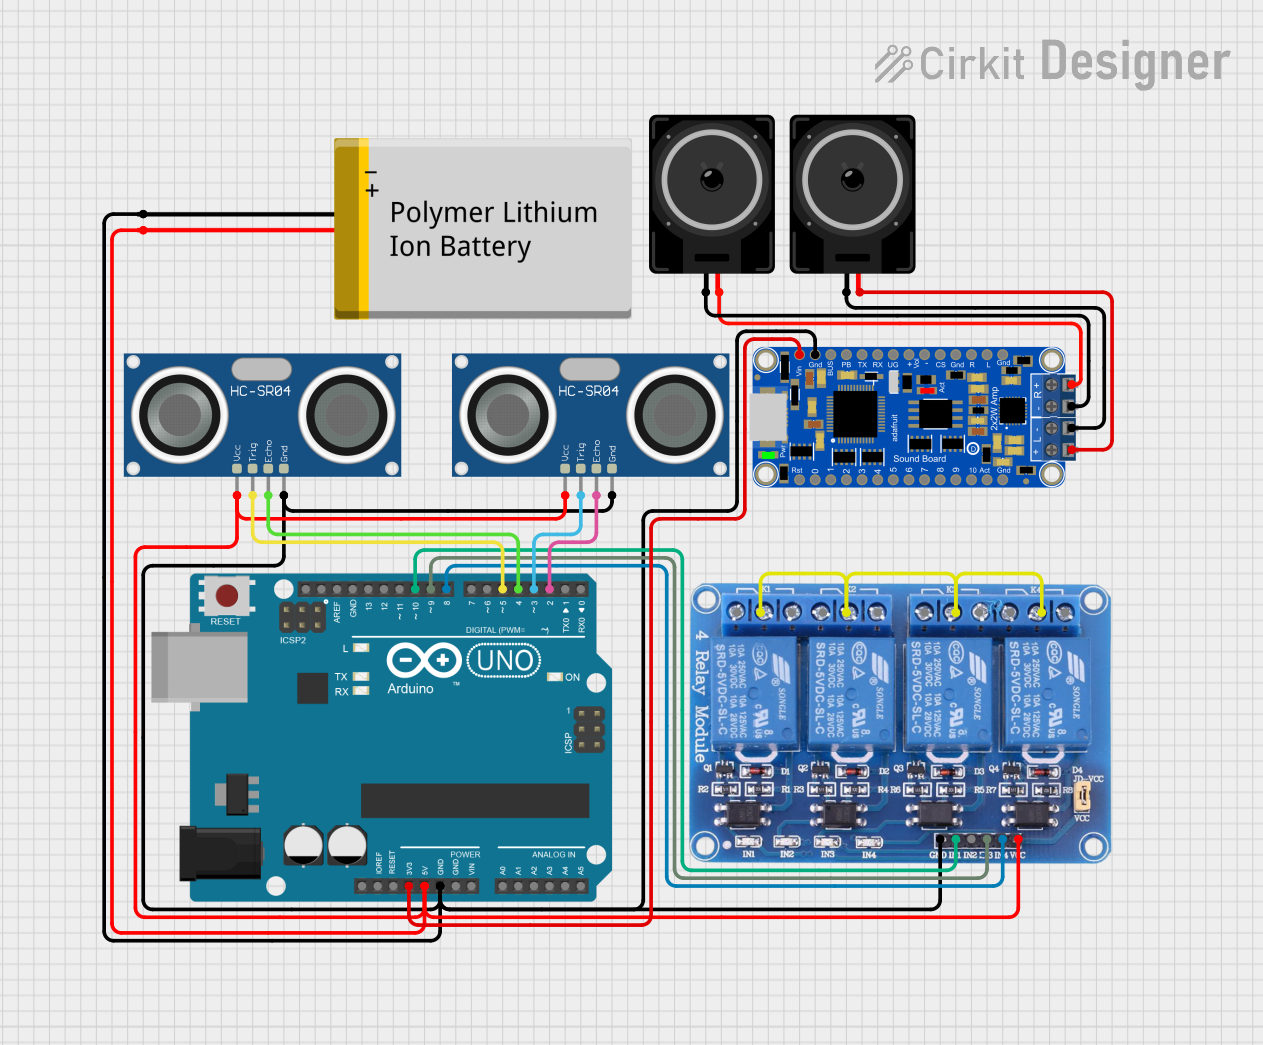
This circuit features an Arduino UNO microcontroller interfaced with two HC-SR04 ultrasonic sensors for distance measurement, a 4-channel relay module for controlling external devices, and an EZ-SFX amplifier connected to two loudspeakers for audio output. The system is powered by a Polymer Lithium Ion Battery and includes basic setup and loop code for the Arduino.
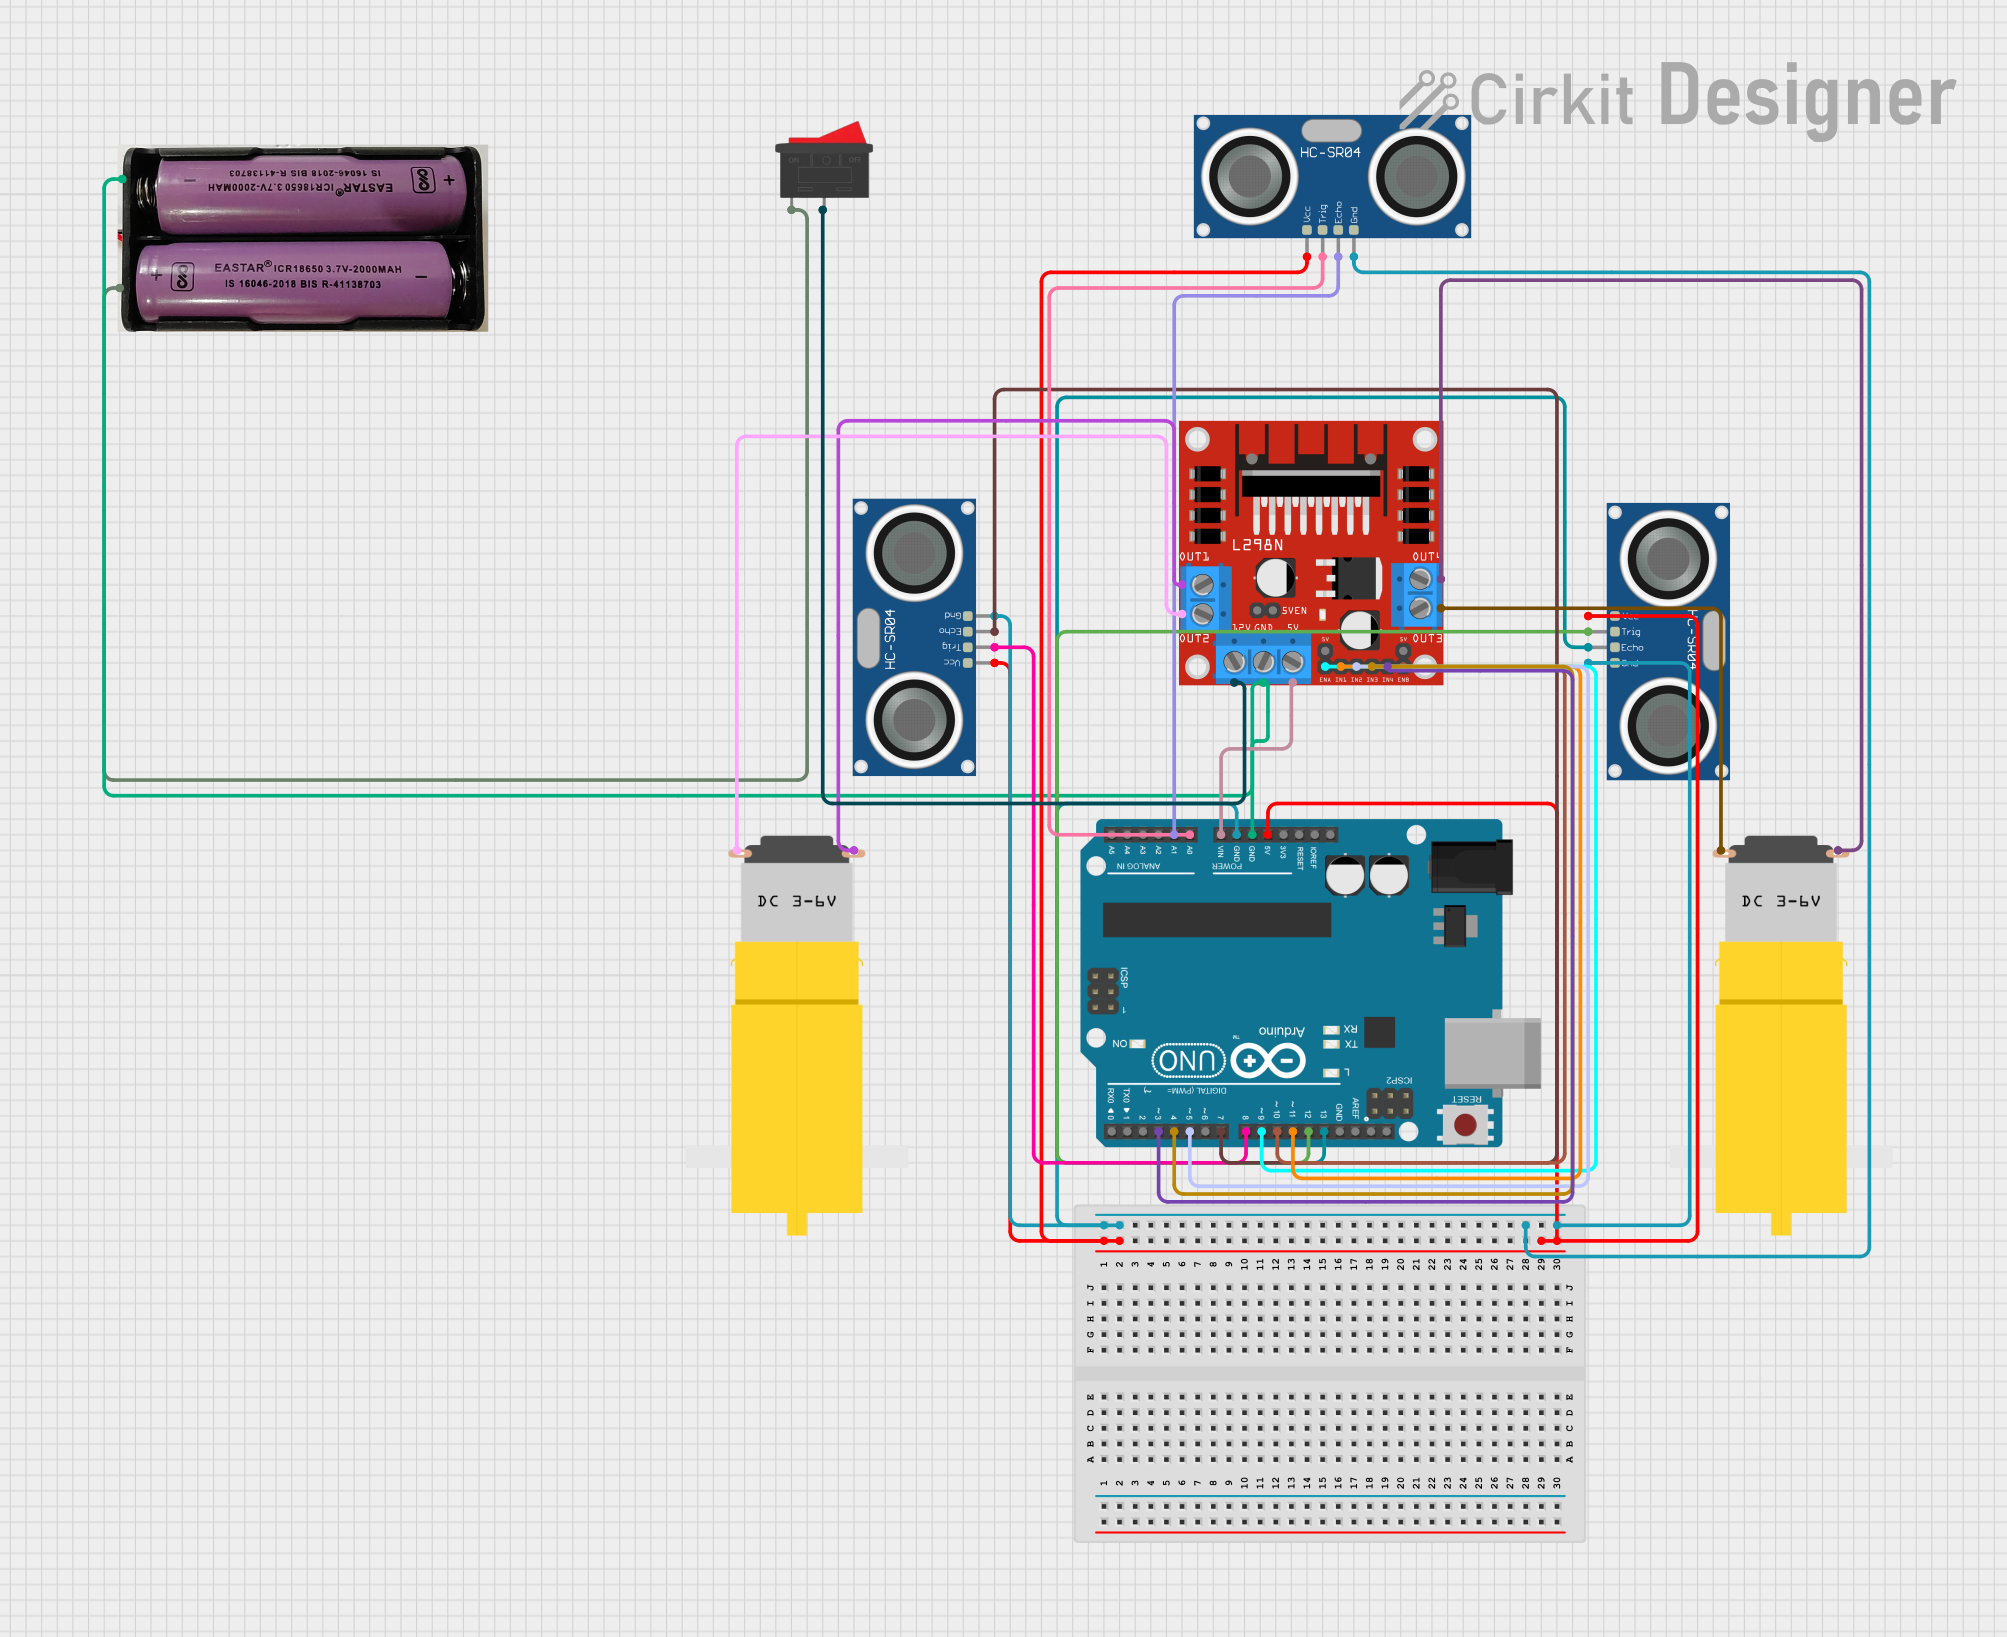
This circuit is a robotic system controlled by an Arduino UNO, featuring three HC-SR04 ultrasonic sensors for obstacle detection and an L298N motor driver to control two DC motors. The system is powered by a 7.4V battery and includes a rocker switch for power control, with the Arduino code set up to read sensor data and manage motor operations.
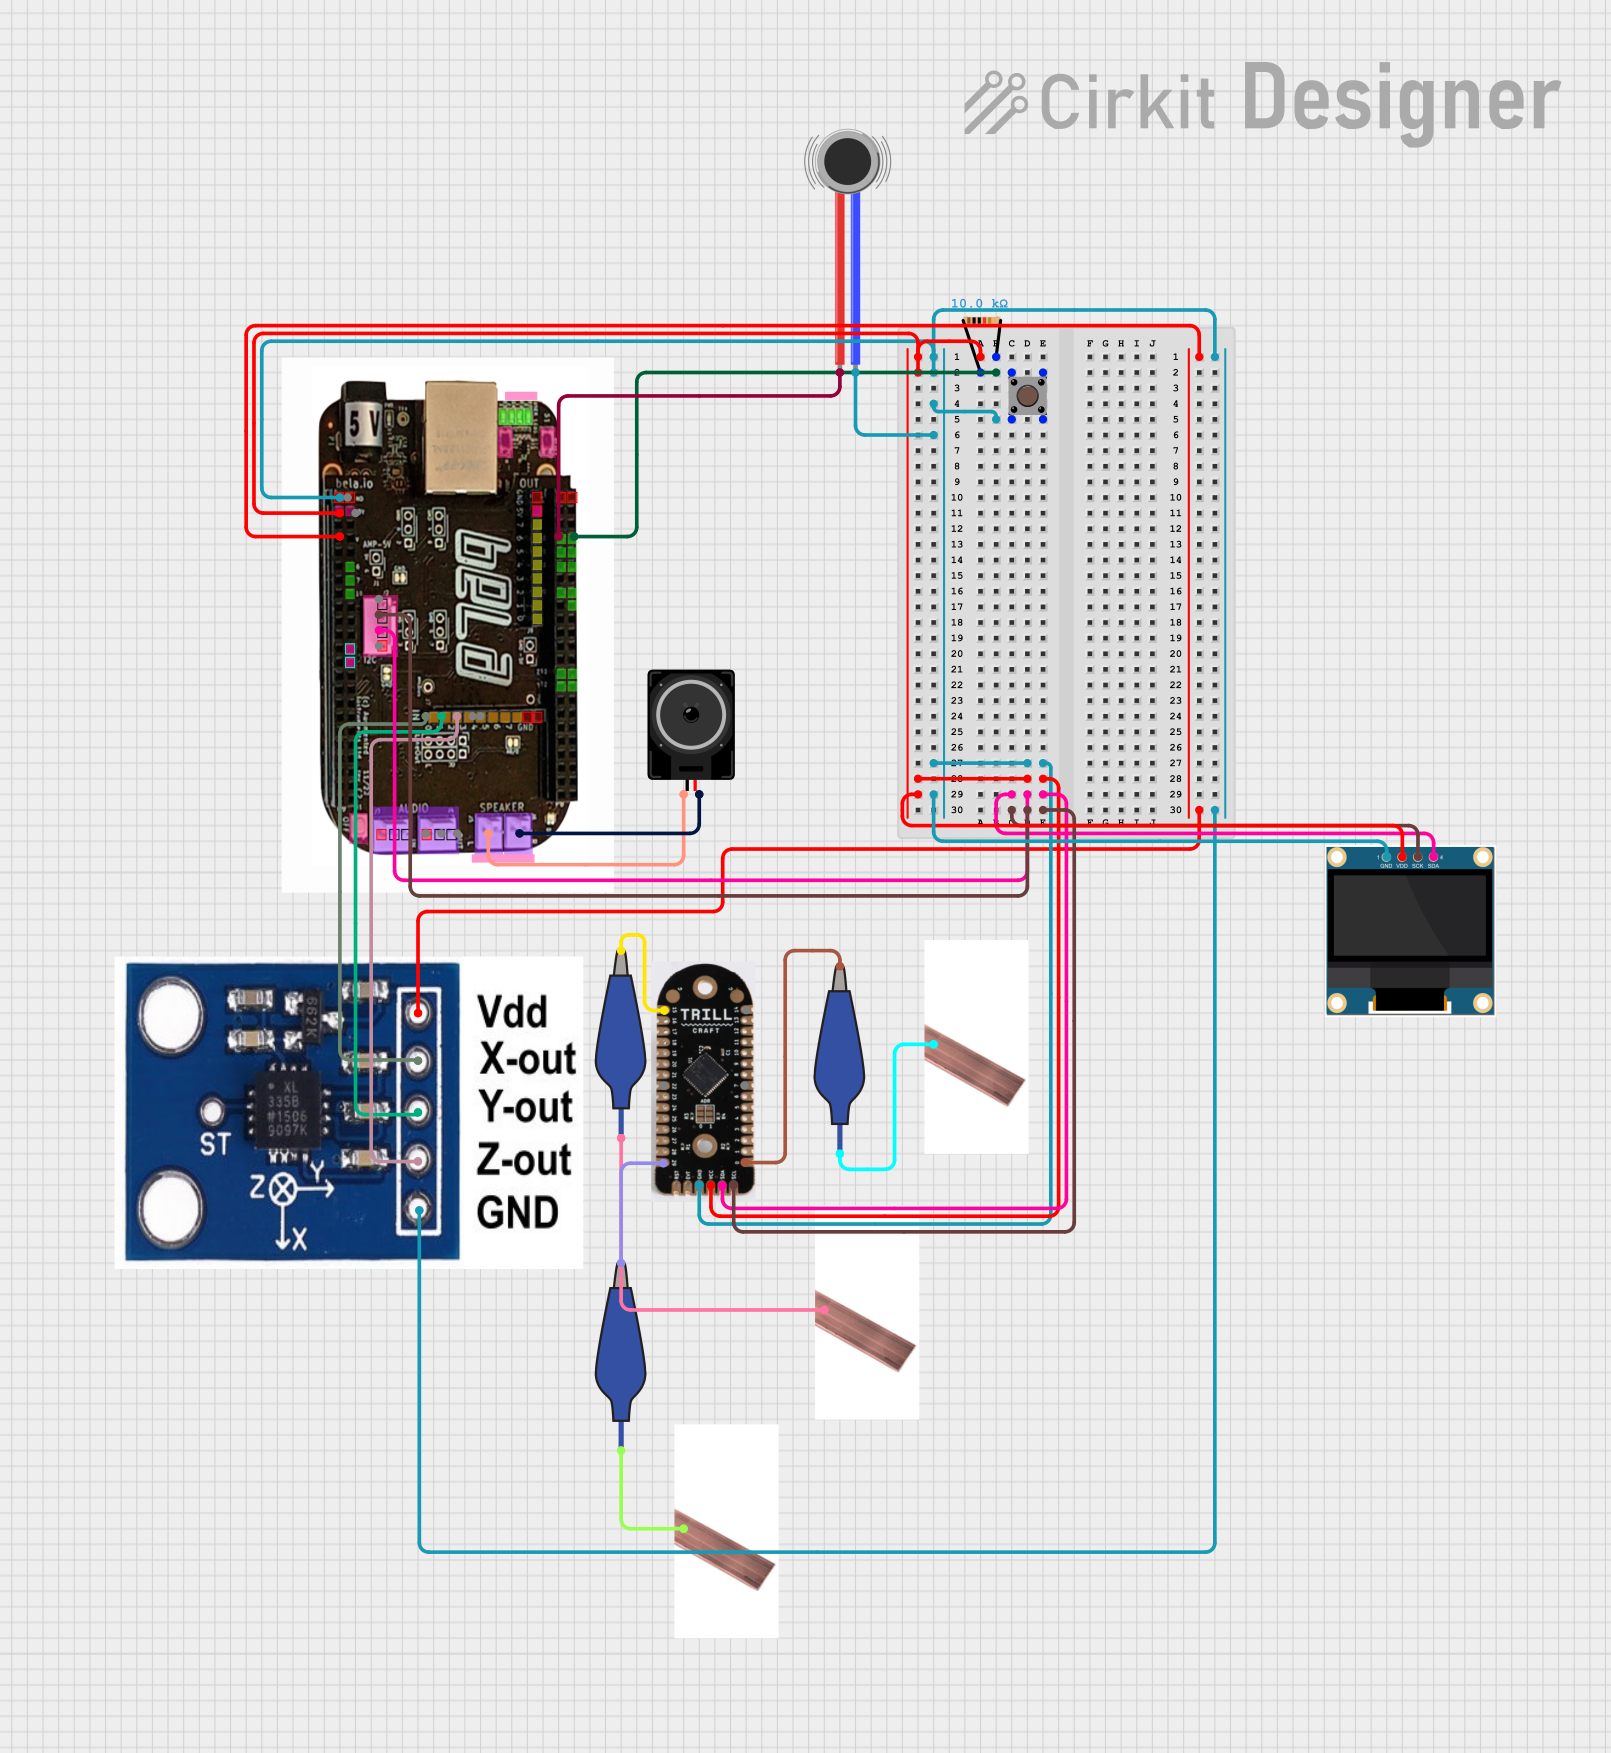
This circuit integrates a Bela Board with various sensors and actuators, including a TRILL CRAFT touch sensor, an ADXXL335 accelerometer, a vibration motor, and a loudspeaker. The Bela Board processes input from the touch sensor and accelerometer, and controls the vibration motor and loudspeaker, while an OLED display provides visual feedback.
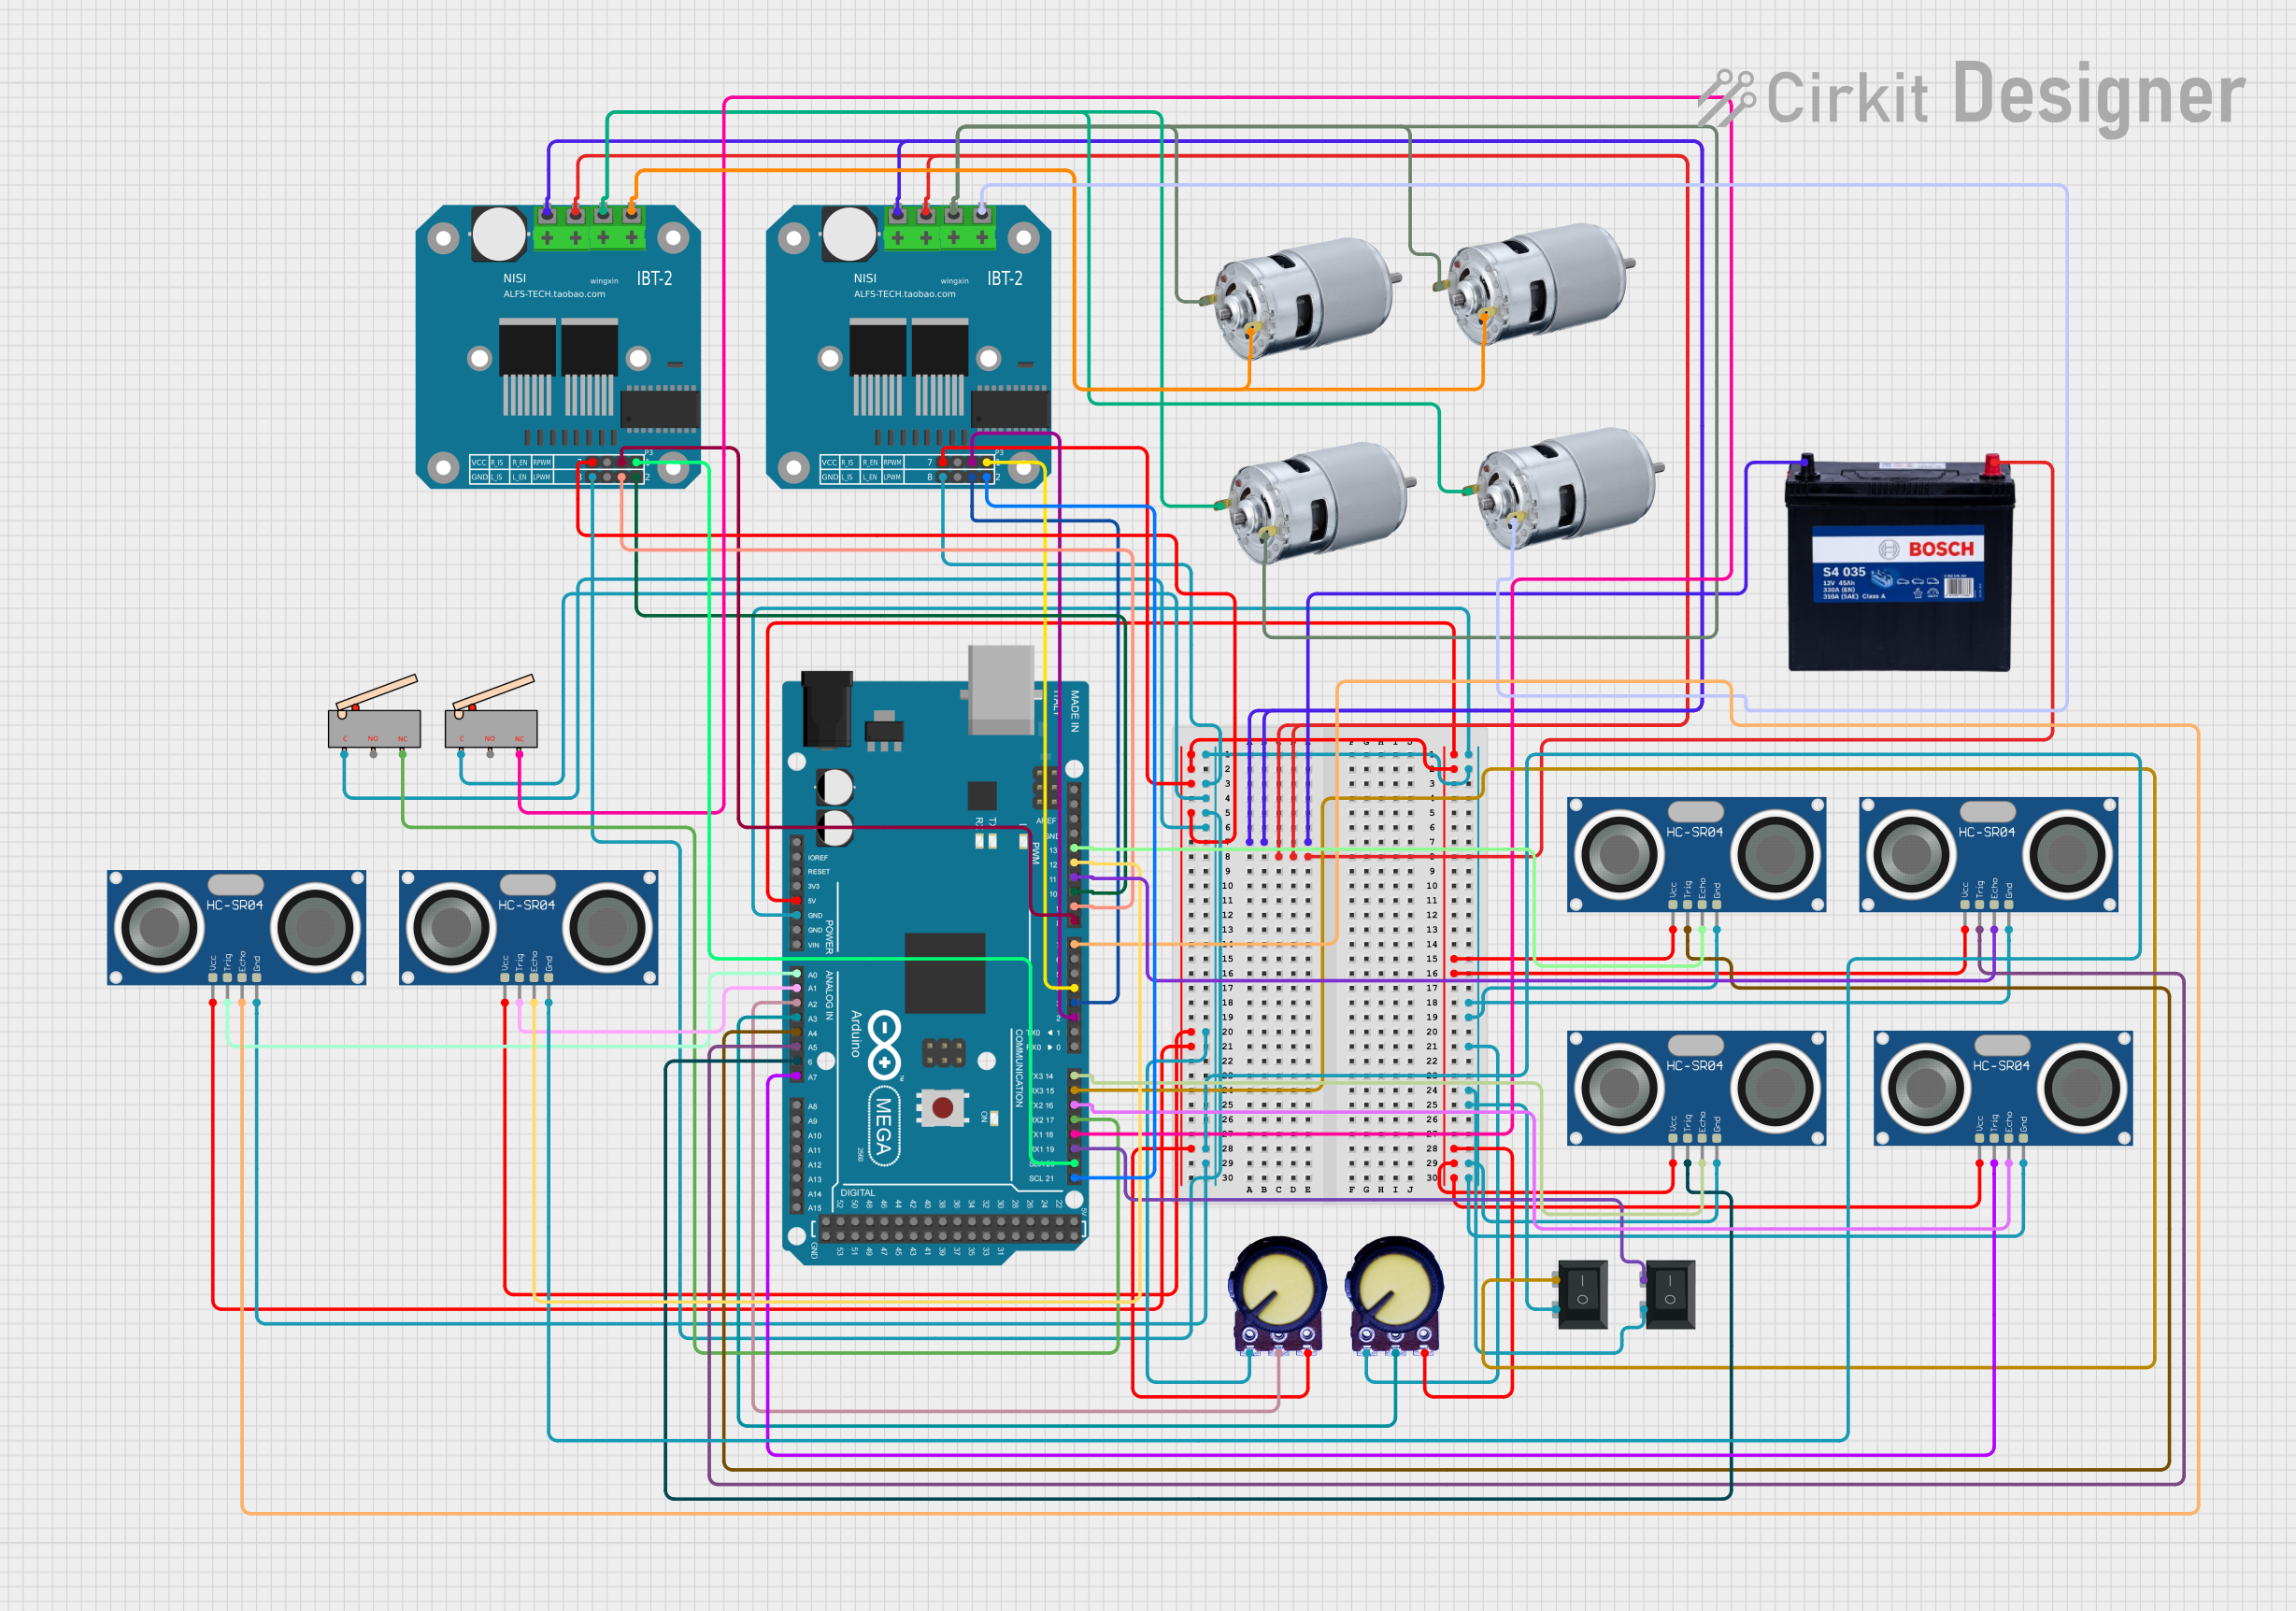
This circuit is a robotic system controlled by an Arduino Mega 2560, which uses multiple ultrasonic sensors for obstacle detection and potentiometers for setting movement limits. It drives four 775 motors through two BTS7960 motor drivers, with limit switches and a rocker switch for additional control inputs.
Below are the key technical details for a typical ultrasonic sensor (e.g., HC-SR04):
Parameter
Value
Operating Voltage
5V DC
Operating Current
15 mA
Operating Frequency
40 kHz
Measuring Range
2 cm to 400 cm
Accuracy
±3 mm
Trigger Input Signal
10 µs TTL pulse
Echo Output Signal
Pulse width proportional to range
Dimensions
45 mm x 20 mm x 15 mm
Pin Configuration and Descriptions
Pin
Name
Description
1
VCC
Connect to 5V DC power supply.
2
Trig
Trigger pin. Send a 10 µs HIGH pulse to initiate distance measurement.
3
Echo
Echo pin. Outputs a pulse whose width corresponds to the measured distance.
4
GND
Ground pin. Connect to the ground of the power supply.
Usage Instructions
How to Use the Ultrasonic Sensor in a Circuit
Power the Sensor: Connect the VCC pin to a 5V power supply and the GND pin to ground.
Trigger the Sensor: Send a 10 µs HIGH pulse to the Trig pin to start the measurement process.
Read the Echo: Measure the duration of the HIGH pulse on the Echo pin. This duration is proportional to the distance of the object.
Calculate Distance: Use the formula below to calculate the distance:
[
\text{Distance (cm)} = \frac{\text{Pulse Duration (µs)}}{58}
]
Alternatively, for distance in inches:
[
\text{Distance (in)} = \frac{\text{Pulse Duration (µs)}}{148}
]
Important Considerations and Best Practices
Ensure the sensor is mounted securely and aligned properly for accurate measurements.
Avoid placing the sensor near ultrasonic noise sources, as this can interfere with its operation.
Use a capacitor (e.g., 10 µF) across the VCC and GND pins to stabilize the power supply.
The sensor may not work reliably for very small or highly absorbent objects.
Example Code for Arduino UNO
Below is an example of how to use the ultrasonic sensor with an Arduino UNO:
// Define pins for the ultrasonic sensor
const int trigPin = 9; // Trigger pin connected to digital pin 9
const int echoPin = 10; // Echo pin connected to digital pin 10

void setup() {
  // Initialize serial communication for debugging
  Serial.begin(9600);

  // Set pin modes
  pinMode(trigPin, OUTPUT); // Trig pin as output
  pinMode(echoPin, INPUT);  // Echo pin as input
}

void loop() {
  // Send a 10 µs HIGH pulse to the Trig pin
  digitalWrite(trigPin, LOW);
  delayMicroseconds(2);
  digitalWrite(trigPin, HIGH);
  delayMicroseconds(10);
  digitalWrite(trigPin, LOW);

  // Measure the duration of the HIGH pulse on the Echo pin
  long duration = pulseIn(echoPin, HIGH);

  // Calculate the distance in centimeters
  float distance = duration / 58.0;

  // Print the distance to the Serial Monitor
  Serial.print("Distance: ");
  Serial.print(distance);
  Serial.println(" cm");

  // Wait before the next measurement
  delay(500);
}
Troubleshooting and FAQs
Common Issues and Solutions
No Output or Incorrect Readings:
Ensure the sensor is powered with 5V and properly grounded.
Verify the Trig and Echo pins are connected to the correct Arduino pins.
Check for loose or faulty wiring.
Unstable or Fluctuating Measurements:
Add a capacitor (e.g., 10 µF) across the VCC and GND pins to filter noise.
Ensure there are no obstructions or reflective surfaces near the sensor.
Sensor Not Detecting Objects:
Ensure the object is within the sensor's range (2 cm to 400 cm).
Check if the object is too small or made of a material that absorbs sound waves.
FAQs
Q: Can the ultrasonic sensor detect transparent objects?
A: Yes, as long as the object reflects sound waves. However, highly absorbent materials may not be detected.
Q: What is the maximum distance the sensor can measure?
A: The maximum range is typically 400 cm, but this may vary depending on environmental conditions.
Q: Can I use the sensor with a 3.3V microcontroller?
A: The sensor is designed for 5V operation. Use a level shifter or voltage divider for compatibility with 3.3V systems.

 Open Project in Cirkit Designer