A servo is a rotary actuator that allows for precise control of angular position, velocity, and acceleration. It consists of a motor coupled to a sensor for position feedback, along with a control circuit. Servos are widely used in robotics, automation, remote-controlled vehicles, and industrial machinery due to their ability to provide accurate and repeatable motion.
Explore Projects Built with Servo
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
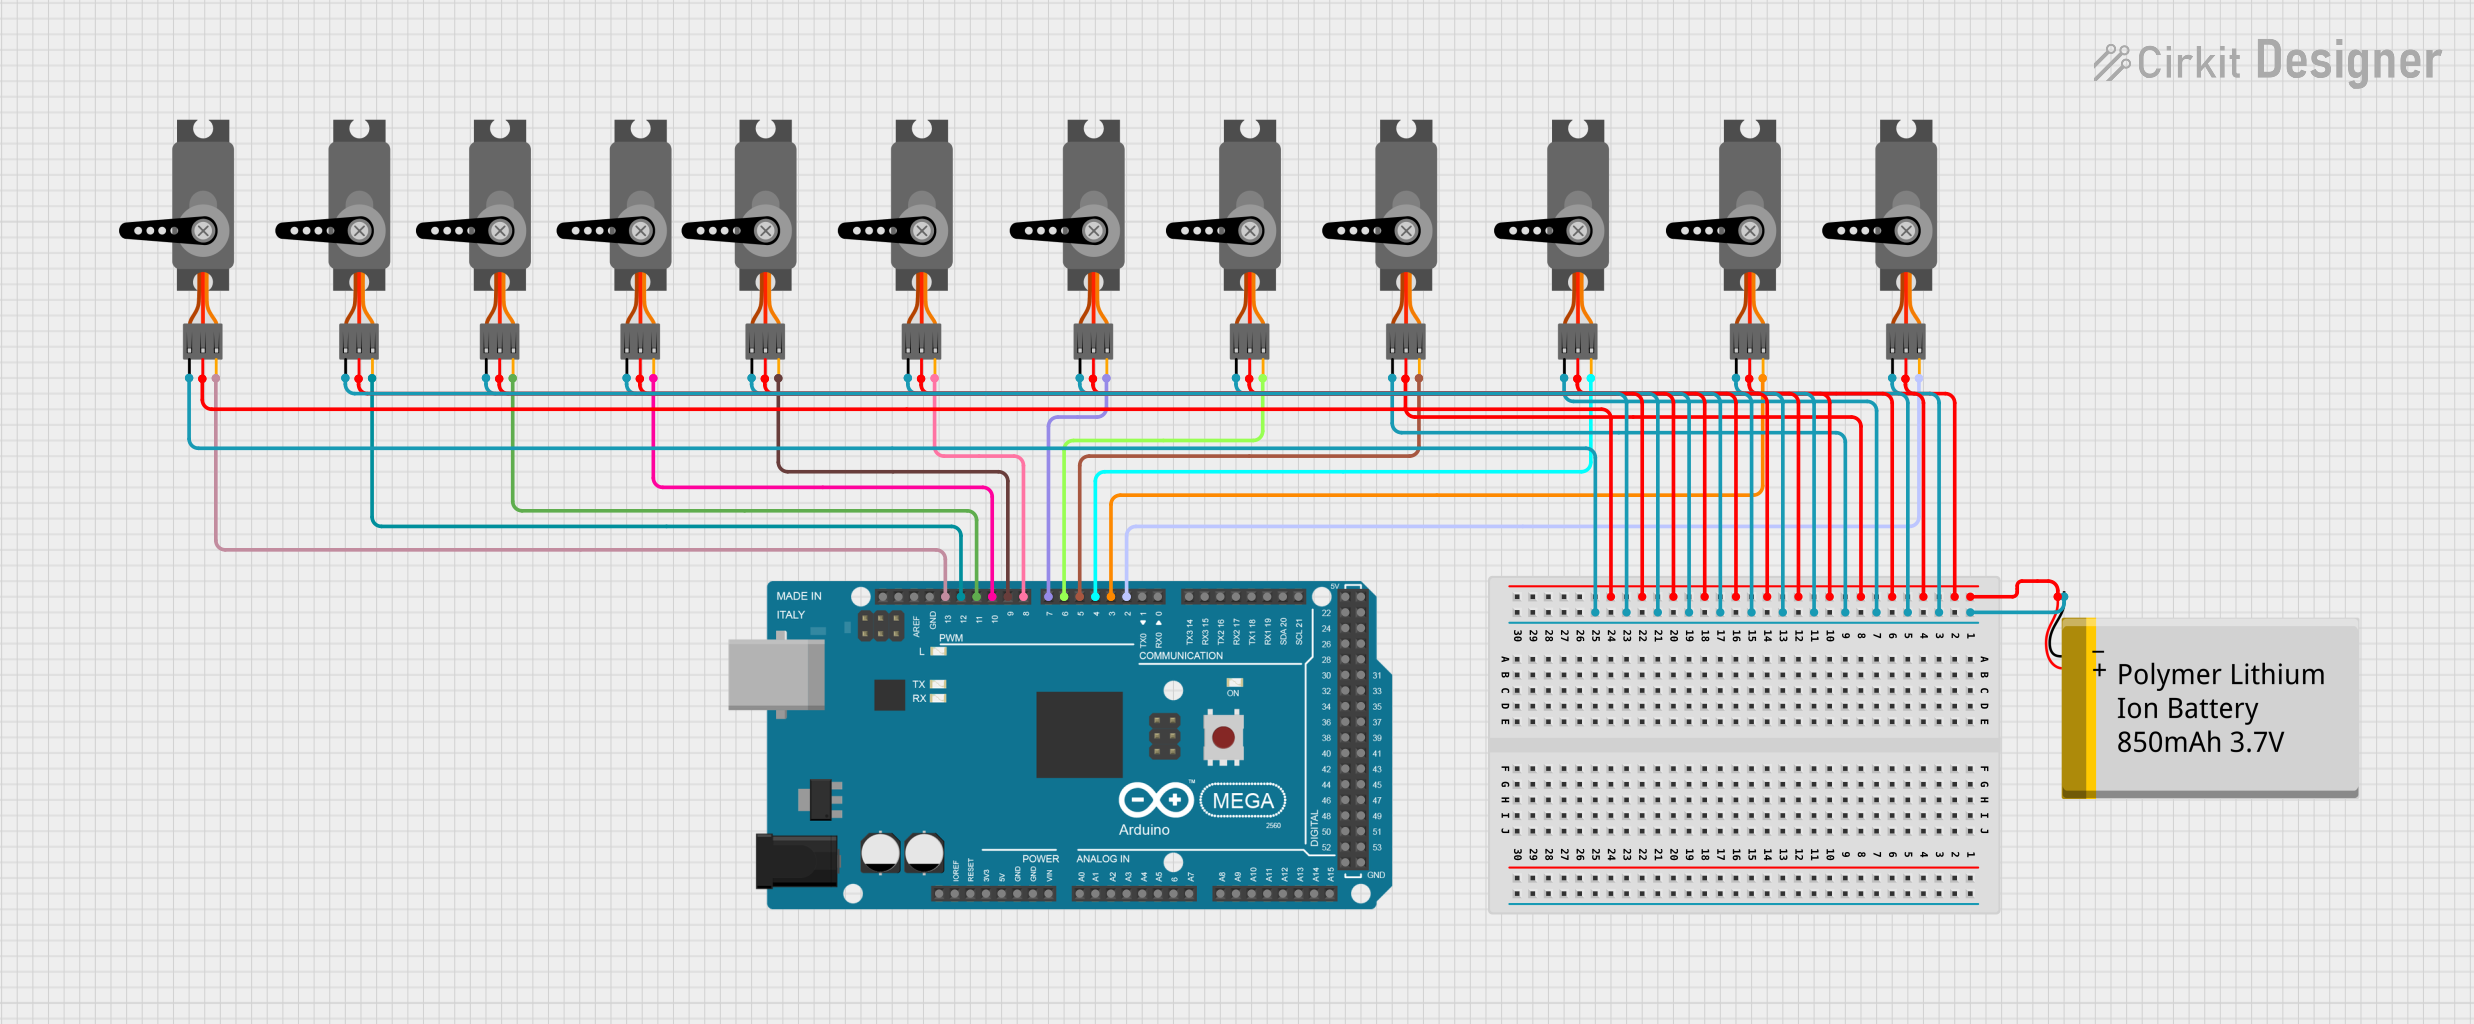
This circuit consists of an Arduino Mega 2560 microcontroller connected to twelve servo motors, each individually controlled by a distinct PWM pin on the Arduino. The servos are powered by a single Polymer Lithium Ion Battery, with all servos sharing a common power (VCC) and ground (GND) connection. The embedded code on the Arduino is designed to randomly position each servo within a 0 to 180-degree range, with a random delay between movements, demonstrating a multi-servo control system possibly for applications like robotics or animatronics.
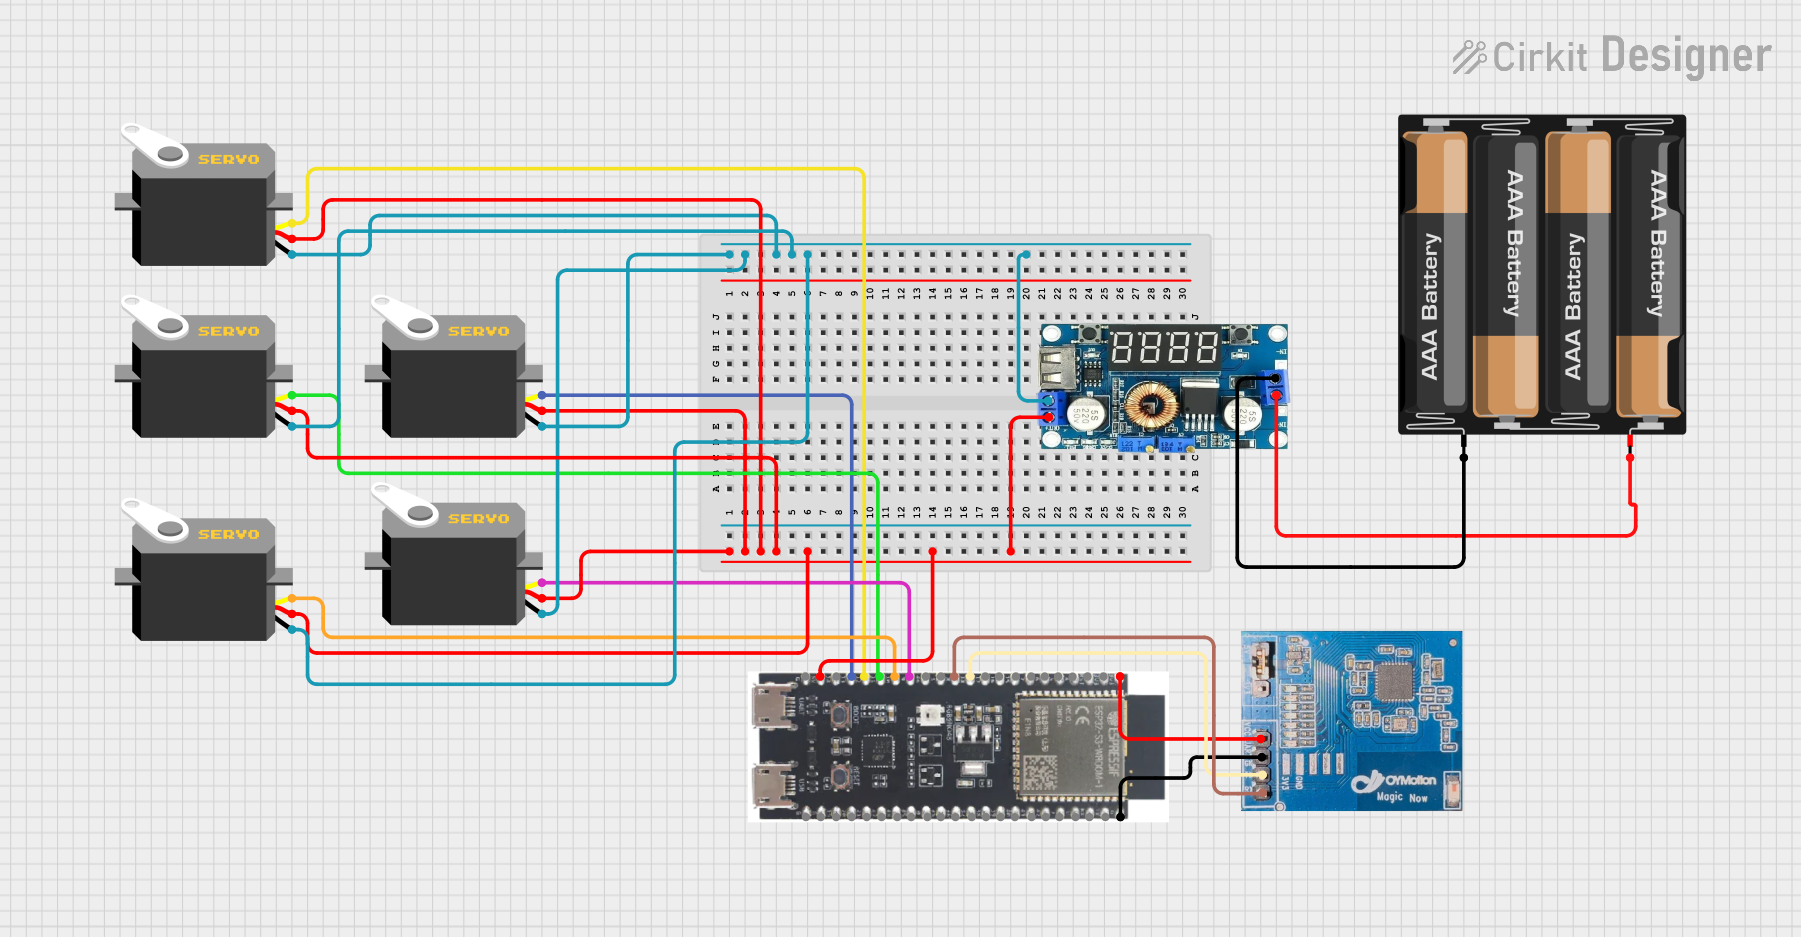
This circuit is a servo control system powered by a 4 x AAA battery pack, regulated by a step-down DC regulator. An ESP32-S3 microcontroller controls five servos and communicates with a gForceJoint UART sensor, enabling precise servo movements based on sensor inputs.
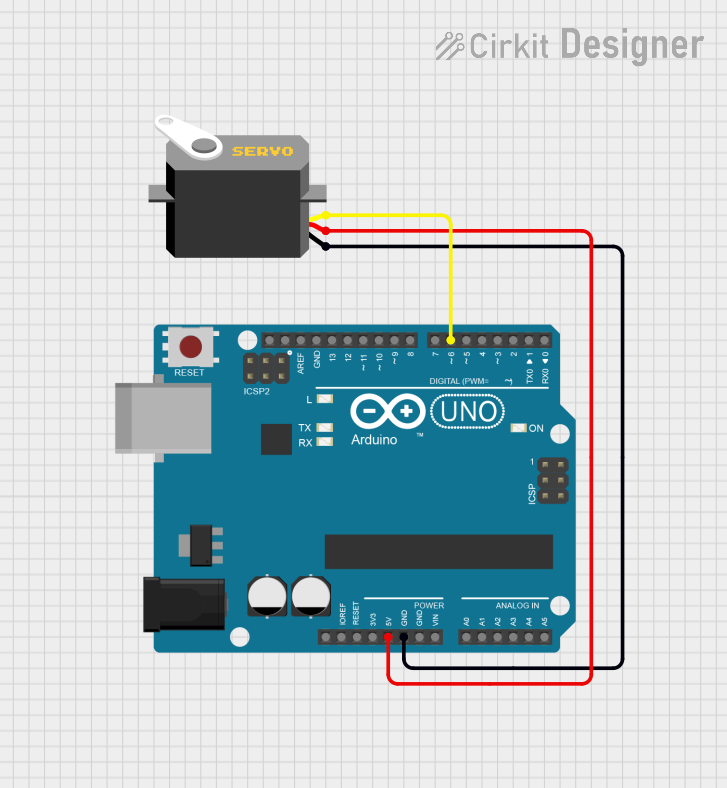
This circuit consists of an Arduino UNO microcontroller connected to a servo motor. The Arduino provides power (5V) and ground connections to the servo, as well as a control signal through one of its digital pins (D6). The embedded code on the Arduino is set up to control the servo's position, sending it to a fixed angle upon each loop iteration.
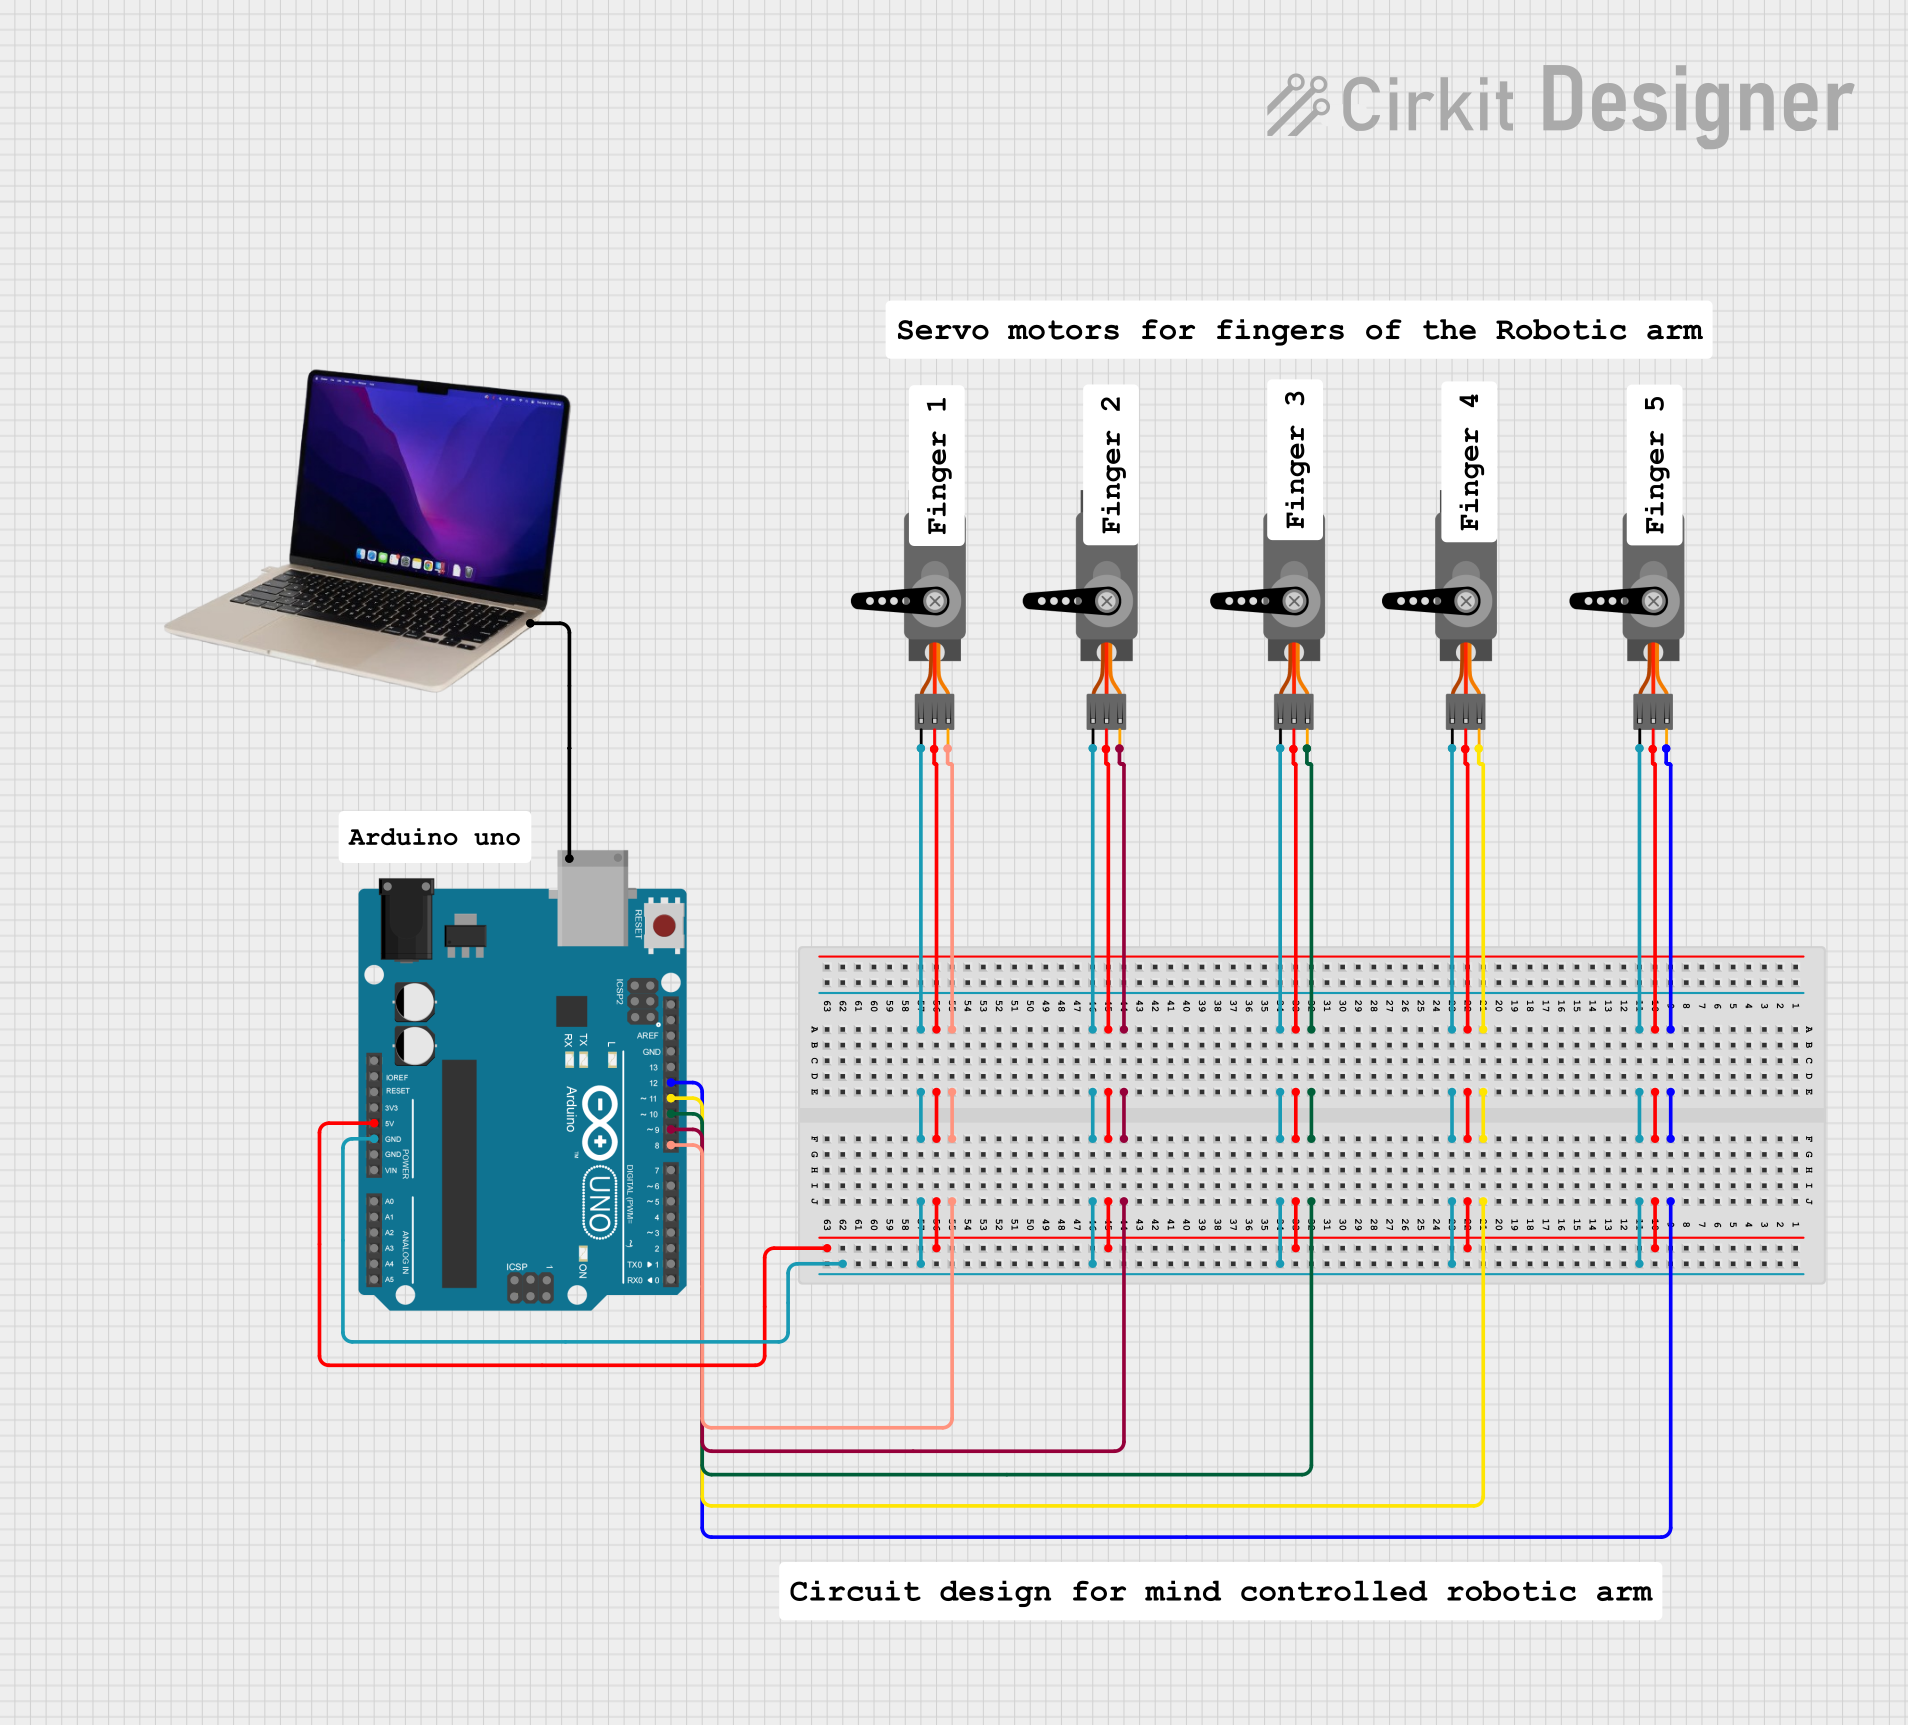
This circuit consists of an Arduino UNO microcontroller connected to five servo motors. The servos are powered by the Arduino's 5V output and share a common ground. Each servo's PWM control pin is individually connected to a digital pin on the Arduino (D8, D9, D10, D11, D12), allowing for independent control of each servo's position. The Arduino is also connected to a laptop via USB for programming and power.
Robotics: Controlling robotic arms, grippers, and joints.
Remote-controlled vehicles: Steering systems and throttle control.
Automation: Conveyor belt positioning and sorting mechanisms.
Model building: Aircraft flaps, rudders, and other moving parts.
Camera gimbals: Stabilizing and positioning cameras.
Technical Specifications
Below are the general technical specifications for a standard hobby servo. Note that specifications may vary depending on the specific model and manufacturer.
Key Technical Details
Operating Voltage: 4.8V to 6V (typical for standard servos)
Operating Current: 100mA to 1A (depending on load)
Torque: 1.5 kg·cm to 20 kg·cm (varies by model)
Rotation Range: Typically 0° to 180° (some models support 360° continuous rotation)
Control Signal: Pulse Width Modulation (PWM)
Pulse width: 1ms (0°), 1.5ms (90°), 2ms (180°)
Frequency: 50Hz (standard)
Pin Configuration and Descriptions
The servo typically has three wires for connection:
Pin Name
Wire Color (Common)
Description
VCC
Red
Power supply (4.8V to 6V)
GND
Black/Brown
Ground
Signal
Yellow/White/Orange
PWM control signal for position
Usage Instructions
How to Use the Servo in a Circuit
Power the Servo: Connect the VCC pin to a 5V or 6V power source and the GND pin to the ground of your circuit.
Control Signal: Connect the Signal pin to a PWM-capable pin on your microcontroller (e.g., Arduino).
PWM Signal: Generate a PWM signal with a frequency of 50Hz. Adjust the pulse width to control the servo's position:
1ms pulse: 0° position
1.5ms pulse: 90° position
2ms pulse: 180° position
Important Considerations and Best Practices
Power Supply: Use a separate power supply for the servo if it draws significant current, as this can prevent voltage drops in your circuit.
Avoid Overloading: Do not exceed the torque rating of the servo to avoid damage.
Signal Stability: Ensure the PWM signal is stable and within the specified frequency range.
Mechanical Stops: Avoid forcing the servo beyond its physical limits to prevent damage to the gears.
Example: Connecting a Servo to an Arduino UNO
Below is an example of how to control a servo using an Arduino UNO and the Servo library.
#include <Servo.h> // Include the Servo library

Servo myServo; // Create a Servo object to control the servo

void setup() {
  myServo.attach(9); // Attach the servo to pin 9 on the Arduino
}

void loop() {
  myServo.write(0); // Move the servo to 0 degrees
  delay(1000);      // Wait for 1 second

  myServo.write(90); // Move the servo to 90 degrees
  delay(1000);       // Wait for 1 second

  myServo.write(180); // Move the servo to 180 degrees
  delay(1000);        // Wait for 1 second
}
Notes on the Code
The Servo library simplifies the process of generating PWM signals.
The myServo.attach(9) function links the servo to pin 9.
The myServo.write(angle) function sets the servo to a specific angle (0° to 180°).
Troubleshooting and FAQs
Common Issues and Solutions
Servo Not Moving
Cause: Incorrect wiring or insufficient power supply.
Solution: Double-check the connections and ensure the power supply meets the servo's requirements.
Jittery or Erratic Movement
Cause: Unstable PWM signal or electrical noise.
Solution: Use a decoupling capacitor near the servo's power pins and ensure the PWM signal is stable.
Overheating
Cause: Excessive load or continuous operation at high torque.
Solution: Reduce the load or allow the servo to rest periodically.
Servo Stuck at One Position
Cause: Damaged gears or motor.
Solution: Inspect the servo for physical damage and replace it if necessary.
FAQs
Q: Can I use a servo with a 3.3V microcontroller?
A: Yes, but you may need a level shifter for the PWM signal, and the servo must still be powered with 4.8V to 6V.
Q: How do I control a continuous rotation servo?
A: For continuous rotation servos, the PWM signal controls speed and direction rather than position. A 1.5ms pulse stops the servo, while shorter or longer pulses control rotation direction and speed.
Q: Can I connect multiple servos to one Arduino?
A: Yes, but ensure the power supply can handle the combined current draw of all servos. Use external power if necessary.
Q: What happens if I exceed the servo's torque rating?
A: Exceeding the torque rating can damage the servo's motor or gears. Always operate within the specified limits.

 Open Project in Cirkit Designer