Introduction
The MPU6050 is a 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer on a single chip. This integration enables the measurement of angular velocity and acceleration in three-dimensional space, making it a versatile and widely used sensor in motion tracking applications.
Common Applications and Use Cases
- Robotics: For balancing robots, motion control, and navigation.
- Drones: To stabilize flight and measure orientation.
- Wearable Devices: For fitness tracking and gesture recognition.
- Gaming: To detect motion and orientation in controllers.
- Industrial Applications: For vibration analysis and equipment monitoring.
Technical Specifications
The MPU6050 is a highly integrated sensor with the following key specifications:
Pin Configuration and Descriptions
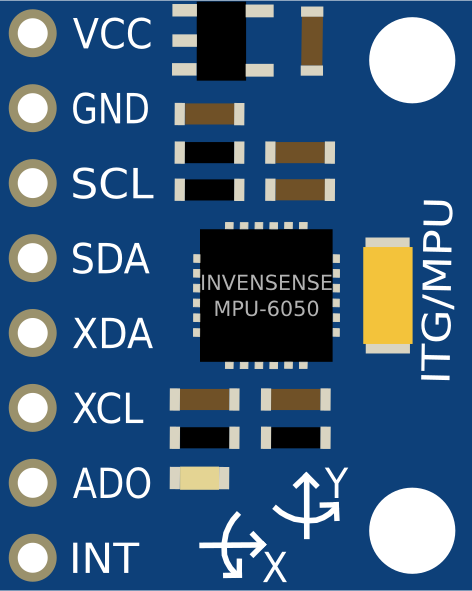
The MPU6050 has 8 pins, as described in the table below:
Usage Instructions
How to Use the MPU6050 in a Circuit
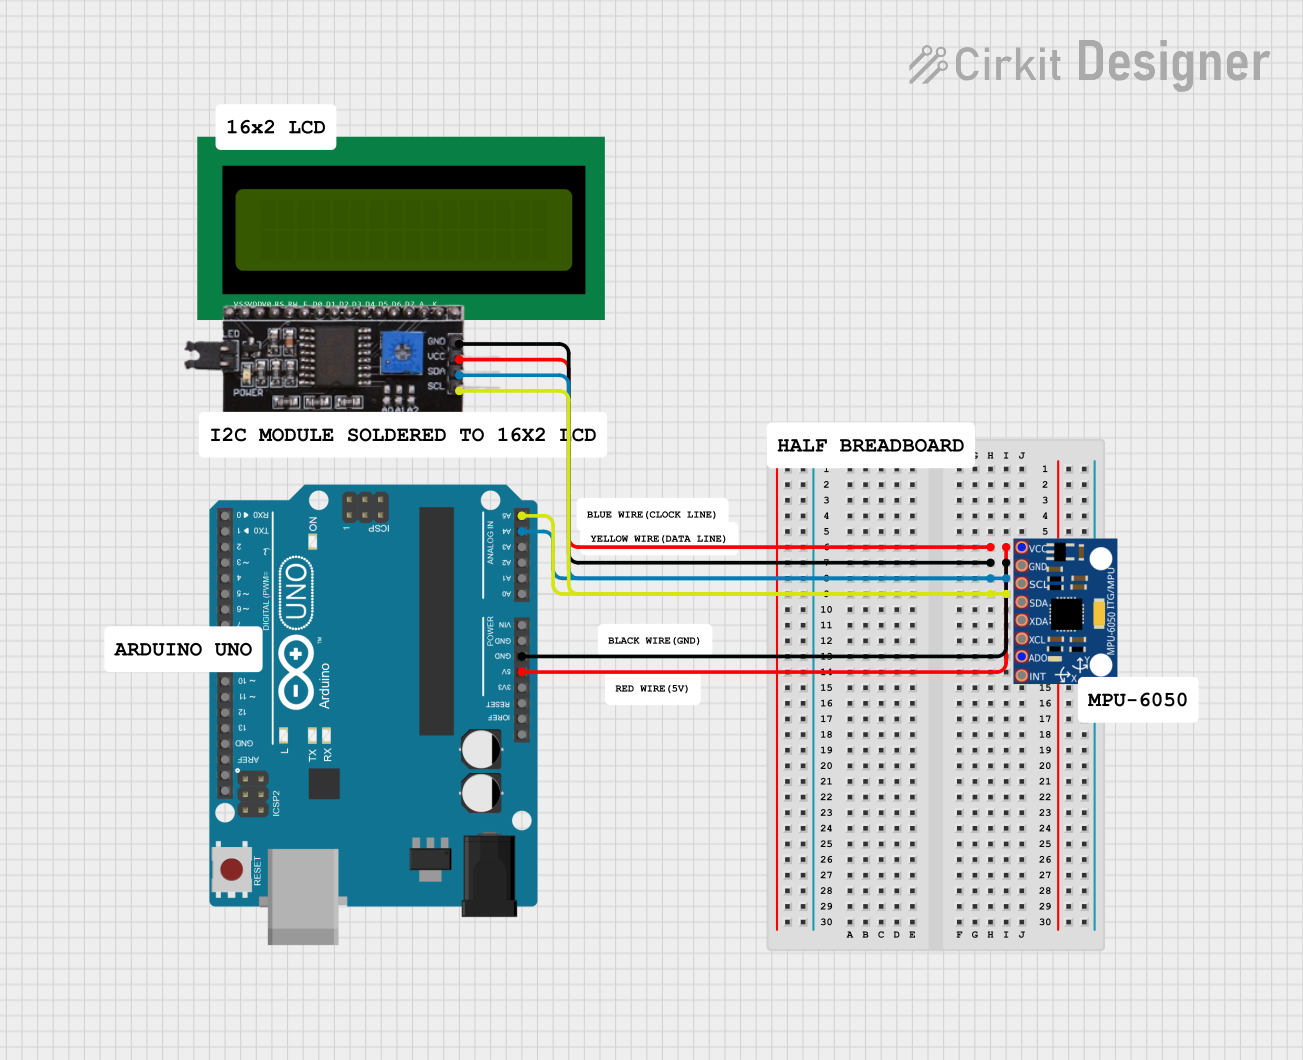
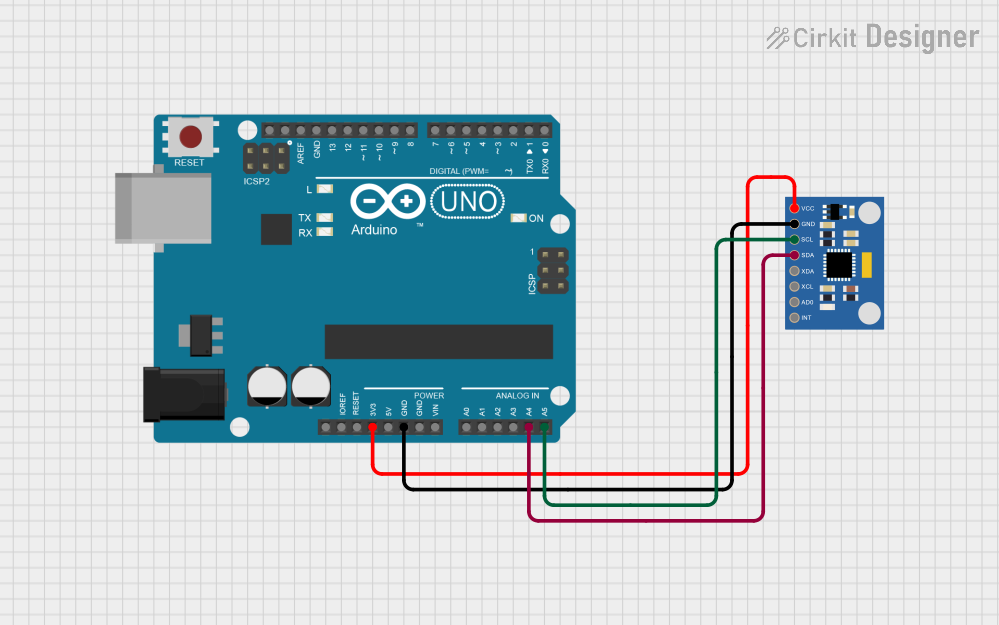
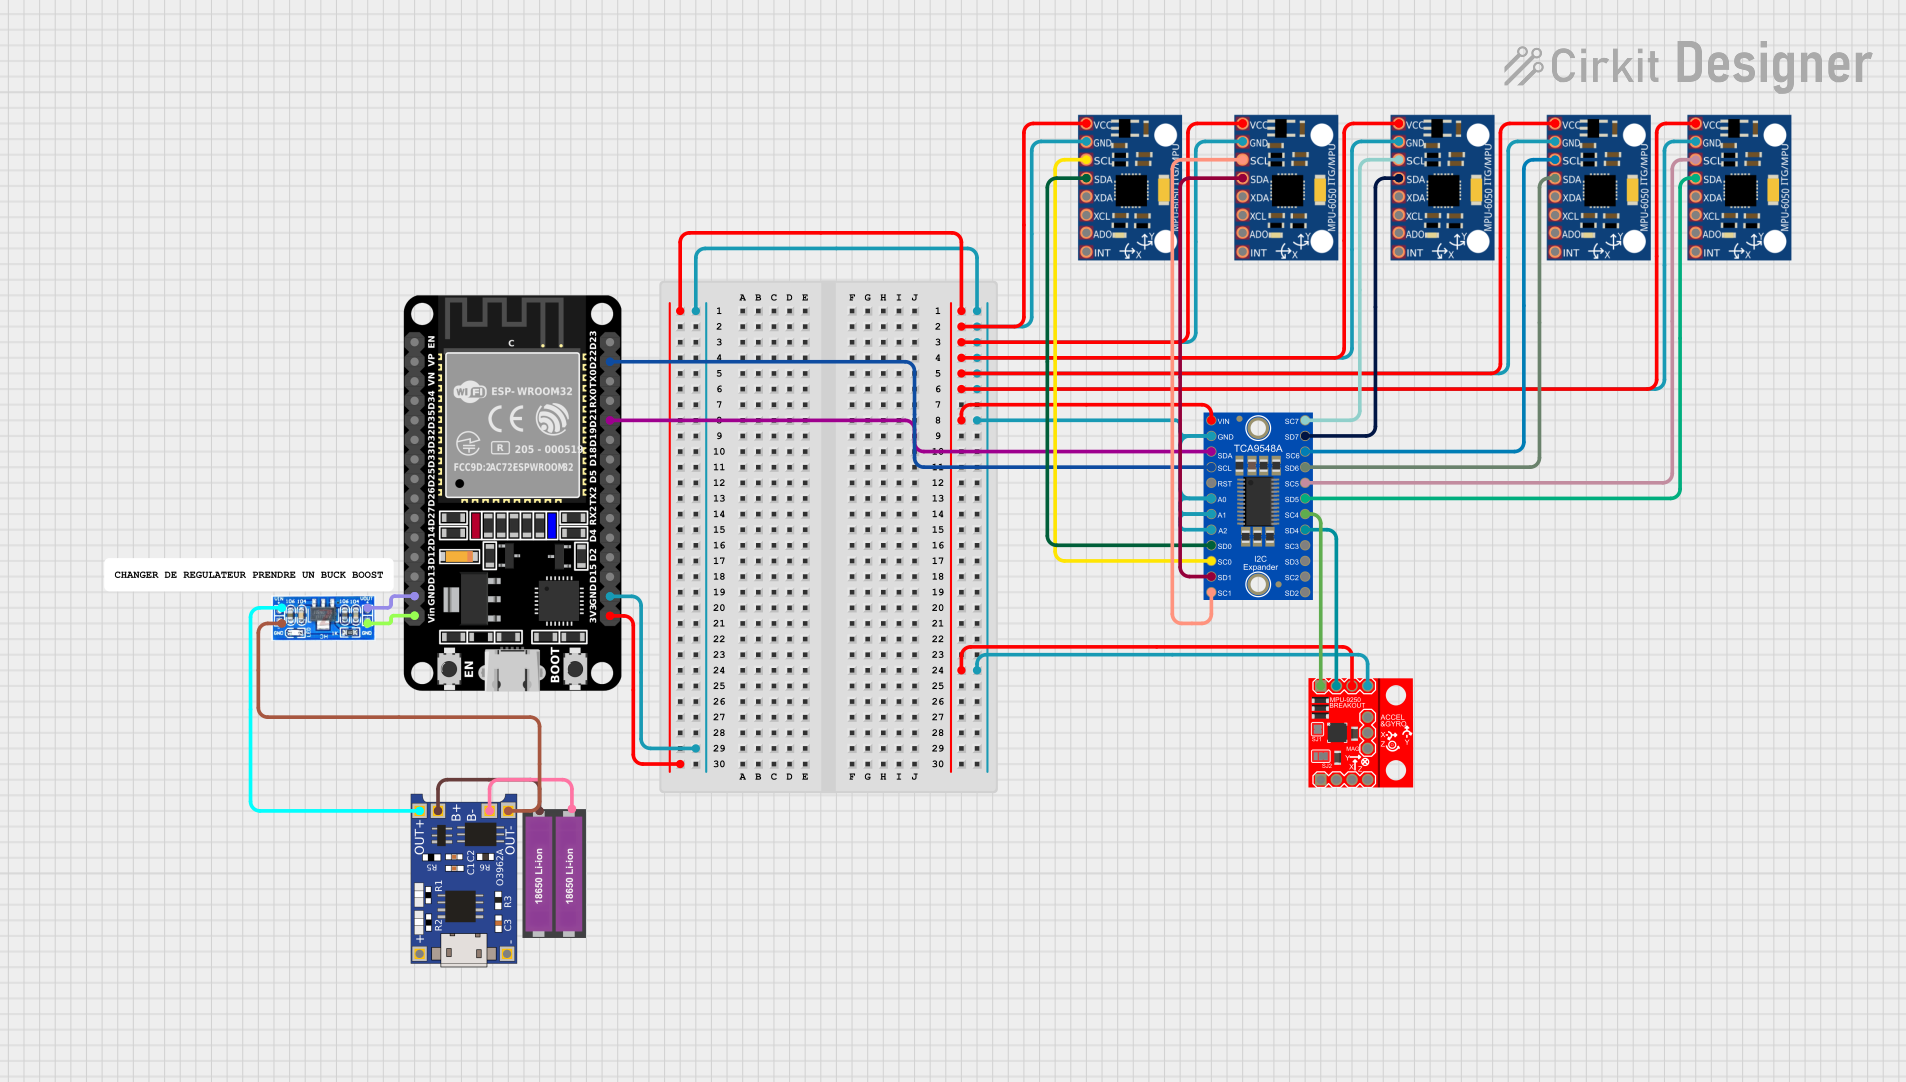
- Power Supply: Connect the VDD pin to a 3.3V power source and the GND pin to ground. If your microcontroller operates at 5V logic, use a level shifter for the I2C lines.
- I2C Communication: Connect the SCL and SDA pins to the corresponding I2C pins on your microcontroller. Use pull-up resistors (typically 4.7kΩ) on both lines.
- Address Selection: Set the I2C address by connecting the AD0 pin to GND (address 0x68) or VDD (address 0x69).
- Interrupt Pin: Optionally, connect the INT pin to a GPIO pin on your microcontroller to handle motion detection interrupts.
Important Considerations and Best Practices
- Bypass Capacitor: Place a 0.1µF ceramic capacitor close to the VDD pin for power supply decoupling.
- Mounting Orientation: Ensure the sensor is mounted securely and aligned correctly for accurate measurements.
- Calibration: Perform gyroscope and accelerometer calibration to improve accuracy.
- I2C Pull-Up Resistors: Ensure proper pull-up resistors are used on the I2C lines to avoid communication issues.
Example Code for Arduino UNO
Below is an example of how to interface the MPU6050 with an Arduino UNO using the Wire library:
#include <Wire.h>

// MPU6050 I2C address (default is 0x68 when AD0 is connected to GND)
const int MPU6050_ADDR = 0x68;

// MPU6050 register addresses
const int PWR_MGMT_1 = 0x6B; // Power management register
const int ACCEL_XOUT_H = 0x3B; // Accelerometer X-axis high byte

void setup() {
  Wire.begin(); // Initialize I2C communication
  Serial.begin(9600); // Initialize serial communication for debugging

  // Wake up the MPU6050 (it starts in sleep mode)
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(PWR_MGMT_1); // Access power management register
  Wire.write(0); // Set to 0 to wake up the sensor
  Wire.endTransmission();

  Serial.println("MPU6050 initialized");
}

void loop() {
  // Request accelerometer data
  Wire.beginTransmission(MPU6050_ADDR);
  Wire.write(ACCEL_XOUT_H); // Start reading from ACCEL_XOUT_H register
  Wire.endTransmission(false); // Send restart condition
  Wire.requestFrom(MPU6050_ADDR, 6); // Request 6 bytes (X, Y, Z high and low)

  if (Wire.available() == 6) {
    int16_t accelX = (Wire.read() << 8) | Wire.read(); // Combine high and low bytes
    int16_t accelY = (Wire.read() << 8) | Wire.read();
    int16_t accelZ = (Wire.read() << 8) | Wire.read();

    // Print accelerometer values
    Serial.print("Accel X: "); Serial.print(accelX);
    Serial.print(" | Accel Y: "); Serial.print(accelY);
    Serial.print(" | Accel Z: "); Serial.println(accelZ);
  }

  delay(500); // Wait 500ms before the next reading
}
Troubleshooting and FAQs
Common Issues
No I2C Communication:
- Ensure the correct I2C address (0x68 or 0x69) is used.
- Check the pull-up resistors on the SDA and SCL lines.
- Verify the wiring and connections.
Incorrect or No Sensor Data:
- Confirm the sensor is powered correctly (check VDD and GND connections).
- Perform calibration to eliminate offsets in the readings.
Interrupt Pin Not Working:
- Ensure the INT pin is connected to a GPIO pin configured as an input.
- Verify the interrupt configuration in the MPU6050 registers.
Tips for Troubleshooting
- Use an I2C scanner sketch to confirm the MPU6050 is detected on the I2C bus.
- Check for loose or incorrect connections in the circuit.
- Use a logic analyzer or oscilloscope to debug I2C communication issues.
FAQs
Q: Can the MPU6050 operate at 5V?
A: No, the MPU6050 operates at a maximum of 3.46V. Use a level shifter for 5V systems.
Q: How do I calibrate the MPU6050?
A: Calibration involves reading raw data from the sensor and calculating offsets for the gyroscope and accelerometer. These offsets can then be subtracted from the raw readings during operation.
Q: What is the maximum sampling rate of the MPU6050?
A: The MPU6050 supports a maximum sampling rate of 1kHz for both the gyroscope and accelerometer.
Q: Can I use the MPU6050 without an interrupt pin?
A: Yes, the interrupt pin is optional. You can poll the sensor data over I2C without using interrupts.

 Open Project in Cirkit Designer