The Pixhawk Cube Orange is an advanced flight controller designed for drones and other unmanned vehicles. Manufactured by Pixhawk, this component (Part ID: ADSB-Carrier Board PX-4) is equipped with a powerful processor, multiple sensor inputs, and support for various communication protocols. It is ideal for complex autonomous missions, offering high reliability and precision.
Explore Projects Built with Pixhawk Cube Orange
Use Cirkit Designer to design, explore, and prototype these projects online. Some projects support real-time simulation. Click "Open Project" to start designing instantly!
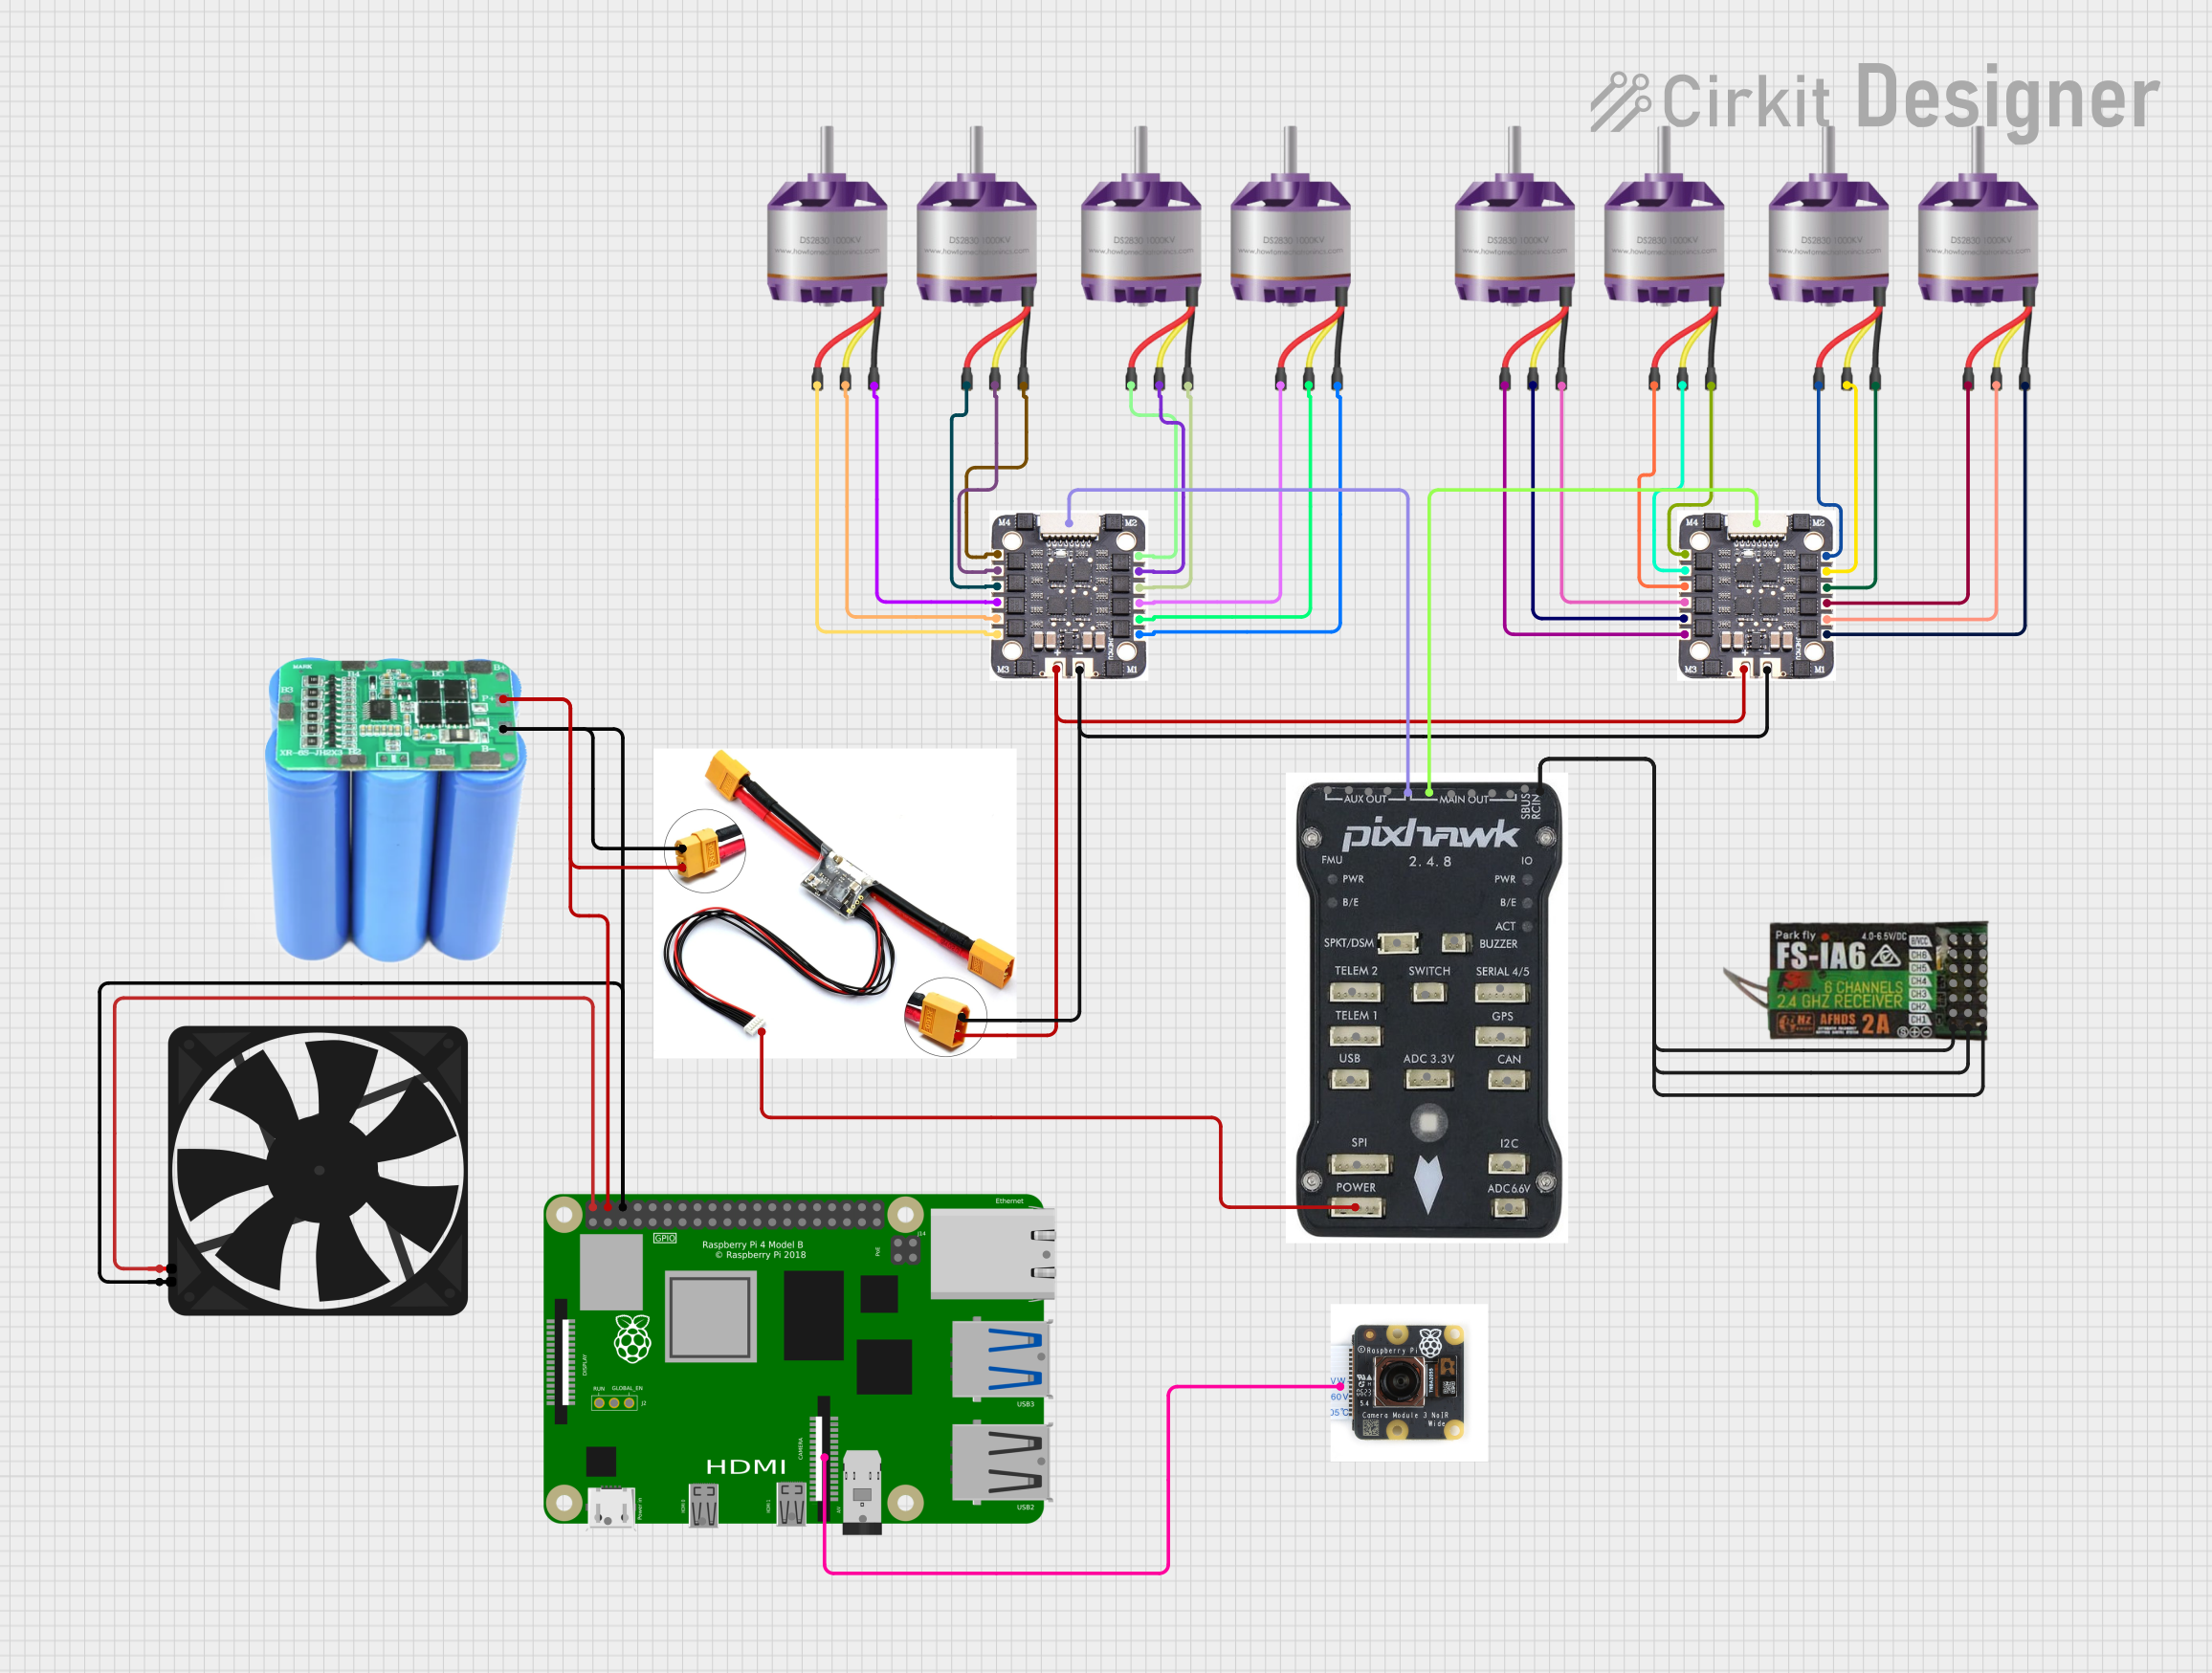
This circuit is designed for a multi-motor application, likely a drone or a similar vehicle, featuring eight brushless motors controlled by two 4-in-1 electronic speed controllers (ESCs). The ESCs are powered by a 3s2p 18650 battery pack and interfaced with a Pixhawk flight controller for motor management. Additionally, the system includes a Raspberry Pi 4B for advanced processing and control, which is connected to a NoIR camera module and a cooling fan, and a power module to supply and monitor the power to the Pixhawk.
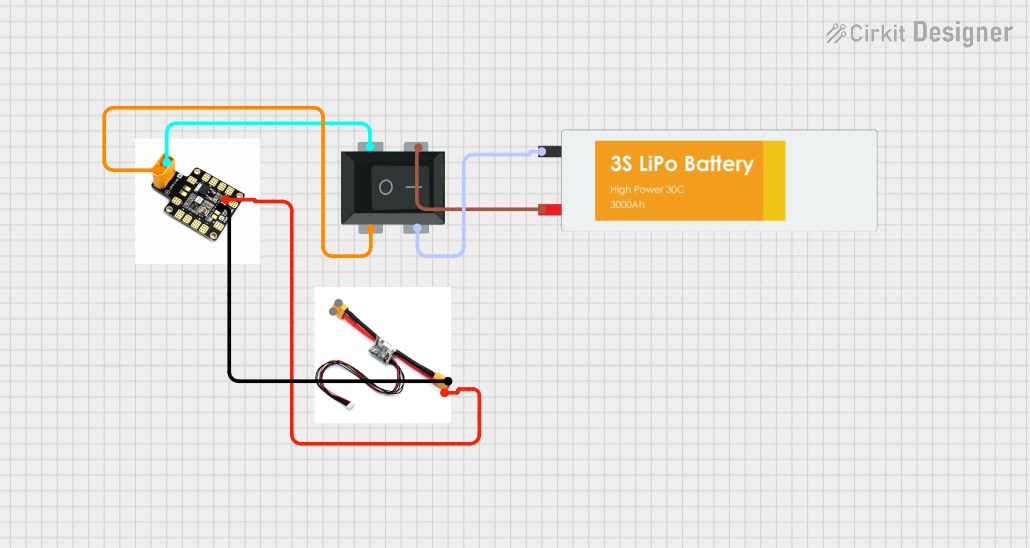
This circuit is designed to power a Pixhawk module using a LiPo battery. The circuit includes a rocker switch to control the power flow from the battery to a power distribution board (PDB), which then supplies 12V to the Pixhawk module.
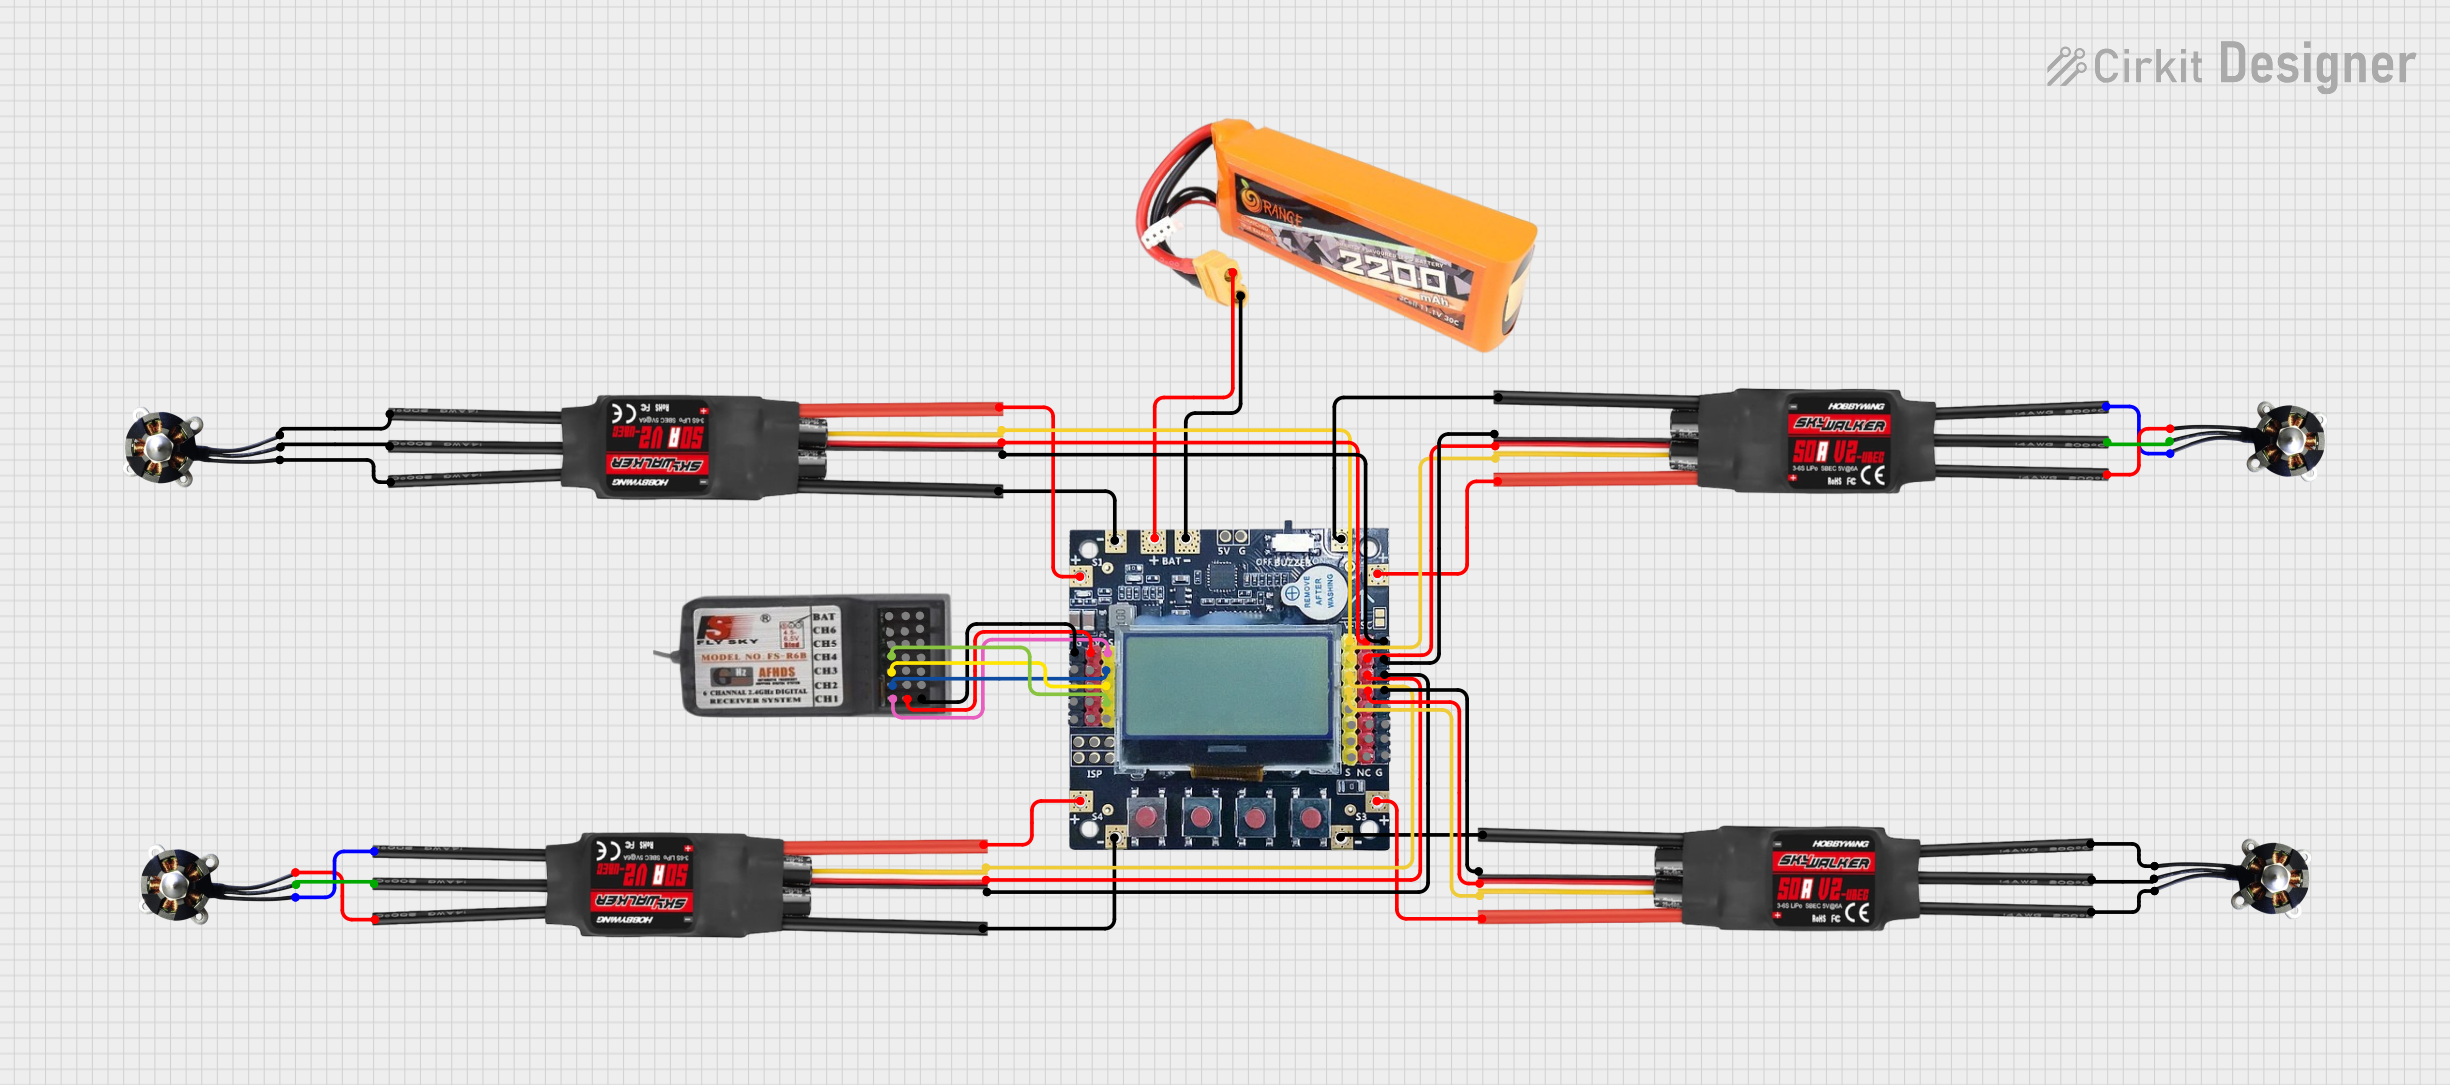
This circuit is a quadcopter control system that includes a LiPo battery, four BLDC motors, four ESCs, a KK2.1.5 flight controller, and an FS-R6B receiver. The KK2.1.5 flight controller manages the ESCs and motors based on input signals from the receiver, which is powered by the LiPo battery.
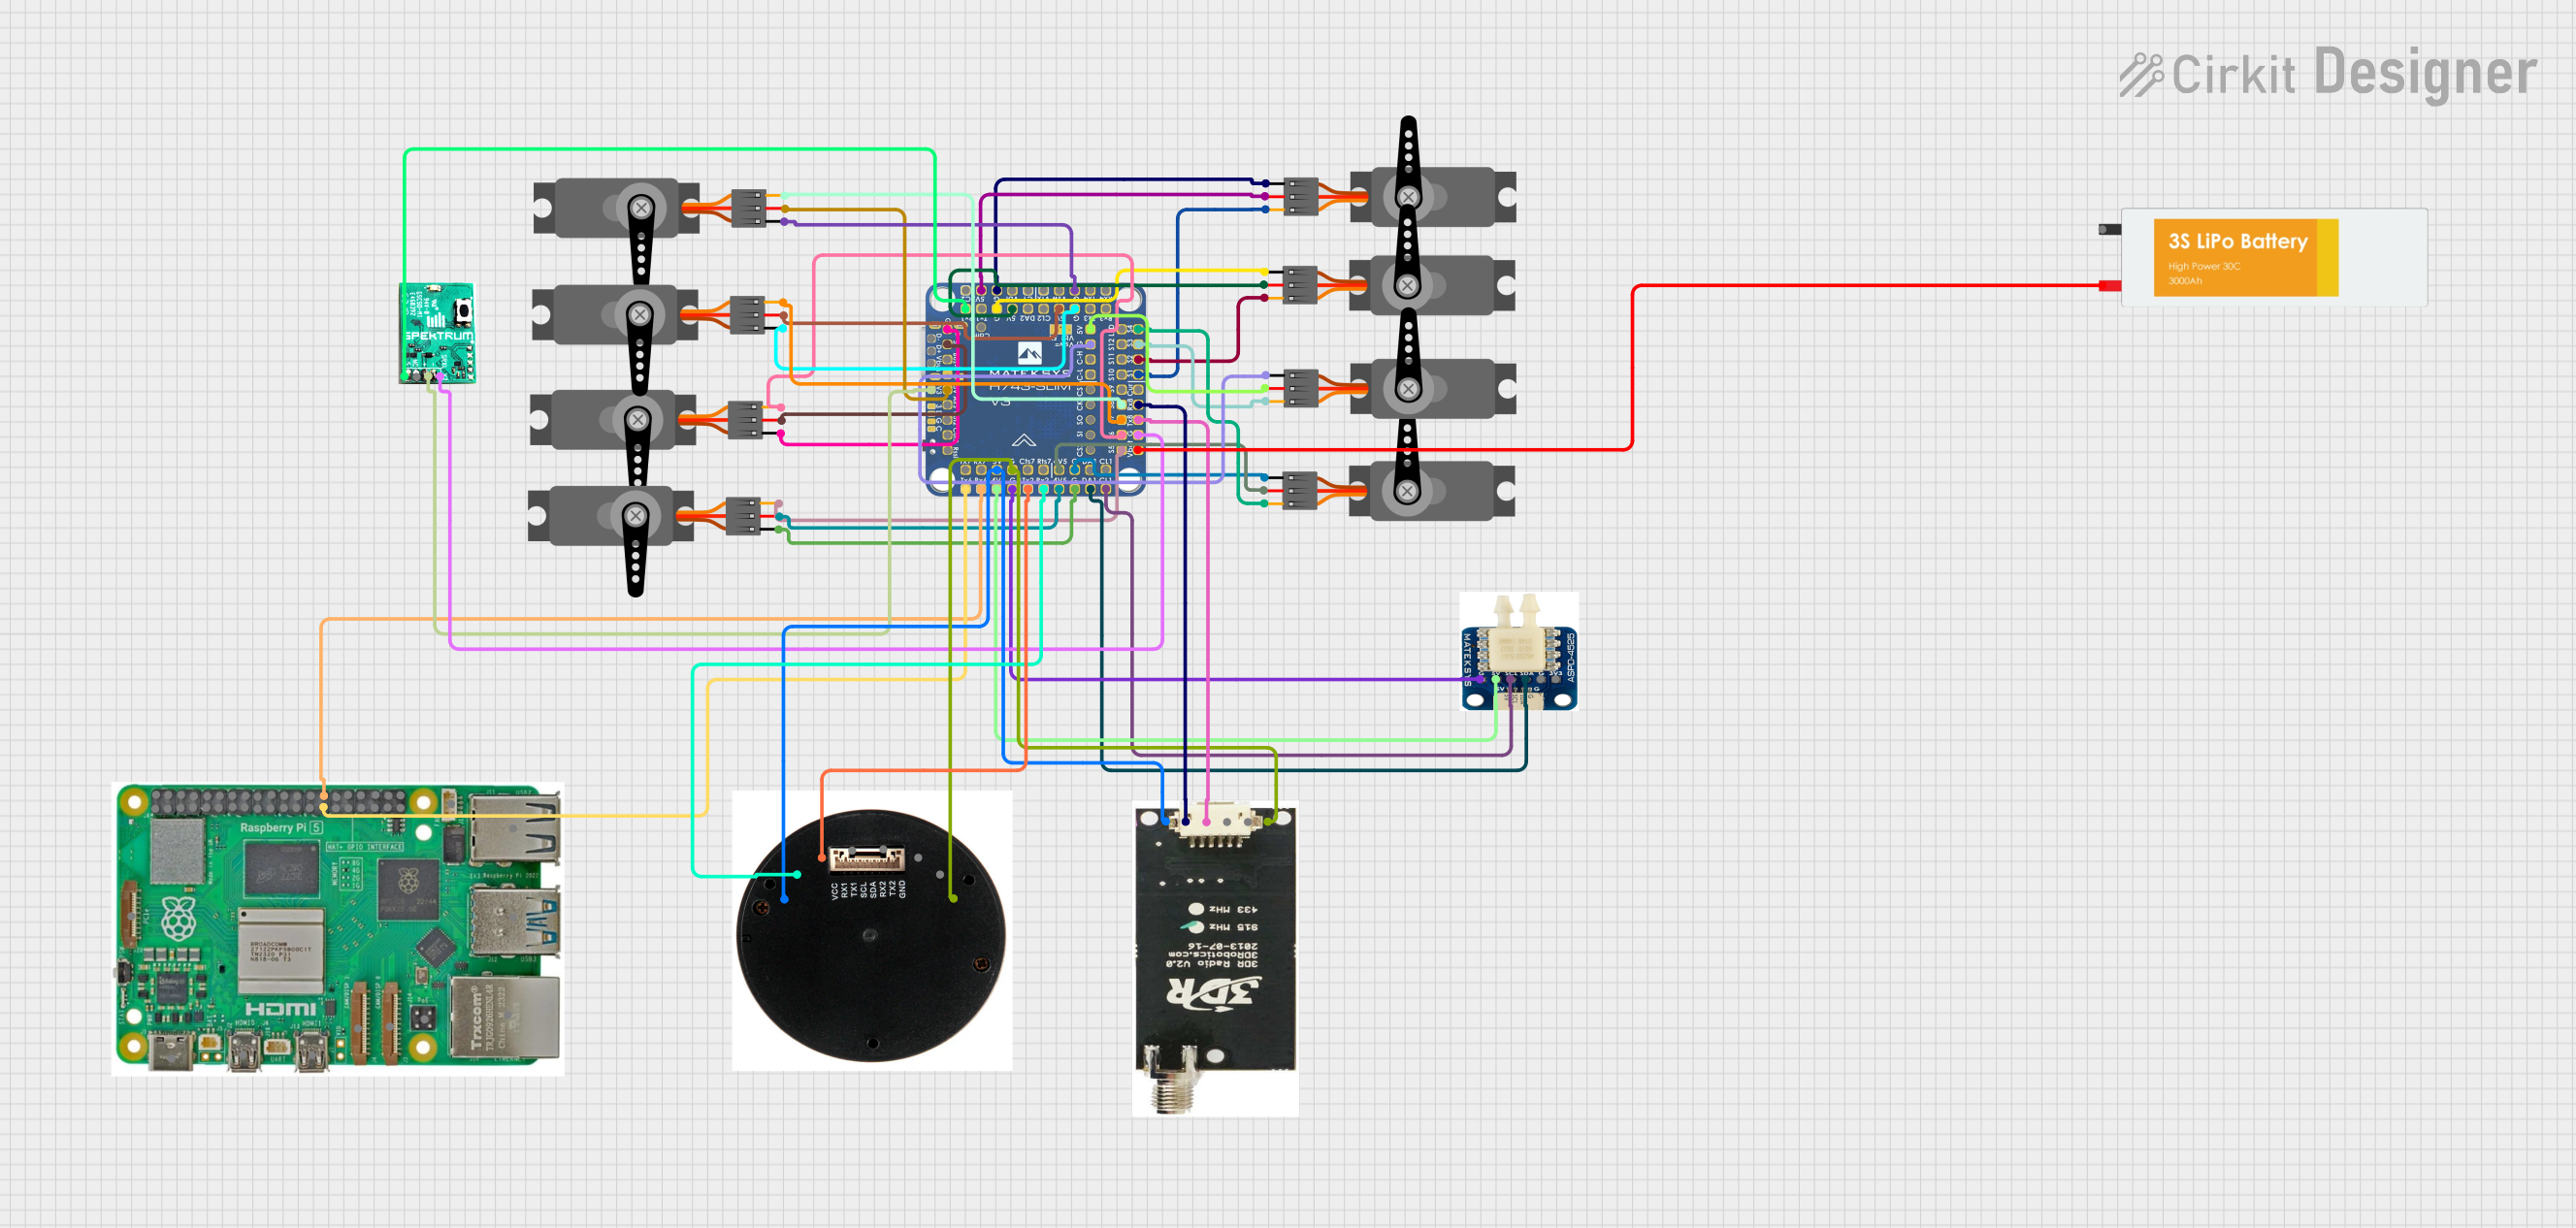
This circuit is designed for a UAV control system, featuring an H743-SLIM V3 flight controller connected to multiple servos for control surfaces, a GPS module for navigation, a telemetry radio for communication, and a digital airspeed sensor for flight data. The system is powered by a LiPo battery and includes a Raspberry Pi for additional processing and control tasks.
Autonomous drones for aerial photography, mapping, and surveying
Unmanned ground vehicles (UGVs) for industrial or research purposes
Robotics and automation systems requiring precise control
Agricultural drones for crop monitoring and spraying
Search and rescue missions with autonomous navigation
Technical Specifications
Key Technical Details
Specification
Value
Processor
STM32H743, 32-bit ARM Cortex-M7, 400 MHz
IMUs (Inertial Measurement Units)
3x IMUs (2x ICM-20948, 1x BMI088)
Barometer
MS5611
Input Voltage Range
4.1V to 5.7V
Maximum Current
2.5A
Communication Interfaces
UART, I2C, CAN, SPI, USB, PWM
GPS Support
Dual GPS support
ADS-B Receiver
Integrated for air traffic awareness
Dimensions
38.5 mm x 38.5 mm x 22 mm
Weight
16 g
Operating Temperature Range
-20°C to 85°C
Pin Configuration and Descriptions
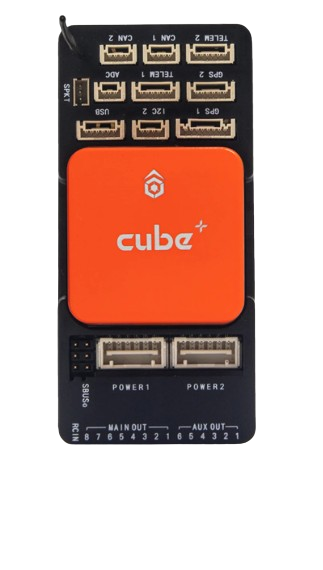
The Pixhawk Cube Orange is mounted on the ADSB-Carrier Board PX-4, which provides the following pinouts:
Power and Communication Pins
Pin Name
Description
POWER1
Primary power input (4.1V to 5.7V)
POWER2
Redundant power input
USB
USB interface for configuration and firmware
TELEM1
Telemetry port 1 (UART)
TELEM2
Telemetry port 2 (UART)
GPS1
Primary GPS input
GPS2
Secondary GPS input
CAN1
CAN bus interface 1
CAN2
CAN bus interface 2
PWM and I/O Pins
Pin Name
Description
MAIN OUT
Outputs for motor/servo control (PWM)
AUX OUT
Auxiliary outputs for additional peripherals
I2C
I2C interface for external sensors
SPI
SPI interface for high-speed peripherals
ADC
Analog-to-digital converter input
Usage Instructions
How to Use the Pixhawk Cube Orange in a Circuit
Powering the Cube: Connect a regulated power supply (4.1V to 5.7V) to the POWER1 or POWER2 input. Ensure redundancy by connecting both inputs if possible.
Connecting Peripherals: Attach sensors, GPS modules, telemetry radios, and other peripherals to the appropriate ports (e.g., TELEM1, GPS1, I2C).
Motor/Servo Outputs: Connect motors or servos to the MAIN OUT or AUX OUT pins. Configure the outputs in the flight control software.
Firmware Setup: Use the USB port to connect the Cube to a computer. Install and configure the firmware using software like QGroundControl or Mission Planner.
Calibrating Sensors: Perform sensor calibration (e.g., accelerometer, gyroscope, compass) through the flight control software.
Testing: Before deployment, test the system in a controlled environment to ensure proper functionality.
Important Considerations and Best Practices
Power Redundancy: Always use both POWER1 and POWER2 inputs to ensure uninterrupted operation in case of a power failure.
Firmware Updates: Regularly update the firmware to access new features and bug fixes.
Vibration Isolation: Mount the Cube on vibration-dampening material to improve sensor accuracy.
GPS Placement: Place GPS modules away from sources of electromagnetic interference for optimal performance.
Pre-Flight Checks: Always perform pre-flight checks, including sensor calibration and motor testing, before deploying the vehicle.
Example: Connecting to an Arduino UNO
The Pixhawk Cube Orange can communicate with an Arduino UNO via UART. Below is an example code snippet for reading telemetry data from the Cube:
#include <SoftwareSerial.h>

// Define RX and TX pins for communication with Pixhawk
SoftwareSerial pixhawkSerial(10, 11); // RX = pin 10, TX = pin 11

void setup() {
  // Initialize serial communication
  Serial.begin(9600); // For debugging via Serial Monitor
  pixhawkSerial.begin(57600); // Pixhawk telemetry baud rate

  Serial.println("Pixhawk-Arduino Communication Initialized");
}

void loop() {
  // Check if data is available from Pixhawk
  if (pixhawkSerial.available()) {
    // Read and print data from Pixhawk
    char data = pixhawkSerial.read();
    Serial.print(data);
  }
}
Note: Ensure the baud rate matches the telemetry port configuration on the Pixhawk Cube Orange.
Troubleshooting and FAQs
Common Issues and Solutions
Issue: The Cube does not power on.
Solution: Verify the power supply voltage (4.1V to 5.7V). Check connections to POWER1 and POWER2.
Issue: GPS module is not detected.
Solution: Ensure the GPS module is connected to the correct port (GPS1 or GPS2). Check for loose connections and verify the GPS configuration in the software.
Issue: Motors/servos are not responding.
Solution: Confirm that the MAIN OUT or AUX OUT pins are correctly connected. Check the motor/servo configuration in the flight control software.
Issue: Telemetry data is not being received.
Solution: Verify the telemetry radio connections and ensure the baud rate matches on both ends.
FAQs
Q: Can the Cube Orange be used with other flight control software?
A: Yes, it is compatible with PX4 and ArduPilot firmware, which can be configured using QGroundControl or Mission Planner.
Q: How do I update the firmware?
A: Connect the Cube to a computer via USB and use QGroundControl or Mission Planner to download and install the latest firmware.
Q: What is the purpose of the ADS-B receiver?
A: The integrated ADS-B receiver provides air traffic awareness, allowing the drone to detect and avoid manned aircraft.
Q: Can I use the Cube Orange for fixed-wing aircraft?
A: Yes, the Cube Orange supports fixed-wing, multirotor, and VTOL configurations.
By following this documentation, users can effectively integrate and operate the Pixhawk Cube Orange in their projects.

 Open Project in Cirkit Designer