How to Use DM542: Examples, Pinouts, and Specs
 Design with DM542 in Cirkit Designer
Introduction
The DM542 is a microstepping driver designed for driving bipolar stepper motors with high precision and smooth motion. Manufactured by Driver, this component is widely used in applications requiring precise motor control, such as CNC machines, 3D printers, robotics, and automated systems. Its compact design, support for various microstepping resolutions, and built-in protection features make it a reliable choice for both industrial and hobbyist projects.
Explore Projects Built with DM542
 Open Project in Cirkit Designer
 Open Project in Cirkit Designer
 Open Project in Cirkit Designer
 Open Project in Cirkit Designer
Explore Projects Built with DM542
Open Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerOpen Project in Cirkit DesignerCommon Applications
- CNC machines for precise cutting and engraving
- 3D printers for accurate layer deposition
- Robotics for smooth and controlled motion
- Conveyor systems in industrial automation
- Camera sliders and other motion control systems
Technical Specifications
The DM542 offers robust performance and flexibility for stepper motor control. Below are its key technical specifications:
| Parameter | Value |
|---|---|
| Supply Voltage Range | 18V to 50V DC |
| Output Current Range | 1.0A to 4.2A (adjustable) |
| Microstepping Resolutions | Full step, 1/2, 1/4, 1/8, 1/16, 1/32 |
| Input Signal Voltage | 5V (compatible with TTL logic) |
| Pulse Frequency Range | 0 to 200 kHz |
| Protection Features | Overcurrent, overvoltage, thermal shutdown |
| Operating Temperature Range | -10°C to +45°C |
| Dimensions | 118mm x 75.5mm x 34mm |
Pin Configuration and Descriptions
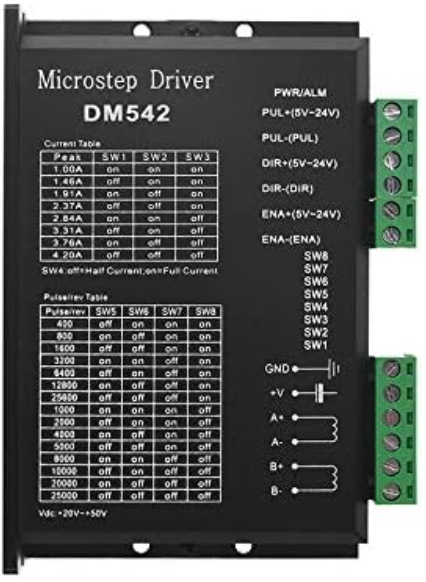
The DM542 has several input and output terminals for connecting to the power supply, stepper motor, and control signals. Below is the pin configuration:
Power and Motor Connections
| Pin Name | Description |
|---|---|
| V+ | Positive terminal for power supply |
| V- | Negative terminal for power supply |
| A+ | Positive terminal for motor coil A |
| A- | Negative terminal for motor coil A |
| B+ | Positive terminal for motor coil B |
| B- | Negative terminal for motor coil B |
Control Signal Connections
| Pin Name | Description |
|---|---|
| PUL+ | Positive terminal for pulse signal (step input) |
| PUL- | Negative terminal for pulse signal |
| DIR+ | Positive terminal for direction signal |
| DIR- | Negative terminal for direction signal |
| ENA+ | Positive terminal for enable signal (optional) |
| ENA- | Negative terminal for enable signal (optional) |
Usage Instructions
Connecting the DM542
- Power Supply: Connect a DC power supply (18V to 50V) to the V+ and V- terminals. Ensure the power supply can provide sufficient current for the stepper motor.
- Stepper Motor: Connect the stepper motor coils to the A+, A-, B+, and B- terminals. Verify the wiring matches the motor's datasheet.
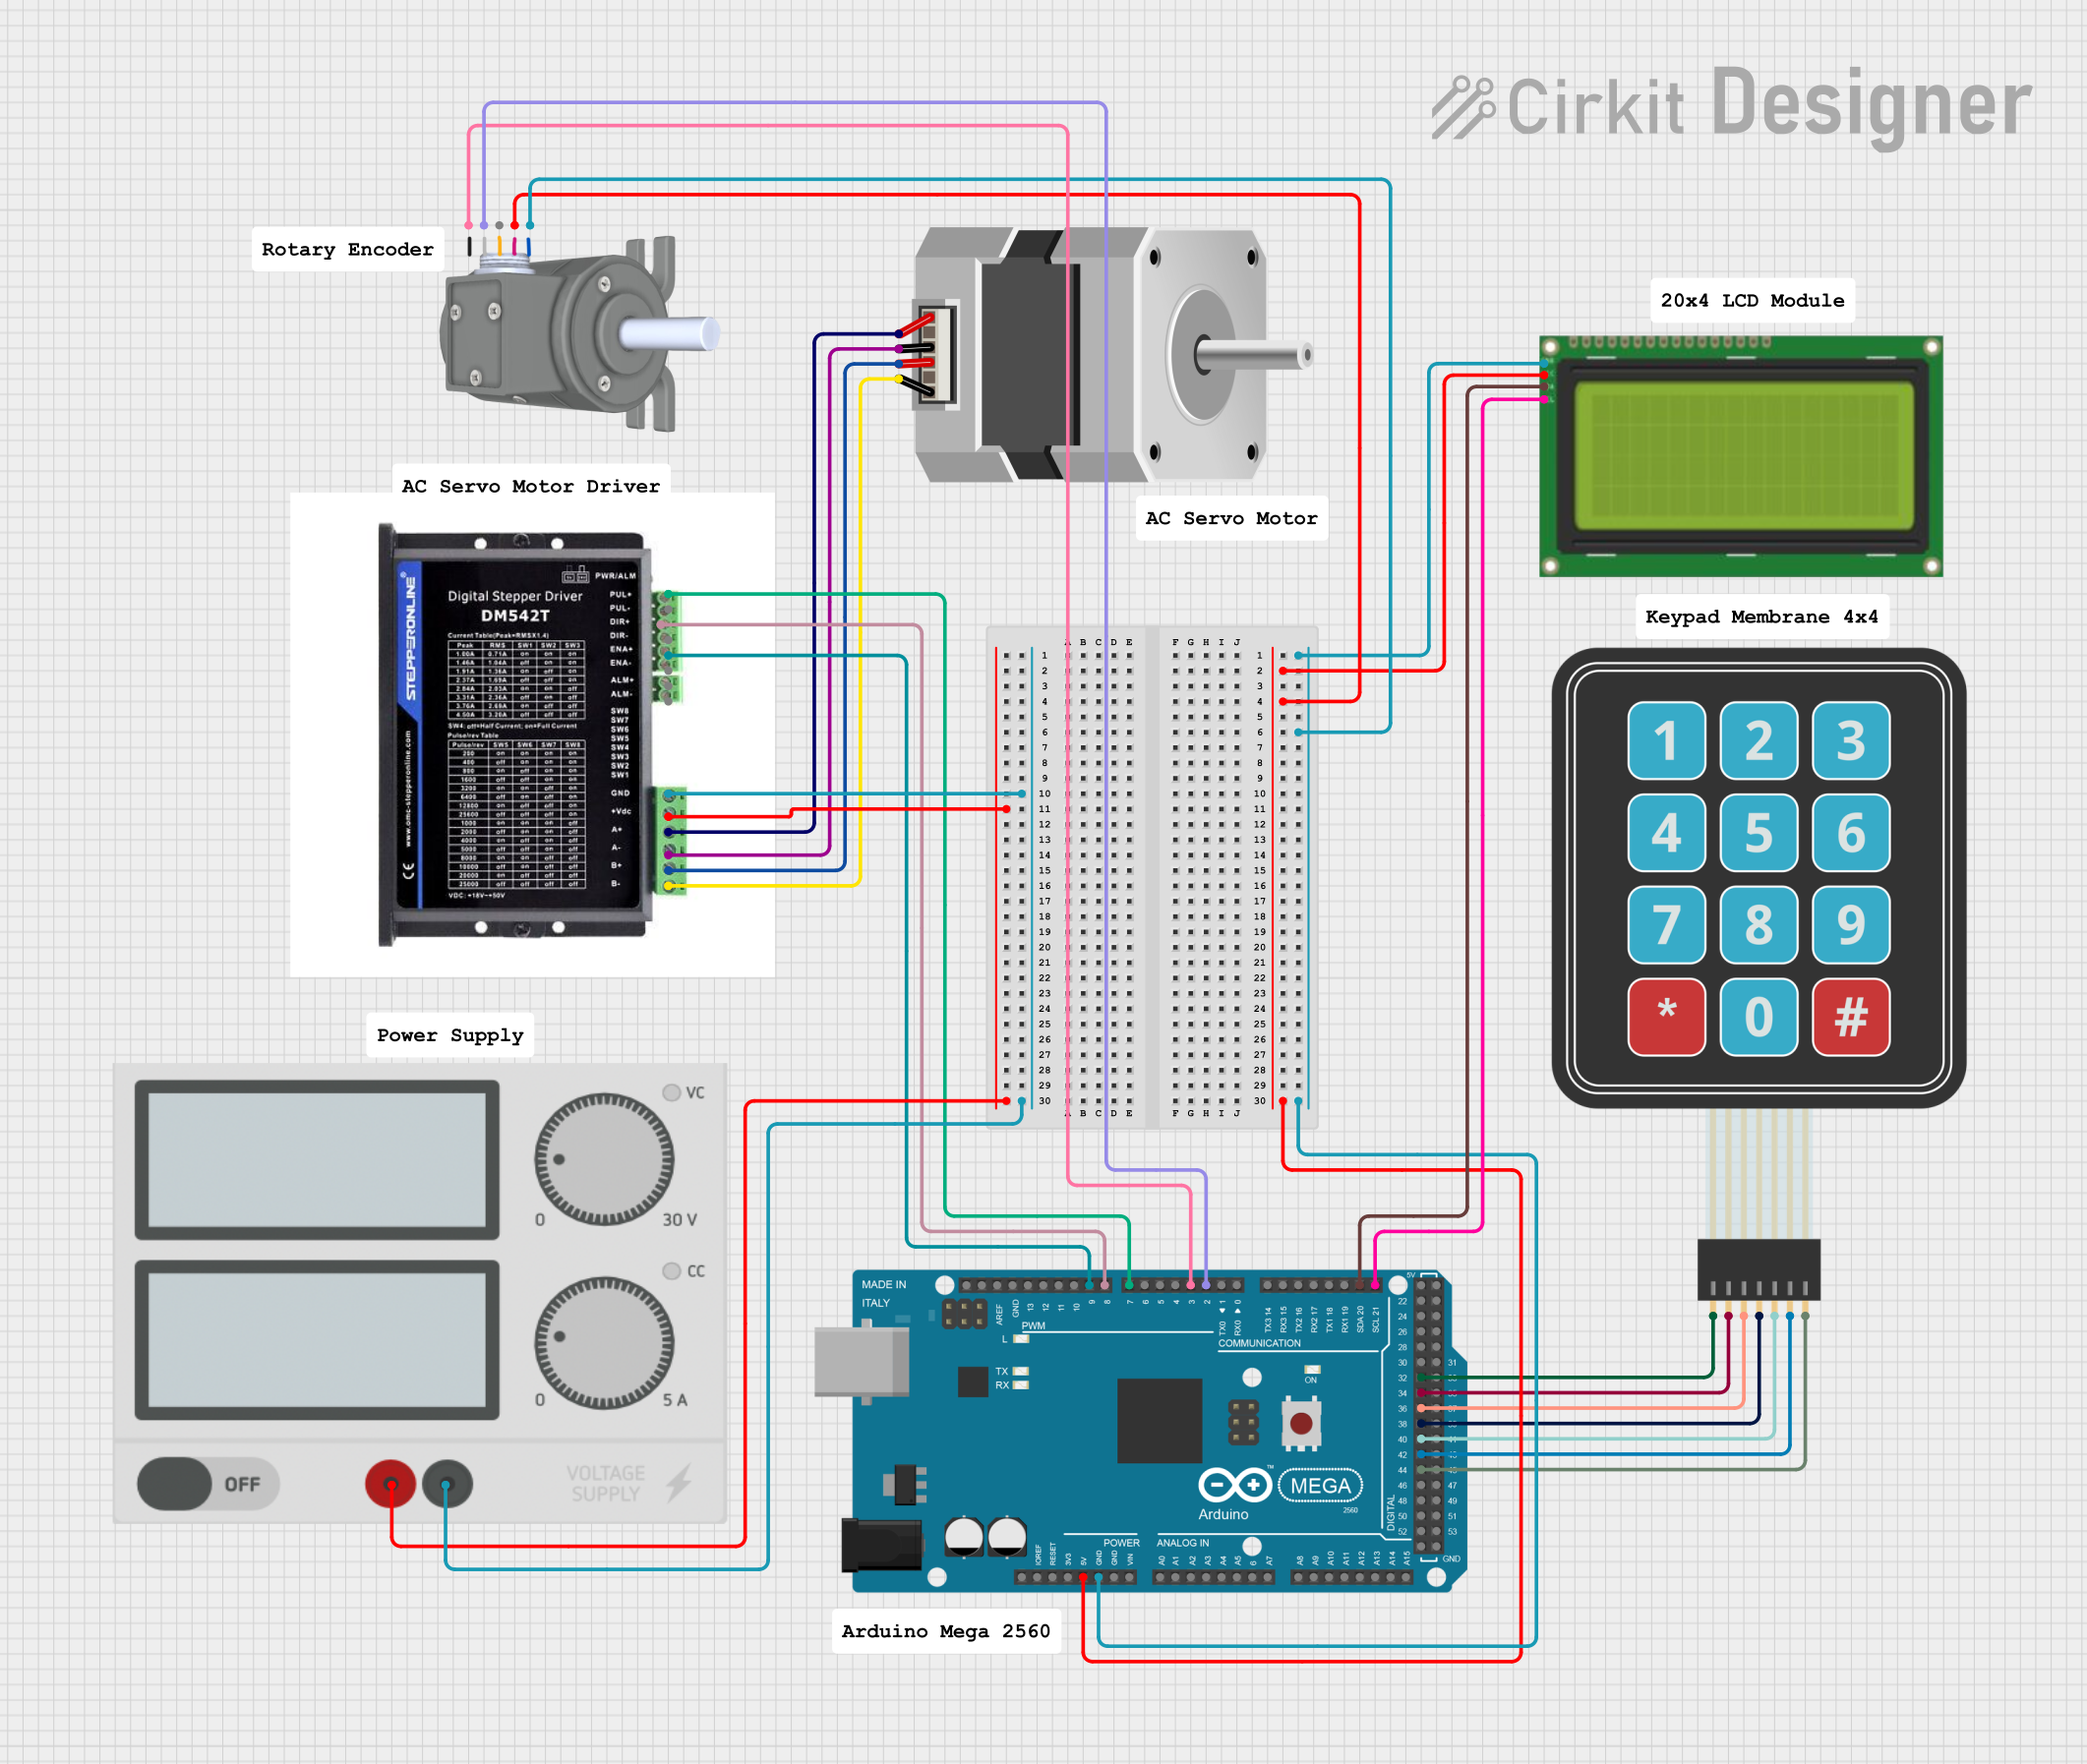
- Control Signals: Connect the PUL+, PUL-, DIR+, DIR-, and optionally ENA+ and ENA- terminals to a microcontroller or control board (e.g., Arduino UNO).
Setting Microstepping and Current
- Use the DIP switches on the DM542 to configure the microstepping resolution and output current. Refer to the DM542 datasheet for the DIP switch settings.
Arduino UNO Example Code
Below is an example of how to control the DM542 using an Arduino UNO:
// Define pins for control signals
const int stepPin = 3;  // Pin connected to PUL+ on DM542
const int dirPin = 4;   // Pin connected to DIR+ on DM542

void setup() {
  pinMode(stepPin, OUTPUT); // Set step pin as output
  pinMode(dirPin, OUTPUT);  // Set direction pin as output

  digitalWrite(dirPin, HIGH); // Set initial direction (HIGH or LOW)
}

void loop() {
  // Generate step pulses
  digitalWrite(stepPin, HIGH); // Set step pin HIGH
  delayMicroseconds(500);      // Wait for 500 microseconds
  digitalWrite(stepPin, LOW);  // Set step pin LOW
  delayMicroseconds(500);      // Wait for 500 microseconds
}
Important Considerations
- Ensure the power supply voltage is within the specified range (18V to 50V).
- Avoid connecting or disconnecting the motor while the driver is powered to prevent damage.
- Use shielded cables for control signals to minimize noise interference.
- Properly configure the DIP switches for your motor's current and microstepping requirements.
Troubleshooting and FAQs
Common Issues and Solutions
Motor Not Moving
- Verify the power supply is connected and providing the correct voltage.
- Check the wiring between the DM542 and the stepper motor.
- Ensure the control signals (PUL, DIR) are being sent correctly.
Motor Vibrates but Does Not Rotate
- Check the wiring of the motor coils. Incorrect wiring can cause improper operation.
- Verify the microstepping settings on the DIP switches.
Driver Overheating
- Ensure the driver is not exceeding its current rating.
- Provide adequate ventilation or a heatsink if necessary.
No Response to Control Signals
- Confirm the control signal voltage levels are compatible with the DM542 (5V TTL).
- Check for loose or disconnected wires.
FAQs
Q: Can the DM542 drive unipolar stepper motors?
A: No, the DM542 is designed for bipolar stepper motors only.
Q: What is the maximum step pulse frequency supported?
A: The DM542 supports a maximum pulse frequency of 200 kHz.
Q: Is the enable signal (ENA) mandatory?
A: No, the ENA signal is optional. If not used, the driver will remain enabled by default.
Q: Can I use the DM542 with a 12V power supply?
A: No, the minimum supply voltage for the DM542 is 18V. Using a lower voltage may result in improper operation.
By following this documentation, users can effectively integrate the DM542 into their projects for precise and reliable stepper motor control.